
Example Graphsdijkstraexample Mrpt 21513 Documentation

Example: graphs_dijkstra_example — MRPT 2.15.8 documentation
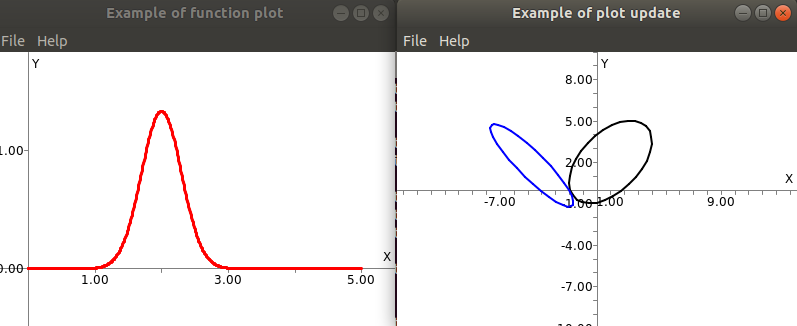
Example: gui_display_plots — MRPT 2.15.13 documentation

C++ coding style for MRPT — MRPT 2.15.13 documentation

Example: math_polygon_split — MRPT 2.15.13 documentation

Example: gui_depth_camera_distortion — MRPT 2.15.13 documentation
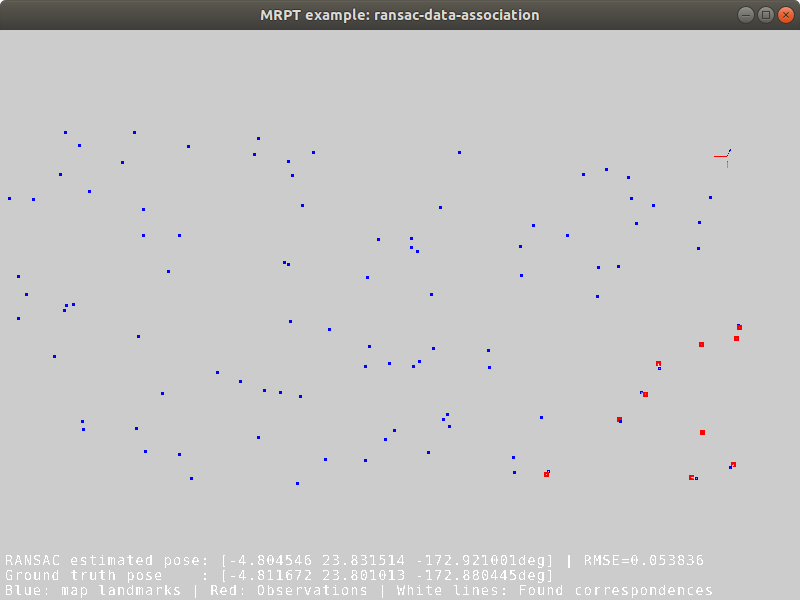
RANSAC C++ examples — MRPT 2.15.13 documentation

C++ coding style for MRPT — MRPT 2.15.13 documentation
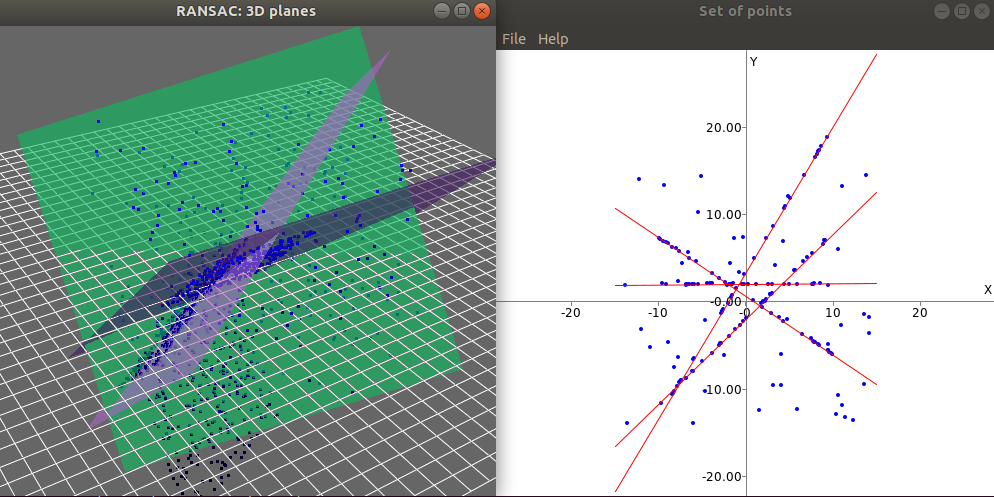
RANSAC C++ examples — MRPT 2.15.13 documentation

Application: RawLogViewer — MRPT 2.15.13 documentation

Example: math_polygon_intersection — MRPT 2.15.13 documentation
Advertisement Space (300x250)
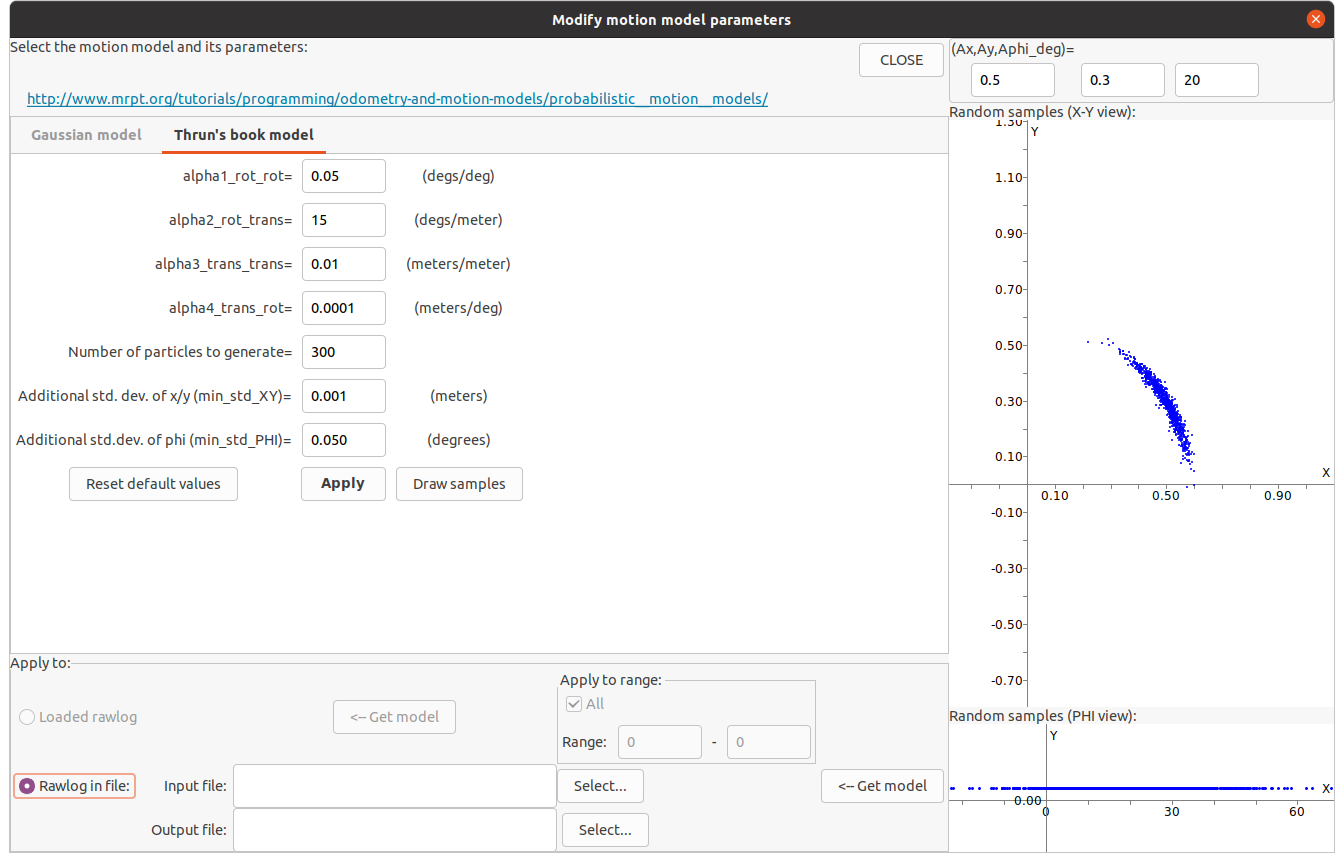
Probabilistic motion models — MRPT 2.15.13 documentation

Application: RawLogViewer — MRPT 3.5.0 documentation

Tutorial: 3D scenes — MRPT 2.15.8 documentation

MRPT design of map classes — MRPT 2.15.18 documentation

Example: opengl_skybox_example — MRPT 2.15.13 documentation

Example: graphslam_example — MRPT 2.15.13 documentation

Example: gui_display3D_example — MRPT 2.15.13 documentation

Example: nav_rrt_planning_example — MRPT 2.15.13 documentation

Application: RawLogViewer — MRPT 3.5.0 documentation
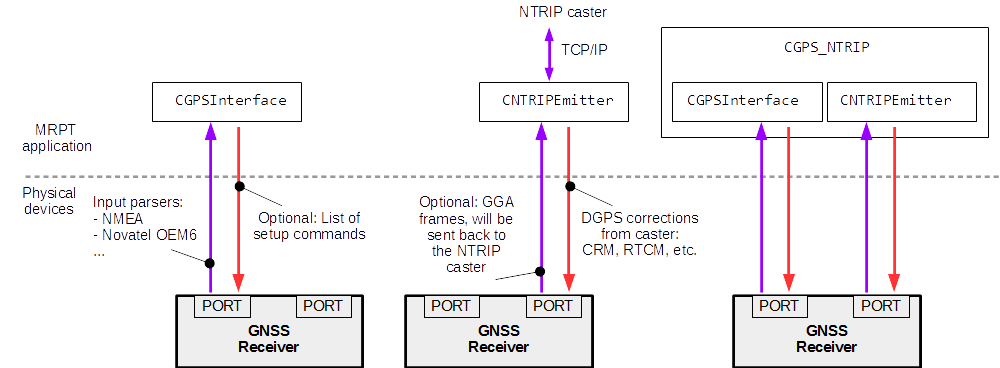
class mrpt::hwdrivers::CGPS_NTRIP — MRPT 2.14.12 documentation
Advertisement Space (336x280)
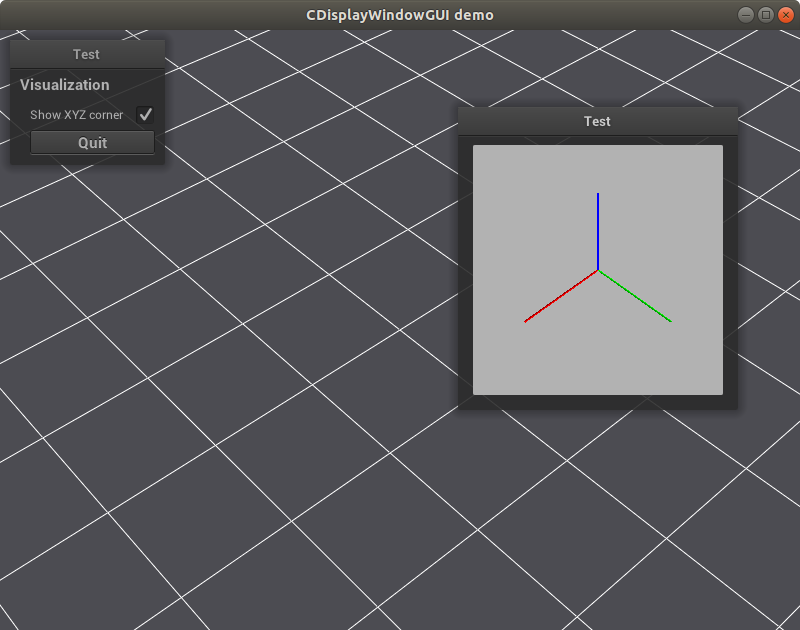
Example: gui_nanogui_demo — MRPT 2.15.13 documentation
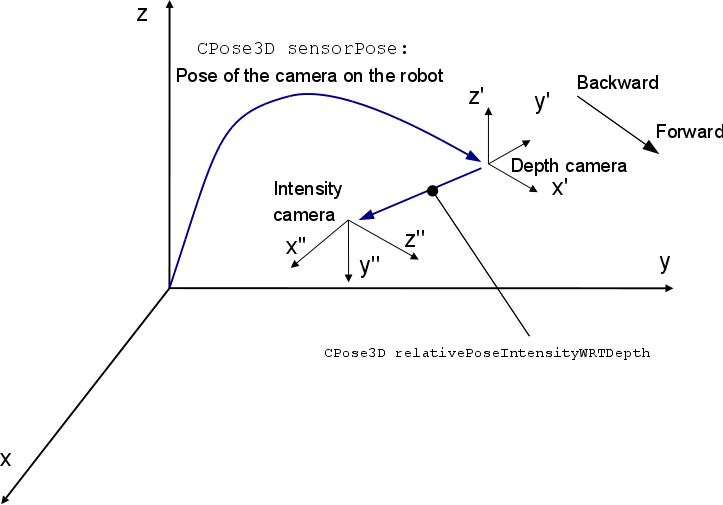
class mrpt::obs::CObservation3DRangeScan — MRPT 2.15.13 documentation
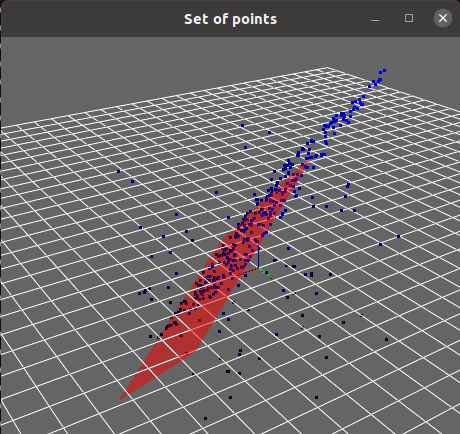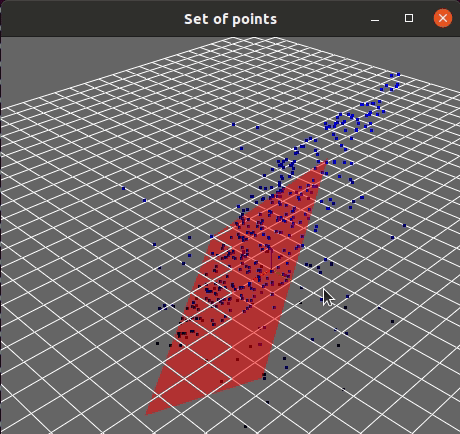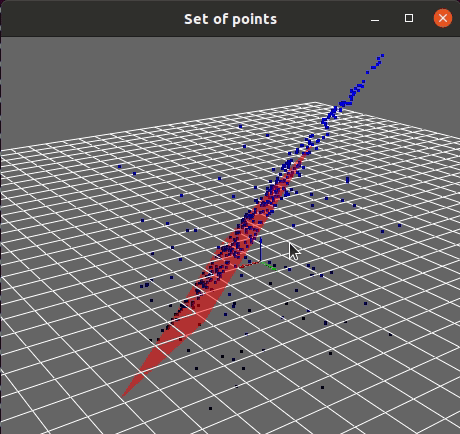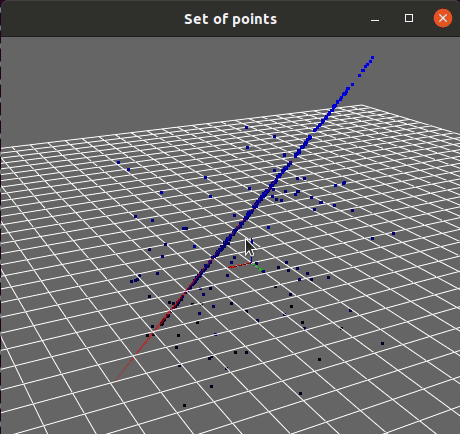
RANSAC C++ examples — MRPT 2.15.13 documentation

class mrpt::opengl::COctoMapVoxels — MRPT 2.15.1 documentation

class mrpt::poses::CPoint3D — MRPT 2.15.13 documentation
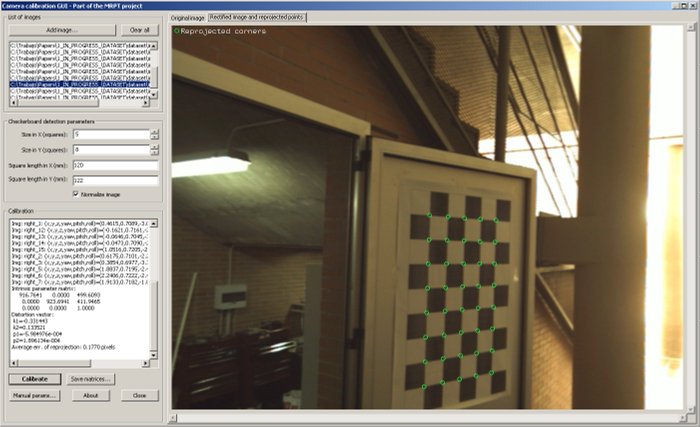
Application: camera-calib — MRPT 2.15.13 documentation
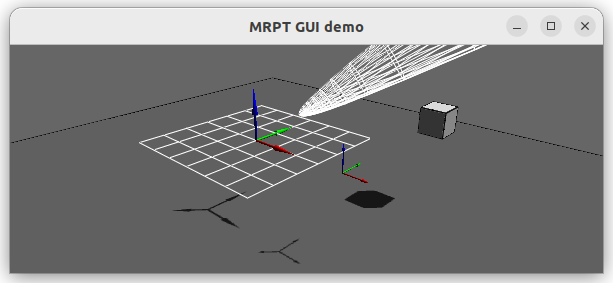
Python examples — MRPT 2.15.13 documentation

Motion planning — MRPT 2.15.19 documentation
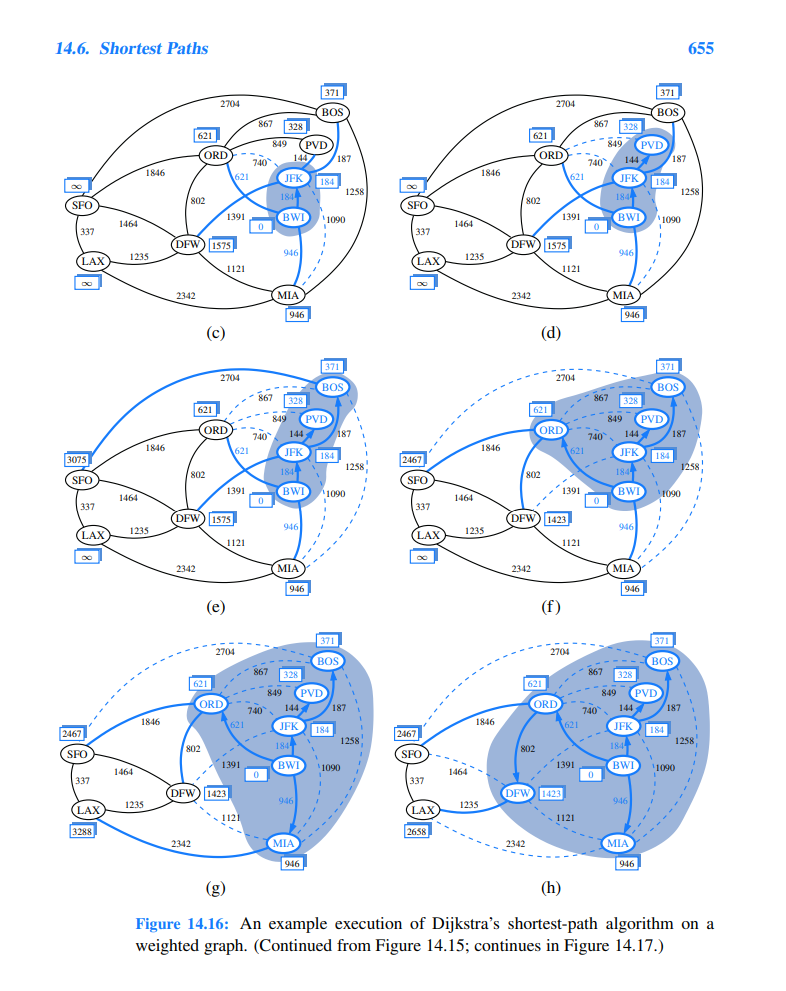
Solved Figure 14.15: An example execution of Dijkstra's | Chegg.com

Path planning algorithm: TP-RRT (TP-Space RRT) – MRPT
Advertisement Space (336x280)

graph3d-example-closer – MRPT

Graph-SLAM maps – MRPT

3 Grados de Libertad MRPT | PDF

Example: graph_slam_demo – MRPT
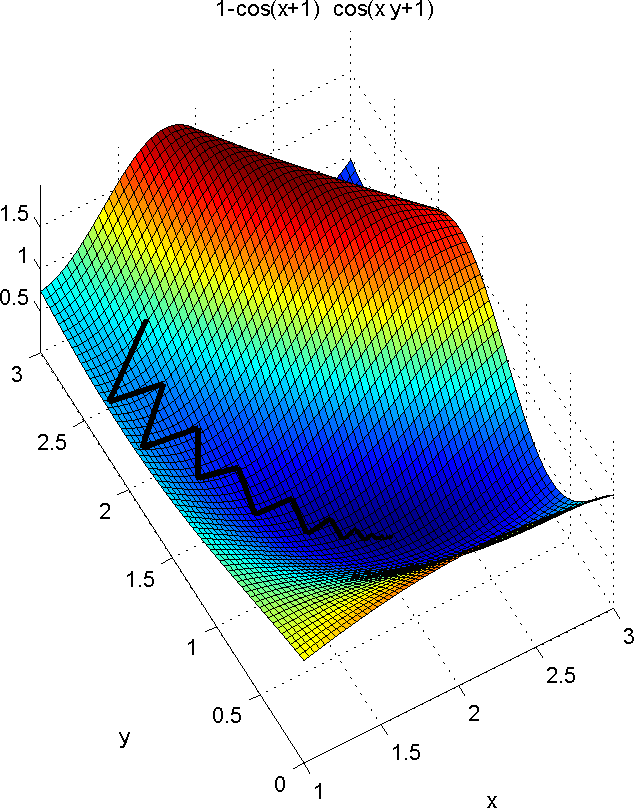
Levenberg-Marquardt algorithm with numeric Jacobians — MRPT 2.15.13 ...
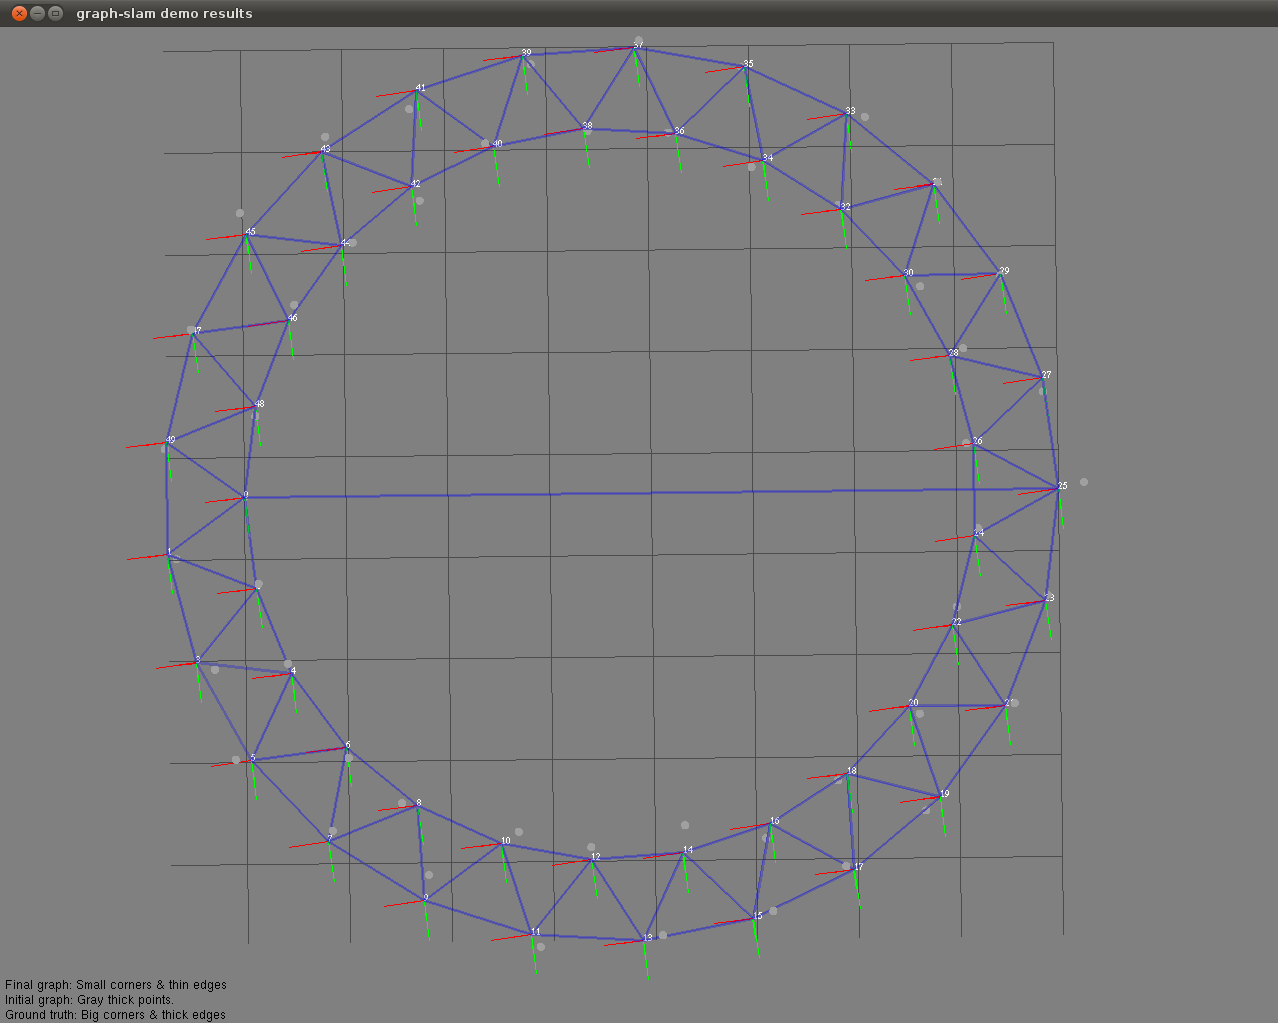
Example: graph_slam_demo – MRPT