
Planning Module Robortscostmapcostmap2d Class Reference
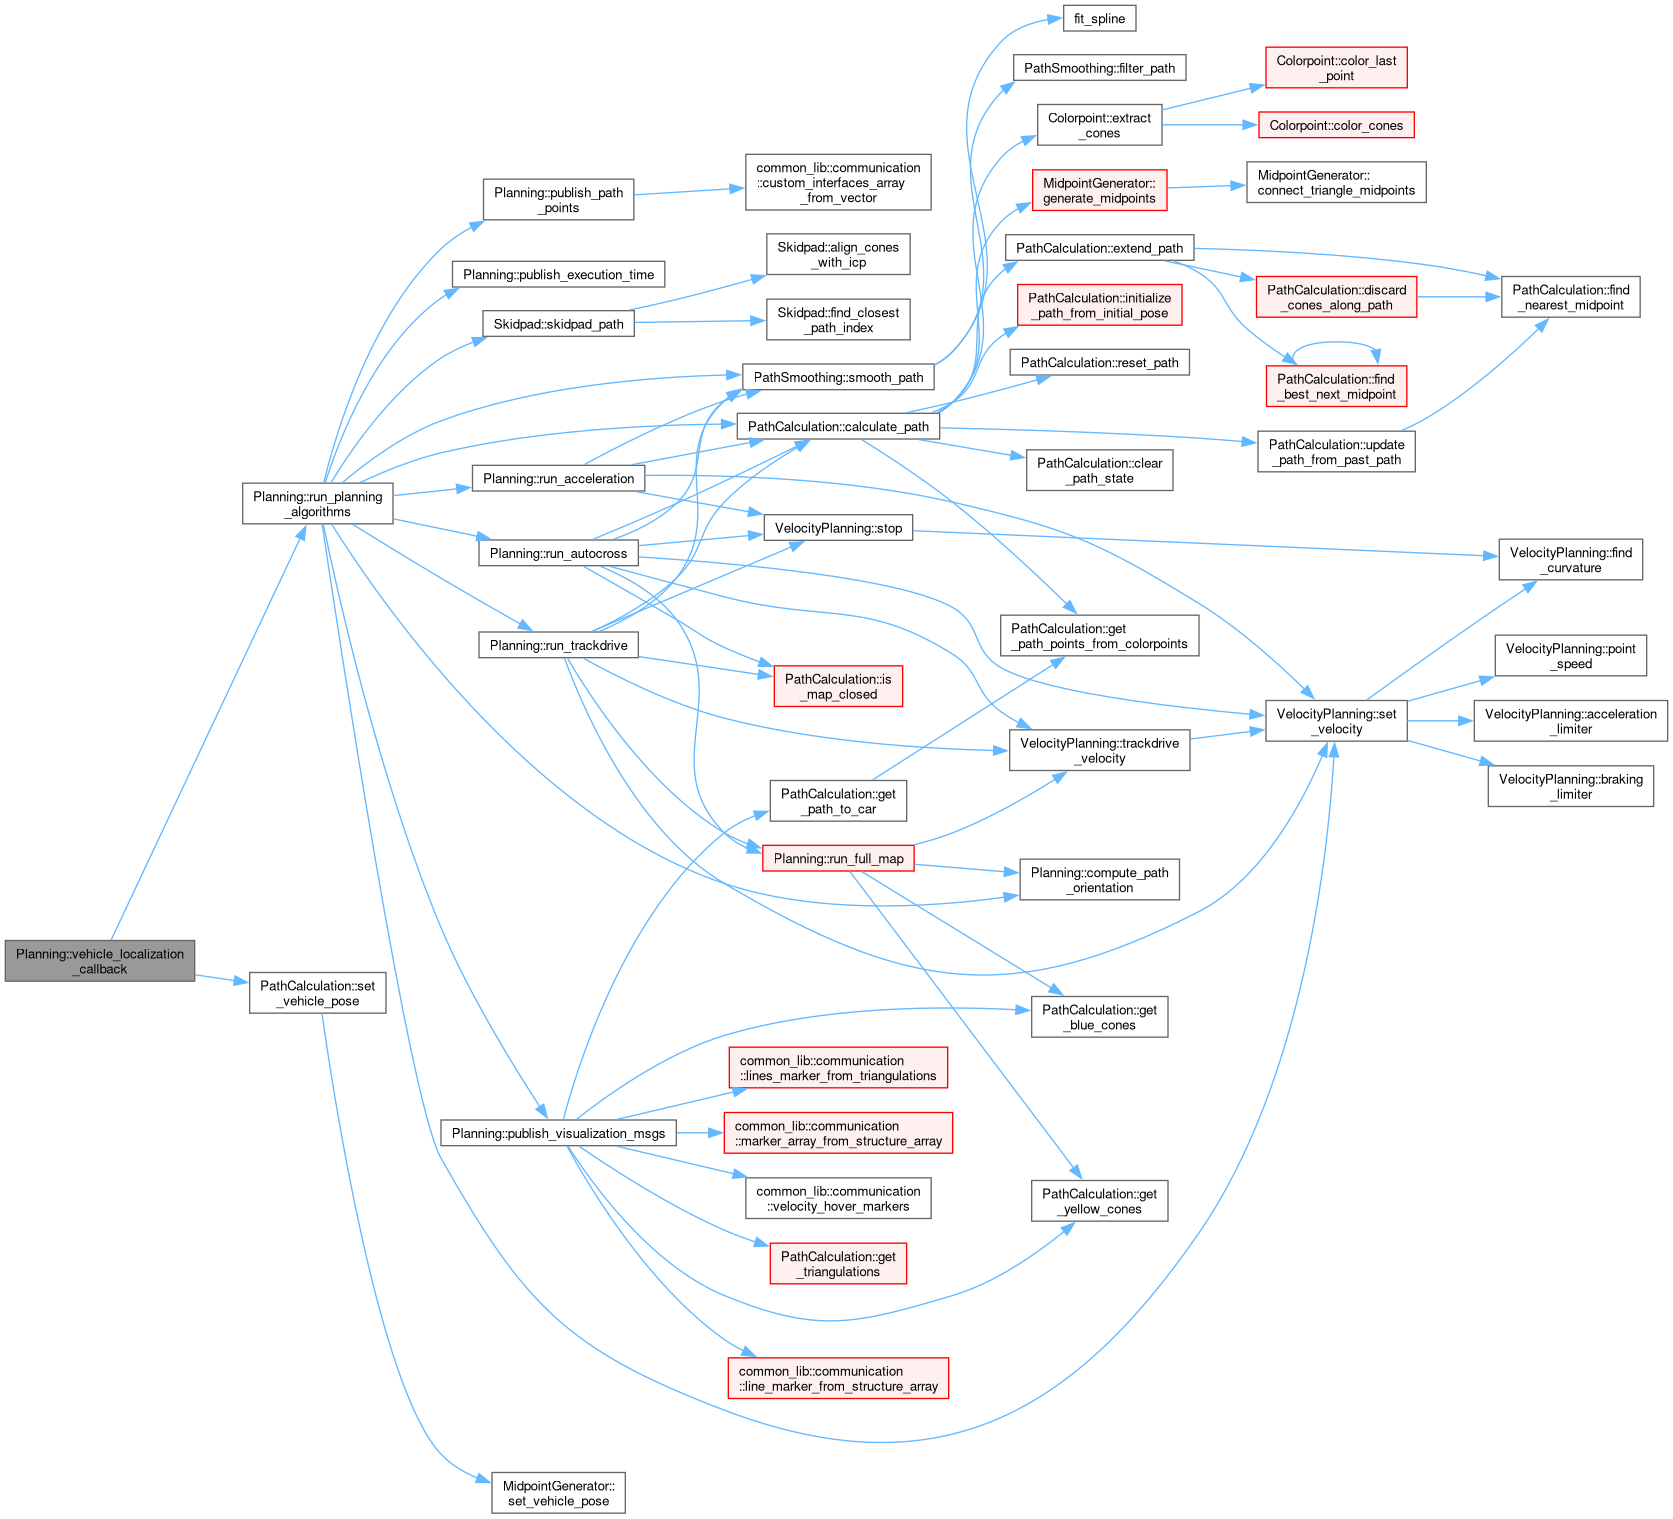
Formula Student Autonomous Systems: Planning Class Reference

costmap_2d: costmap_2d::Costmap2D Class Reference

costmap_2d: costmap_2d::ObstacleLayer Class Reference
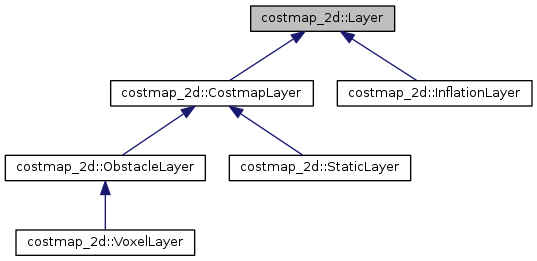
costmap_2d: costmap_2d::Layer Class Reference

costmap_2d: costmap_2d::CostmapTester Class Reference

KrisLibrary: CostSpaceRRTPlanner Class Reference

How to Use Odoo 16 Planning Module

Planning Module: roborts_local_planner::BaseRobotFootprintModel Class ...

KrisLibrary: RigidRobot2DCSpace Class Reference

KrisLibrary: RRTPlanner Class Reference
Advertisement Space (300x250)

How to Use Odoo 16 Planning Module

Figure 1 from Dynamic Path Planning of a mobile robot adopting a ...

mbf_costmap_core: costmap_planner.h File Reference

Multi-Robot Trajectory Planning via Constrained Bayesian Optimization ...
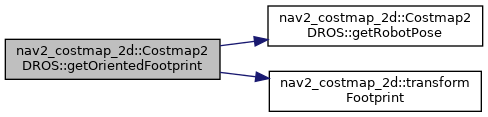
Nav2 Navigation Stack - humble: nav2_costmap_2d::Costmap2DROS Class ...

costmap_2d: costmap_2d.cpp File Reference

mbf_costmap_nav: costmap_planner_execution.h File Reference

User interface for creating/updating the map, motion planning and ...
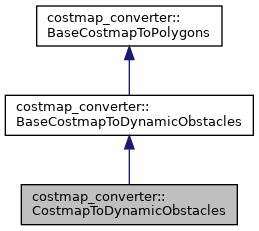
costmap_converter: costmap_converter::CostmapToDynamicObstacles Class ...
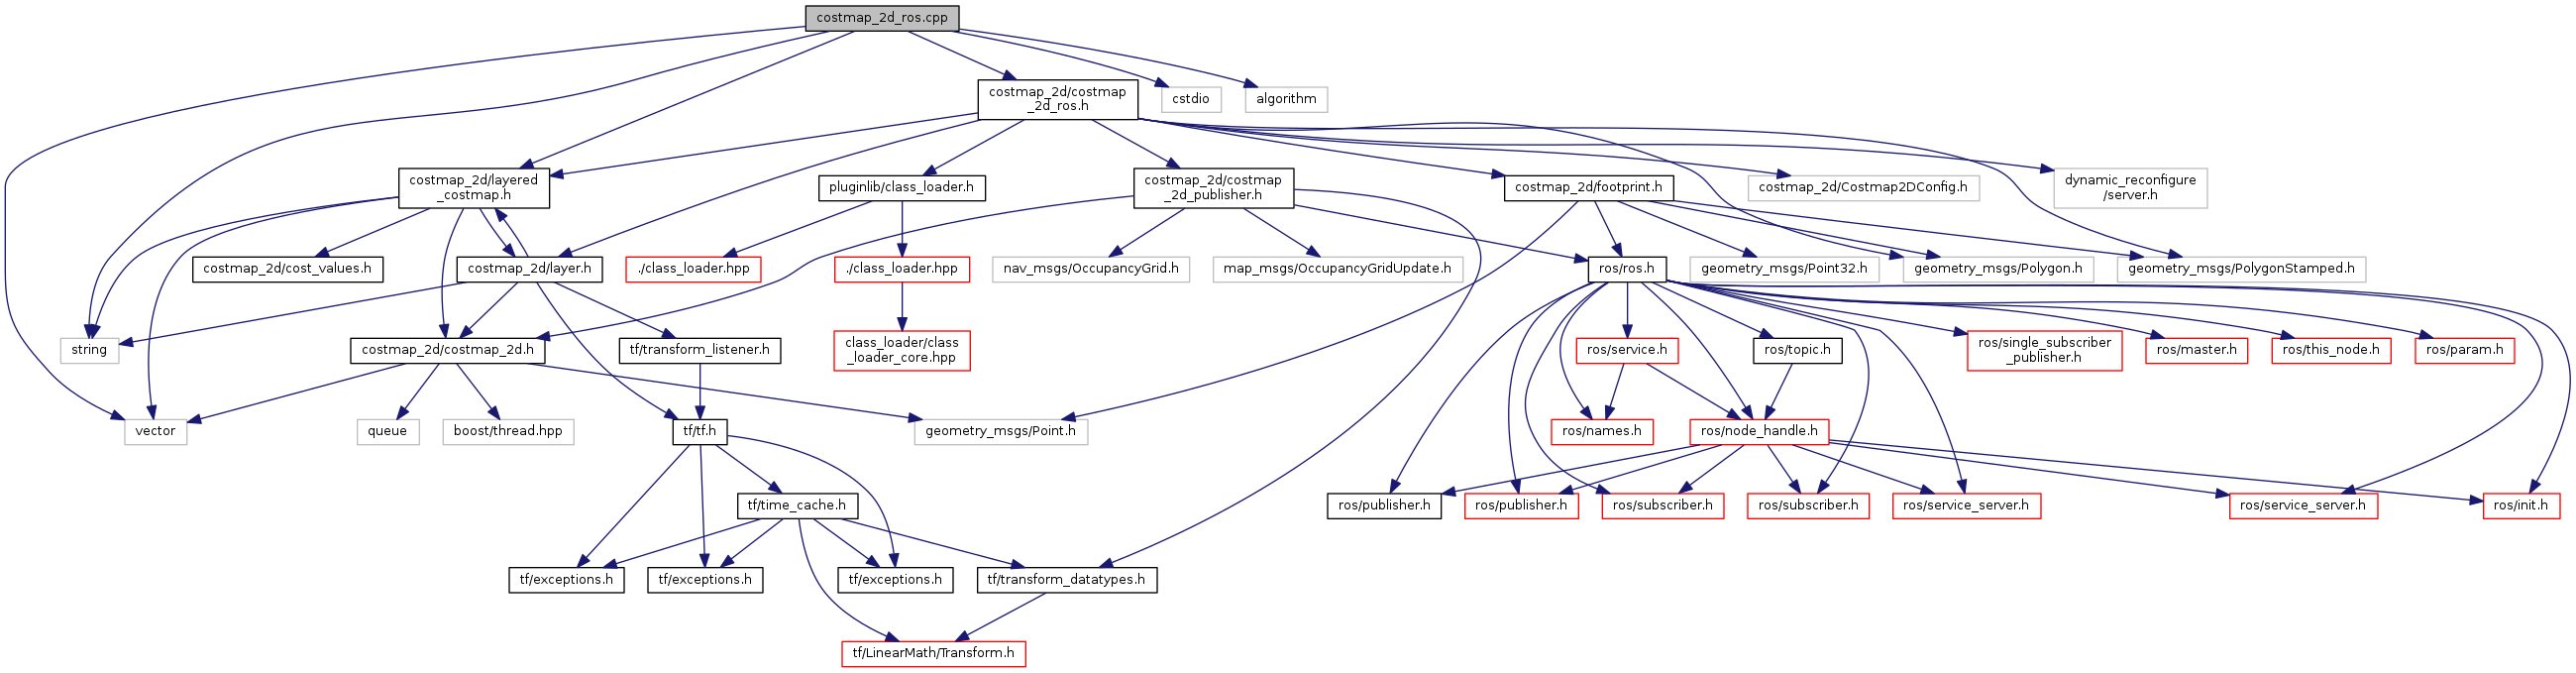
costmap_2d: costmap_2d_ros.cpp File Reference
Advertisement Space (336x280)

costmap_2d: costmap_2d_ros.h File Reference

PPT - Single Robot Motion Planning PowerPoint Presentation, free ...

Efficient View Path Planning for Autonomous Implicit Reconstruction

Simplified view of Planning internals and connected modules | Download ...

The general structure of the planning modules | Download Scientific Diagram
System framework (our navigation system includes mapping and planning ...

The general structure of the planning modules | Download Scientific Diagram

costmap_2d: layered_costmap.h File Reference

Path planning — Robotics Toolbox for Python documentation
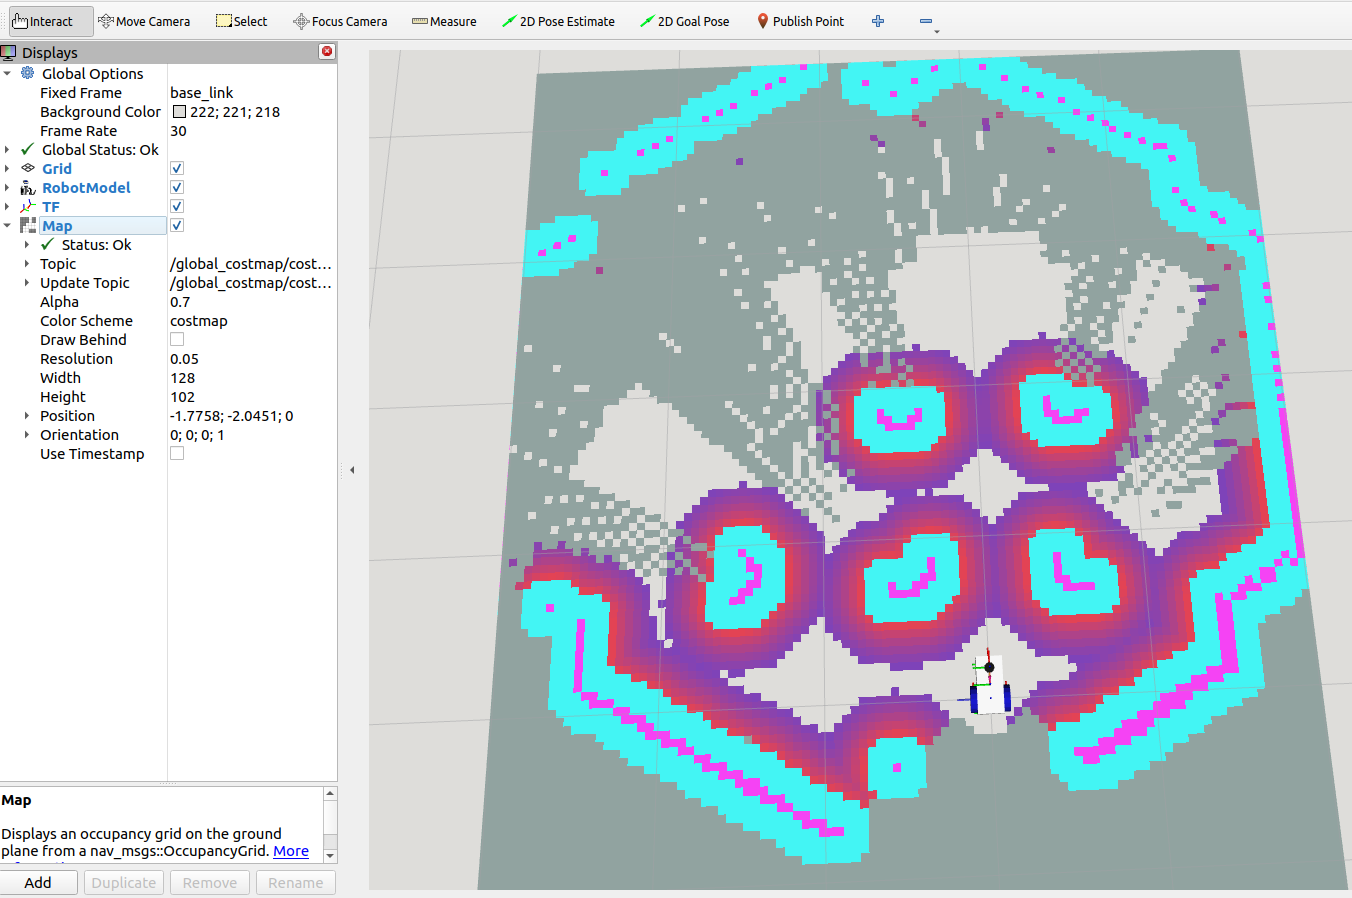
Adding Path Planning from Nav2 — Software for Robotics Tutorials ...
Advertisement Space (336x280)

costmap_2d: costmap_math.cpp File Reference

costmap_2d: costmap_2d_ros.h File Reference
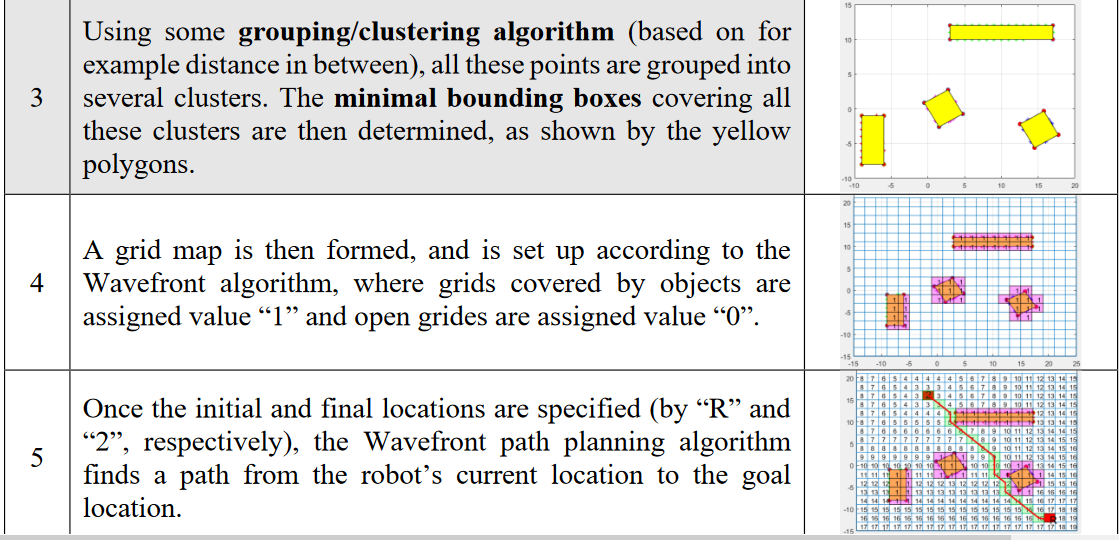
Map Building &Path Planning of a Mobile Robot in a | Chegg.com

costmap_2d: costmap_2d.h File Reference

PPT - Robotics Chapter 5 – Path and Trajectory Planning PowerPoint ...

ros - Global costmap is only partial, and the path planning goes ...