
Ros 2 10115 Cmdvel
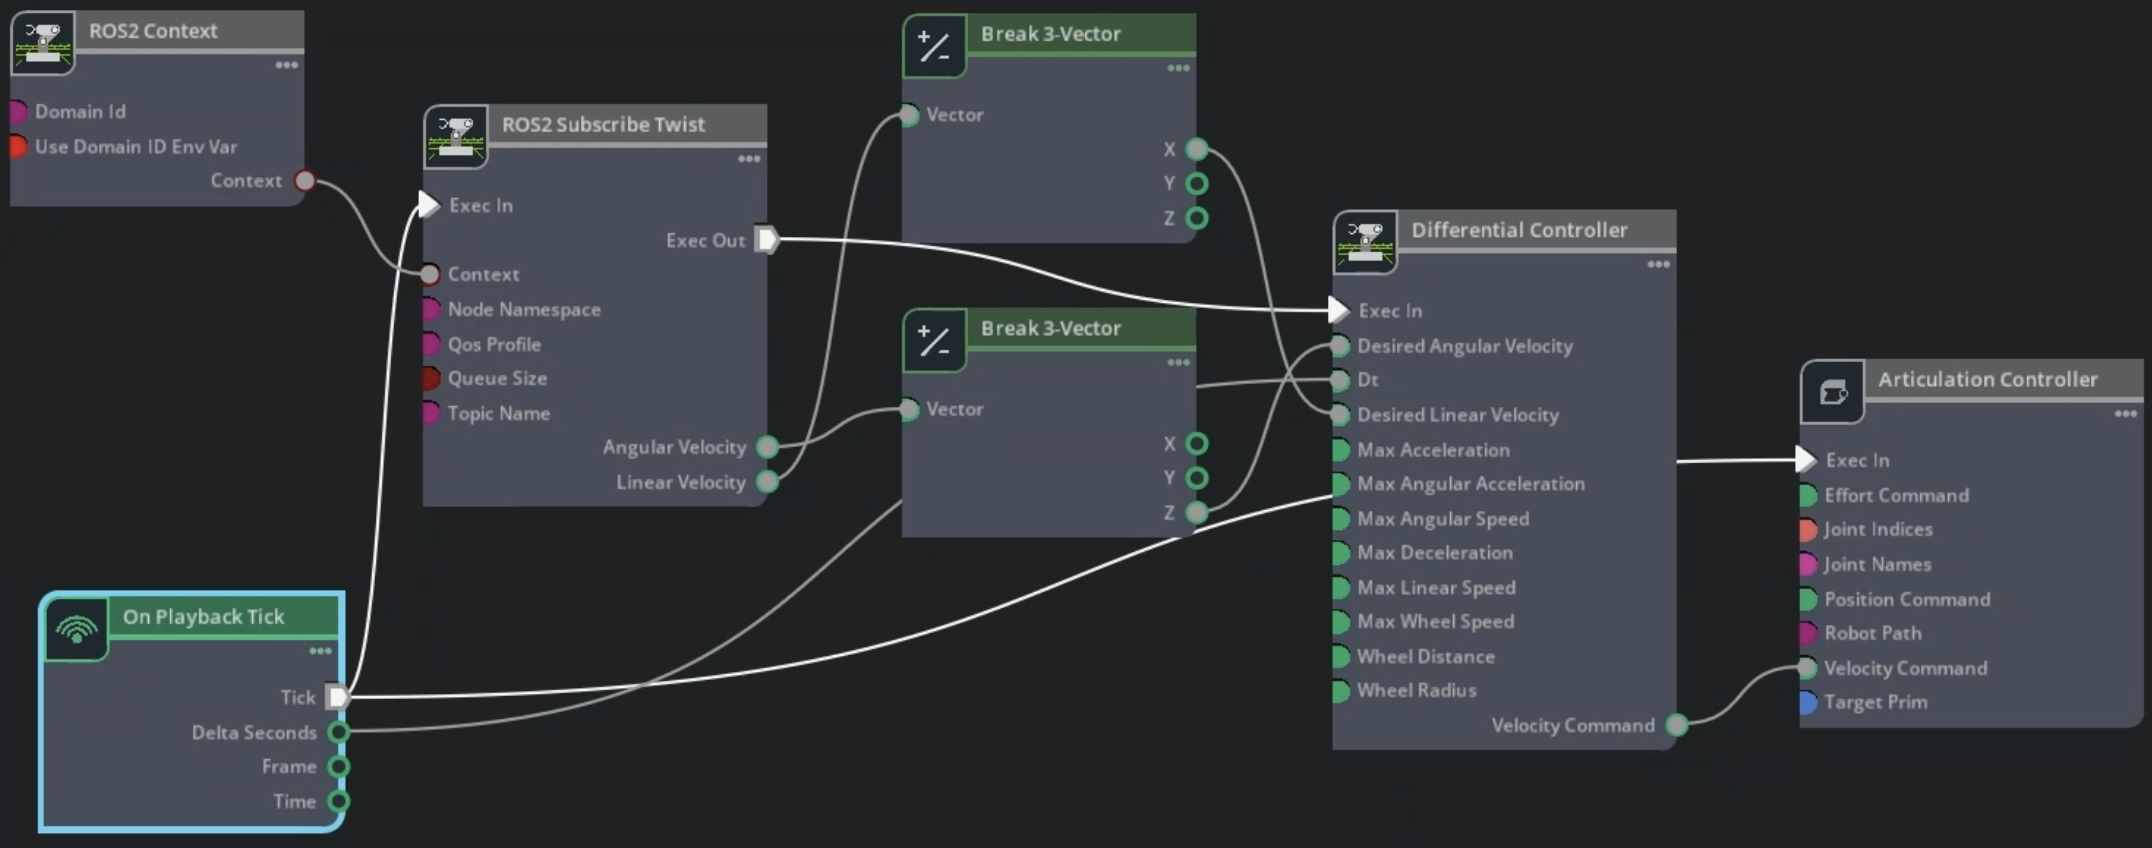
ROS 2 Putting It All Together — Isaac Sim Documentation
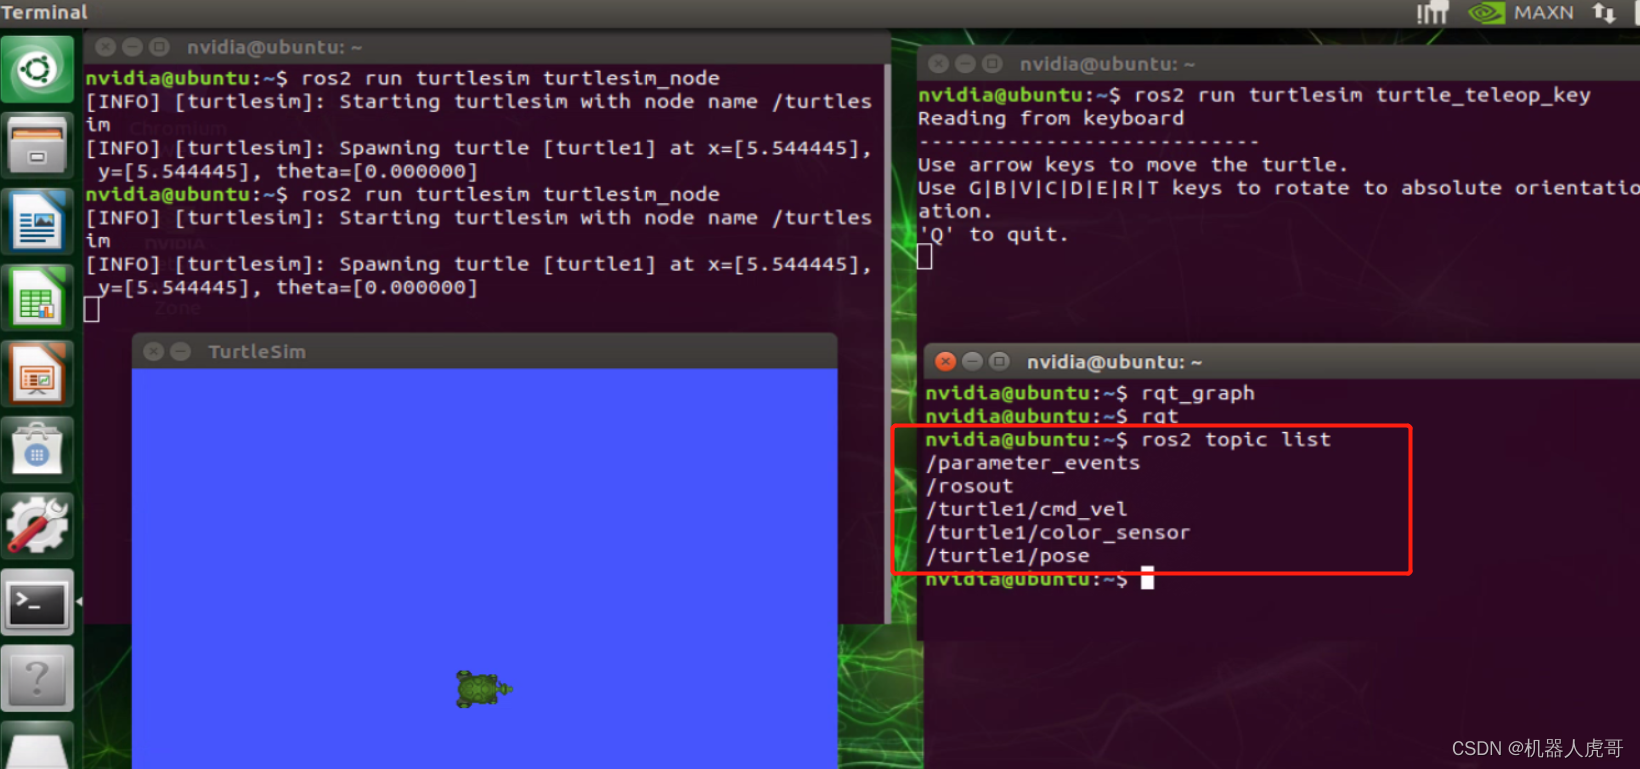
【ROS2入门】理解 ROS 2 Topics 话题_ros2 topic info 详细信息-CSDN博客

Understanding ROS 2 topics — ROS 2 Documentation: Crystal documentation

Intro to ROS Part 2: Getting Started with ROS 2 Using the Command Line
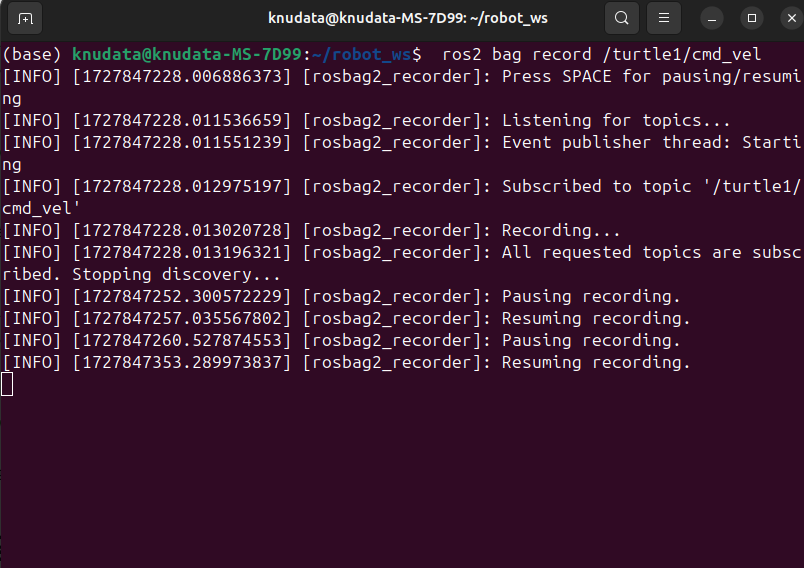
ROS 2 토픽 Topic

ROS 2 Bag Record Remapping Options | PDF | Command Line Interface ...
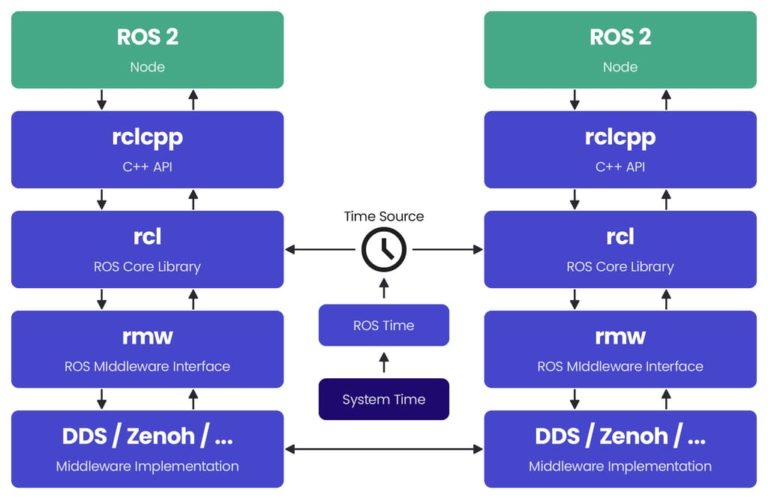
Transforming ROS 2 development with rtest - Spyrosoft

Install ROS 2 on Windows - YouTube
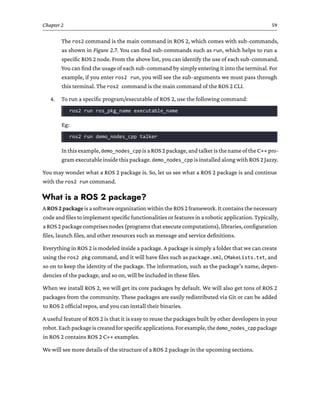
Mastering ROS 2 for Robotics Programming.pdf

Understanding topics — ROS 2 Documentation: Humble documentation
Advertisement Space (300x250)
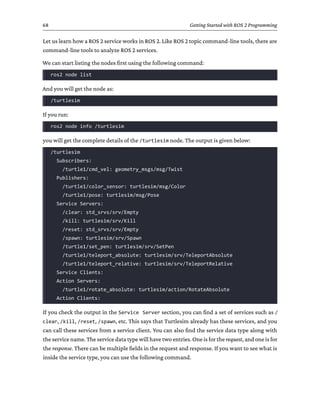
Mastering ROS 2 for Robotics Programming.pdf

Intro to ROS Part 2: Getting Started with ROS 2 Using the Command Line
GitHub - adoodevv/so101_ros2: ROS 2 stack for the SO-101 robot arm ...

Use ROS 2 Logger App to Save ROS 2 Messages from Simulink - MATLAB ...

ROS 1 和 ROS 2 的前世、今生、安装使用说明与资料汇总-腾讯云开发者社区-腾讯云
Intro to ROS Part 2: Getting Started with ROS 2 Using the Command Line
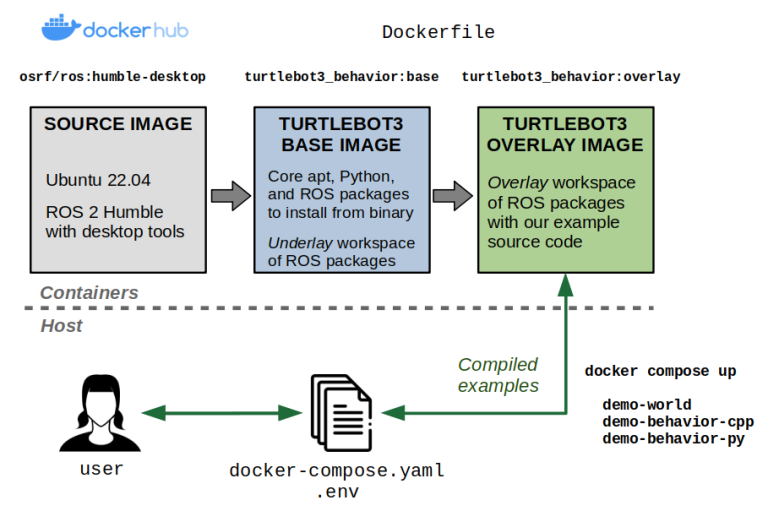
An updated guide to Docker and ROS 2 - Robohub

【ROS2入门】理解 ROS 2 Topics 话题_ros2 topic info 详细信息-CSDN博客
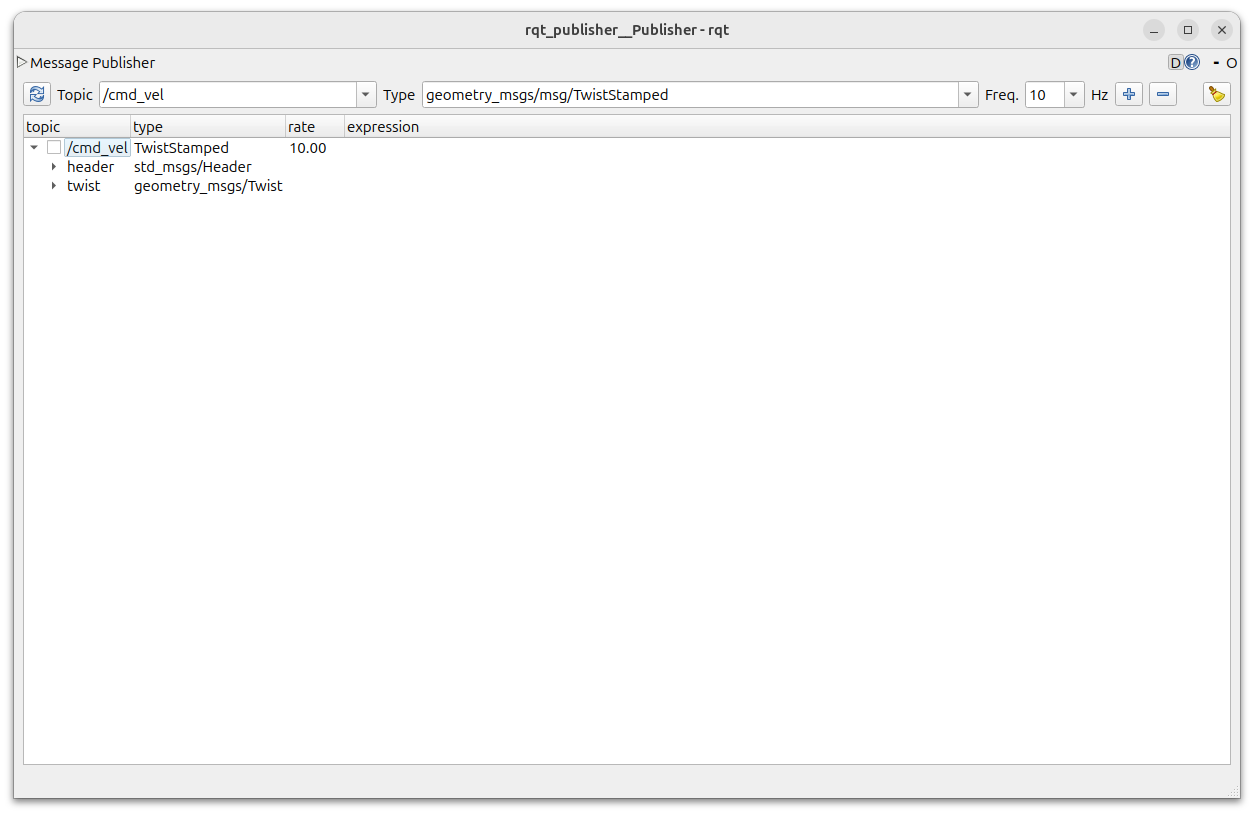
Lab 1: Mobile Robotics - ROS 2 Labs in The Diamond
GitHub - rt-education/cmd_vel_pubsub: ROS 2入門セミナーに使用するROS 2のサンプルパッケージです ...
Advertisement Space (336x280)
GitHub - chihweiyang/ROS_cmd_vel: using ros node to send cmd_vel ...
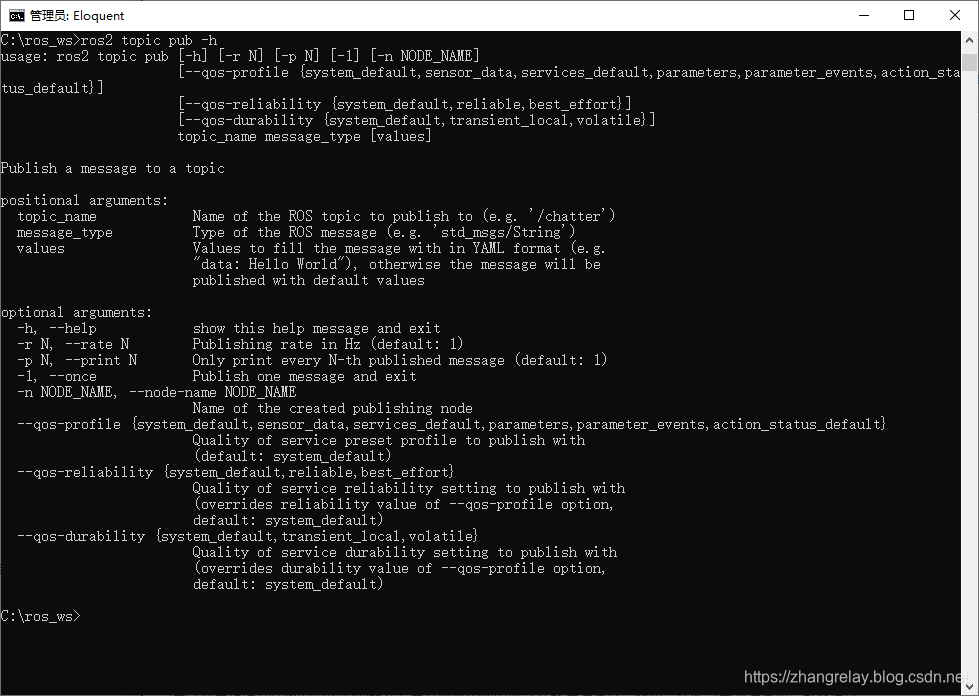
ROS 2主题-topics--云社区-华为云
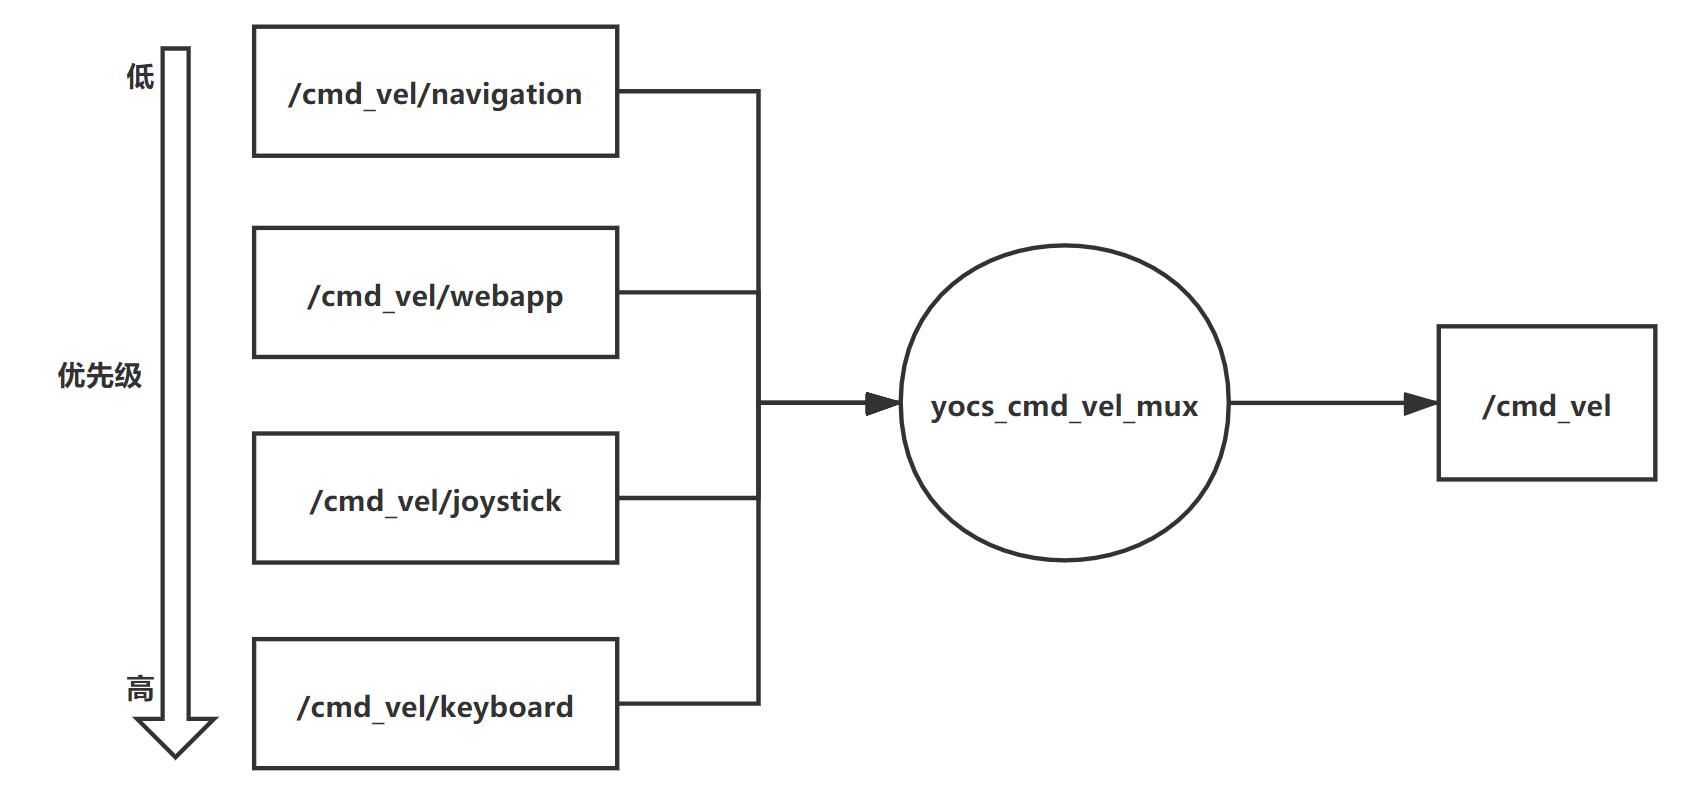
ROS 功能包:yocs_cmd_vel_mux 多路复用速度控制(机器人速度控制切换) - ChenWeihan - 博客园
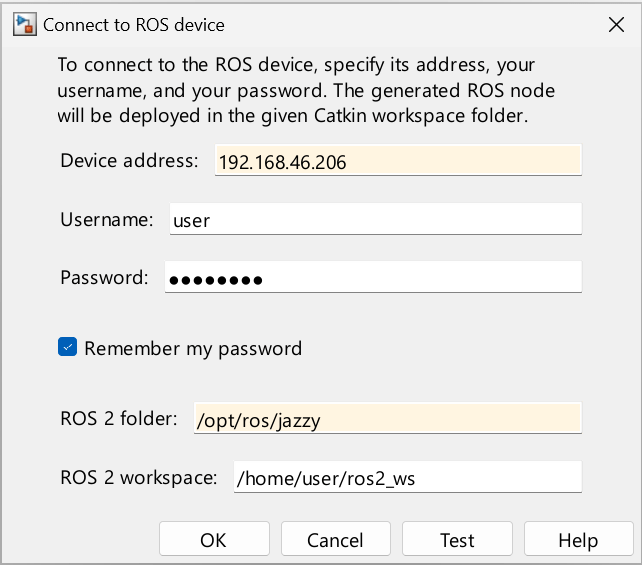
Send and Receive CAN Data in Simulink Using ROS 2-CAN Bridge Node ...
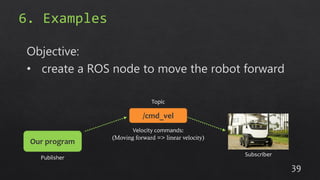
ROS - An open source platform for robotics software developers (lecture ...

Tutorial 1: ROS basic concepts and development tools — 240AR060 ...

ROS2 esp32 micro ros cmd_vel - YouTube
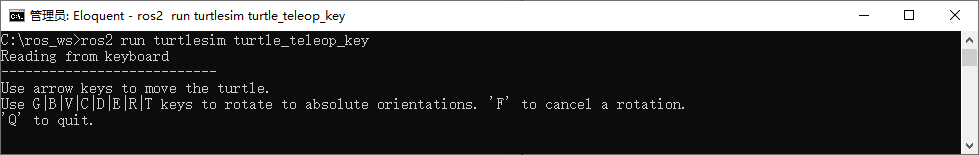
ROS 2行动-actions-_ros2 action-CSDN博客

ros - Error while compiling modified cmd_vel_mux - Robotics Stack Exchange

Kaya robot uses cmd_vel of ROS to control the left front movement error ...
Advertisement Space (336x280)
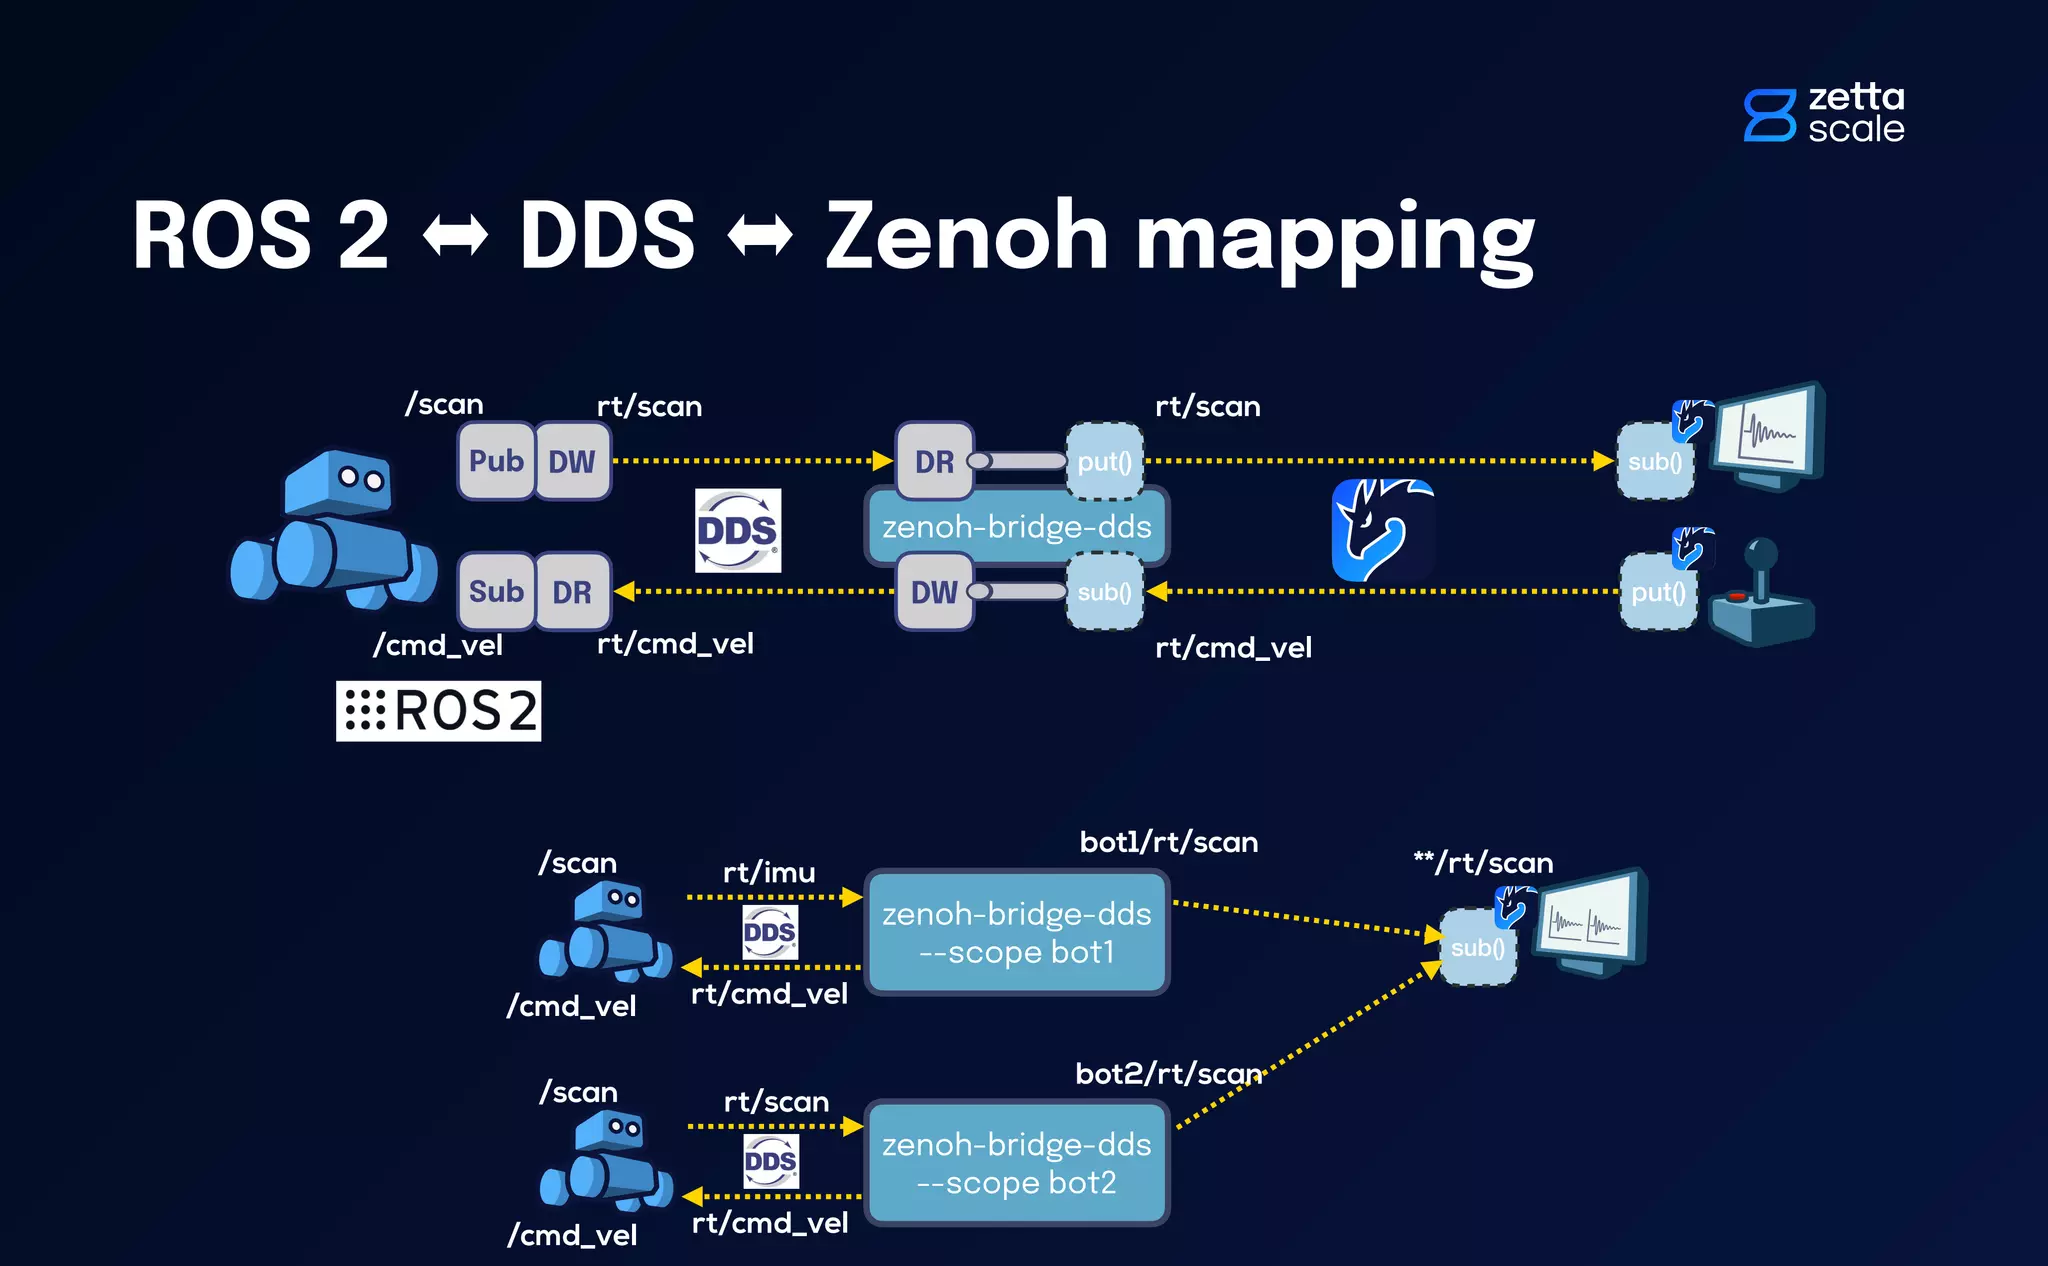
"Taming the Dragon": ROS2 Robot-to-Anything with Zenoh | PDF
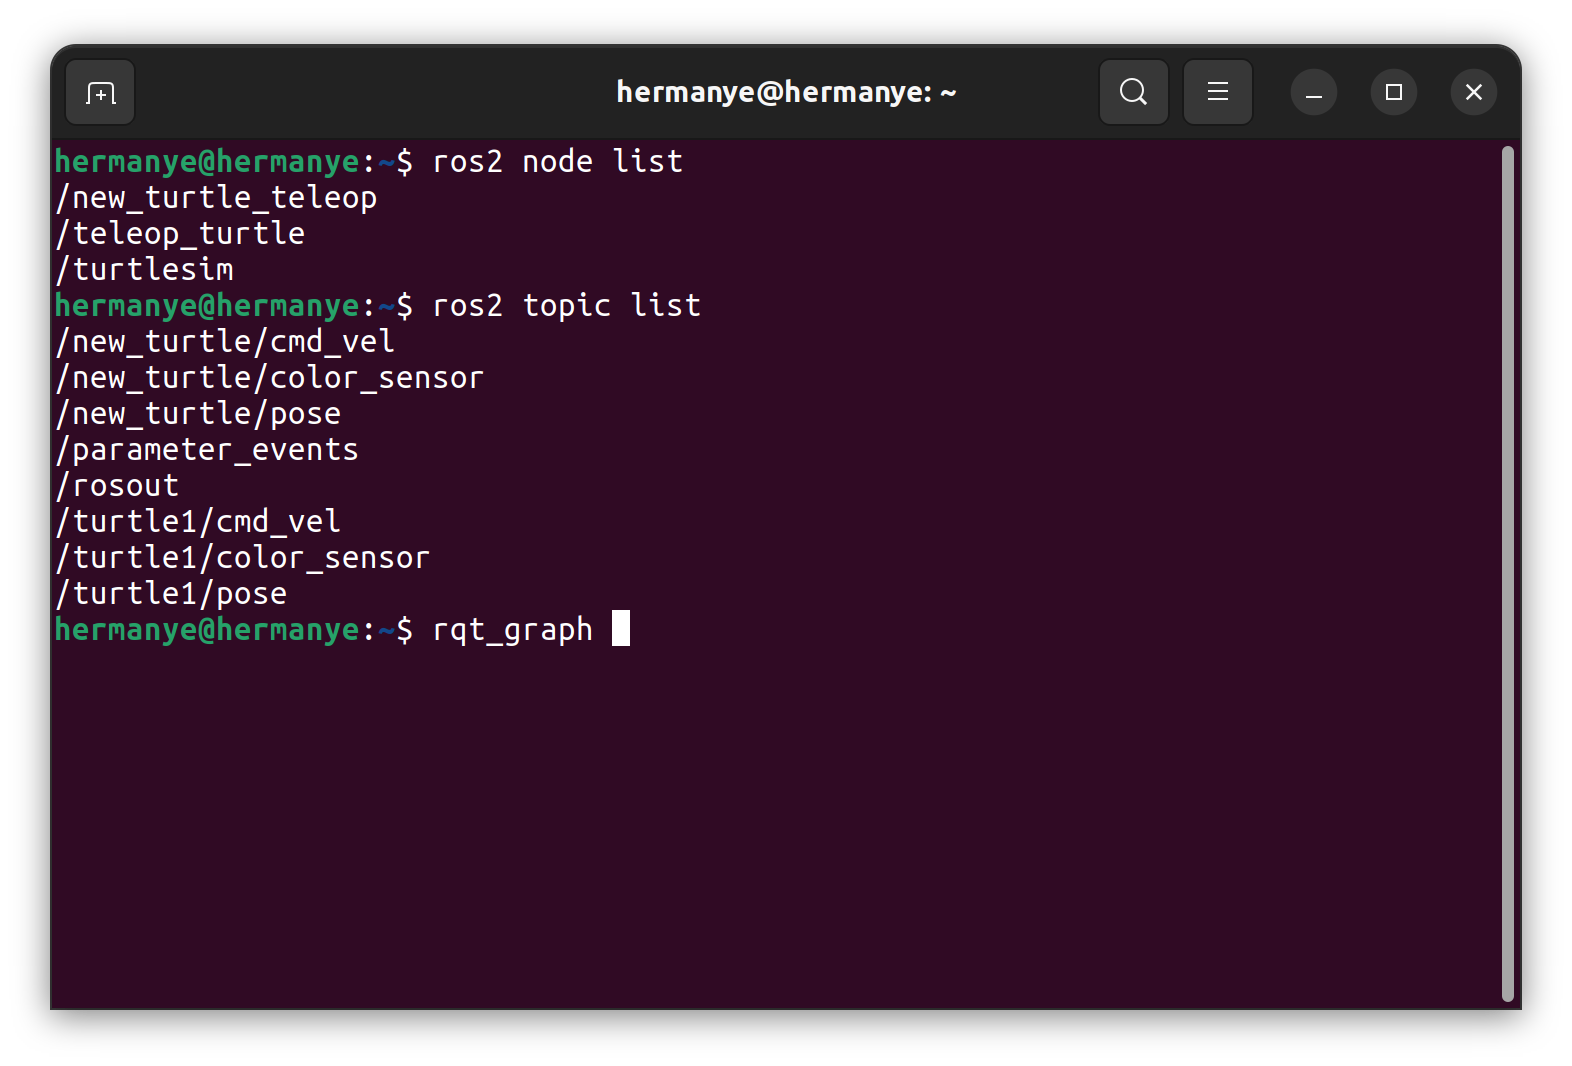
使用命令行与Python实现ROS2服务通信教程-开发者社区-阿里云
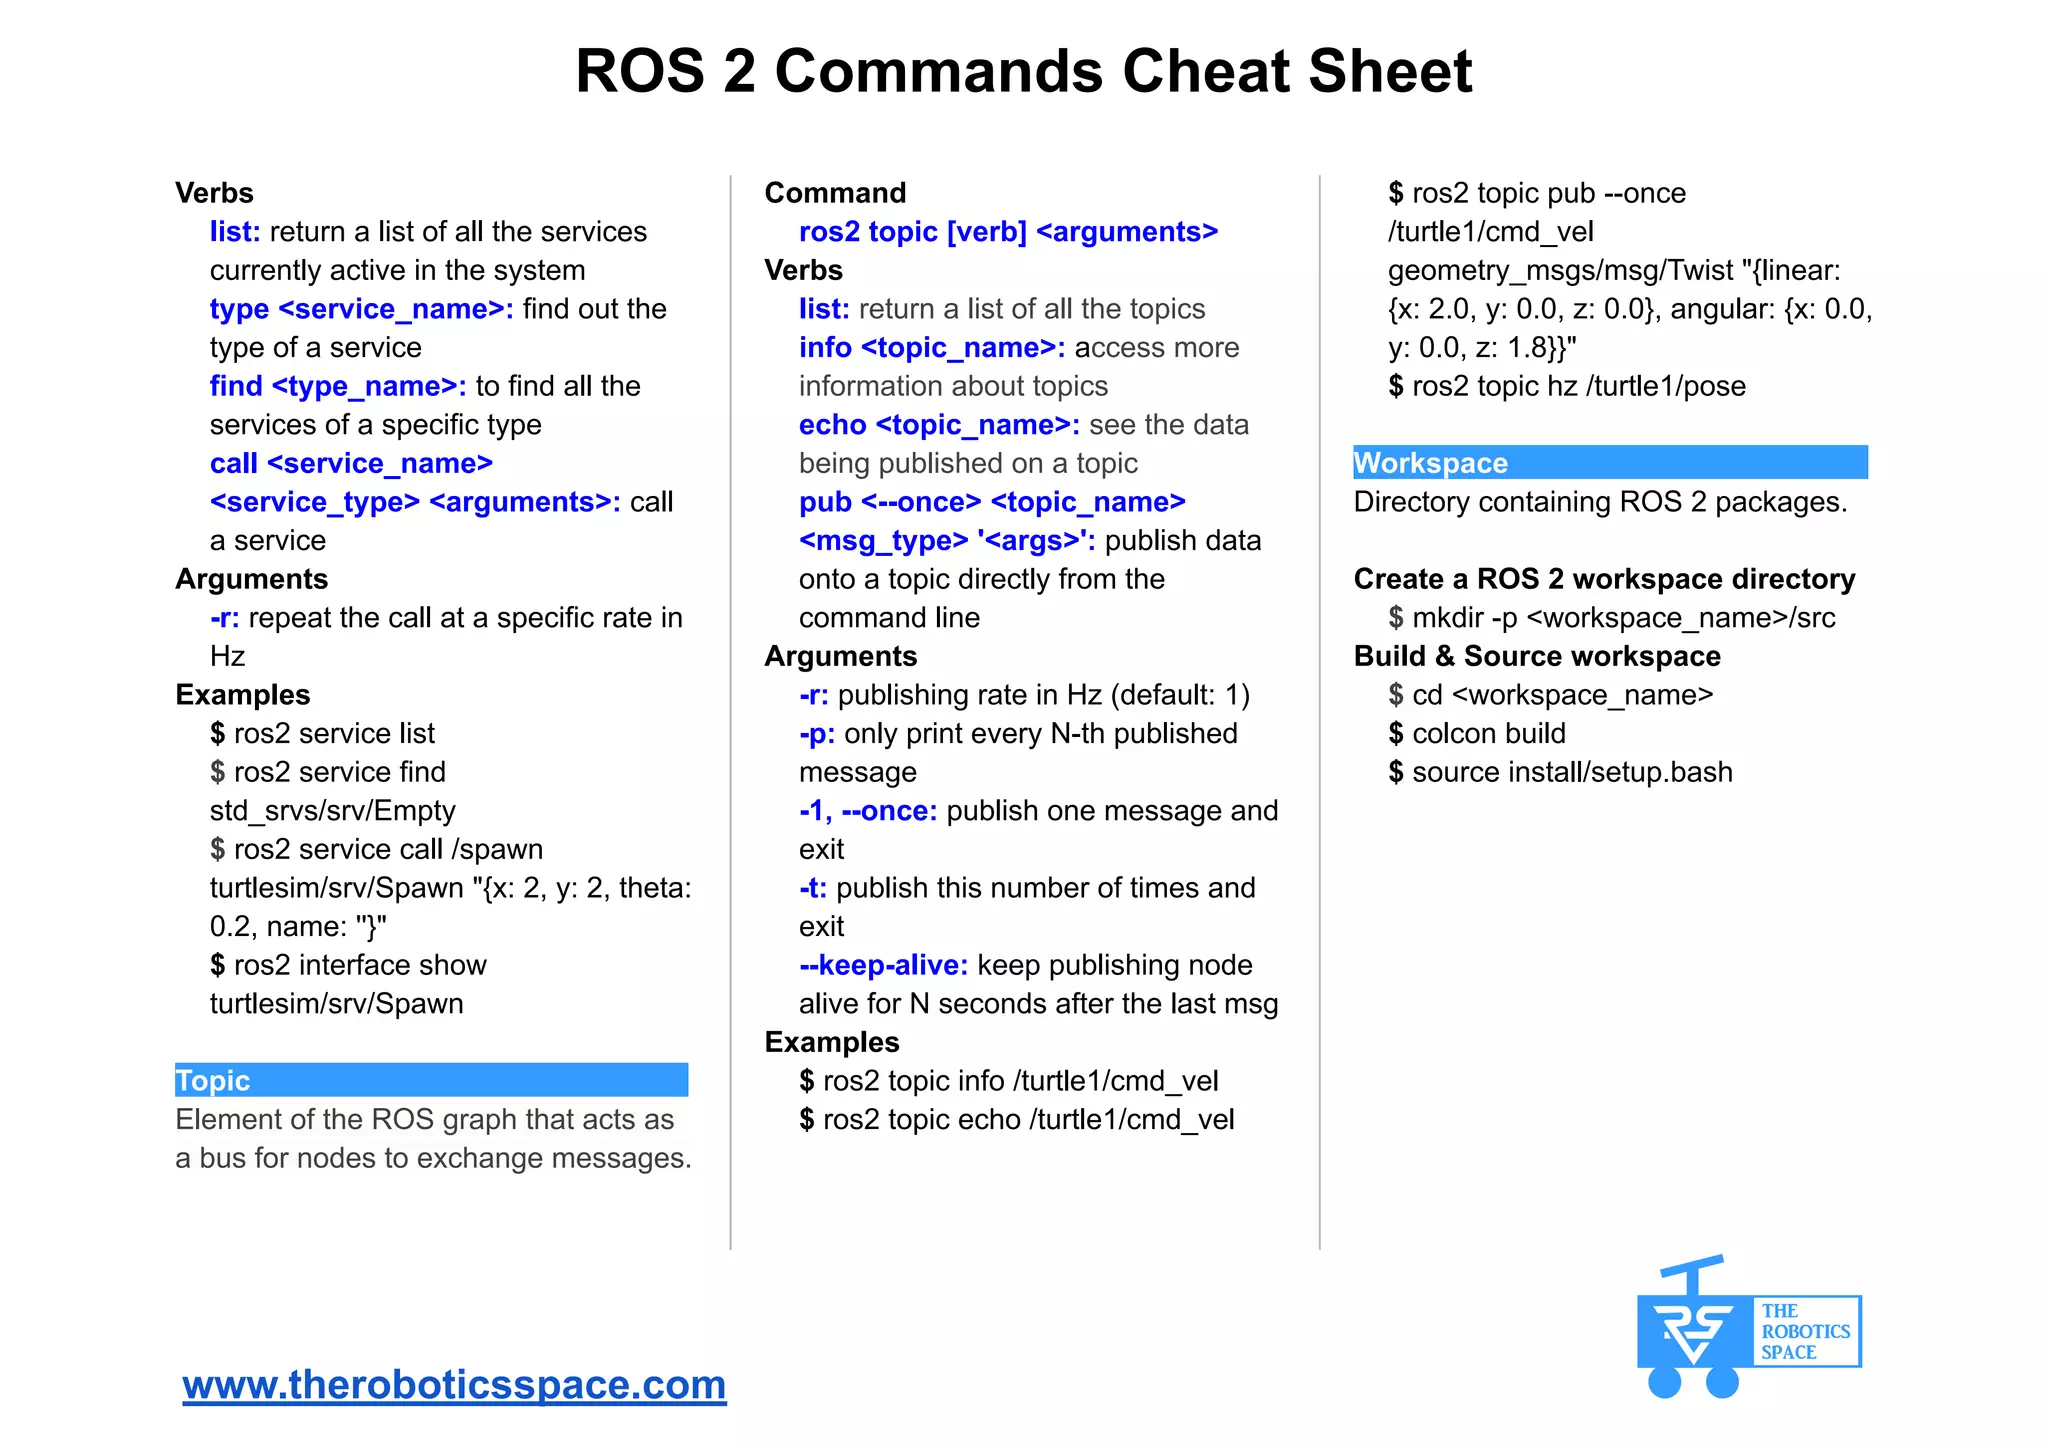
ros2_humble_cheat_sheet2.pdf
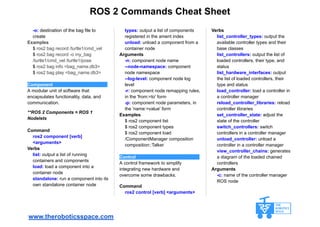
ros2_humble_cheat_sheet2.pdf
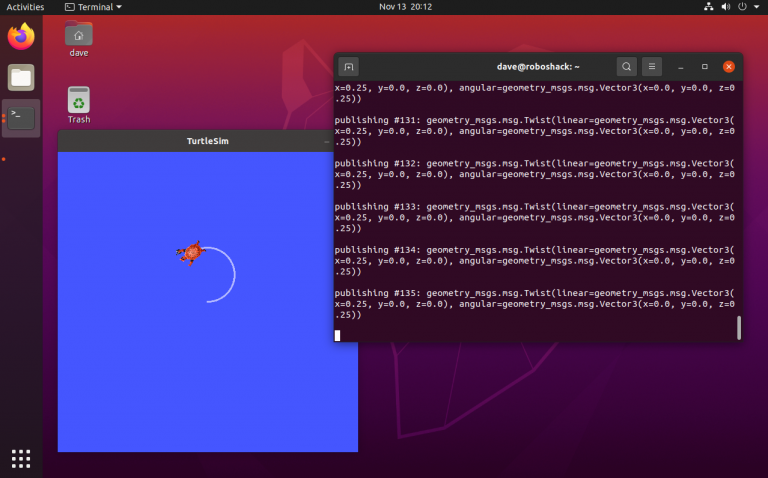
ROS2 topics – Dave's RoboShack

基于ROS的多差速移动机器人编队控制仿真实现_基于ros2的多机器人编队-CSDN博客