
Ros Python Csdn
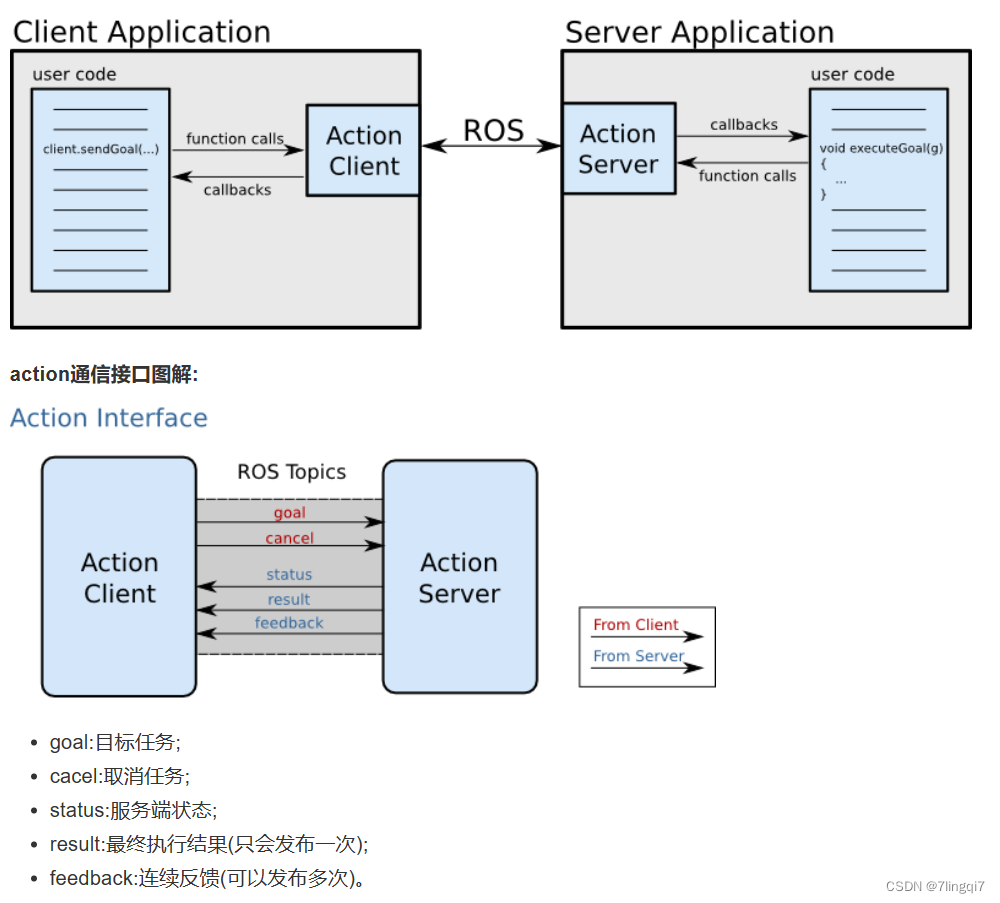
【ros实验三】使用 ROS 动作(Action)机制实现目标请求——实现零件完成度检测(python)_ros action python ...

Writing a ROS Python Makefile-CSDN博客
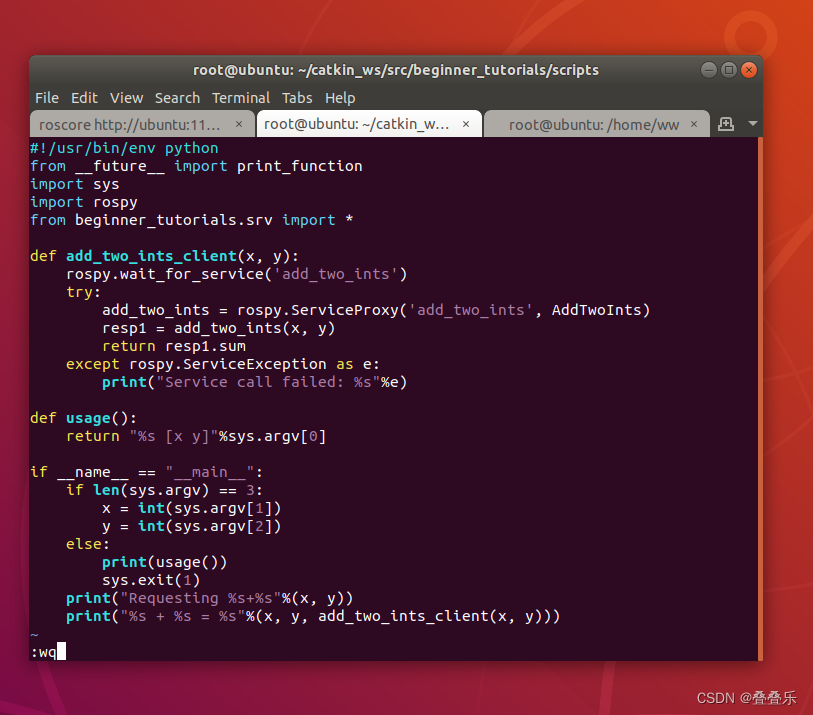
编写 ROS 服务节点 Service 和 Client(python/C++)(六)_ros python service-CSDN博客

编写 ROS 服务节点 Service 和 Client(python/C++)(六)_ros python service-CSDN博客

ROS Python 入门学习笔记 --0--ROS安装与配置_python ros-CSDN博客

ROS Python 入门学习笔记--1--工作空间与功能包的创建_基于python的ros学习-CSDN博客
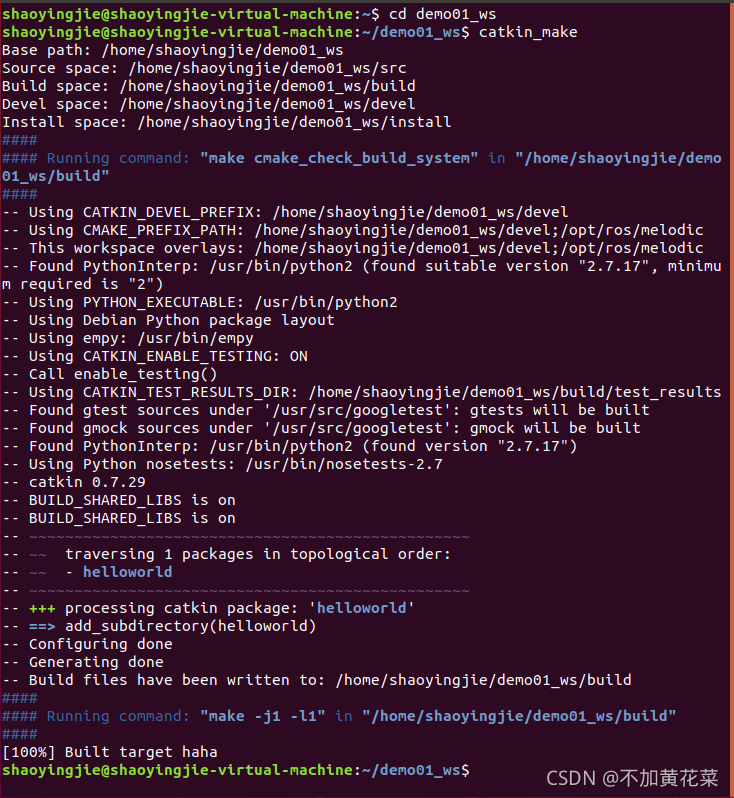
Ros学习笔记(一)Ros中HelloWorld实现(C++/Python)_vsode ros python hello实现-CSDN博客

ros python 20210202_ros使用python哪个版本-CSDN博客

ROS Tutorial #3.2: Python Services - YouTube

ROS Python 入门学习笔记 --0--ROS安装与配置_python ros-CSDN博客
Advertisement Space (300x250)

Python Ros Node Publisher – python – ZDMD
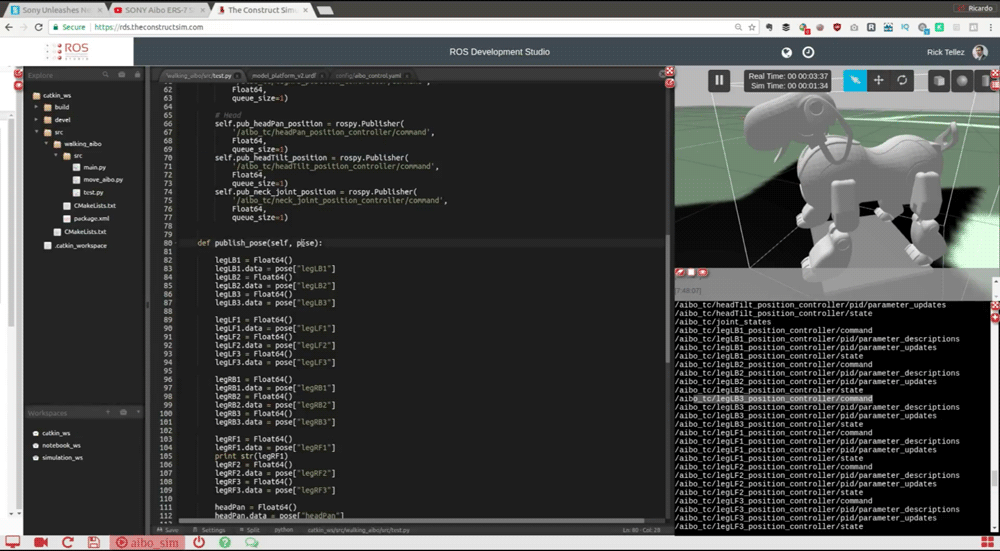
Learn ROS with Python or with C++? Pros & Cons | The Construct

ROS Python vs. ROS C++ (Infographic) | The Construct
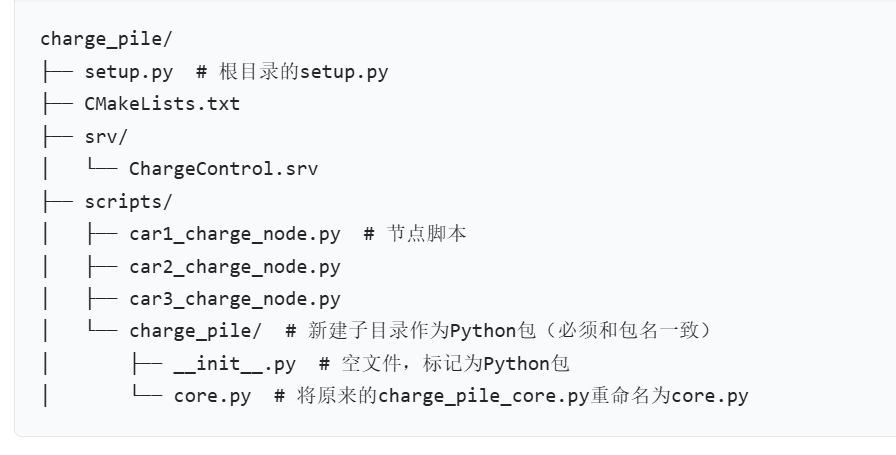
ROS python import 导入问题-CSDN博客

Yahboom DOFBOT AI Vision Robotic Arm With ROS Python Programming For ...
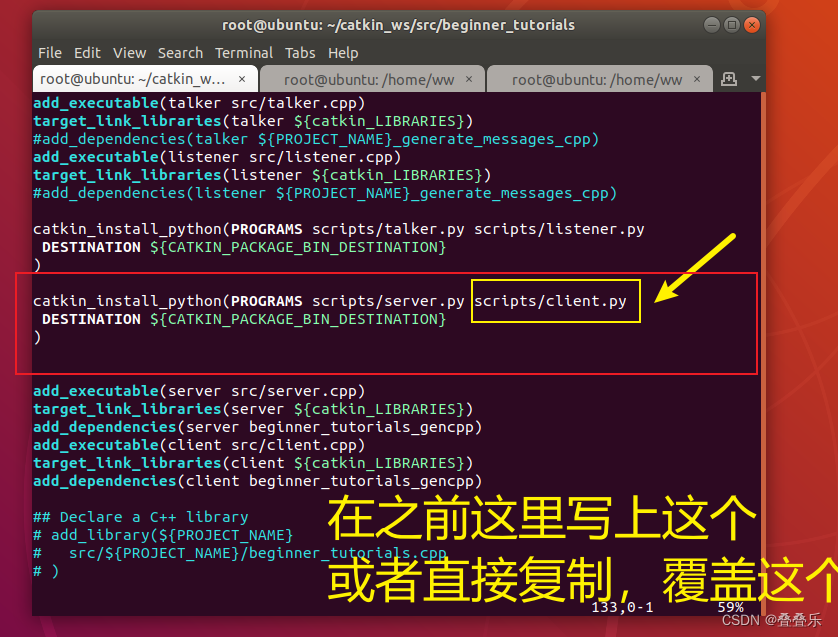
编写 ROS 服务节点 Service 和 Client(python/C++)(六)_ros python service-CSDN博客

Intro to ROS Part 5: Services, Requests, and Responses with Python

Latest 2024 model ROS programmable Robot with Python support AI for Je ...

ROS Python - YouTube

【ROS入门】6. 话题消息的定义与使用_python ros 话题使用-CSDN博客
Advertisement Space (336x280)
傻瓜教程——ROS运行hello world(python版)_ros noetic python 的cmakelist-CSDN博客
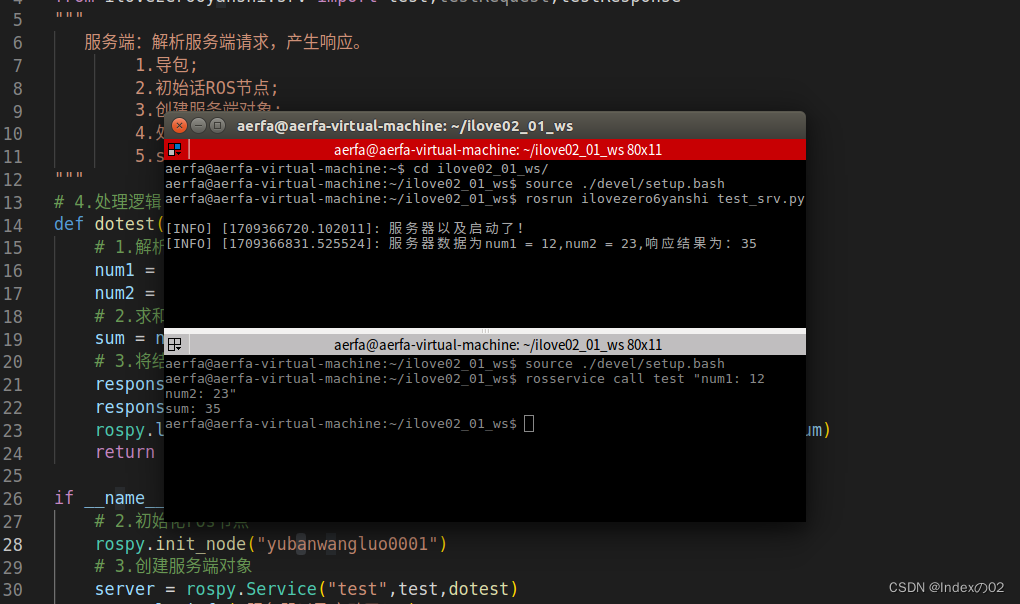
ROS-服务通信(Python)srv的基本实现流程与优化_ros python 通讯 service-CSDN博客
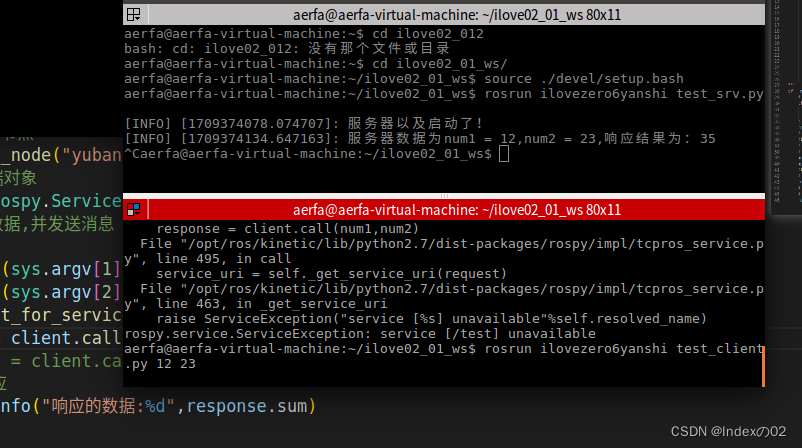
ROS-服务通信(Python)srv的基本实现流程与优化_ros python 通讯 service-CSDN博客

ROS | 用C++和python实现运动控制功能_ros 配合python控制-CSDN博客

ROS 用python实现小乌龟做圆周运动_ros小海龟做圆周运动python-CSDN博客
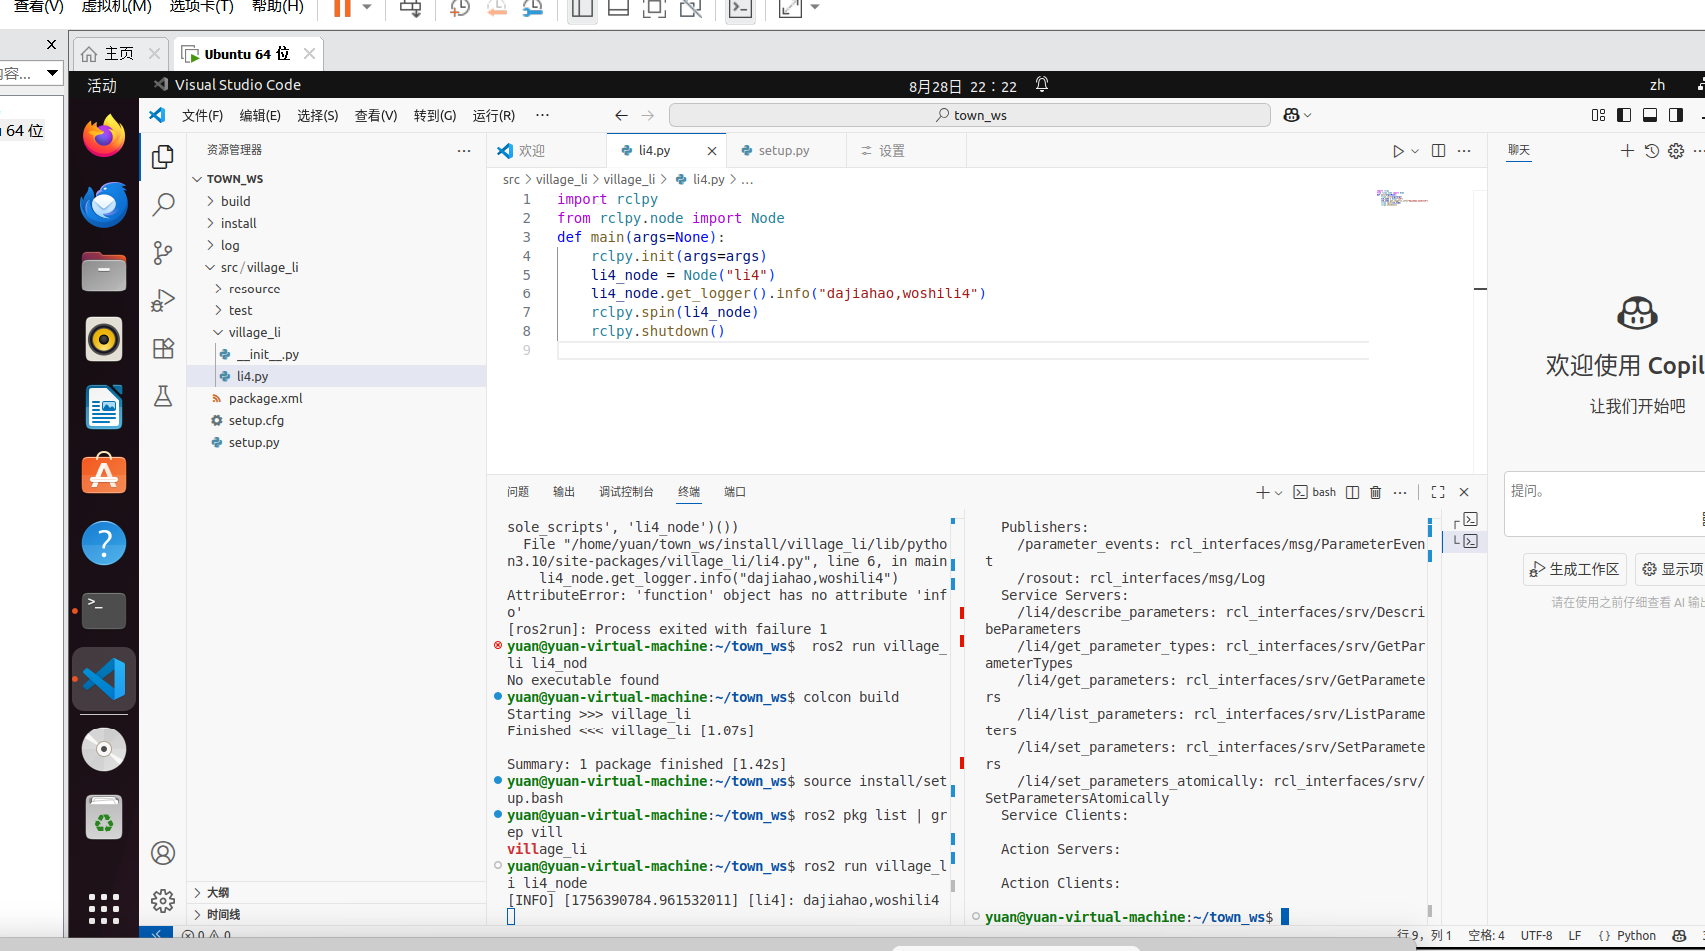
ROS 面向过程编写一个python节点-CSDN博客

ROS 面向过程编写一个python节点-CSDN博客
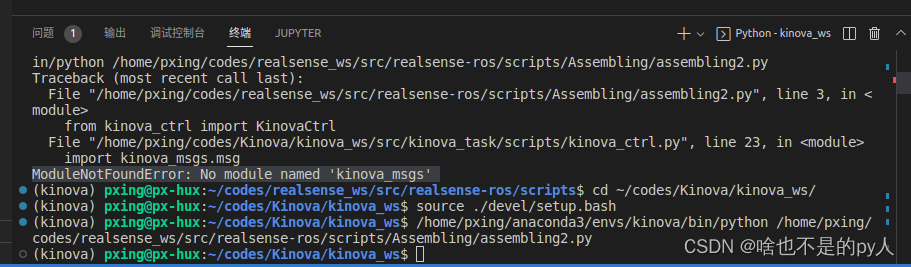
Python 导入并使用其他目录下的ROS文件_ros中使用python导入包-CSDN博客

ROS | C++和python实现IMU数据获取_ros分析imu数据-CSDN博客

ROS 用python实现小乌龟做圆周运动_ros小海龟做圆周运动python-CSDN博客
Advertisement Space (336x280)

基于python的ROS功能包(对比C++的ROS开发,Python的ROS开发简单和方便的无数倍。)_ros 编程 c++ python ...
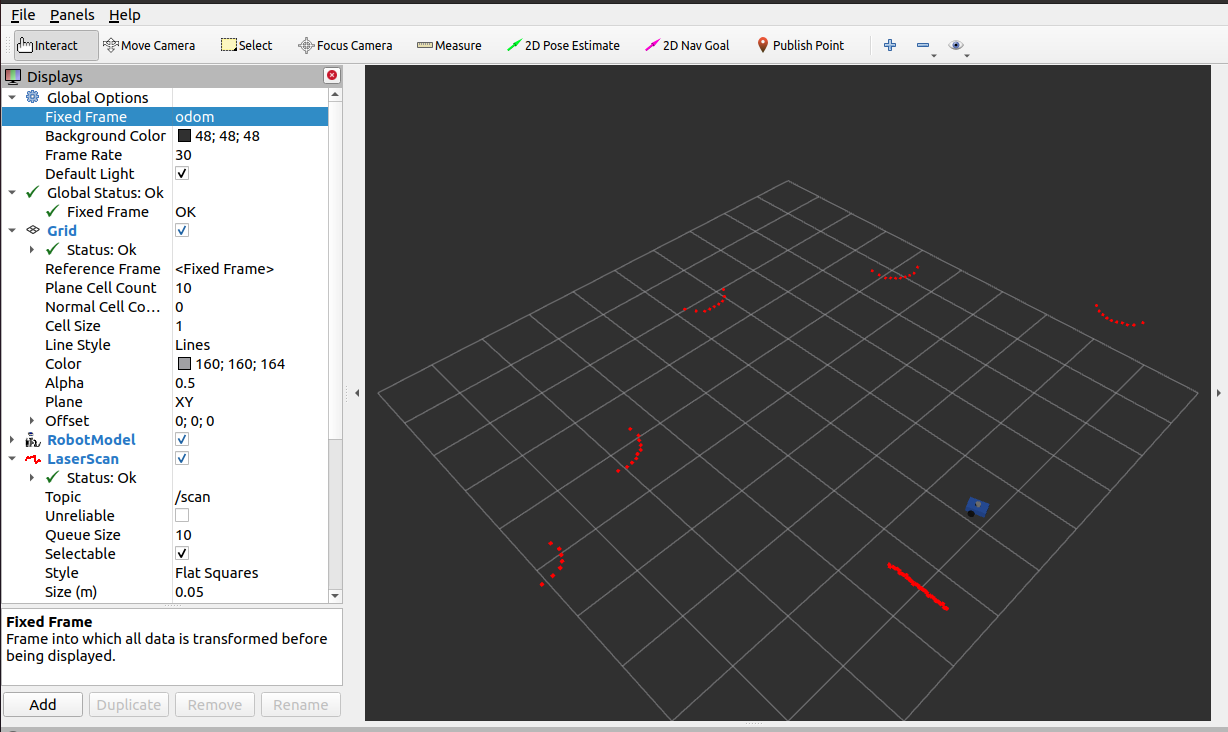
第13天 ROS Noetic Gazebo差速小车从零搭建|键盘遥控、雷达数据读取、Python自主节点全流程-CSDN博客
ROS 自定义 话题消息与使用 python实现_ros自定义消息python-CSDN博客

ROS 2机器人开发--话题通信:订阅与发布_ros2订阅话题-CSDN博客

傻瓜教程——ROS运行hello world(python版)_ros noetic python 的cmakelist-CSDN博客

[ROS Q&A] 186 - How to store value from a subscribed topic in ROS in ...