
Vio Slam
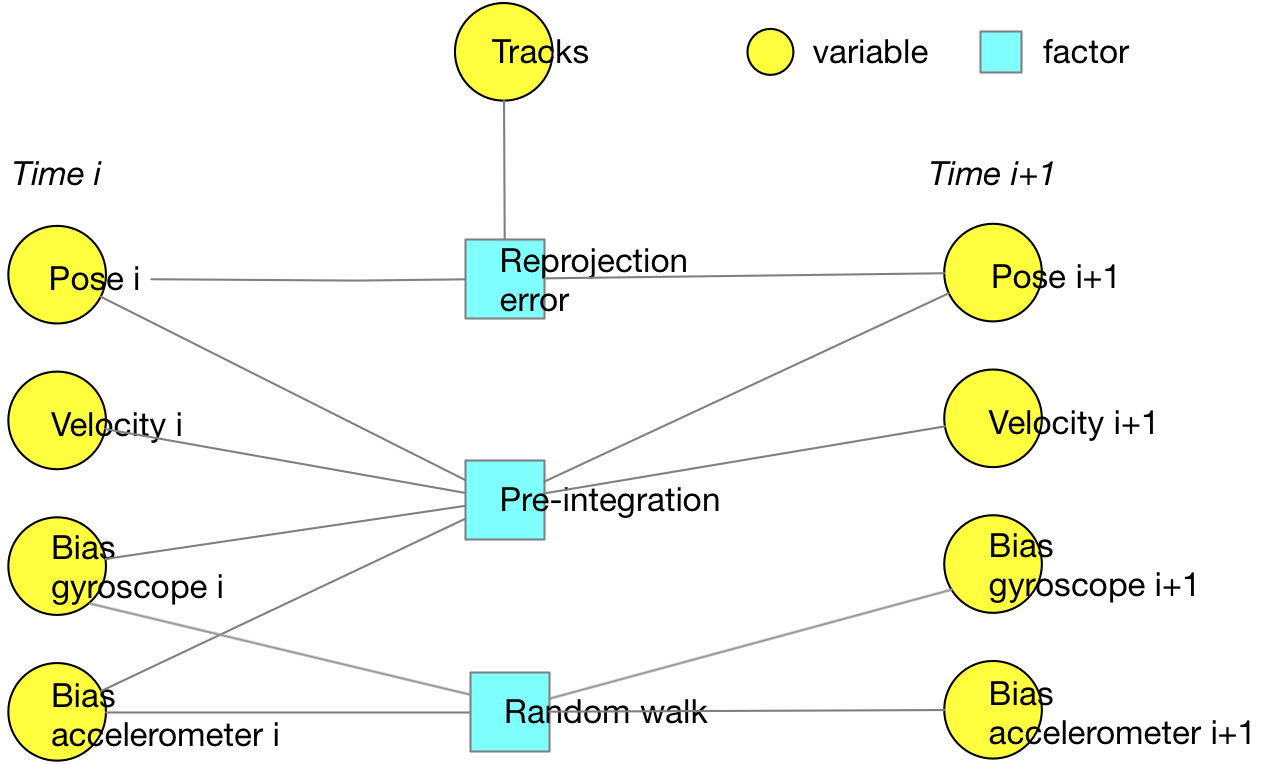
VIO SLAM
GitHub - Relo02/Go2-VIO-SLAM: Integration of VIO SLAM with an ...
GitHub - guisongchen/vio_slam_try: vio slam code

Impact of IMU accuracy on V SLAM VIO performance - YouTube

초소형 VIO 모듈: SLAM 카메라 보드 최신 리비전 공개 | AI Trends

RAE on-device VIO & SLAM - YouTube

Setting up VIO / VSLAM with Nav2! - ROS General - Open Robotics Discourse

GitHub - MIT-SPARK/Kimera-VIO: Visual Inertial Odometry with SLAM ...
Collaborative SLAM estimate for 5 agents (EuRoC MH Dataset) running ...

VIO(Visual Imu Odometry) SLAM with Rtabmap Using Jetson Xavier ...
Advertisement Space (300x250)
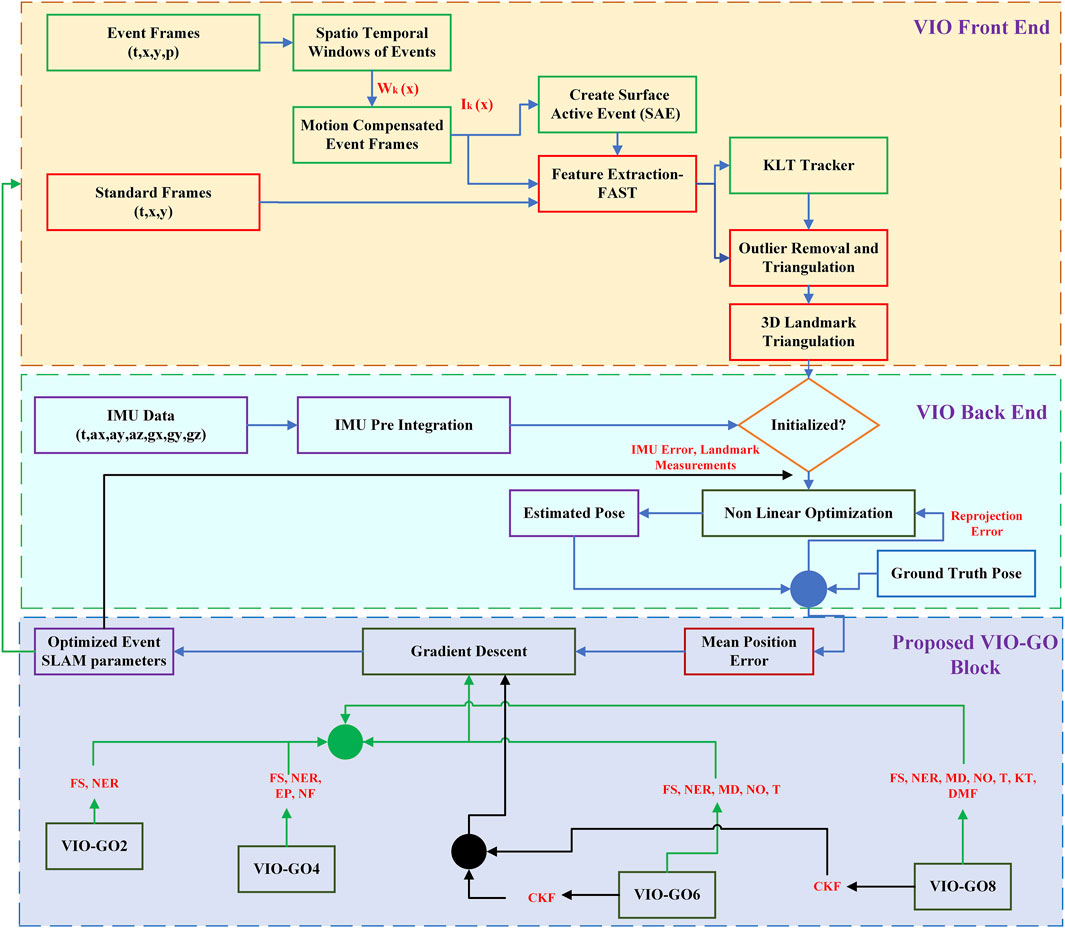
Frontiers | VIO-GO: optimizing event-based SLAM parameters for robust ...
GitHub - ali-pahlevani/VIO_SLAM_Module: This is the Prototype-v1 VIO ...
Visual SLAM and Visual Odometry and in Mobile Robotics Overview
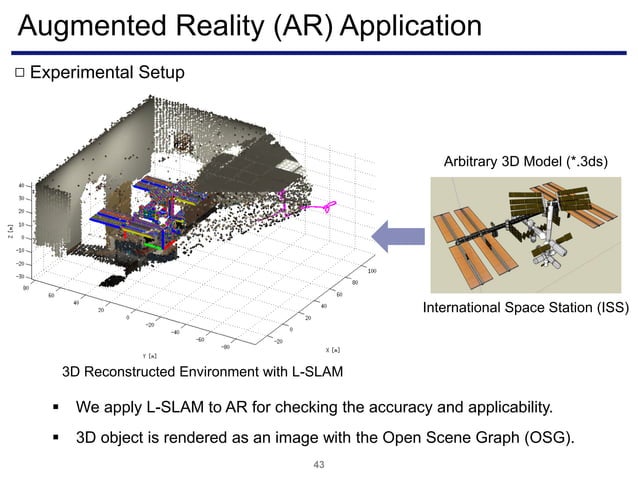
Visual odometry & slam utilizing indoor structured environments | PPT
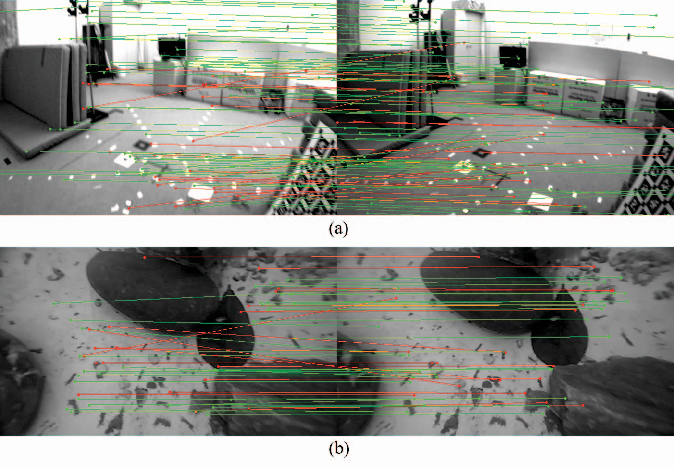
Figure 3 from Robust Initialization for Stereo Visual-Inertial SLAM ...

Figure 3 from A Distributed SLAM with UWB-VIO Fusion Framework for ...
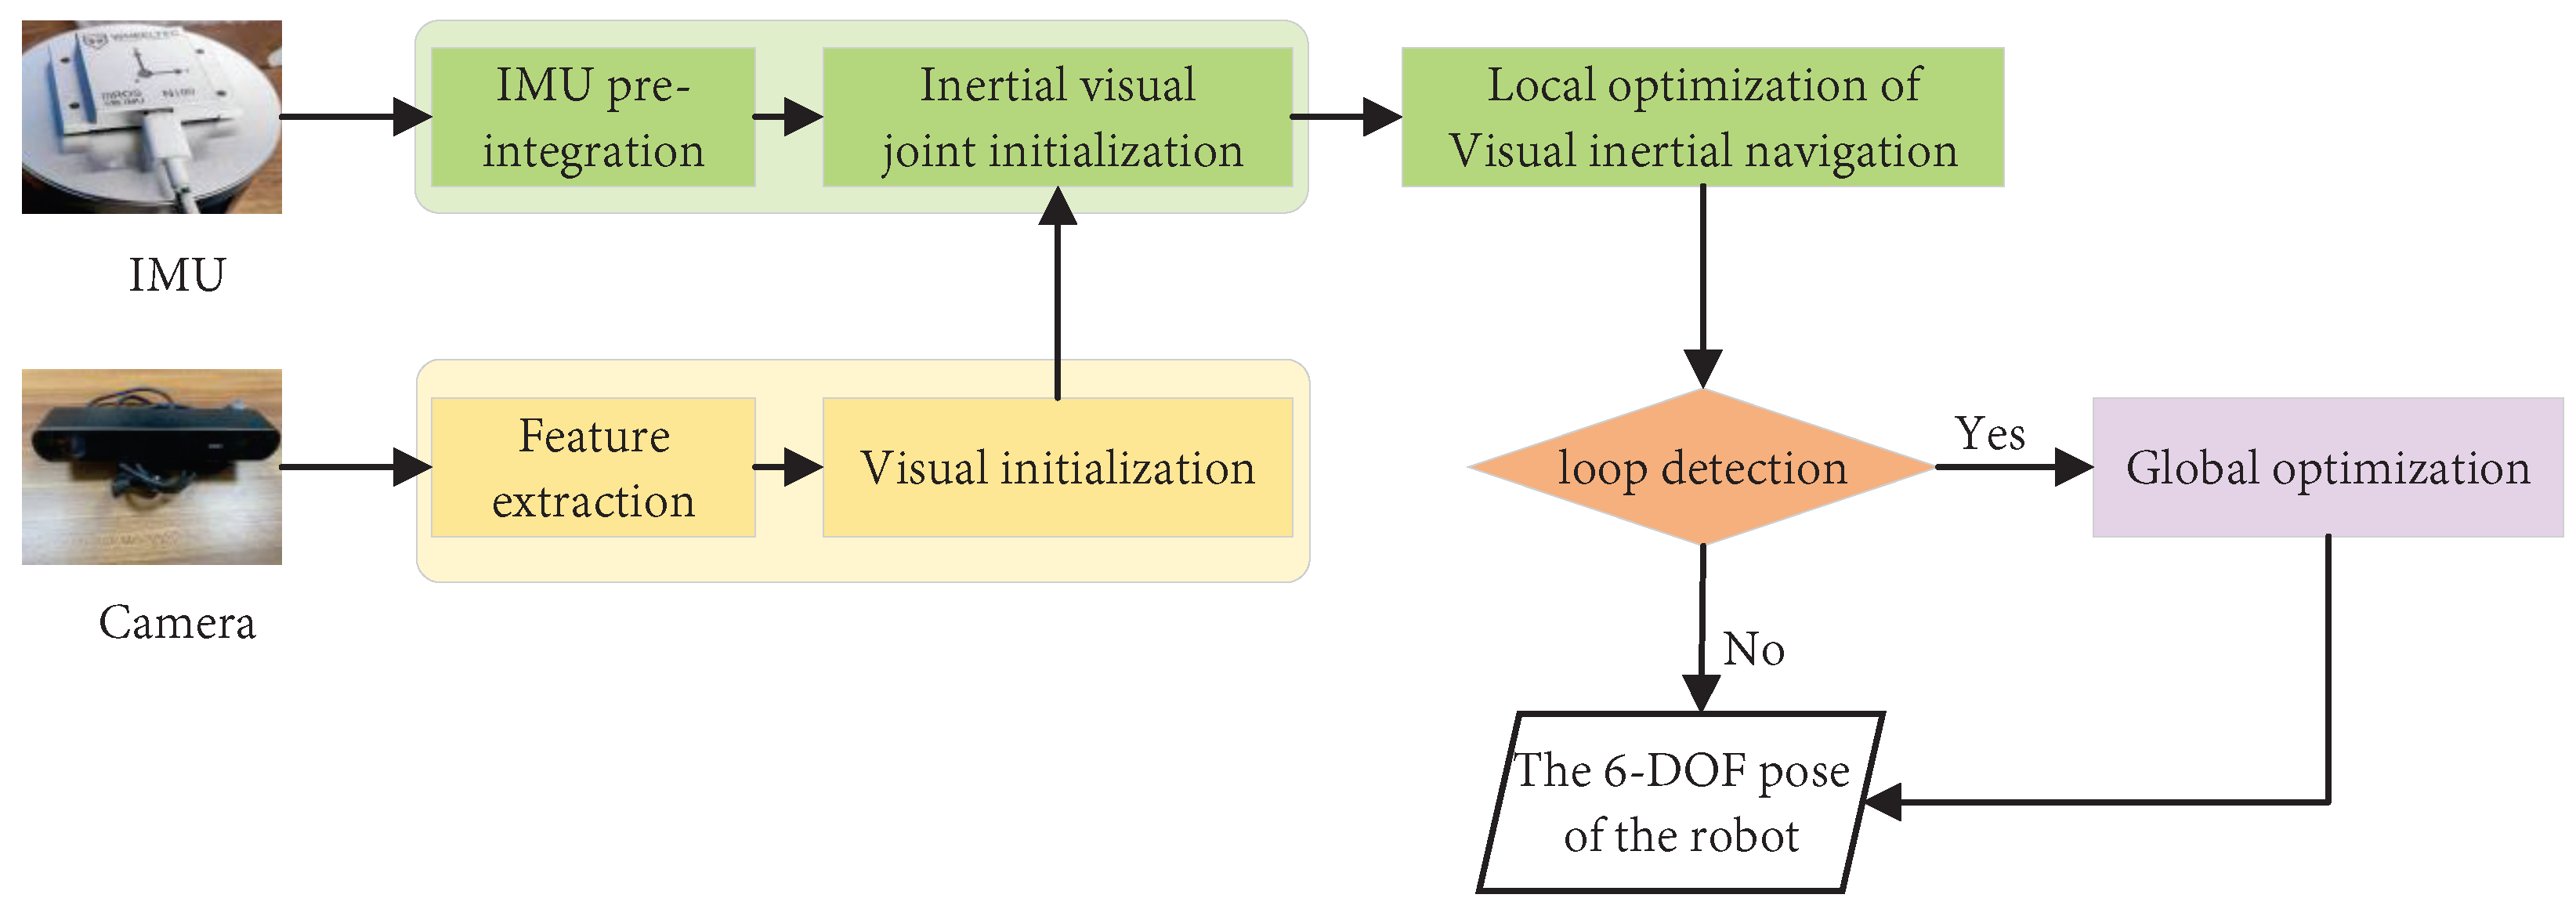
Overview of Multi-Robot Collaborative SLAM from the Perspective of Data ...
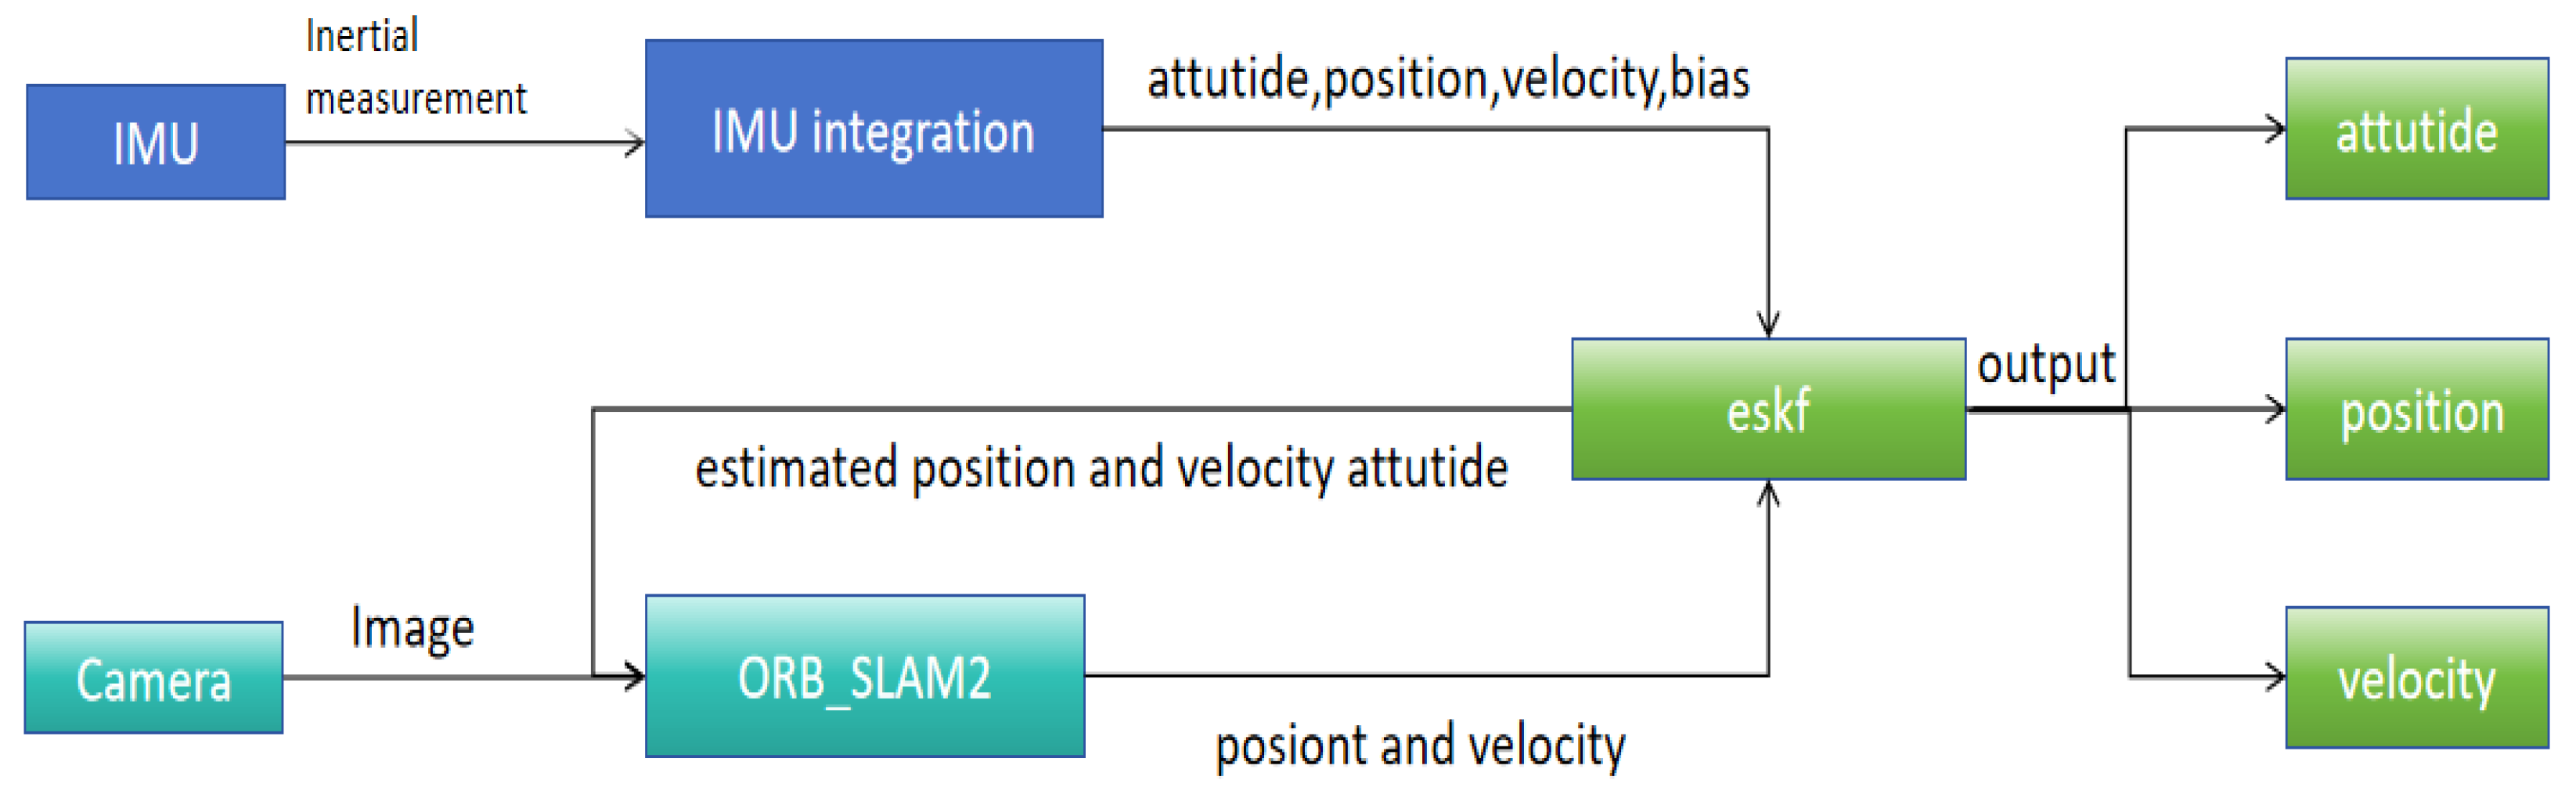
ESKF-g2o-SLAM: A Stereo Visual–Inertial SLAM with ORB Features and ESKF ...
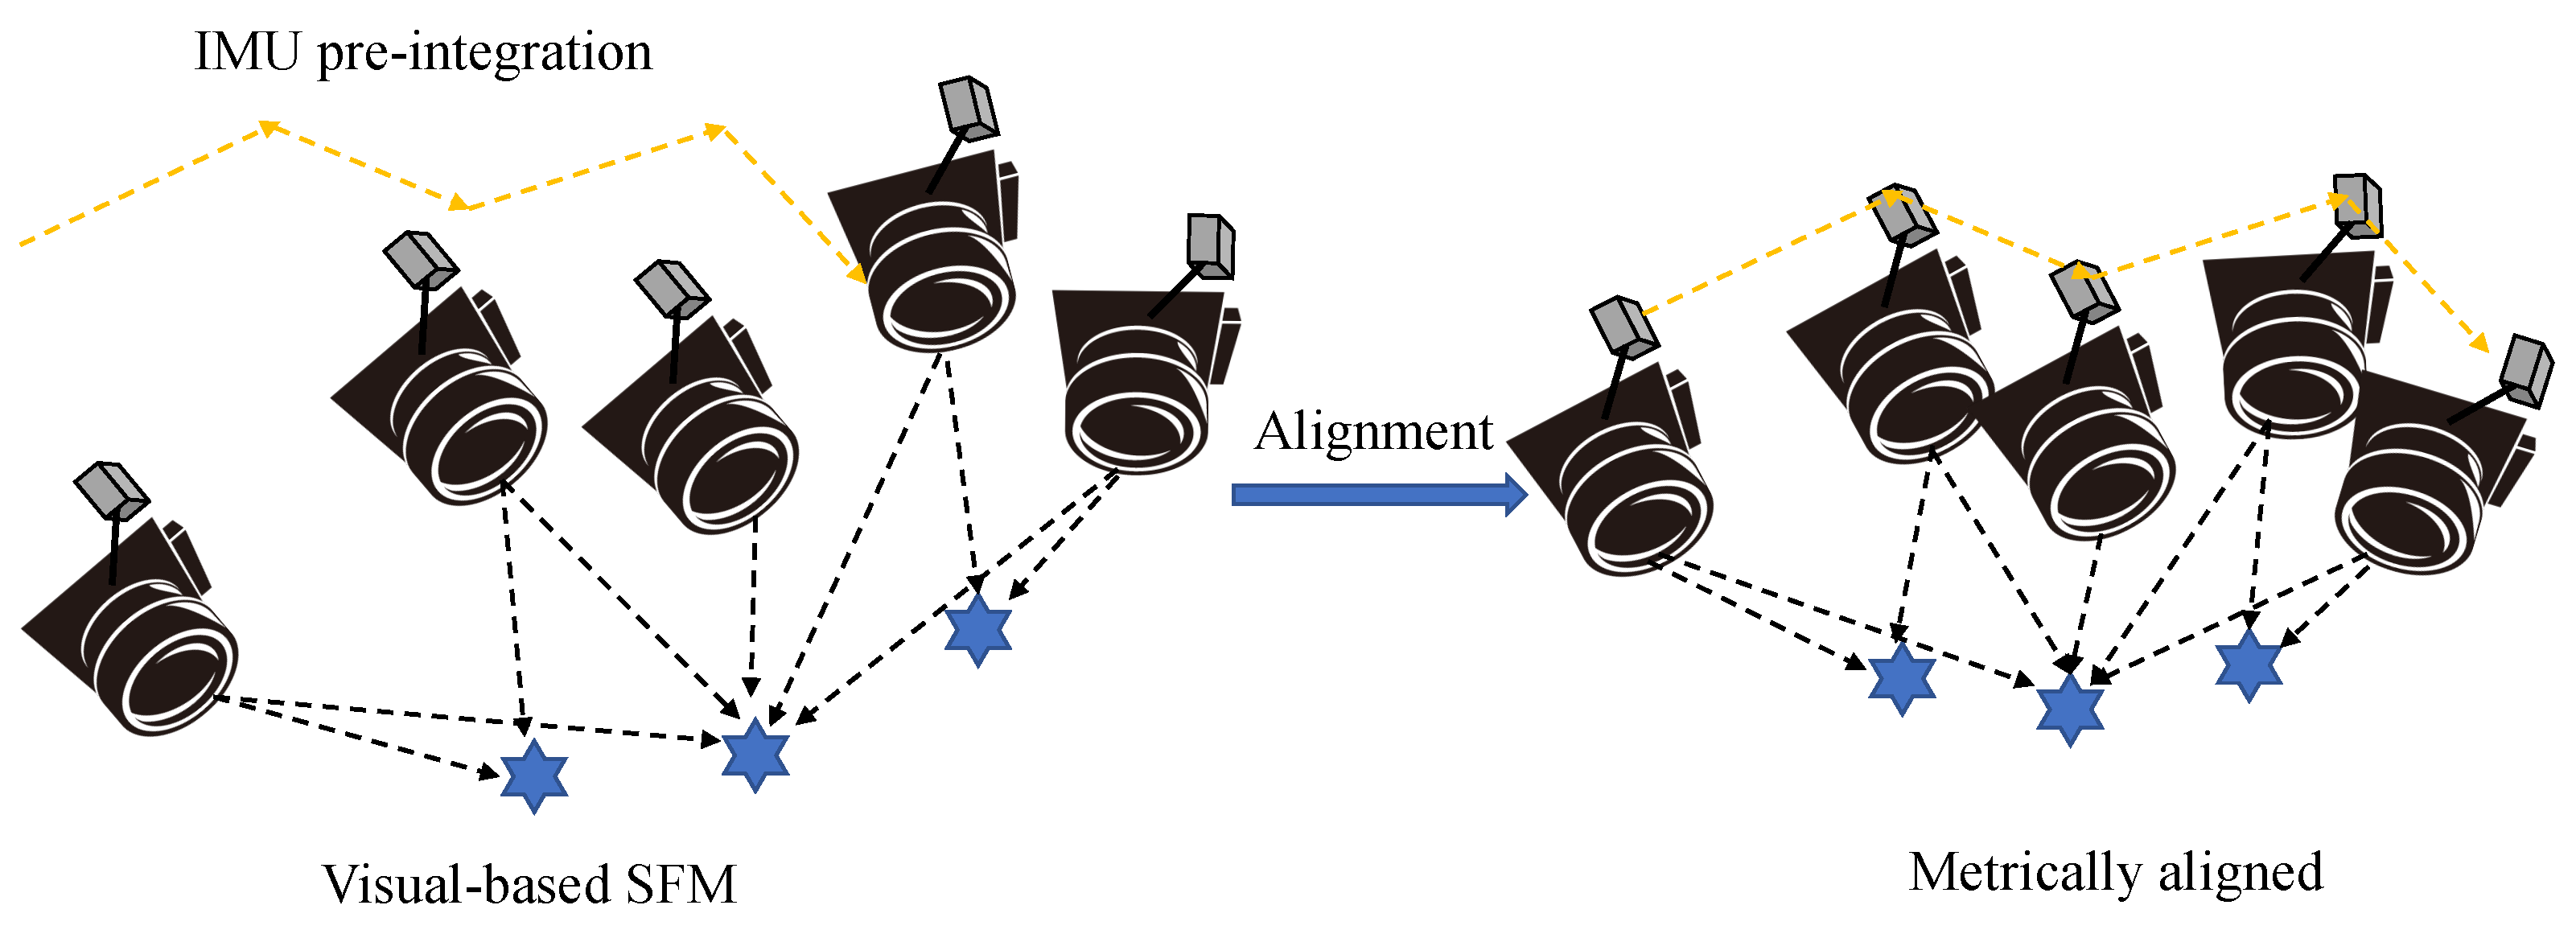
E2-VINS: An Event-Enhanced Visual–Inertial SLAM Scheme for Dynamic ...

Evaluation of VIO-based SLAM and comparison with the monocular ORB-SLAM ...
Advertisement Space (336x280)
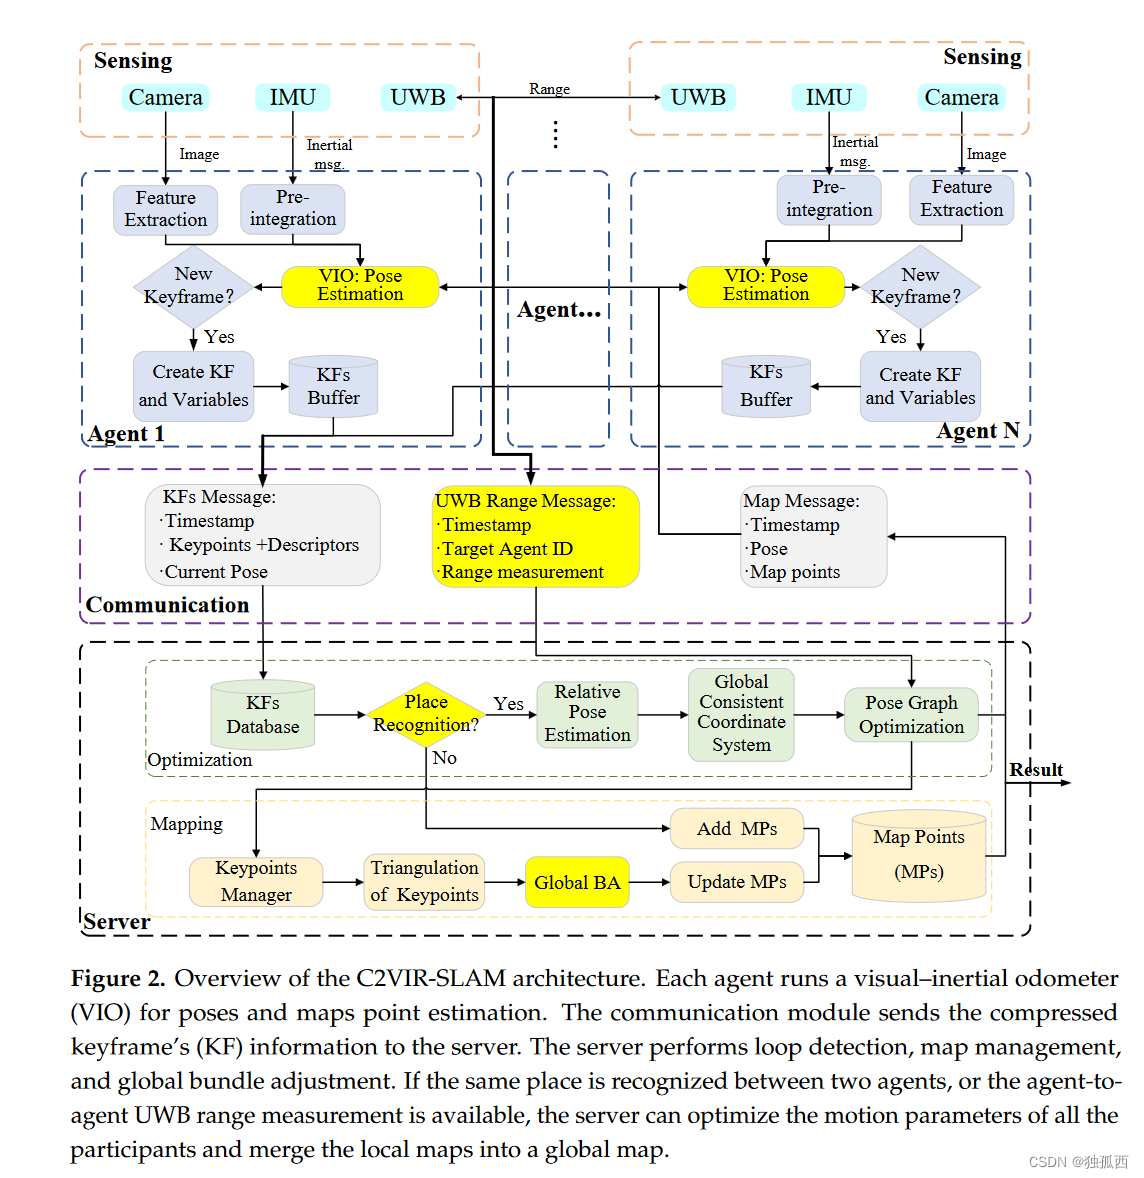
论文阅读:C2VIR-SLAM: Centralized Collaborative Visual-Inertial-Range SLAM ...

论文阅读:C2VIR-SLAM: Centralized Collaborative Visual-Inertial-Range SLAM ...
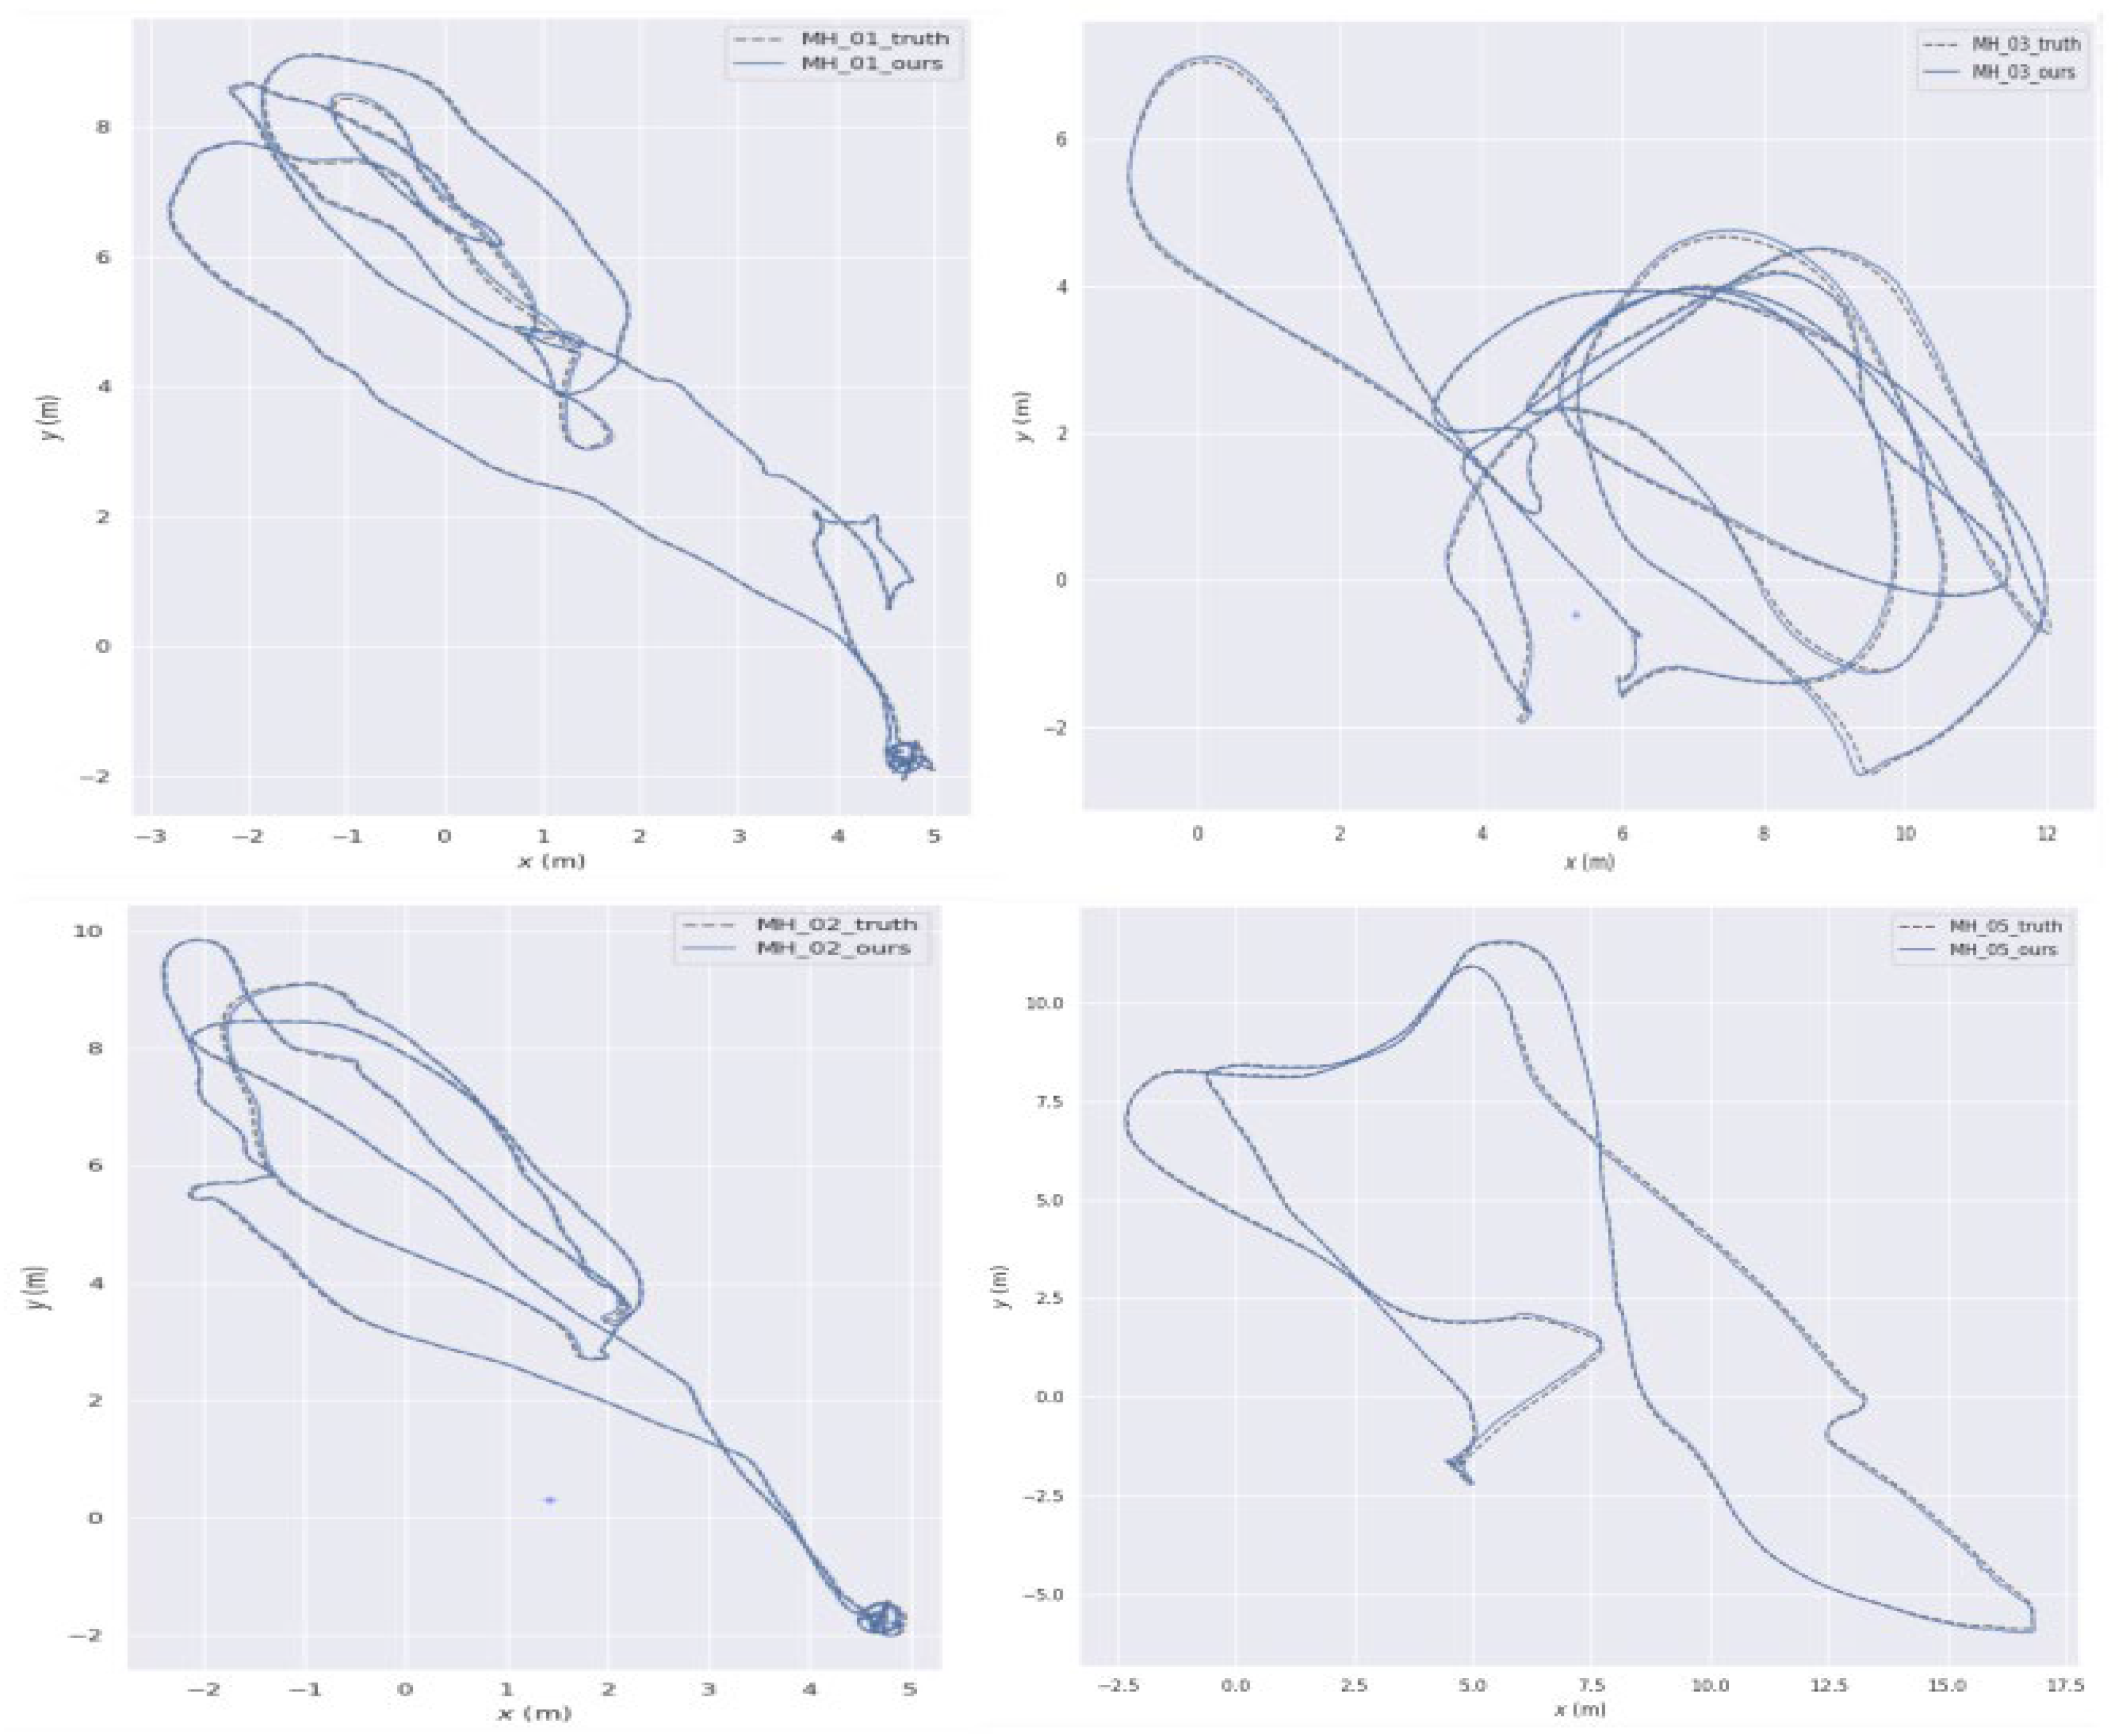
ESKF-g2o-SLAM: A Stereo Visual–Inertial SLAM with ORB Features and ESKF ...

A Robust Visual Inertial Odometry SLAM Considering Robot Self Dynamics ...

Improving Visual SLAM by Combining SVO and ORB-SLAM2 with a ...

(PDF) VIO-GO: optimizing event-based SLAM parameters for robust ...
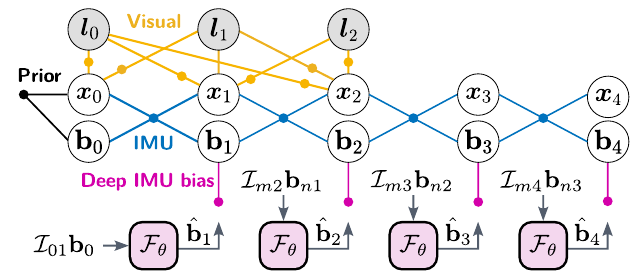
Visual Inertial SLAM (and beyond) at ICRA 2023 - Slamcore
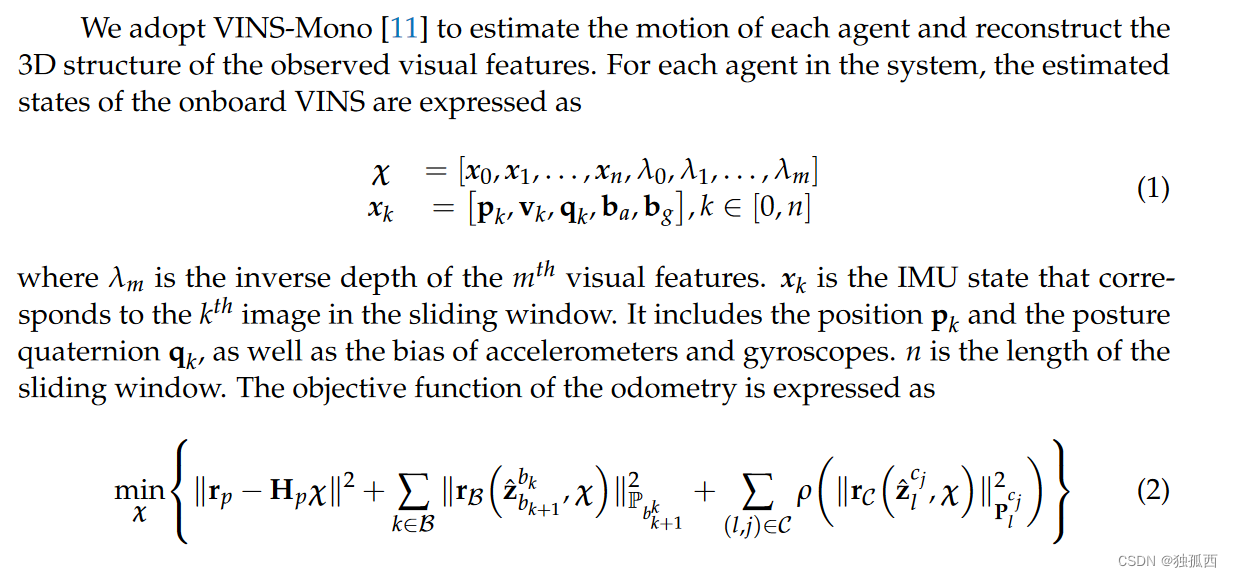
论文阅读:C2VIR-SLAM: Centralized Collaborative Visual-Inertial-Range SLAM ...
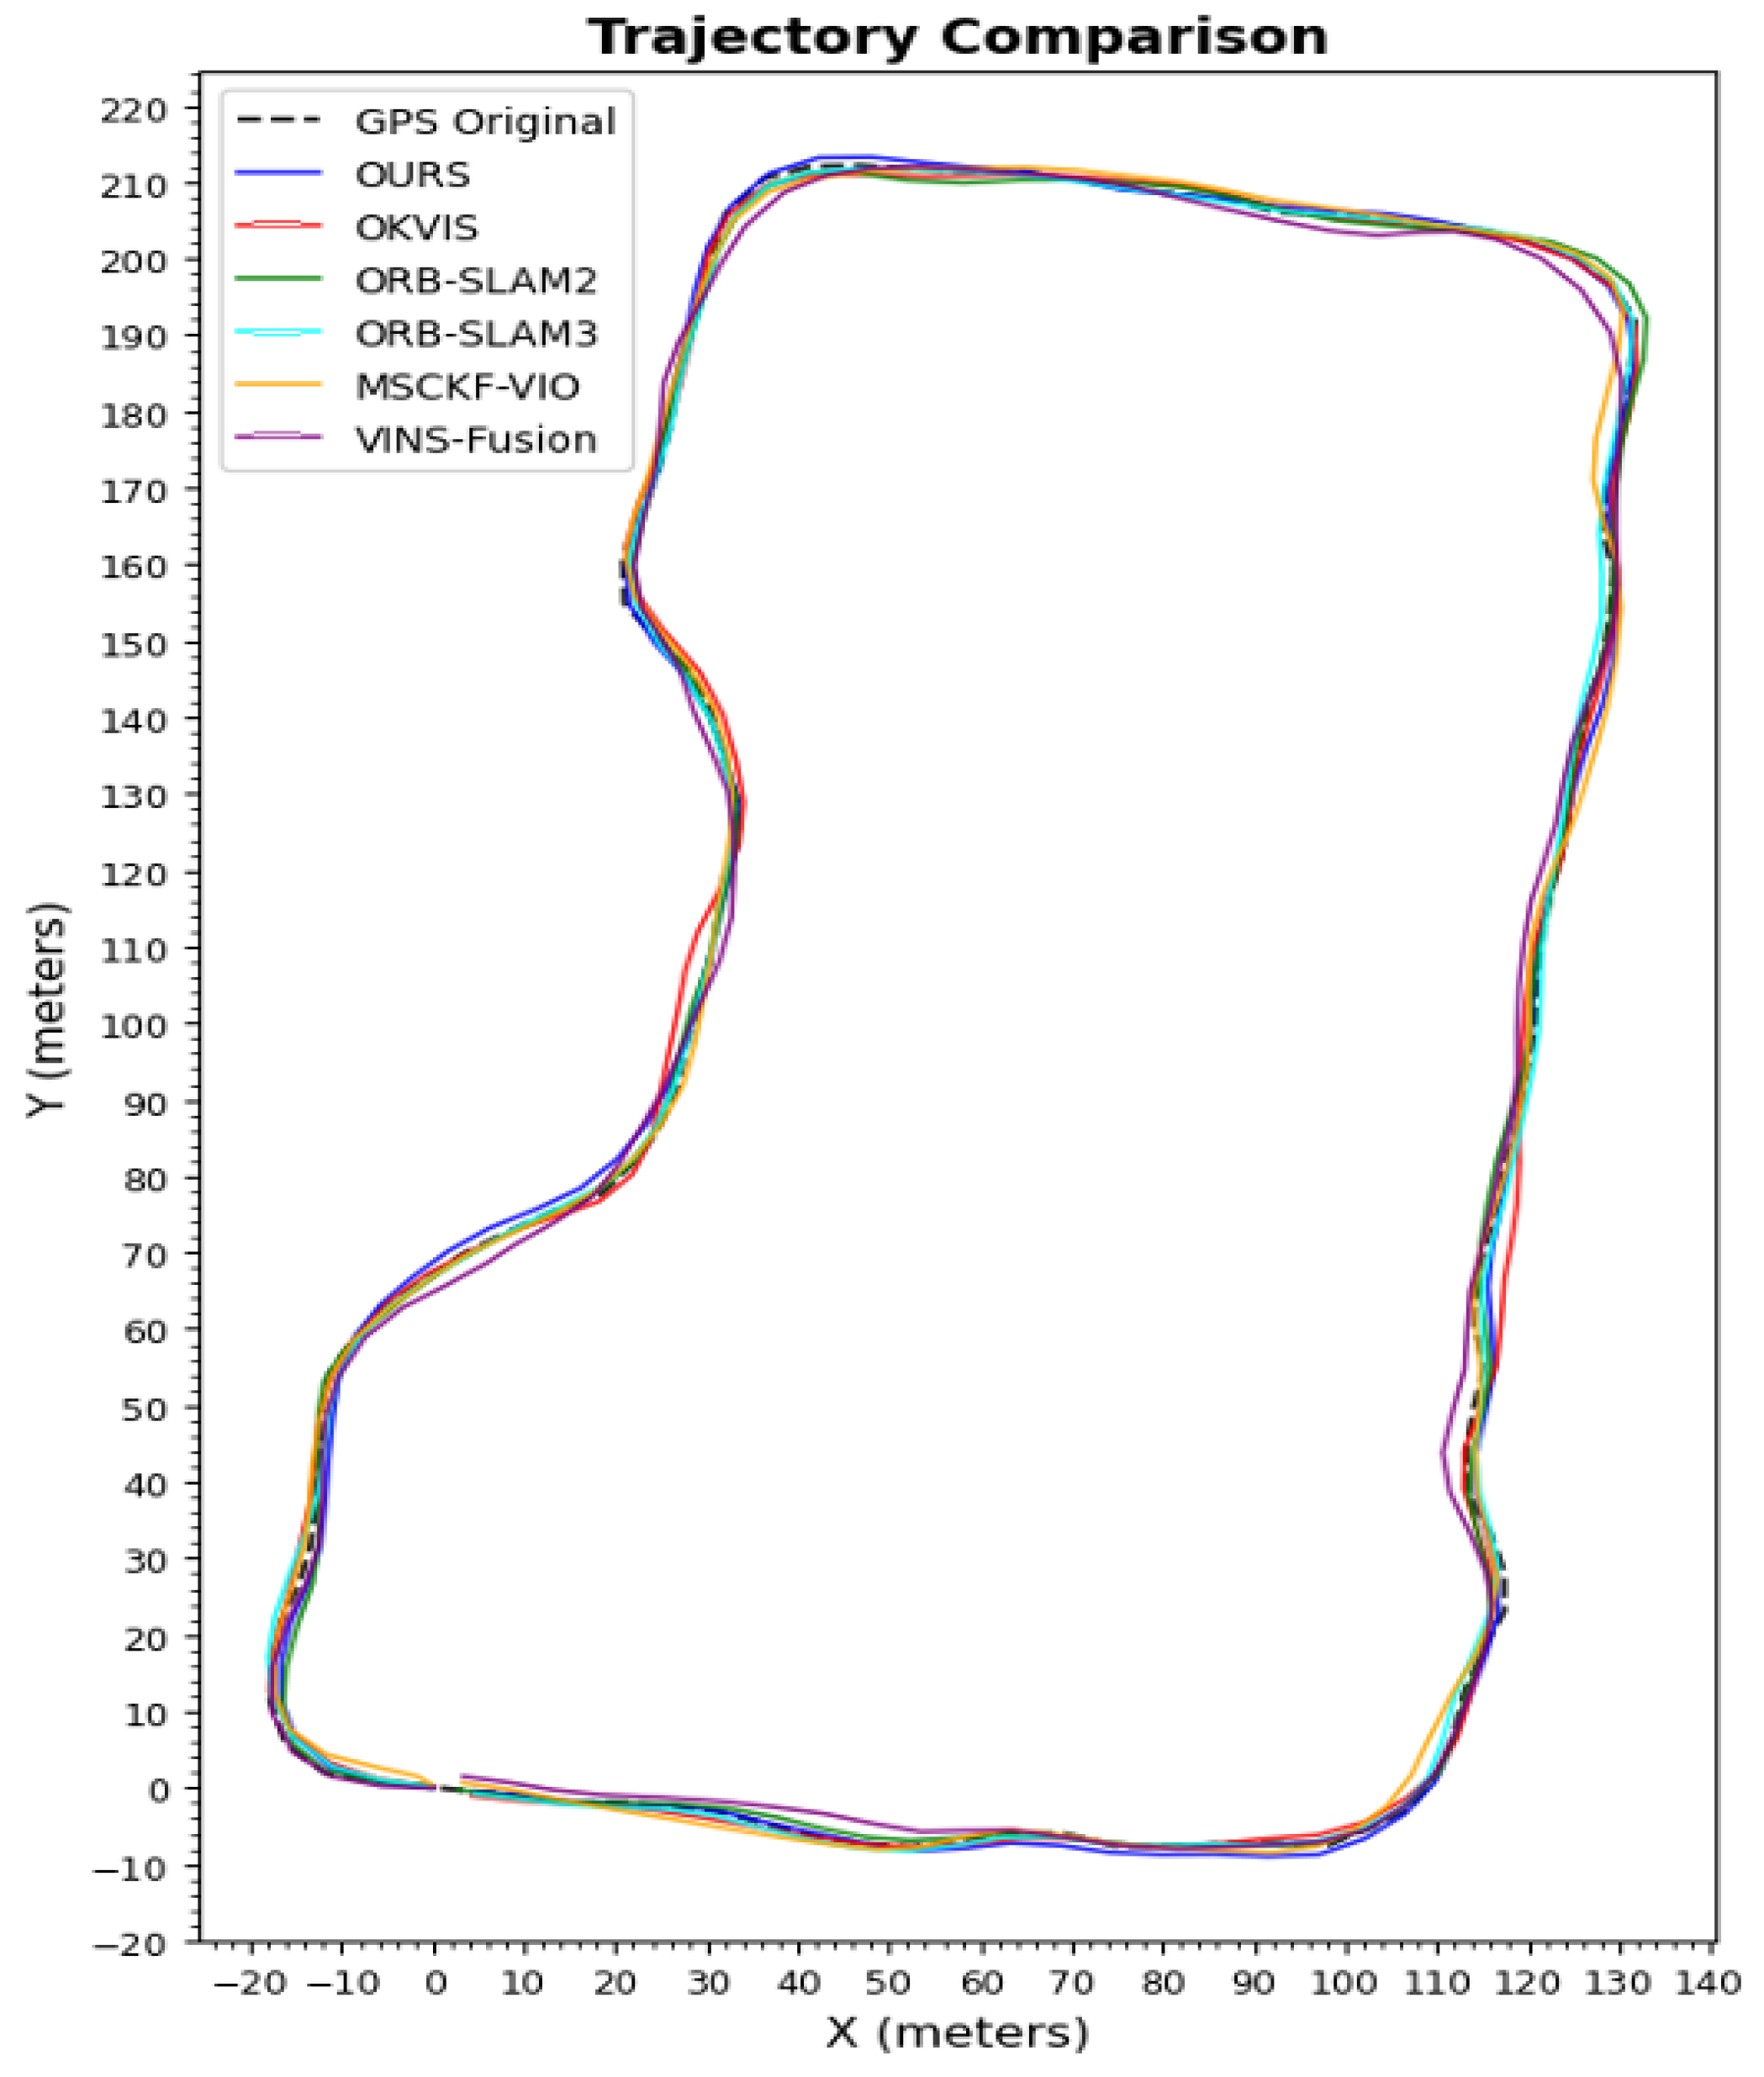
ESKF-g2o-SLAM: A Stereo Visual–Inertial SLAM with ORB Features and ESKF ...

Frames in VIO system | Download Scientific Diagram
Advertisement Space (336x280)

Visual SLAM for Unmanned Aerial Vehicles: Localization and Perception

VIO 初始化探究:旋转平移解耦的高效鲁棒初始化 - 深蓝学院 - 专注人工智能与机器人的学习平台
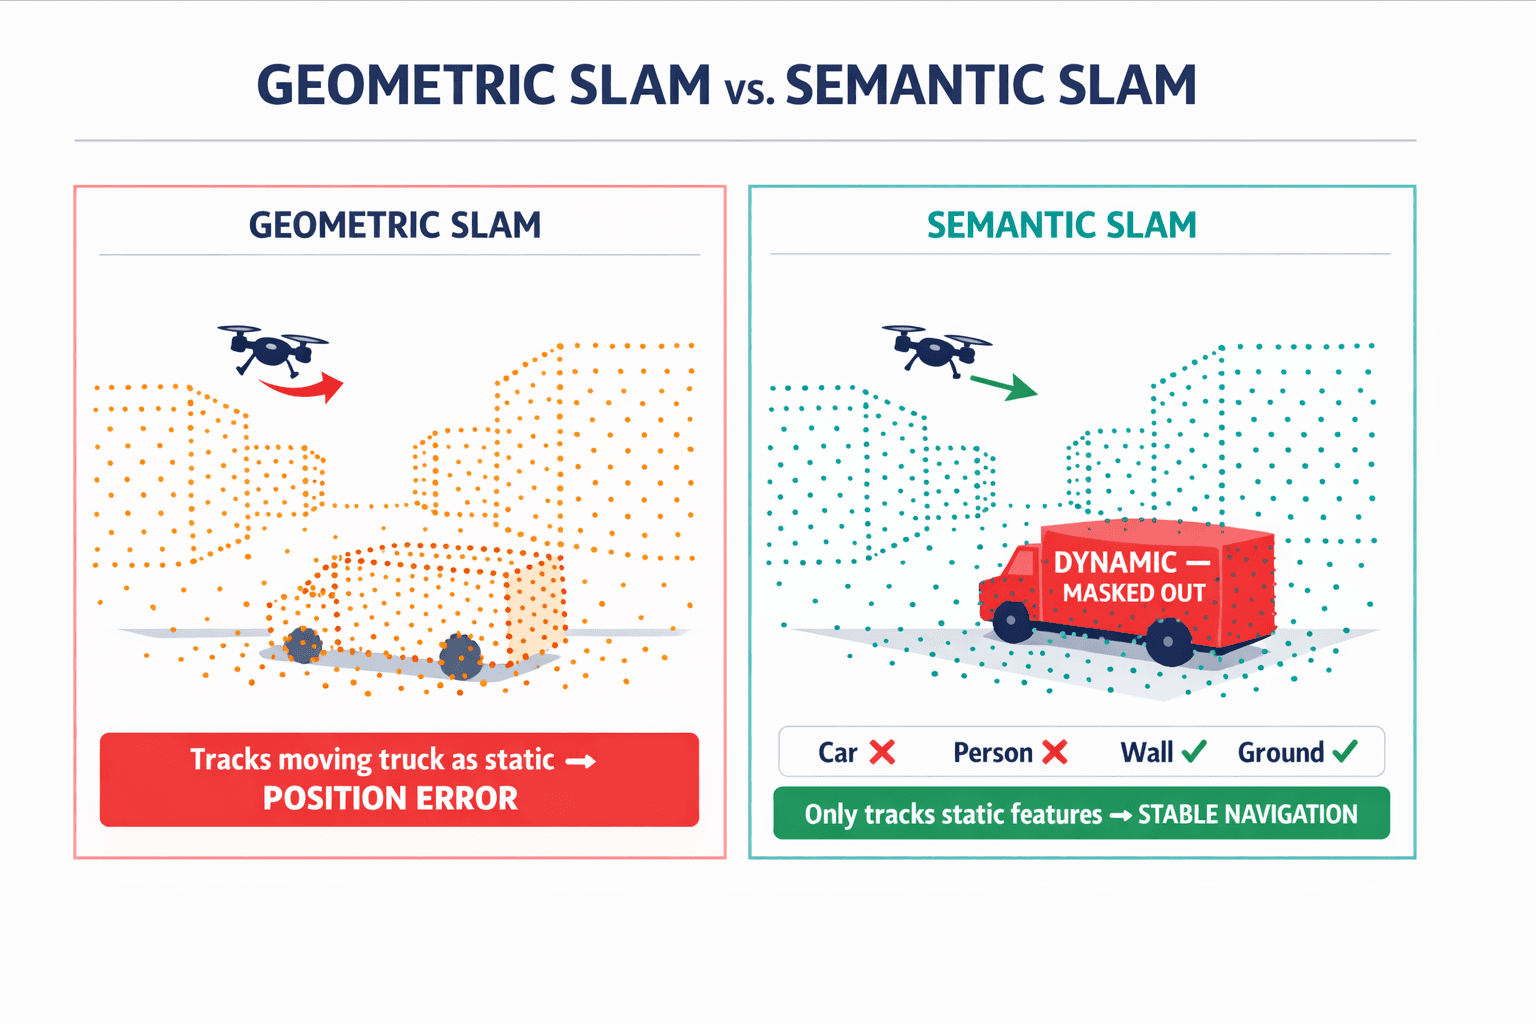
GPS-Denied Drone Navigation: Why VIO and Edge AI Are the Future
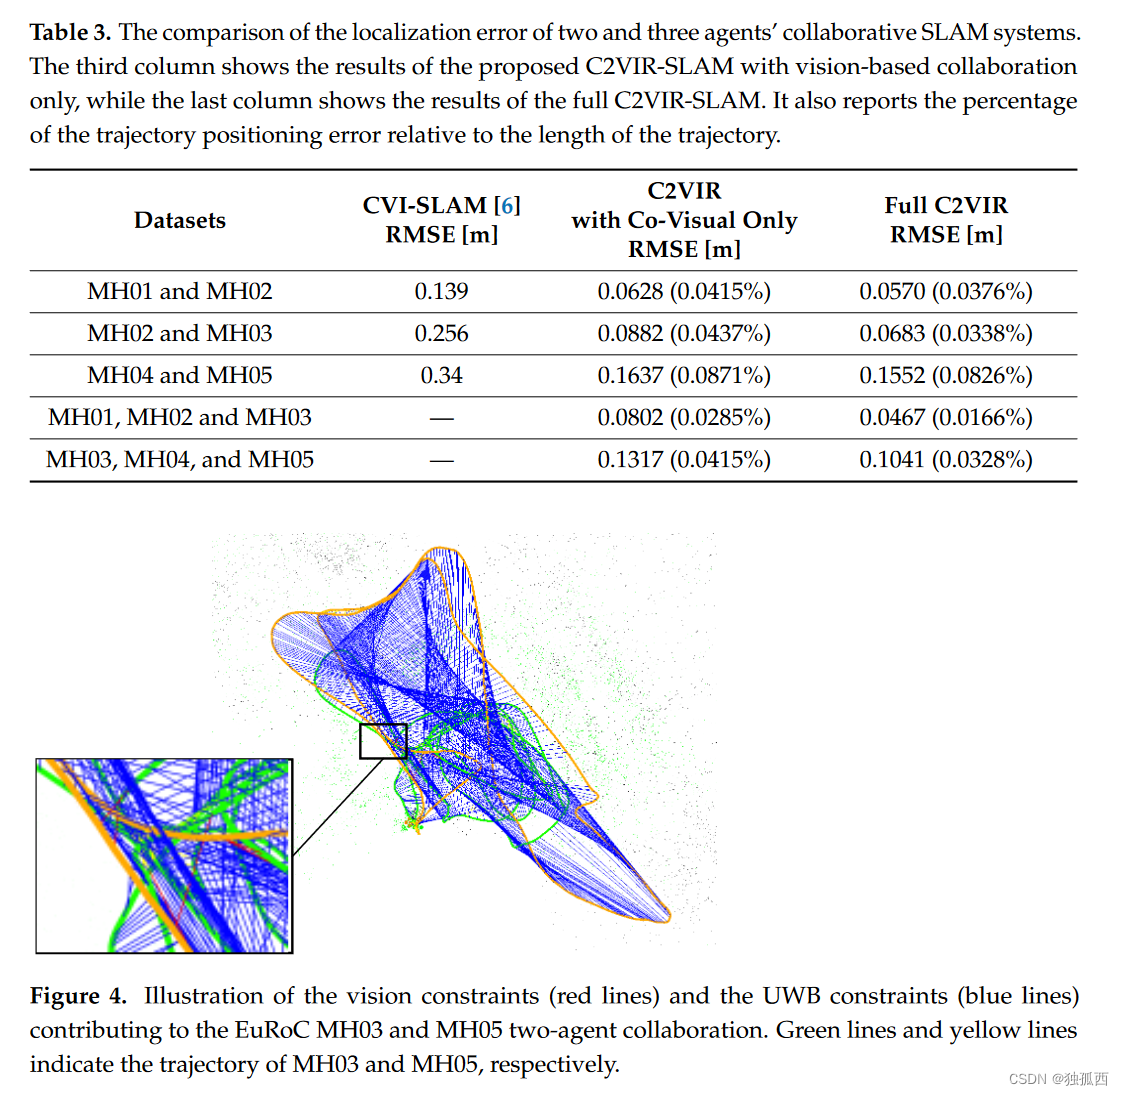
论文阅读:C2VIR-SLAM: Centralized Collaborative Visual-Inertial-Range SLAM ...

VILO SLAM: Tightly Coupled Binocular Vision–Inertia SLAM Combined with ...

VILO SLAM: Tightly Coupled Binocular Vision–Inertia SLAM Combined with ...