
A An Obstacle In A Environment Overlaid With A Grid B The Obstacle

a An obstacle in a environment overlaid with a grid. b The obstacle ...

a An obstacle in a environment overlaid with a grid. b The obstacle ...

a An obstacle in a environment overlaid with a grid. b The obstacle ...
Planning in a multiple obstacle environment with Relevant Region ...

Establishment of the grid map for the body with a complete obstacle ...

A Traversability Map with overlaid candidate arcs The Obstacle ...
The obstacle modeling in a grid map representation (The first three ...

Three grid maps with different levels of obstacle complexities: (a) a ...
The obstacles A and B are considered for shielding. Obstacle C is not ...

The obstacles A and B are considered for shielding. Obstacle C is not ...
Advertisement Space (300x250)

| (A) An indoor environment including a single room with a single ...

Visualization of our obstacle avoidance using a 3d grid map (left: real ...

A diagram showing how an obstacle is projected into a grid-discretized ...

Grid in the presence of an obstacle j in the direction of the vector d ...

Obstacle avoidance test in a complex obstacle environment: (a ...

A Predictive Guidance Obstacle Avoidance Algorithm for AUV in Unknown ...

Obstacle avoidance test in a complex obstacle environment: (a ...

Obstacle avoidance test in a complex obstacle environment: (a ...

Squared grid overlaid on a polygonal environment: Red (dark) squares ...
a A one-obstacle environment. b Augmented obstacles due to the cables ...
Advertisement Space (336x280)

A circle grid-based approach for obstacle avoidance motion planning of ...

Get a obstacle avoidance path base on a grid-based map and non-grid ...

A Circle Grid-based Approach for Obstacle Avoidance Motion Planning of ...

Analysis of the grid with single obstacle for five different approaches ...

An environment with an obstacle represented as an ellipse. For that ...
Dynamic obstacle avoidance: (a) Environment A, (b) Environment B ...

Two kinds of grid traps. (a) The obstacle grid is between the robot ...

Two kinds of grid traps. (a) The obstacle grid is between the robot ...

Planning results for a single-obstacle grid map: (a) planning results ...
Obstacle grid map, the obstacle moves to its around 9 directions ...
Advertisement Space (336x280)

Dynamic obstacle avoidance: (a) Environment A, (b) Environment B ...
Simulated environment: (a) without obstacle; (b) with an obstacle ...

Two kinds of grid traps. (a) The obstacle grid is between the robot ...

An example combined obstacle overlay with no-go forests (green), no-go ...
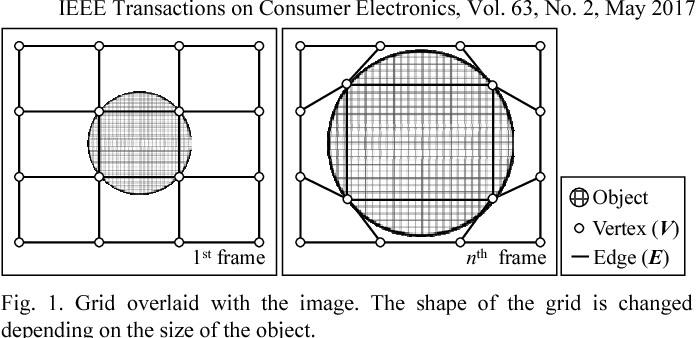
Figure 1 from An enhanced obstacle avoidance method for the visually ...