
A The Optimal Path From Start To Finish With Two Obstacles B The

a The optimal path from start to finish with two obstacles. b The ...

a The optimal path from start to finish with two obstacles. b The ...

a The optimal path from start to finish with two obstacles. b The ...

a The optimal path from start to finish with two obstacles. b The ...

a The path from start to finish with one obstacle. b The optimal path ...

a The possible path from start to finish with three obstacles. b The ...

Find the magnitude of the displacement from start to finish for path B ...

Find the displacement from start to finish for path A in the figure ...

A room with two obstacles; 1 – the desired path for the robot to ...
(a) Optimal path found by the algorithm after one or two epochs with β ...
Advertisement Space (300x250)

a The optimal points. b The optimal path without obstacles. c The ...
(a)-(d) show the optimal path between two points without obstacles (see ...

Curved dashed line from A to B start and finish points and direction ...

P2. Finding the path from start to end

Two approaches for getting from A to B, around obstacle O. On the left ...

a The optimal points. b The optimal path without obstacles. c The ...

(a) Real-time Path Speed Profile of the Robot with Two Obstacles using ...

The optimal trajectory with (left) one obstacle and (right) two ...

An Algorithm to Find the Shortest Path through Obstacles of Arbitrary ...

Optimal path with the ABC algorithm and the IABC algorithm: (a) optimal ...
Advertisement Space (336x280)
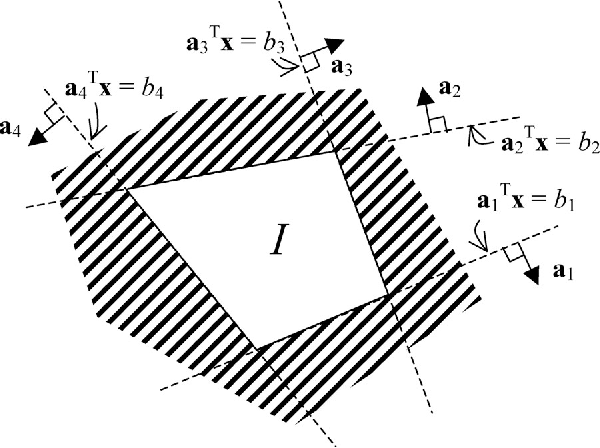
Figure 1 from Chance-Constrained Optimal Path Planning With Obstacles ...

It is possible that the optimal path crosses a line more than once ...
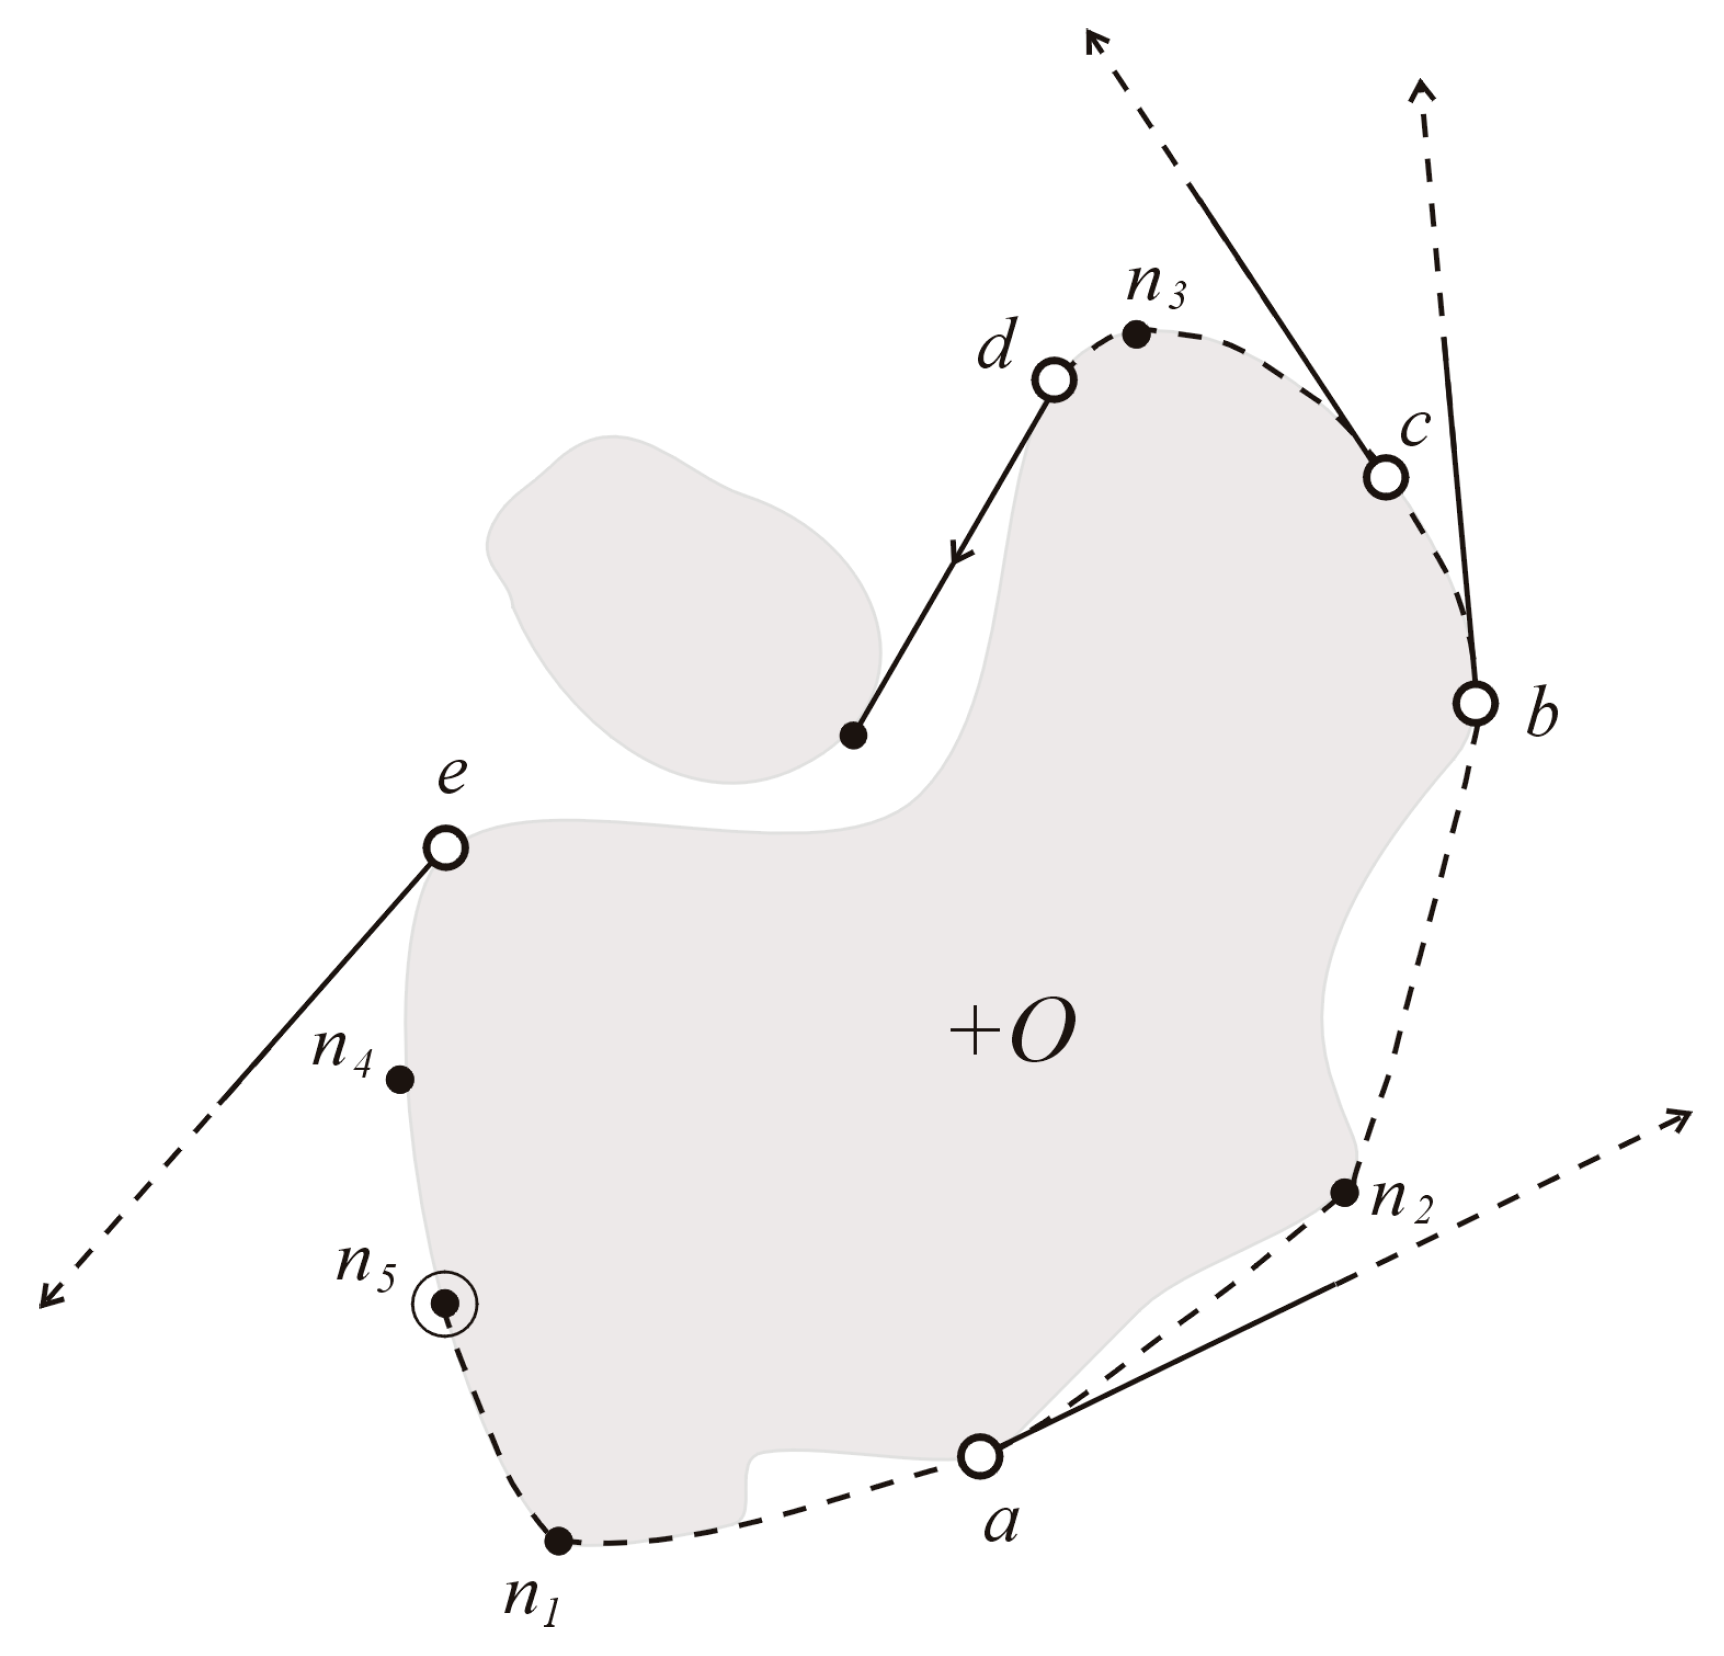
An Algorithm to Find the Shortest Path through Obstacles of Arbitrary ...
The optimal path results with different targets: (a) the shortest ...

Time optimal path on a plane in the presence of a square obstacle that ...

Selecting obstacle groups with respect to the start and target location ...

The optimal trajectory with (left) one obstacle and (right) two ...

An Algorithm to Find the Shortest Path through Obstacles of Arbitrary ...

An Algorithm to Find the Shortest Path through Obstacles of Arbitrary ...

The planned path when facing seven static obstacles and two moving ...
Advertisement Space (336x280)

Prediction process of the optimal path under the two cases. | Download ...

Optimal path with obstacles on reference trajectory | Download ...

2Approximate optimal trajectory with two moving obstacles for Example 6 ...

Construction of approximate optimal path between two points with ...

PPT - Optimal Path Planning Using the Minimum-Time Criterion by James ...