
An Input Intensity Image R Left And The Point Cloud P Where The

An input intensity image R (left) and the point cloud P , where the ...

An input intensity image R (left) and the point cloud P , where the ...

An input intensity image R (left) and the point cloud P , where the ...

An input intensity image R (left) and the point cloud P , where the ...

Example of input data and point cloud (left: RGB image from the real ...

Example of input data and point cloud (left: RGB image from the real ...

Point cloud input on the left and the resulting smooth shaded ...

Example of input data and point cloud (left: RGB image from the real ...

Point cloud intensity image (a) The first monitoring, (b) The second ...
The pipeline of our system. Raw input point cloud P is input to ...
Advertisement Space (300x250)

The pipeline of our system. Raw input point cloud P is input to ...

The rotation network transforms the input point cloud P raw to bring it ...

(a) Vertically integrated intensity for an R input condition at the ...

Comparison of an RGB image (a) and the intensity image from the LiDAR ...

The input intensity image and the associated ground truth range. Since ...

4 Column approximation for the image intensity at point P at the ...

The input intensity image and the associated ground truth range. Since ...

The intensity coloured point cloud and the front view of the river ...

(a) Given the input point cloud (left), our target is to estimate a ...

The input point cloud (a) from the previous steps is processed to ...
Advertisement Space (336x280)

(a) Given the input point cloud (left), our target is to estimate a ...

Intensity (a) and phase (b) of the input field l ( θ ) for generating a ...

Left: Relation between the output intensity and the input intensity at ...

The plot of the output and input intensity relationship using Fig. 2a ...

Overview of the method. The input consists of a point cloud with two ...

Overview of the method. The input consists of a point cloud with two ...

Left: Relation between the output intensity and the input intensity at ...
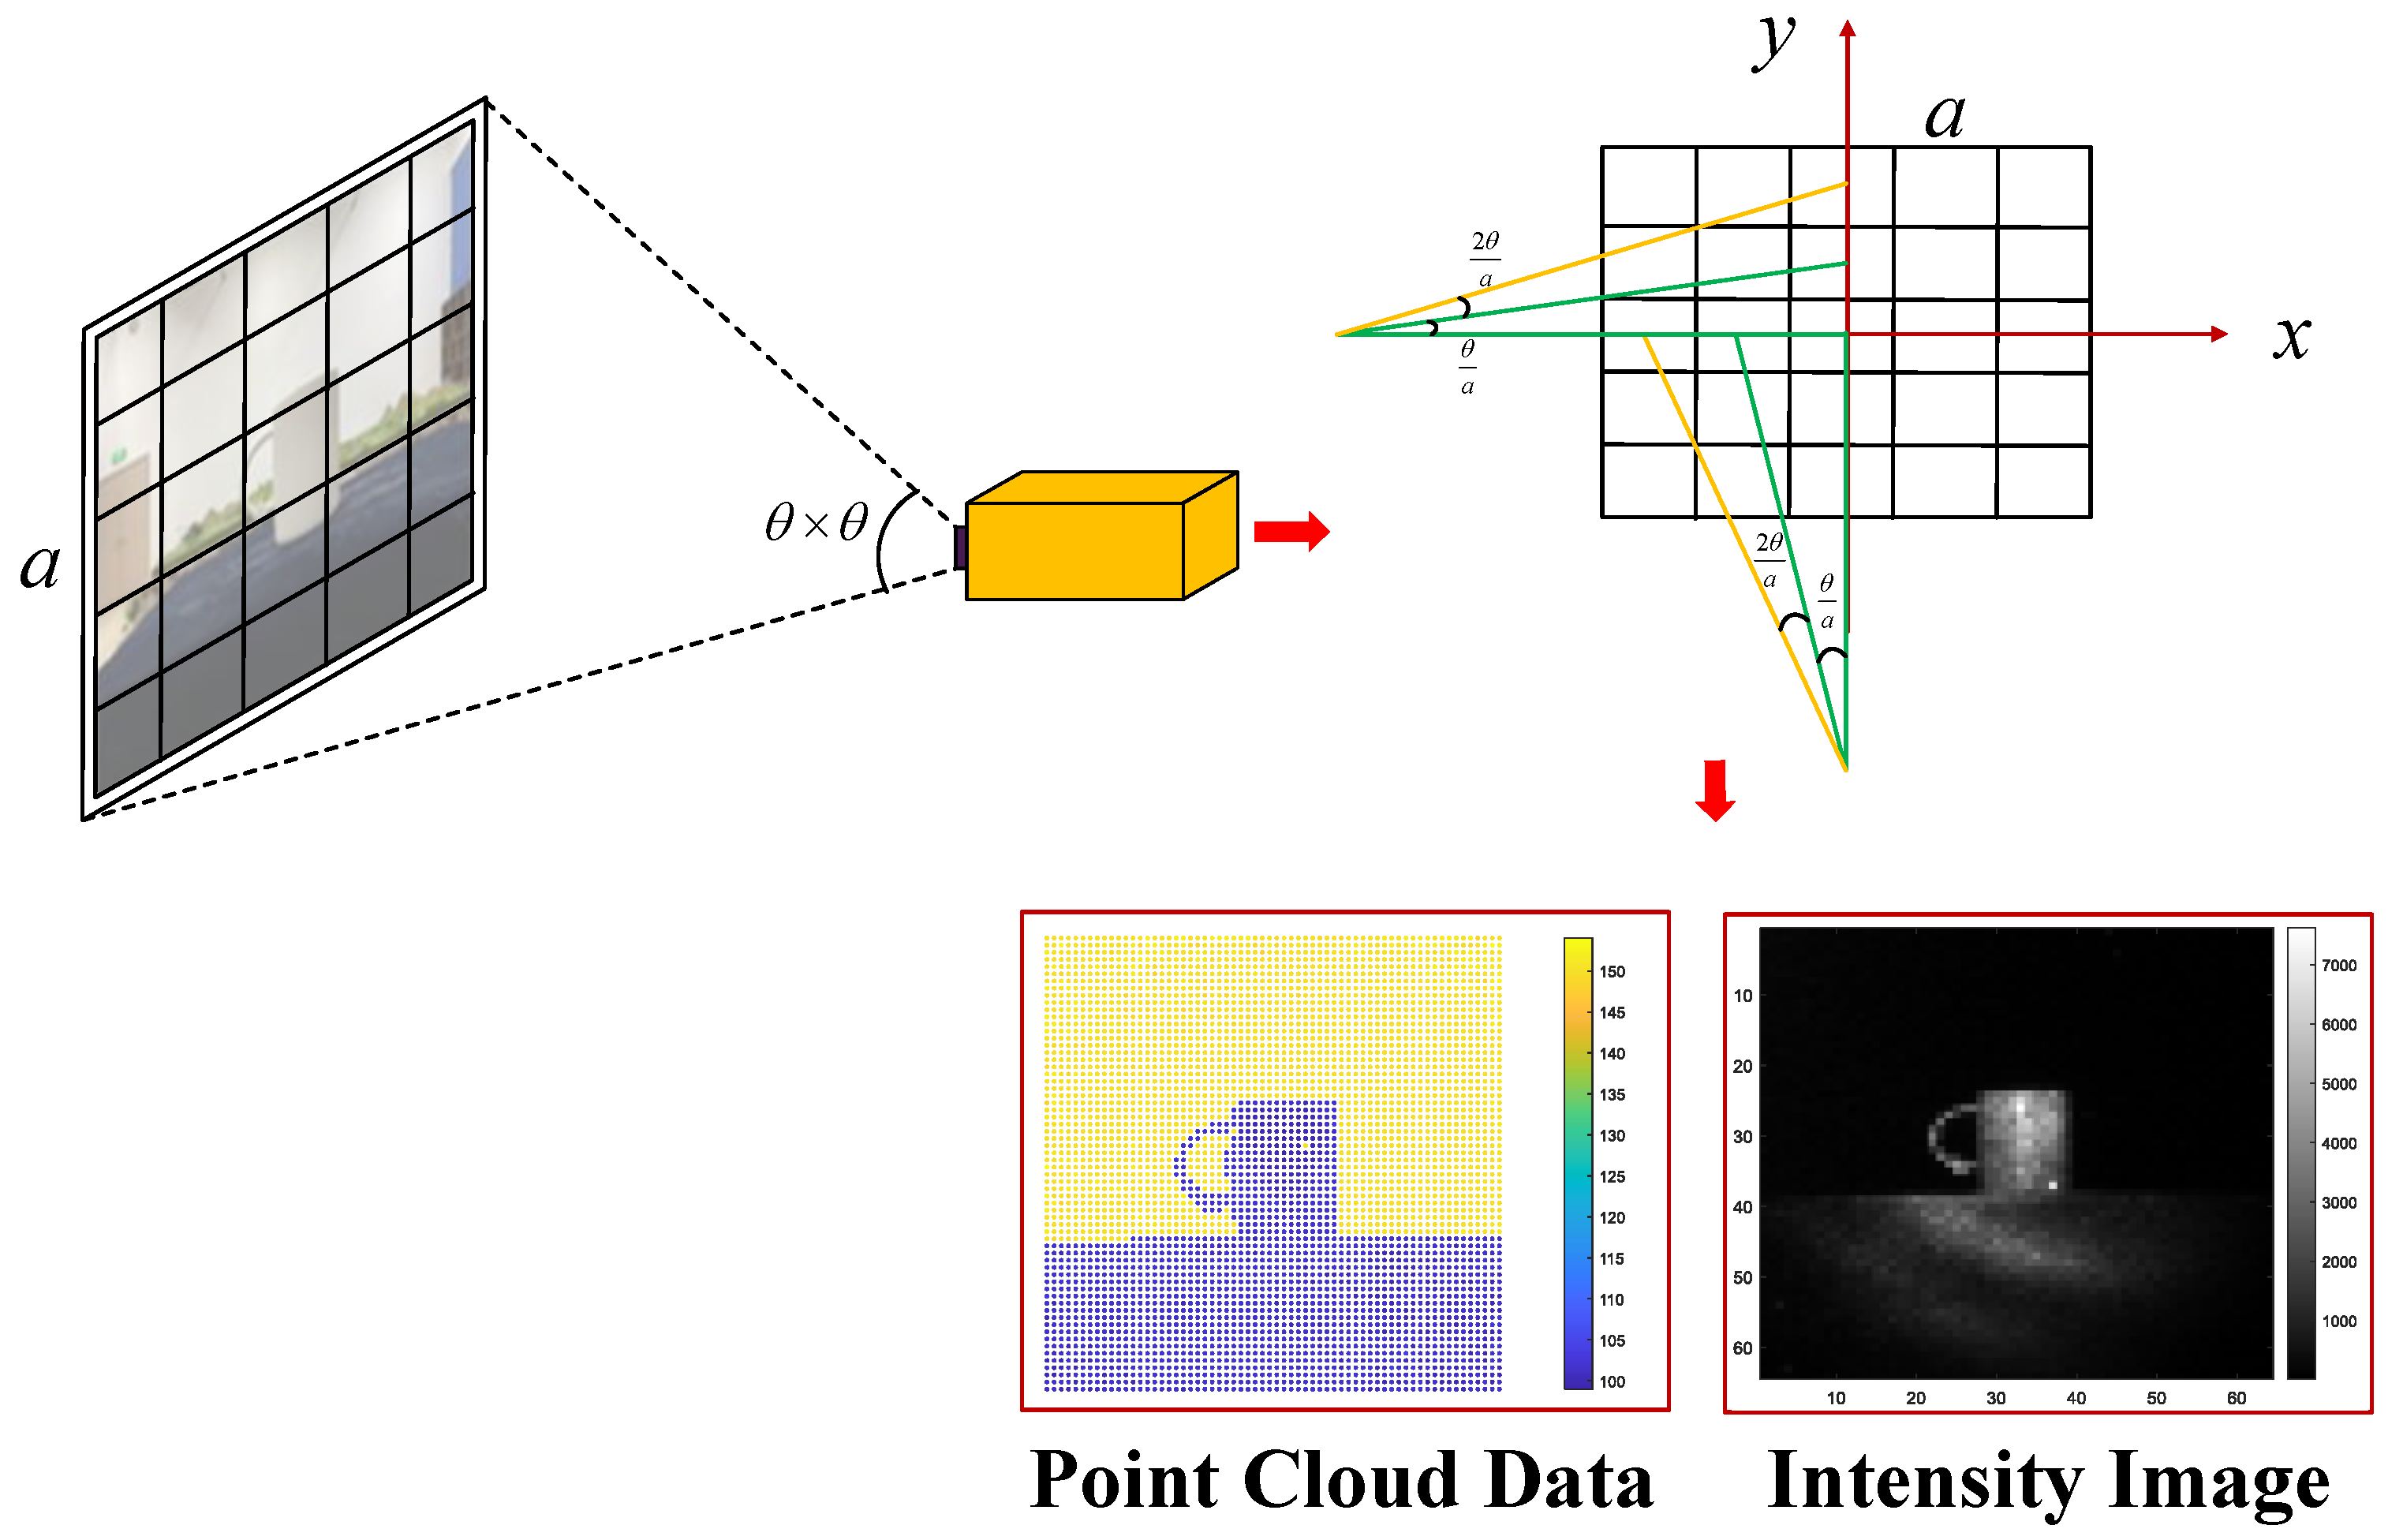
LiDAR Point Cloud Object Recognition Method via Intensity Image ...

LiDAR Point Cloud Object Recognition Method via Intensity Image ...

LiDAR Point Cloud Object Recognition Method via Intensity Image ...
Advertisement Space (336x280)

Object coordinate system and intensity coded point cloud before (left ...

Input point cloud (left) and ROS visualization (right) of detected ...

Intensity image (Left) and superimposed point clouds (Right) Figure 3 ...

Four intensity distributions (I H , I P , I R , I L ) of specific input ...

Key steps of extracting point cloud process. From left to right: input ...

Input point cloud (left) and ROS visualization (right) of detected ...