
Experiment Setup Consists Of Two Parts A Robotic Grasping System For

Experiment setup consists of two parts: a Robotic grasping system for ...

The grasping experiment of robotic arm system on a mobile platform ...

Ship sheet grasping system. The grasp system consists of a robot with a ...

Experiment setting: the setup is a grasping metal setting.We use the ...

(a) The overall grasping system setup. A group of household items are ...

Experiment setting: the setup is a grasping metal setting.We use the ...

The hardware setup of the robotic grasping experiment. | Download ...

A Hyperspectral Imaging Guided Robotic Grasping System

The coordinate systems of the robotic intelligent grasping system ...

(a) An experiment on the grasping objects using a robotic gripper and ...
Advertisement Space (300x250)

A Light-Weight Grasping Pose Estimation Method for Mobile Robotic Arms ...
= Pipeline of the task-oriented robotic grasping experiment using our ...
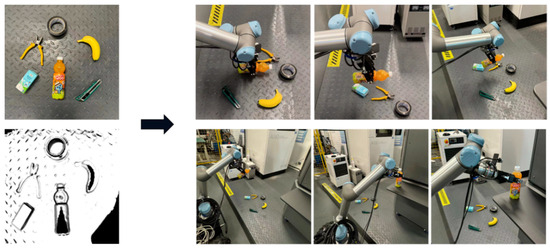
A Light-Weight Grasping Pose Estimation Method for Mobile Robotic Arms ...

A Robotic Arm Grasping System Based on Computer Vision and Brain ...

A Vision-Driven Collaborative Robotic Grasping System Tele-Operated by ...

(a) The overall grasping system setup. A group of household items are ...

A Systematic Approach to Stable Grasping of a Two-Finger Robotic Hand ...

A Robotic Arm Grasping System Based on Computer Vision and Brain ...

Design and Implementation of a Multi-Function Gripper for Grasping ...
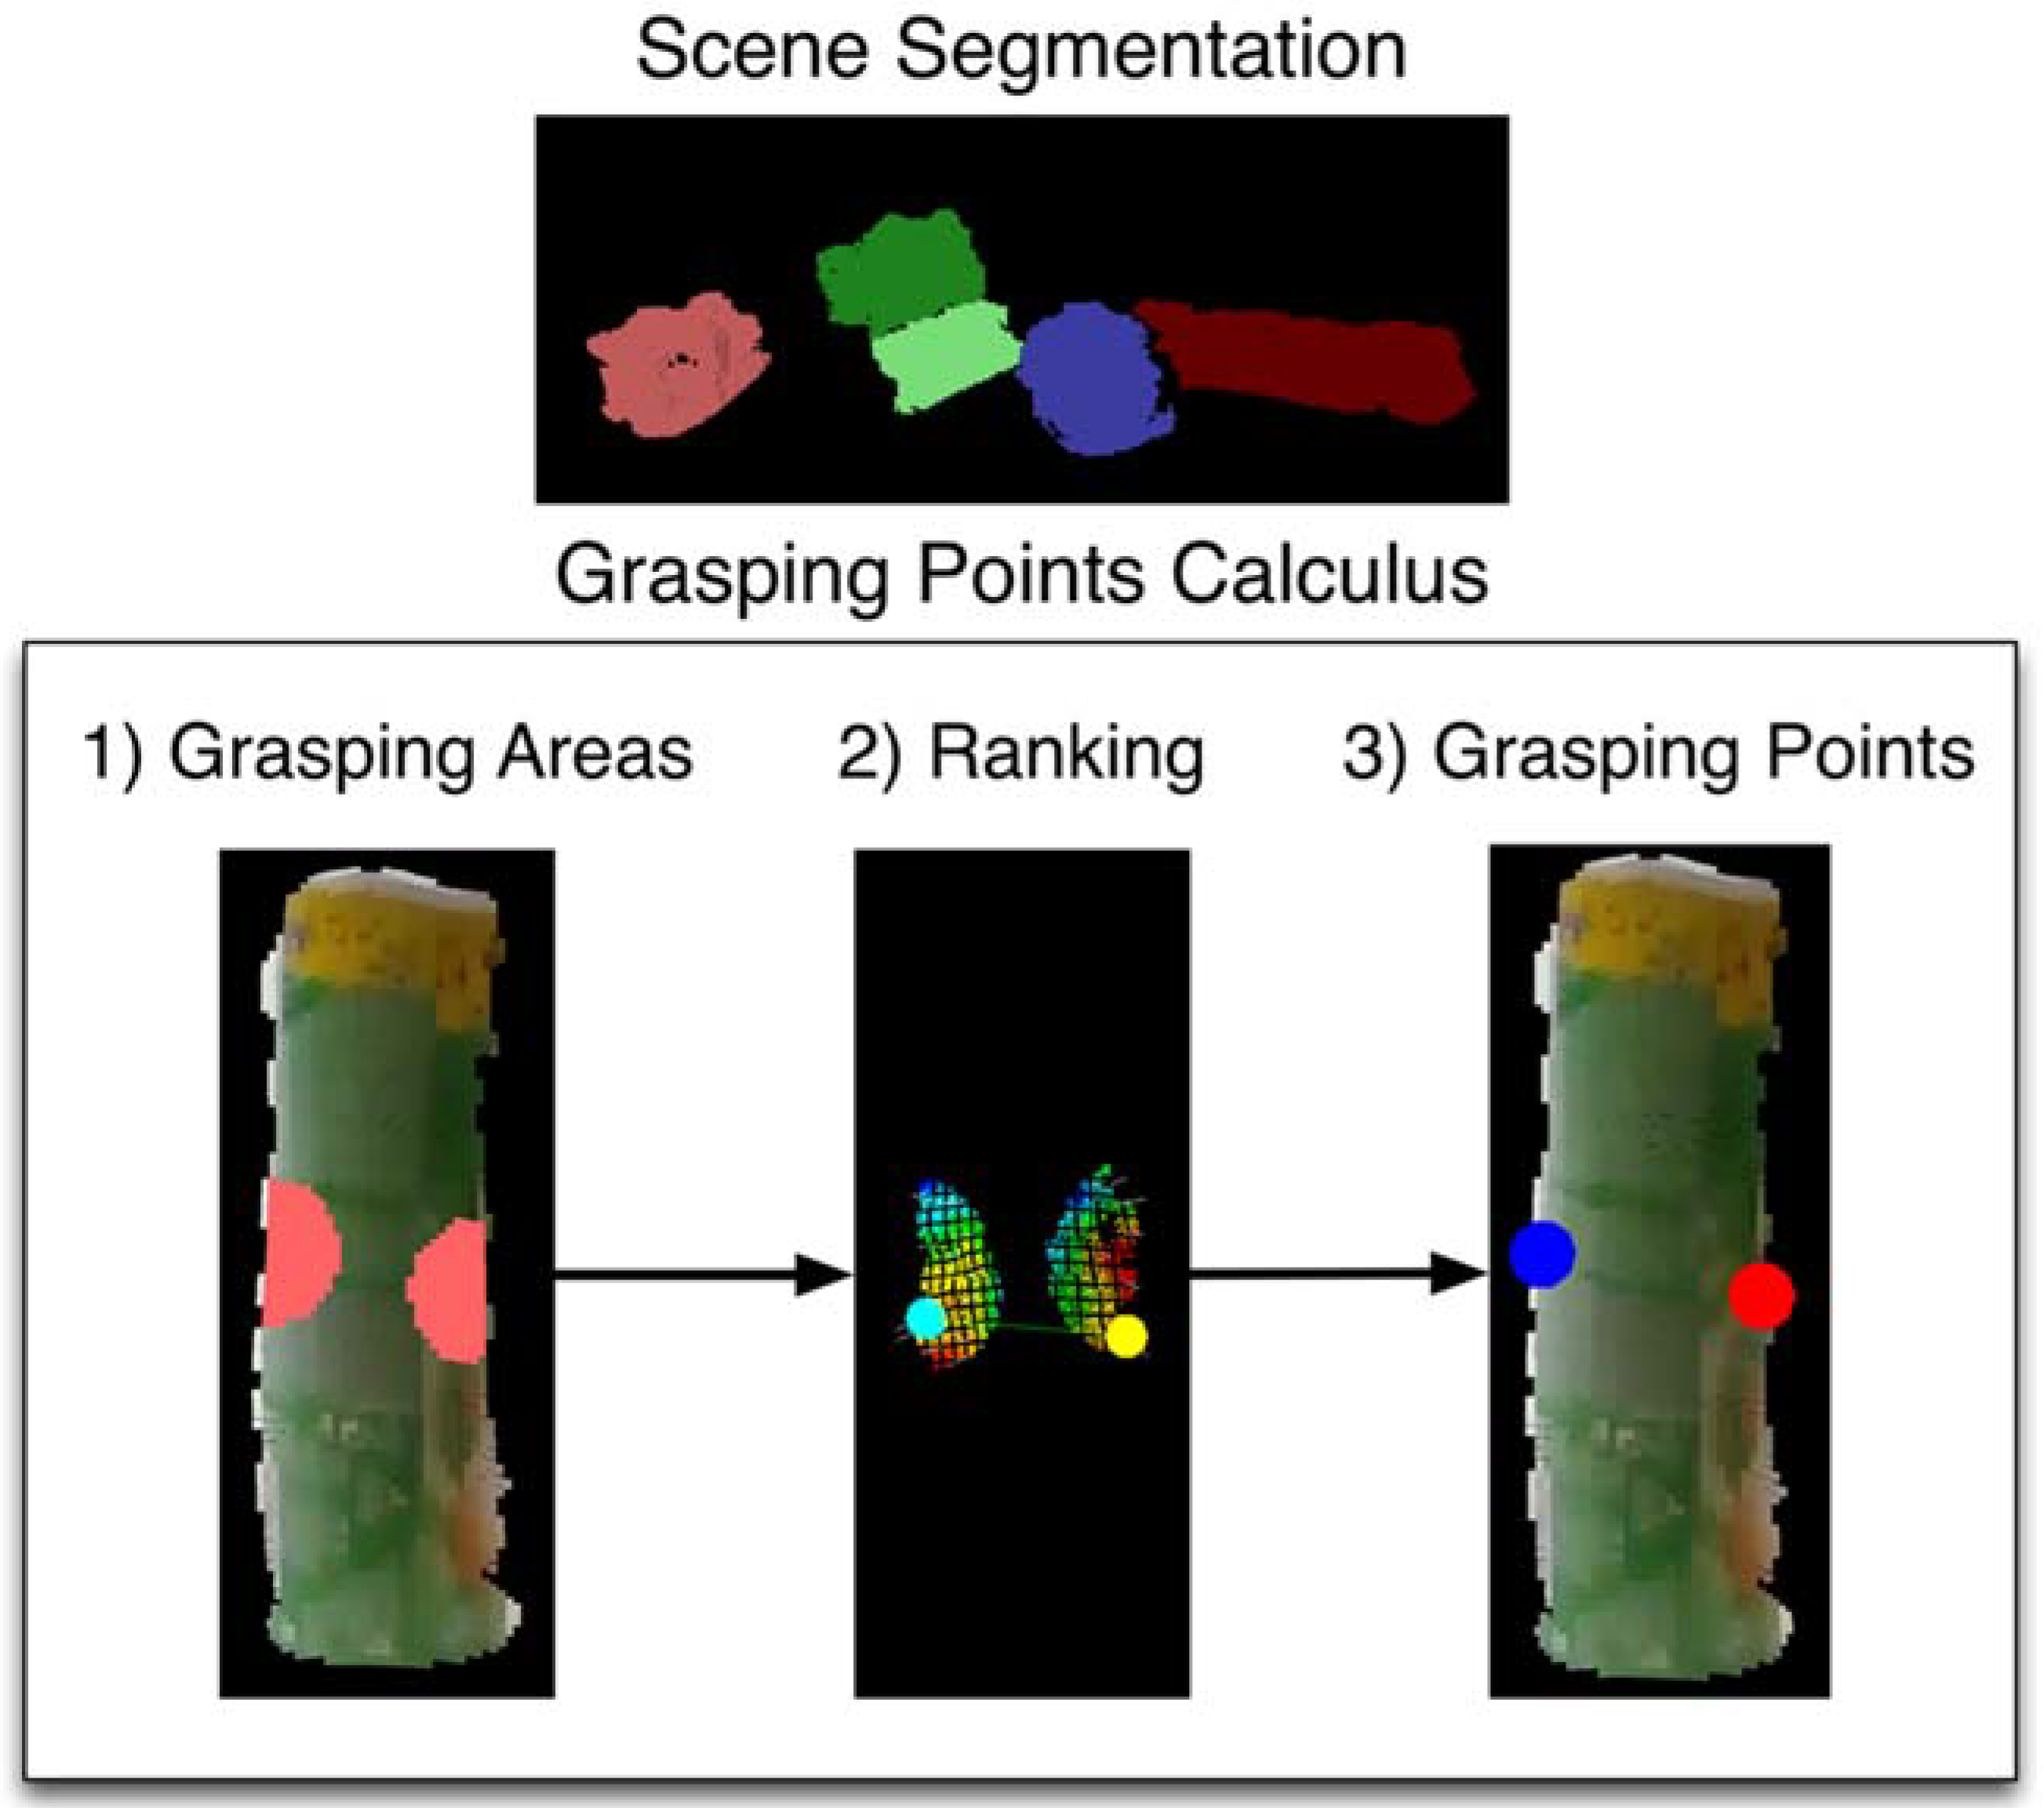
A Vision-Driven Collaborative Robotic Grasping System Tele-Operated by ...
Advertisement Space (336x280)

A Hyperspectral Imaging Guided Robotic Grasping System

The automatic robotic grasping system with a six degree-of-freedom ...

The automatic robotic grasping system with a six degree-of-freedom ...

Experimental setup for robot intelligent grasping system. | Download ...
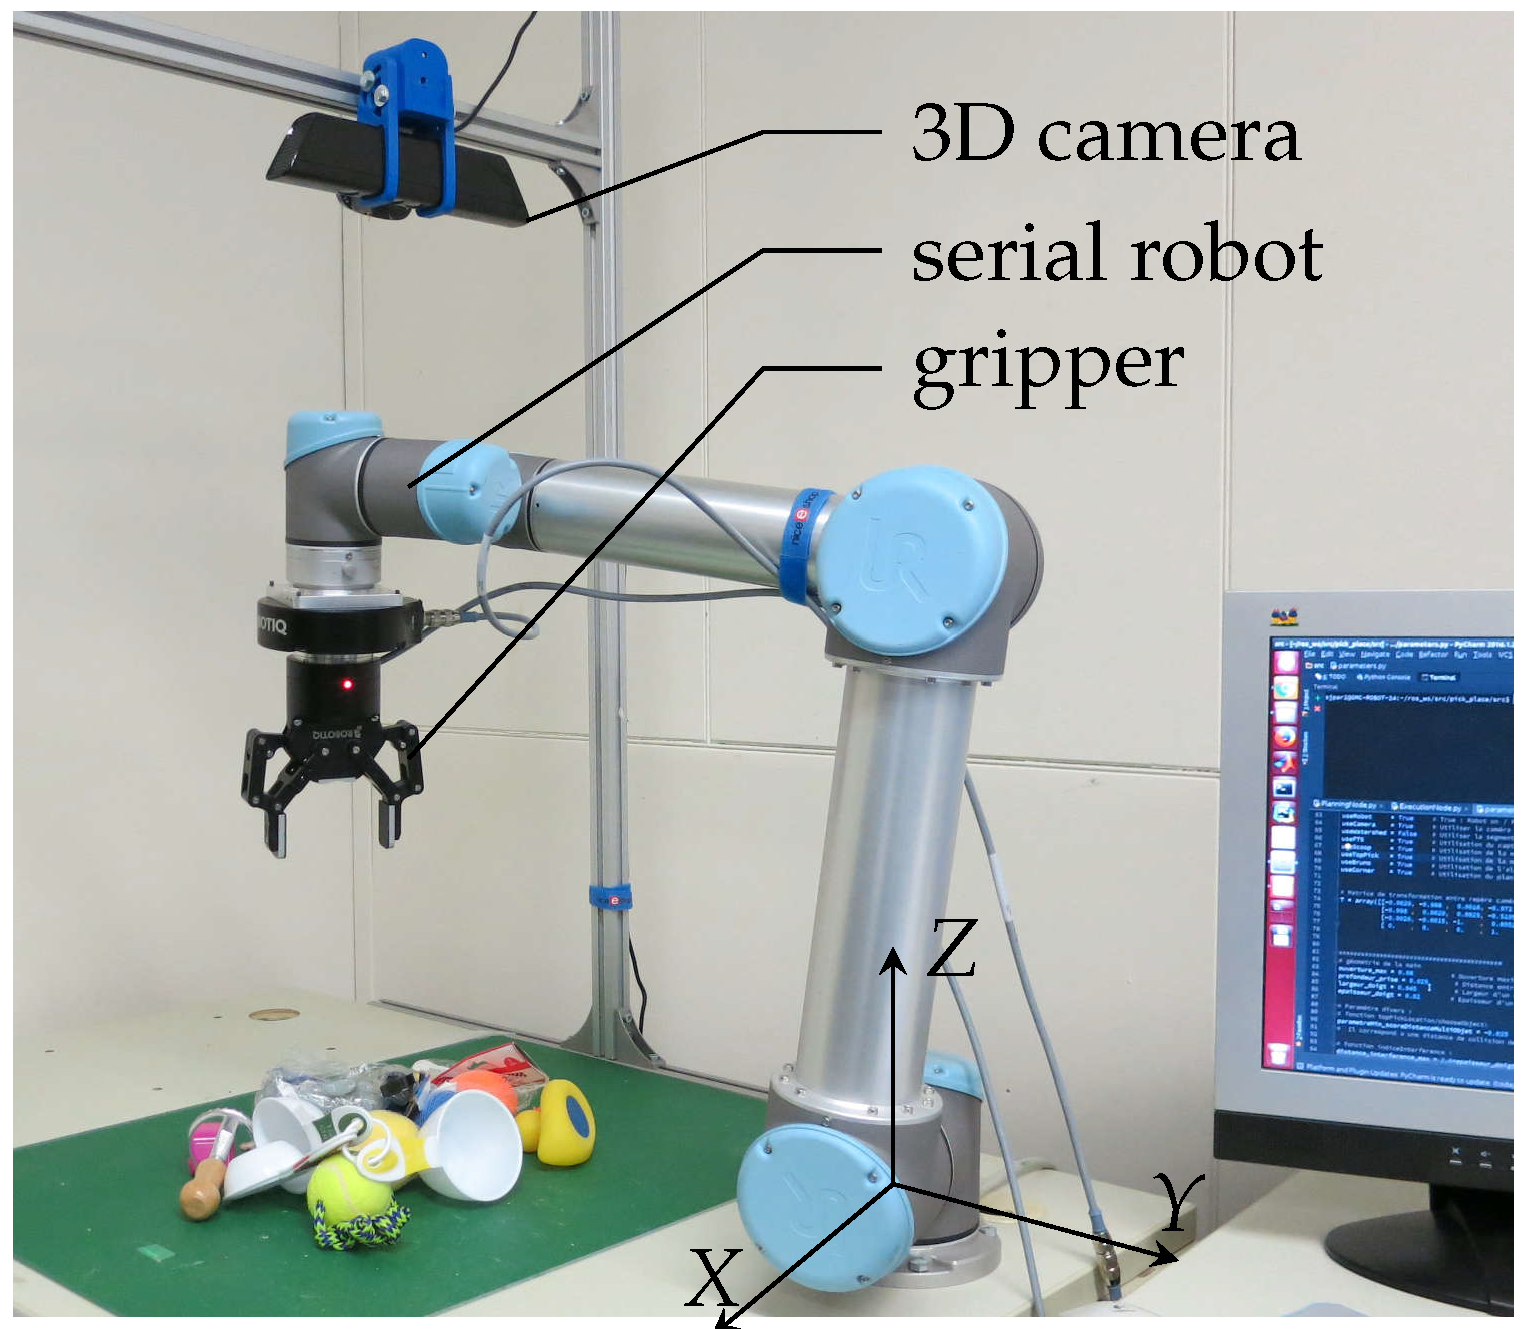
Model-Based Grasping of Unknown Objects from a Random Pile

HTC-Grasp: A Hybrid Transformer-CNN Architecture for Robotic Grasp ...

Demonstration of our robotic grasping experimental set-up. The robot ...

Design and experimental investigation of the grasping system of an ...
Experimental setup for robotic hand grasp, manipulation, and computer ...

A robotic grasping approach with elliptical cone-based potential fields ...
Advertisement Space (336x280)

Evaluation of different robotic grippers for simultaneous multi-object ...

a) The two‐finger robotic hand for object grasping proposed in Calandra ...

Cascaded Feature Fusion Grasping Network for Real-Time Robotic Systems

Grasping function of the mobile robot. (a) Mobile grasping robotic ...

Robotic grasping experiment on scenes. The robot is asked to grasp ...

Experimental setup of the grasping tests: The object was placed 15 cm ...