
Figure 1 From Bev Slam Building A Globally Consistent World Map Using

Figure 1 from BEV-SLAM: Building a Globally-Consistent World Map Using ...

Figure 2 from BEV-SLAM: Building a Globally-Consistent World Map Using ...

Figure 4 from BEV-SLAM: Building a Globally-Consistent World Map Using ...

Figure 3 from BEV-SLAM: Building a Globally-Consistent World Map Using ...

Figure 1 from A robust SLAM algorithm using hybrid map approach ...

Table IV from BEV-SLAM: Building a Globally-Consistent World Map Using ...

Table II from BEV-SLAM: Building a Globally-Consistent World Map Using ...
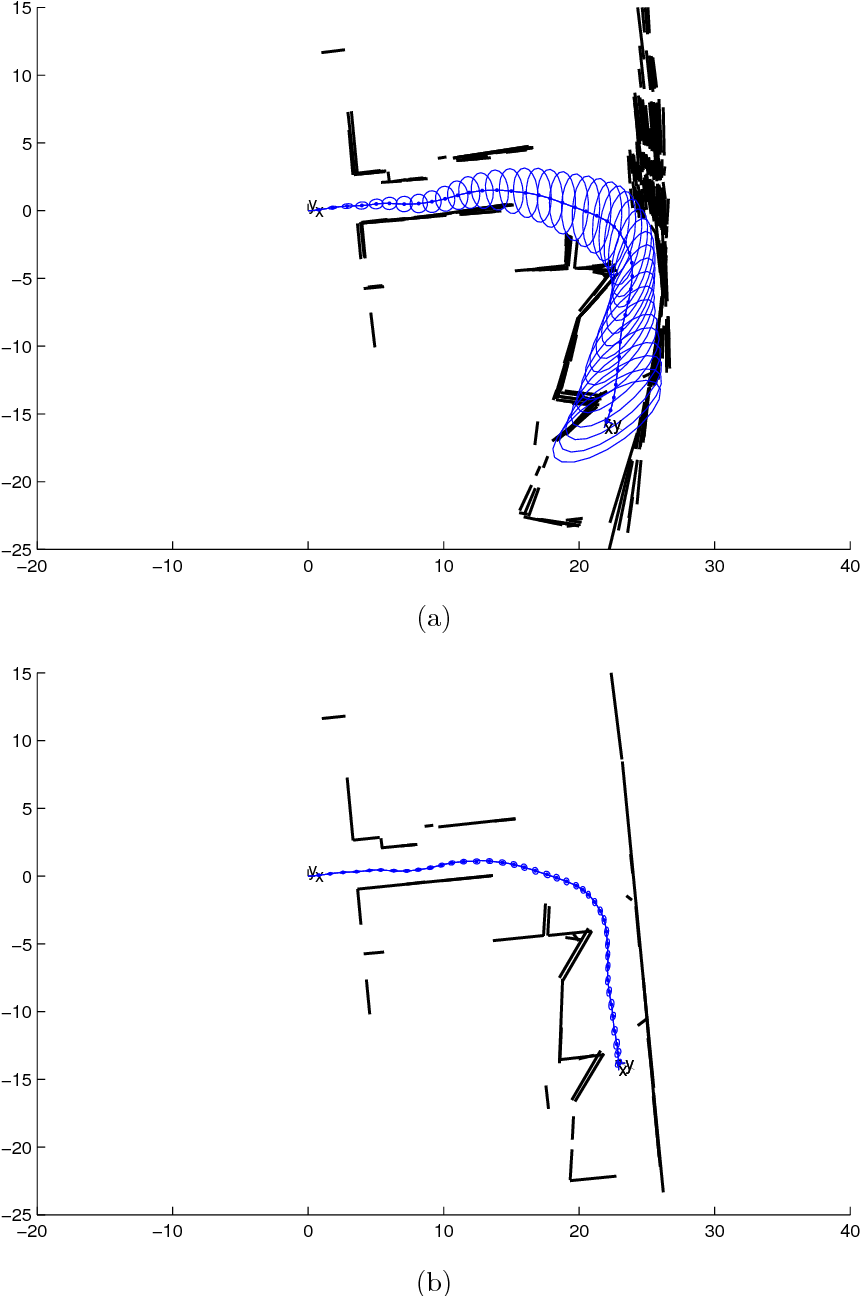
Figure 1.1 from Chapter 1 Map Building and SLAM Algorithms | Semantic ...

Figure 1 from Active Bionic Visual SLAM and Semantic Map Generation in ...
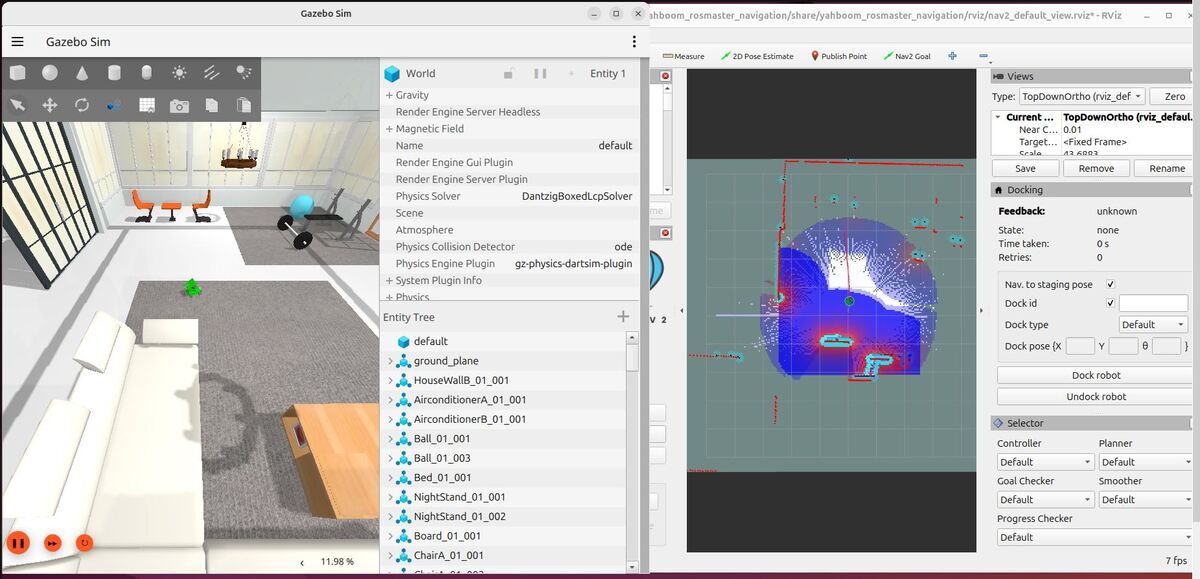
Building a Map of the Environment Using SLAM – ROS 2 Jazzy
Advertisement Space (300x250)
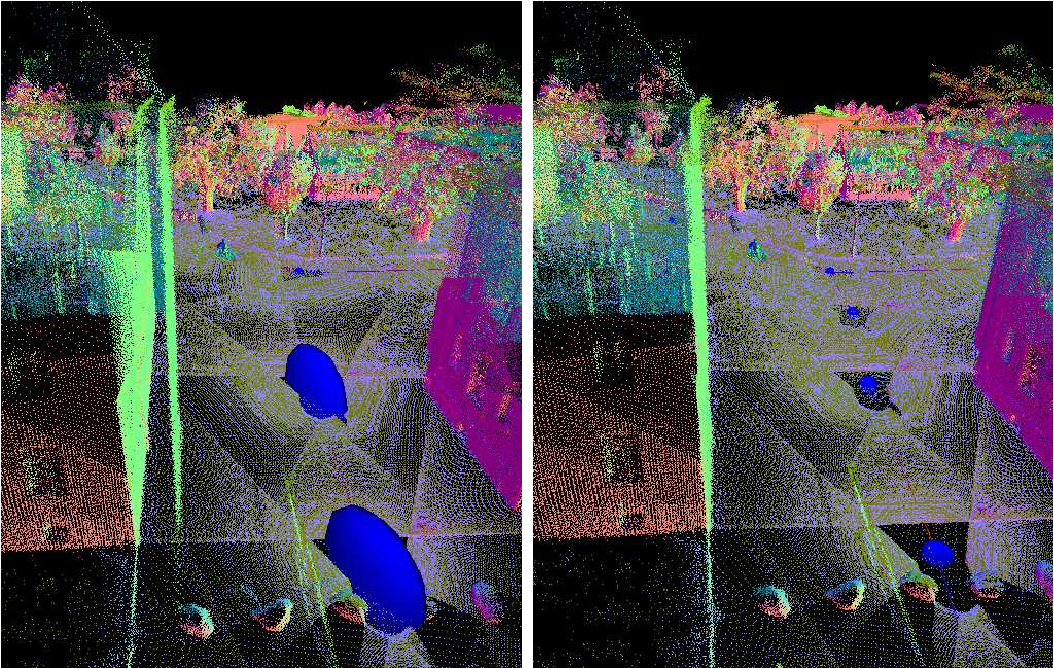
Figure 5.12 from A Full 2D/3D GraphSLAM System for Globally Consistent ...
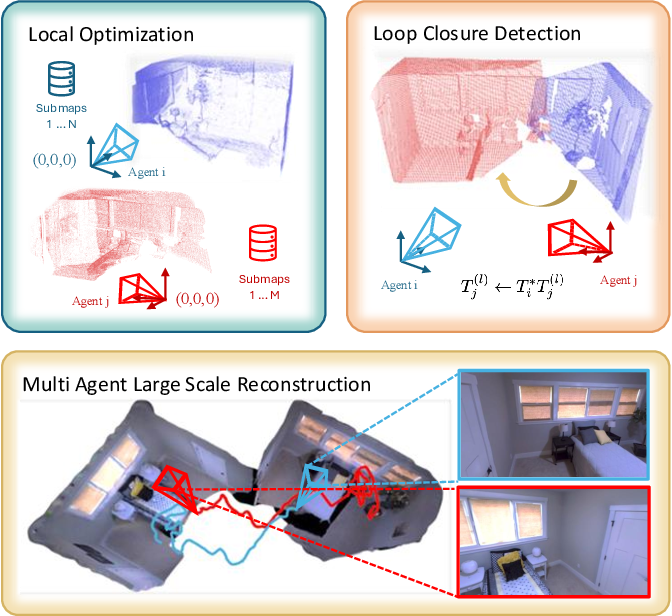
Figure 1 from GRAND-SLAM: Local Optimization for Globally Consistent ...
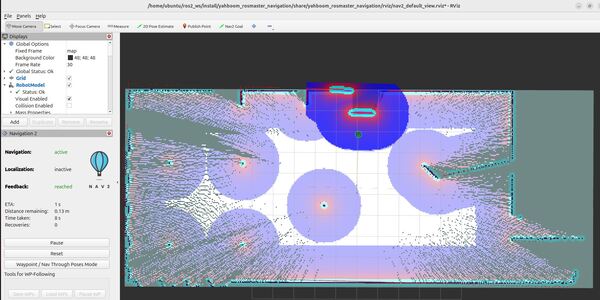
Building a Map of the Environment Using SLAM – ROS 2 Jazzy

Figure 1 from A Solution to the Simultaneous Localisation and Map ...
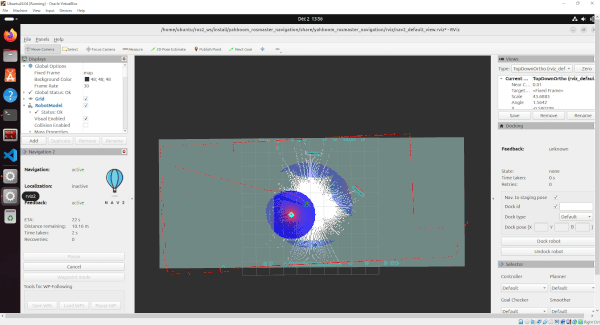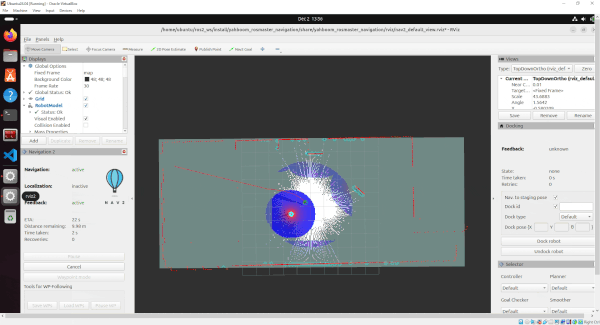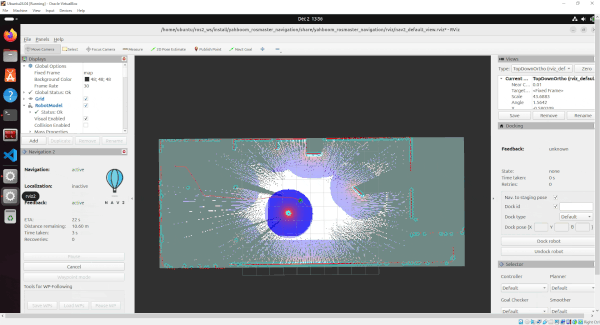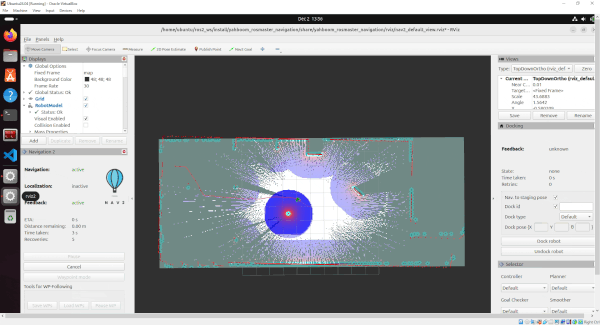
Building a Map of the Environment Using SLAM – ROS 2 Jazzy

Figure 1 from Generating 3D fundamental map by large-scale SLAM and ...
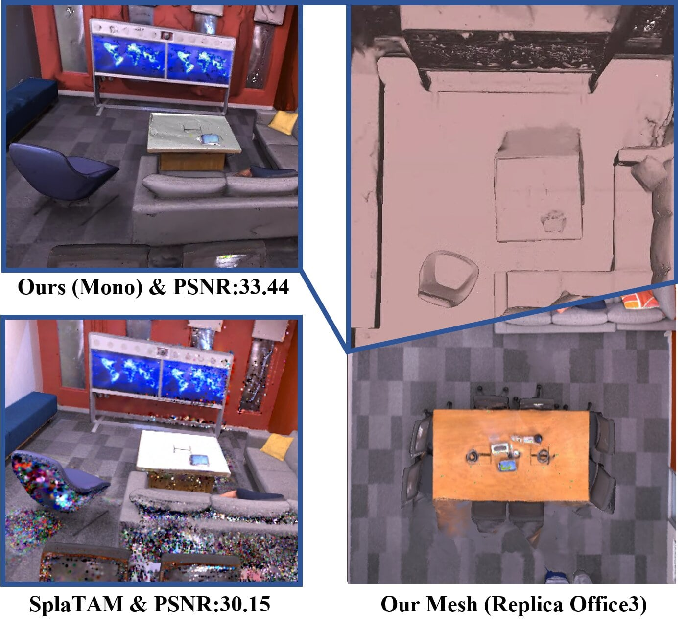
Figure 1 from FGO-SLAM: Enhancing Gaussian SLAM with Globally ...

Towards Autonomous Indoor Parking: A Globally Consistent Semantic SLAM ...
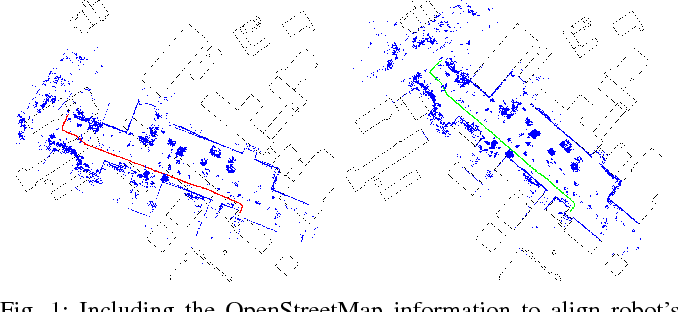
Figure 1 from Exploiting building information from publicly available ...

Left: Using with SLAM created map. Center: While creating a map with ...
Advertisement Space (336x280)

Towards Autonomous Indoor Parking: A Globally Consistent Semantic SLAM ...

The overall structure of SLAM is about building a relative map of ...

Towards Autonomous Indoor Parking: A Globally Consistent Semantic SLAM ...
An snapshot from the second experiment which uses a visual SLAM map ...
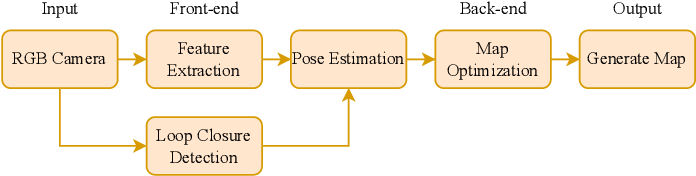
Figure 1 from Review of Autonomous SLAM Mapping and Navigation for ...

(PDF) Building Globally Consistent Gridmaps From Topologies

coVoxSLAM: GPU Accelerated Globally Consistent Dense SLAM | AI Research ...

Full article: Map completion from partial observation using the global ...

[2410.12169] Towards Autonomous Indoor Parking: A Globally Consistent ...

coVoxSLAM: GPU Accelerated Globally Consistent Dense SLAM
Advertisement Space (336x280)

coVoxSLAM: GPU Accelerated Globally Consistent Dense SLAM
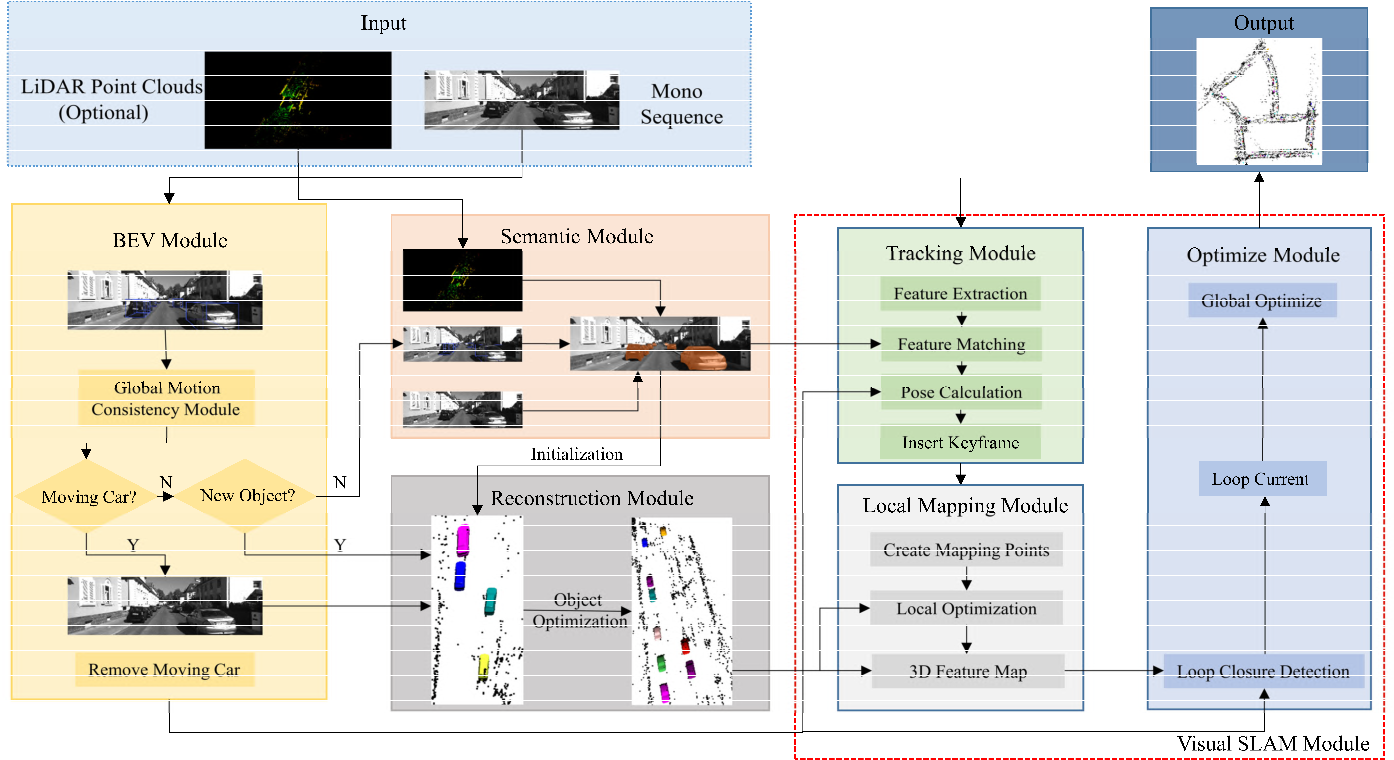
Figure 2 from BE-SLAM: BEV-Enhanced Dynamic Semantic SLAM with Static ...

(PDF) Global Map Generation and SLAM using LiDAR and Stereo Camera for ...
A view of the built map of the visual SLAM system during a manual ...

Figure 1 from NGEL-SLAM: Neural Implicit Representation-based Global ...

GitHub - PRBonn/2DGS-SLAM: 2DGS-SLAM: Globally Consistent RGB-D SLAM ...