
Figure 1 From Compact Torque Sensor For A Robot Hand Semantic Scholar
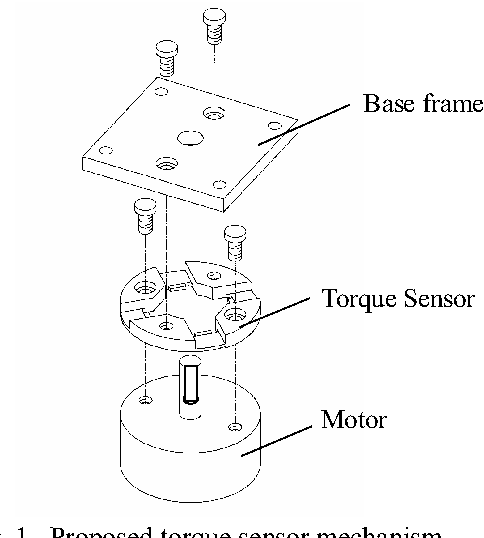
Figure 1 from Compact torque sensor for a robot hand | Semantic Scholar

Figure 1 from Torque Sensors for Robot Joint Control | Semantic Scholar
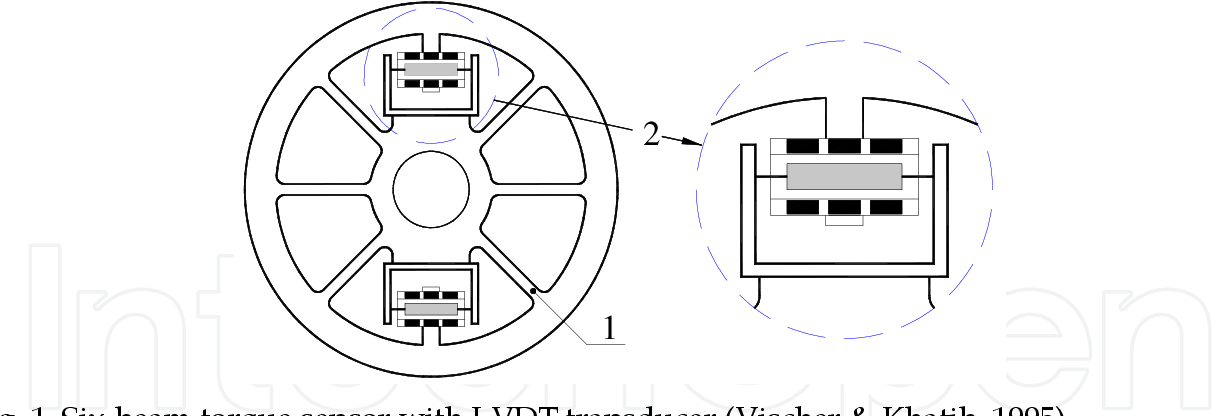
Figure 1 from Torque Sensors for Robot Joint Control | Semantic Scholar

Figure 1 from Application of 6-Axis Force Torque (F/T) Sensor for a ...
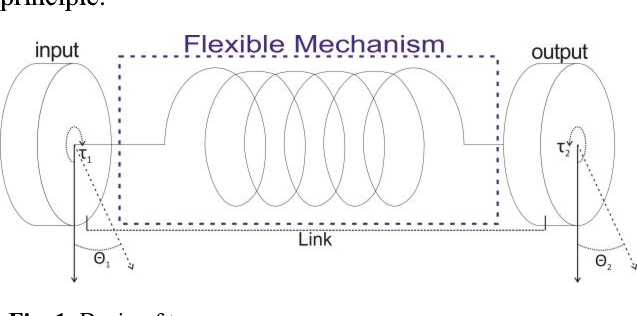
Figure 1 from A low cost 3D-printed robot joint torque sensor ...
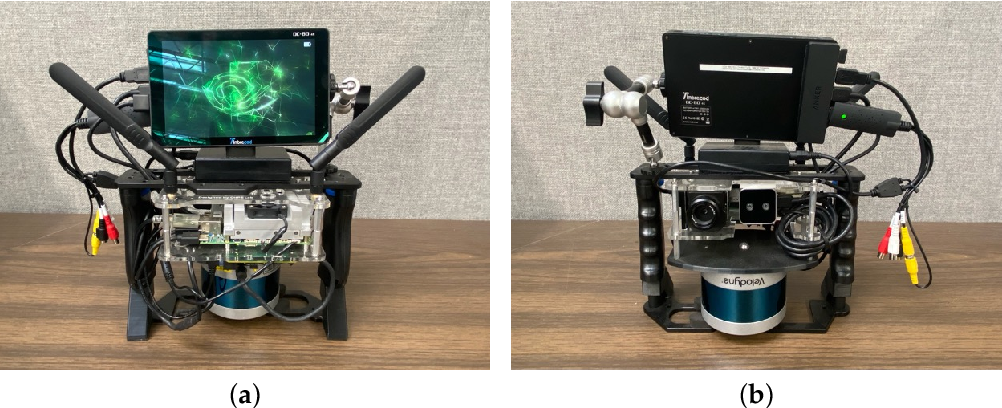
Figure 1 from A Compact Handheld Sensor Package with Sensor Fusion for ...

Figure 1 from A Novel Three-Axis Capacitive Force Sensor for Robot ...
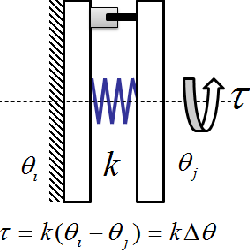
Figure 1 from Development of a one-body optical torque sensor for ...
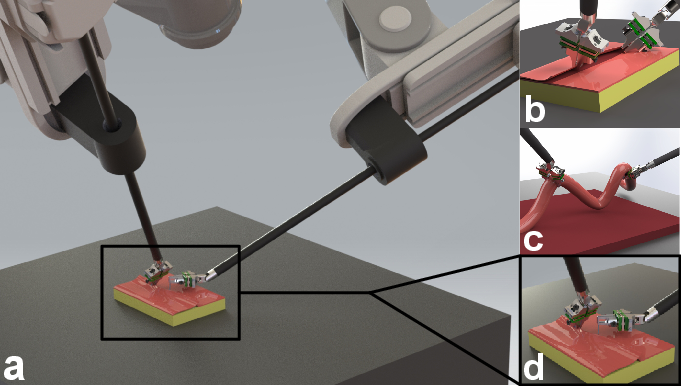
Figure 1 from A Modular 3-Degree-of-Freedom Force Sensor for Robot ...

Figure 1 from A new anthropomorphic robotic hand | Semantic Scholar
Advertisement Space (300x250)
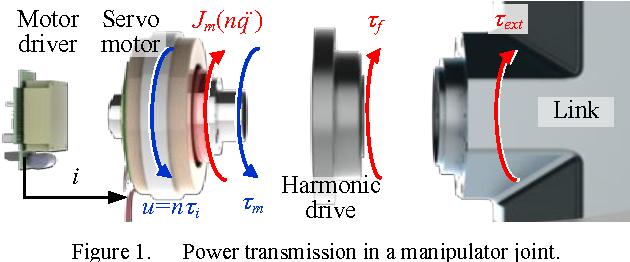
Figure 1 from Torque control based sensorless hand guiding for direct ...

Figure 1 from Robot Joint Module with a Reactive-type Joint Torque ...
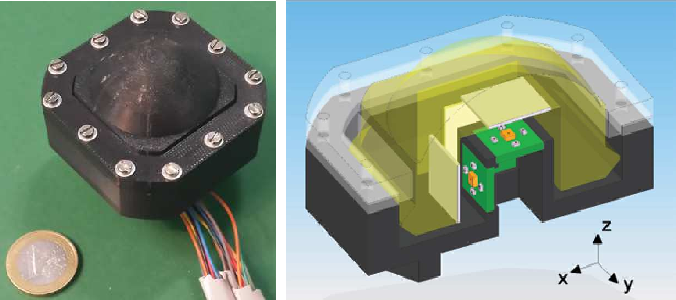
Figure 1 from A new force/torque sensor for robotic applications based ...
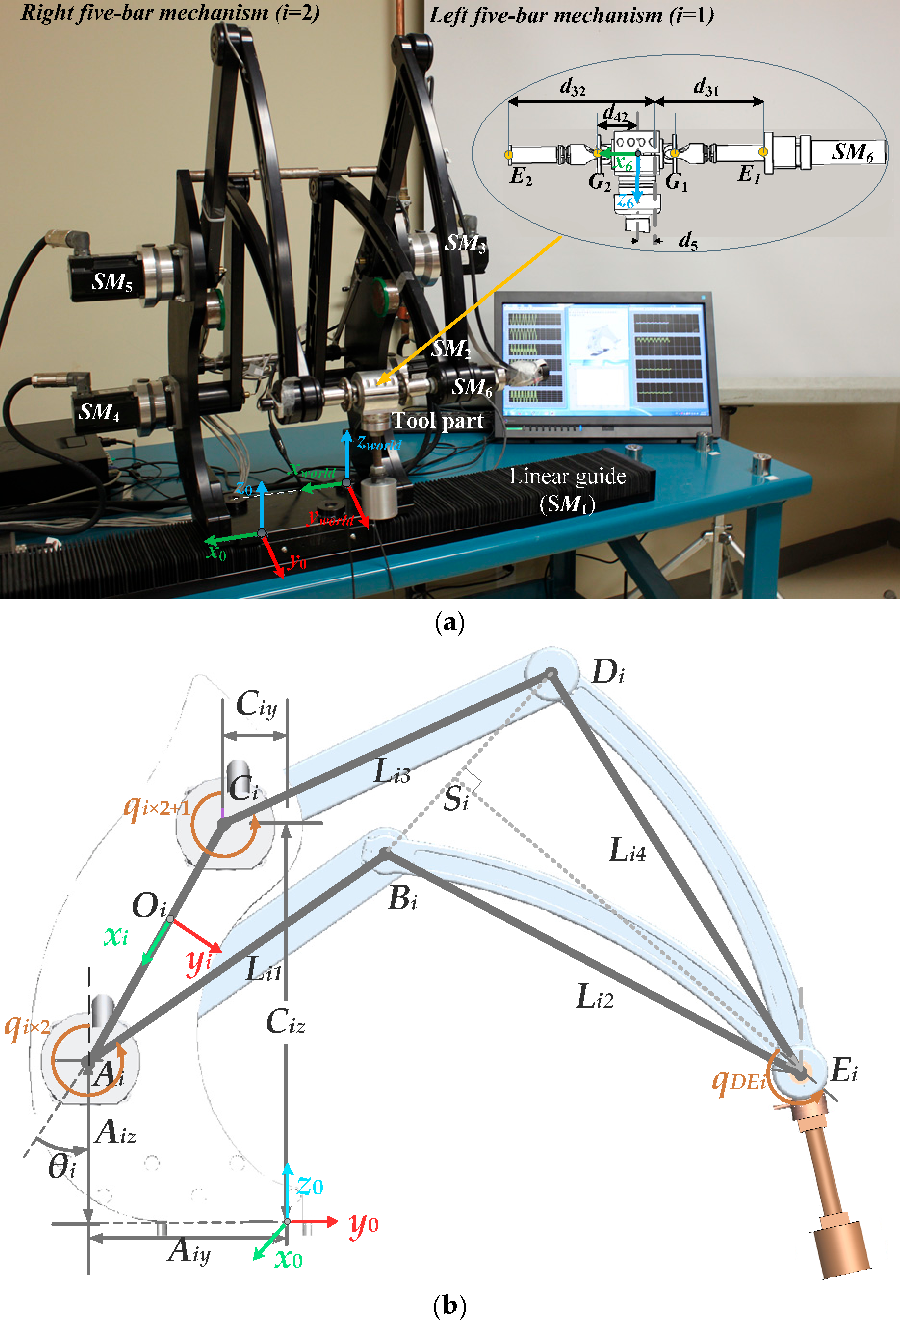
Figure 1 from Use of a Force-Torque Sensor for Self-Calibration of a 6 ...
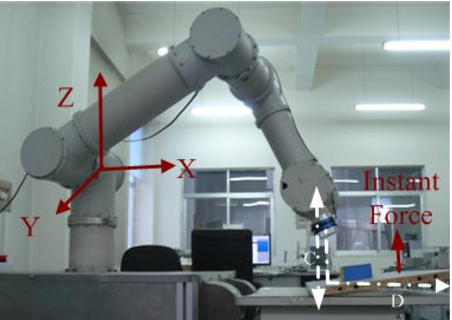
Figure 1 from Development of Torque Sensor with High Sensitivity for ...

Figure 1 from Torque control based sensorless hand guiding for direct ...
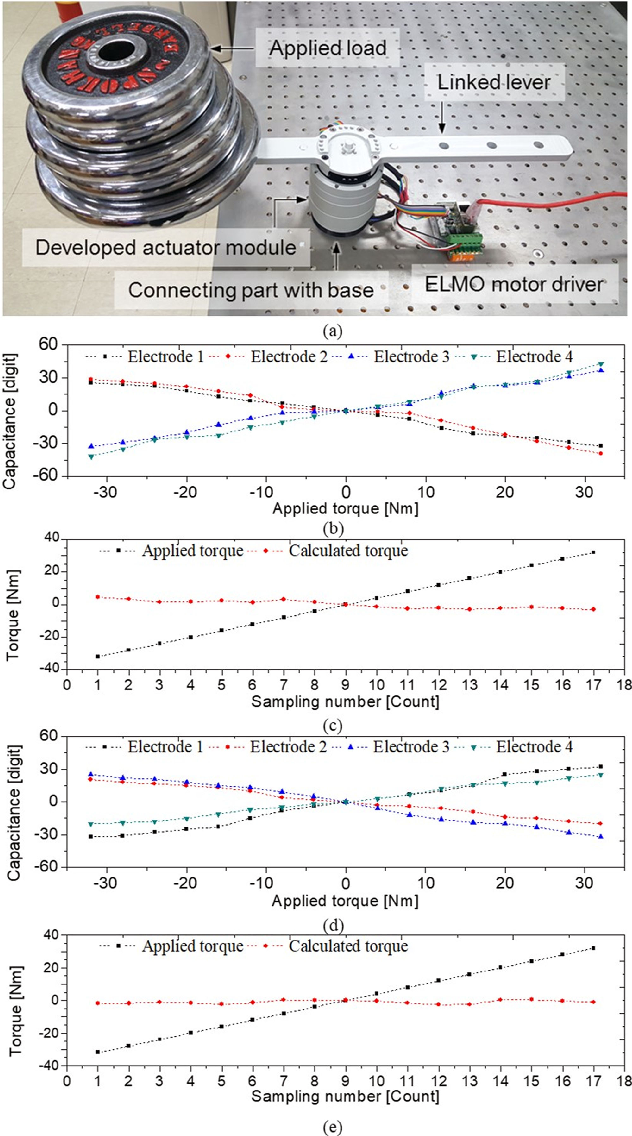
Figure 1 from Torque Sensor Embedded Actuator Module for Robotic ...

Figure 1 from Torque sensor based robot arm control using disturbance ...

Figure 9 from A novel capacitive type torque sensor for robotic ...

Figure 11 from Development of a Six-Axis Force and Torque Sensor for ...
Advertisement Space (336x280)

Figure 1 from Design of a Ring-Type Bearingless Torque Sensor With Low ...

Figure 3 from A novel capacitive type torque sensor for robotic ...

Figure 1 from Underactuated robot hand for dual-arm manipulation ...

Figure 1 from Estimating Robot Body Torque for Two-Handed Cooperative ...
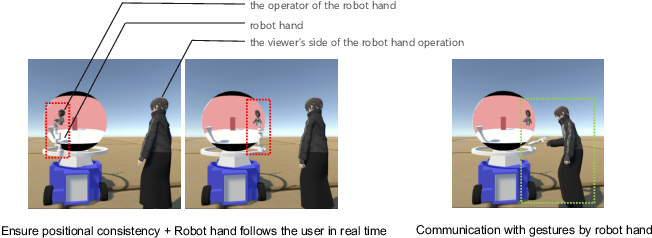
Figure 1 from 360 Robot Hand System for Omni-directional Interaction by ...

Figure 1 from Three-Axis Flat and Lightweight Force/Torque Sensor for ...
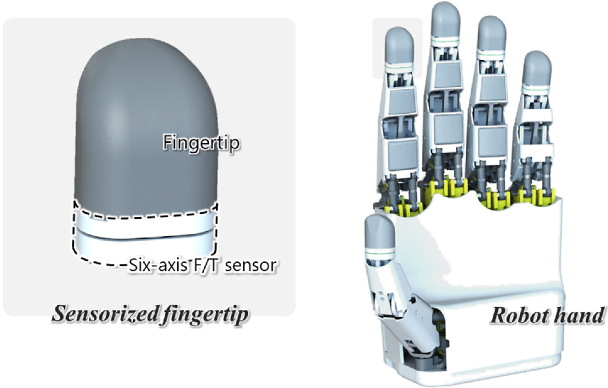
Figure 1 from Six-Axis Force/Torque Fingertip Sensor for an ...
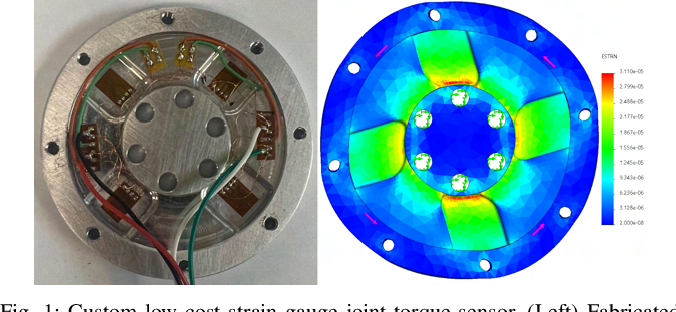
Figure 1 from Contact Sensing via Joint Torque Sensors and a Force ...

Figure 1 from Joint Torque Estimation using Base Force-Torque Sensor to ...

Figure 1 from Implementing Full-body Torque Control in Humanoid Robot ...
Advertisement Space (336x280)
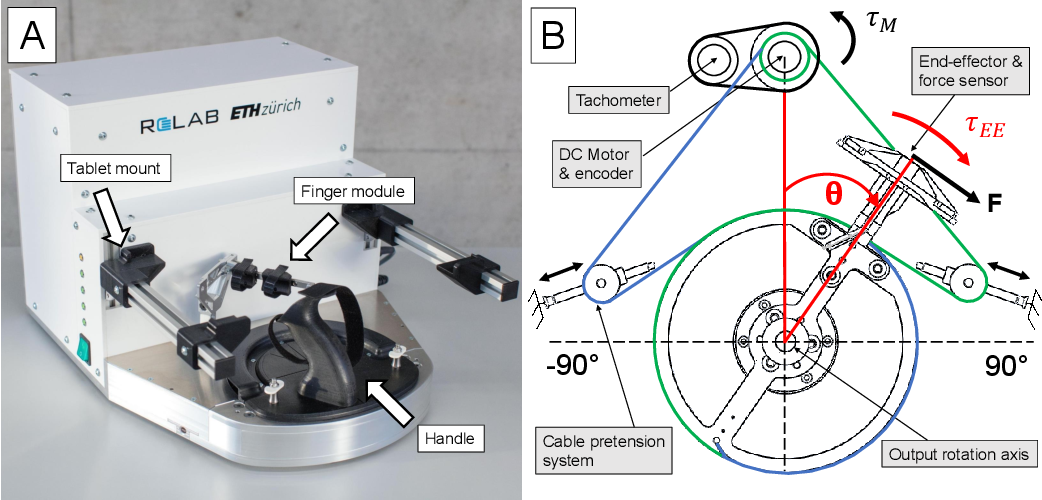
Figure 1 from Design and Characterization of a Robotic Device for the ...
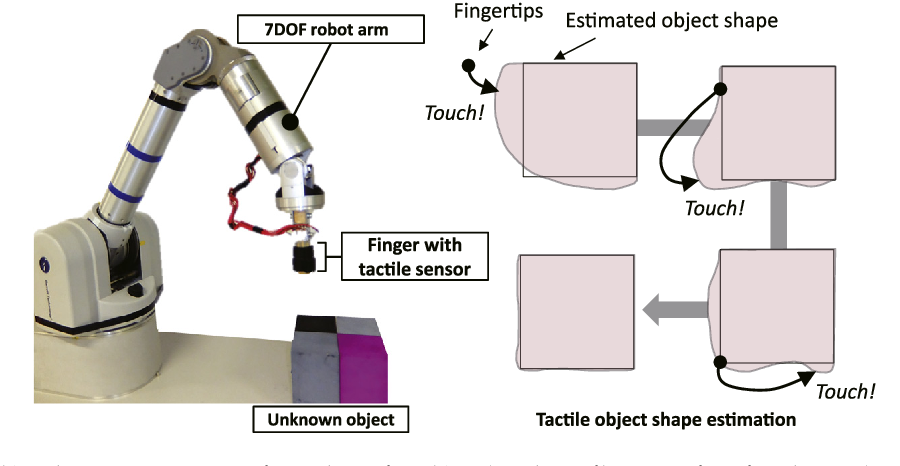
Figure 1 from Robotics and Autonomous Systems | Semantic Scholar
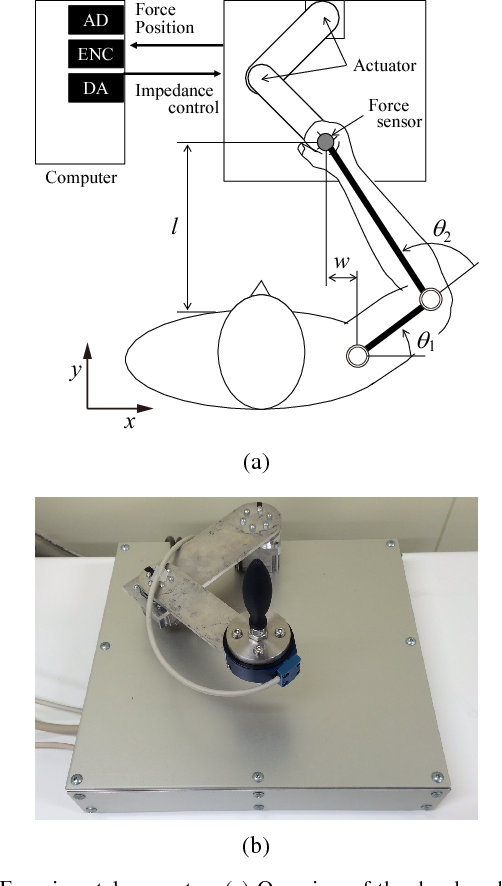
Figure 1 from Development of a robotic evaluation system for the ...
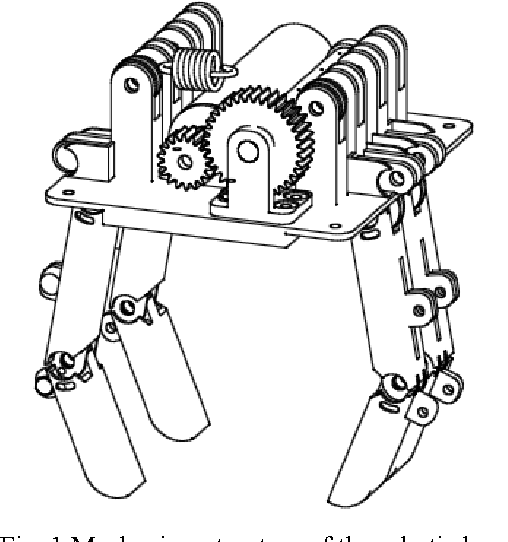
Figure 1 from Mechanism design of underactuated robotic hand | Semantic ...

Figure 1 from Implementation of a Wireless Human Hand Gesture ...
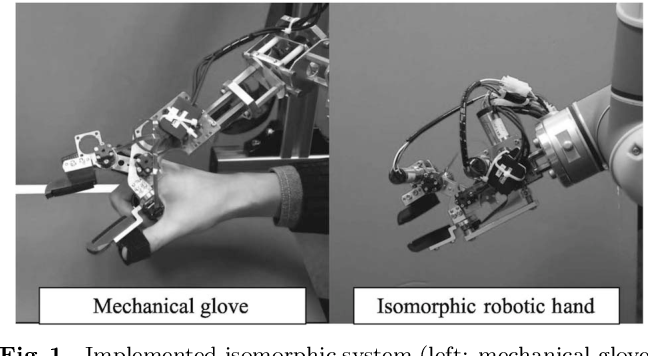
Figure 1 from Third-party Evaluation of the Robotic Hand Design Using a ...