
Figure 1 From Design Of A Robust Bilateral Controller For Teleoperators
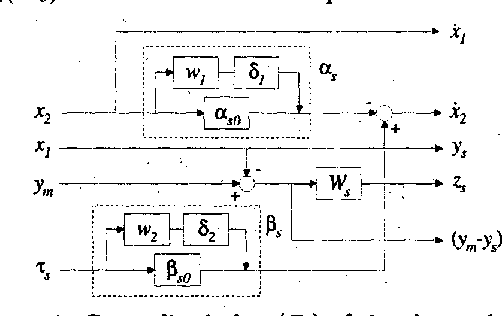
Figure 1 from Design of a robust bilateral controller for teleoperators ...
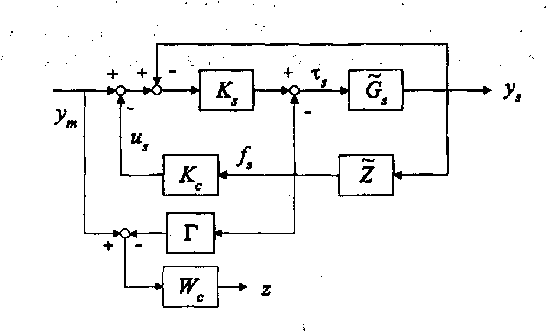
Figure 3 from Design of a robust bilateral controller for teleoperators ...
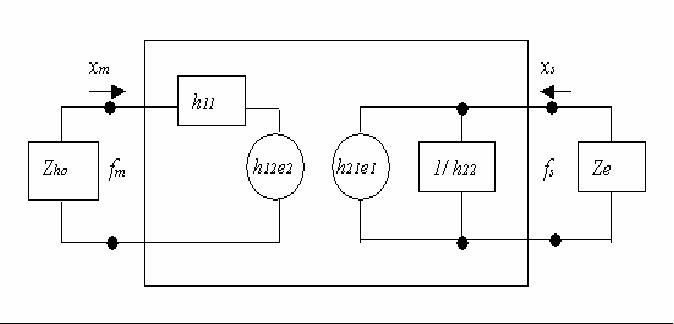
Figure 1 from Design of Bilateral Teleoperators for Soft Environments ...
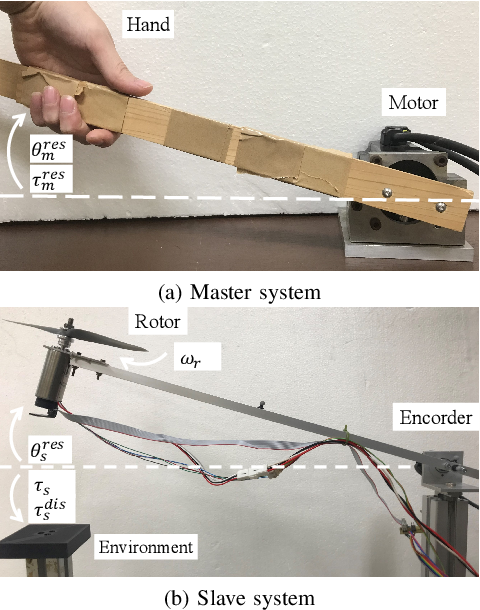
Figure 1 from Design of Adaptive Controller for Bilateral Control ...

Figure 1 from Adaptive robust control for bilateral teleoperators in ...
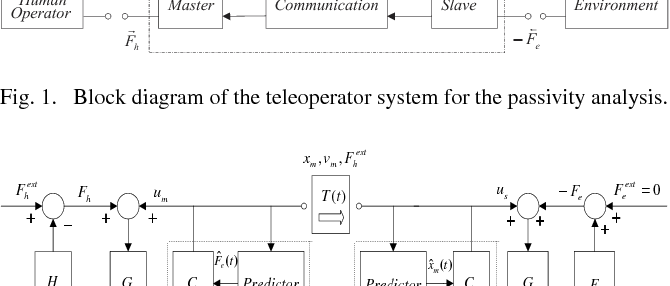
Figure 1 from Predictive controller design for bilateral teleoperation ...

Figure 1 from Design of Adaptive Controller using Object Position for ...
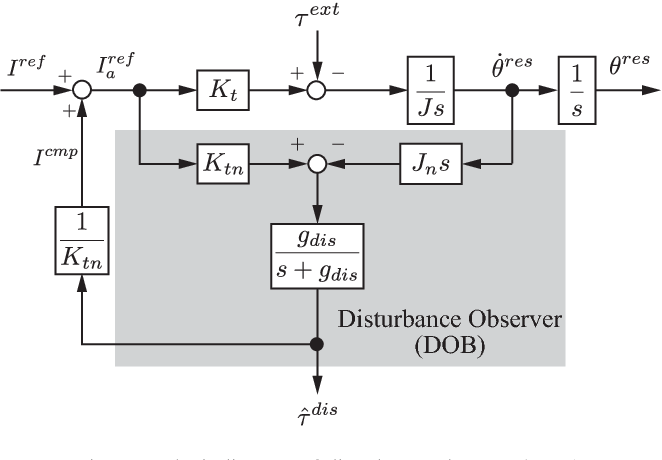
Figure 1 from An approach to controller design of bilateral control ...
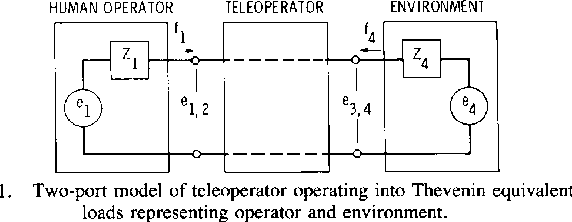
Figure 1 from A design framework for teleoperators with kinesthetic ...

Figure 1 from A Design of Digital Controller Using Disturbance Observer ...
Advertisement Space (300x250)
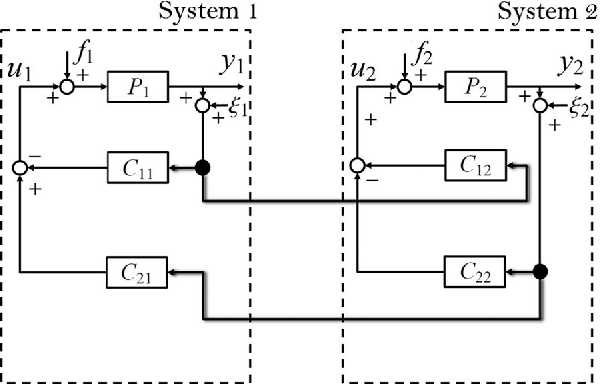
Figure 1 from Design of Two-Channel Bilateral Control Systems by a ...
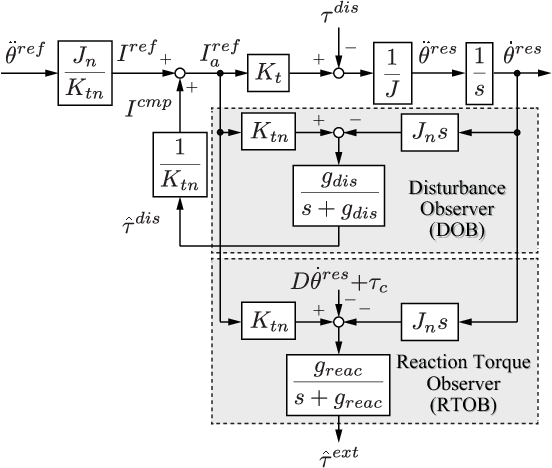
Figure 1 from A design of four-channel bilateral control system under ...
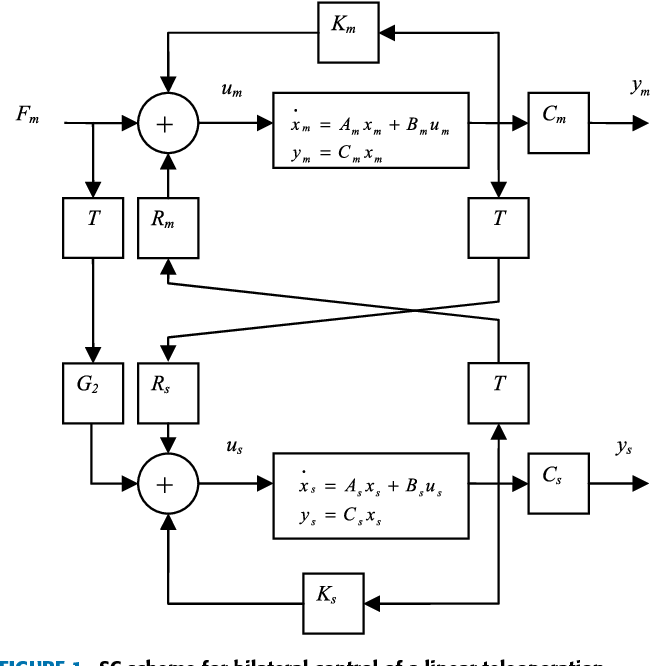
Figure 1 from Fuzzy Model Based Bilateral Control Design of Nonlinear ...

Figure 1 from Advanced Finite-Time Control For Bilateral Teleoperators ...
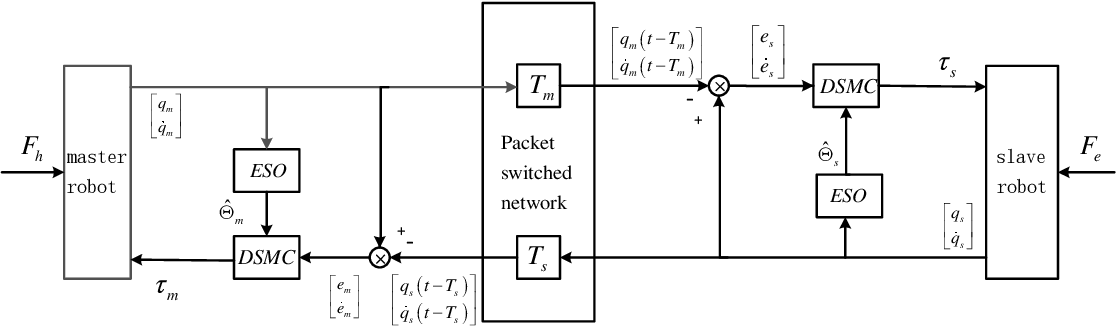
Figure 1 from Discrete Sliding Mode Control Design for Bilateral ...
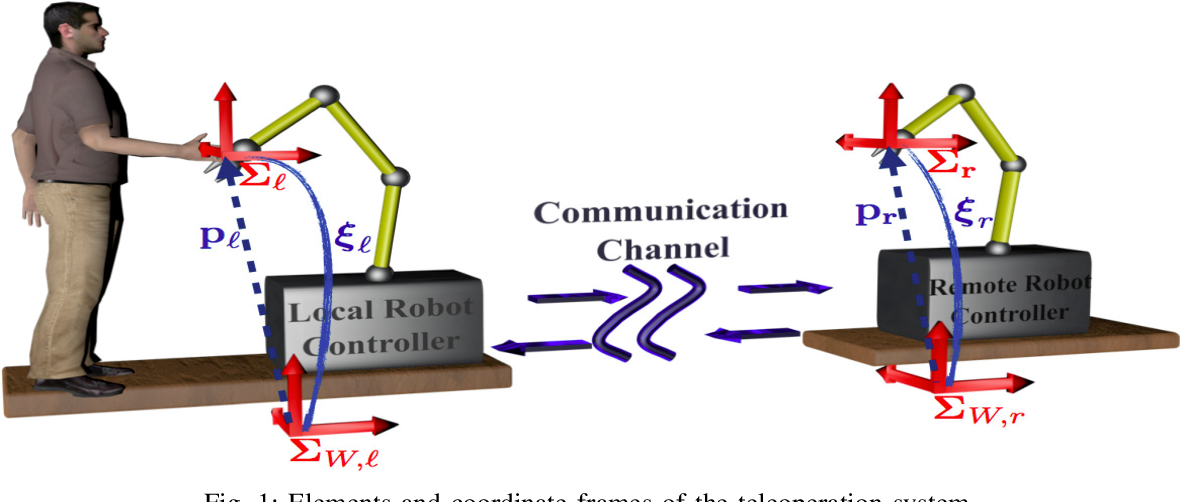
Figure 1 from Control of bilateral teleoperators in the operational ...

Figure 1 from A Modular Bilateral Haptic Control Framework for ...
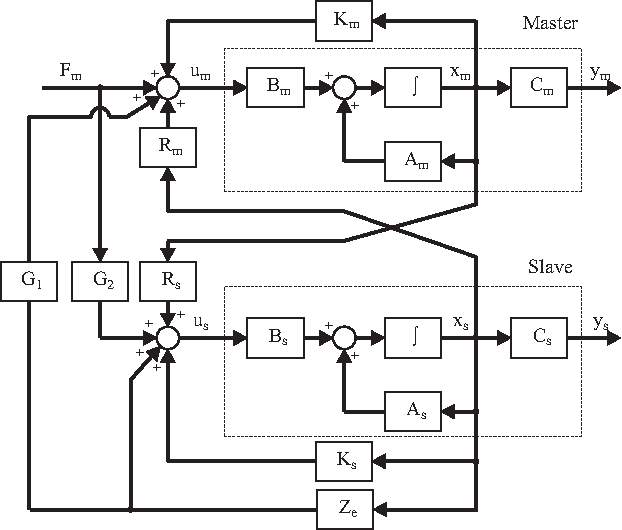
Figure 1 from Bilateral controller design based on transparency in the ...

Figure 1 from Robust stability analysis of bilateral teleoperation ...
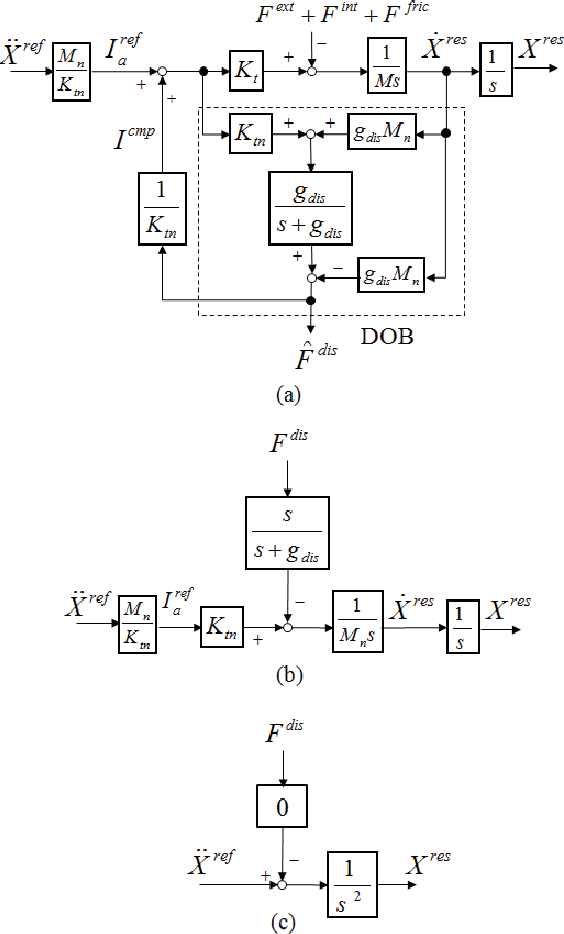
Figure 1 from Novel Four-Channel Bilateral Control Design for Haptic ...
Advertisement Space (336x280)

Figure 1 from An Approach to Architecture Design of Bilateral Control ...

Figure 1 from An Approach to Architecture Design of Bilateral Control ...
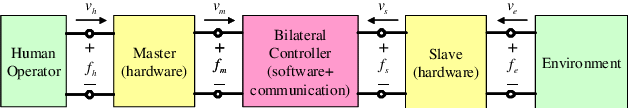
Figure 1 from A stabilizing control technique for bilateral ...

Figure 1 from Stability experiments of a scaled bilateral teleoperation ...
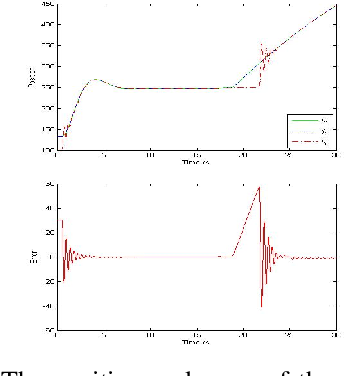
Figure 1 from Adaptive robust control of bilateral teleoperation ...

Figure 1 from Design of a Tele-Control Electrical Vehicle System Using ...

Figure 1 from Bilateral Teleoperation of a Multi-Robot Formation with ...

Figure 1 from New stability and tracking criteria for a class of ...
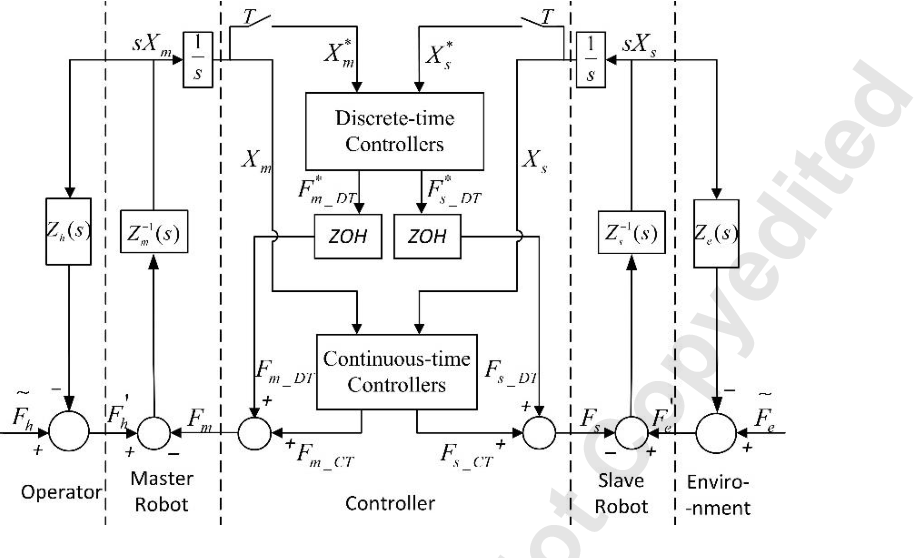
Figure 1 from Hybrid Analog/Digital Control of Bilateral Teleoperation ...

Figure 1 from A Passivity-Based Bilateral Teleoperation Architecture ...
Advertisement Space (336x280)
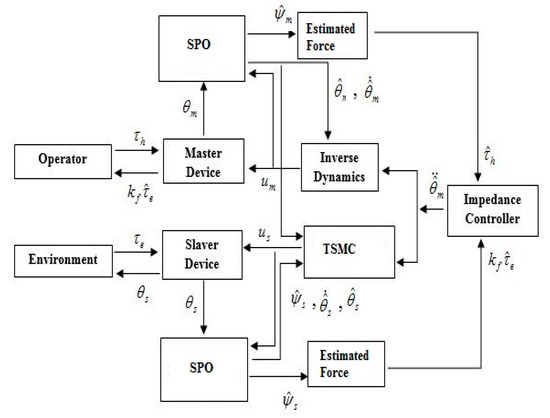
Robust Controller for Pursuing Trajectory and Force Estimations of a ...

Design of robust adaptive fuzzy control for uncertain bilateral ...

Figure 1 from Control in the operational space of bilateral ...
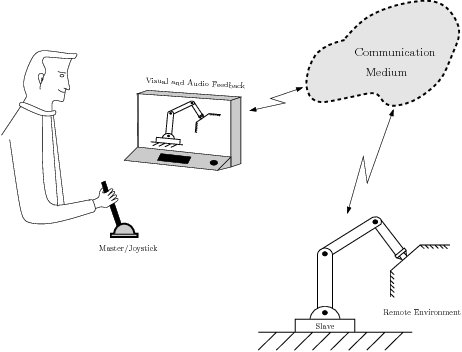
Figure 1 from Stability of Quantized and Delayed Bilateral ...

(PDF) Robust Passivity-based Nonlinear Controller Design for Bilateral ...

Figure 2 from Scaled teleoperation controller design for ...