
Figure 1 From Dynamic Tracking Control Of The Humanoid Robot Joints
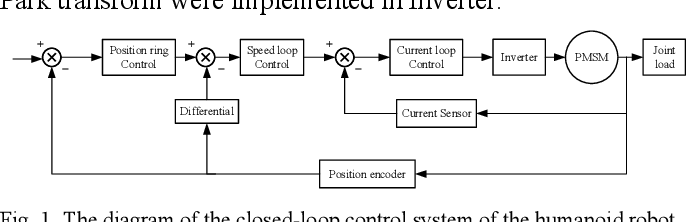
Figure 1 from Dynamic tracking control of the humanoid robot joints ...
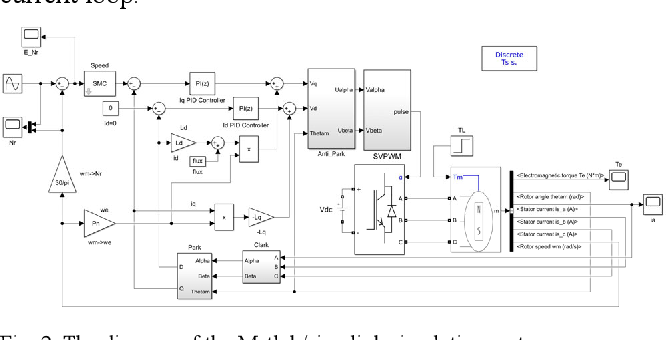
Figure 2 from Dynamic tracking control of the humanoid robot joints ...

Figure 1 from Dynamic leg function of the BioBiped humanoid robot ...

Figure 1 from Human motion tracking control for humanoid robot based on ...
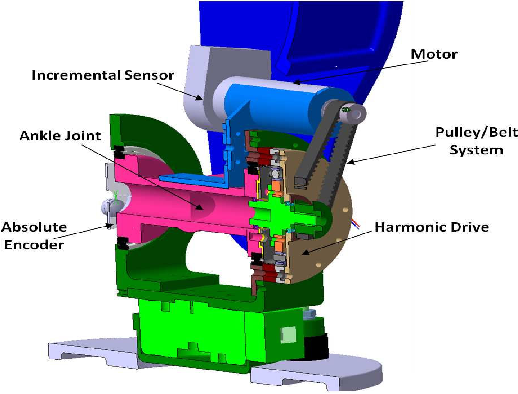
Figure 1 from Robust motion control for humanoid robot flexible joints ...

Figure 1 from Dynamic parameters identification of a humanoid robot ...

Figure 1 from Control and evaluation of a humanoid robot with rolling ...
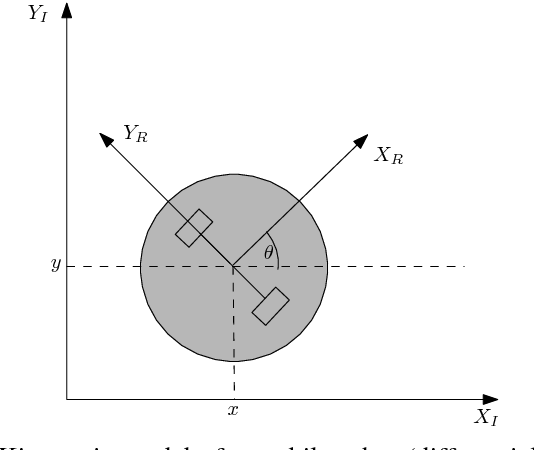
Figure 1 from Universal dynamic tracking control law for mobile robot ...
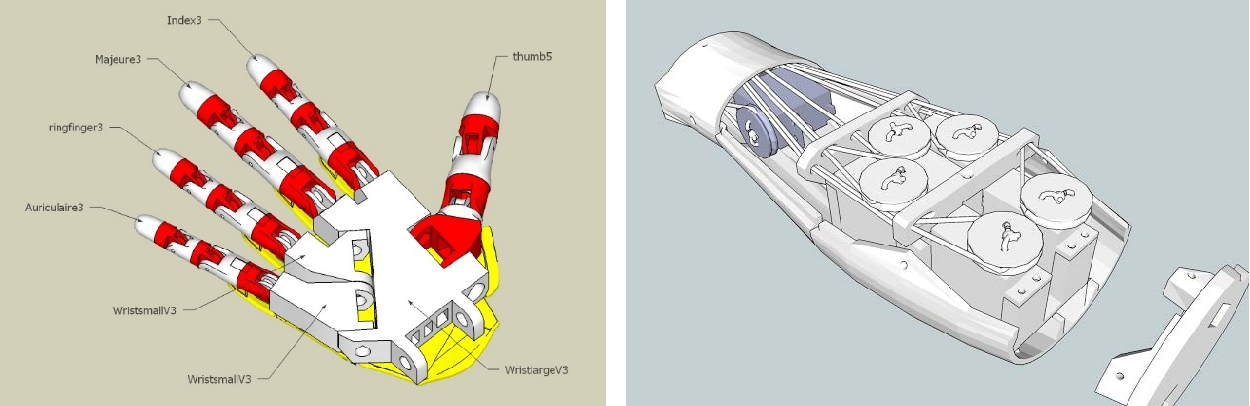
Figure 1 from RESEARCH OF ROBOT - HUMANOID CONTROL METHODS USING HUMAN ...

Figure 1 from Kinematic Control of Humanoid Upper Body Robot Using ...
Advertisement Space (300x250)

Figure 2 from Human motion tracking control for humanoid robot based on ...
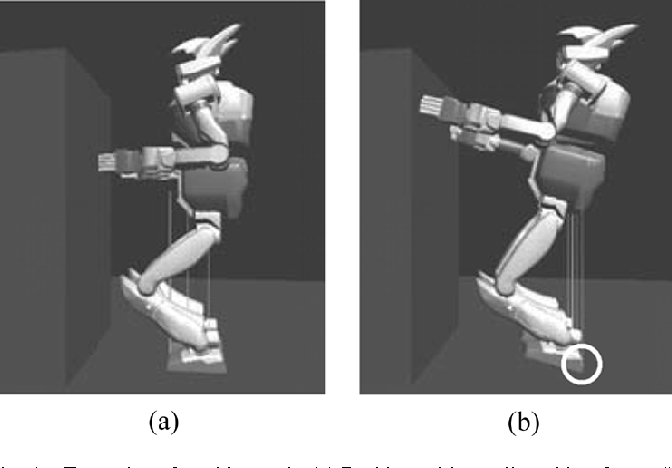
Figure 1 from Dynamics and balance of a humanoid robot during ...
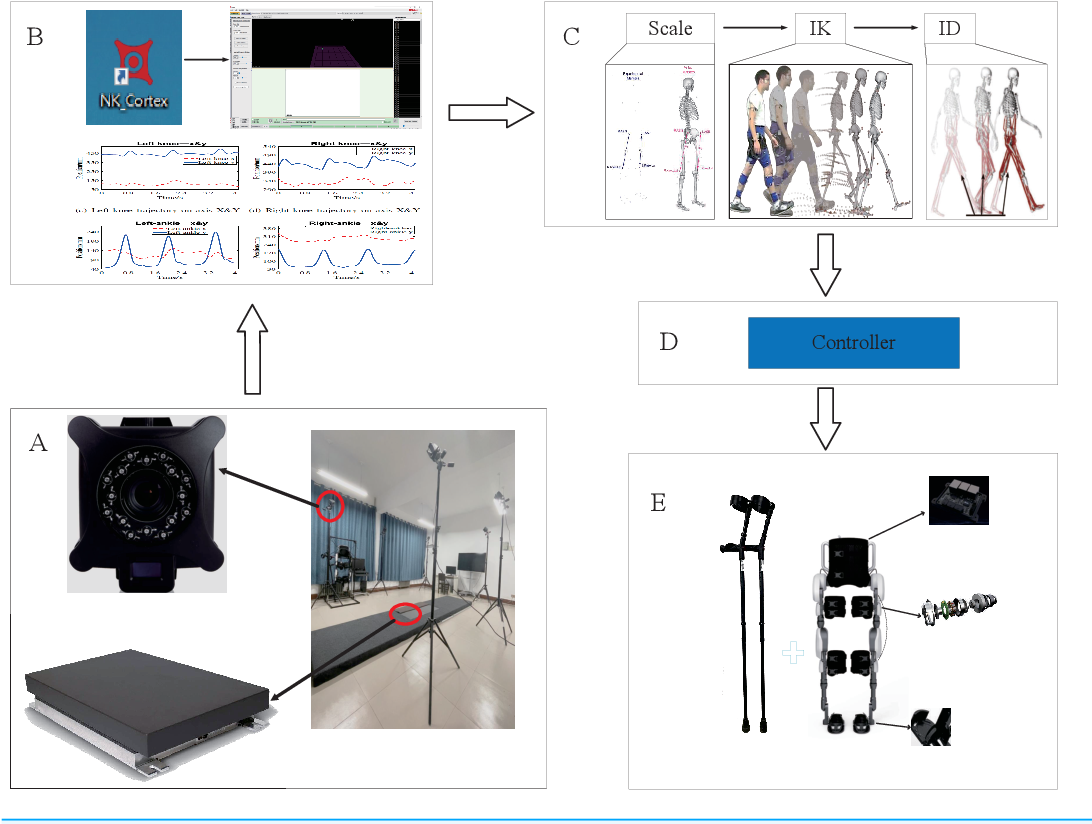
Figure 1 from Musculoskeletal modeling and humanoid control of robots ...

Figure 1 from Dynamic Locomotion Teleoperation of a Reduced Model of a ...
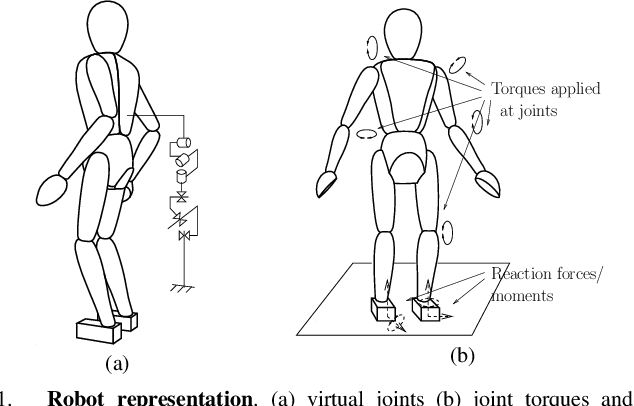
Figure 1 from Contact consistent control framework for humanoid robots ...

Design of a Humanoid Upper-Body Robot and Trajectory Tracking Control ...

Design of a Humanoid Upper-Body Robot and Trajectory Tracking Control ...

Control and evaluation of a humanoid robot with rolling contact joints ...
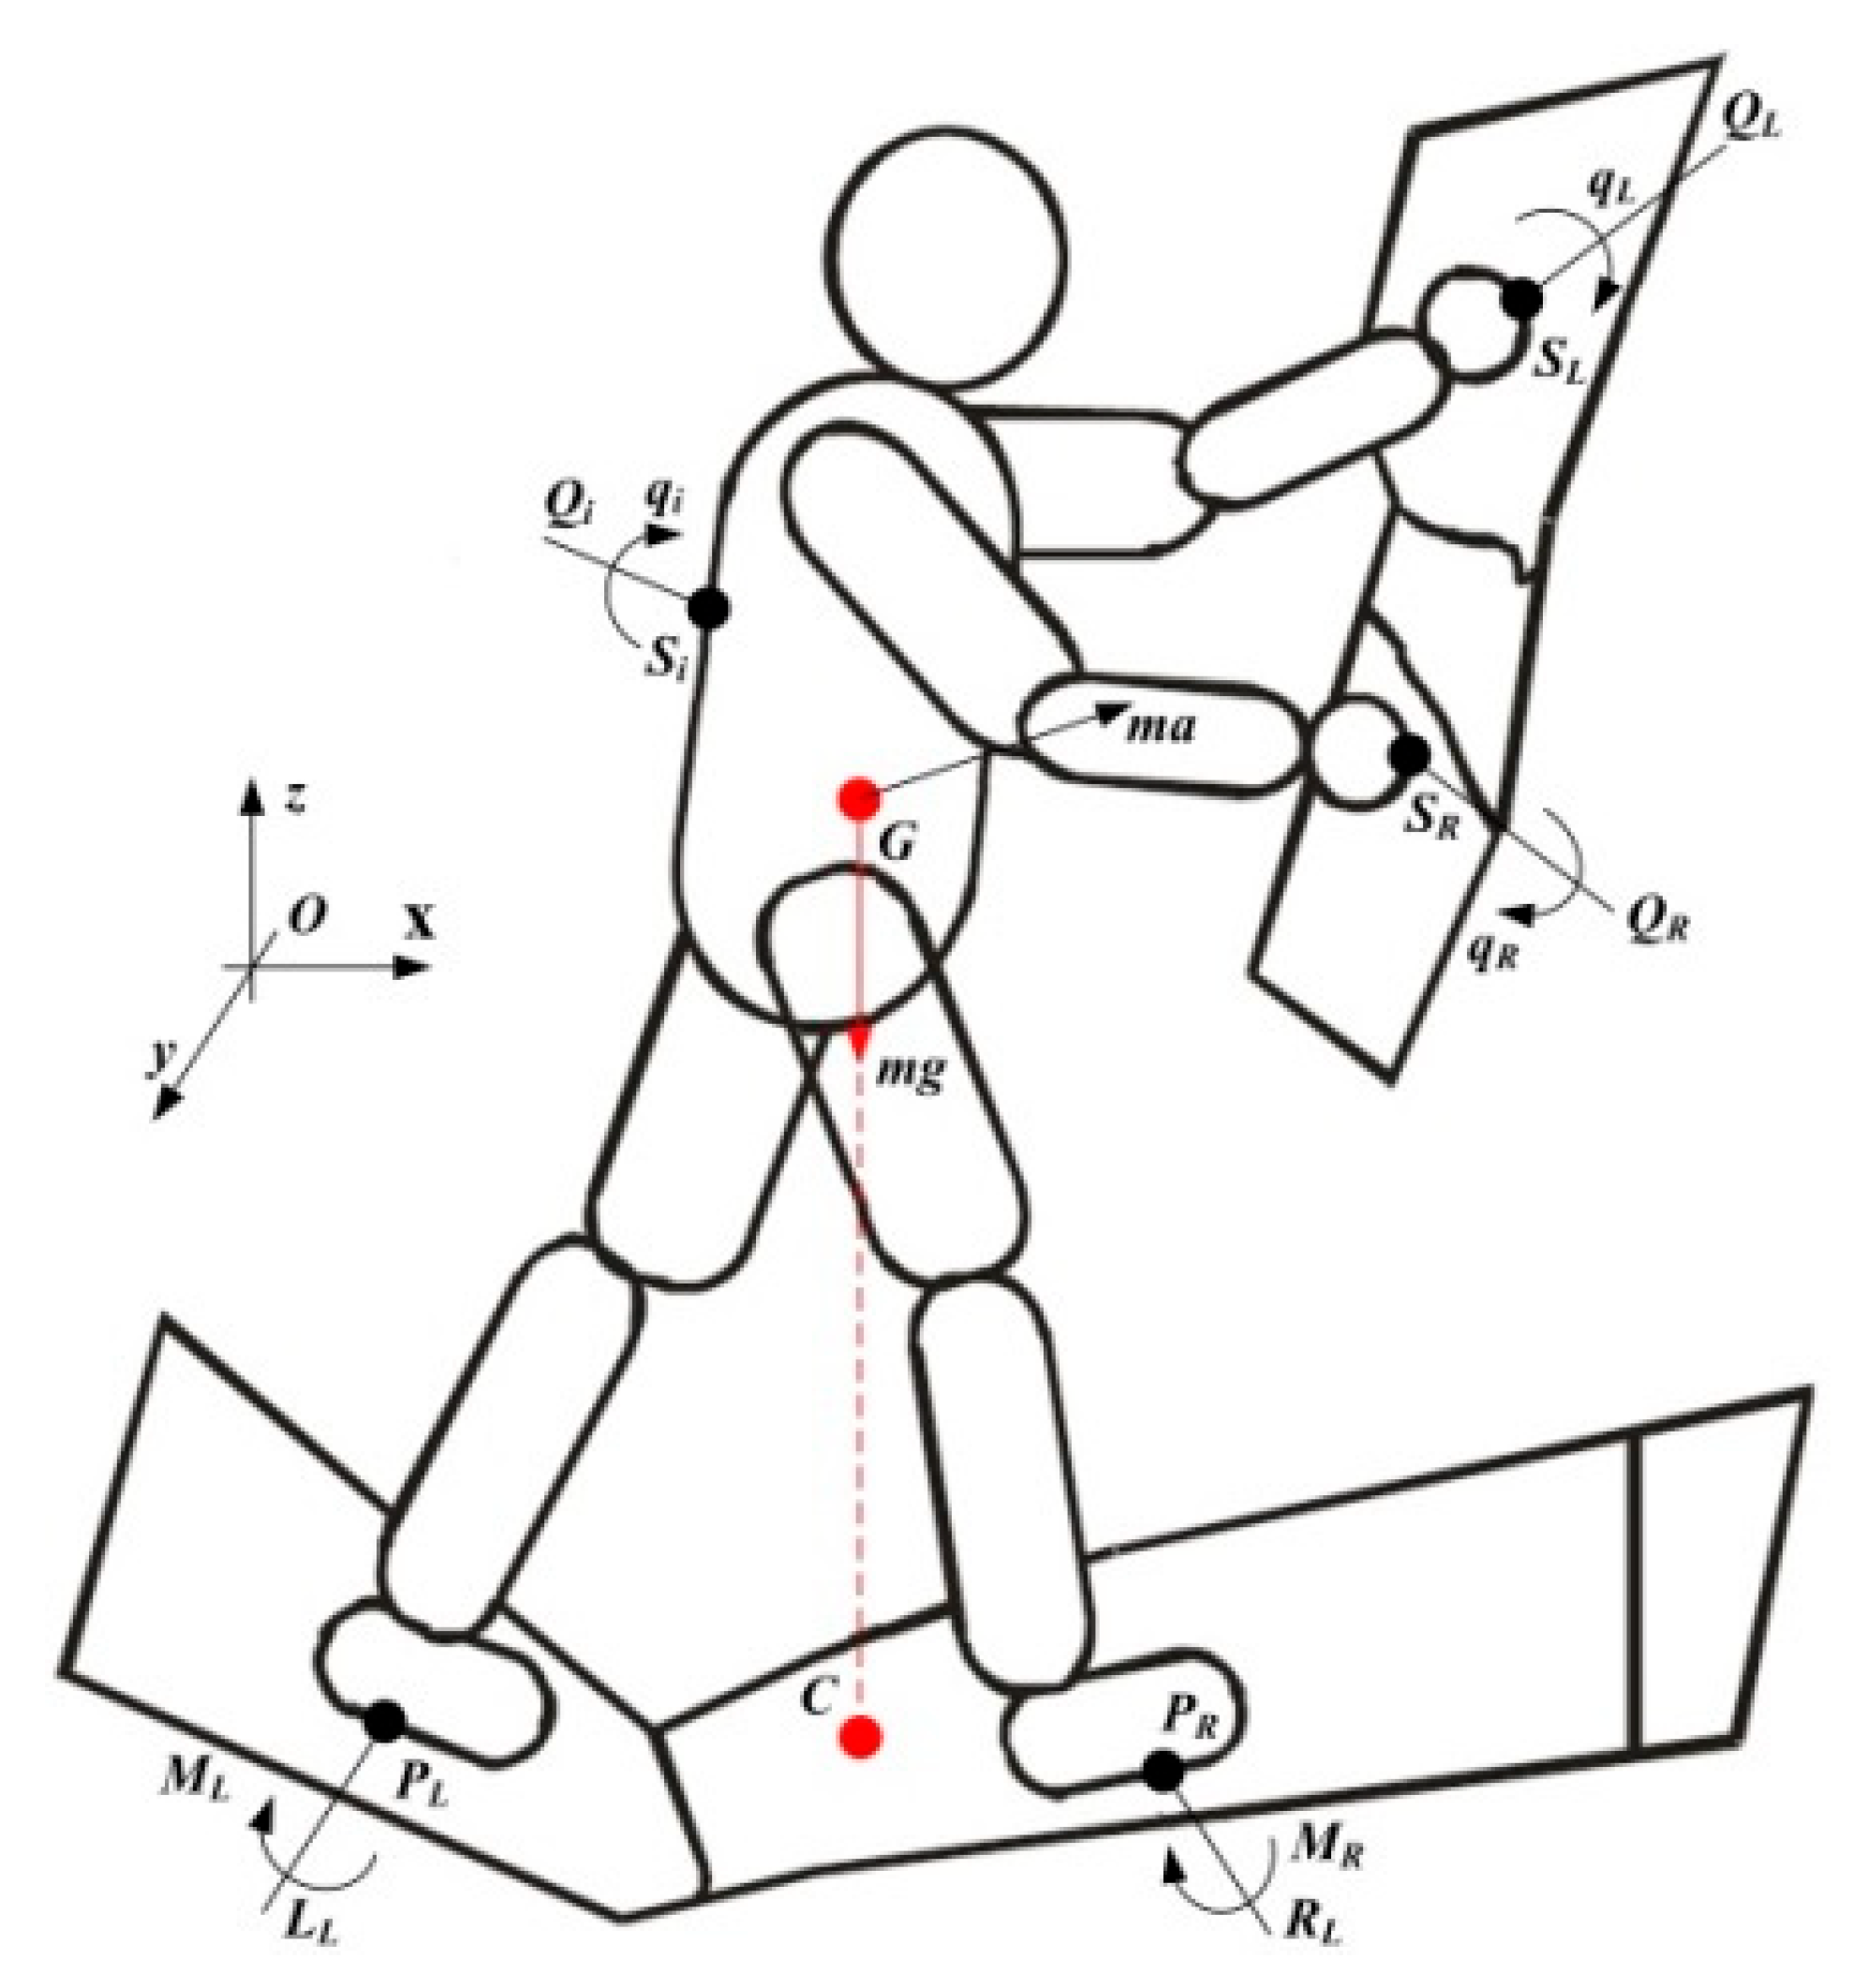
Stability and Dynamic Walk Control of Humanoid Robot for Robot Soccer ...
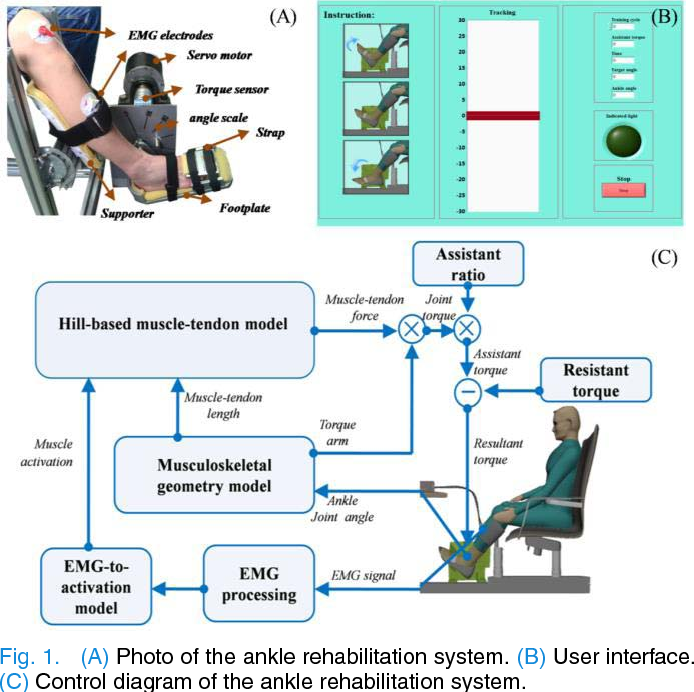
Figure 1 from Movement Performance of Human–Robot Cooperation Control ...
Advertisement Space (336x280)

Figure 1 from The control algorithm enabling natural physical ...
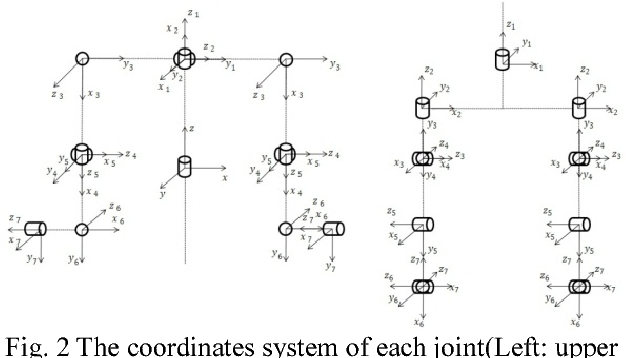
Figure 1 from Simulation based for intelligent control system of multi ...

Figure 1 from Structure design and motion analysis of waist of humanoid ...
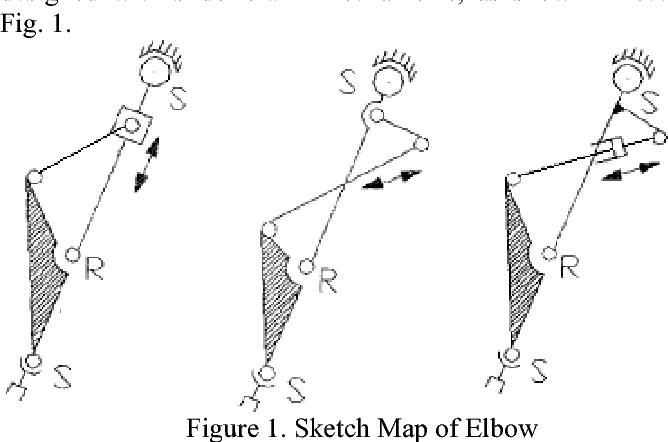
Figure 1 from Hybrid intelligent joint controller for humanoid robot ...

3: Examples of joints for a humanoid character and the PR2 robot ...
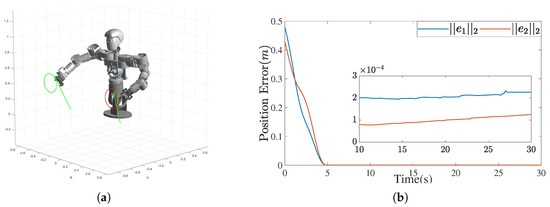
Design of a Humanoid Upper-Body Robot and Trajectory Tracking Control ...

Joint tracking of the robot: (a) The robot with all the joints are ...

Photo and kinematic structure of the humanoid robot Lola. Joint ...

Figure 1 from Distance Control Between an Object and an End Effector ...
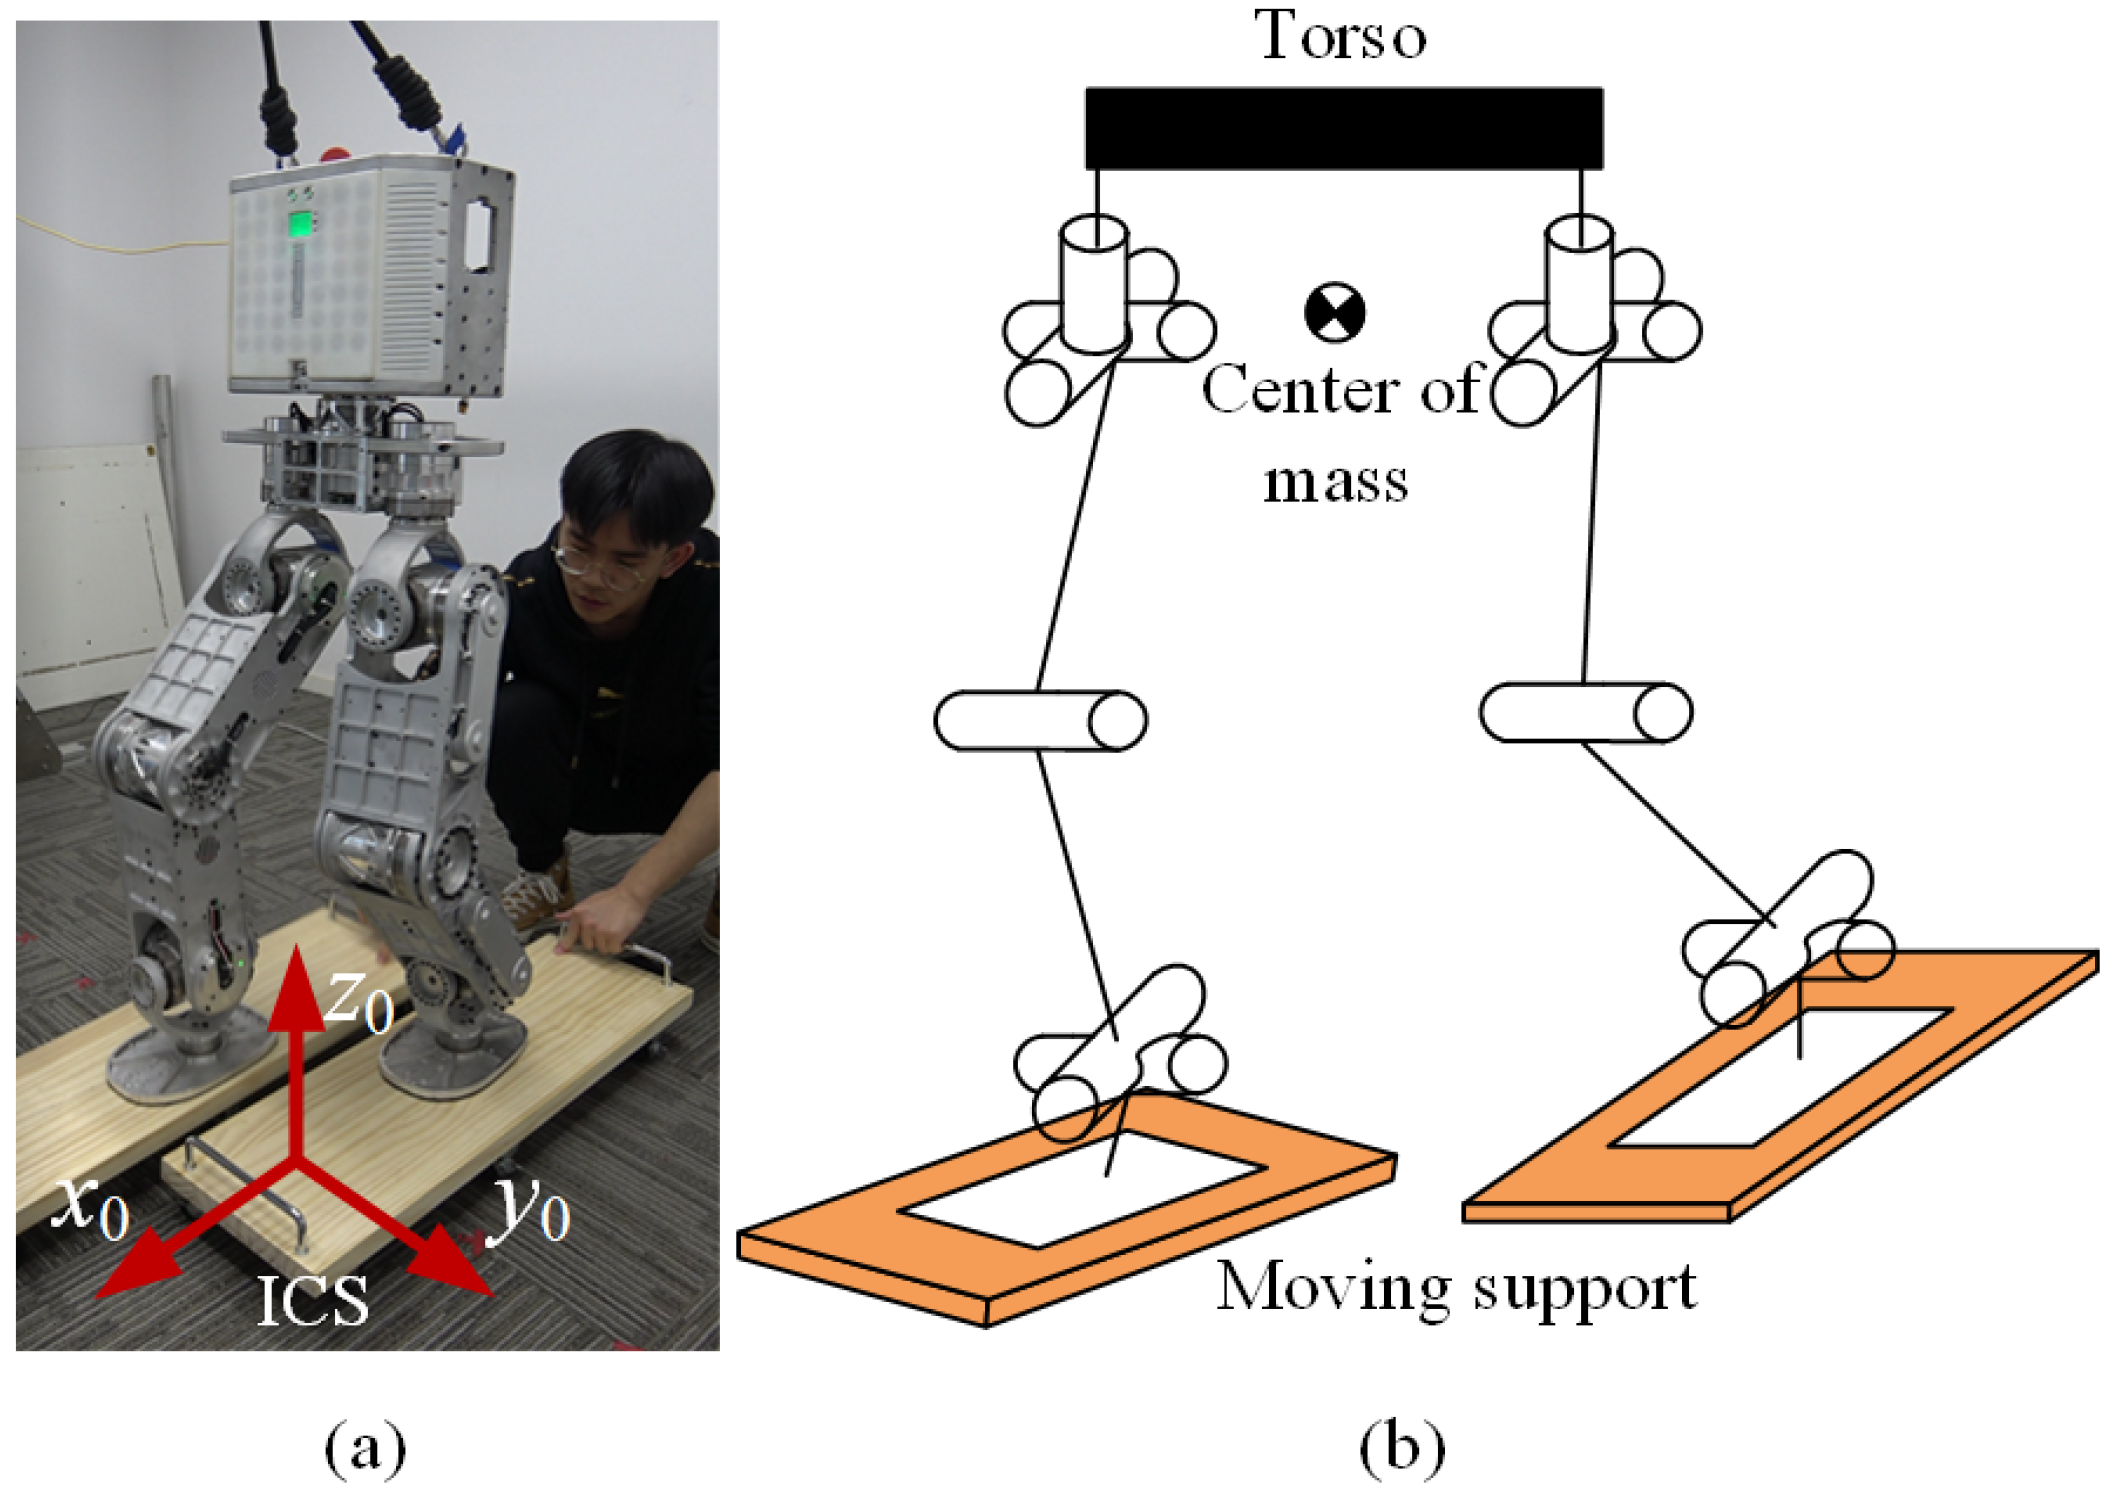
Dynamic Balancing of Humanoid Robot with Proprioceptive Actuation ...
Advertisement Space (336x280)

Frontiers | Control and evaluation of a humanoid robot with rolling ...

Frontiers | Control and evaluation of a humanoid robot with rolling ...

Frontiers | Control and evaluation of a humanoid robot with rolling ...

Figure 1 from Multi-contact MPC for Dynamic Loco-manipulation on ...
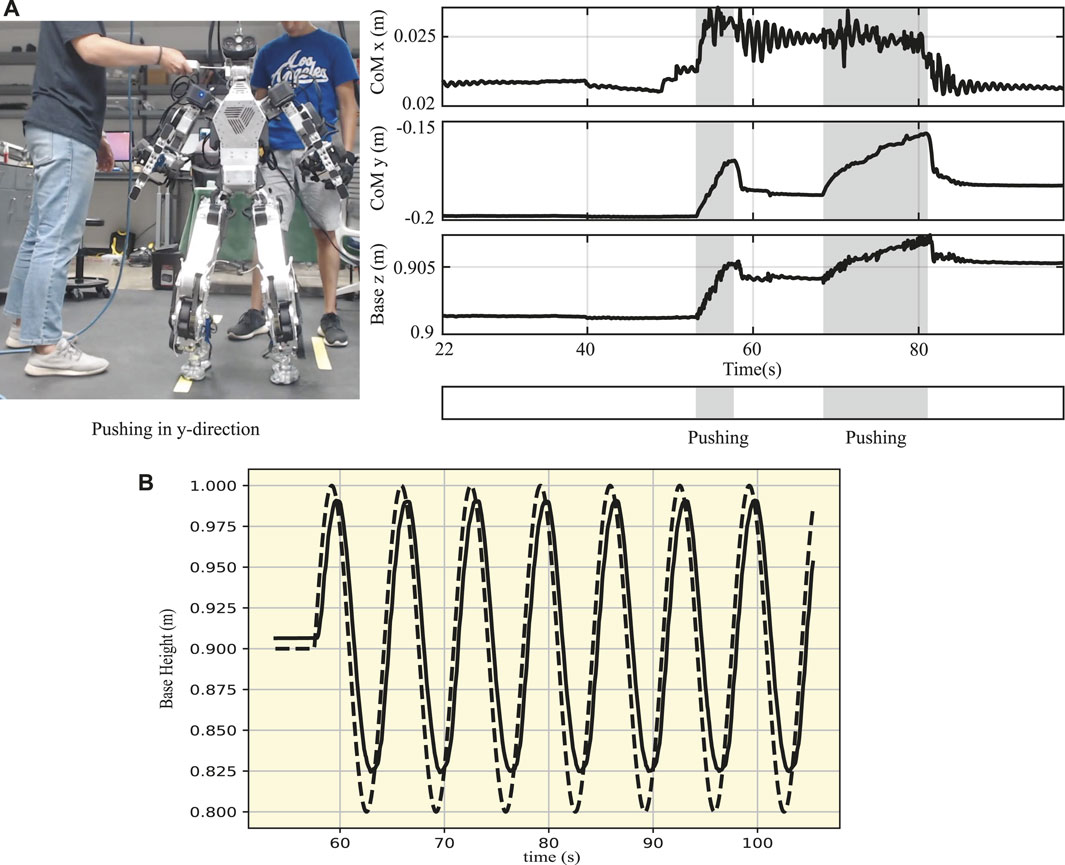
Frontiers | Control and evaluation of a humanoid robot with rolling ...

Real‐Time Control of a Humanoid Robot for Whole‐Body Tactile ...