
Figure 1 From Efficient Motion Planning For High Dof Hands Using
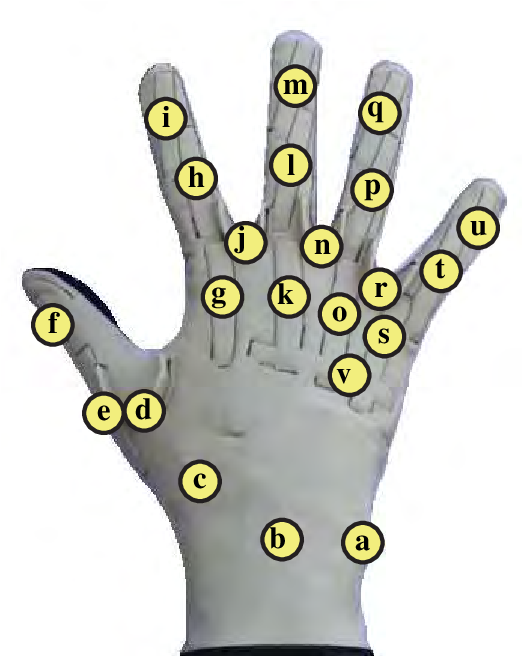
Figure 1 from Efficient motion planning for high DOF hands using ...

(PDF) Efficient motion planning for high DOF hands using principal ...

Figure 2 from Motion planning for high DOF anthropomorphic hands ...
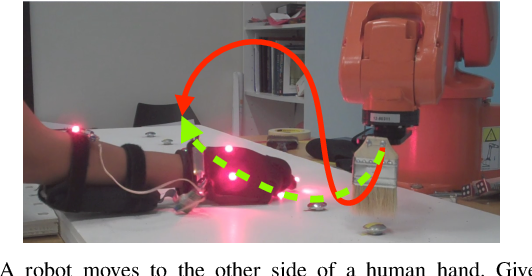
Figure 1 from Safe and Efficient High Dimensional Motion Planning in ...

Figure 1 from Fast Motion Planning for High-DOF Robot Systems Using ...

Figure 1 from Fast and Efficient Motion Planning Algorithm for CFETR ...

Figure 1 from Computational Efficient Motion Planning Method for ...

Figure 1 from Humanoid motion planning using multi-level DOF ...
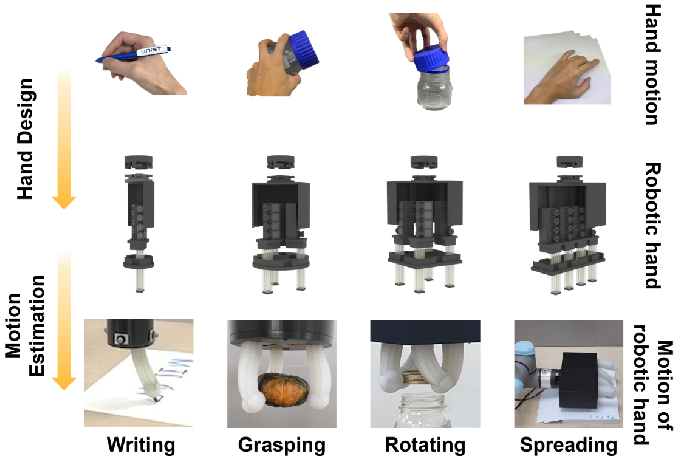
Figure 1 from High DOF Tendon-Driven Soft Hand: A Modular System for ...
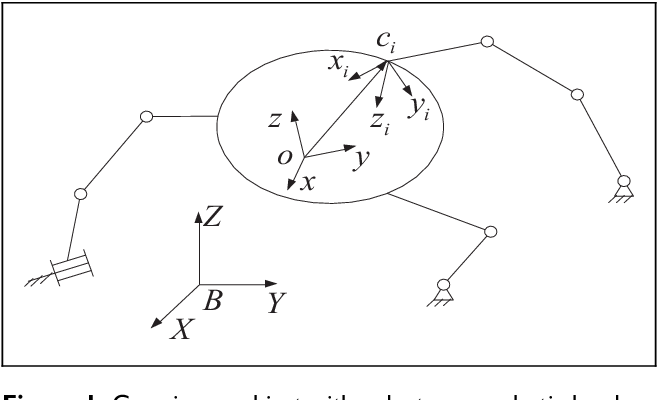
Figure 1 from Optimal grasp planning for a dexterous robotic hand using ...
Advertisement Space (300x250)
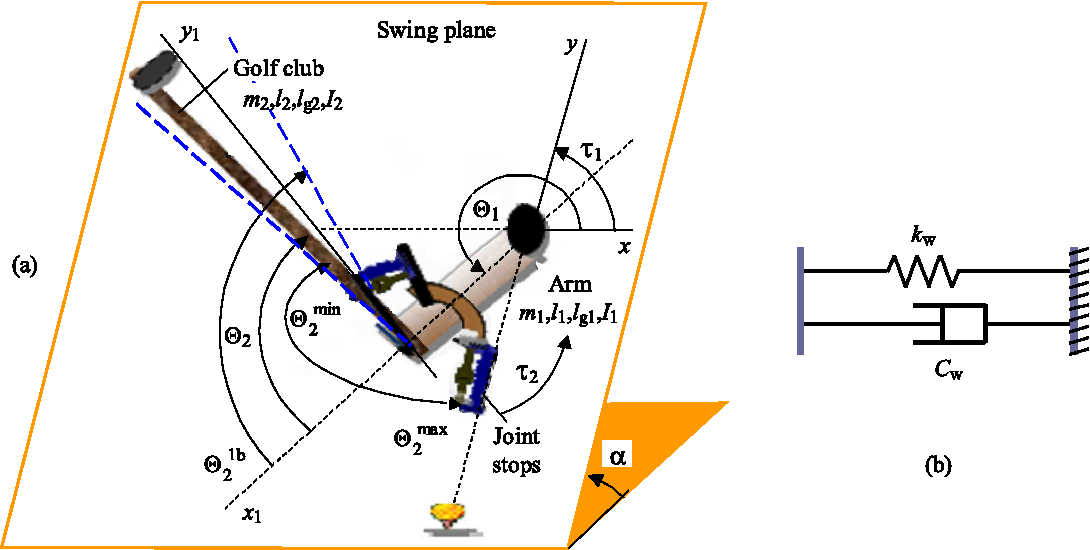
Figure 1 from Optimizing Motion Planning for Hyper Dynamic Manipulator ...
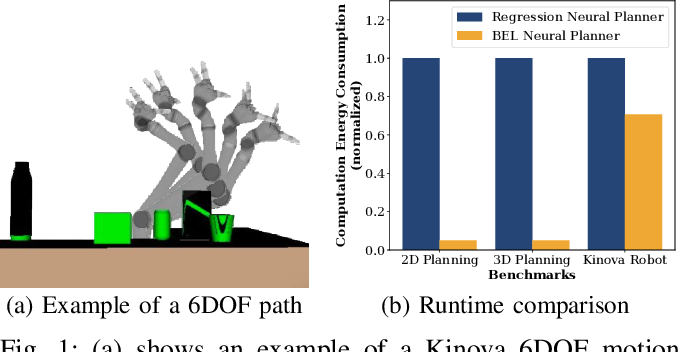
Figure 1 from Neural Encodings for Energy-Efficient Motion Planning ...

Figure 1 from A Plane-based Map for Wheel-legged Rover Efficient Motion ...

Figure 2 from Fast and Efficient Motion Planning Algorithm for CFETR ...

Figure 1 from Lazy Toggle PRM : An Efficient Motion Planning Strategy ...
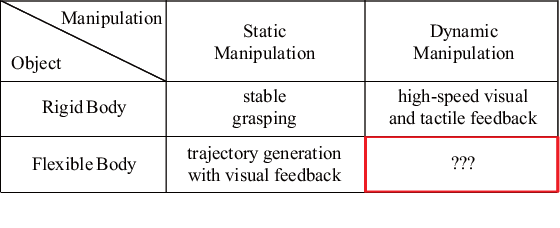
Figure 1 from Motion planning for dynamic knotting of a flexible rope ...

Self-Adaptive Robust Motion Planning for High DoF Robot Manipulator ...

Figure 1 from Learning a Hand Model From Dynamic Movements Using High ...

Figure 1 from A Survey of Optimization-Based Task and Motion Planning ...

Decoupled Motion Planning for High DOF Robots | PDF | Algorithms ...
Advertisement Space (336x280)

(PDF) Self-Adaptive Robust Motion Planning for High DoF Robot ...

Self-Adaptive Robust Motion Planning for High DoF Robot Manipulator ...

Figure 1 from Design of a Novel 1 DOF Hand Rehabilitation Robot for ...

Self-Adaptive Robust Motion Planning for High DoF Robot Manipulator ...

Figure 1 from CLEAR-MP: Clearance Learning-Based Efficient Motion ...
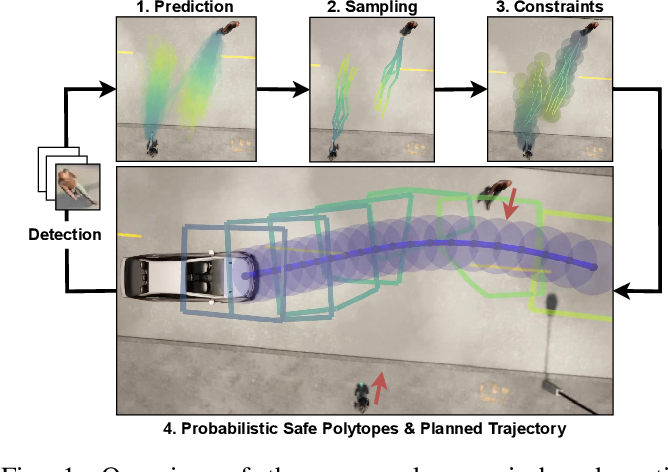
Figure 1 from Scenario-based motion planning with bounded probability ...
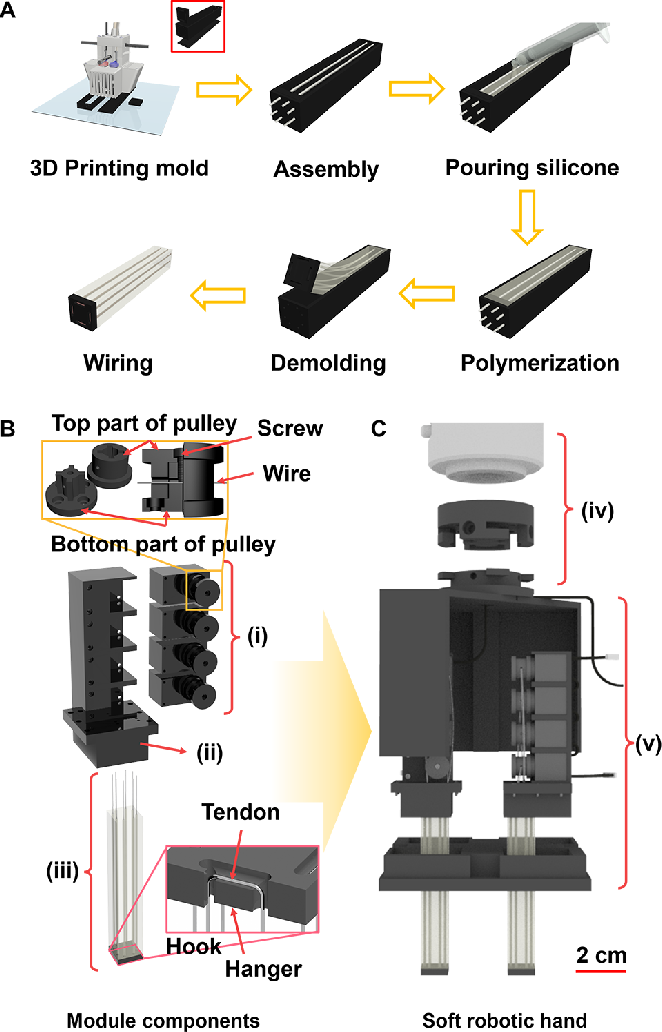
Figure 2 from High DOF Tendon-Driven Soft Hand: A Modular System for ...
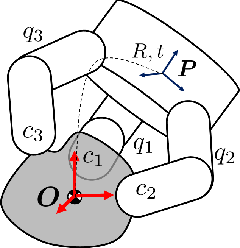
Figure 1 from optimization Model for Planning Precision Grasps with ...
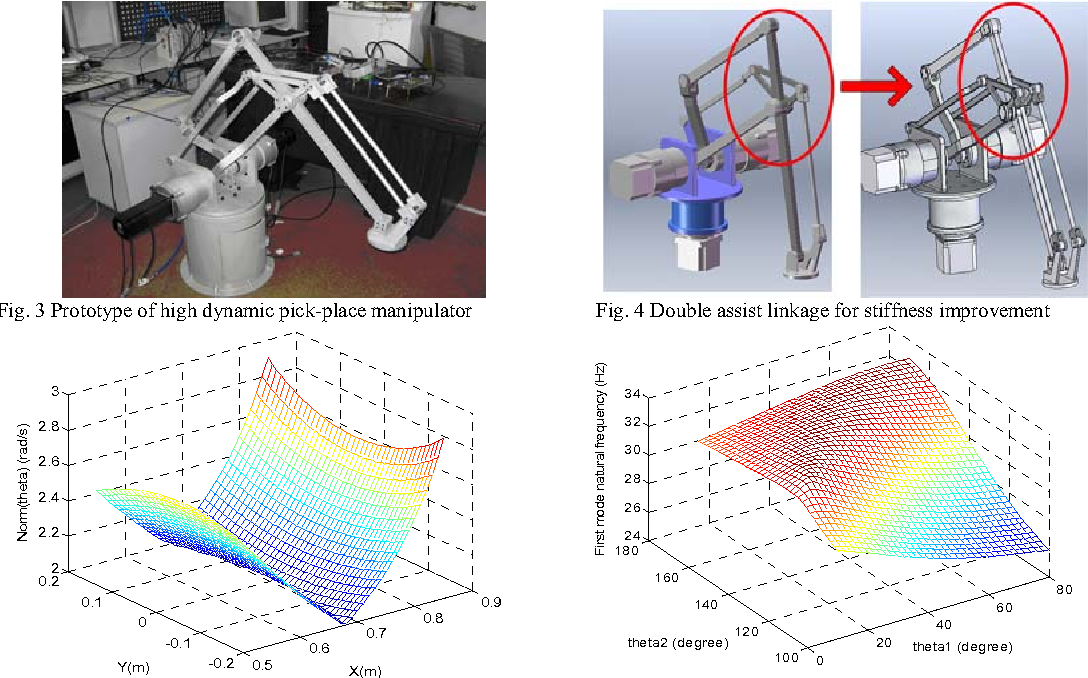
Figure 1 from Optimal design for a 2-dof high dynamic manipulator based ...
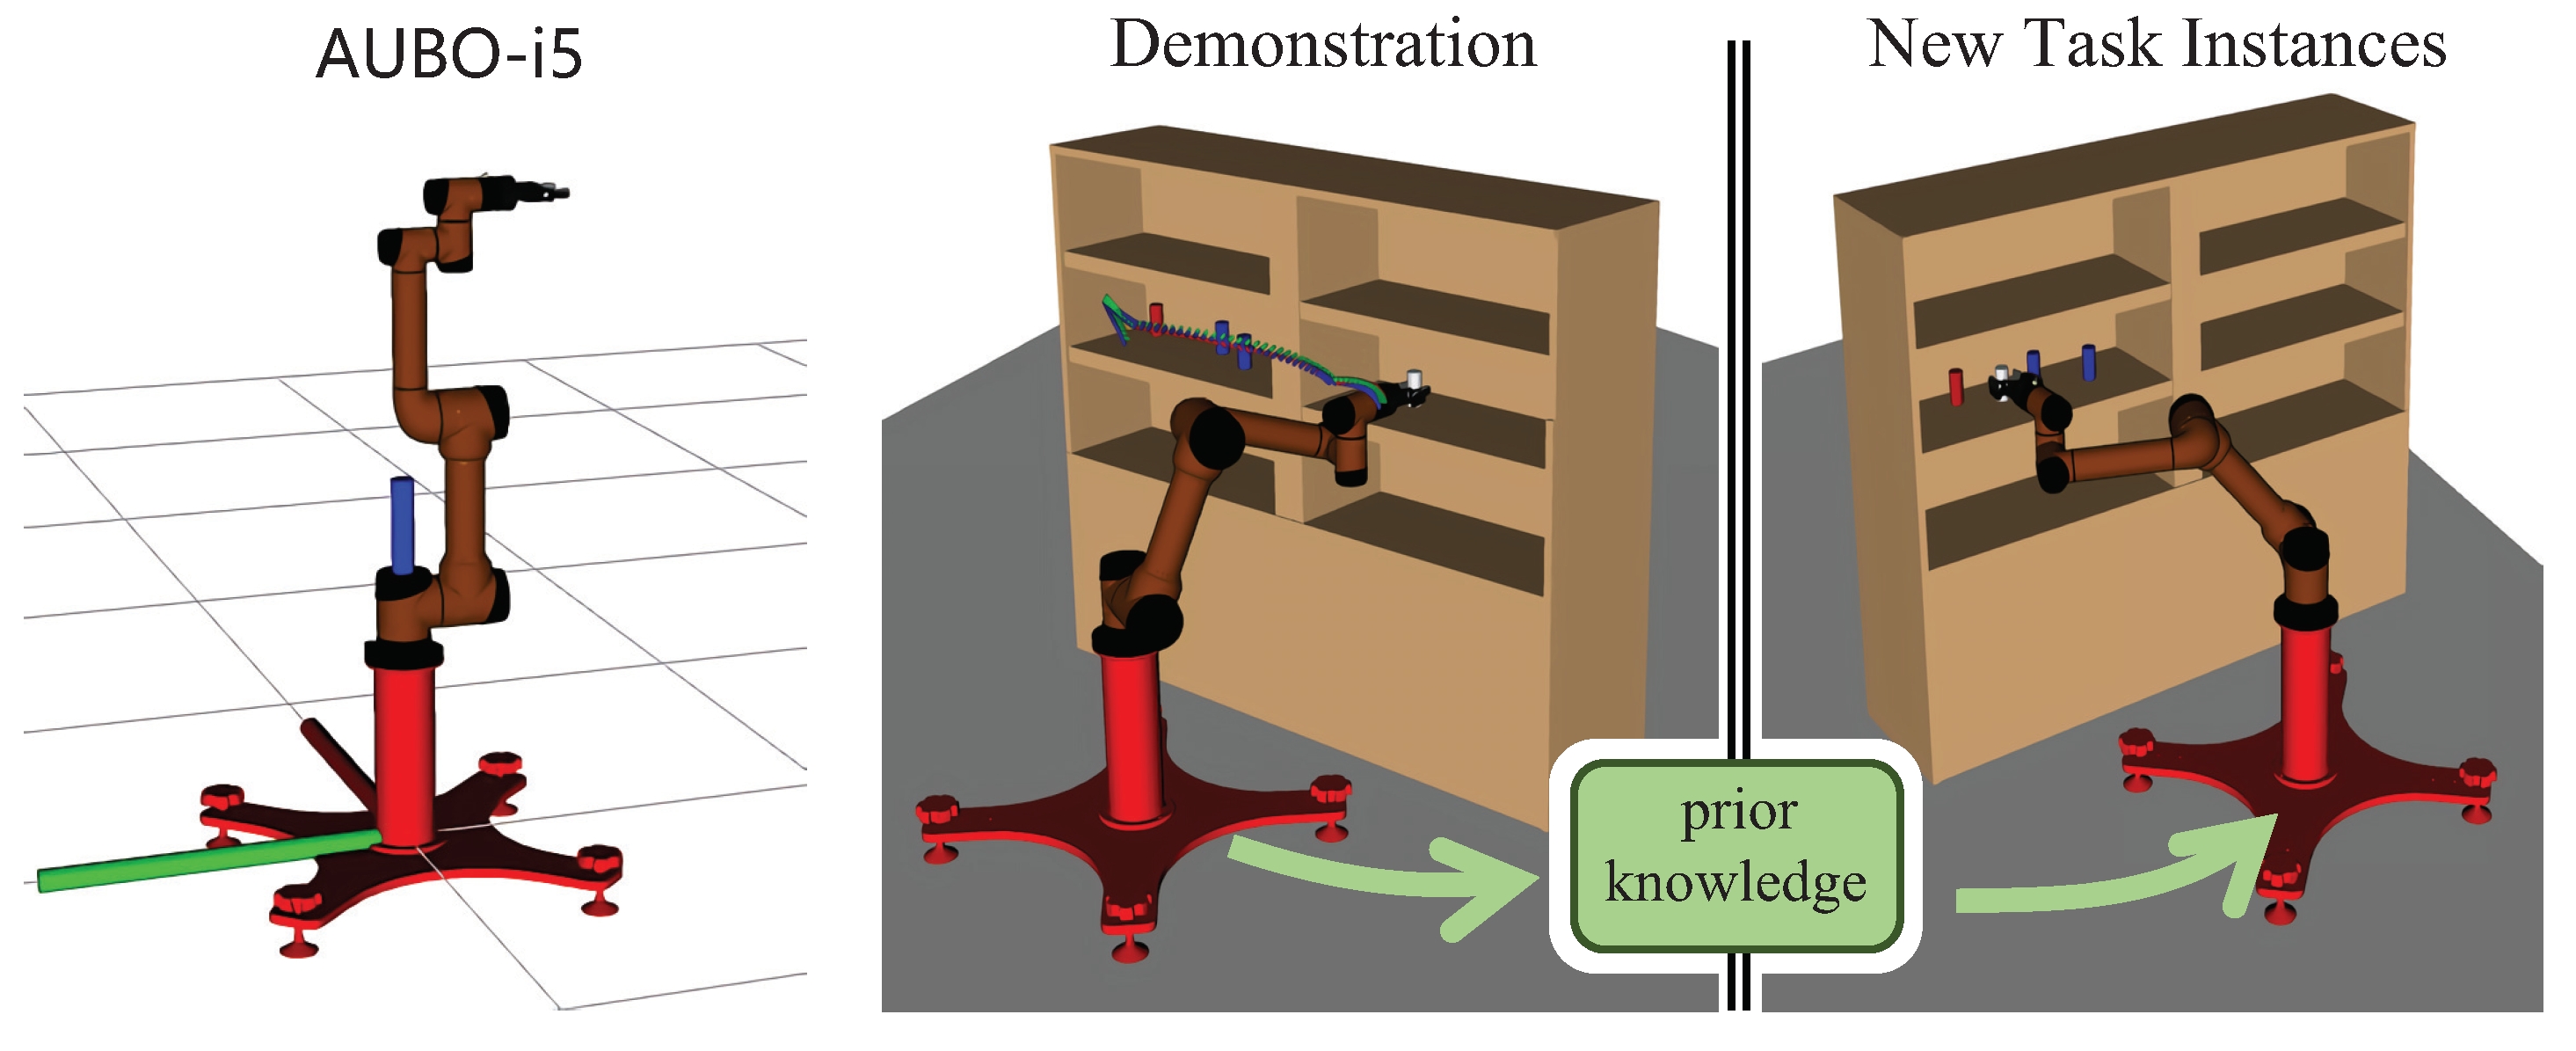
An Efficient Motion Planning Method with a Lazy Demonstration Graph for ...
Advertisement Space (336x280)
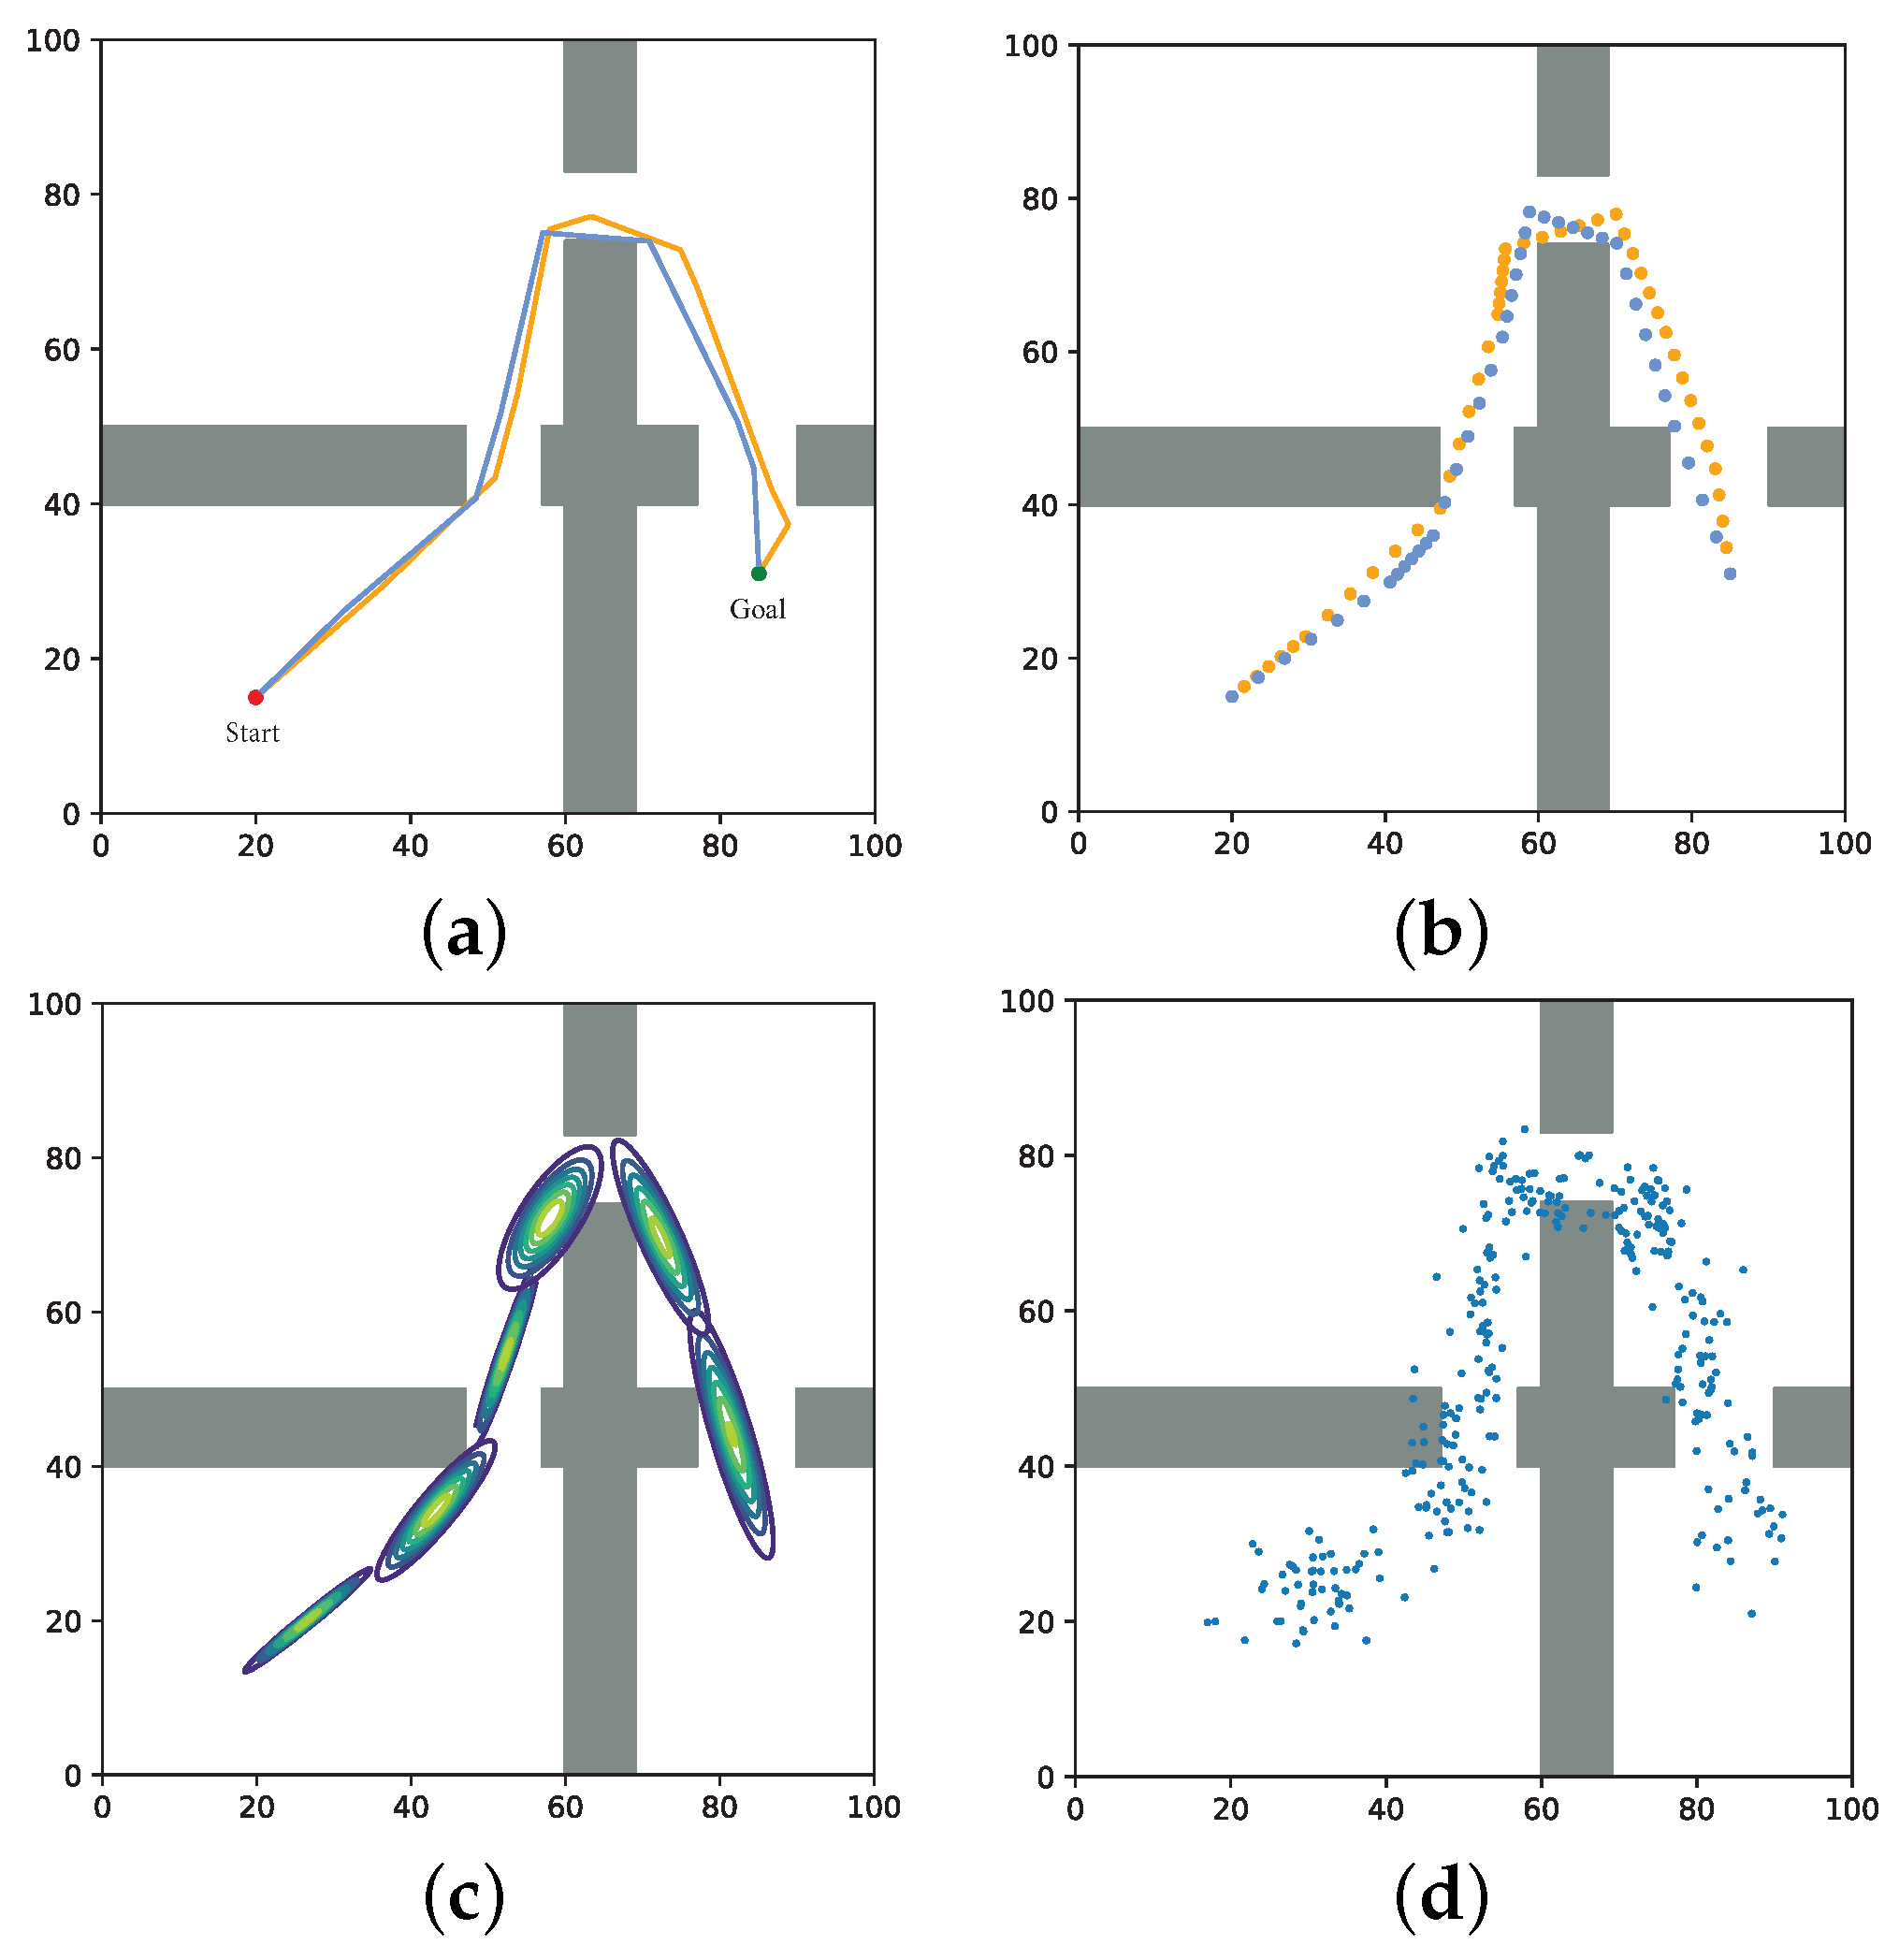
An Efficient Motion Planning Method with a Lazy Demonstration Graph for ...

Fast Motion Planning for High-DOF Robot Systems Using Hierarchical ...
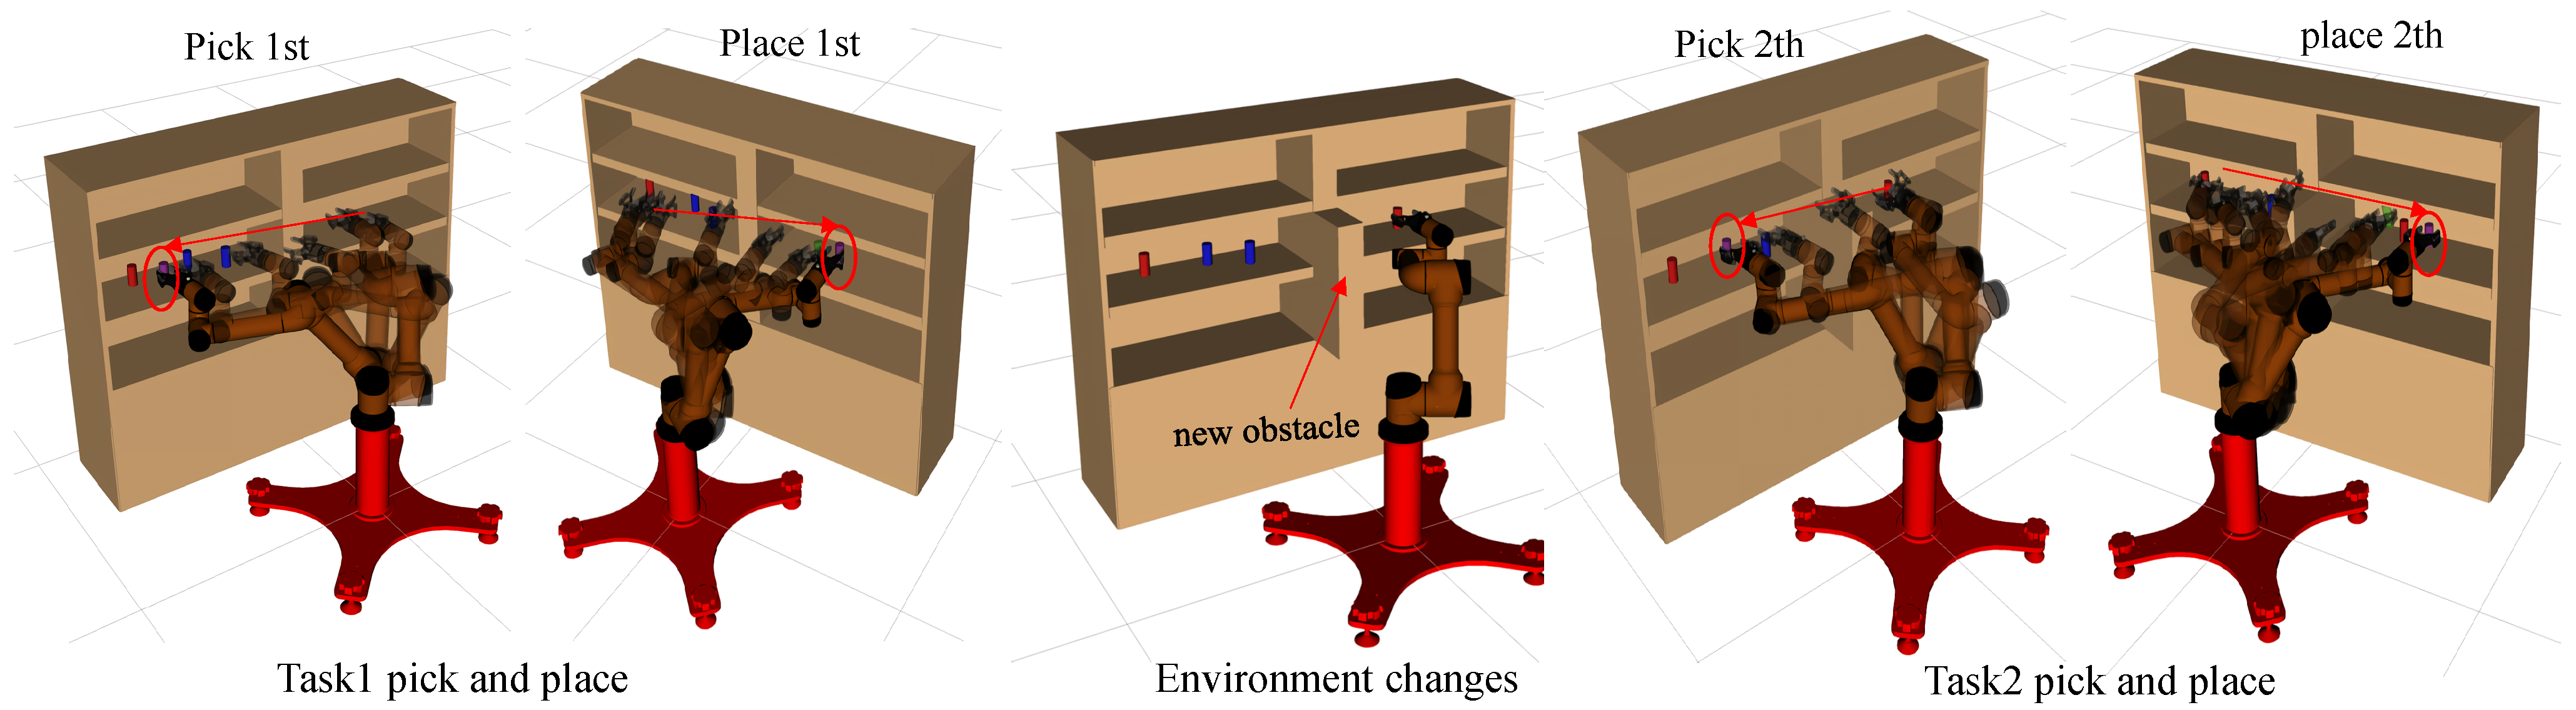
An Efficient Motion Planning Method with a Lazy Demonstration Graph for ...

Efficient Motion Planning for Manipulators with Control Barrier ...

Look as You Leap: Planning Simultaneous Motion and Perception for High ...
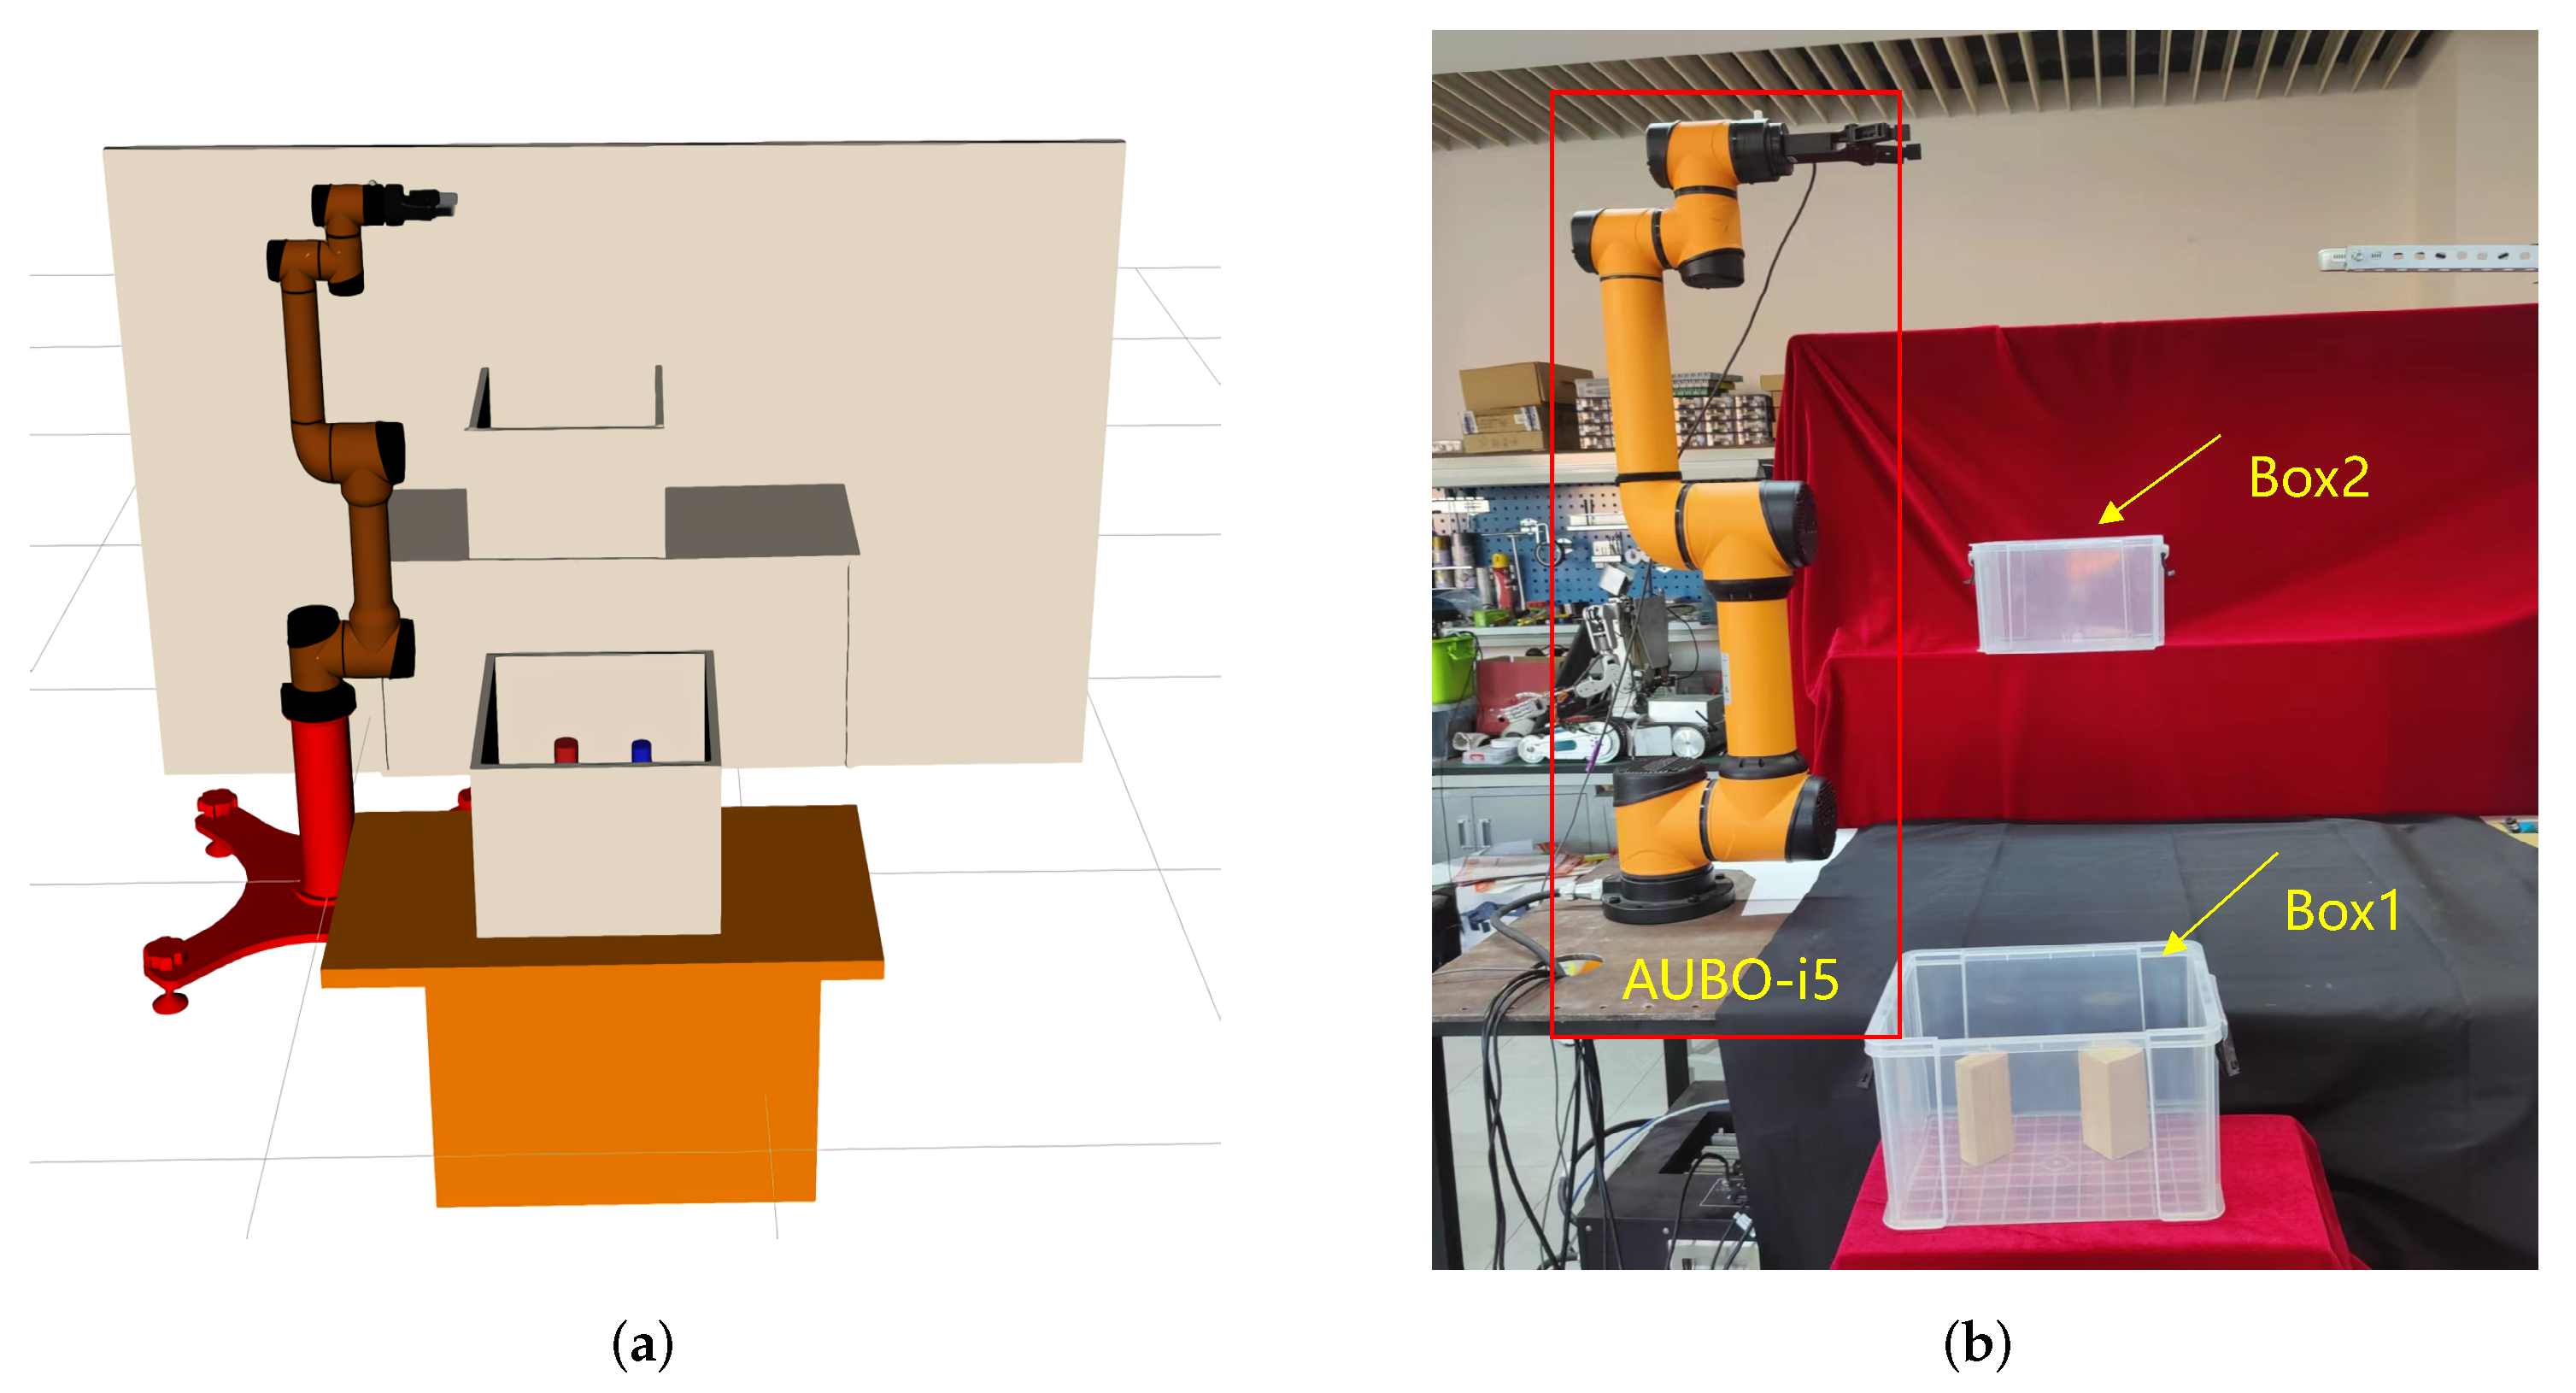
An Efficient Motion Planning Method with a Lazy Demonstration Graph for ...