
Figure 1 From Glas Global To Local Safe Autonomy Synthesis For Multi

Figure 1 from GLAS: Global-to-Local Safe Autonomy Synthesis for Multi ...
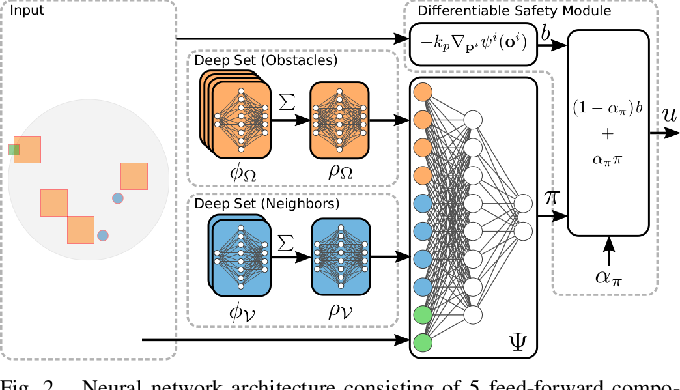
Figure 1 from GLAS: Global-to-Local Safe Autonomy Synthesis for Multi ...
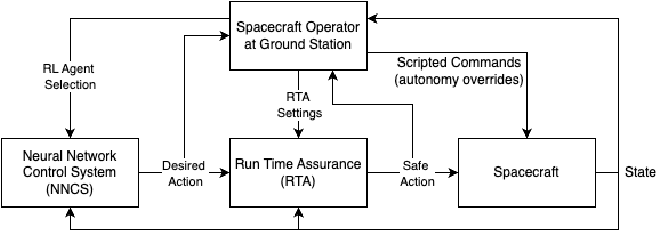
Figure 1 from The Safe Trusted Autonomy for Responsible Space Program ...
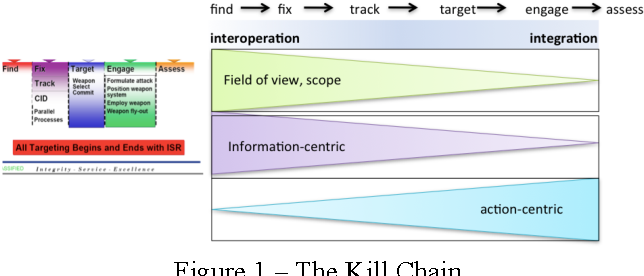
Figure 1 from A Modeling Framework for Synchronizing Global and Local ...

Figure 1 from Safe Autonomy for Uncrewed Surface Vehicles Using ...

Figure 1 from Parametric speech synthesis using local and global sparse ...
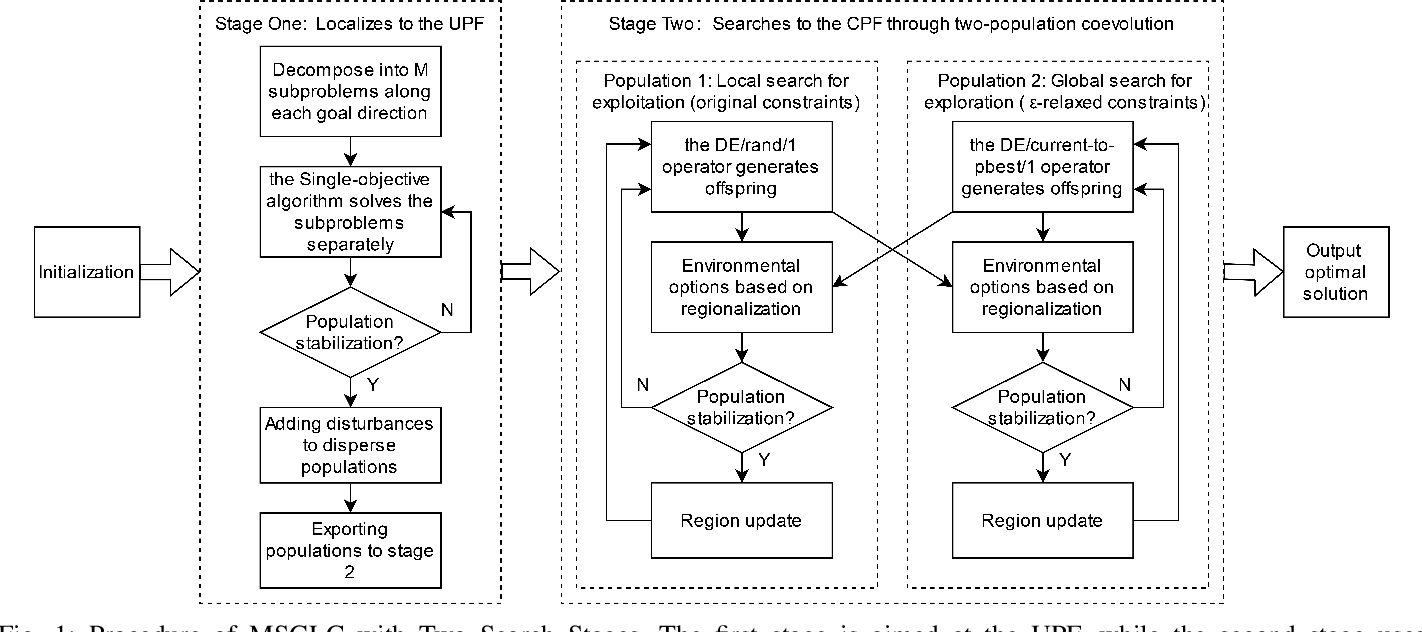
Figure 1 from Multi-stage Global and Local Cooperative Constrained ...

(PDF) Controller Synthesis for Local and Global Specifications in Multi ...
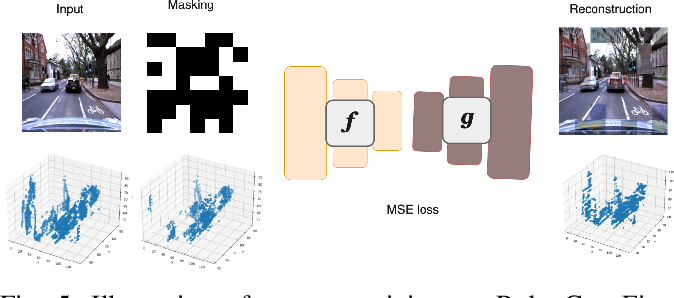
Figure 5 from Unifying Local and Global Multimodal Features for Place ...

Figure 1 from Comparison and synthesis of two aerospace case studies to ...
Advertisement Space (300x250)

Figure 2 from Chance-Constrained Control for Safe Spacecraft Autonomy ...

(PDF) GLAS: Global-to-Local Safe Autonomy Synthesis for Multi-Robot ...

(PDF) GLAS: Global-to-Local Safe Autonomy Synthesis for Multi-Robot ...
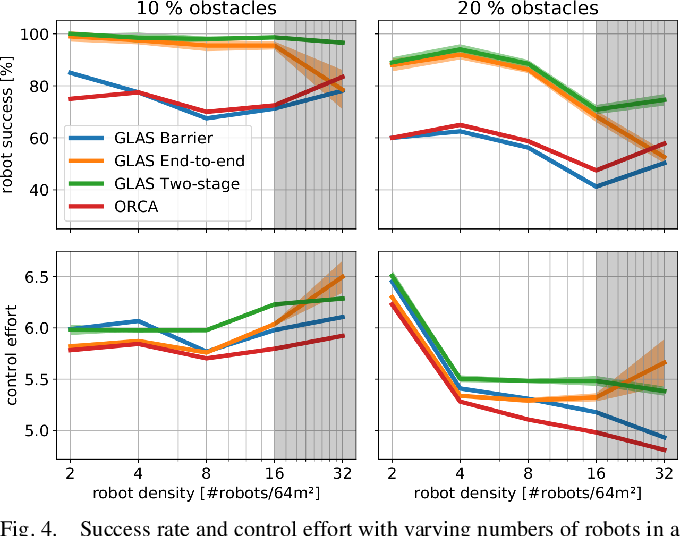
GLAS: Global-to-Local Safe Autonomy Synthesis for Multi-Robot Motion ...

Figure 1 from G3: An Effective and Adaptive Framework for Worldwide ...
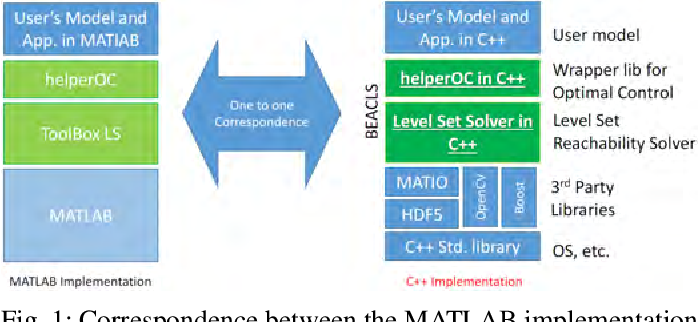
Figure 1 from Provably Safe and Scalable Multivehicle Trajectory ...

Figure 1 from Learner Autonomy: A Synthesis of Theory and Practice ...

GLFA-Net: A Hybrid Network for Mr-to-Ct Synthesis Via Global And Local ...
Formal Methods for Safe Autonomy Data-driven Verification, Synthesis ...
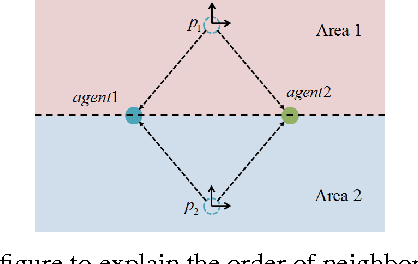
Figure 1 from Global convergence of formation in multi-agent systems ...
Advertisement Space (336x280)
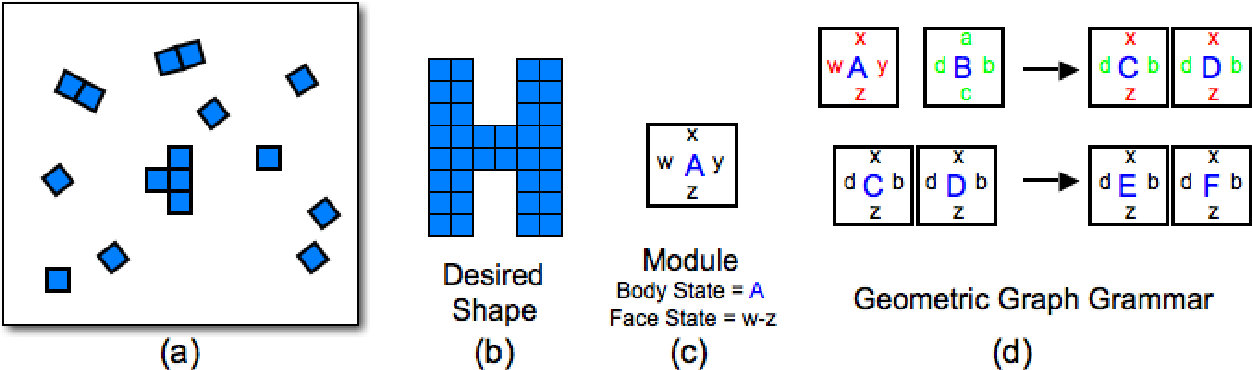
Figure 1 from Towards a Common Comparison Framework for Global-to-Local ...

【论文阅读】GLASS: Global to Local Attention for Scene-Text Spotting - 知乎

York Global Initiative for Safe Autonomy - Centre for Assuring Autonomy ...

GLAS (Global-to-Local Autonomy Synthesis) for Multi-Robot Motion ...

Diffusion-SAFE: Shared Autonomy Framework with Diffusion for Safe Human ...

Figure 2 from Multi-modal Gated Mixture of Local-to-Global Experts for ...

To Inform and Delight: Employing Synthesis for Scholarship That Shines ...

Finding the Right Balance Between Local Autonomy and Global Control ...

Synthesis of Provably Correct Autonomy Protocols for Shared Control

Formal Methods for Safe Autonomy: Data-driven Verification, Synthesis ...
Advertisement Space (336x280)

An Improved Global and Local Fusion Path-Planning Algorithm for Mobile ...

Balancing Local Autonomy and Global Strategy: Tips and Tricks

Formal Methods for Safe Autonomy: Data-driven Verification, Synthesis ...
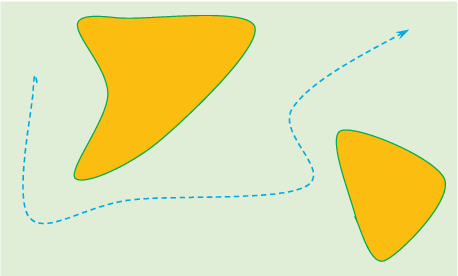
Figure 1 from Dynamics-Constrained Global-Local Hybrid Path Planning of ...

[논문 리뷰] Safe Autonomy for Uncrewed Surface Vehicles Using Adaptive ...

An Improved Global and Local Fusion Path-Planning Algorithm for Mobile ...