
Figure 1 From Kinematic And Dynamic Models Of Hyper Redundant
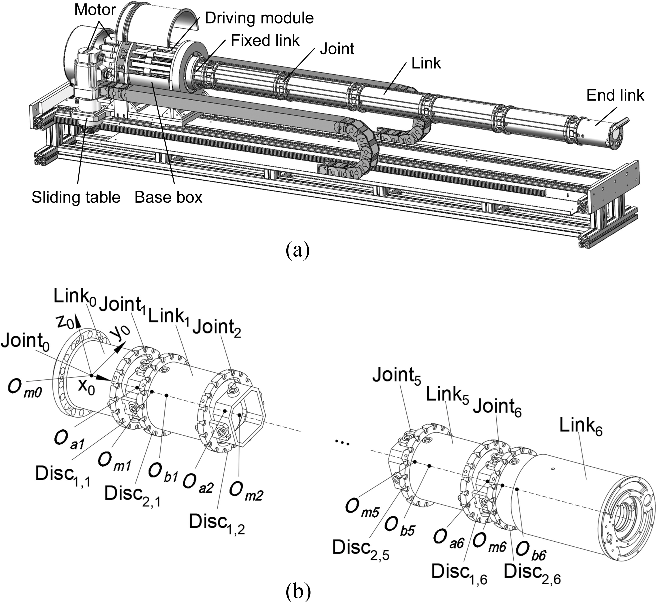
Figure 1 from Kinematic and Dynamic Models of Hyper -Redundant ...

Figure 3 from Kinematic and Dynamic Models of Hyper -Redundant ...

Figure 4 from Kinematic and Dynamic Models of Hyper -Redundant ...

Figure 5 from Kinematic and Dynamic Models of Hyper -Redundant ...
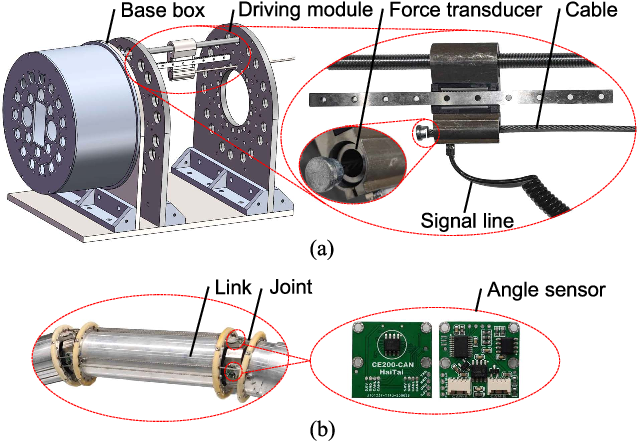
Figure 8 from Kinematic and Dynamic Models of Hyper -Redundant ...

Figure 1 from Kinematic and Dynamic Manipulability Optimizations of ...

Table II from Kinematic and Dynamic Models of Hyper -Redundant ...

Figure 1 from Kinematic and Dynamic Manipulability Optimizations of ...
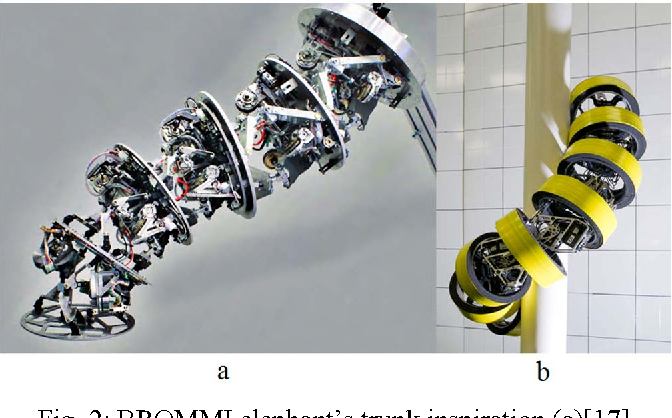
Figure 2 from Kinematic modeling of hyper redundant robot using ball ...

Figure 1 from Kinematic Compatible Design and Analysis of a Back ...
Advertisement Space (300x250)

(PDF) Kinematic and Dynamic Models of Hyper-Redundant Manipulator Based ...

Figure 1 from A Framework for Kinematic Modeling and Trajectory ...
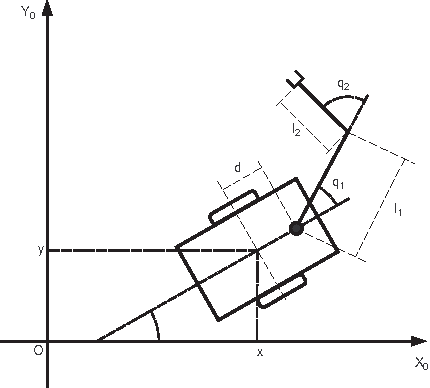
Figure 1 from Kinematic modeling and redundancy resolution for ...
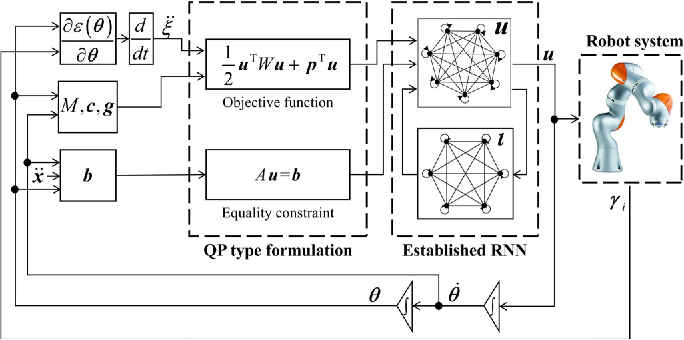
Figure 1 from A Kinematics Control Scheme of Redundant Manipulators ...
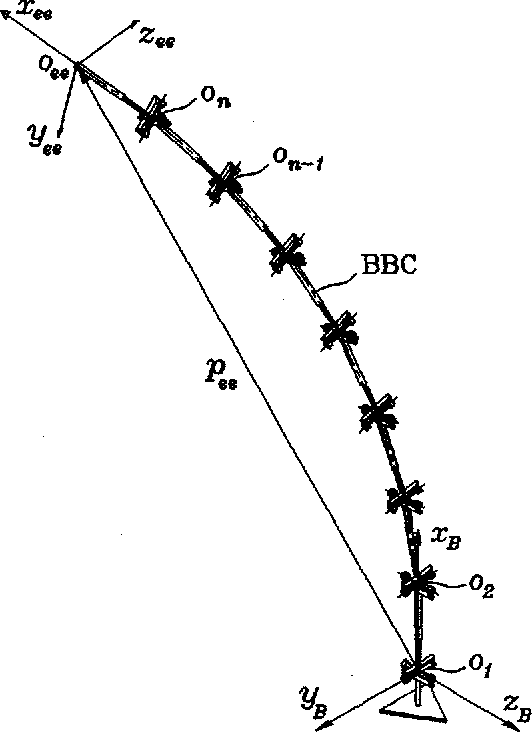
Figure 1 from A discrete model for the configuration control of hyper ...

Figure 1 from Kane's method-based dynamic modeling and triple ...
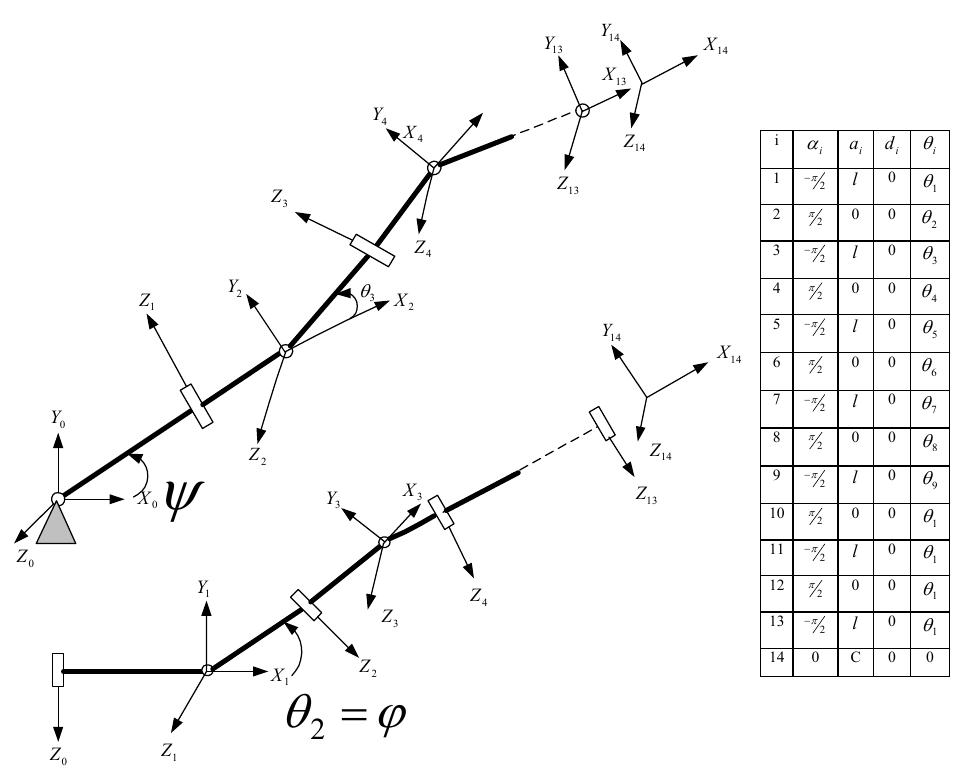
Figure 1 - from A mobile hyper redundant mechanism for
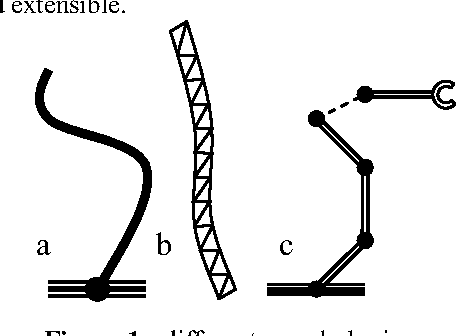
Figure 1 from Modeling of hyper-redundant manipulators dynamics and ...
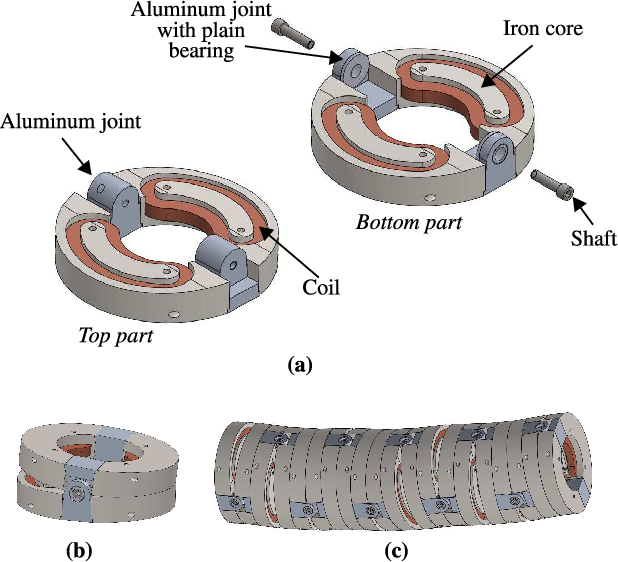
Figure 1 from The kinematic synthesis of a spatial, hyper-redundant ...

Figure 1 from A Dynamic Programming Framework for Optimal Planning of ...
Advertisement Space (336x280)

Figure 1 from Research on Dynamics Modeling and Obstacle Avoidance ...

Figure 1 from A Closed-Form Solution for the Inverse Kinematics of the ...
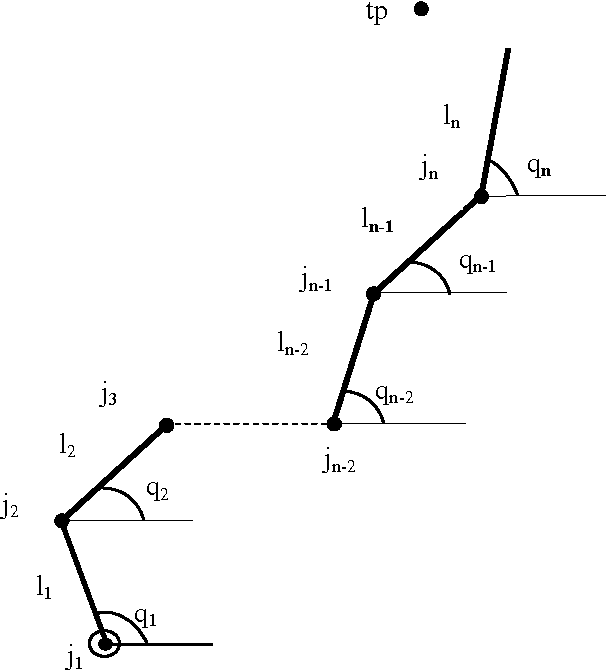
Figure 1 from A geometrical inverse kinematics method for hyper ...
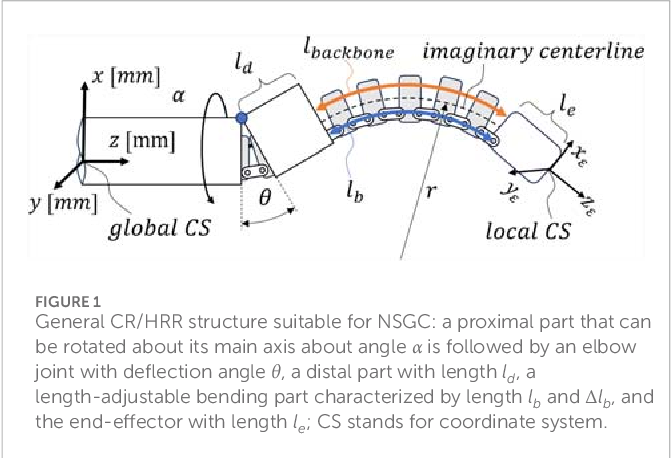
Figure 1 from A projection-based inverse kinematic model for extensible ...

Figure 1 from Generating optimal reference kinematic configurations for ...

Figure 1 from Kinematic Modelling for Hyper-Redundant Robots—A ...

Figure 1 from RRT-Based Path Planning for Follow-the-Leader Motion of ...
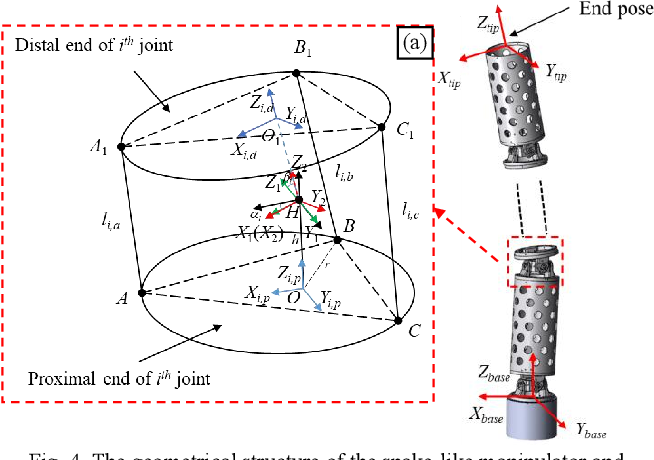
Figure 1 from RRT-Based Path Planning for Follow-the-Leader Motion of ...
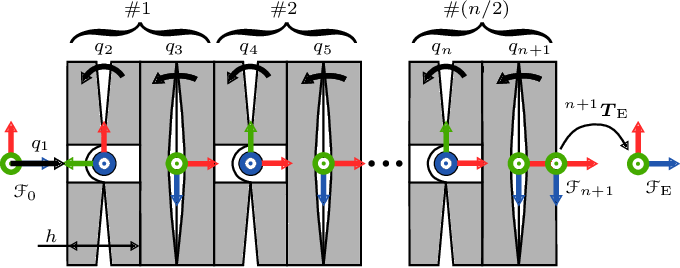
Figure 1 from Intuitive Telemanipulation of Hyper-Redundant Snake ...

Figure 1 from A Kinematically Redundant (6+1)-dof Hybrid Parallel Robot ...
Advertisement Space (336x280)
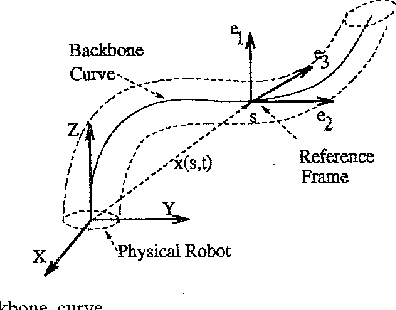
Figure 1 from The kinematics of hyper-redundant robot locomotion ...
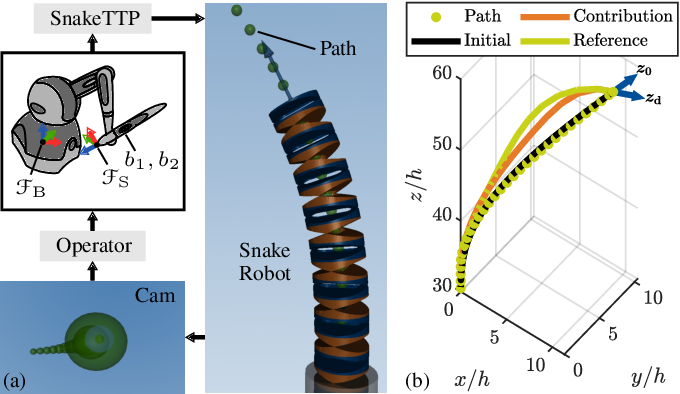
Figure 1 from Intuitive Telemanipulation of Hyper-Redundant Snake ...

Figure 2 from A Framework for Kinematic Modeling and Trajectory ...
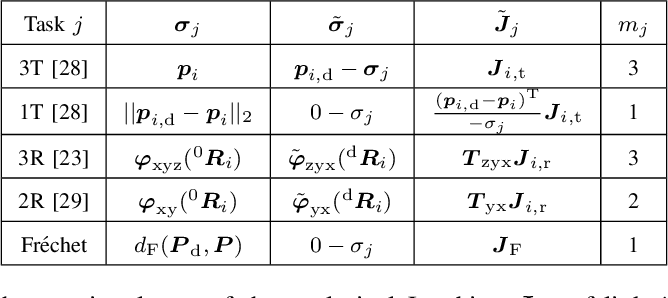
Figure 1 from Intuitive Telemanipulation of Hyper-Redundant Snake ...

Figure 2 from Redundancy resolution and control of a novel spatial ...

Figure 1 from Bald Eagle Search Algorithm for High Precision Inverse ...