
Figure 1 From Learning Based Control For Deployment Of Tethered Space

Figure 1 from Learning-Based Control for Deployment of Tethered Space ...

Figure 1 from Data-Driven Optimal Control of Tethered Space Robot ...
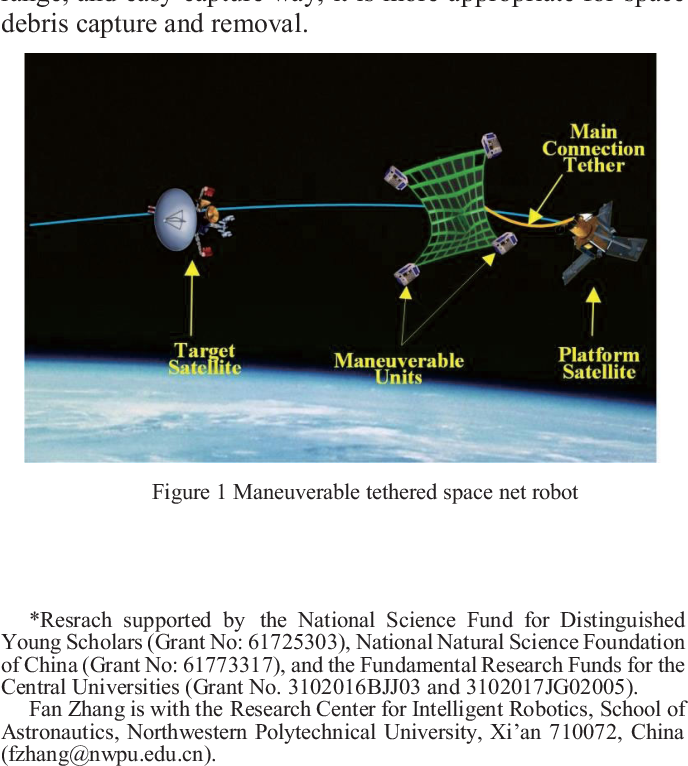
Figure 1 from Trajectory Tracking Control for an Tethered Space Net ...

Figure 1 from Learning fuzzy control parameters for kite-based tethered ...

Figure 2 from Adaptive super-twisting control for deployment of space ...
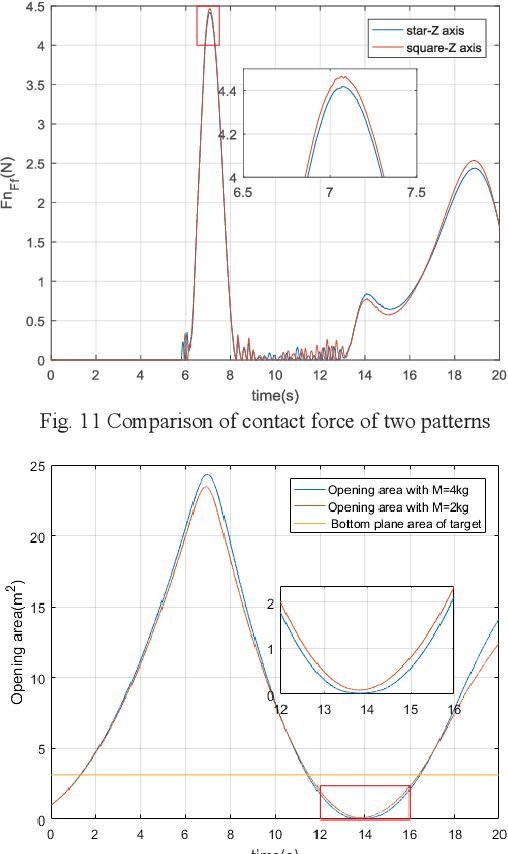
Figure 11 from Deployment Dynamics of Tethered Space Net Based on ...
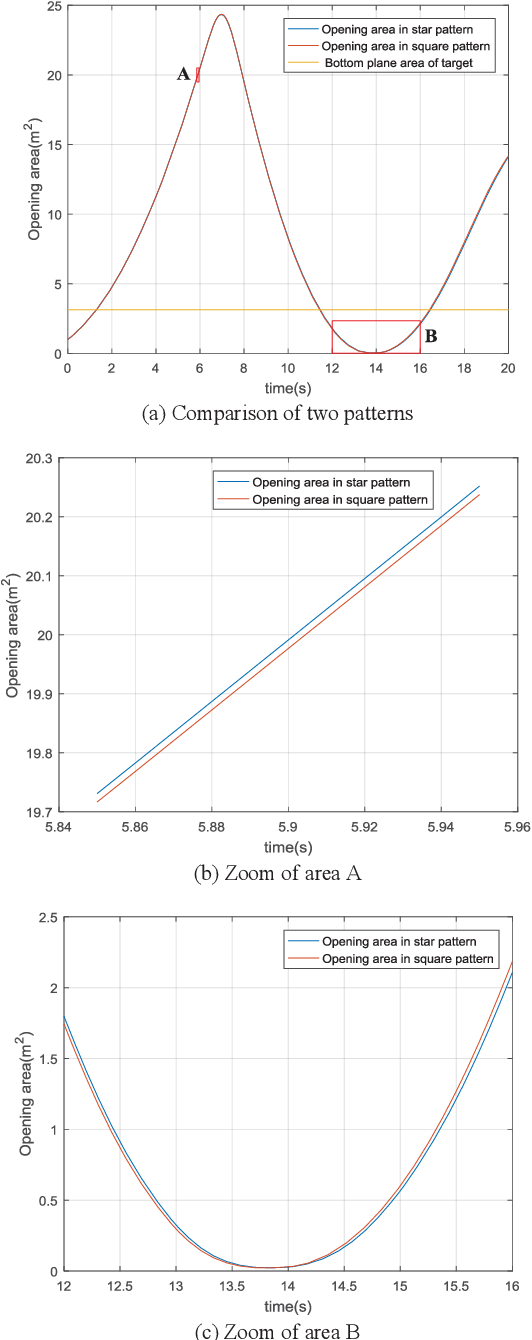
Figure 10 from Deployment Dynamics of Tethered Space Net Based on ...
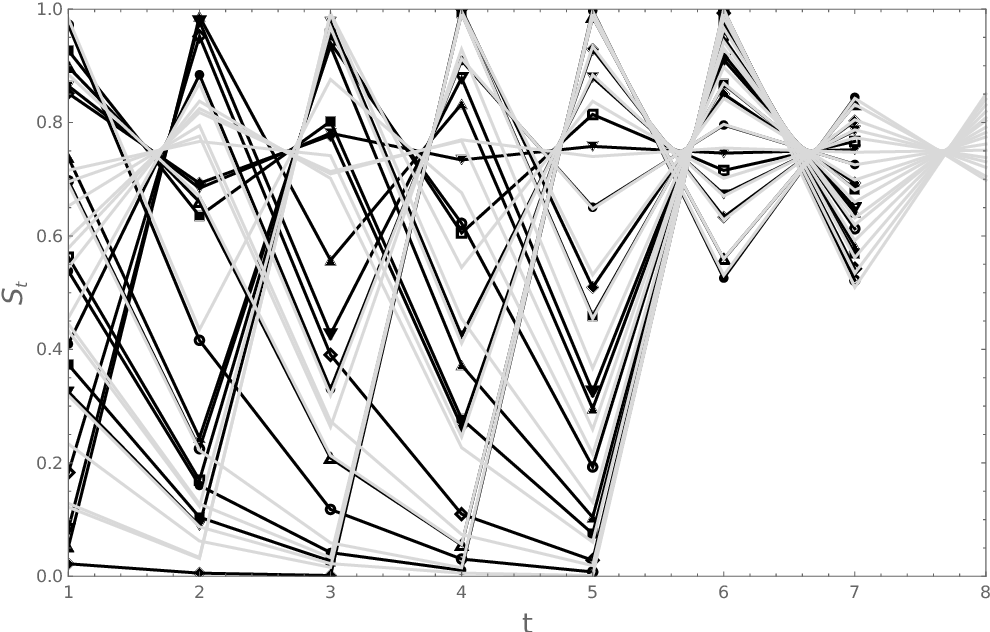
Figure 1 from A machine learning based control of chaotic systems ...
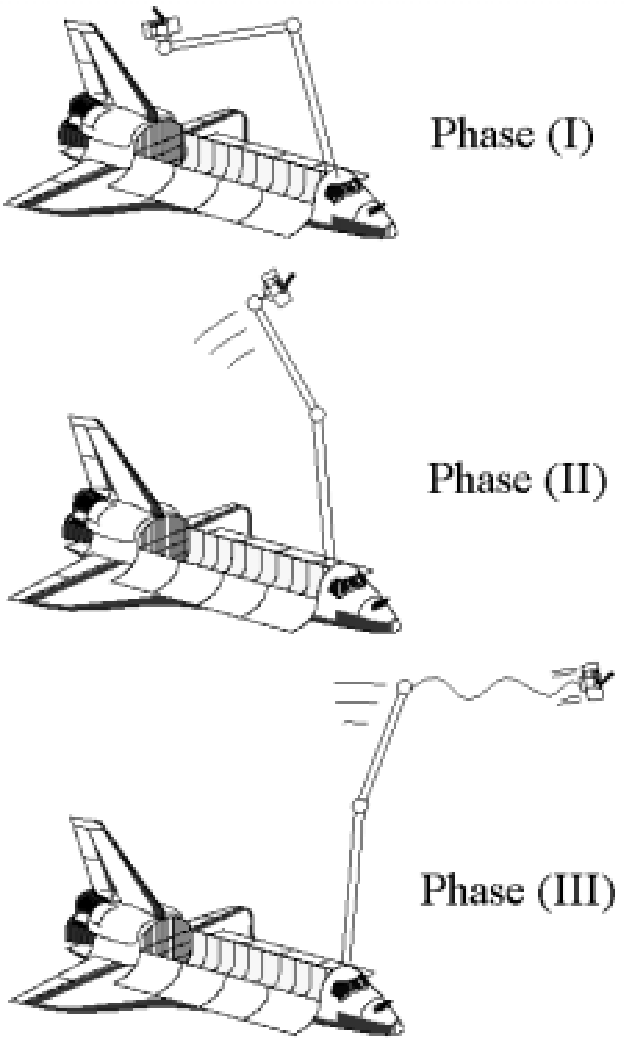
Figure 1 from Trajectory Adjustment Control of Tethered Object During ...

Figure 1 from Human-Assisted Regulation of the Deployment of a Tethered ...
Advertisement Space (300x250)

Table 1 from Data-Driven Optimal Control of Tethered Space Robot ...

Figure 1 from Observer-Based Control of Position and Tension for an ...

Figure 1 from Active Learning-Based Control for Resiliency of Uncertain ...

Figure 1 from Adaptive Neural Network Dynamic Surface Control of the ...
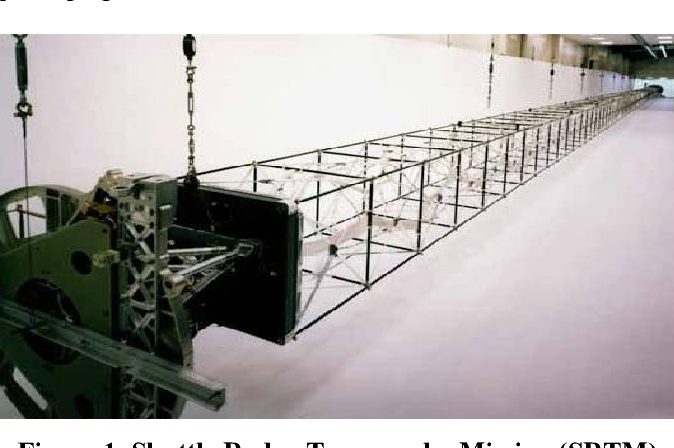
Figure 1 from Learning-based control scheme to deploy modular space ...
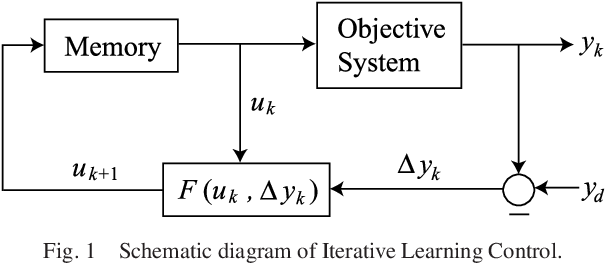
Figure 1 from Task-Space Iterative Learning for Redundant Robotic ...

Figure 2 from An Effective Approach Control Scheme for the Tethered ...

Figure 1 from Hierarchical Learning-Based Control for Multi-Agent ...
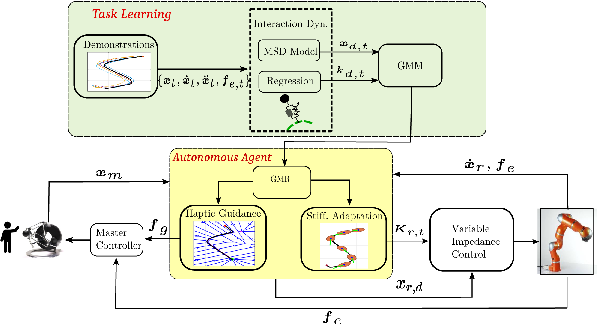
Figure 1 from A Learning-Based Shared Control Approach for Contact ...
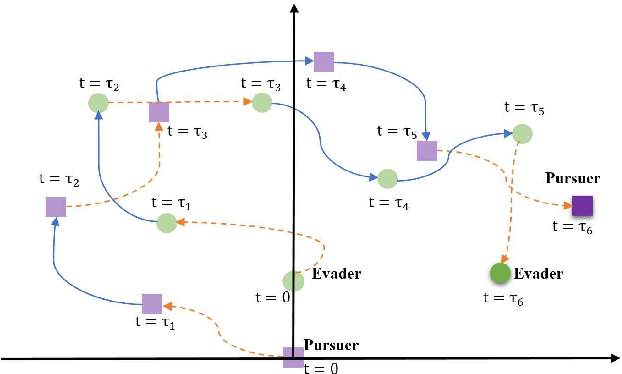
Figure 1 from Learning-Based Control Policy and Regret Analysis for ...
Advertisement Space (336x280)
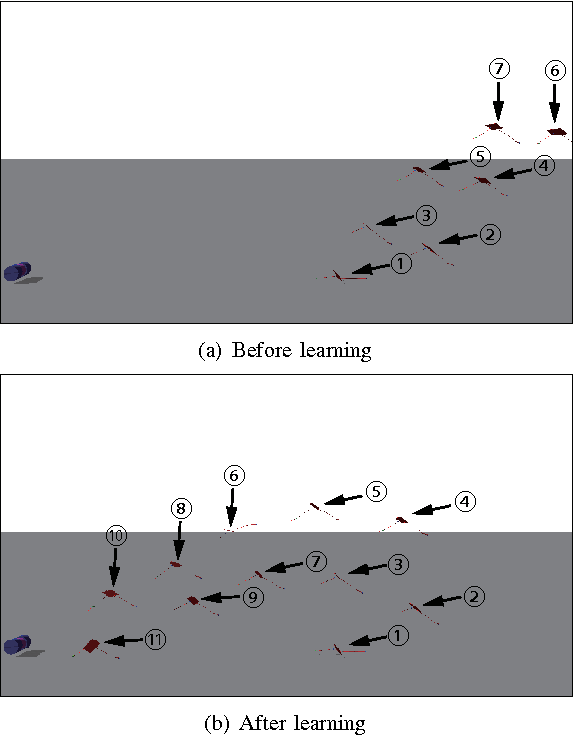
Figure 11 from Learning fuzzy control parameters for kite-based ...

Figure 1 from Reinforcement Learning-based Control of Nonlinear Systems ...

Figure 14 from New Sensor and Actuator for Space Tether Control ...
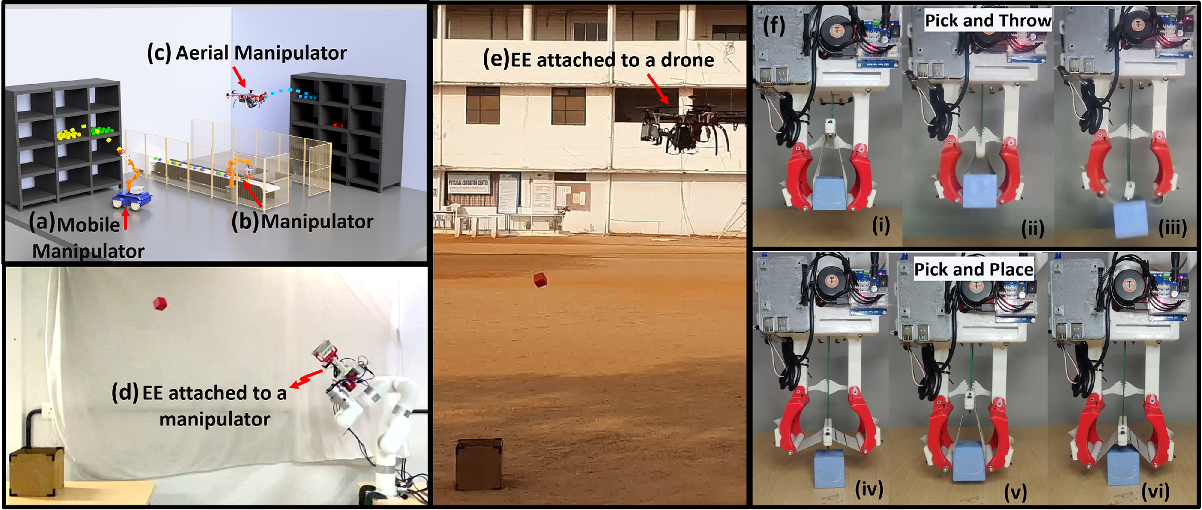
Figure 1 from Identification and Learning-Based Control of an End ...

Figure 1 from Deep Reinforcement Learning-Based Control Framework for ...
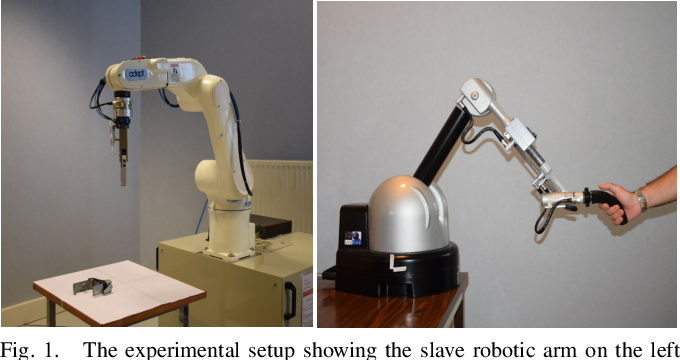
Figure 1 from A learning-based shared control architecture for ...

Figure 1 from Deep reinforcement learning-based control framework for ...

Figure 1 from Learning-based Control and Estimation for Attitude ...

Figure 1 from Design of a Rule-Based Tuned PID Controller for Tether ...

Neural Operator based Reinforcement Learning for Control of first-order ...
Advertisement Space (336x280)

(PDF) Observer-based control for the platform of a tethered space robot
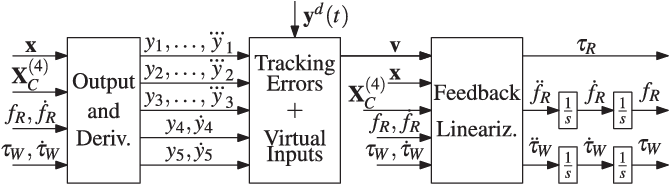
Figure 2 from Observer-Based Control of Position and Tension for an ...
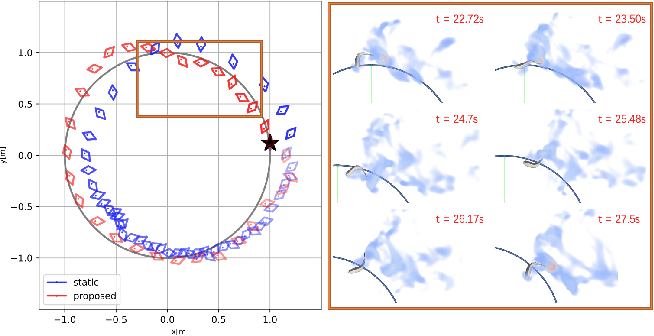
Figure 1 from Exploring Learning-Based Control Policy for Fish-Like ...

Figure 1 from Hierarchical Reinforcement Learning Based Multi-Agent ...

Figure 1 from Hierarchical Reinforcement Learning Based Multi-Agent ...

Hamiltonian formulation and energy-based control for space tethered ...