
Figure 1 From Learning H Infinity Locomotion Control Semantic Scholar
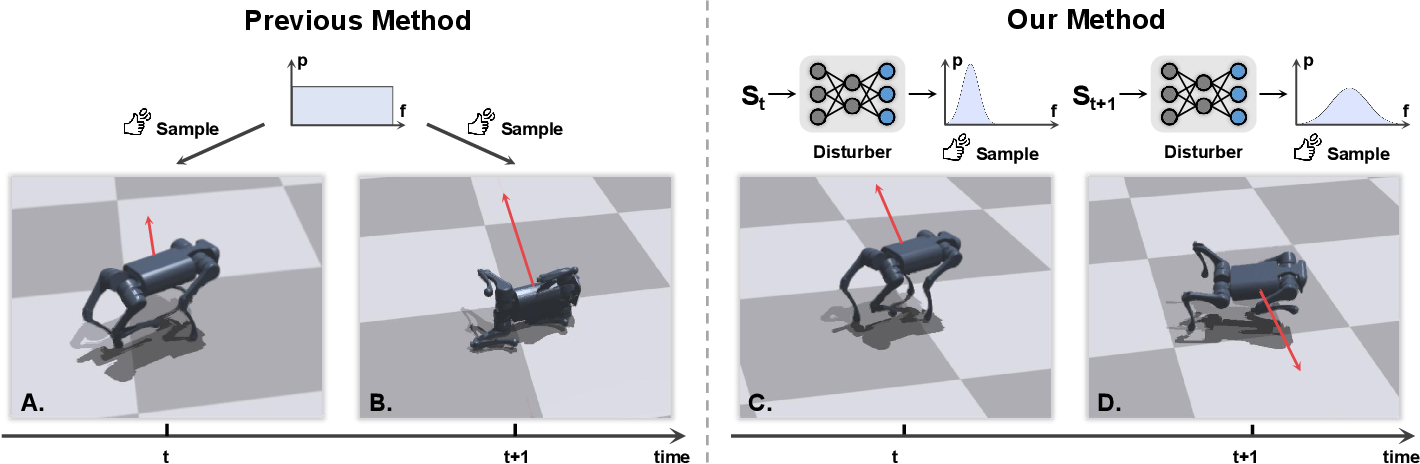
Figure 1 from Learning H-Infinity Locomotion Control | Semantic Scholar

Figure 6 from Learning H-Infinity Locomotion Control | Semantic Scholar

Figure 2 from Learning H-Infinity Locomotion Control | Semantic Scholar

Figure 4 from Learning H-Infinity Locomotion Control | Semantic Scholar
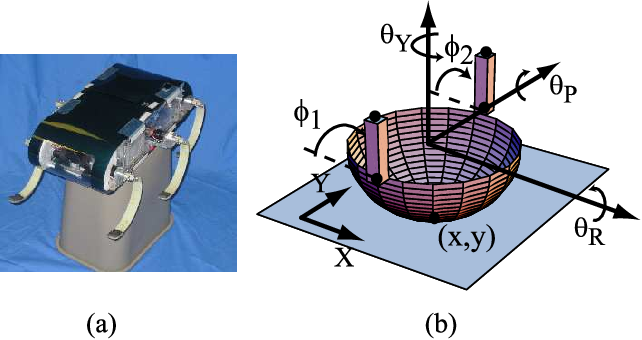
Figure 1 from Toward Legless Locomotion Control | Semantic Scholar
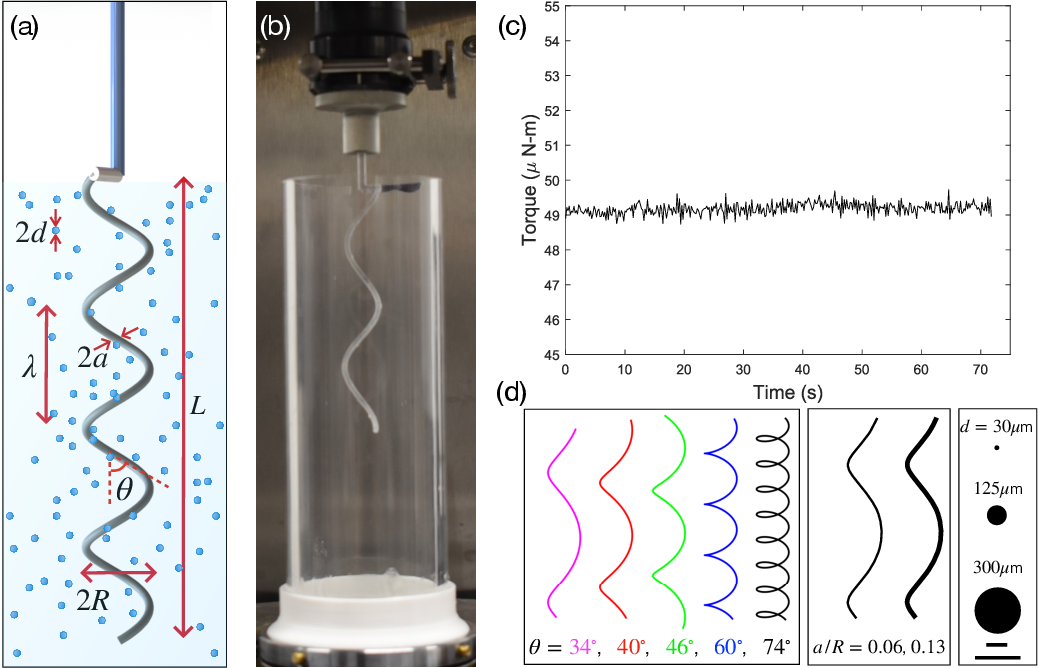
Figure 1 from Helical locomotion in dilute suspensions | Semantic Scholar

Figure 1 from Distributed H 2 /H infinity Consensus Control and ...
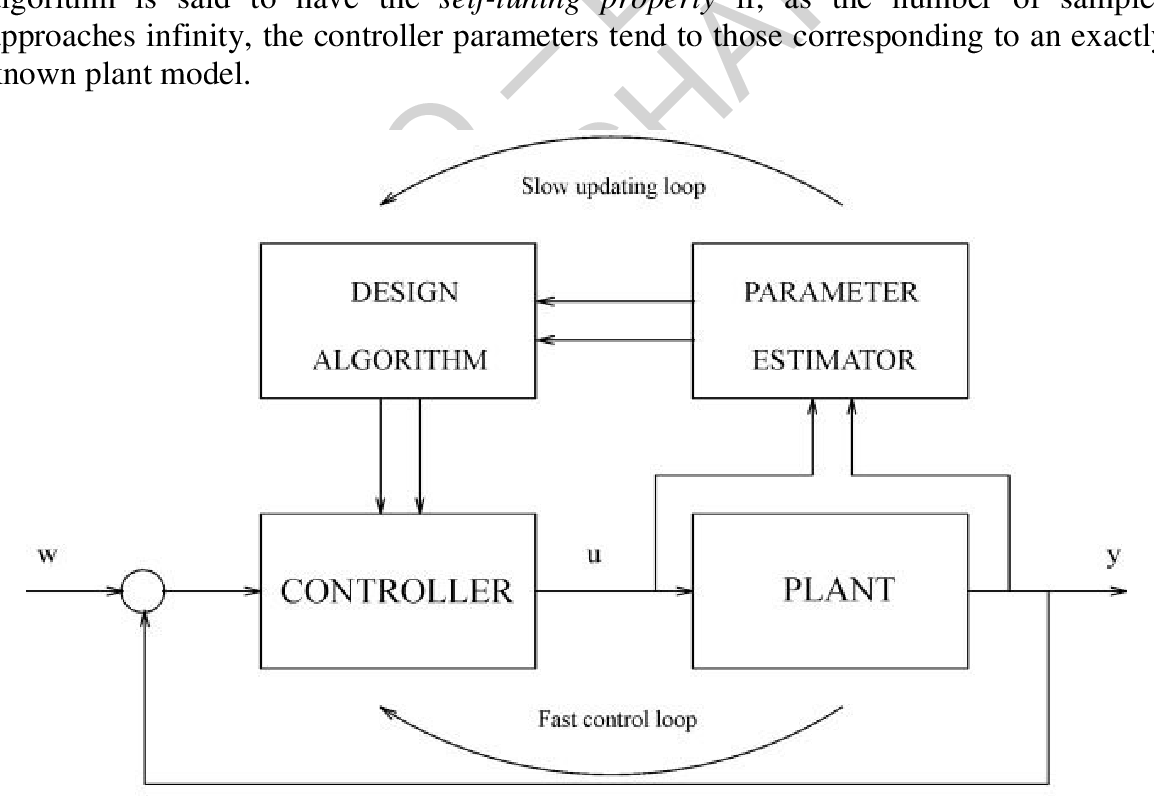
Figure 1 from ADAPTIVE PREDICTIVE CONTROL | Semantic Scholar
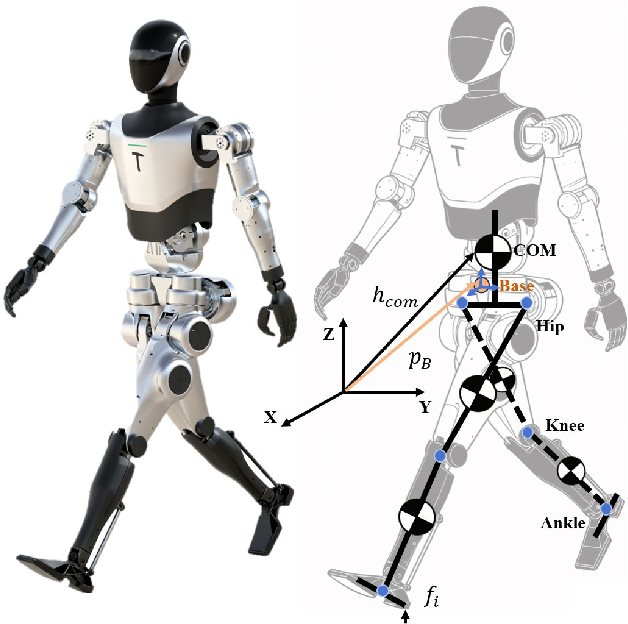
Figure 1 from Intelligent Reinforcement Learning and Control for ...

Figure 1 from Humanoid Robot Locomotion Control based on Perceptive ...
Advertisement Space (300x250)
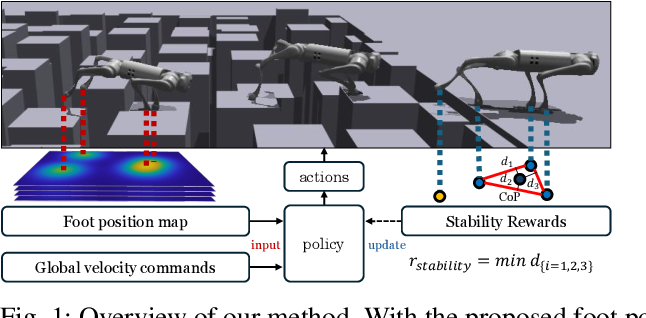
Figure 1 from Learning Locomotion on Complex Terrain for Quadrupedal ...
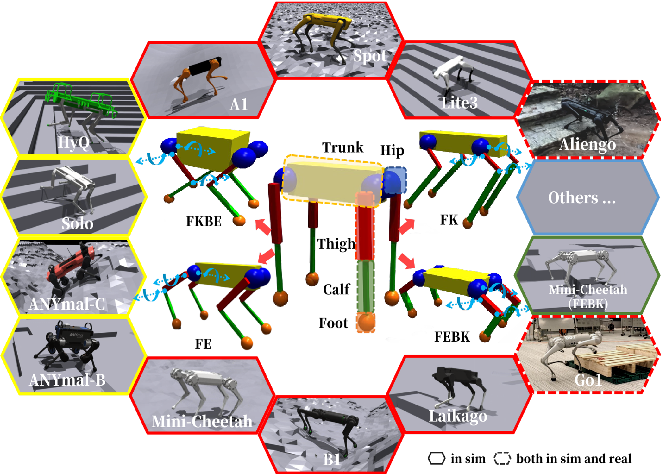
Figure 1 from MorAL: Learning Morphologically Adaptive Locomotion ...
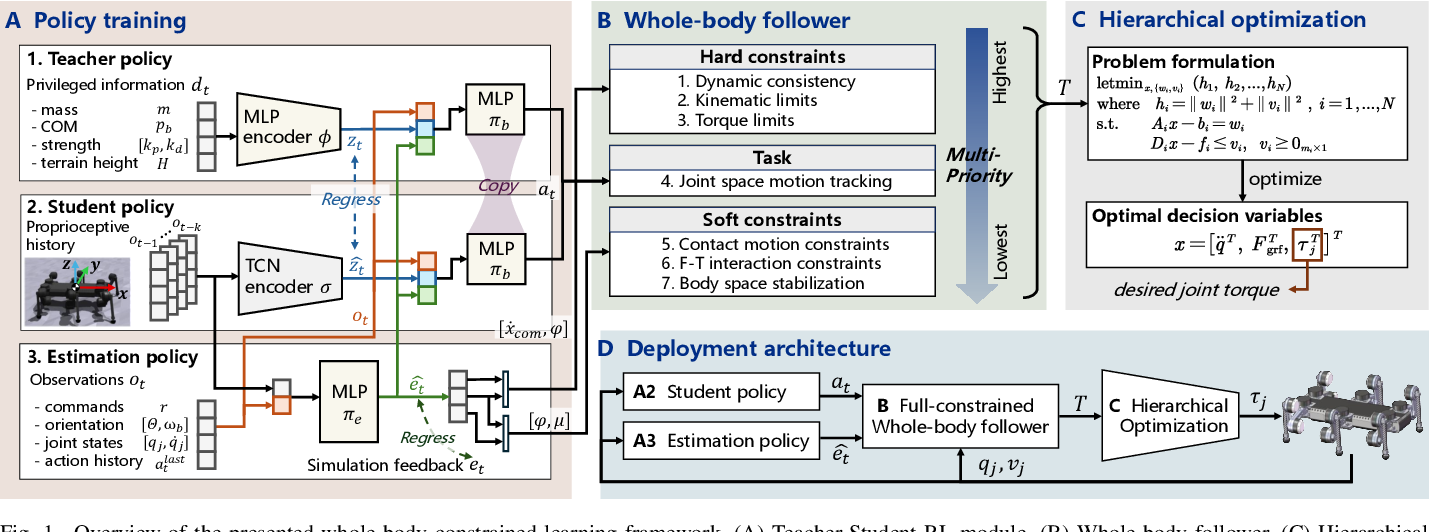
Figure 1 from Whole-Body Constrained Learning for Legged Locomotion via ...

Figure 1 from An Intelligent Locomotion Control Architecture for ...

Figure 1 from Learning Semantics-Aware Locomotion Skills from Human ...
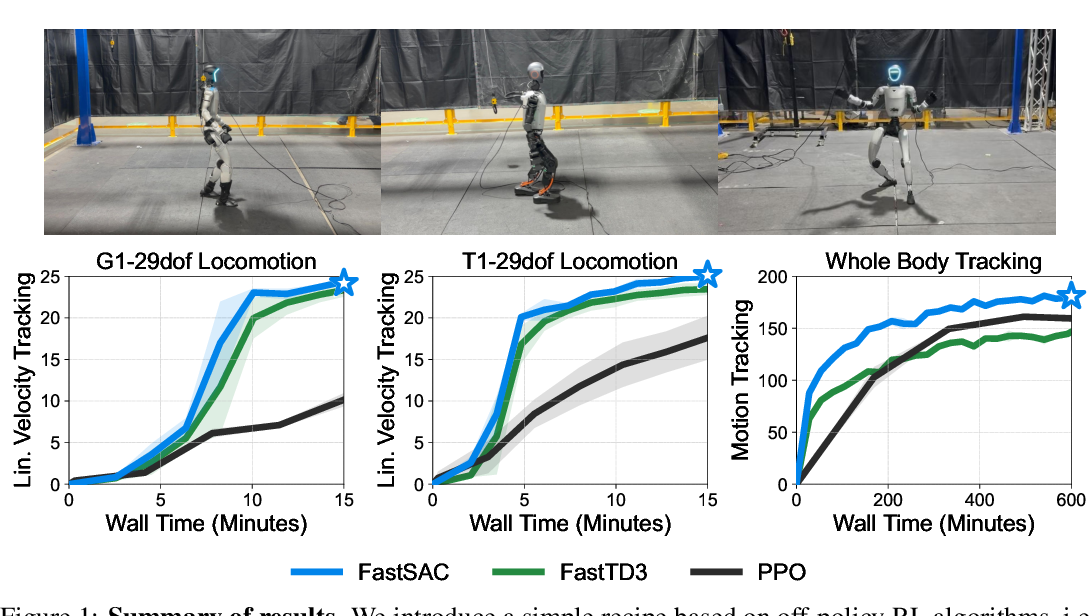
Figure 1 from Learning Sim-to-Real Humanoid Locomotion in 15 Minutes ...
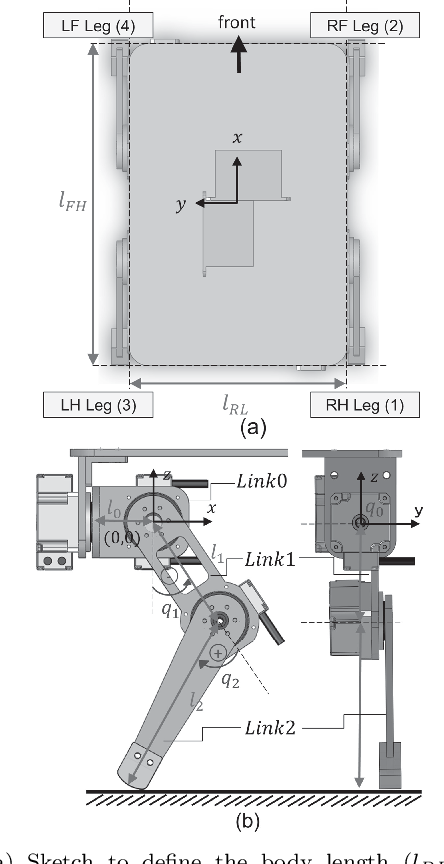
Figure 1 from Compliant Locomotion Control for a Quadruped Robot with ...
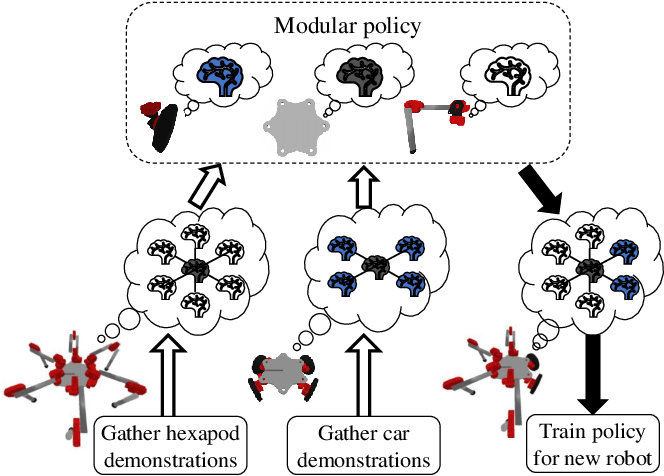
Figure 1 from Learning Modular Robot Locomotion from Demonstrations ...

Figure 1 from Learning Hybrid Locomotion Skills -- Learn to Exploit ...

Figure 1 from Humanoid Locomotion as Next Token Prediction | Semantic ...
Advertisement Space (336x280)

Figure 1 from Learning Modular Robot Visual-motor Locomotion Policies ...

Figure 1 from Learning Multi-Skill Legged Locomotion Using Conditional ...

Figure 1 from Leveraging Symmetry in RL-based Legged Locomotion Control ...

Figure 1 from Learning a Distributed Hierarchical Locomotion Controller ...

Figure 1 from Deep Learning for Human Locomotion Analysis in Lower-Limb ...
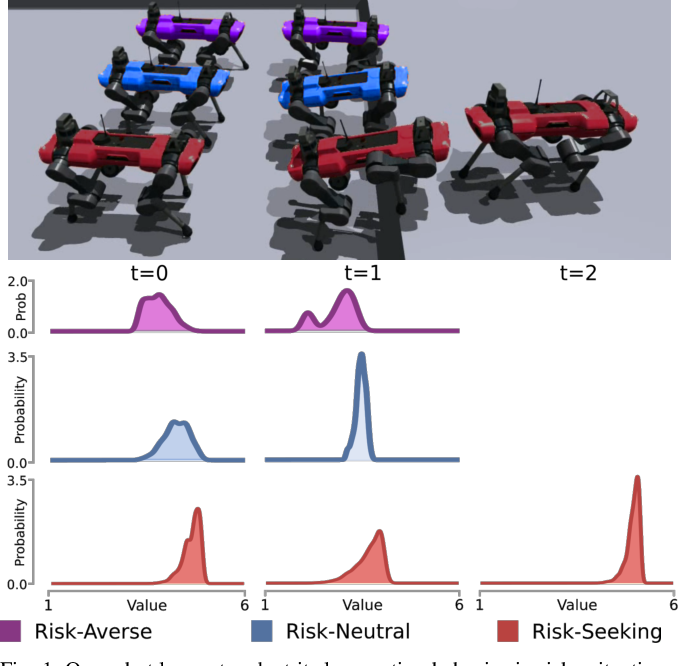
Figure 1 from Learning Risk-Aware Quadrupedal Locomotion using ...

Figure 1 from Complex Locomotion Skill Learning via Differentiable ...

Figure 1 from Deep Learning for Human Locomotion Analysis in Lower-Limb ...
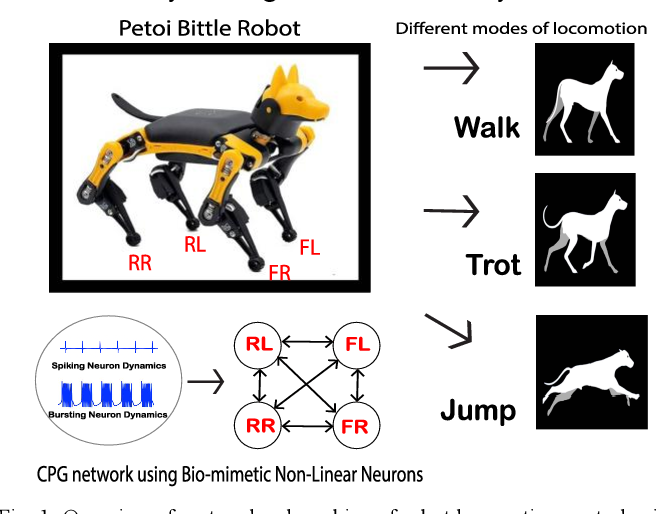
Figure 1 from Robot Locomotion Control Using Central Pattern Generator ...

Figure 2 from Composite Motion Learning with Task Control | Semantic ...
Advertisement Space (336x280)

Figure 1 from Learning Vision-Based Bipedal Locomotion for Challenging ...

Figure 1 from Learning to Generate Research Idea with Dynamic Control ...

Figure 1 from Design and Control of Microscale Dual Locomotion Mode ...
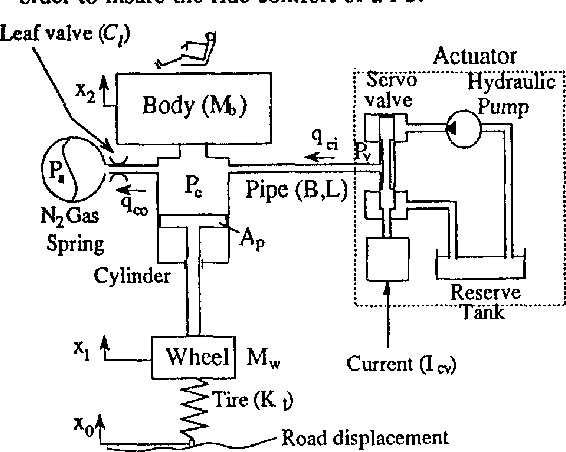
Figure 1 from H/sub infinity / control of an automotive active ...

Figure 1 from Efficiently Learning Small Policies for Locomotion and ...

Figure 1 from Learning Robust and Agile Legged Locomotion Using ...