
Figure 1 From Learning Manipulation Under Physics Constraints With

Figure 1 from Learning Manipulation under Physics Constraints with ...

Learning Manipulation under Physics Constraints with Visual Perception

Learning Manipulation under Physics Constraints with Visual Perception

Learning Manipulation under Physics Constraints with Visual Perception
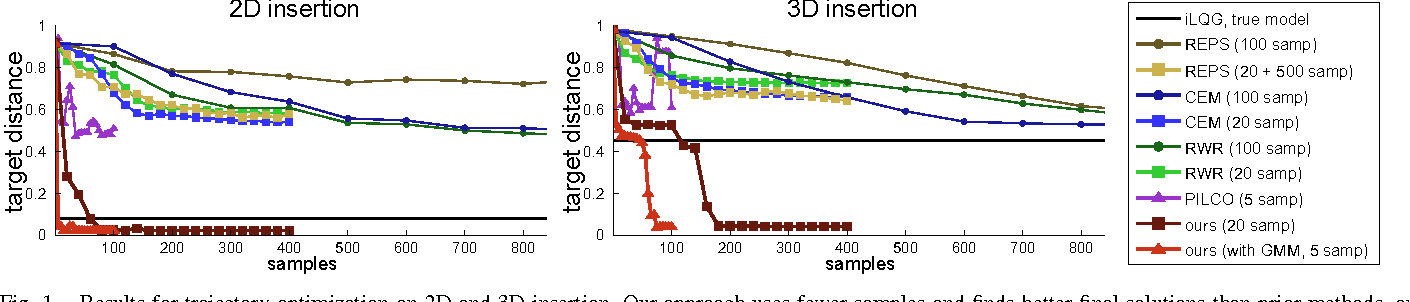
Figure 1 from Learning Dynamic Manipulation Skills under Unknown ...
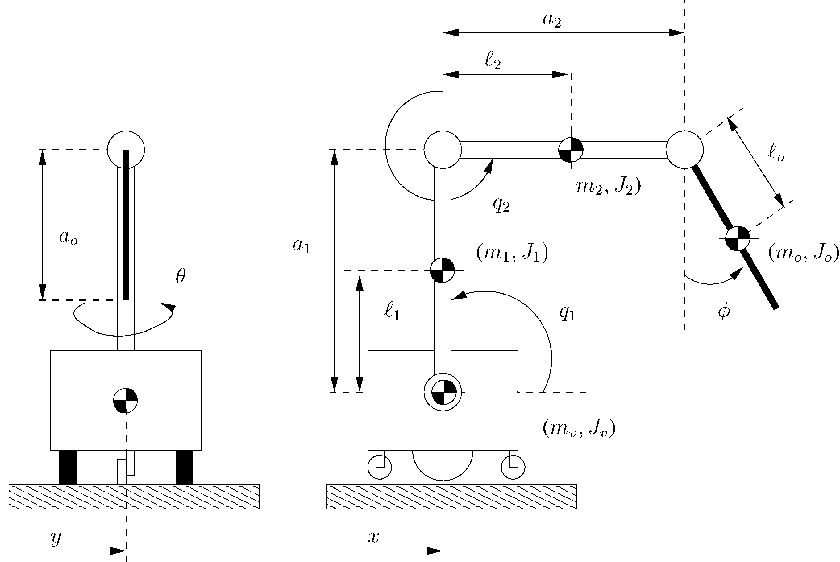
Figure 1 from Mobile manipulation of flexible objects under deformation ...
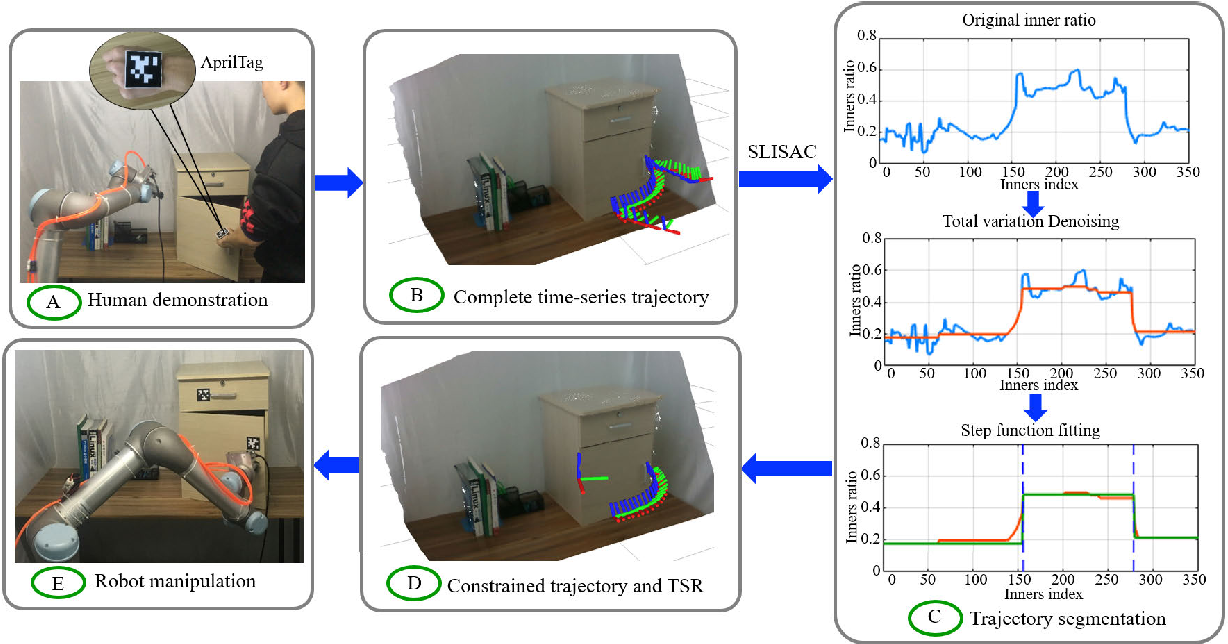
Figure 1 from Learning Articulated Constraints From a One-Shot ...
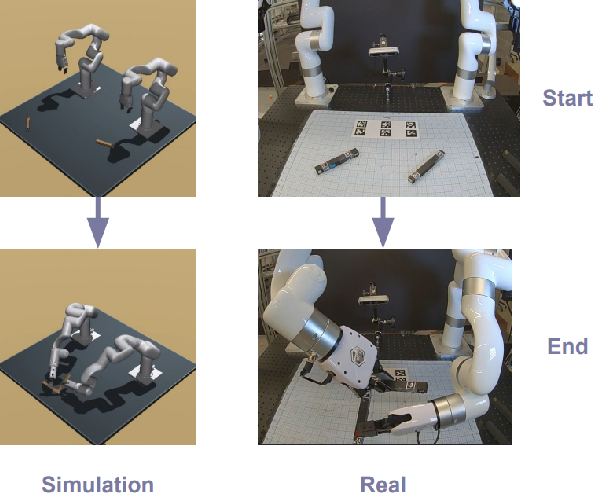
Figure 1 from Learning Bimanual Manipulation | Semantic Scholar

Figure 1 from Learning Robotic Manipulation Tasks through Visual ...
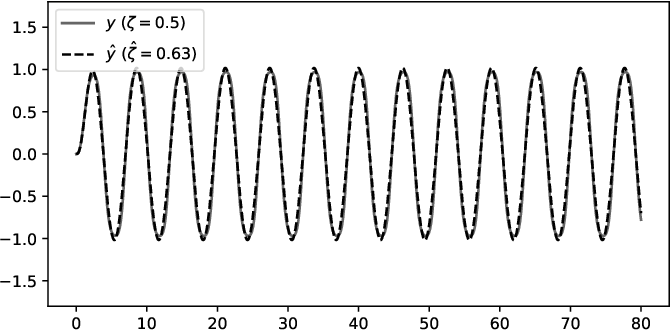
Figure 1 from Structural Constraints for Physics-augmented Learning ...
Advertisement Space (300x250)

Figure 1 from From Equilibrium Statistical Physics Under Experimental ...

Figure 1 from Imitation Learning for Object Manipulation Based on ...

Figure 1 from Learning Robotic Manipulation Policies from Point Clouds ...

Figure 1 from Learning Forceful Manipulation Skills from Multi-modal ...

Figure 1 from Learning motion primitives of object manipulation using ...

Figure 1 from Neural Networks with Physics-Informed Architectures and ...

Figure 1 from Learning Hybrid-Control Policies for High-Precision In ...
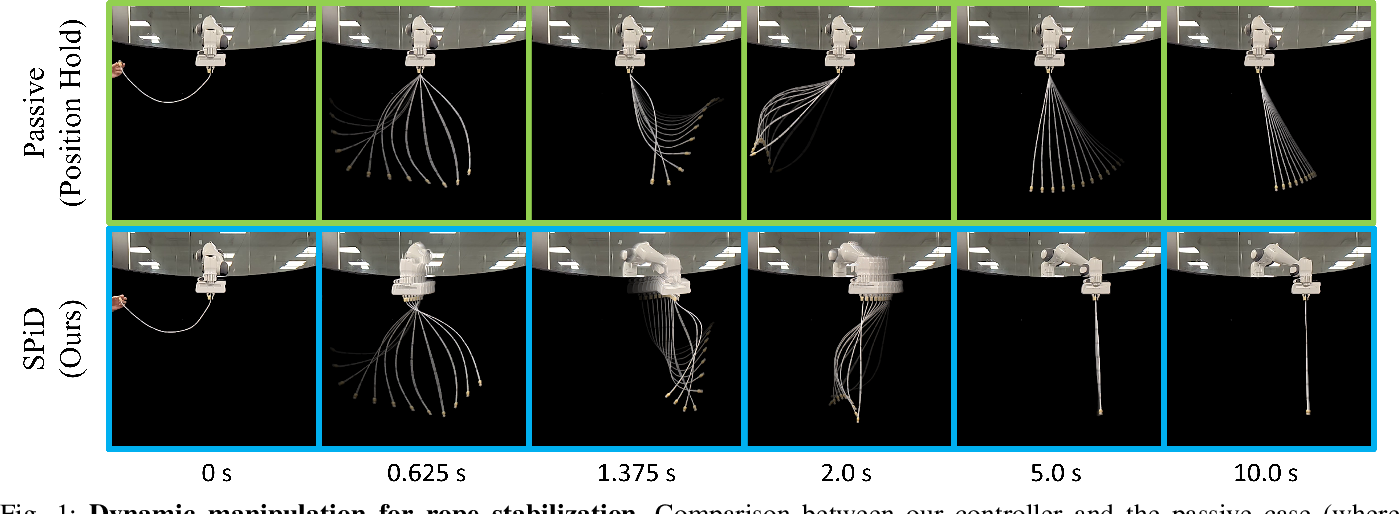
Figure 1 from Self-supervised Physics-Informed Manipulation of ...
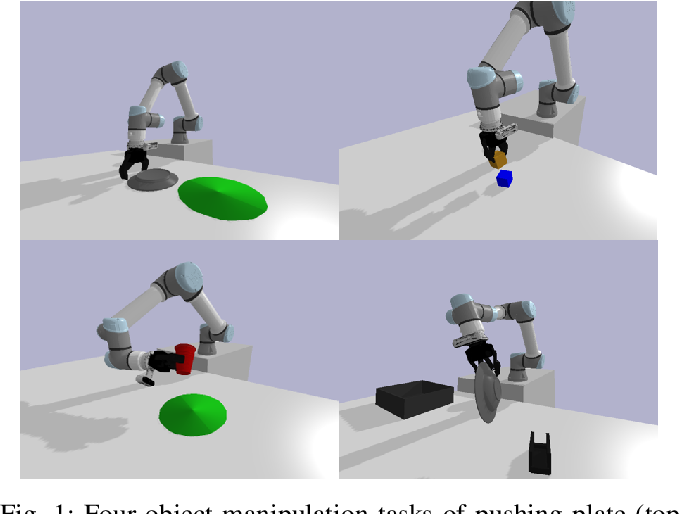
Figure 1 from Reinforcement Learning for Vision-based Object ...
Machine Learning under Resource Constraints - Discovery in Physics by ...
Advertisement Space (336x280)

Figure 1 from Interpreting Behaviors and Geometric Constraints as ...

Figure 1 from Multi-Level Task Learning Based on Intention and ...
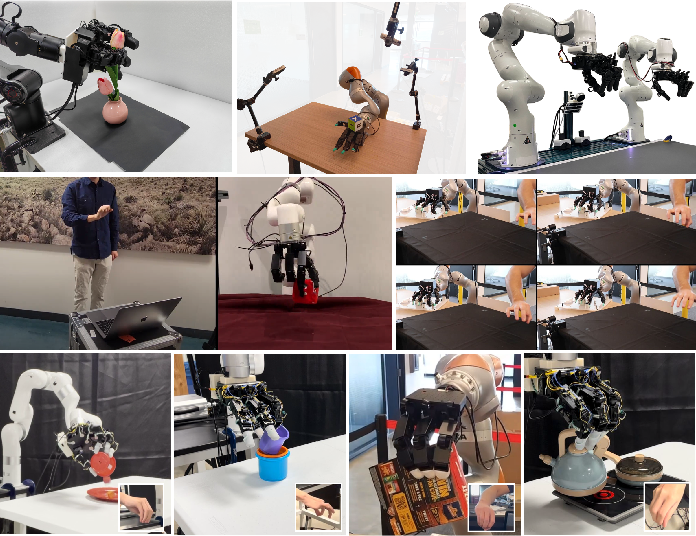
Figure 1 from Dexterous Manipulation Through Imitation Learning: A ...
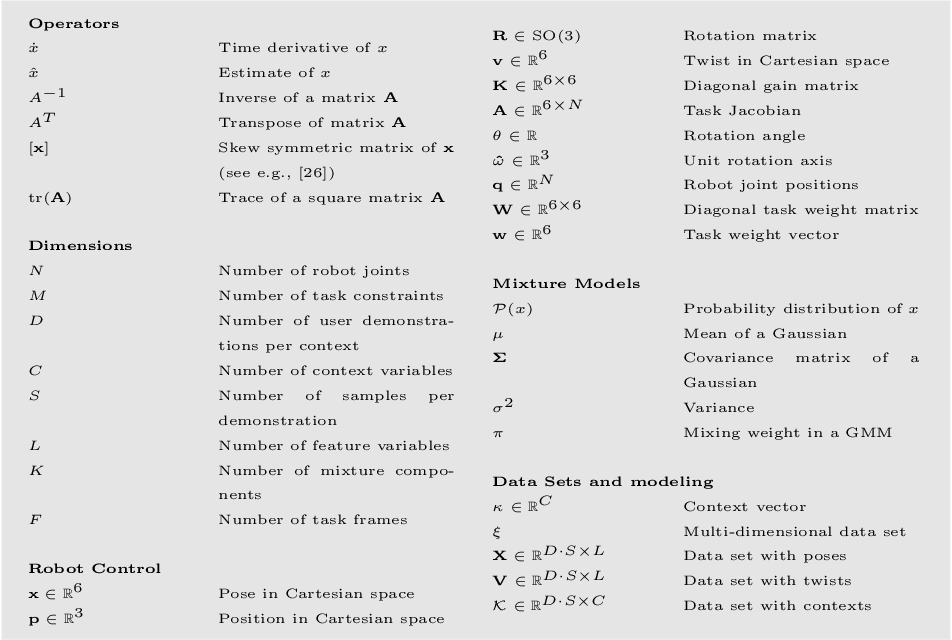
Table 1 from Learning Context-Adaptive Task Constraints for Robotic ...

Figure 1 from Multi-Level Task Learning Based on Intention and ...

Figure 1 from Physics-Informed Neural Networks for Learning Allen-Cahn ...
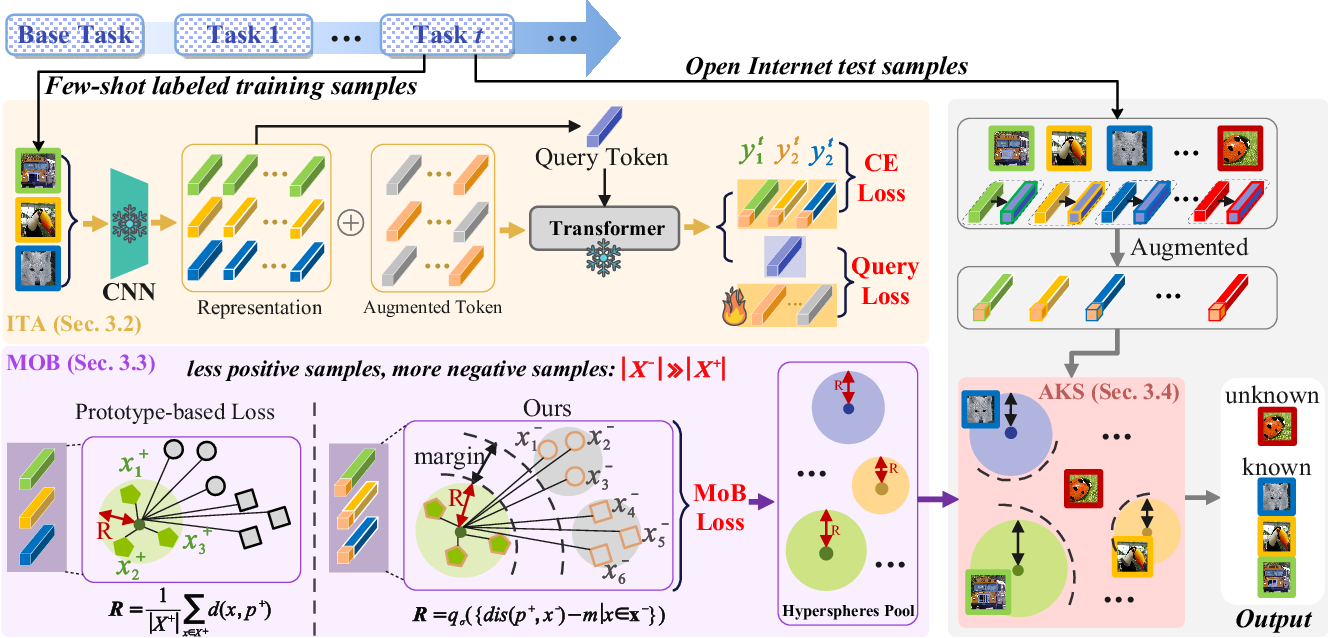
Figure 2 from Improving Open-world Continual Learning under the ...
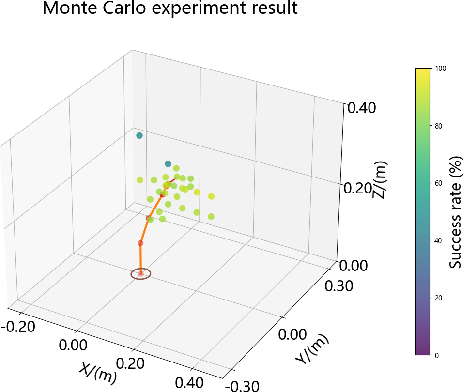
Figure 10 from Learning Smooth and Robust Space Robotic Manipulation of ...

Figure 1 from Generating Manipulation Sequences using Reinforcement ...
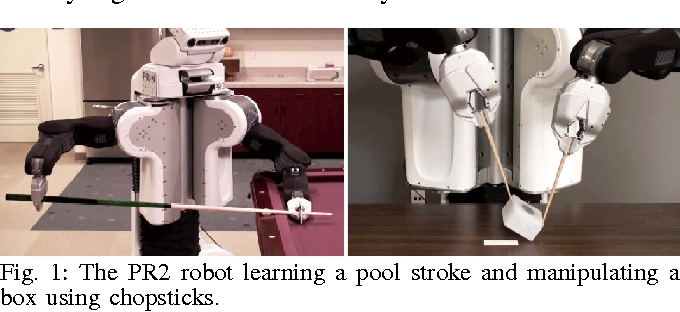
Figure 1 from Skill learning and task outcome prediction for ...
Advertisement Space (336x280)

Figure 5 from Constraint-aware Policy for Compliant Manipulation ...

Figure 2 from Simulating Early Childhood Drawing Behaviors under ...
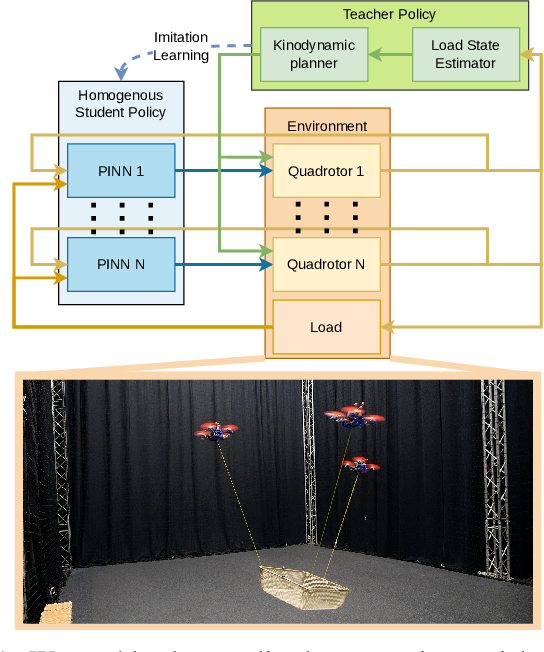
Figure 1 from Decentralized Real-Time Planning for Multi-UAV ...

Learning Physics from Pretrained Video Models: A Multimodal Continuous ...
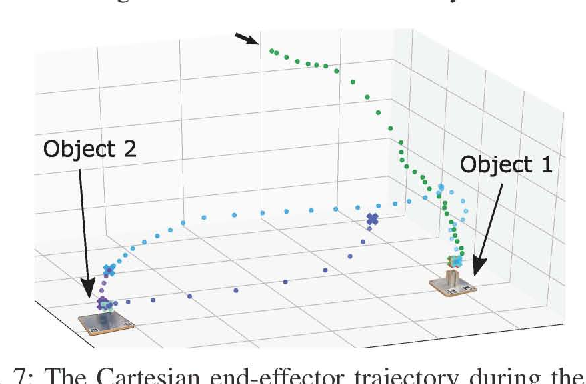
Figure 7 from Multi-Level Task Learning Based on Intention and ...

(PDF) Learning Articulated Constraints From a One-Shot Demonstration ...