
Figure 1 From Map Matching Using Line Segment Features For Self Vehicle
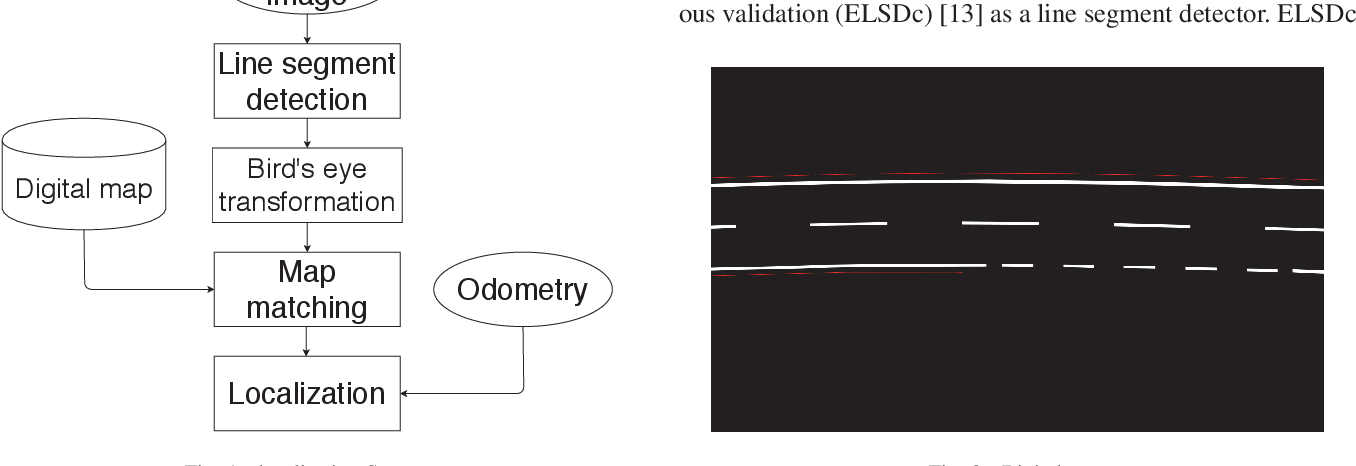
Figure 1 from Map Matching using Line Segment Features for Self-Vehicle ...
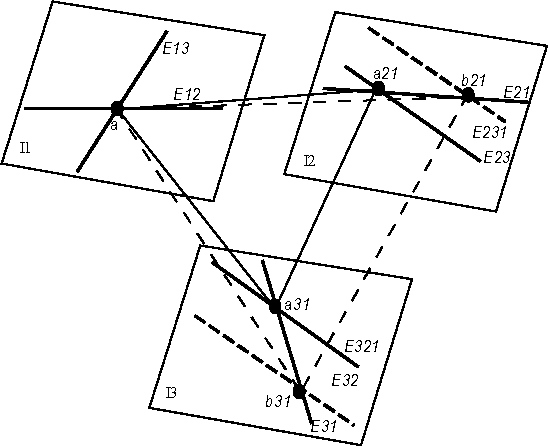
Figure 1 from MULTI-IMAGE MATCHING USING SEGMENT FEATURES | Semantic ...
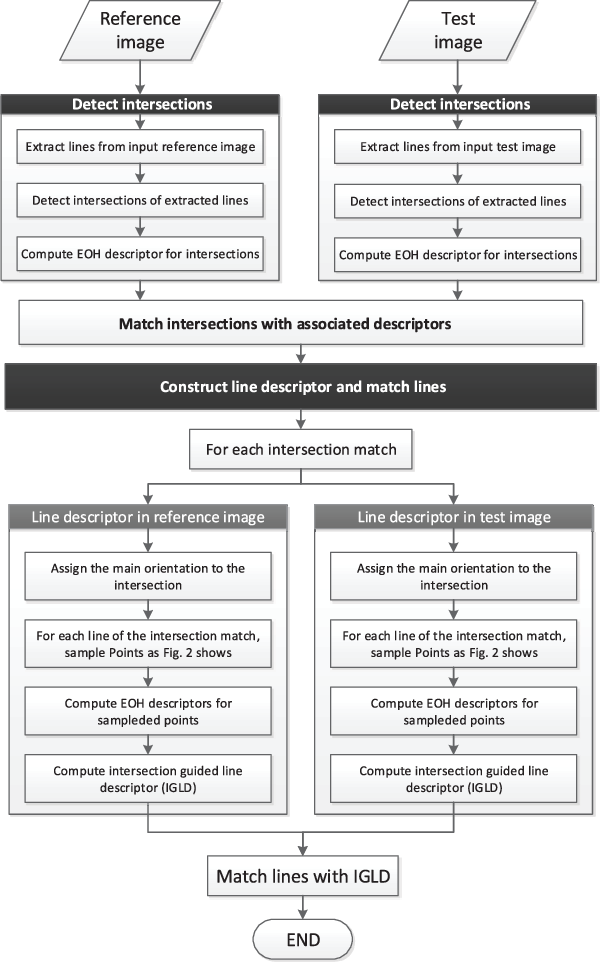
Figure 1 from Reliable Line Segment Matching for Multispectral Images ...
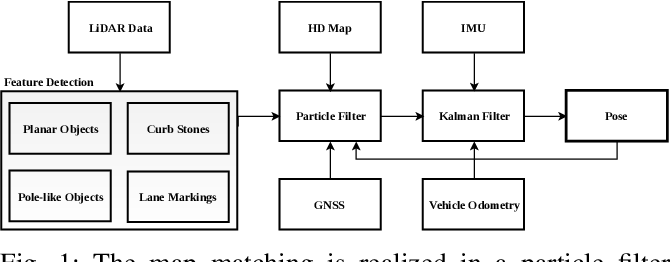
Figure 1 from Map Matching for Vehicle Localization Based on Serial ...
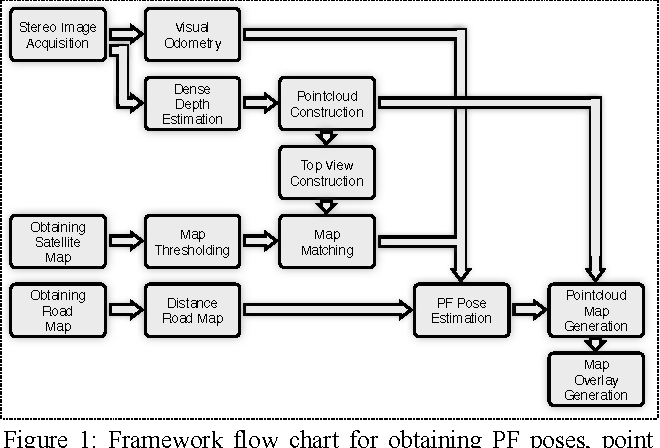
Figure 1 from A framework for global vehicle localization using stereo ...
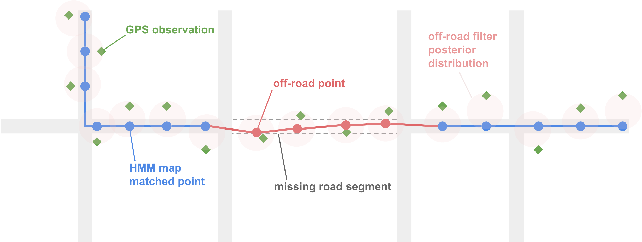
Figure 1 from Map matching when the map is wrong: Efficient on/off road ...

Figure 1 from Accurate vehicle self-localization in high definition map ...

Figure 1 from Vehicle Localization Network using Simultaneous Coarse ...
Line segment matching result for a 2D line-feature image from a ...

Figure 1 from A Self-Localization Method for Urban Environments using ...
Advertisement Space (300x250)

Figure 1 from Comprehensive and Practical Vision System for Self ...
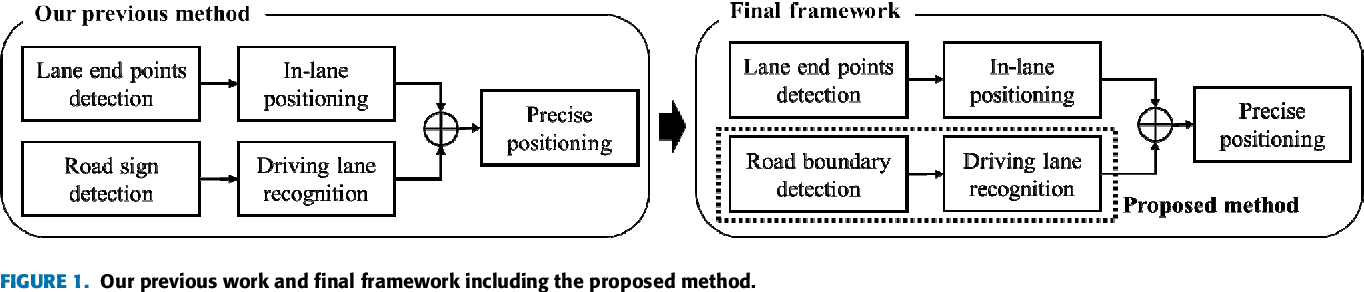
Figure 1 from Map Matching-Based Driving Lane Recognition for Low-Cost ...

Figure 3 from LINE SEGMENT MATCHING ALGORITHM BASED ON FEATURE GROUPING ...
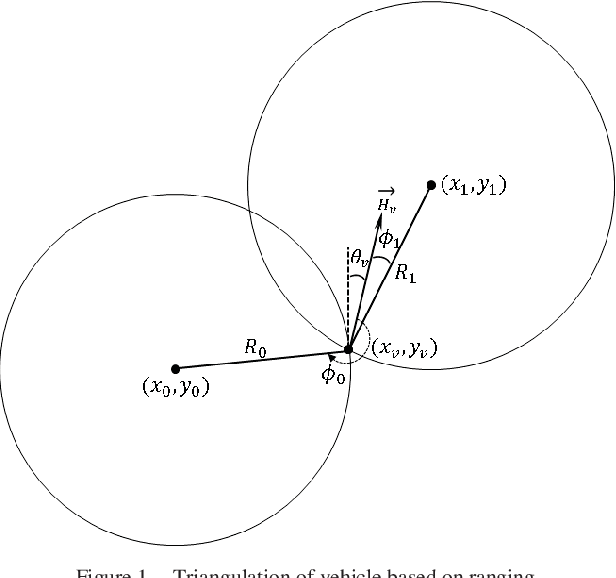
Figure 1 from MAP Aided Self-positioning Based on LIDAR Perception for ...
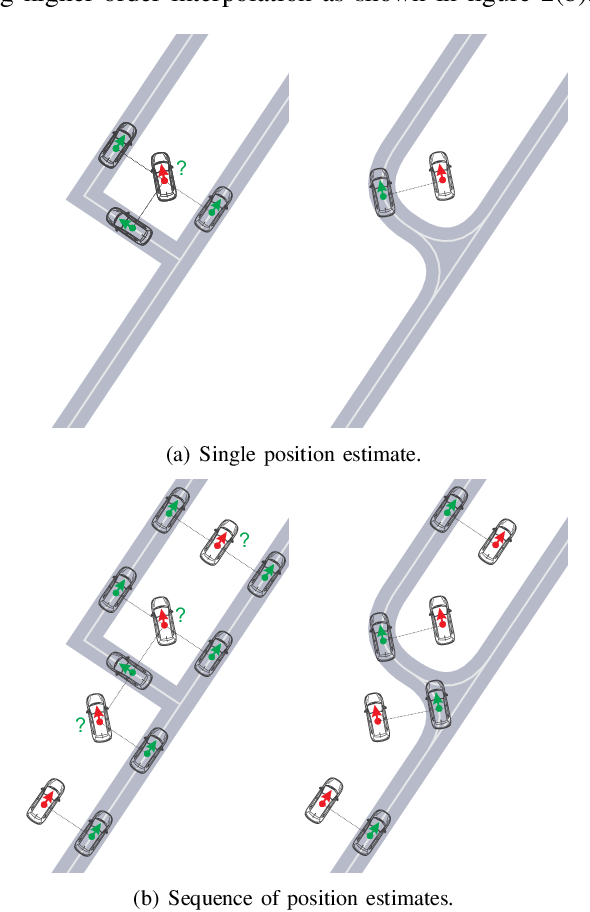
Figure 2 from A statistical approach to map matching using road network ...

Line segment matching result for a 2D line-feature image from a ...
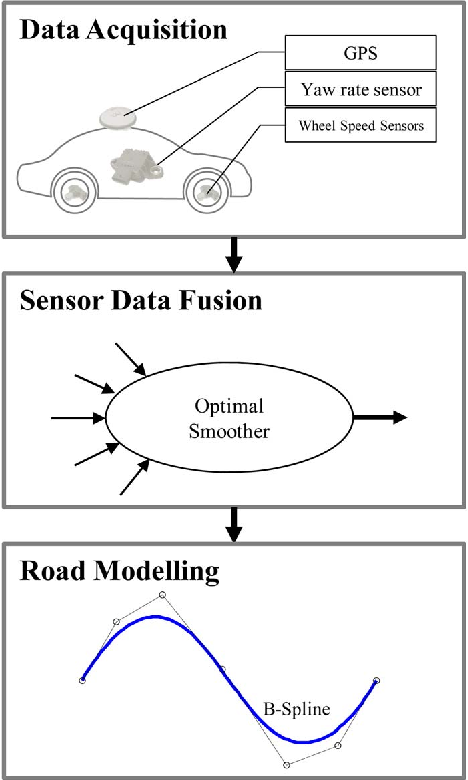
Figure 1 from Generation of a Precise Roadway Map for Autonomous Cars ...

Figure 3 from Patched Line Segment Learning for Vector Road Mapping ...

Figure 1 from Accurate vehicle self-localization in high definition map ...

Figure 1 from Accurate vehicle self-localization in high definition map ...
Advertisement Space (336x280)
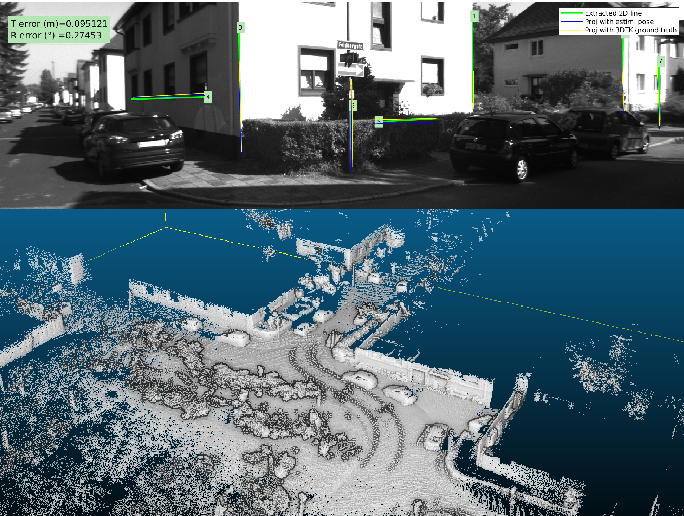
Figure 1 from Vision based vehicle relocalization in 3D line-feature ...

(PDF) Estimation of Initial Position Using Line Segment Matching in Maps
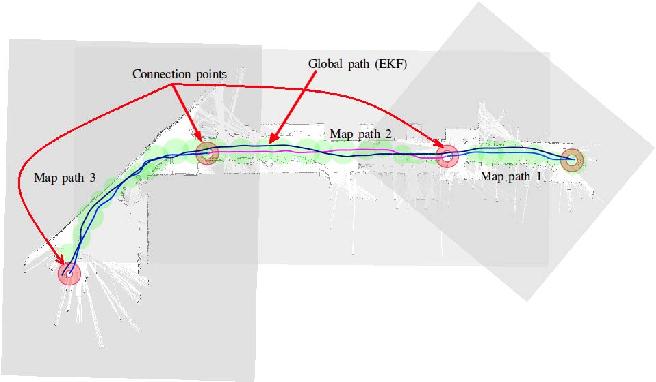
Figure 1 from An Optimization Technique for Positioning Multiple Maps ...

Estimation of Initial Position Using Line Segment Matching in Maps ...
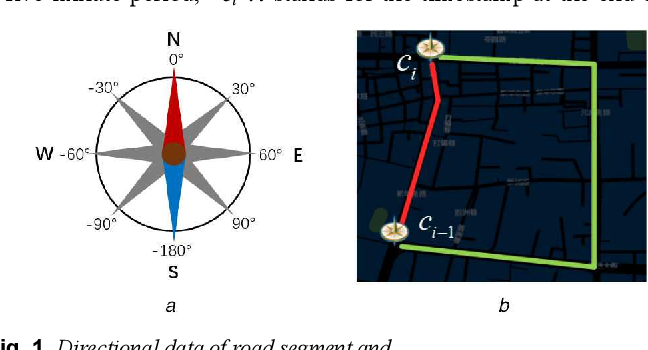
Figure 1 from Deep learning enabled vehicle trajectory map‐matching ...

Figure 1 from Vehicle self-localization with high-precision digital ...

Figure 1 from Intelligent Vehicle Self-Localization Based on Double ...
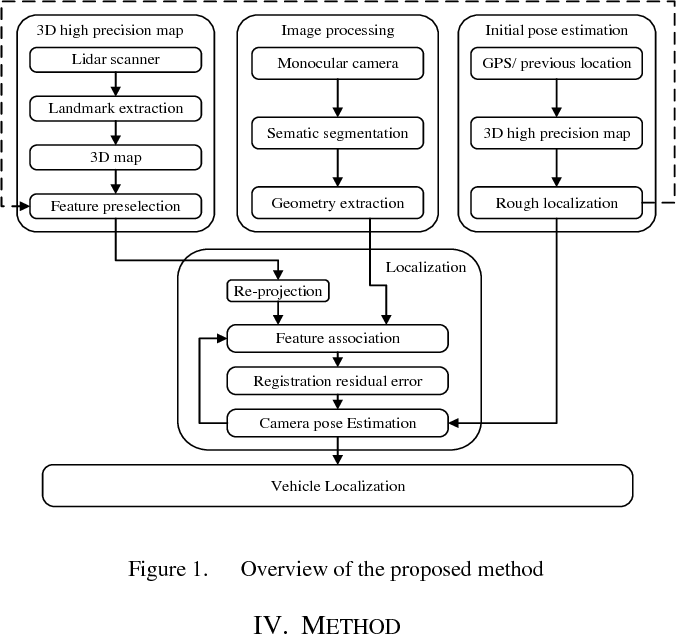
Figure 1 from Monocular Vehicle Self-localization method based on ...

Figure 1 from A Survey on Map-Based Localization Techniques for ...

Figure 1 from A Steering Strategy for Self-Driving Automobile Systems ...
Advertisement Space (336x280)

Figure 8 from A Self-Localization Method for Urban Environments using ...

Figure 1 from Drivable Area and Lane Line Detection Model based on ...

Figure 2 from A Line Segments Matching Method based on Epipolar-line ...

Targeting Lane-Level Map Matching for Smart Vehicles: Construction of ...

Lane-Level Map-Matching Method for Vehicle Localization Using GPS and ...

Lane-Level Map-Matching Method for Vehicle Localization Using GPS and ...