
Figure 1 From Motion Planning Of Manipulator By Points Guided Sampling
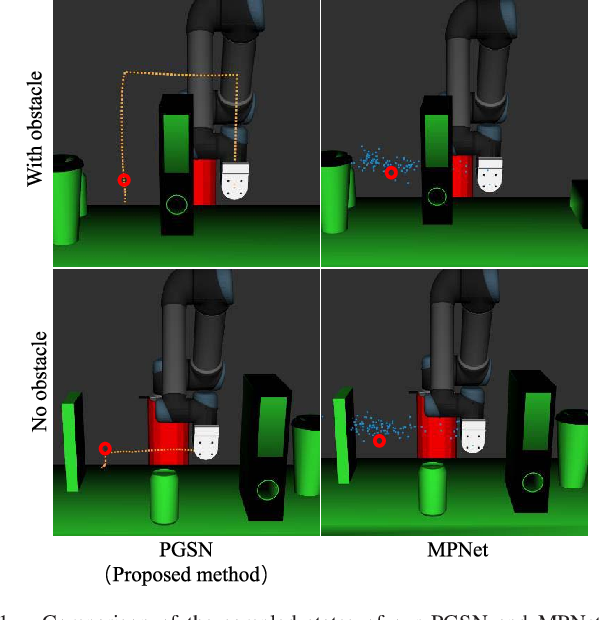
Figure 1 from Motion Planning of Manipulator by Points-Guided Sampling ...

Figure 1 from Motion Planning of Manipulator by Points-Guided Sampling ...
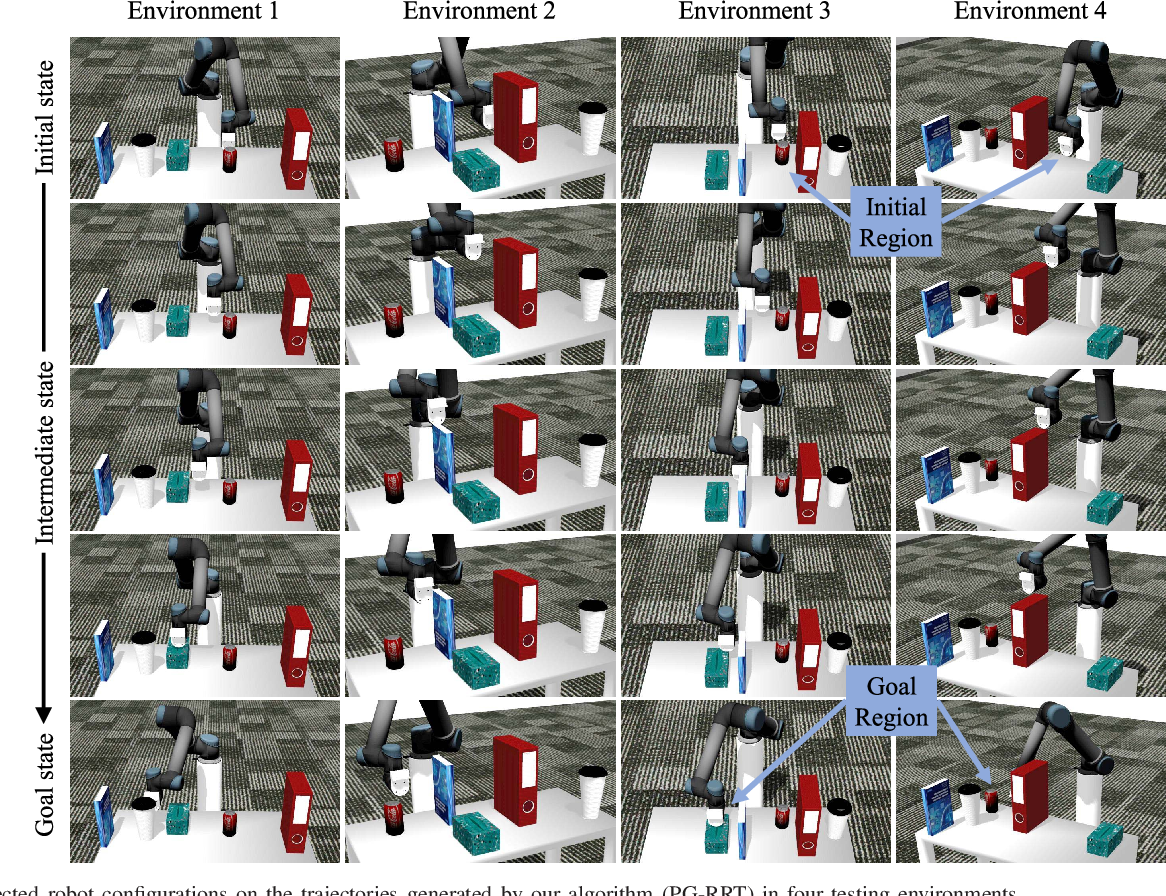
Figure 8 from Motion Planning of Manipulator by Points-Guided Sampling ...
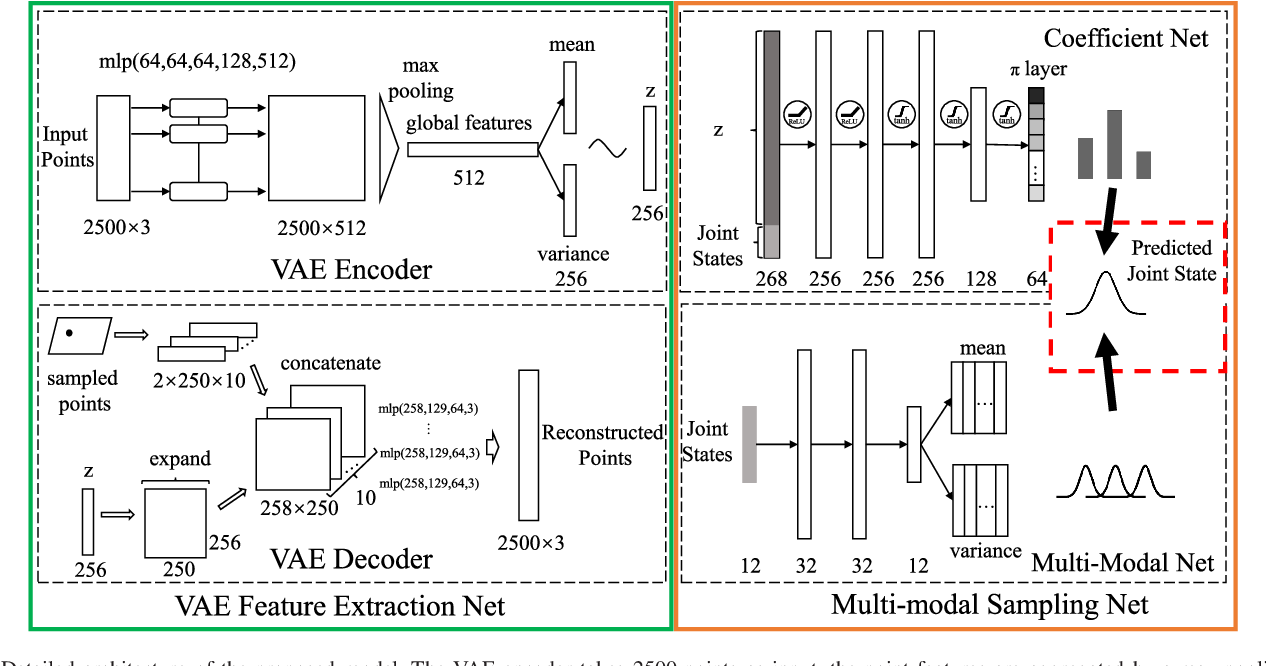
Figure 2 from Motion Planning of Manipulator by Points-Guided Sampling ...
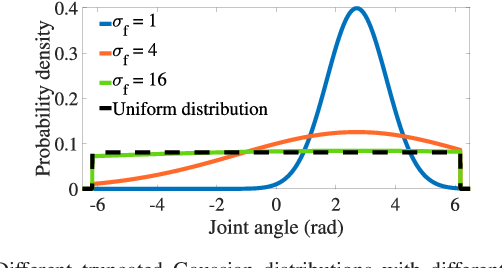
Figure 4 from Motion Planning of Manipulator by Points-Guided Sampling ...
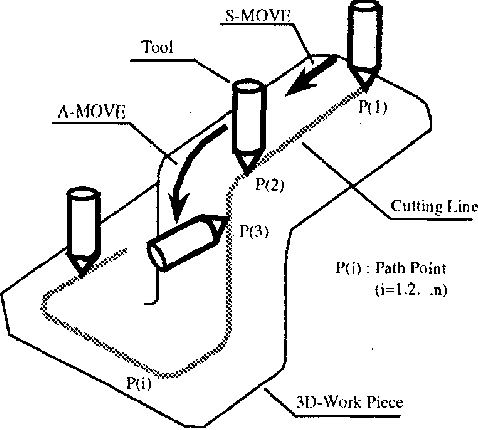
Figure 1 from Motion planning of a redundant manipulator based on ...
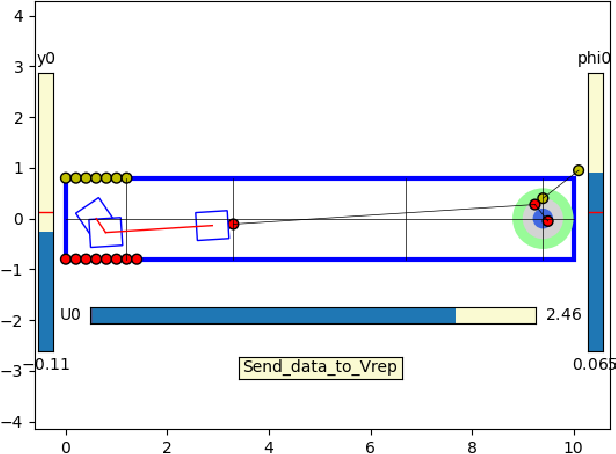
Figure 1 from Motion Planning and Simulation of a Mobile Manipulator ...
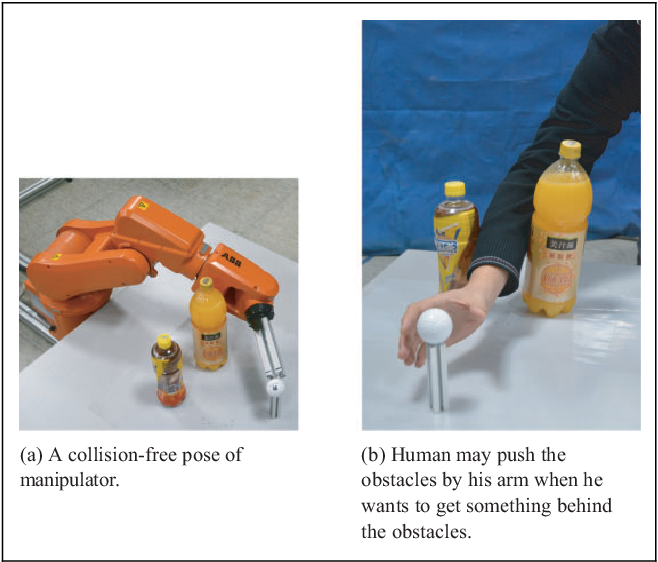
Figure 1 from Manipulator motion planning using flexible obstacle ...

Figure 1 from A Learning System for Motion Planning of Free-Float Dual ...
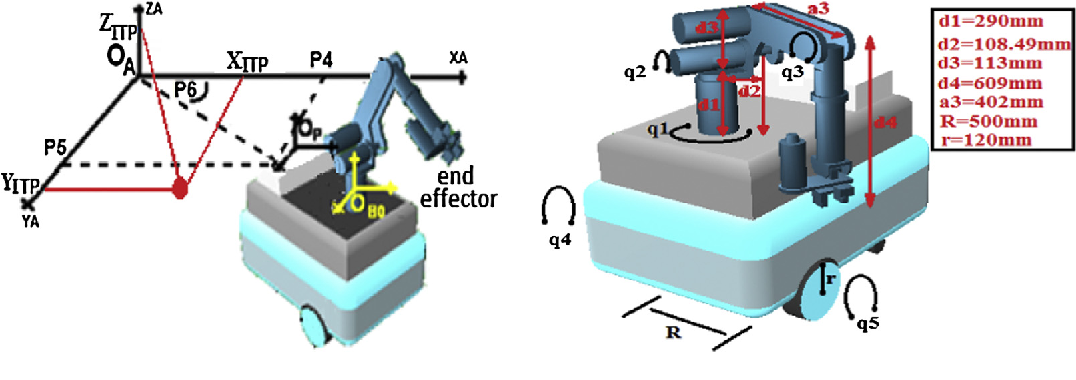
Figure 1 from Motion analysis of a mobile manipulator executing pick-up ...
Advertisement Space (300x250)

Figure 1 from Motion Planning for a Humanoid Mobile Manipulator System ...
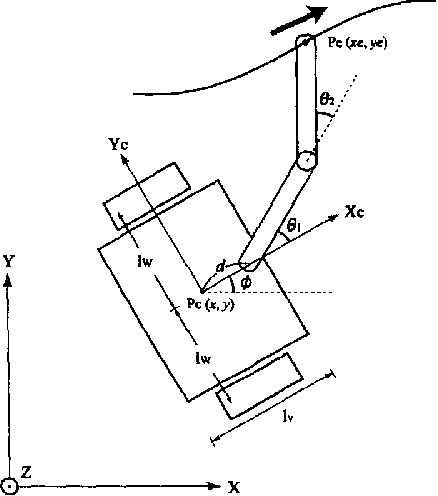
Figure 1 from Trajectory planning of mobile manipulator with end ...

Figure 1 from A Survey of Optimization-Based Task and Motion Planning ...

Figure 1 from Benchmarking of Motion Planning Algorithms with Real-time ...
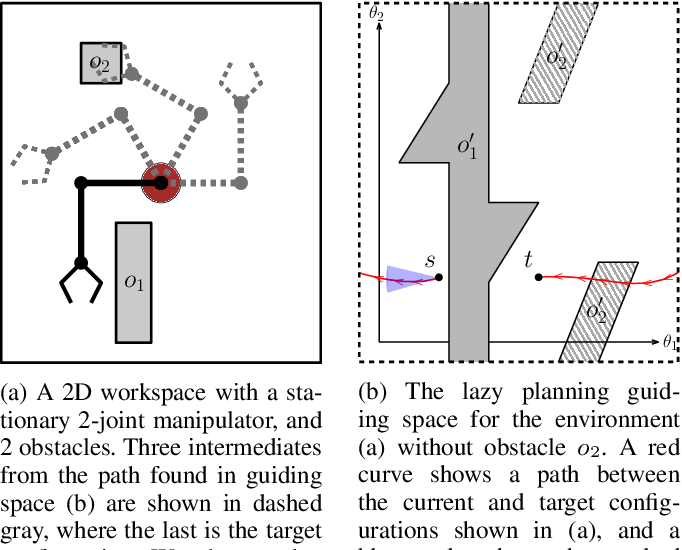
Figure 1 from Evaluating Guiding Spaces for Motion Planning | Semantic ...
Solutions from TTGO for motion planning of a manipulator from a given ...

Figure 1 from Optimal motion planner of mobile manipulators in ...

Figure 1 from A new automatic motion planning algorithm for a 4-degree ...

Figure 1.1 from A guided approach to sampling-based motion planning ...

Figure 1 from A Hierarchical Motion Planning Method for Mobile ...
Advertisement Space (336x280)

Figure 1 from Multi-Manipulator Motion Planning based on Gaussian ...

Figure 16 from Manipulator Motion Planning Based on Prior Knowledge ...

Figure 1 from Task scheduling and motion planning for an industrial ...

Figure 1 from A concept for manipulator trajectory planning | Semantic ...
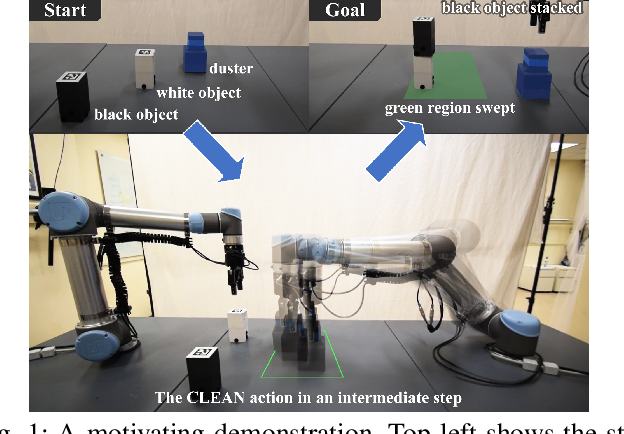
Figure 1 from A General Task and Motion Planning Framework For Multiple ...
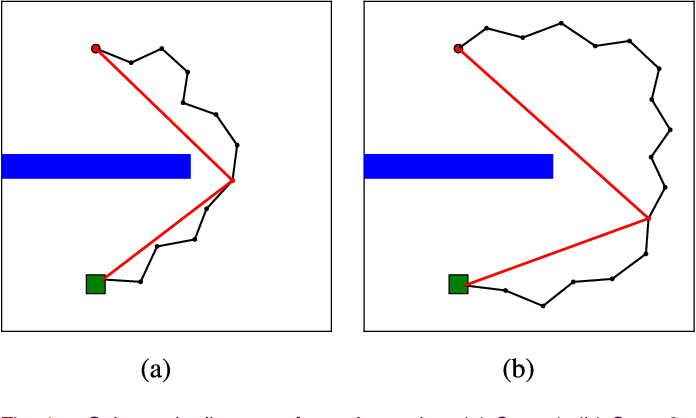
Figure 1 from Sampling-Based Optimal Motion Planning With Smart ...
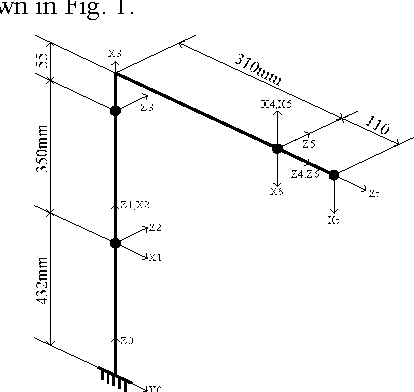
Figure 1 from General motion planning method for manipulators with no ...
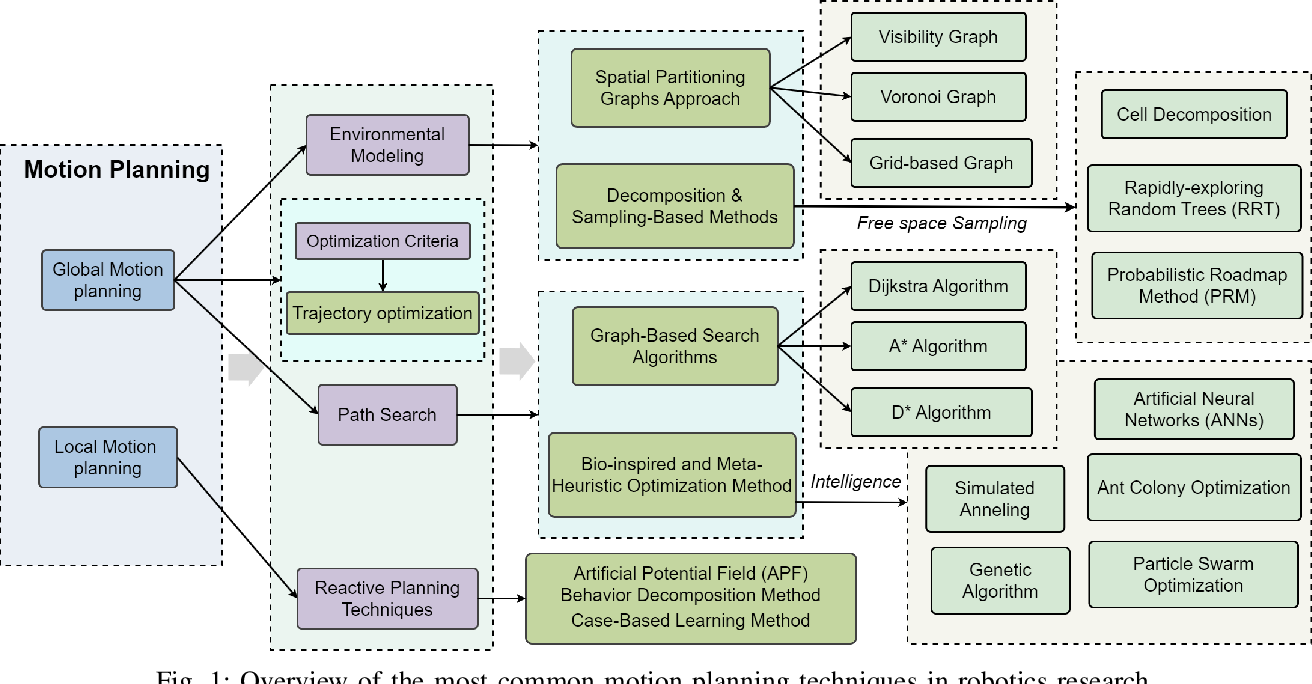
Figure 1 from Motion Planning for Robotics: A Review for Sampling-based ...

Figure 1 from Acceleration-Level Repetitive Motion Planning and Its ...
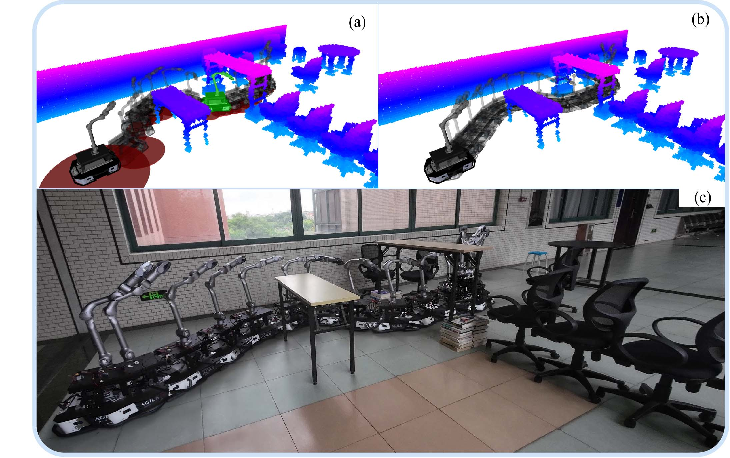
Figure 1 from SR-Planner: Sampling-Based Path Planning With Feasibility ...
Advertisement Space (336x280)
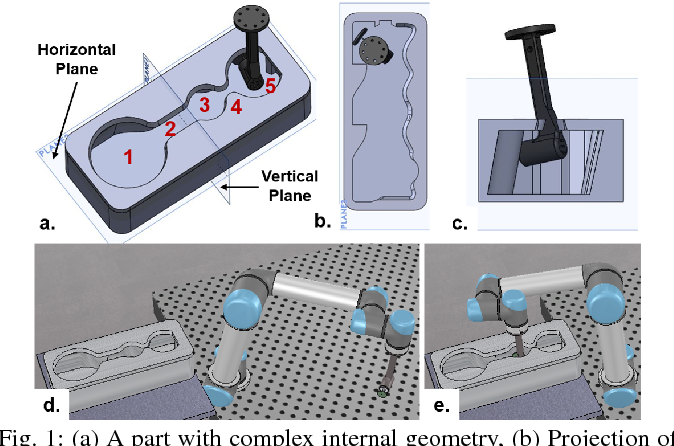
Figure 1 from Trajectory Planning for Manipulators Operating in ...

Figure 1 from Coordinating locomotion and manipulation of a mobile ...

Sampling-based motion planning of manipulator with goal-oriented ...

The motion planning of the manipulator using the method in (Sheng et ...

Task-Oriented Motion Planning of a Space Manipulator under Multiple ...
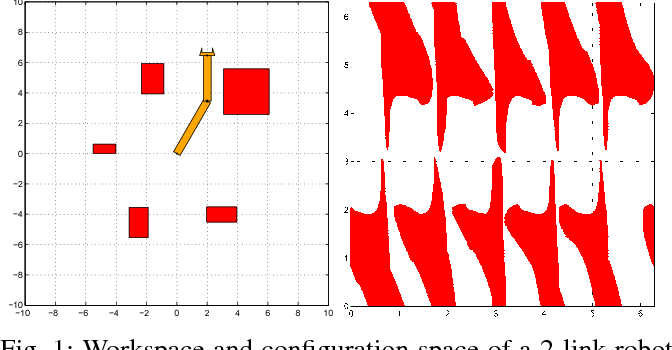
Figure 1 from Machine learning guided exploration for sampling-based ...