
Figure 1 From Multi Agent Formation Control With Obstacles Avoidance
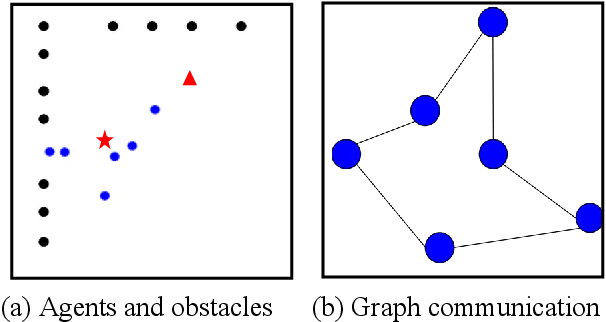
Figure 1 from Multi-agent Formation Control with Obstacles Avoidance ...
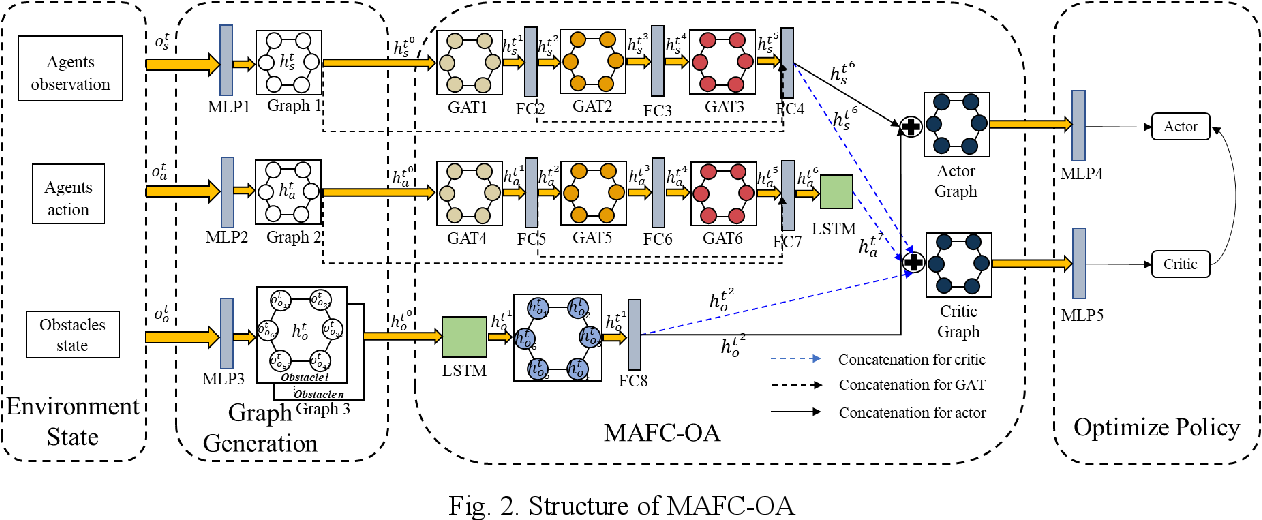
Figure 1 from Multi-agent Formation Control with Obstacles Avoidance ...
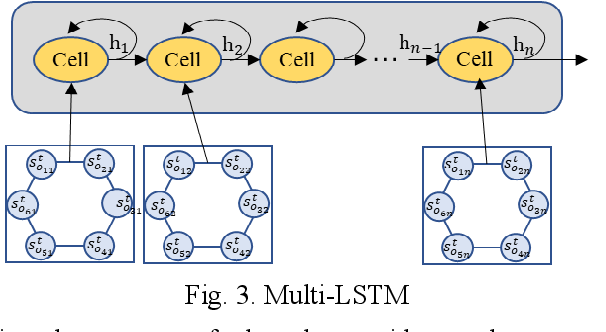
Figure 1 from Multi-agent Formation Control with Obstacles Avoidance ...
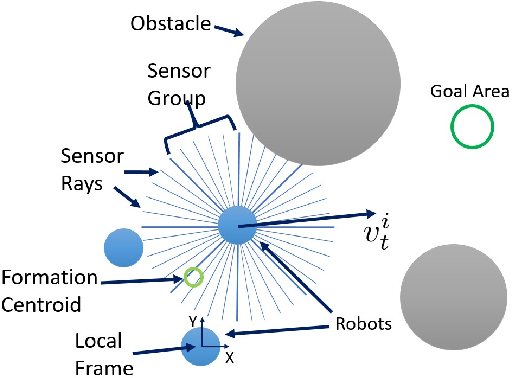
Figure 1 from Multi-Agent Formation Control With Obstacle Avoidance ...
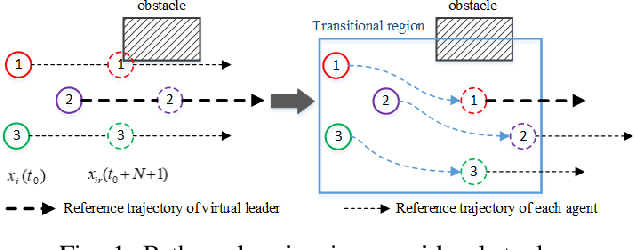
Figure 1 from Multi-agent formation control with obstacle avoidance ...

Figure 1 from Formation Control with Obstacle Avoidance for Multi-Agent ...

Figure 1 from Formation Control With Obstacle Avoidance for a Class of ...
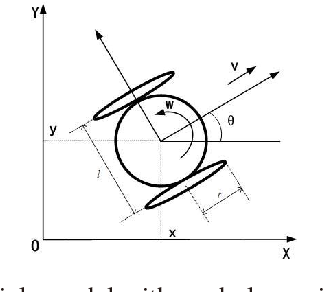
Figure 1 from Formation control and obstacle avoidance for multi ...
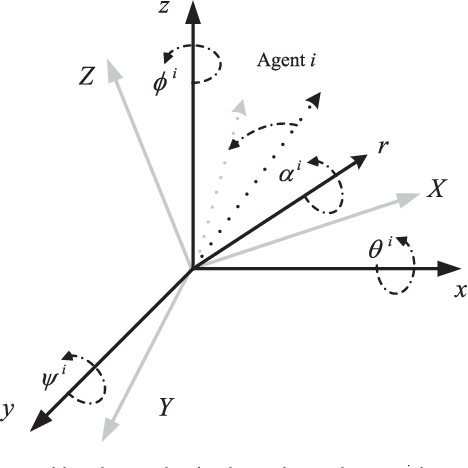
Figure 1 from Formation Control with Mismatched Orientation in Multi ...
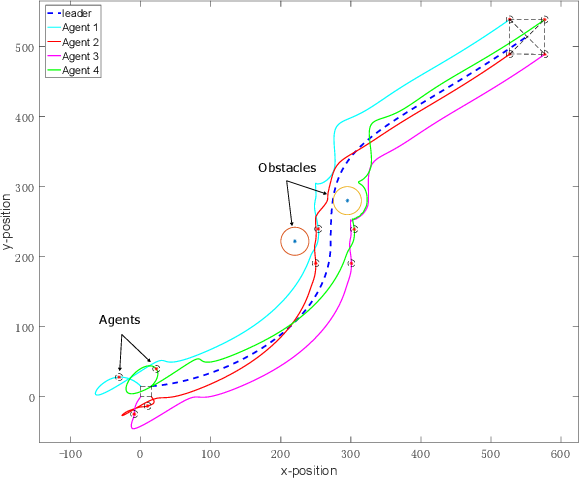
Figure 1 from Artificial Potential-Based Formation Control with ...
Advertisement Space (300x250)

Figure 2 from Formation Control with Obstacle Avoidance for Multi-Agent ...
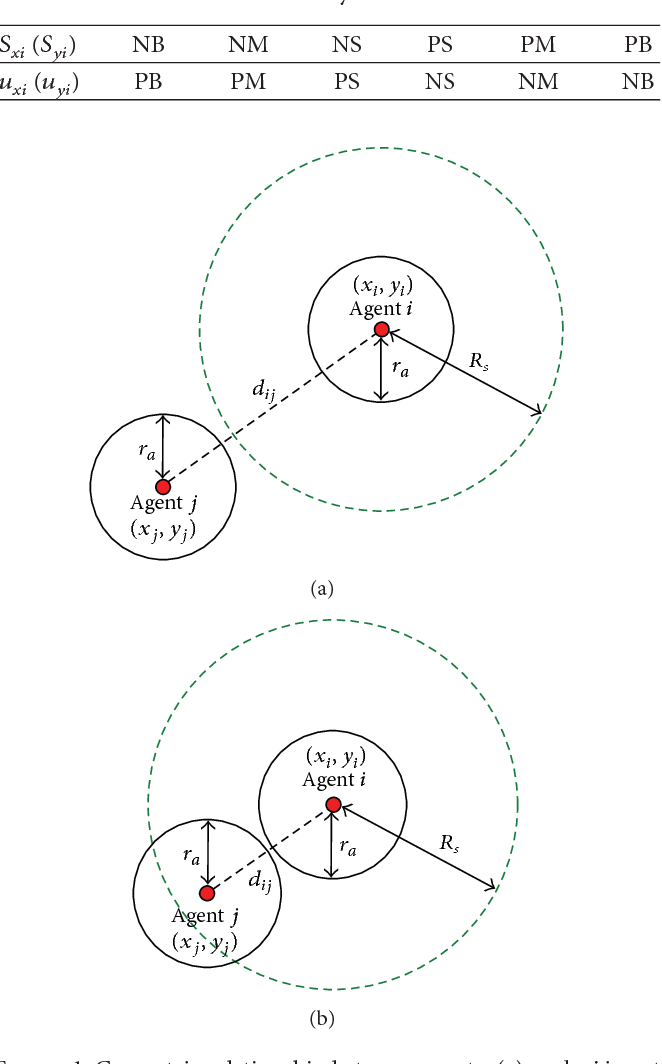
Figure 1 from Fuzzy Formation Control and Collision Avoidance for ...
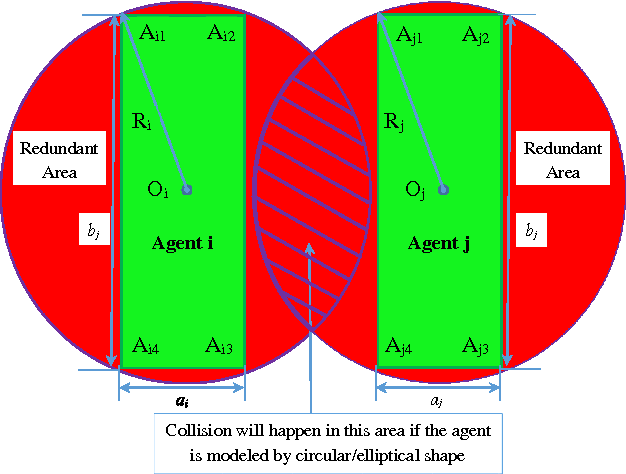
Figure 1 from Formation Control and Obstacle Avoidance of Multiple ...
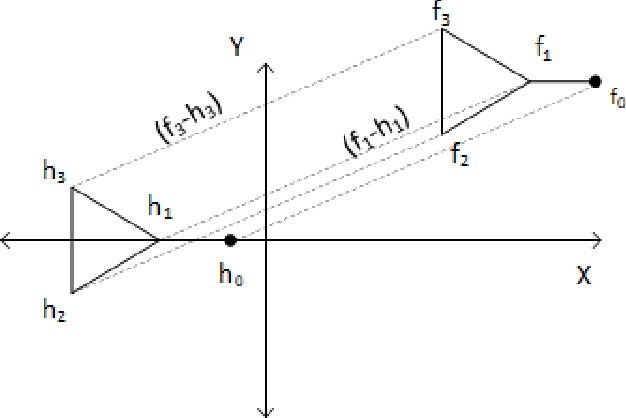
Figure 1 from Formation Control of Multi-Robot System with Collision ...
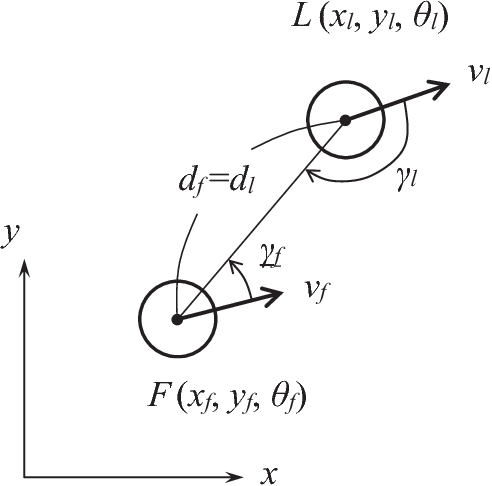
Figure 1 from Formation Control of Multiple Mobile Robots with Large ...

Figure 1 from A Distributed Formation Control Scheme with Obstacle ...
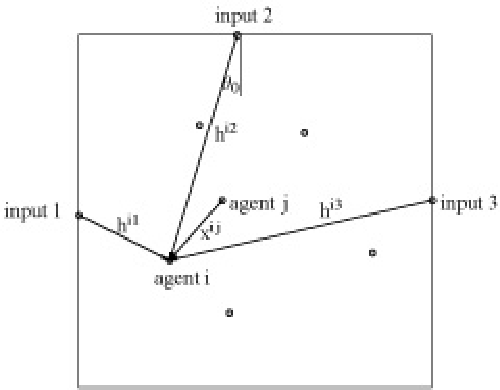
Figure 1 from Formation control of multi-agent systems with ...

Figure 1 from Multi-USV Formation Control and Obstacle Avoidance Under ...

Figure 1 from Decentralized Multi–Agent Formation Control with Pole ...

Figure 1 from Collision/Obstacle Avoidance Dynamic Formation ...
Advertisement Space (336x280)

Figure 1 from A Dynamic Obstacle Avoidance Control Algorithm for ...

Figure 1 from A Hybrid Formation Control Design for Multi-Robot System ...

Figure 1 from Multiagent Formation Control for Obstacle Traversing ...

Figure 1 from Adaptive Multi-Agent Control with Dynamic Obstacle ...

(PDF) Formation Control with Obstacle Avoidance of Second-Order Multi ...
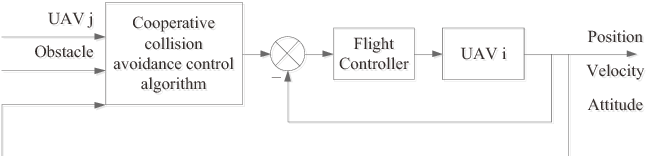
Figure 1 from Cooperative Formation and Obstacle Avoidance Algorithm ...
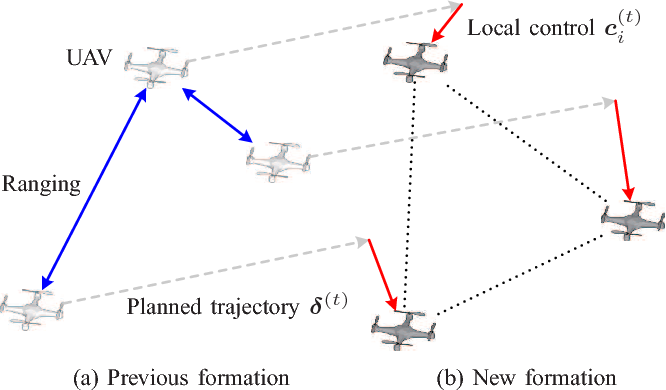
Figure 1 from Integrated Localization and Control for Accurate Multi ...

Figure 1 from Optimized Multi-Agent Formation Control Based on an ...
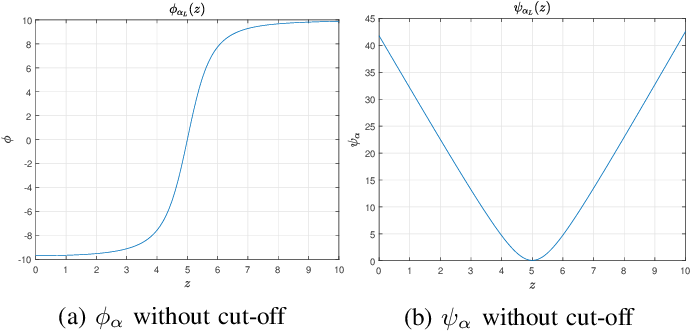
Figure 1 from Dynamic Circular Formation Of Multi-Agent Systems With ...
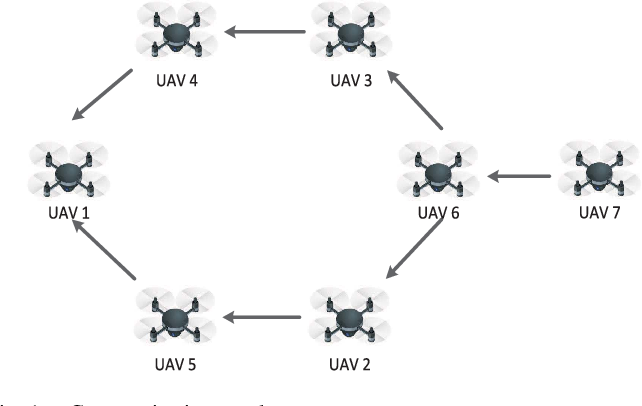
Figure 1 from Model Predictive Formation Tracking-Containment Control ...
Advertisement Space (336x280)

Figure 1 from Dynamic Circular Formation Of Multi-Agent Systems With ...
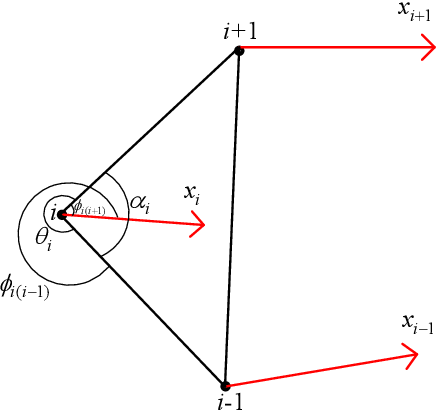
Figure 1 from Multi-agent formation control using angle measurements ...

Figure 2 from Collision-Free Distributed Formation Control of Multi ...

Figure 1 from A multi-layer control scheme for multi-robot formations ...
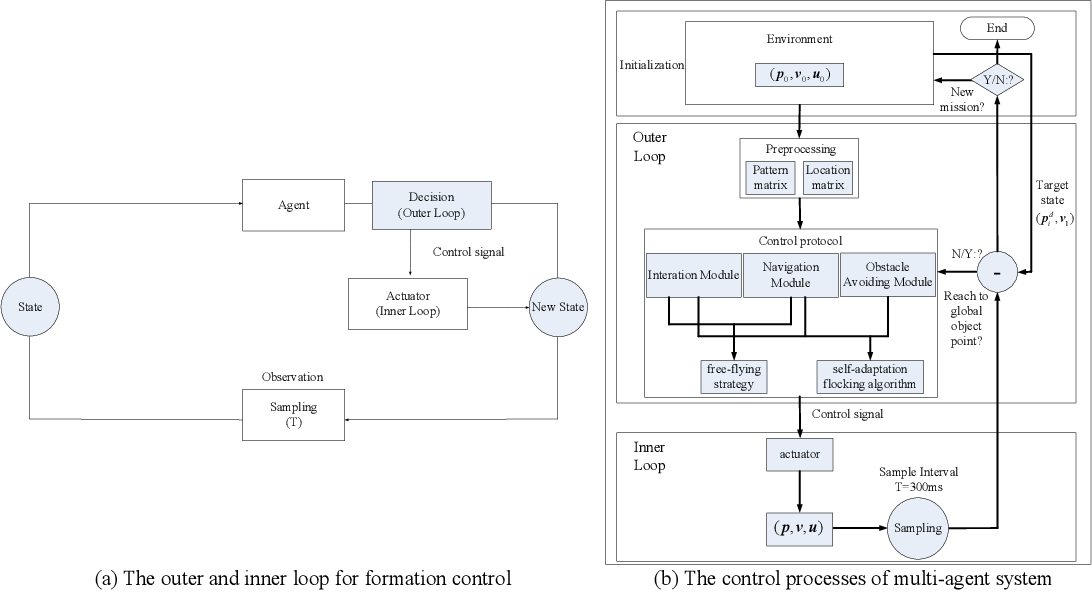
Figure 1 from Maintaining Complex Formations and Avoiding Obstacles for ...

Optimally distributed formation control with obstacle avoidance for ...