
Figure 1 From Position Control Of Flexible Joint Robots By Adapting

Figure 1 from Position Control of Flexible Joint Robots by Adapting ...
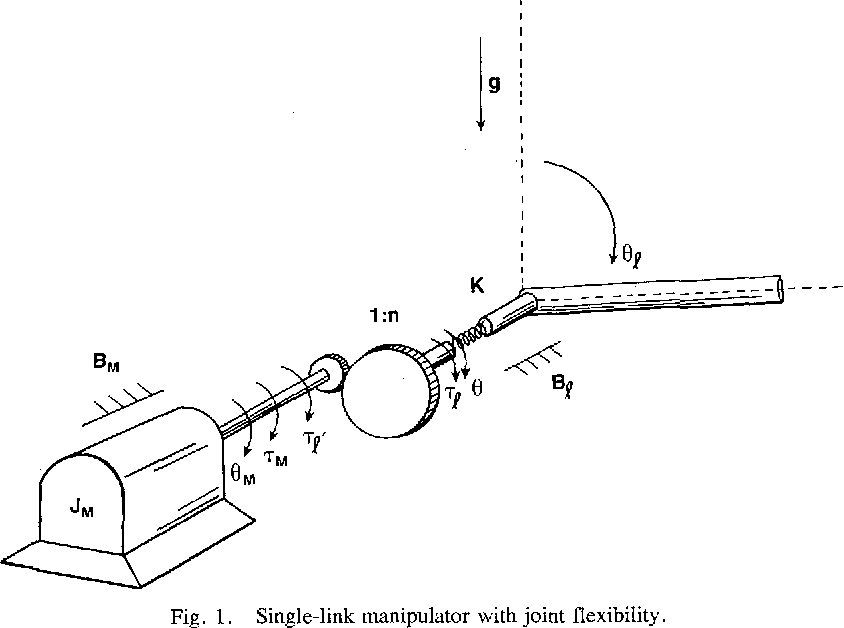
Figure 1 from An Approach Control of Flexible Joint Robots Integral ...
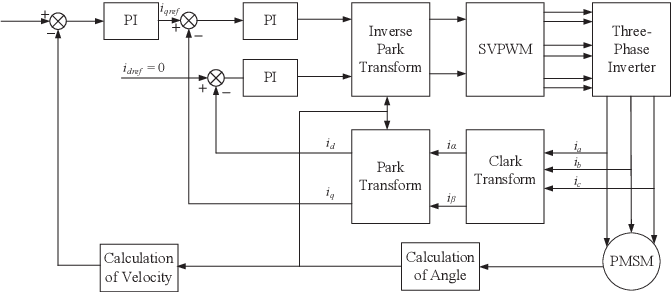
Figure 1 from Model-Free Robust Joint Control of Flexible Joint Robots ...
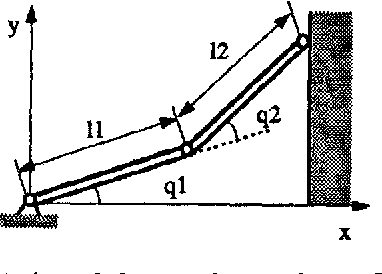
Figure 1 from Adaptive position and force control of flexible joint ...
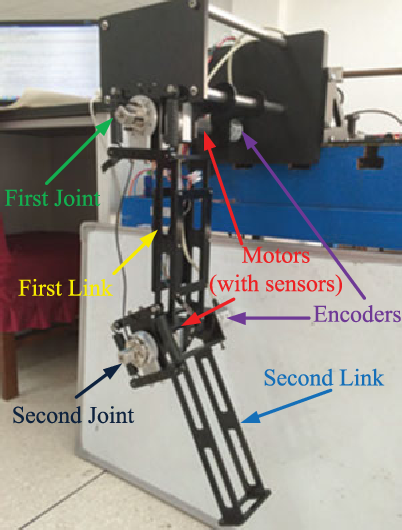
Figure 1 from Position Control for Flexible Joint Robot Based on Online ...
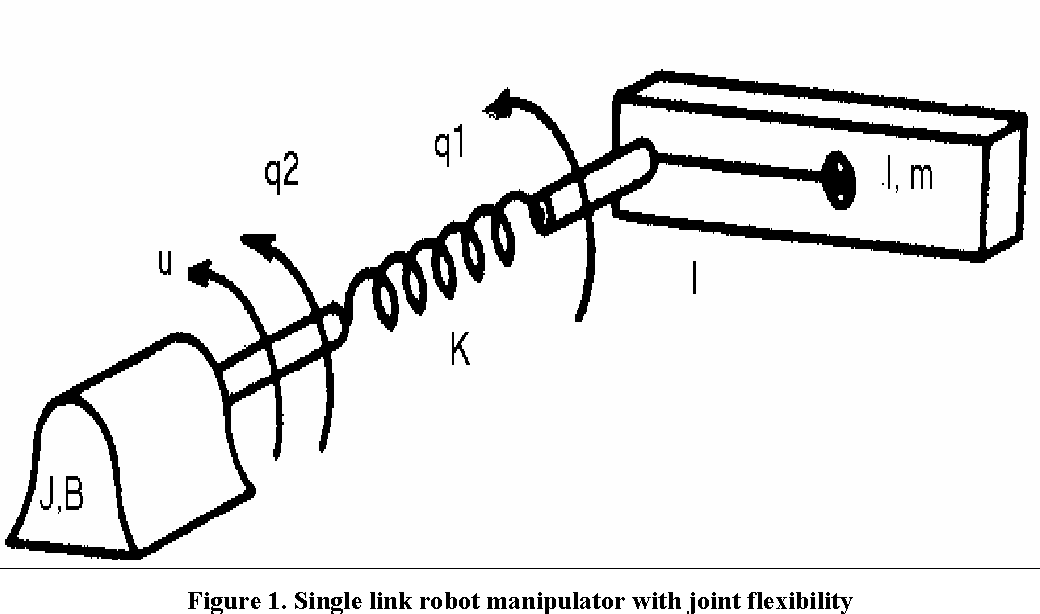
Figure 1 from Predictive Control of Flexible Joint Robotic Manipulator ...
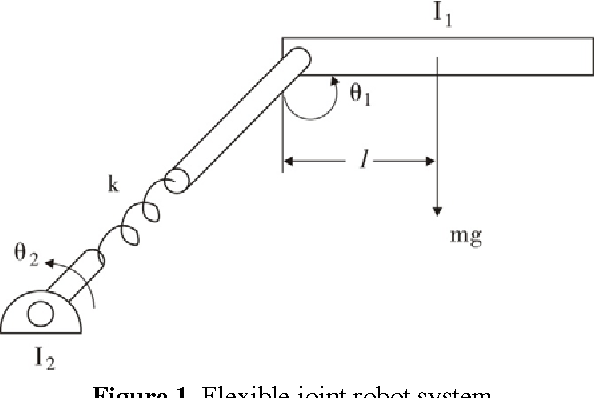
Figure 1 from Stability Control of Flexible Joint Robot Based T-S Fuzzy ...
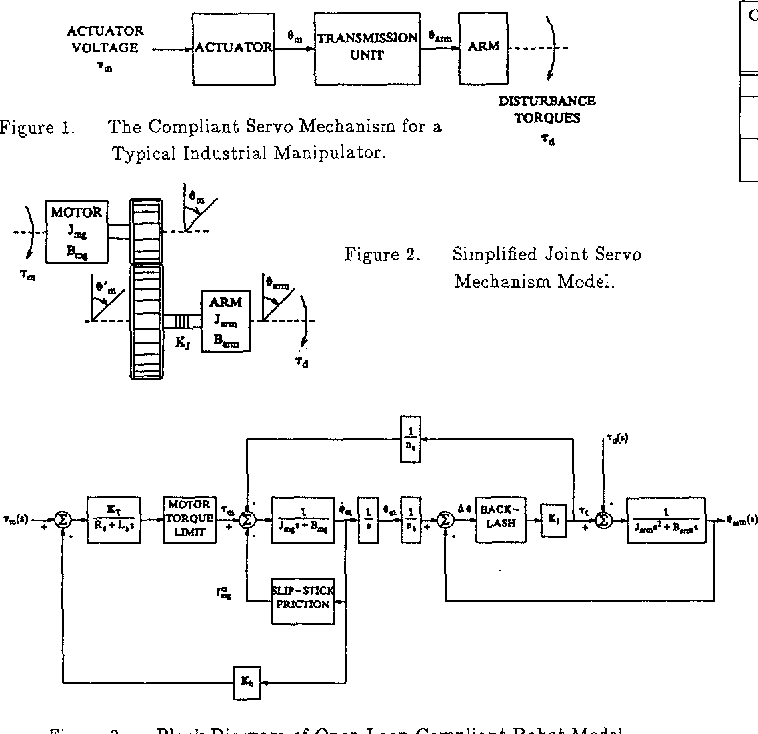
Figure 1 from Control of industrial robots with flexible joints ...
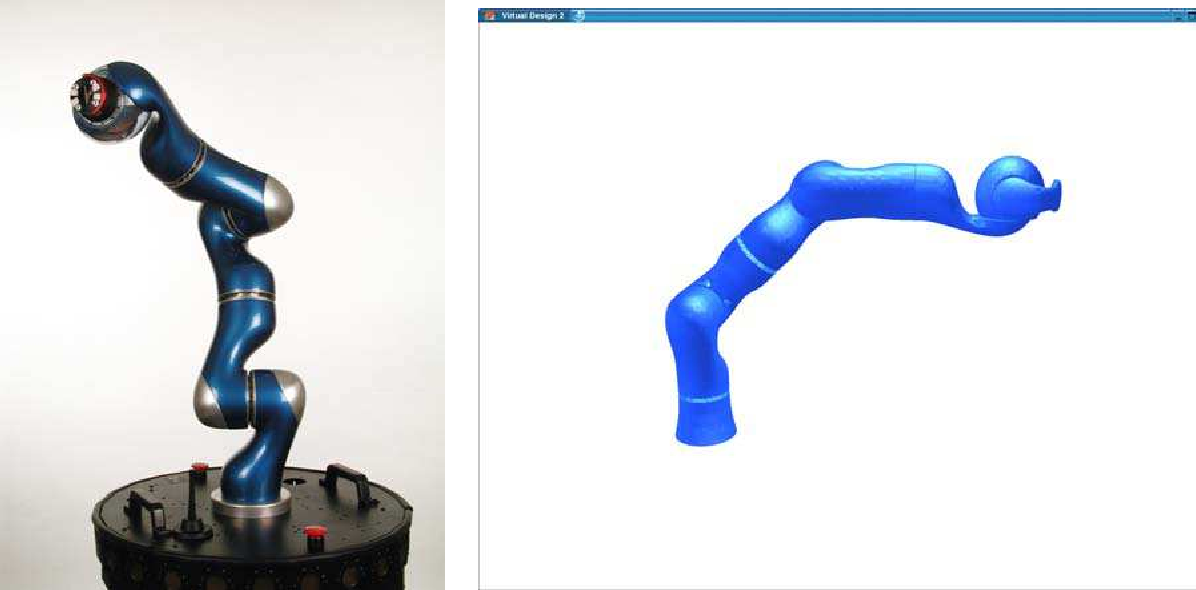
Figure 1 from Cartesian Impedance Control of Flexible Joint Robots: A ...
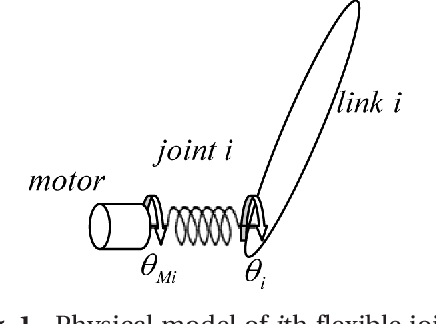
Figure 1 from Control of flexible joint robot manipulators using a ...
Advertisement Space (300x250)

Figure 1 from Feedback Control for n-Link Flexible Joint Robots With ...
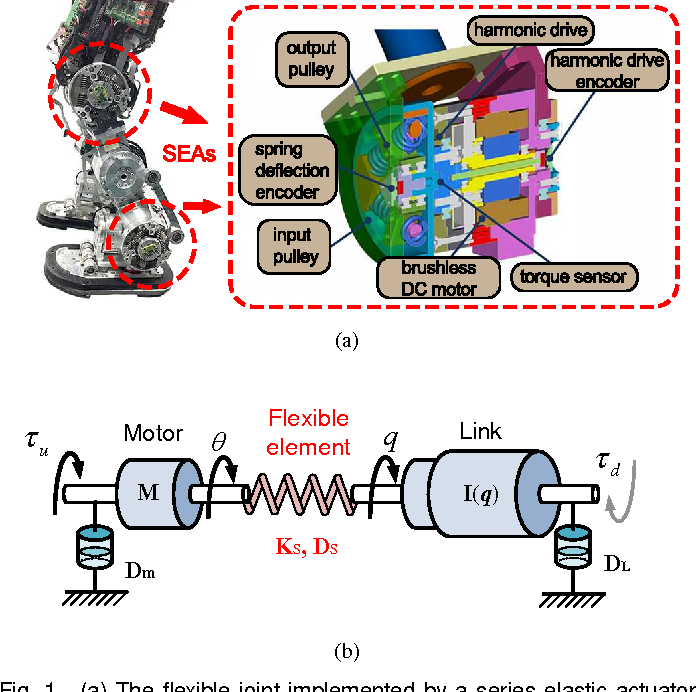
Figure 1 from Model-Free Robust Adaptive Control of Humanoid Robots ...
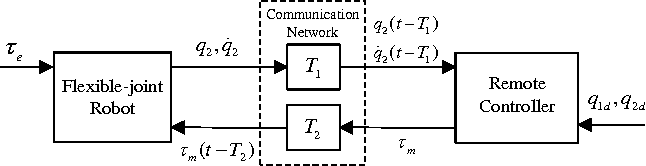
Figure 1 from Position regulation of flexible-joint robots with input ...
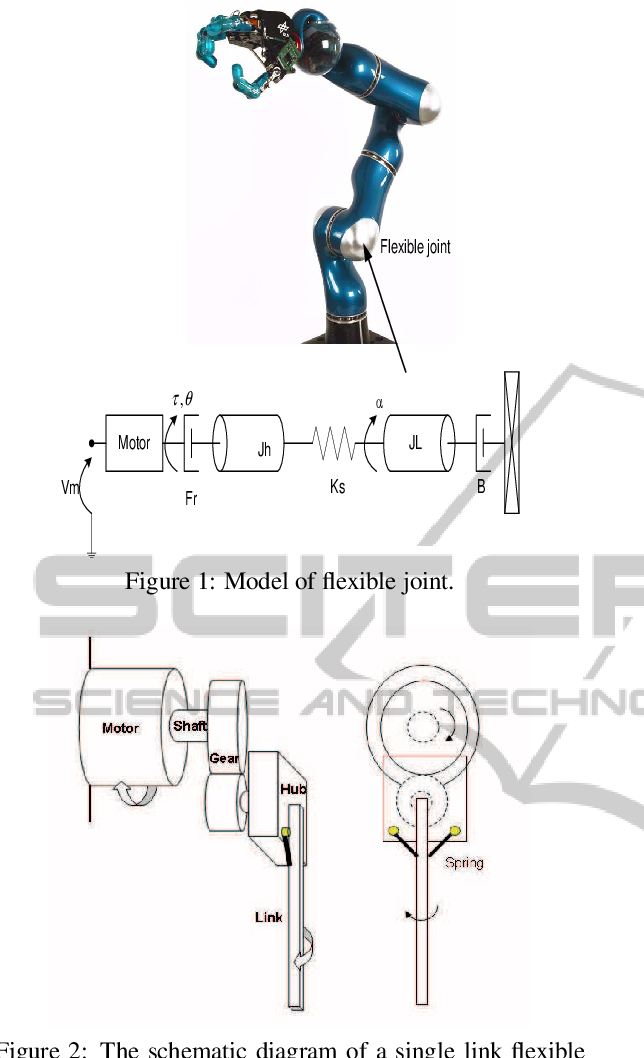
Figure 1 from Flatness based feed-forward control of a flexible robot ...

Figure 1 from Algebraic estimation and control of single-link flexible ...

Figure 1 from Force/Position Control for Flexible Joint Robot Using ...
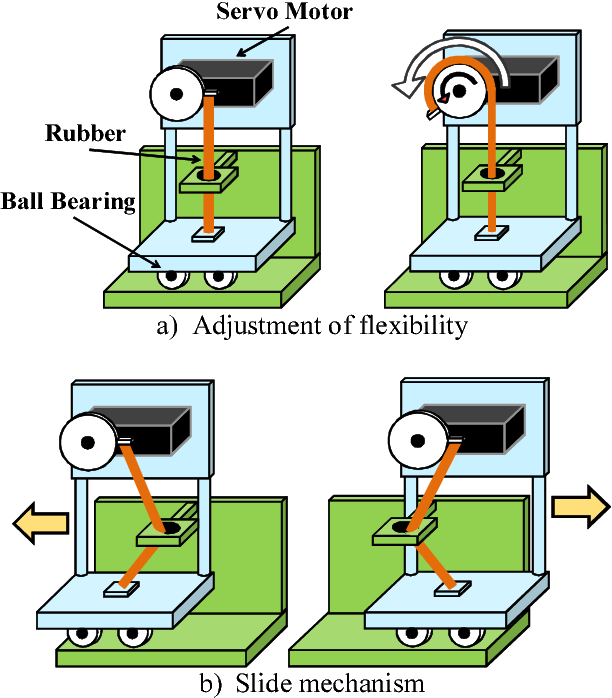
Figure 1 from Proposal of a flexible translational joint mechanism for ...
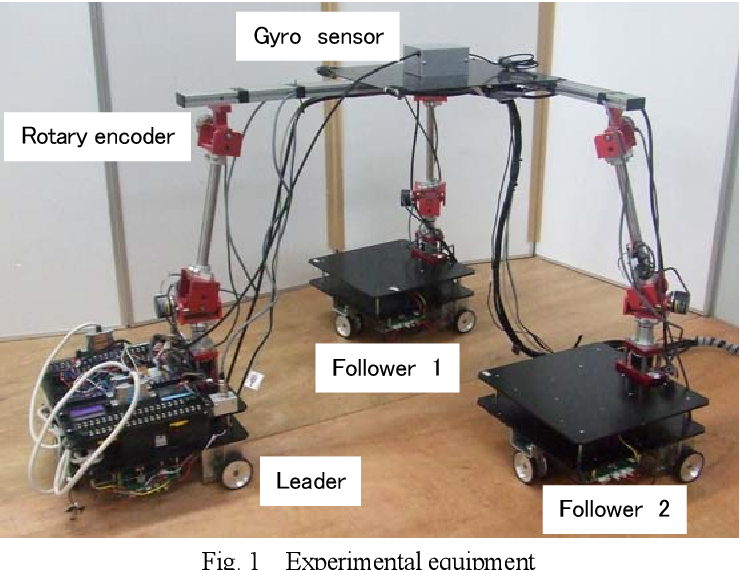
Figure 1 from Cooperative Transfer Control by Using Mobile Robots with ...

Figure 1 from Model Predictive Control for robots adapting their task ...
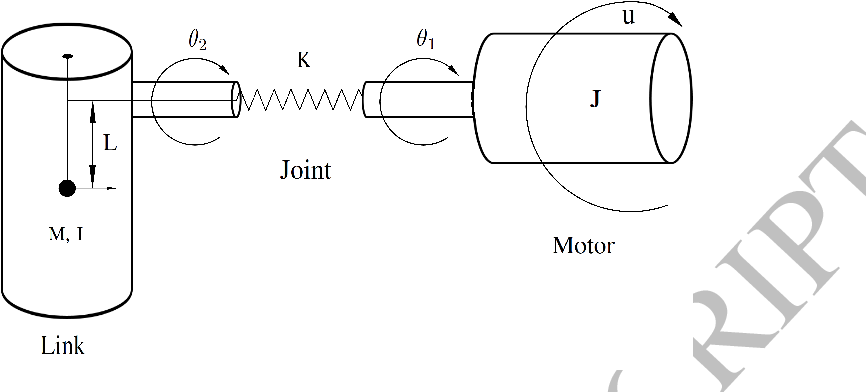
Figure 2 from Neuro-adaptive observer based control of flexible joint ...
Advertisement Space (336x280)

Figure 1 from Optimal position controller of a two-link flexible joints ...
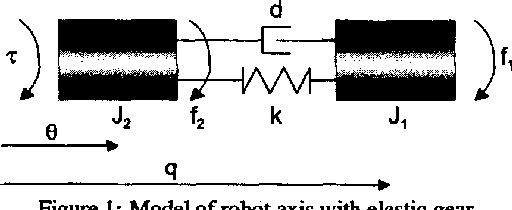
Figure 1 from Control of robots with elastic joints based on automatic ...
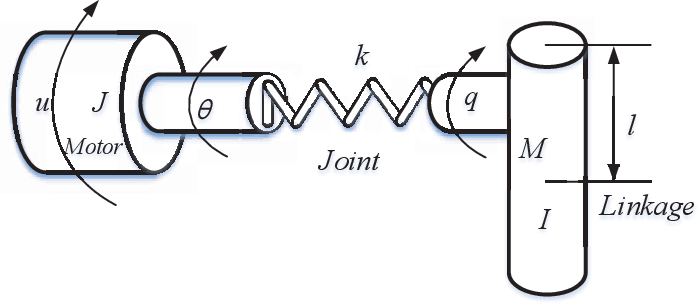
Figure 1 from Flexible Joint Manipulator Control Based on Adaptive ...

Figure 1 from Adaptive Neural Networks Control of Flexible-Joint Robots ...

Figure 1 from Novel Adaptive Control for Flexible-Joint Robots With ...
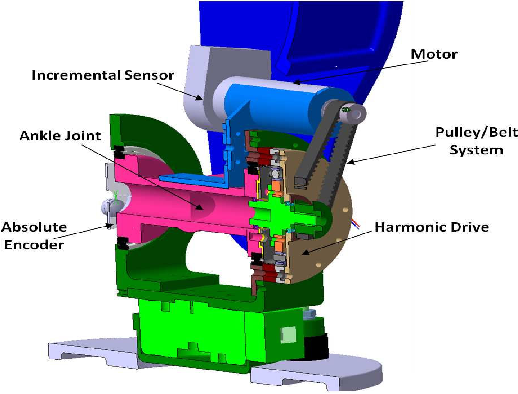
Figure 1 from Robust motion control for humanoid robot flexible joints ...

Figure 1 from Adaptive position control with using a smooth projection ...
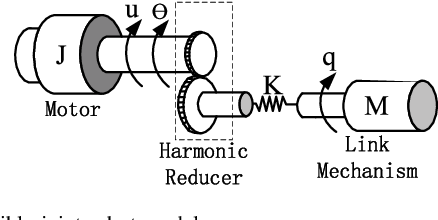
Figure 1 from Command Filtering-Based Adaptive Fuzzy Control of ...

Figure 4 from Model-Free Robust Adaptive Control of Humanoid Robots ...
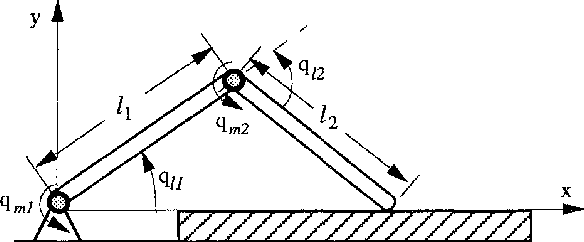
Figure 1 from A unified approach to motion and force control of ...
Advertisement Space (336x280)

Figure 1 from Vibration-suppression and fast-positioning control of ...

Identification and Control of Flexible Joint Robots Based on a ...

Figure 5 from Design and Analysis of Flexible Joints for Robots Based ...

(PDF) Identification and Control of Flexible Joint Robots Based on a ...
Figure 1 from Neural network-based variable impedance control of ...

Figure 2 from Design and Analysis of Flexible Joints for Robots Based ...