
Figure 1 From Robust Control For A 3dof Articulated Robotic Manipulator

Figure 1 from Robust Control for a 3DOF Articulated Robotic Manipulator ...

Figure 1 from Robust Control for a 3DOF Articulated Robotic Manipulator ...

Figure 1 from Robust Control for a 3DOF Articulated Robotic Manipulator ...

Figure 1 from Optimized Kinematic Control for a 3DOF Robot Manipulator ...

(PDF) Robust Control for a 3DOF Articulated Robotic Manipulator Joint ...
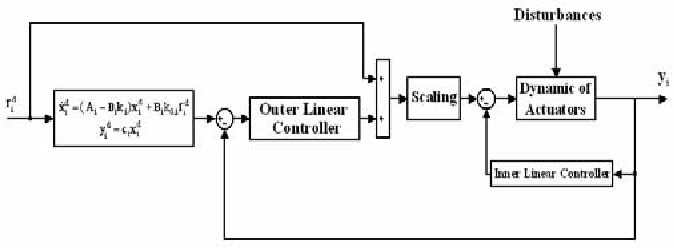
Figure 1 from A Model-Free Robust Control Approach for Robot ...

Figure 1 from Design and Control of 3-DOF Articulated Robotic Arm using ...
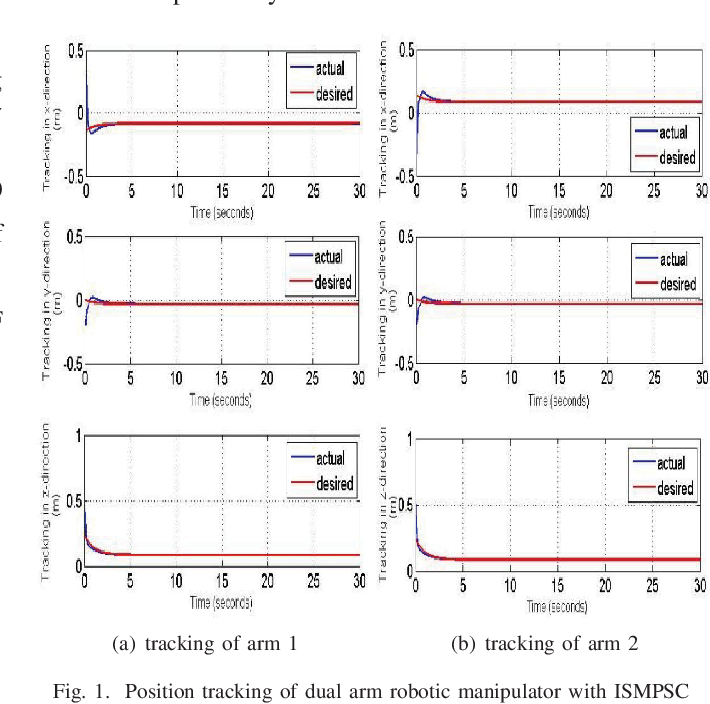
Figure 1 from Position Synchronization Control of a 3DoF Dual Arm ...

Figure 1 from An Adaptive Robust Control Method for Trajectory Tracking ...

Figure 1 from Modeling and Controlling of a 3 DOF Robot Manipulator ...
Advertisement Space (300x250)

Figure 1 from Design and Comparison of Two Control Strategies for Multi ...
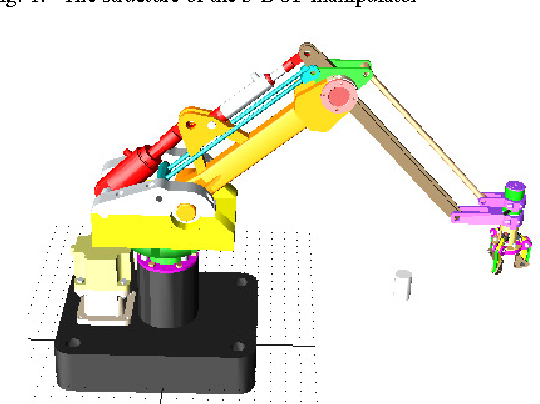
Figure 1 from Kinematic analysis and simulation of a 3-DOF robotic ...
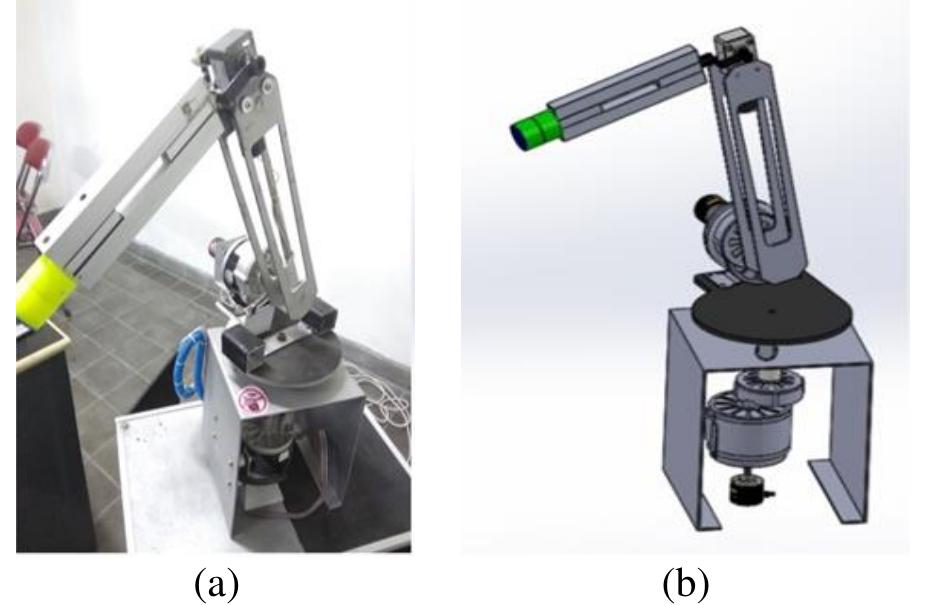
Figure 6 - from Joint control of a robotic arm using

Figure 1 from Model Predictive Control of a Three Degrees of Freedom ...
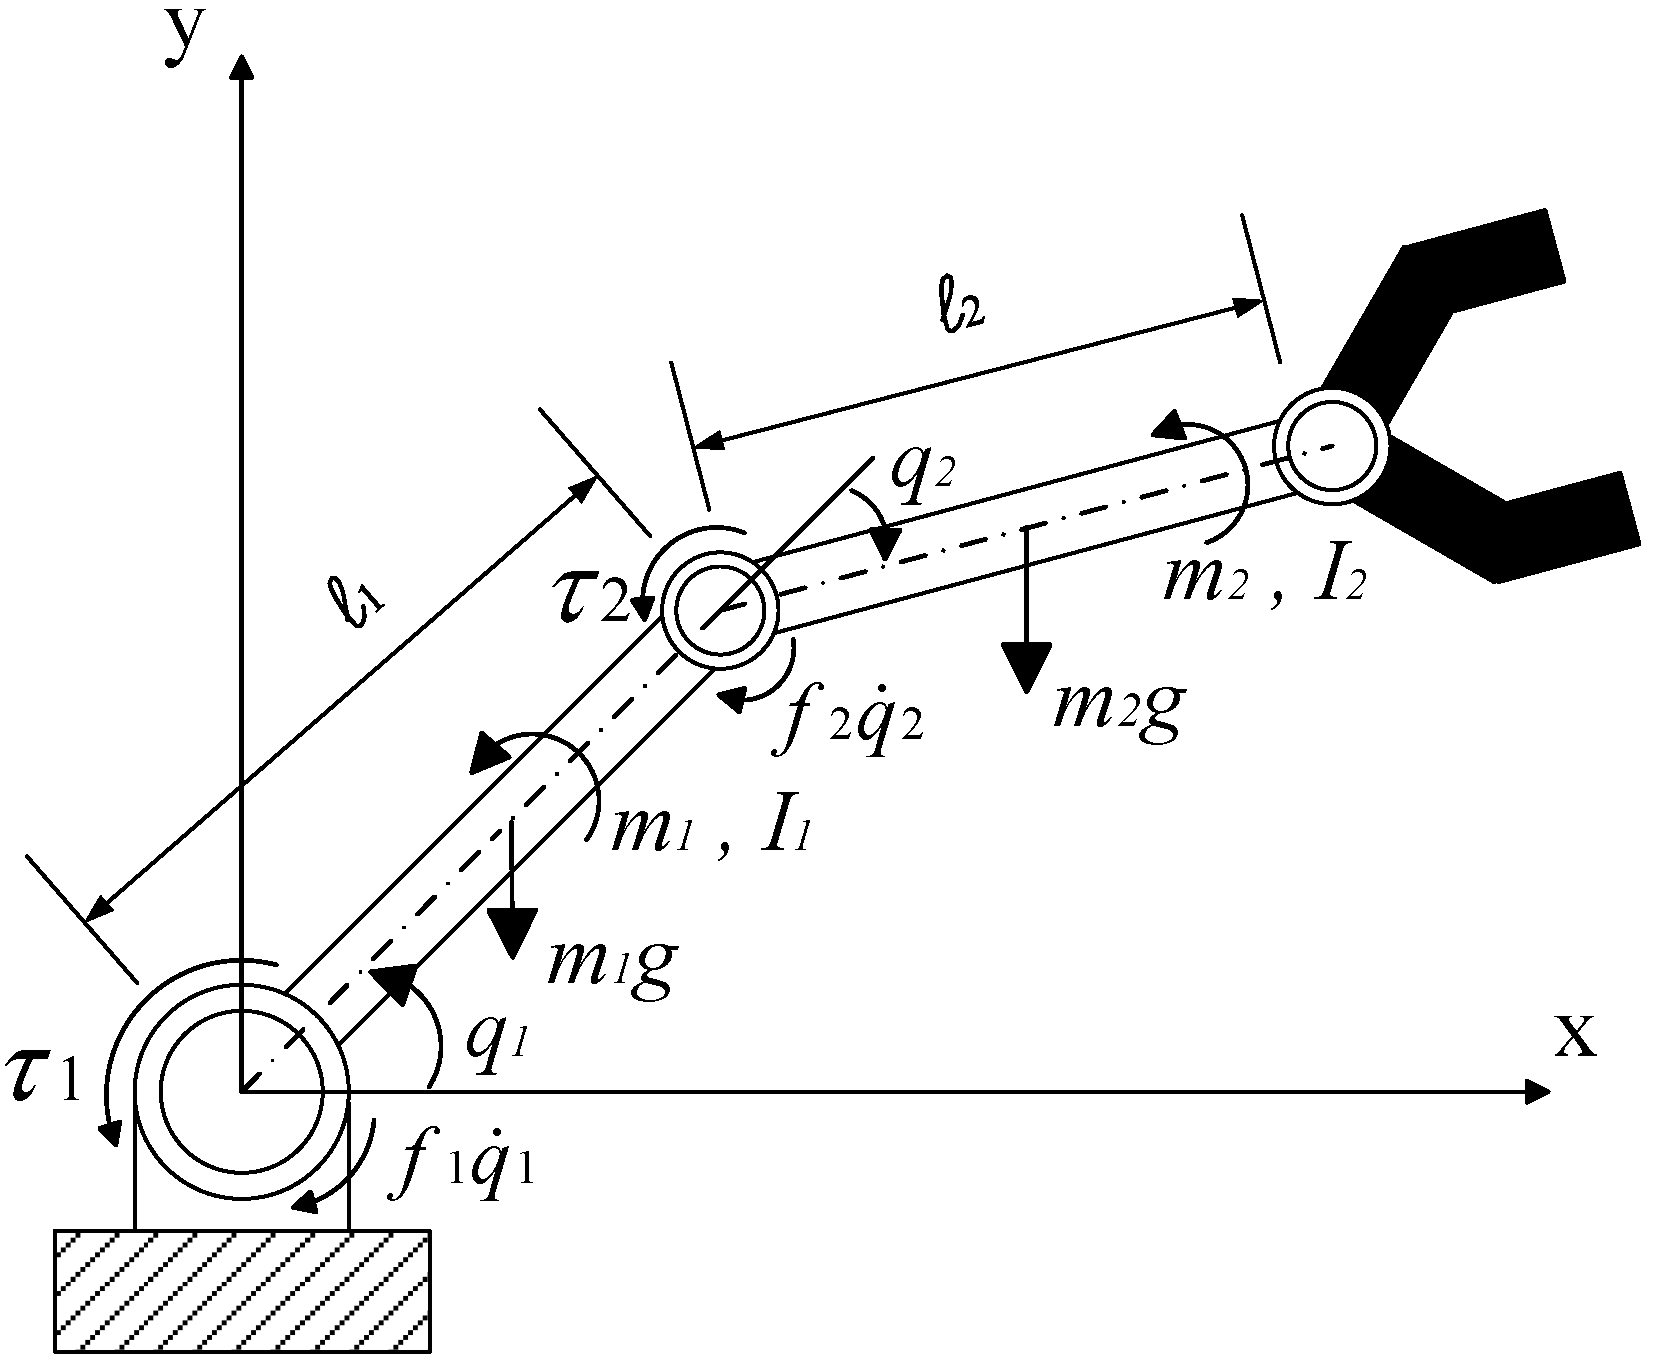
A Robust Noise-Free Linear Control Design for Robot Manipulator with ...

Observer-Based Adaptive Robust Force Control of a Robotic Manipulator ...
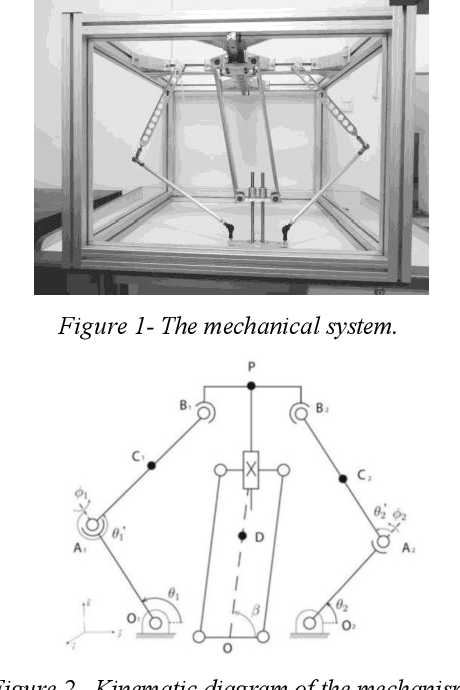
Figure 1 from Development of a controllerfor a 3-DOF robotic platform ...

Figure 2 from A Novel Control Method to Change Motion of 3DOF Parallel ...

Figure 1 from Real–Time Model Reference Adaptive Fuzzy Control of a ...

Intelligent robust control design for a 3-DoF industrial manipulator ...
Advertisement Space (336x280)
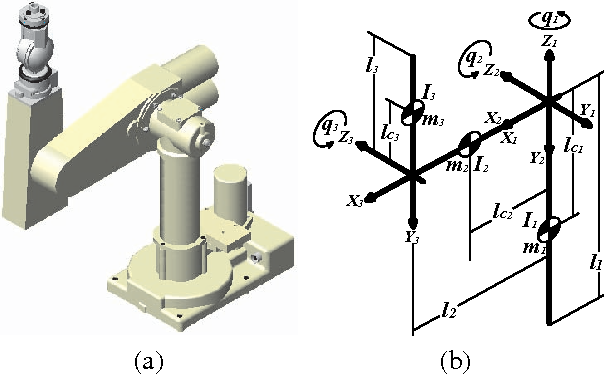
Figure 1 from Regulation Problem for an Industrial Manipulator with 3 ...

(PDF) Modeling and control of a 3-DOF articulated robotic manipulator ...

Fuzzy Control Strategies Development for a 3-DoF Robotic Manipulator in ...

(PDF) Modeling and control of a 3-DOF articulated robotic manipulator ...

Full article: Modeling and control of a 3-DOF articulated robotic ...

3DOF articulated manipulator in Spherical coordinates for forward ...

Figure 13 from Model Predictive Control Design of a 3-DOF Robot Arm ...

3DOF articulated manipulator in Spherical coordinates for inverse ...

Implementation of Fault-Tolerant Control for a Robot Manipulator Based ...

Figure 4 from Analysis of a proposed algorithm for point to point ...
Advertisement Space (336x280)

Full article: Modeling and control of a 3-DOF articulated robotic ...

Figure 2 from Structural synthesis of 3DOF articulated manipulators ...

(PDF) Control of a Three-dof Robotic Gripper for Space Applications

SOLVED: A 3 DOF robot manipulator is shown below 02 T-Y 0 = 74 Figure 1 ...
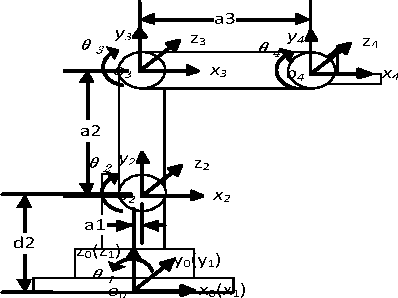
Figure 2 from Kinematic analysis and simulation of a 3-DOF robotic ...

Figure 4 from Workspace Mapping and Force Control for the 3-DOF Robot ...