
Figure 1 From Robust Object Grasping Using Force Compliant Motion

Figure 1 from Robust Object Grasping using Force Compliant Motion ...

Figure 12 from Robust Object Grasping using Force Compliant Motion ...
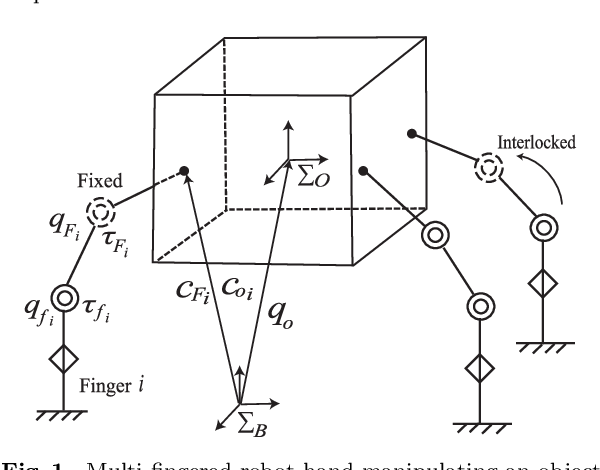
Figure 1 from Selection and Control of Object Motion and Internal Force ...
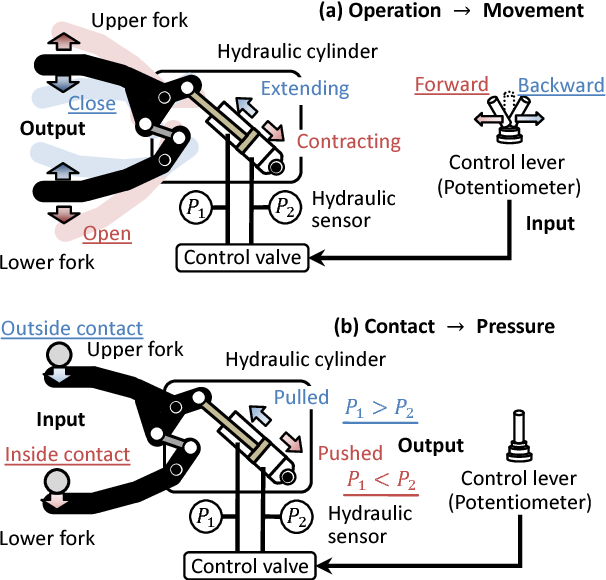
Figure 1 from An object grasp motion model using control signal and ...
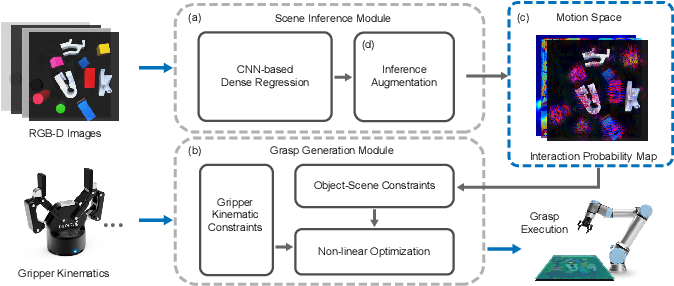
Figure 1 from Improving Robotic Grasping by Using Object-Gripper Motion ...
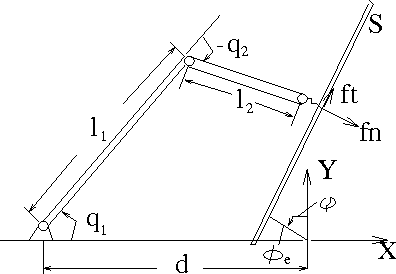
Figure 1 from Adaptive Robust Motion and Force Tracking Control of ...
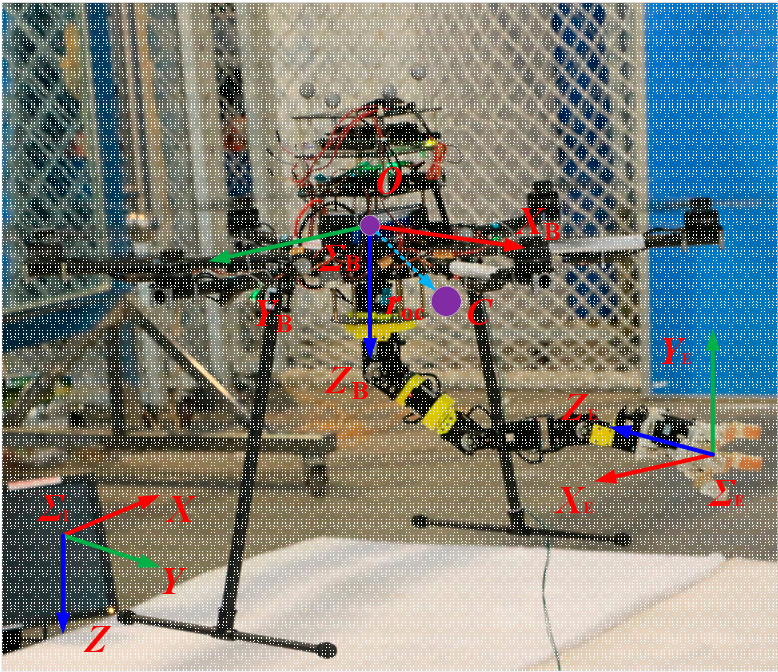
Figure 1 from Aerial Grasping of an Object in the Strong Wind: Robust ...
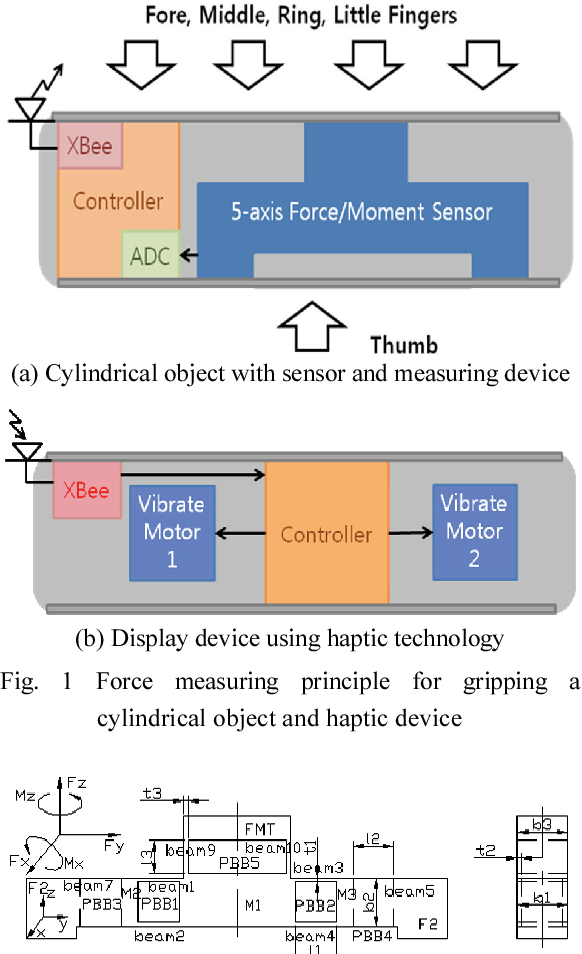
Figure 1 from Development of Cylindrical-object Grasping Force ...

Figure 1 from Target-driven Object Grasping Method for Mobile ...
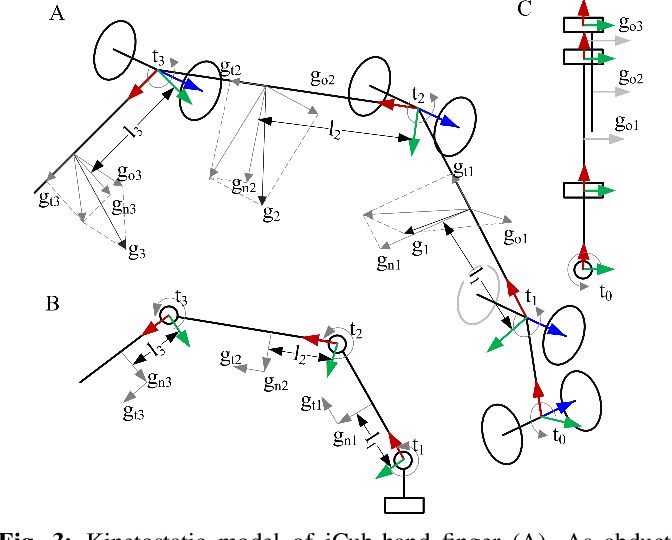
Figure 1 from Robust grasping for an under-actuated anthropomorphic ...
Advertisement Space (300x250)
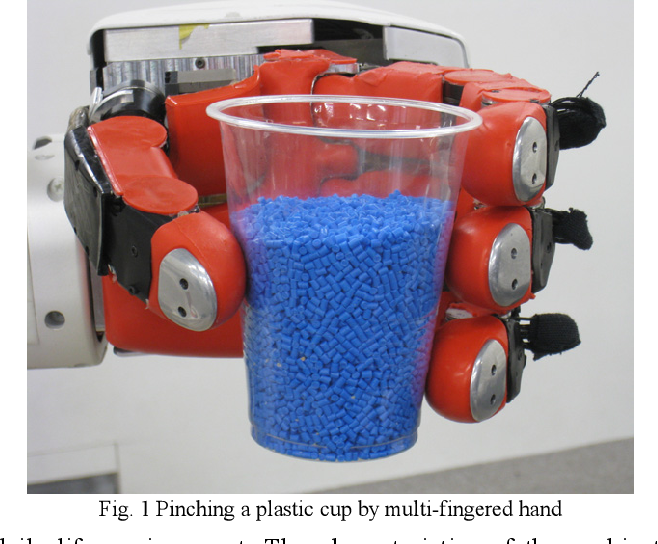
Figure 1 from A methodology for setting grasping force for picking up ...

Figure 1 from Grasping Living Objects With Adversarial Behaviors Using ...
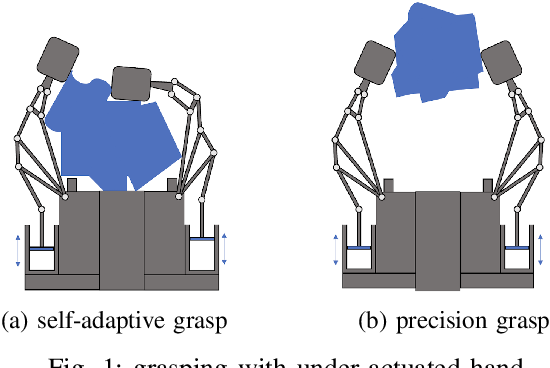
Figure 1 from Data-driven-based Stable Object Grasping for a Triple ...
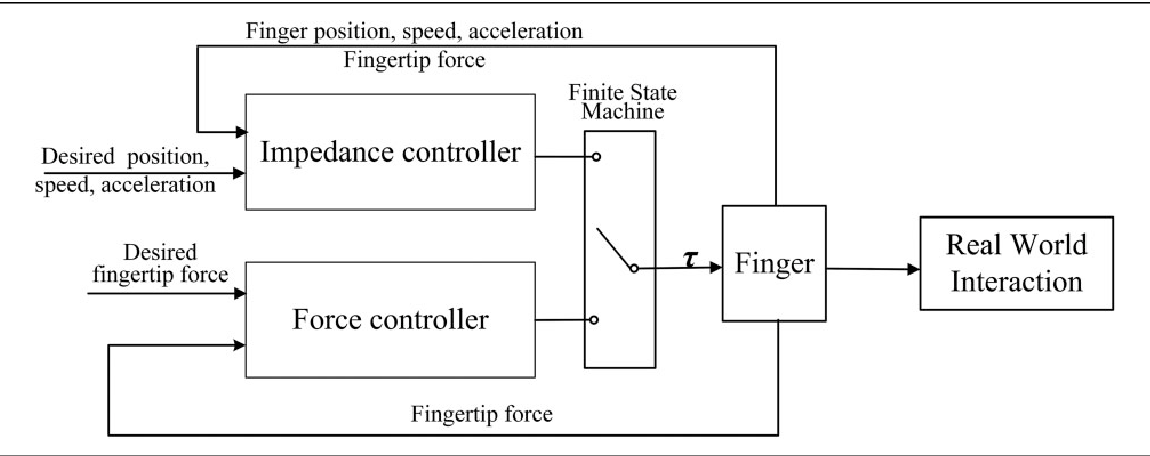
Figure 1 from Research on adaptive grasping with object pose ...
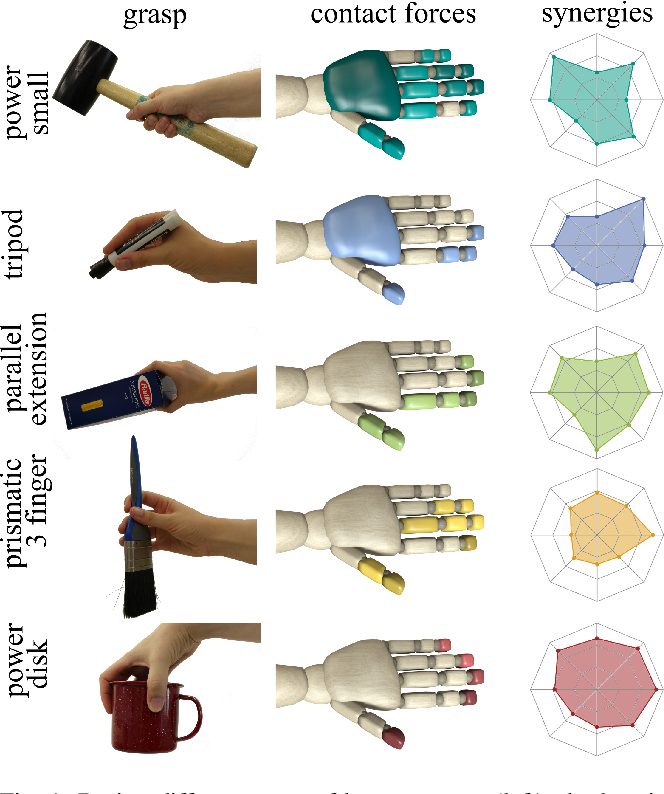
Figure 1 from On Force Synergies in Human Grasping Behavior | Semantic ...
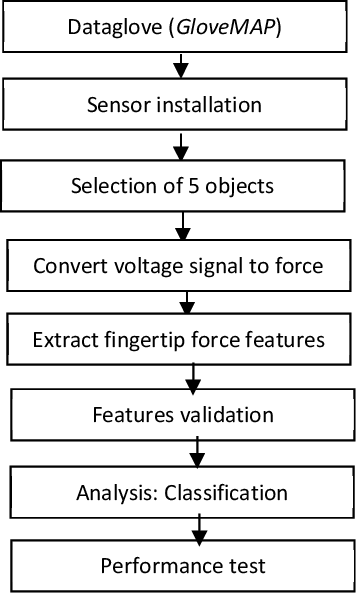
Figure 1 from Analysis of Object Grasping based on the Distributed ...
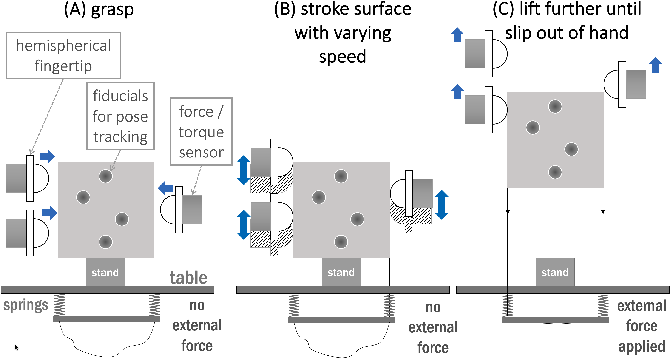
Figure 1 from Overlooked Variables in Compliant Grasping and ...
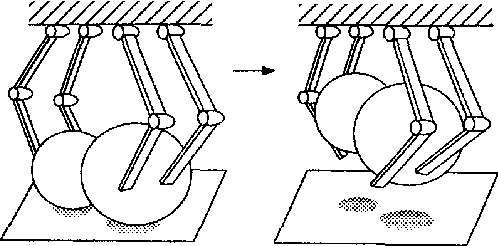
Figure 1 from Kinematics and internal force in grasping multiple ...
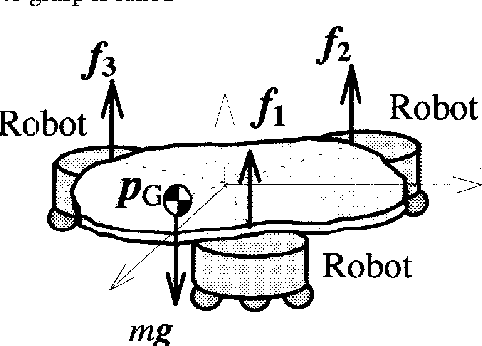
Figure 1 from Initial grasping strategy for an unknown object by ...
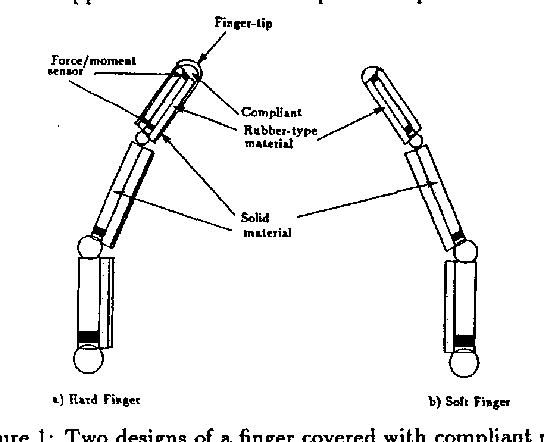
Figure 1 from Toward interpretation of forces in compliant contact for ...
Advertisement Space (336x280)

Figure 1 from Force-Guided High-Precision Grasping Control of Fragile ...

Figure 1 from Robotic grasp detection toward unknown objects using 3D ...
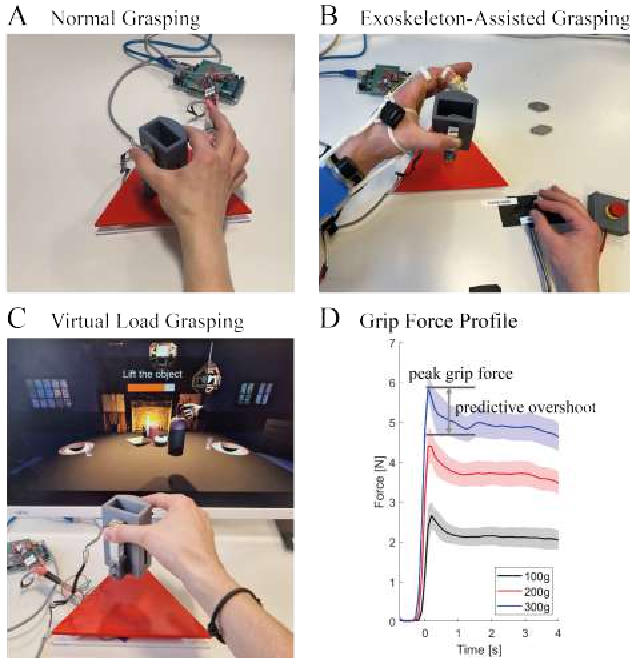
Figure 1 from Grip Force Dynamics During Exoskeleton-Assisted and ...
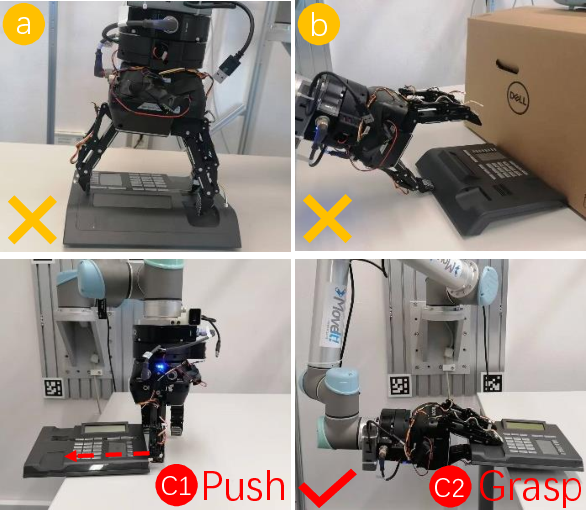
Figure 1 from Reinforcement Learning Based Pushing and Grasping Objects ...

Figure 1 from Semi-Autonomous Grasping Control of Prosthetic Hand and ...
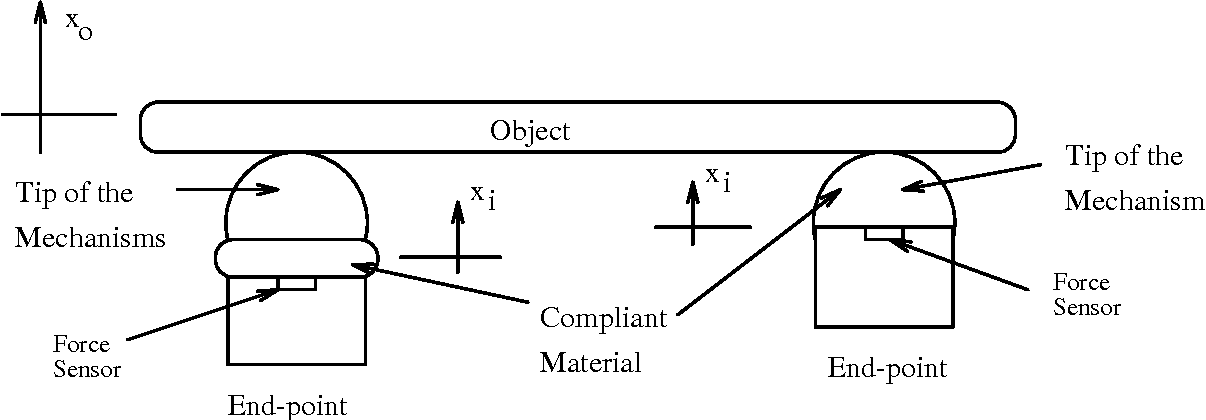
Figure 1 from Force and position control of grasp in multiple robotic ...
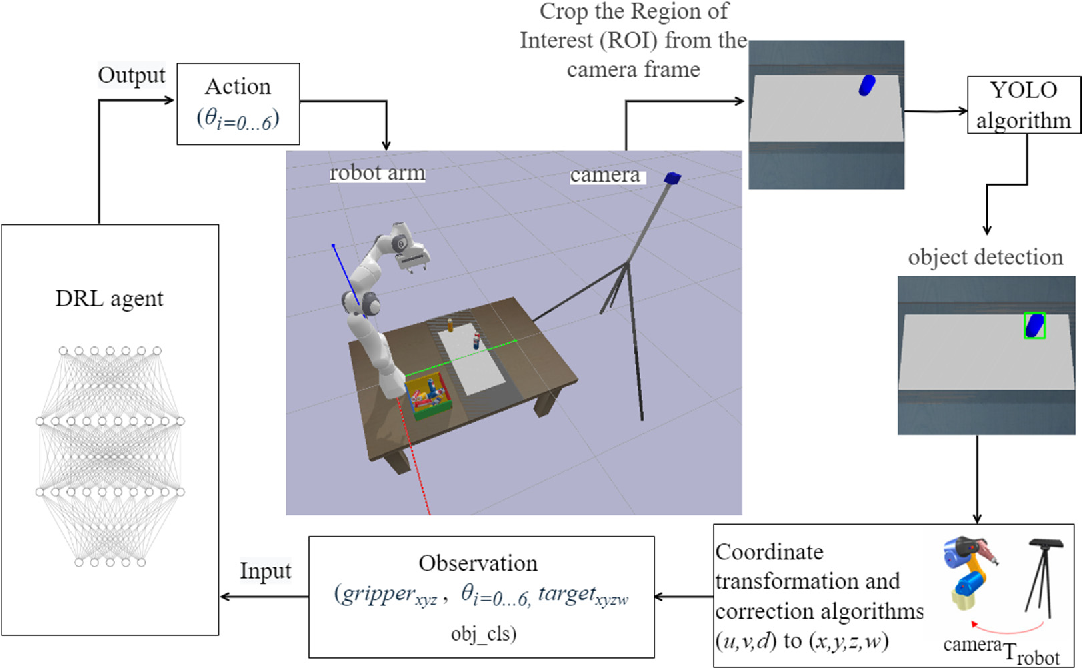
Figure 1 from Vision-Based Reinforcement Learning for Robotic Grasping ...

Table 1 from Cognitive Grasping and Manipulation of Unknown Object with ...

Results of the grasping force tests. From a) to c), the tubular object ...

Figure 1 from Semi-Autonomous Grasping Control of Prosthetic Hand and ...
Advertisement Space (336x280)

Figure 1 from Semi-Autonomous Grasping Control of Prosthetic Hand and ...

Figure 1 from Learning Adaptive Grasping From Human Demonstrations ...
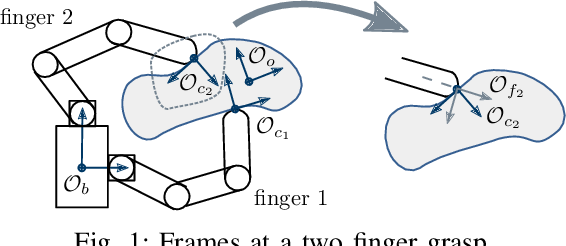
Figure 1 from Model Predictive Interaction Control for Force Closure ...
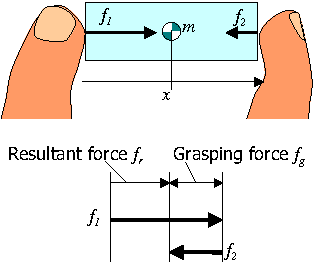
Figure 1 from Presenting grasping and resultant forces for rigid body ...
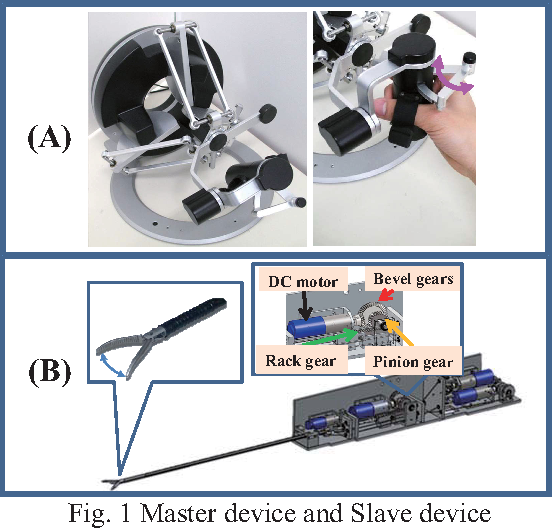
Figure 1 from Estimation of the grasping torque of robotic forceps ...

[论文评述] Bayesian optimization for robust robotic grasping using a ...