
Figure 1 From Unified Motion Planning Of Passing Under Obstacles With

Figure 1 from Unified motion planning of passing under obstacles with ...

Figure 1 from Unified motion planning of passing under obstacles with ...

Figure 1 from Avoiding Dynamic Obstacles with Real-time Motion Planning ...
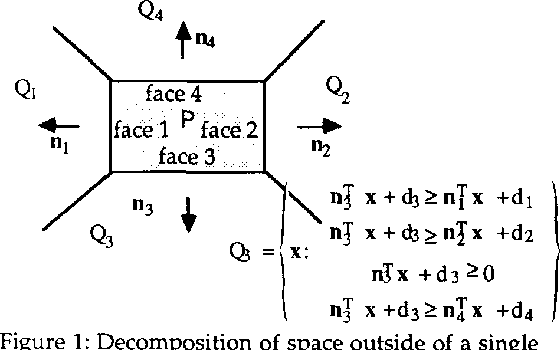
Figure 1 from Motion planning with time-varying polyhedral obstacles ...

Figure 1 from A New Method of Solving UAV Trajectory Planning Under ...
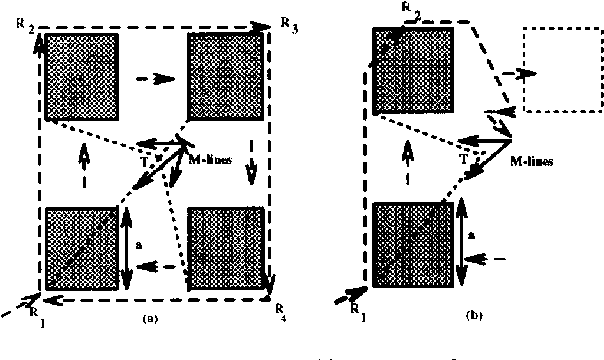
Figure 1 from Velocity bounds for motion planning in the presence of ...
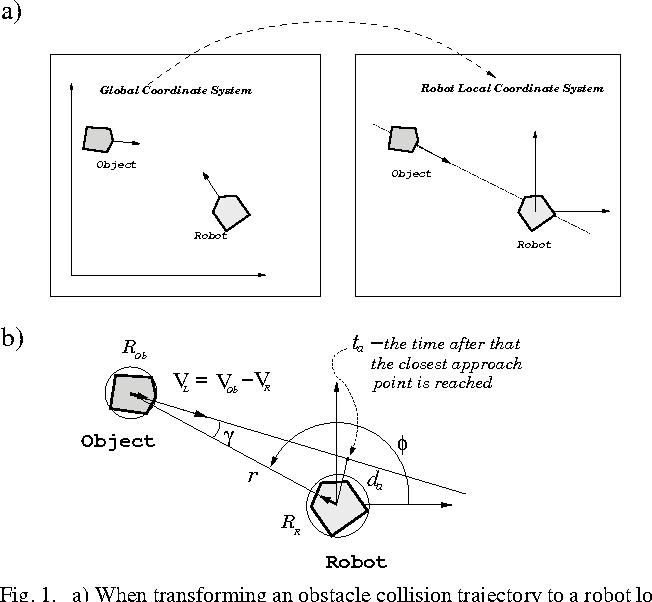
Figure 1 from Robot local motion planning among moving obstacles ...
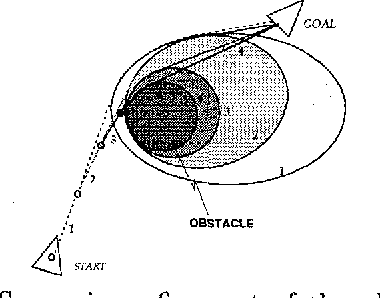
Figure 1 from Motion planning with uncertainty | Semantic Scholar
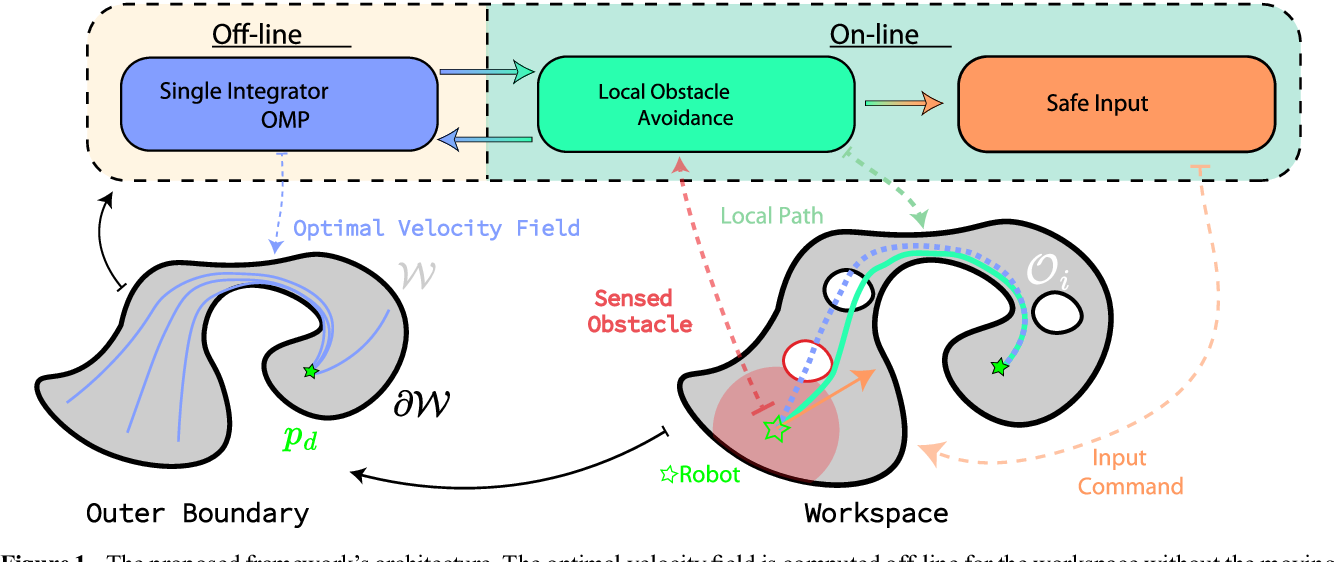
Figure 1 from Robust and topology-aware motion planning with moving ...
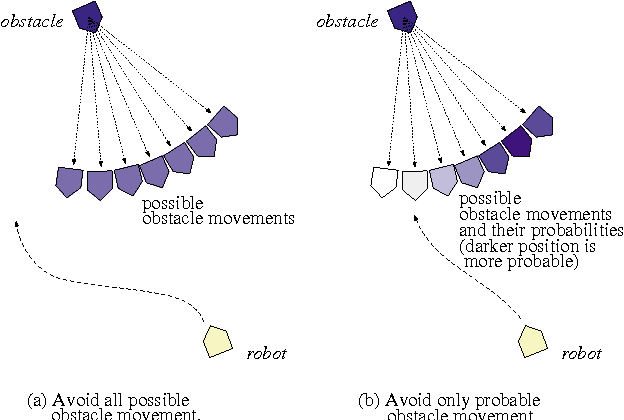
Figure 1 from Modeling motion uncertainty of moving obstacles for robot ...
Advertisement Space (300x250)
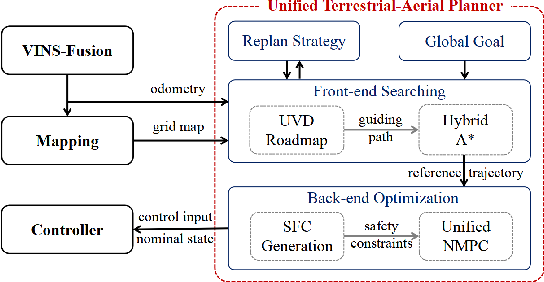
Figure 1 from Motion Planning for HyTAQs: A Topology-guided Unified ...

Figure 1 from Behavior planning of an unmanned ground vehicle with ...
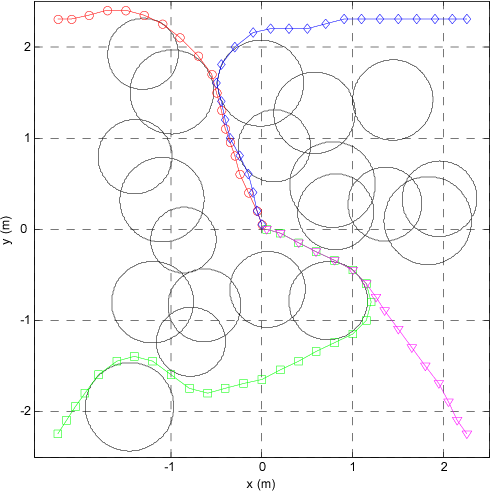
Figure 1 from Time-optimal motion planning of autonomous vehicles in ...
Figure 1 from Real-time motion planning in the presence of moving ...

Figure 1 from Behavior planning of an unmanned ground vehicle with ...
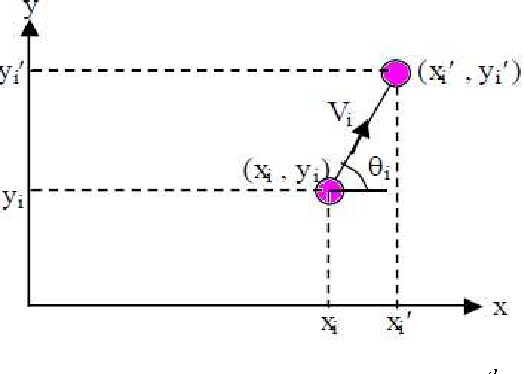
Figure 1 from Dynamic obstacle avoidance in multi-robot motion planning ...
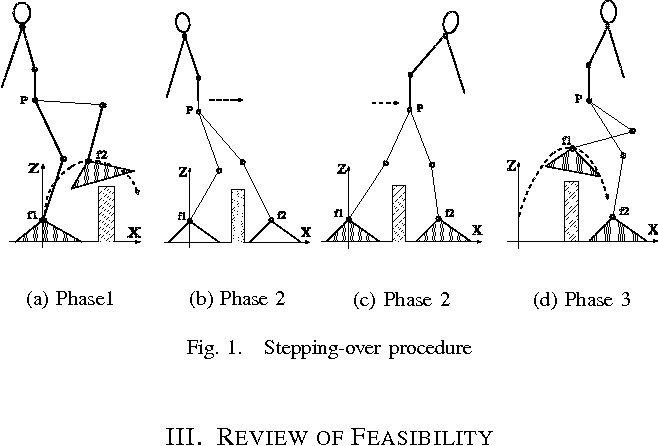
Figure 1 from Motion planning for humanoid robots stepping over ...

Figure 1 from Motion Planning and Obstacle Avoidance for Robot ...

Figure 1 from A review on motion planning and obstacle avoidance ...

Figure 1 from Robust Predictive Motion Planning by Learning Obstacle ...
Advertisement Space (336x280)

Figure 1 from Path planning and obstacle avoidance of unmanned aerial ...
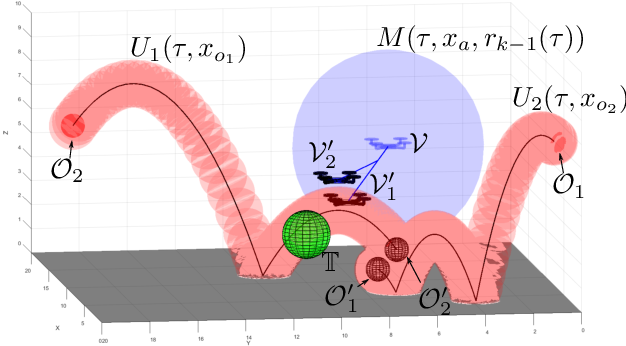
Figure 1 from A Set-based Motion Planning Algorithm for Aerial Vehicles ...

Figure 1 from MoConVQ: Unified Physics-Based Motion Control via ...
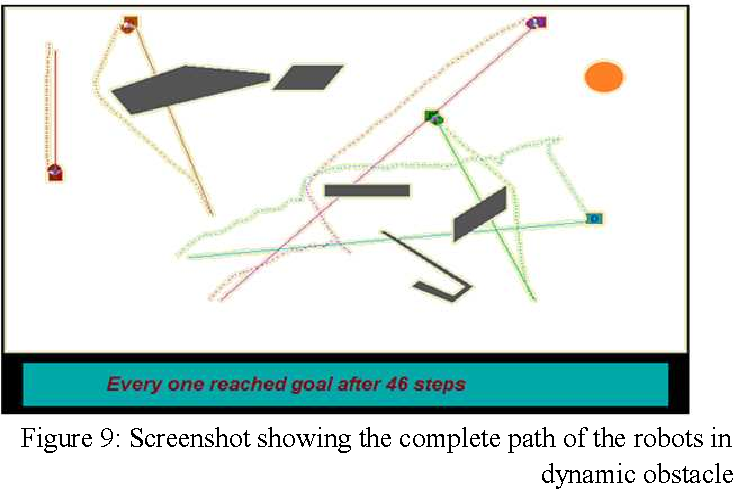
Figure 1 from Dynamic obstacle avoidance in multi-robot motion planning ...

Figure 1 from Computational Efficient Motion Planning Method for ...

Figure 1 from A Unified Framework Integrating Trajectory Planning and ...
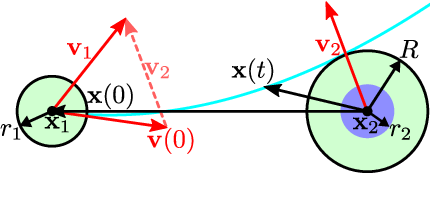
Figure 1 from Robots' Motion Planning in Human Crowds by Acceleration ...

Motion Planning around Obstacles with Graphs of Convex Sets

Figure 1 from A Unified Trajectory Planning and Tracking Control ...
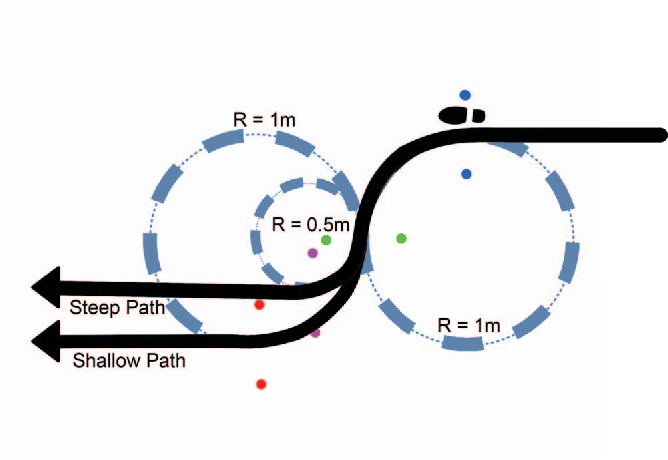
Figure 1 from The Change of Gait Motion During Curvilinear Obstacle ...
Advertisement Space (336x280)

Figure 1 from A Maneuvering-Board Approach to Path Planning with Moving ...

Figure 1 from Minimum Displacement Motion Planning for Movable ...

Figure 3 from Robotic Arm Motion Planning with Autonomous Obstacle ...
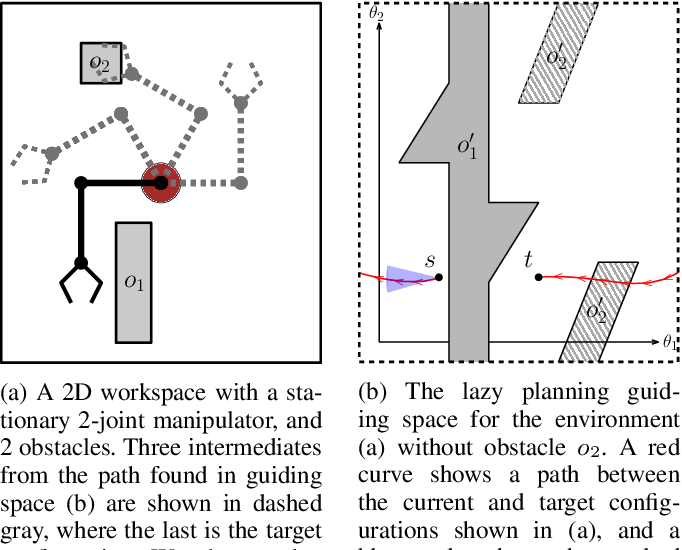
Figure 1 from Evaluating Guiding Spaces for Motion Planning | Semantic ...

Figure 1 from A Hardware-efficient Unified Motion Estimation for Video ...

(PDF) Motion Planning With Dynamic Obstacles Using Convexified Control ...