
Figure 1 From Whole Body Motion Pattern Generation For Biped Humanoid
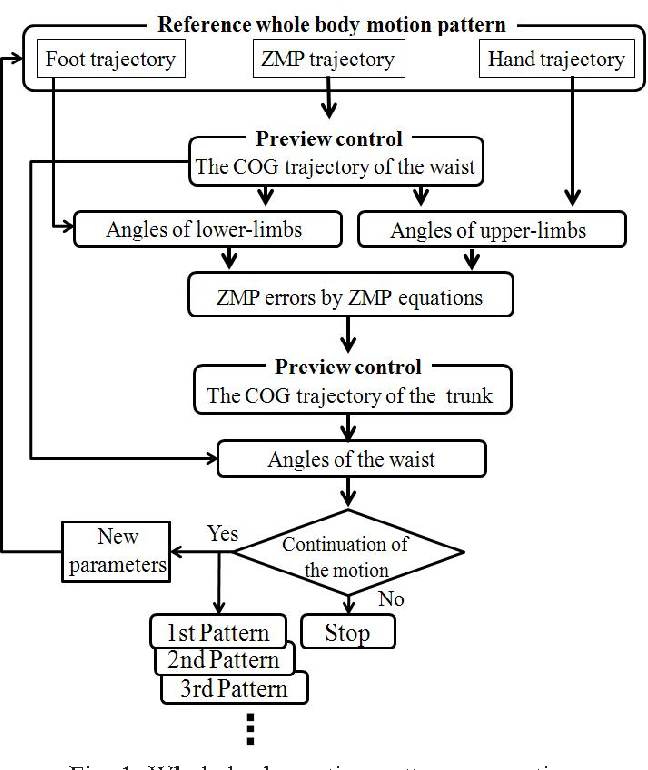
Figure 1 from Whole body motion pattern generation for biped humanoid ...
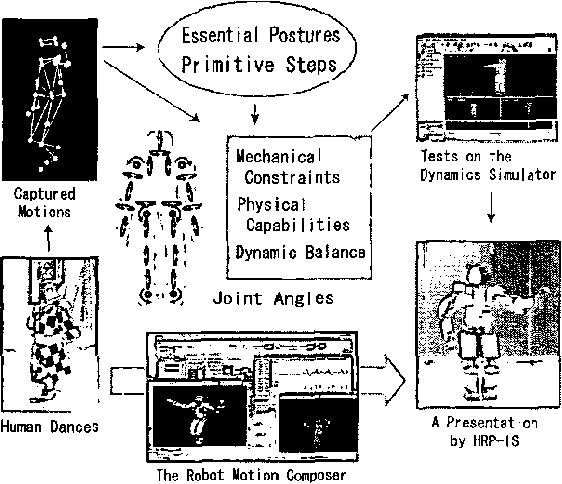
Figure 1 from Generating whole body motions for a biped humanoid robot ...

Figure 1 from Whole body motion generation of a humanoid robot using a ...

Figure 1 from Stable whole-body motion generation for humanoid robots ...
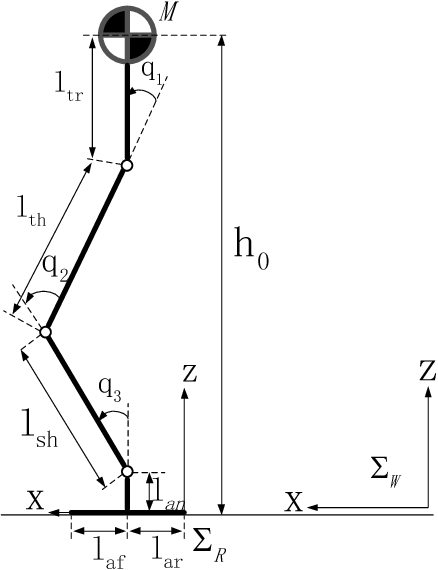
Figure 1 from Bio-inspired falling motion control for a biped humanoid ...

Figure 1 from Whole body motion control strategy of humanoid robot ...

Figure 1 from Whole body motion control strategy of humanoid robot ...

Figure 1 from Design of Crawling Motion for a Biped Walking Humanoid ...
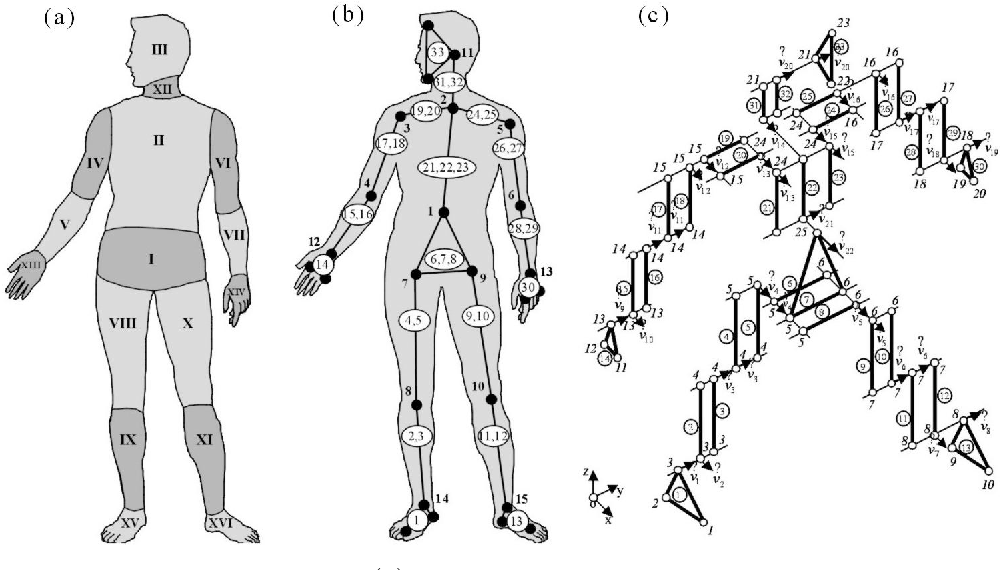
Figure 1 from Biomechanical modelling for whole body motion using ...
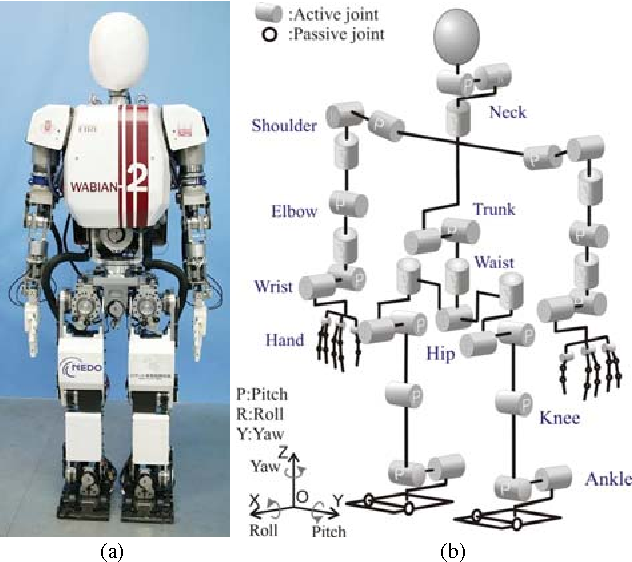
Figure 1 from Application of Biped Humanoid Robot to Motion Simulation ...
Advertisement Space (300x250)
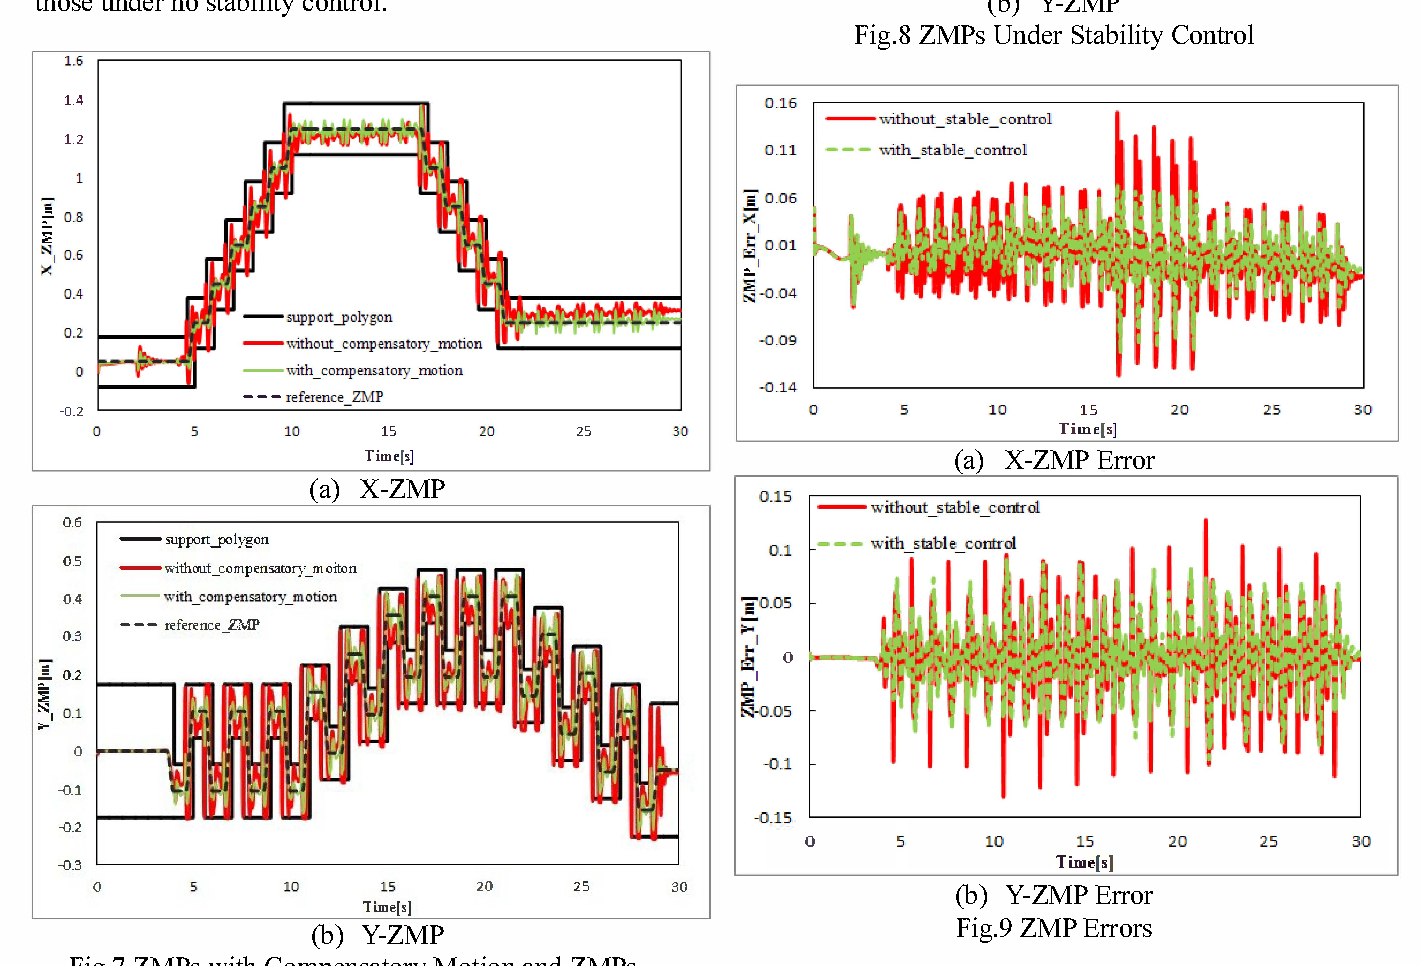
Figure 7 from Stability control and pattern generation for biped ...

Figure 12 from Online Running Pattern Generation for Humanoid Robot ...
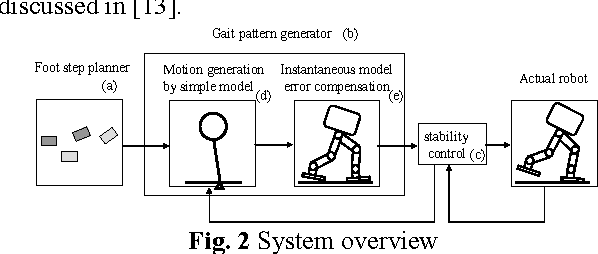
Figure 2 from Real time motion generation and control for biped robot ...
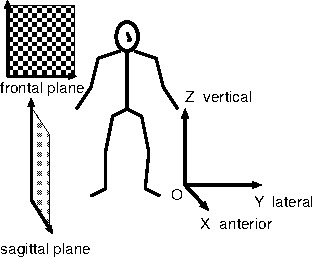
Figure 1 from Continuous Gait-Pattern Generation for Biped Robots ...

Figure 3 from Motion separating based whole body motion planning for ...

Figure 1 from Realization of quick turn of biped humanoid robot by ...

Figure 1 from A Biologically Inspired Biped Locomotion Strategy for ...

Figure 1 from Style-phase adaptation of human and humanoid biped ...

Figure 1 from A Biologically Inspired Biped Locomotion Strategy for ...
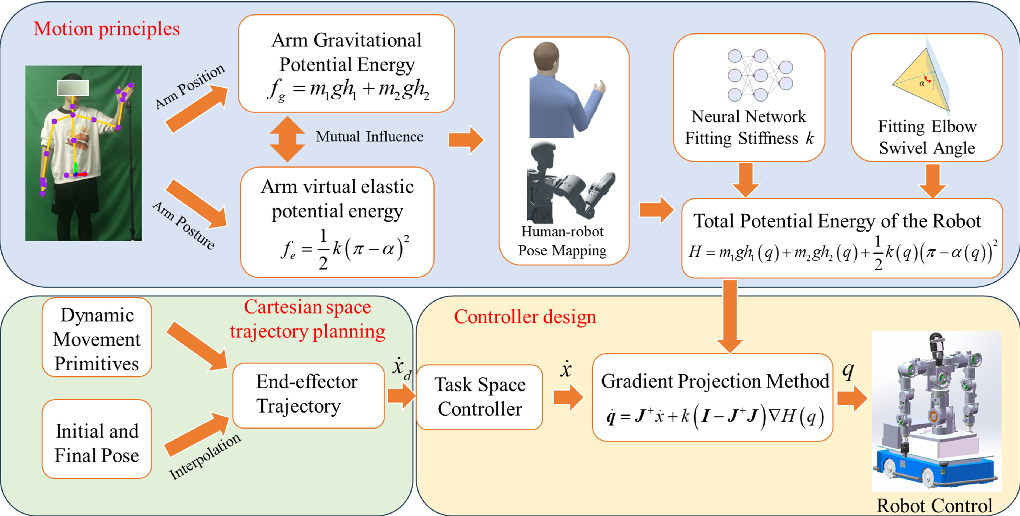
Figure 1 from A Whole-Body Coordinated Motion Control Method for Highly ...
Advertisement Space (336x280)

The joint level whole body motion for getting up from a fall. (a ...

Figure 1 from Mechanisms of biped humanoid robot and online walking ...

Figure 1 from Whole-Body Motion Generation Integrating Operator's ...

Figure 1 from Mechanisms of biped humanoid robot and online walking ...
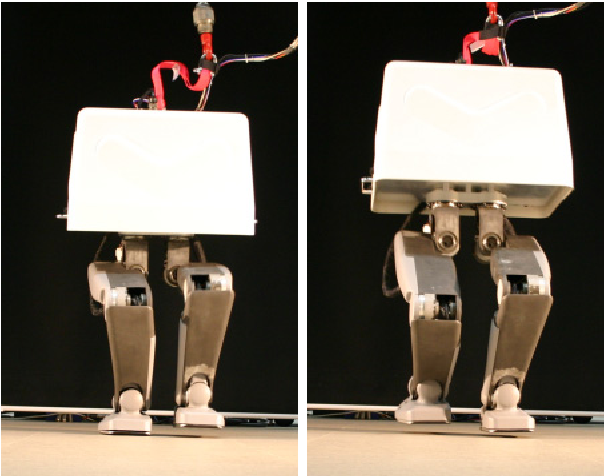
Figure 1 from A running experiment of humanoid biped | Semantic Scholar
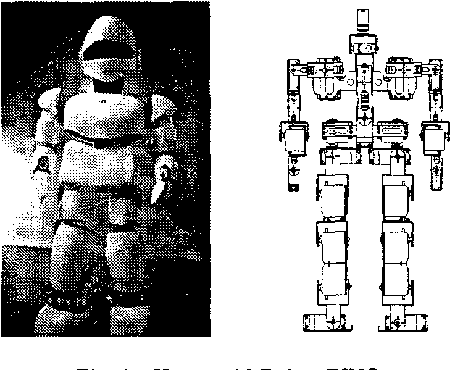
Figure 1 from A method for co-evolving morphology and walking pattern ...
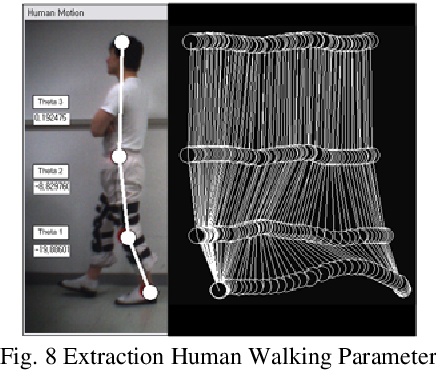
Figure 8 from Adaptive Gait Pattern Generation of Biped Robot based on ...
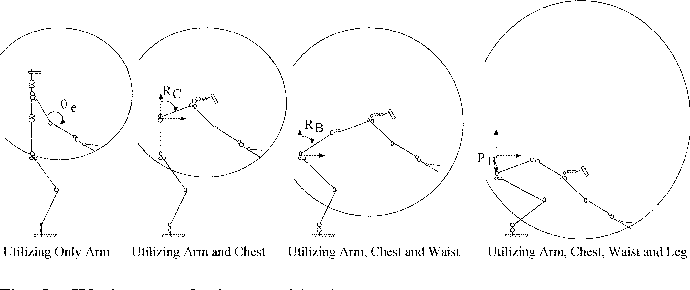
Figure 1 from Whole-Body Motion Generation Integrating Operator's ...
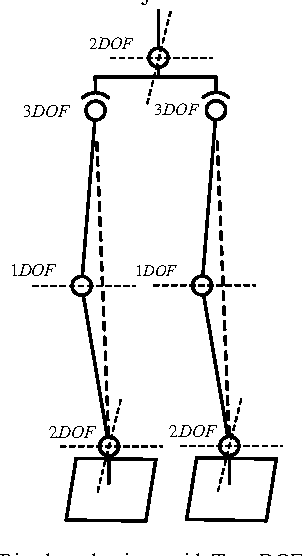
Figure 1 from Human-like Walking of Humanoid Robot Based on Biped ...

Figure 1 from Multi-Speed Walking Gait Generation for Bipedal Robots ...
Advertisement Space (336x280)

Figure 12 from Whole-body motion of a humanoid robot for passing ...

Figure 1 from A Biologically Inspired Biped Locomotion Strategy for ...

Figure 9 from Application of Biped Humanoid Robot to Motion Simulation ...
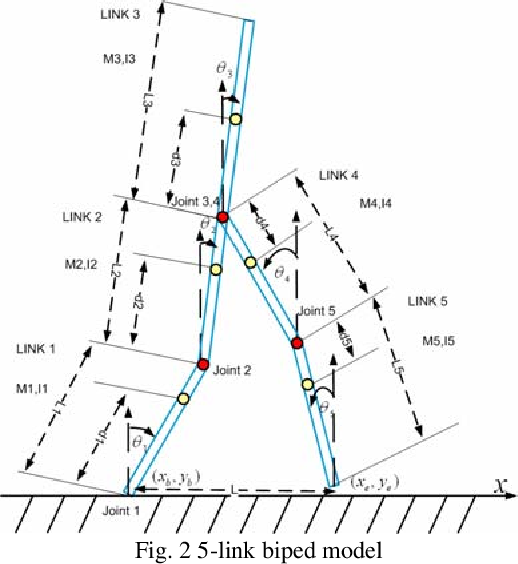
Figure 2 from Adaptive Gait Pattern Generation of Biped Robot based on ...

Figure 7 from Whole-body motion of a humanoid robot for passing through ...

Figure 1 from Forward and inverse kinematic based full body gait ...