
Figure 13 From Design And Locomotion Control Of A Dactylopteridae
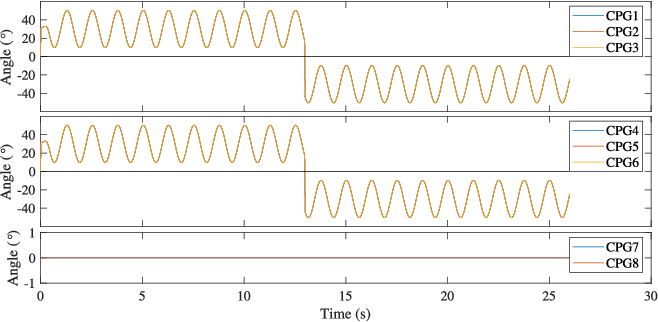
Figure 13 from Design and Locomotion Control of a Dactylopteridae ...

Figure 1 from Design and Locomotion Control of a Dactylopteridae ...

Figure 1 from Design and Locomotion Control of a Dactylopteridae ...
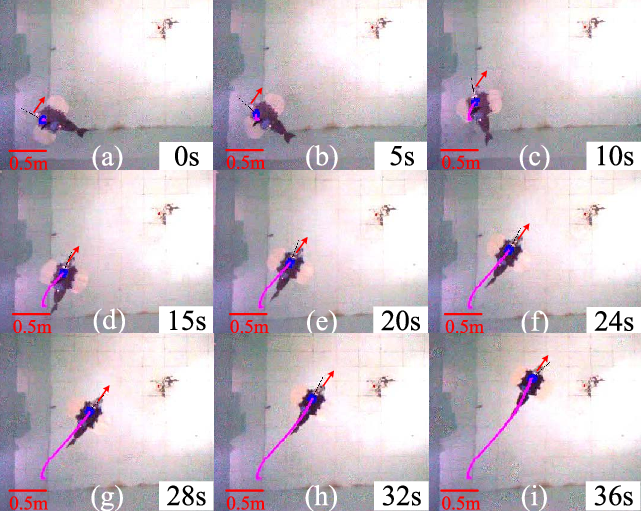
Figure 19 from Design and Locomotion Control of a Dactylopteridae ...

Figure 1 from Design and Locomotion Control of a Dactylopteridae ...

Figure 1 from Design and Locomotion Control of a Dactylopteridae ...

Figure 1 from Design and Locomotion Control of a Dactylopteridae ...

Figure 12 from Design and Locomotion Control of a Dactylopteridae ...

Figure 1 from Design and Locomotion Control of a Dactylopteridae ...

Figure 1 from Design and Locomotion Control of a Dactylopteridae ...
Advertisement Space (300x250)
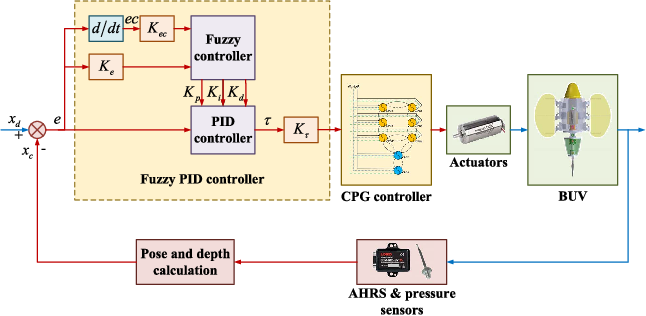
Figure 9 from Design and Locomotion Control of a Dactylopteridae ...

Figure 1 from Design and Locomotion Control of a Dactylopteridae ...

Figure 1 from Design and Locomotion Control of a Dactylopteridae ...
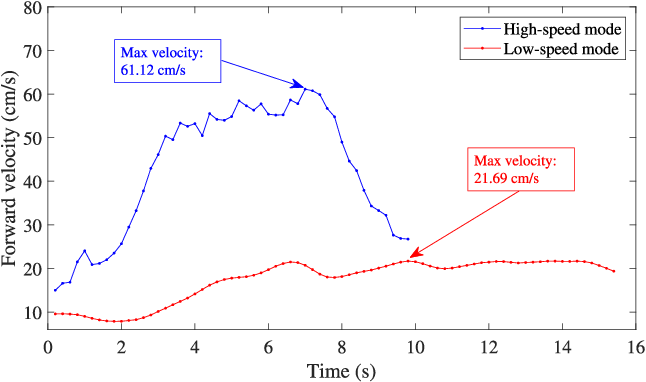
Figure 14 from Design and Locomotion Control of a Dactylopteridae ...

Figure 1 from Design and Locomotion Control of a Dactylopteridae ...

Figure 15 from Design and Locomotion Control of a Dactylopteridae ...

Figure 1 from Design and Locomotion Control of a Dactylopteridae ...

Figure 1 from Design and Locomotion Control of a Dactylopteridae ...

Figure 1 from Design and Locomotion Control of a Dactylopteridae ...
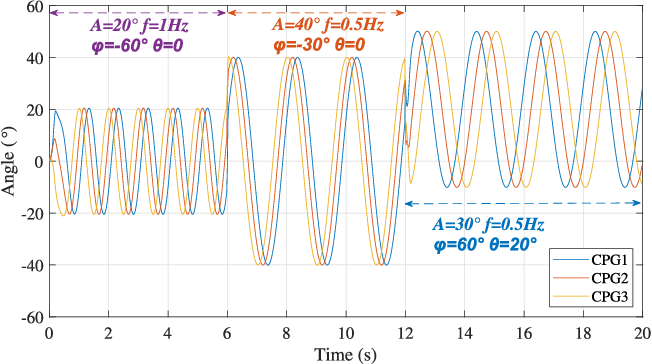
Figure 7 from Design and Locomotion Control of a Dactylopteridae ...
Advertisement Space (336x280)
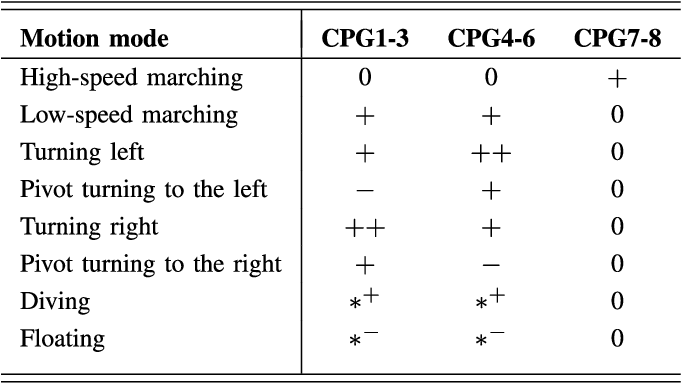
Table II from Design and Locomotion Control of a Dactylopteridae ...
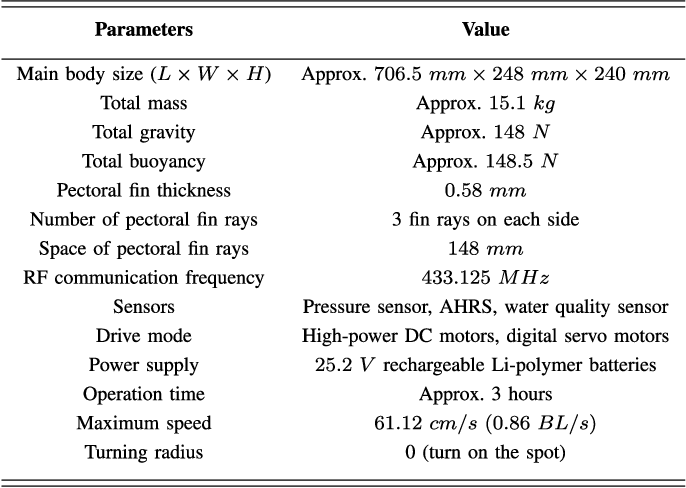
Table I from Design and Locomotion Control of a Dactylopteridae ...
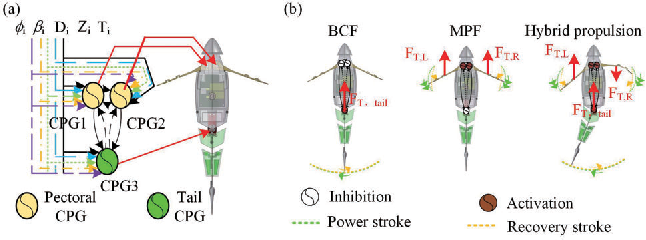
Figure 2 from Design and CPG-Based Locomotion Control of a Multi ...
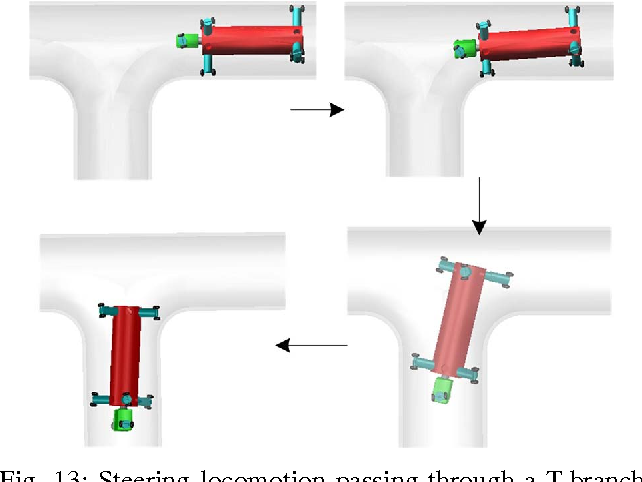
Figure 13 from Design and locomotion control strategy for a steerable ...
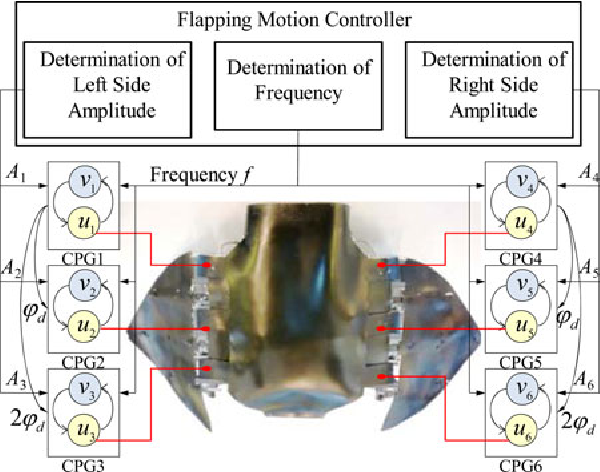
Figure 18 from Design and Locomotion Control of a Biomimetic Underwater ...
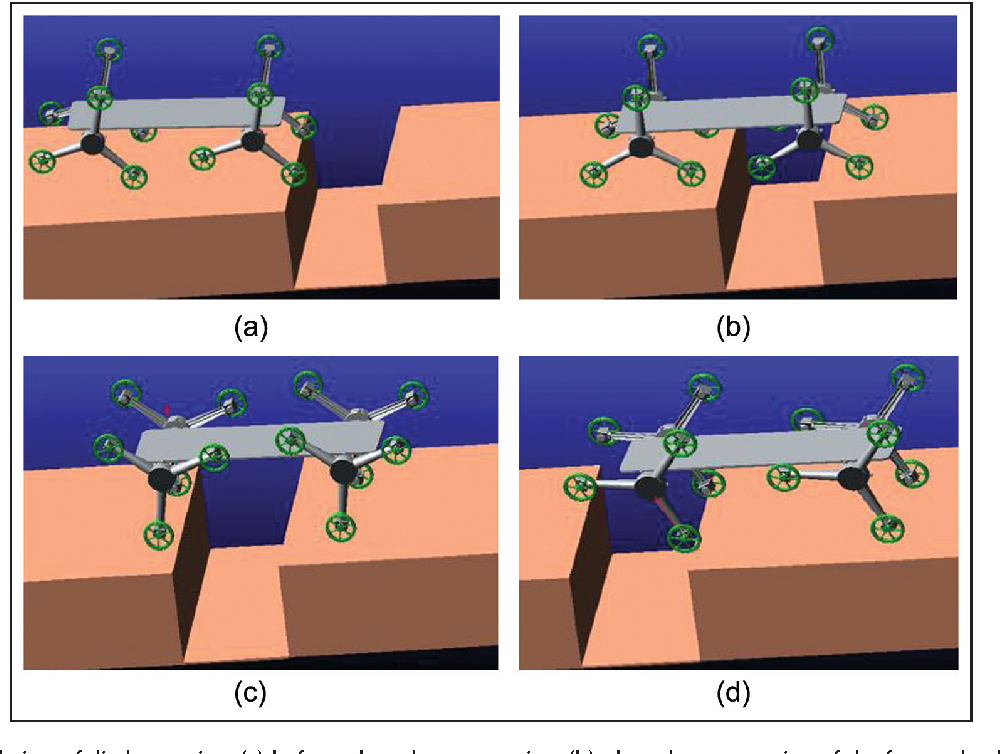
Figure 1 from Design and analysis of a wheel-legged hybrid locomotion ...
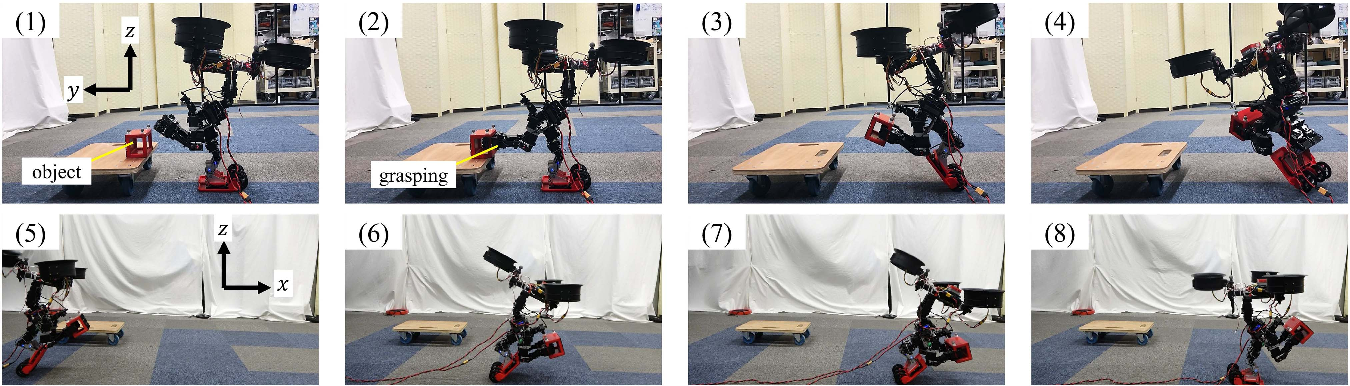
Figure 14 from Design and Control of a Small Humanoid Equipped With ...
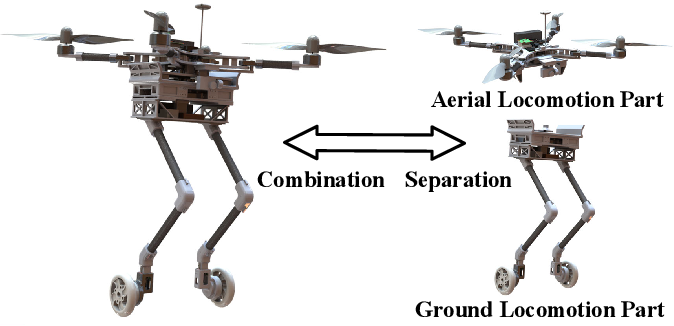
Figure 1 from Design and Control of SeparaTrek: A Hybrid Aerial-Ground ...
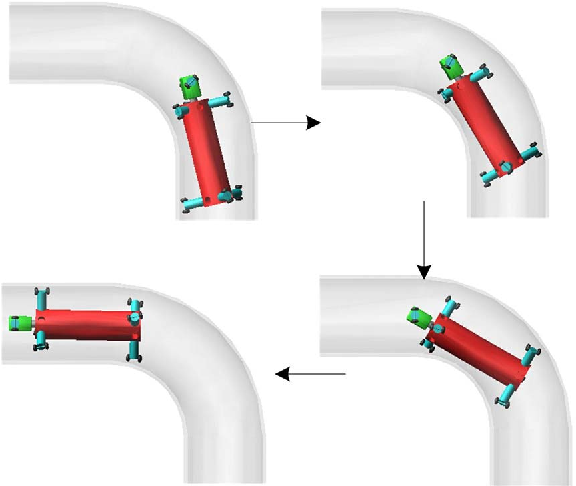
Figure 11 from Design and locomotion control strategy for a steerable ...
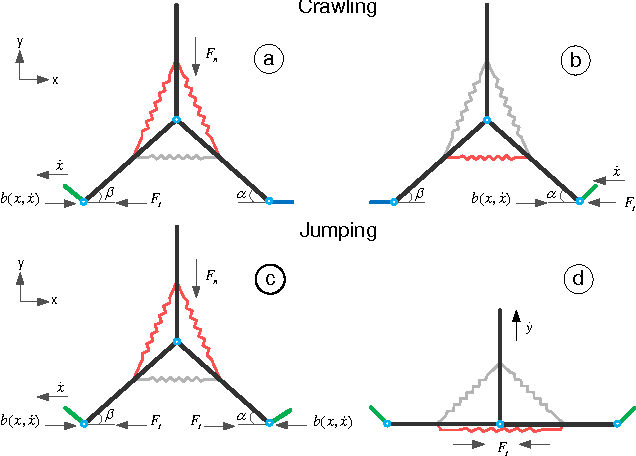
Figure 3 from The design and control of the multi-modal locomotion ...
Advertisement Space (336x280)
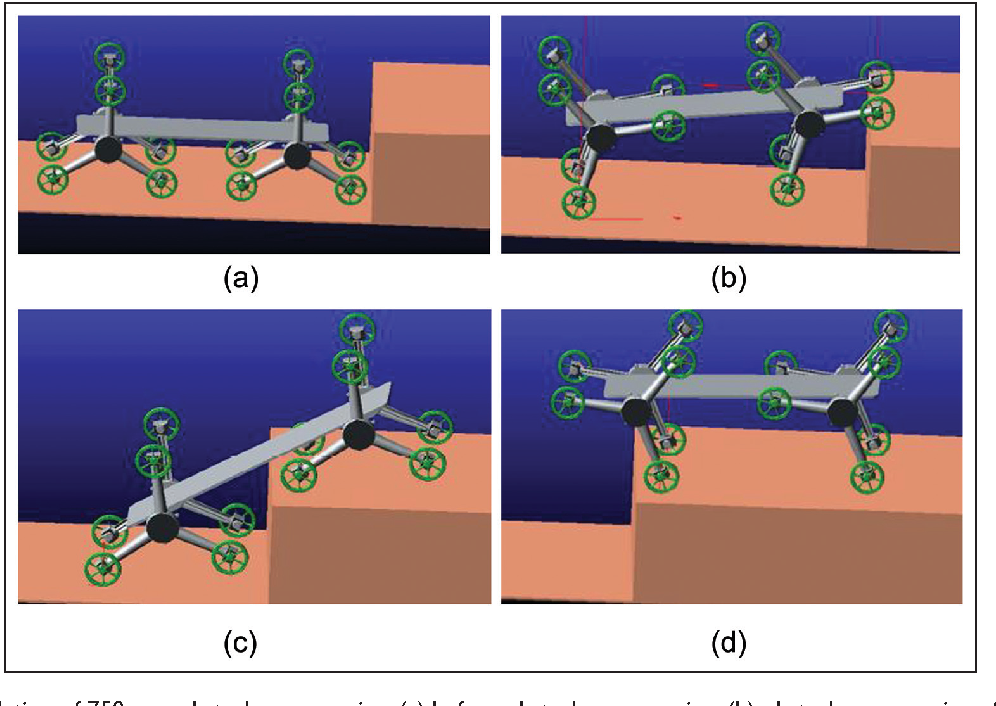
Figure 1 from Design and analysis of a wheel-legged hybrid locomotion ...

Figure 1 from Design and Control of Microscale Dual Locomotion Mode ...

Figure 13 from Locomotion Control of Quadrupedal Robot With Passive ...

Figure 1 from Design of a Large-scale Electrically-actuated Quadruped ...
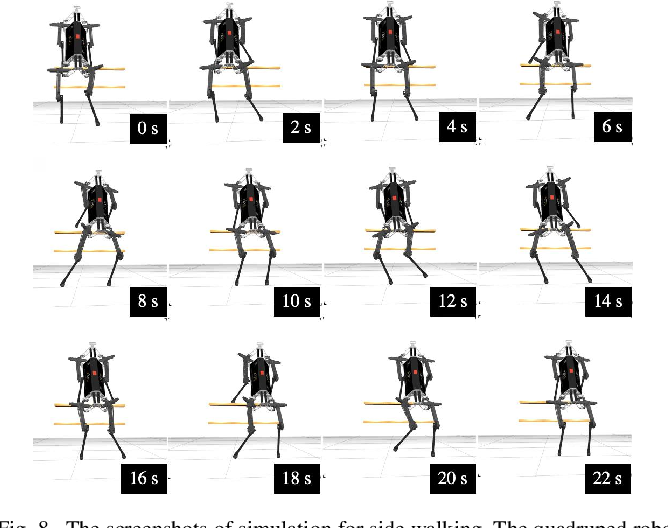
Figure 1 from Design of a Large-scale Electrically-actuated Quadruped ...

Design and Control of a Humanoid Equipped with Flight Unit and Wheels ...