
Figure 2 From Adaptive Gait Planning With Dynamic Movement Primitives
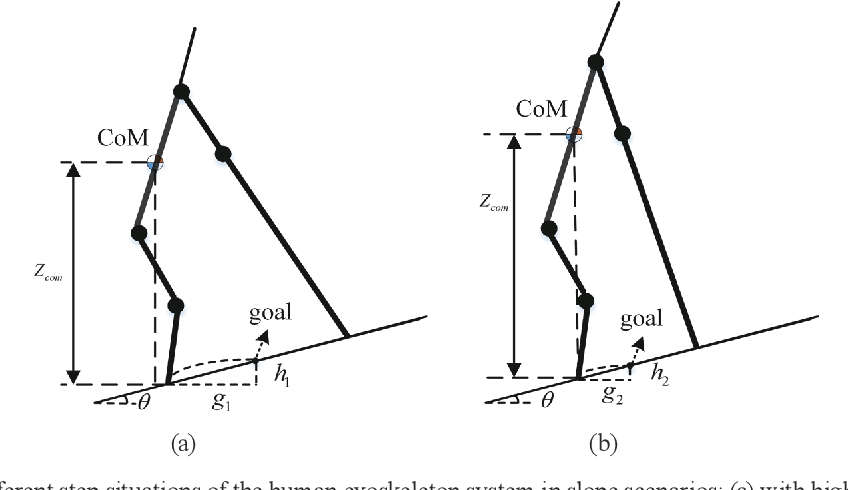
Figure 2 from Adaptive Gait Planning with Dynamic Movement Primitives ...
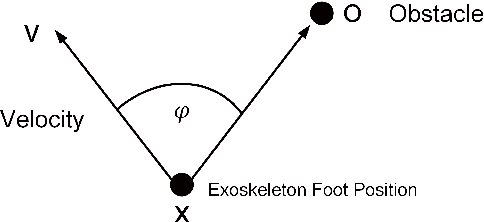
Figure 2 from Gait Planning with Dynamic Movement Primitives for Lower ...
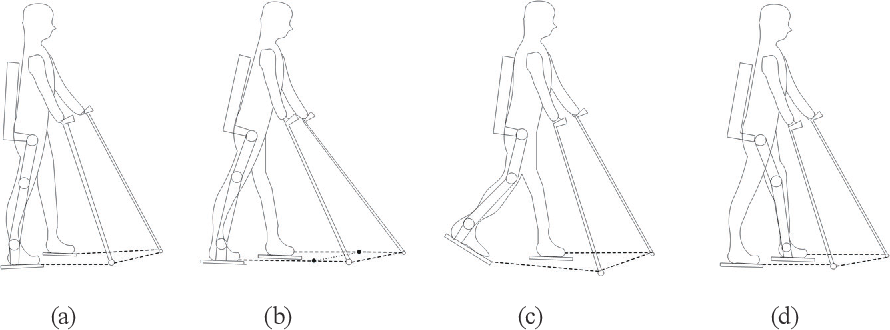
Figure 1 from Adaptive Gait Planning with Dynamic Movement Primitives ...

Figure 5 from Adaptive Gait Planning with Dynamic Movement Primitives ...
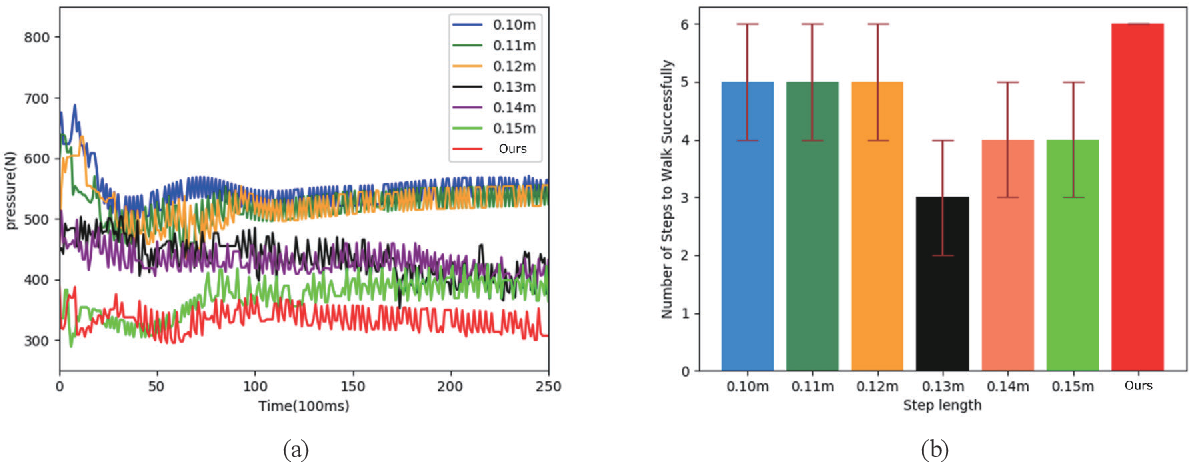
Figure 7 from Adaptive Gait Planning with Dynamic Movement Primitives ...

Figure 1 from Gait Planning with Dynamic Movement Primitives for Lower ...
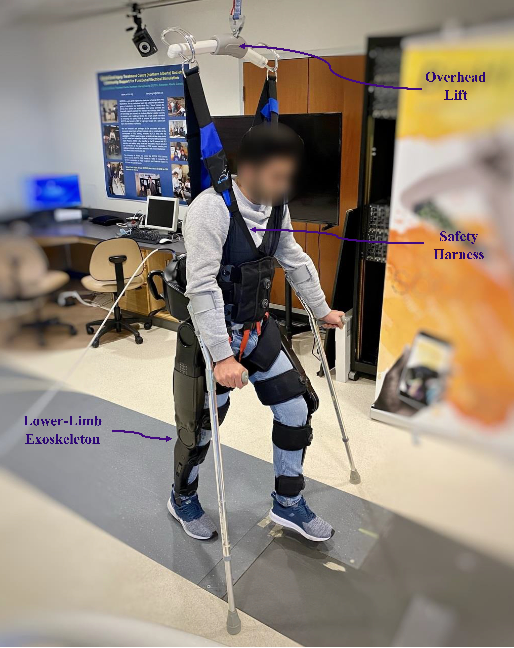
Figure 2 from Adaptive CPG-Based Gait Planning With Learning-Based ...
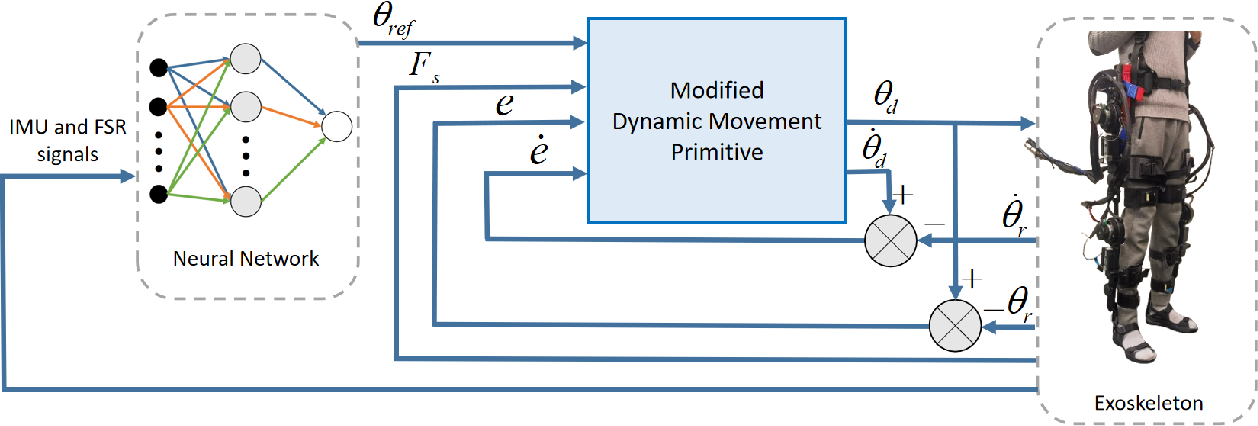
Figure 3 from Adaptive Gait Generation Using Dynamic Movement ...
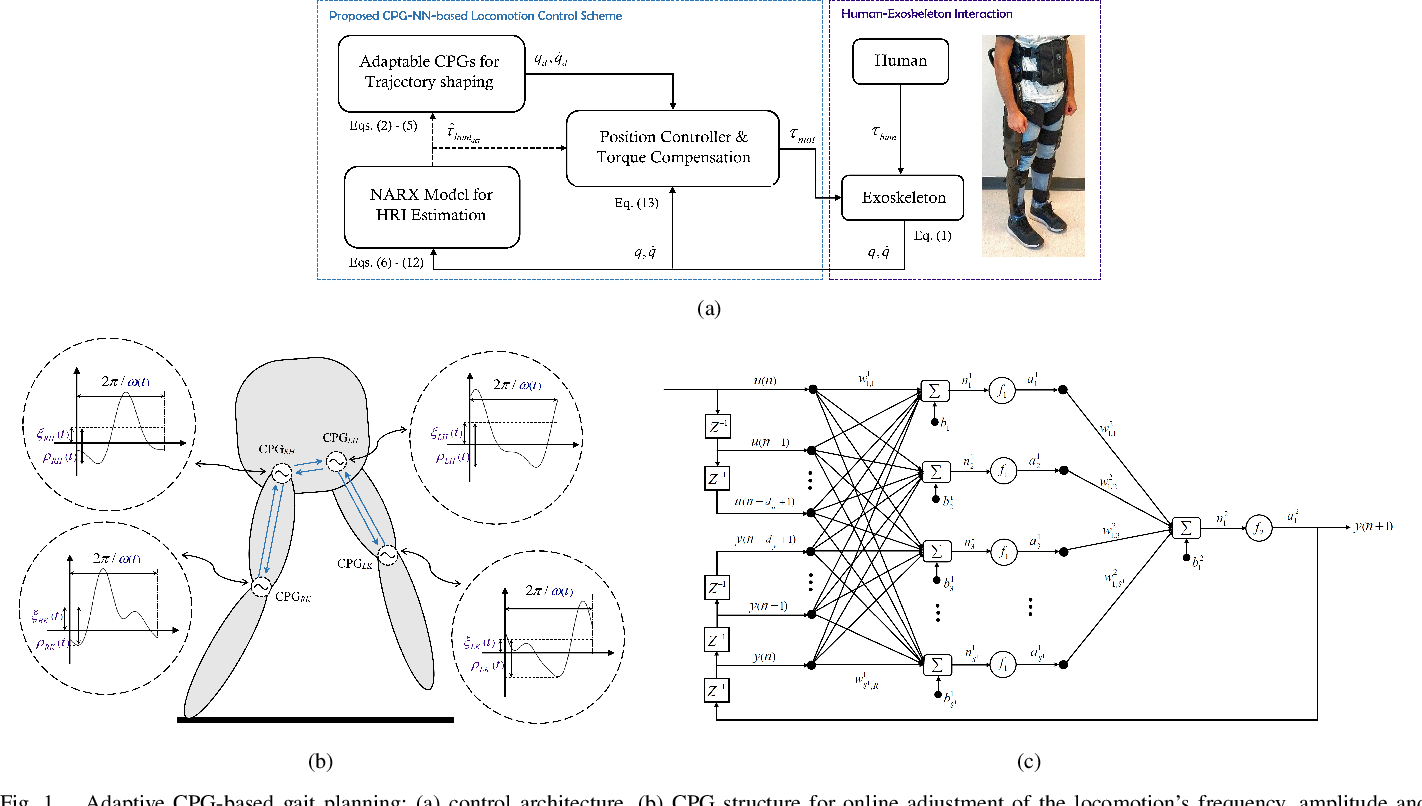
Figure 1 from Adaptive CPG-Based Gait Planning With Learning-Based ...

Figure 1 from Dynamic Movement Primitives for moving goals with ...
Advertisement Space (300x250)

Figure 12 from Slope Gradient Adaptive Gait Planning for Walking ...

Trajectory planning with dynamic movement primitives (DMP). The robot ...
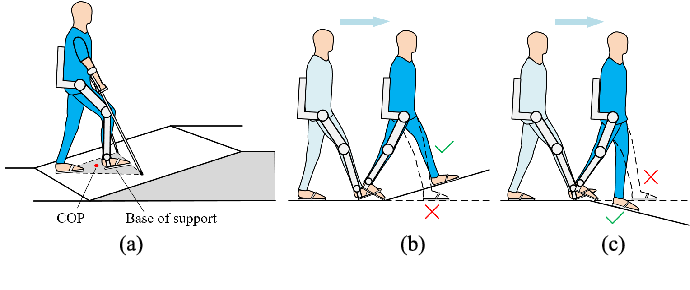
Figure 1 from Slope Gradient Adaptive Gait Planning for Walking ...
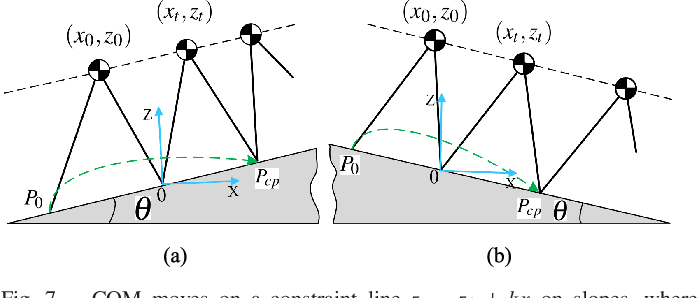
Figure 7 from Slope Gradient Adaptive Gait Planning for Walking ...
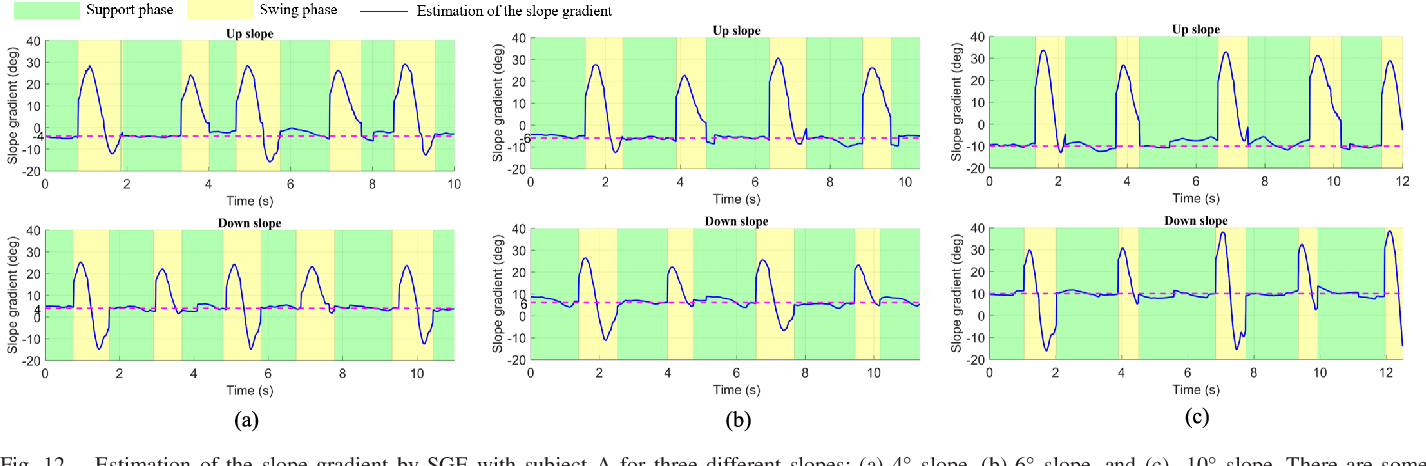
Figure 12 from Slope Gradient Adaptive Gait Planning for Walking ...

Figure 2 from An Adaptive Oscillator-Driven Gait Phase Model for ...

Figure 2 from Adaptive Algorithm for Gait Segmentation Using a Single ...
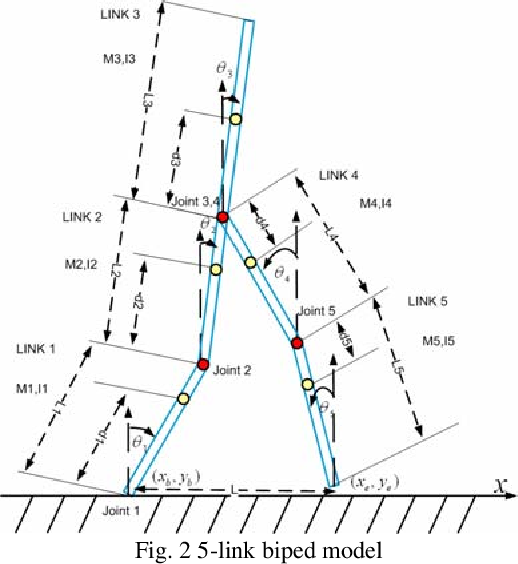
Figure 2 from Adaptive Gait Pattern Generation of Biped Robot based on ...

Figure 2 from Detecting Human Gait Phases and Conditions with Deep ...
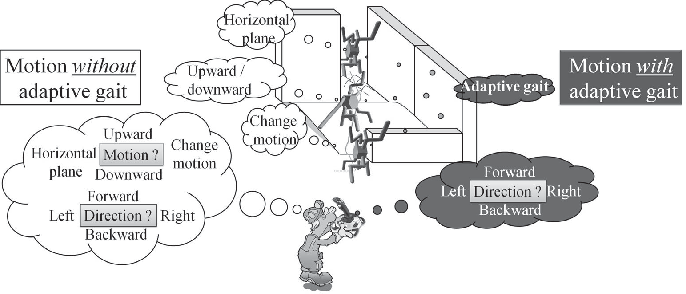
Figure 1 from Adaptive gait for dynamic rotational walking motion by ...
Advertisement Space (336x280)
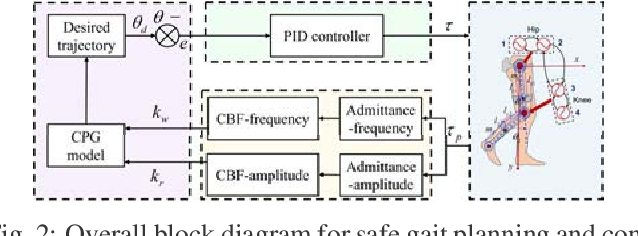
Figure 2 from CBF-Based Constrained Optimization for Safe and Adaptive ...

Figure 5 from Dynamic Principles of Gait and Their Clinical ...
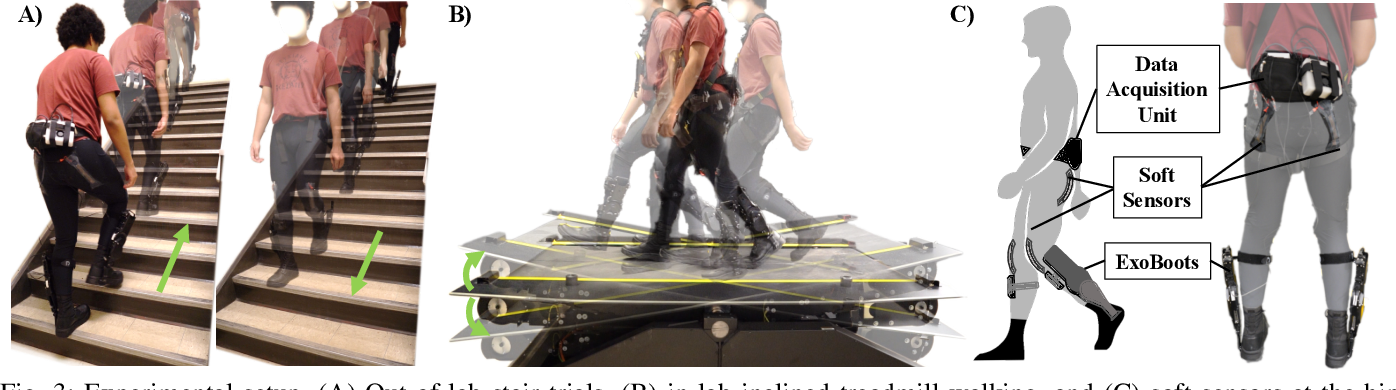
Figure 3 from Model-Agnostic Meta-Learning for Adaptive Gait Phase and ...

Figure 1 from A Modified Dynamic Movement Primitive Algorithm for ...
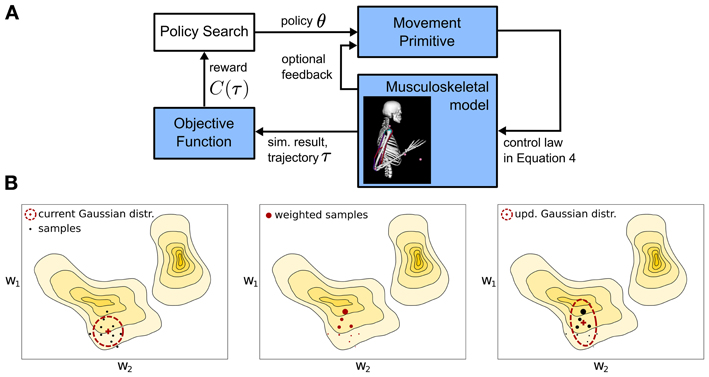
Frontiers | Learned parametrized dynamic movement primitives with ...
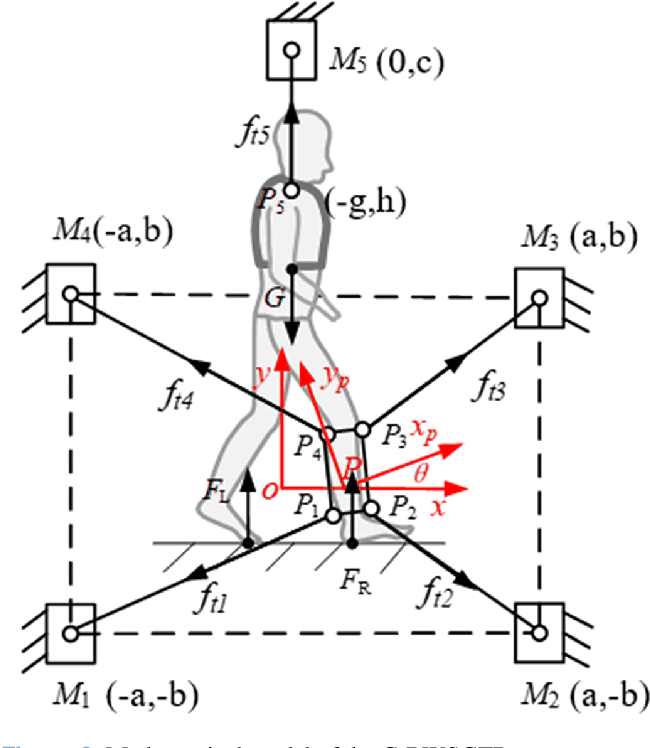
Figure 2 from Motion planning and control strategy of a cable-driven ...

(PDF) Asymptotically Stable Gait Primitives for Planning Dynamic ...
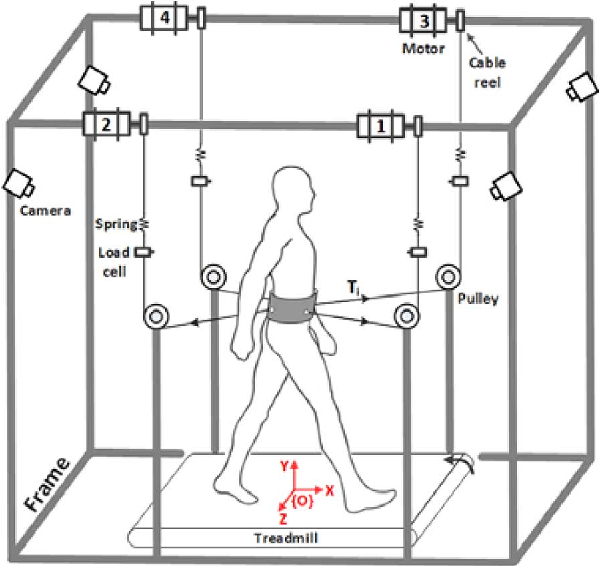
Figure 1 from Direction-Dependent Adaptation of Dynamic Gait Stability ...

Figure 1-1 from Dynamic walking models to understand asymmetric gait ...
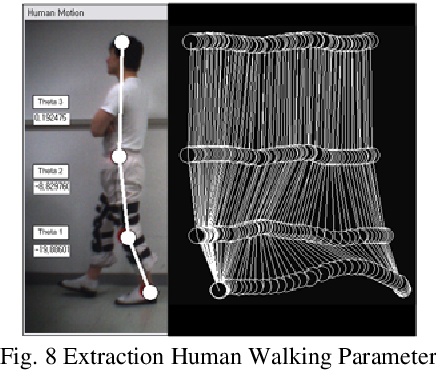
Figure 8 from Adaptive Gait Pattern Generation of Biped Robot based on ...
Advertisement Space (336x280)

Figure 2 from Gait event-based human-robot synchrony for gait ...

Figure 1 from Vision-Based Dexterous Motion Planning by Dynamic ...

Figure 1 from Unsupervised Gait Phase Estimation With Domain ...
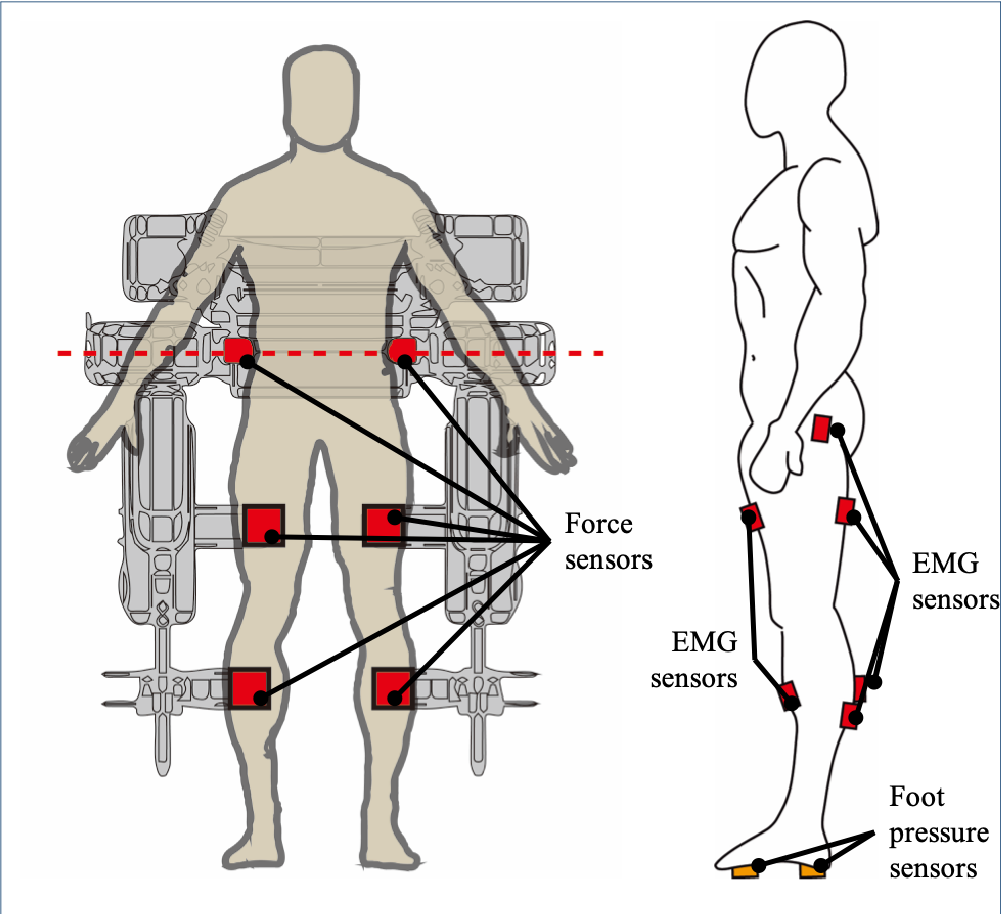
Figure 2 from The effect of pelvic movements of a gait training system ...
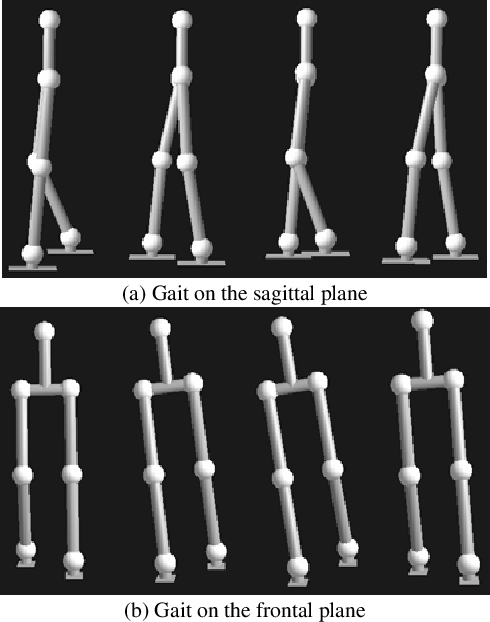
Figure 14 from Adaptive Gait Pattern Generation of Biped Robot based on ...

Figure 8 from Gait Planning and Motion Control Based on Vrep Simulation ...