
Figure 2 From Design And Development Of An Active Tendon Actuation

Figure 2 from Design and Development of an Active Tendon Actuation ...
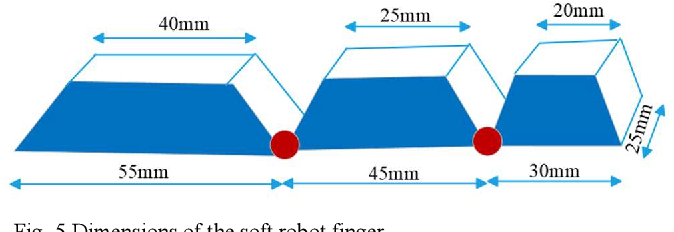
Figure 2 from Design and Development of an Active Tendon Actuation ...

Figure 2 from Design and Development of an Active Tendon Actuation ...
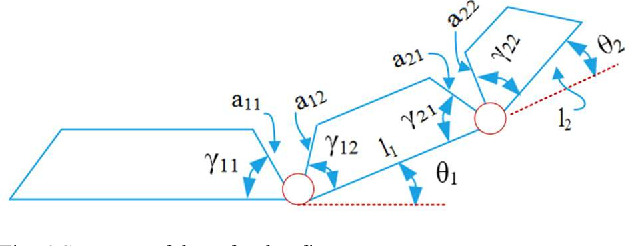
Figure 6 from Design and Development of an Active Tendon Actuation ...

Figure 4 from Design and Development of an Active Tendon Actuation ...

Figure 7 from Design and Development of an Active Tendon Actuation ...

Figure 11 from Design and Development of an Active Tendon Actuation ...

Figure 8 from Design and Development of an Active Tendon Actuation ...

(PDF) Design and Development of an Active Tendon Actuation System for a ...
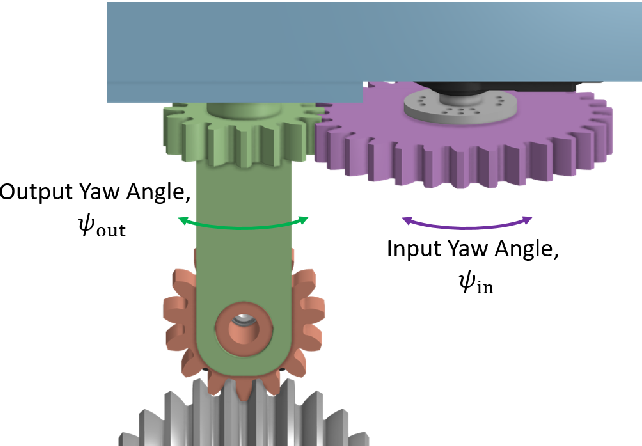
Figure 2 from Design and Development of 2-DOF Active Revolute Joint for ...
Advertisement Space (300x250)

Figure 2 from Development of a robotic finger with an active dual-mode ...

Figure 2 from Development of a robotic finger with an active dual-mode ...

Figure 1 from ACTUATION REQUIREMENTS OF AN ACTIVE TENDON CONCEPT IN ...

Figure 2 from Development of a robotic finger with an active dual-mode ...

Figure 2 from Development of a robotic finger with an active dual-mode ...
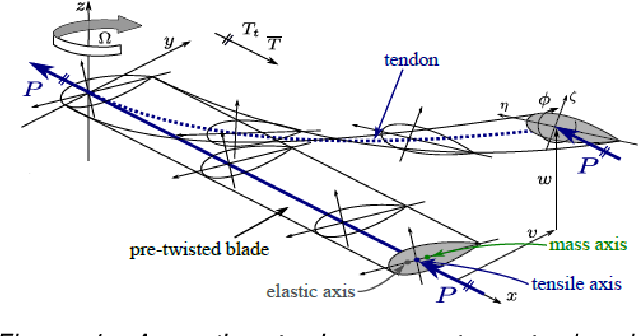
Figure 1 from ACTUATION REQUIREMENTS OF AN ACTIVE TENDON CONCEPT IN ...
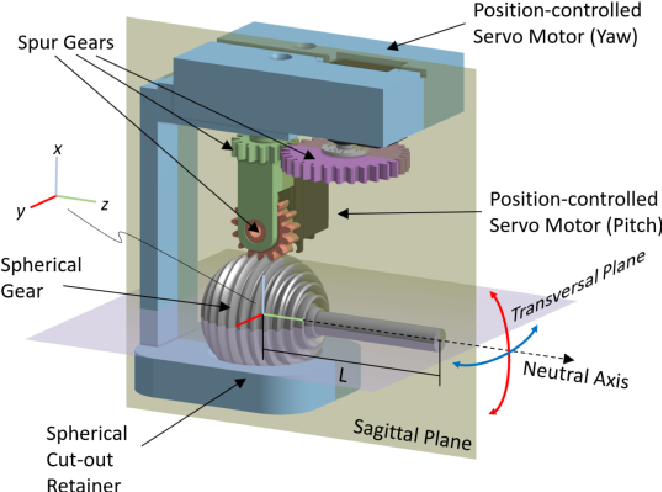
Figure 1 from Design and Development of 2-DOF Active Revolute Joint for ...

Figure 2 from Development of a robotic finger with an active dual-mode ...
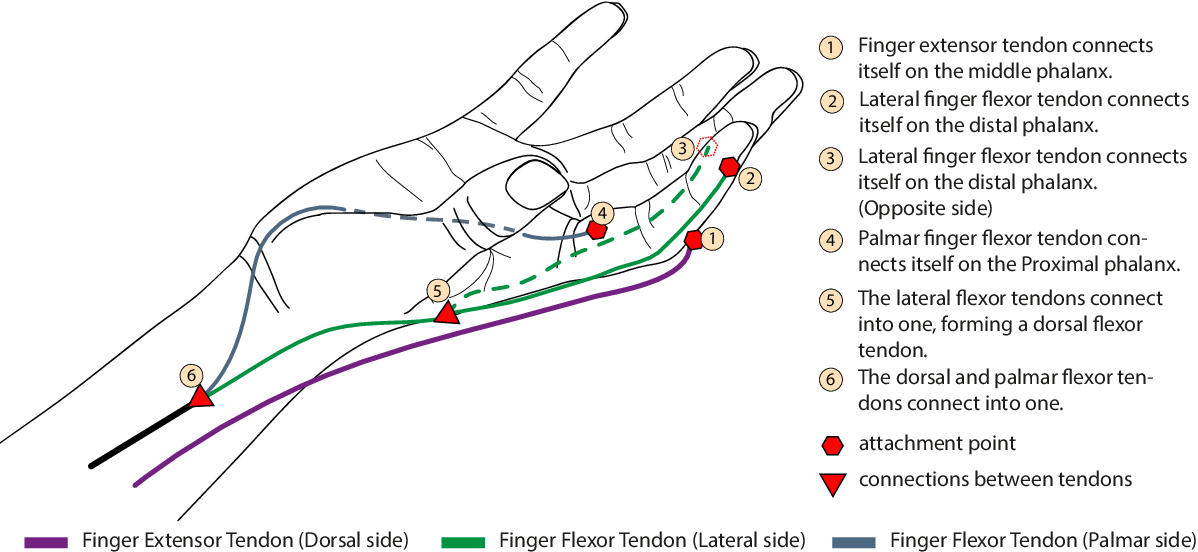
Figure 2 from A concept design of an adaptive tendon driven mechanism ...

Figure 6 from Design and Development of 2-DOF Active Revolute Joint for ...
Advertisement Space (336x280)

Figure 2 from Mechanical design of a tendon activated prosthetic hand ...
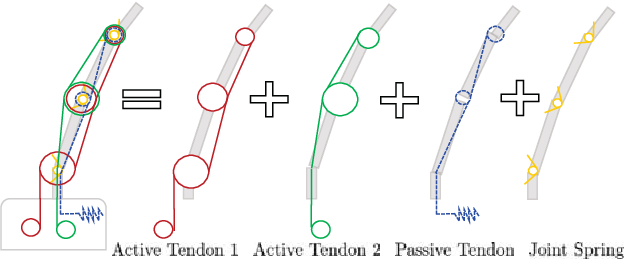
Figure 2 from Stiffness Decomposition and Design Optimization of Under ...
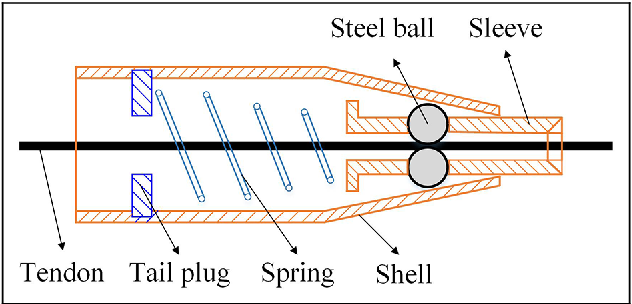
Figure 2 from Design and position-tracking control of a flexible joint ...
(PDF) Design and Development of an Active Suspension System Using ...
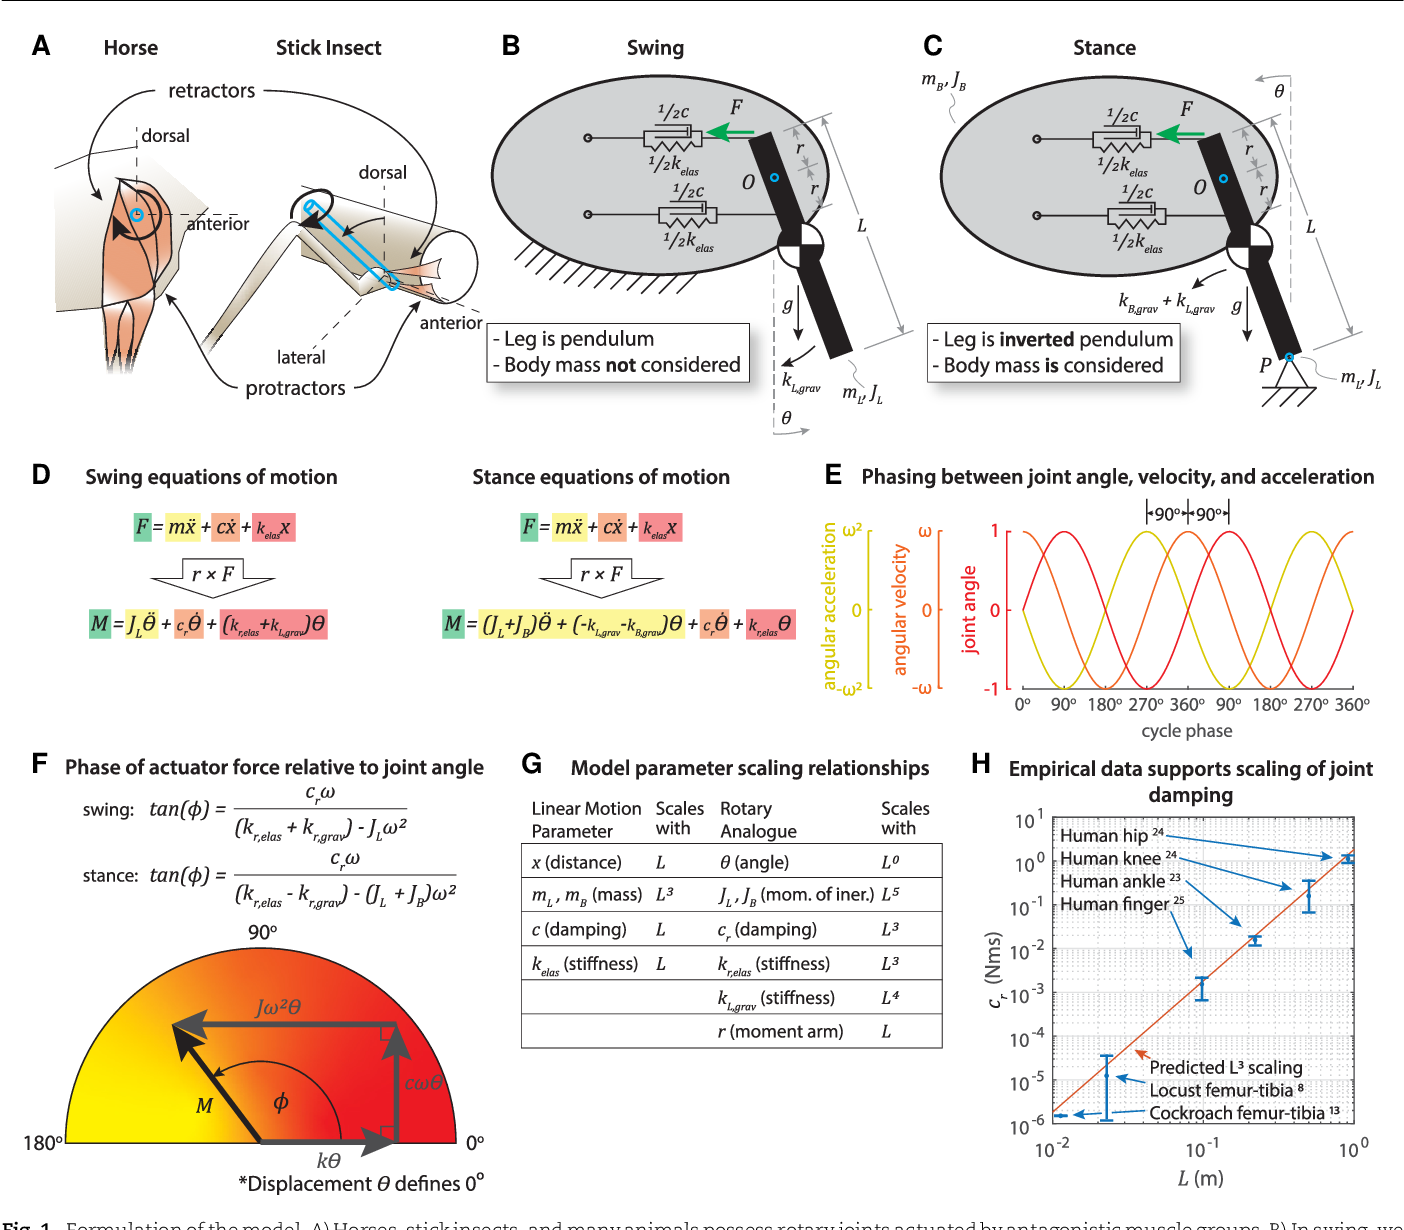
Figure 2 from Phase shift between joint rotation and actuation reflects ...

Figure 2 from Development of a polymer-based tendon-driven wearable ...

Figure 4 from Design of a back-driveable actuation system for modular ...

Figure 2 from Hybrid Soft Pneumatic and Tendon Actuated Finger With ...

Figure 3 from Design of a back-driveable actuation system for modular ...

Figure 2 from Development of Fully Tendon-Driven Lightweight ...
Advertisement Space (336x280)

Figure 1 from Design and Locomotion Control of a Soft Robot Using ...

Figure 2 from Design of tendon-driven mechanism with 2N configuration ...
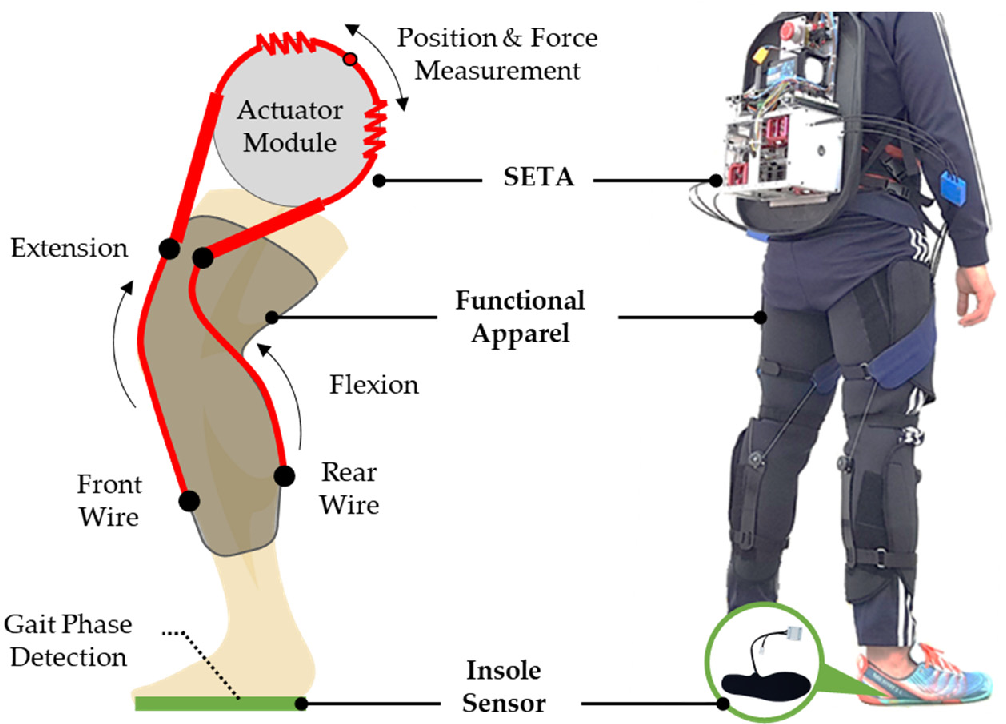
Figure 1 from Development of a Series Elastic Tendon Actuator (SETA ...

Tendon actuation schematic of the hand exoskeleton.(a) Palmar and (b ...

Figure 2 from Bow spring/tendon actuation for low cost haptic ...

Elastic tendon actuation model of joint 3 and 4. The tendons, pulleys ...