
Figure 2 From Evobot Design And Learning Based Control Of A Two

Figure 2 from evoBOT – Design and Learning-Based Control of a Two ...

Figure 1 from evoBOT – Design and Learning-Based Control of a Two ...

Figure 3 from evoBOT – Design and Learning-Based Control of a Two ...

Figure 4 from evoBOT – Design and Learning-Based Control of a Two ...
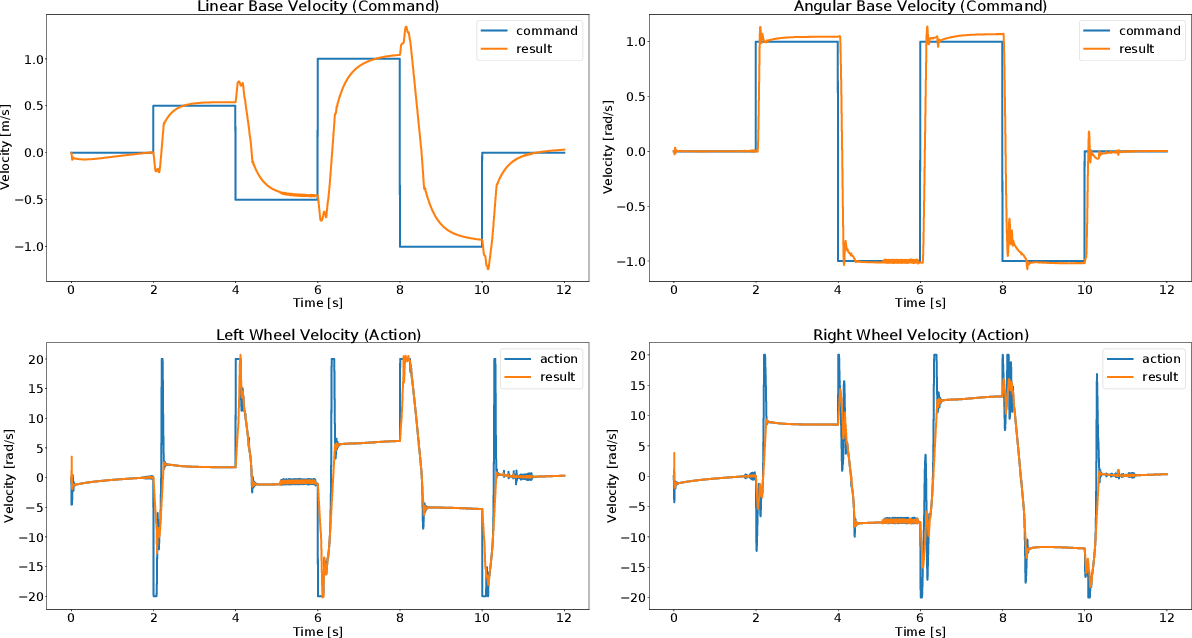
Figure 5 from evoBOT – Design and Learning-Based Control of a Two ...
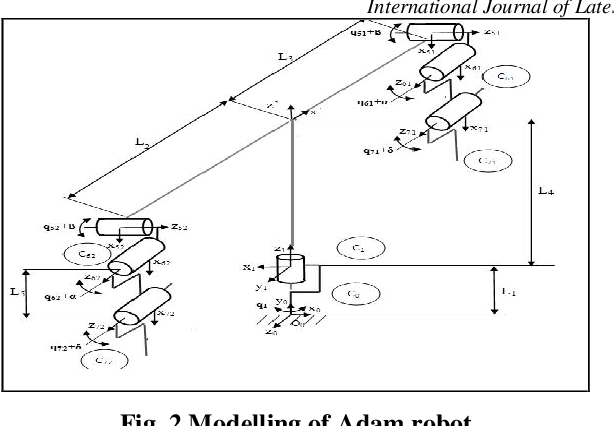
Figure 2 from DESIGN AND CONTROL OF A DUAL-ARM ROBOT | Semantic Scholar
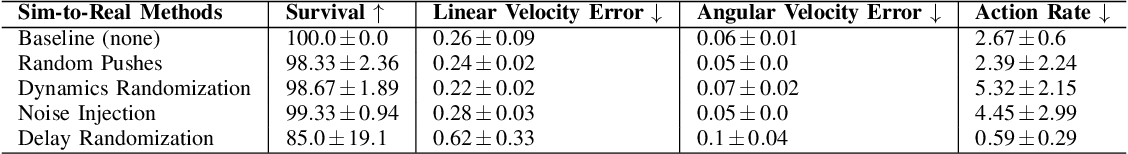
Table III from evoBOT – Design and Learning-Based Control of a Two ...

Figure 1 from Design and Control of a Two-wheeled Self-balancing Robot ...

Figure 1 from Modeling and Control of a Two Wheeled Self-Balancing ...

Figure 2 from Vision-Based Line-Following Control of a Two-Wheel Self ...
Advertisement Space (300x250)

Design and Control of a Wheeled Bipedal Robot Based on Hybrid Linear ...
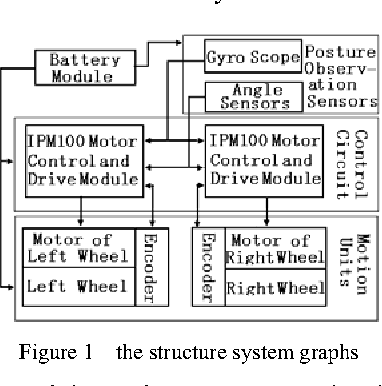
Figure 1 from The control and design of Dual - wheel upright self ...

Figure 1 from Design and Control of Two-Wheeled and Self-Balancing ...

Design and Control of a Bipedal Robotic Character

Figure 1 from Motion controller design for two-wheeled robot based on a ...
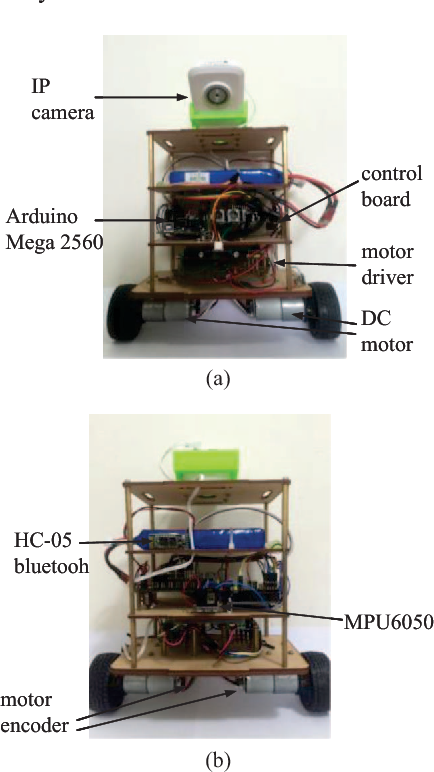
Figure 1 from Vision-Based Line-Following Control of a Two-Wheel Self ...
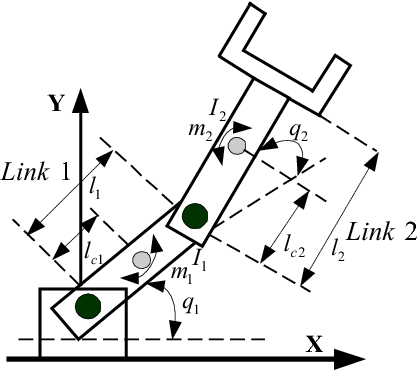
Figure 1 from Real-Time Learning Controller Design for a Two-Link ...
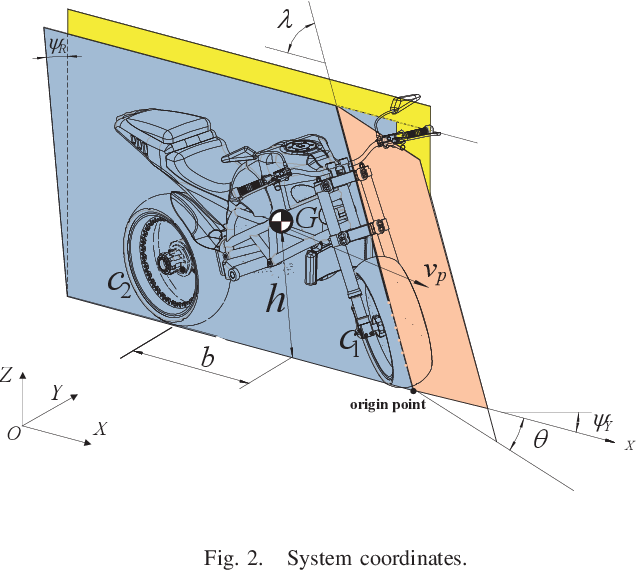
Figure 2 from High maneuverability control of Single-track Two-wheeled ...
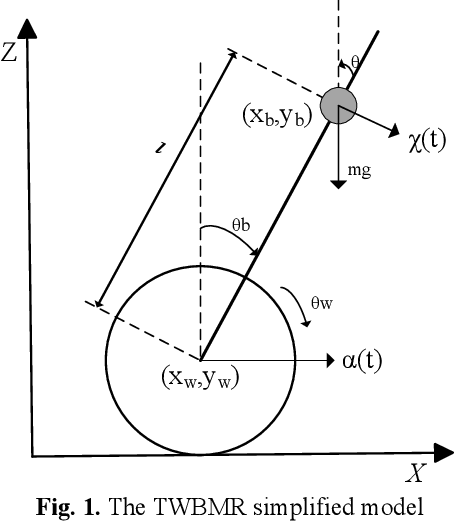
Figure 1 from Design and implementation of two-wheeled self-balancing ...
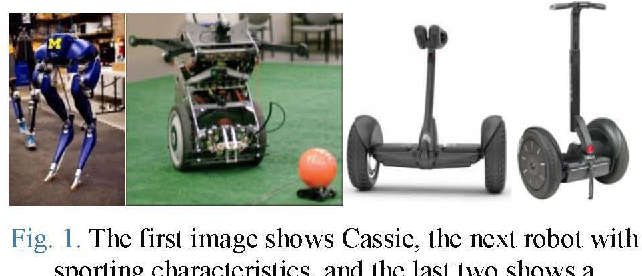
Figure 1 from Modelling and Design a Self-Balancing Dual-Wheeled Robot ...
Advertisement Space (336x280)
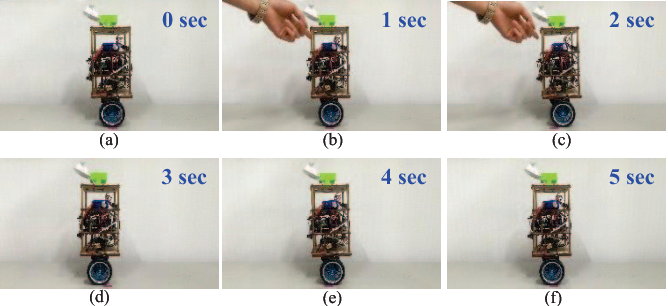
Figure 5 from Vision-Based Line-Following Control of a Two-Wheel Self ...
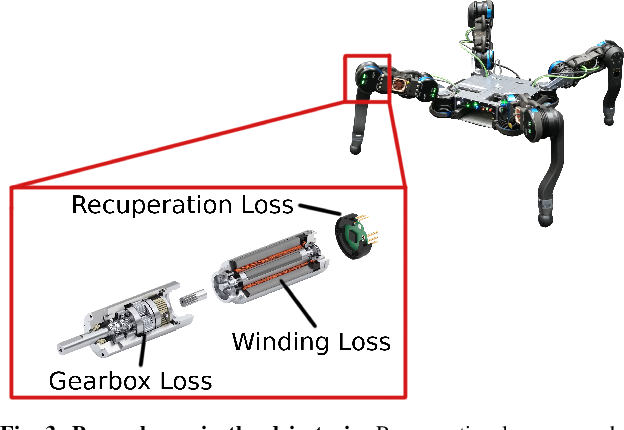
Figure 3 from Efficient Learning-Based Control of a Legged Robot in ...

Figure 1 from Design and Experimental Validation of Deep Reinforcement ...

(PDF) Modeling and Control of a Two Wheeled Self-Balancing Robot: a ...

Figure 2 from Learning-Based Control of Autonomous Vehicles Using an ...

Figure 1 from Mobile Robot Control Based on 2D Visual Servoing: A New ...

Figure 6 from Design, Modeling and Control of Fully Actuated 2D ...

Figure 1 from Implementation of a Two Wheel Self-Balanced Robot using ...
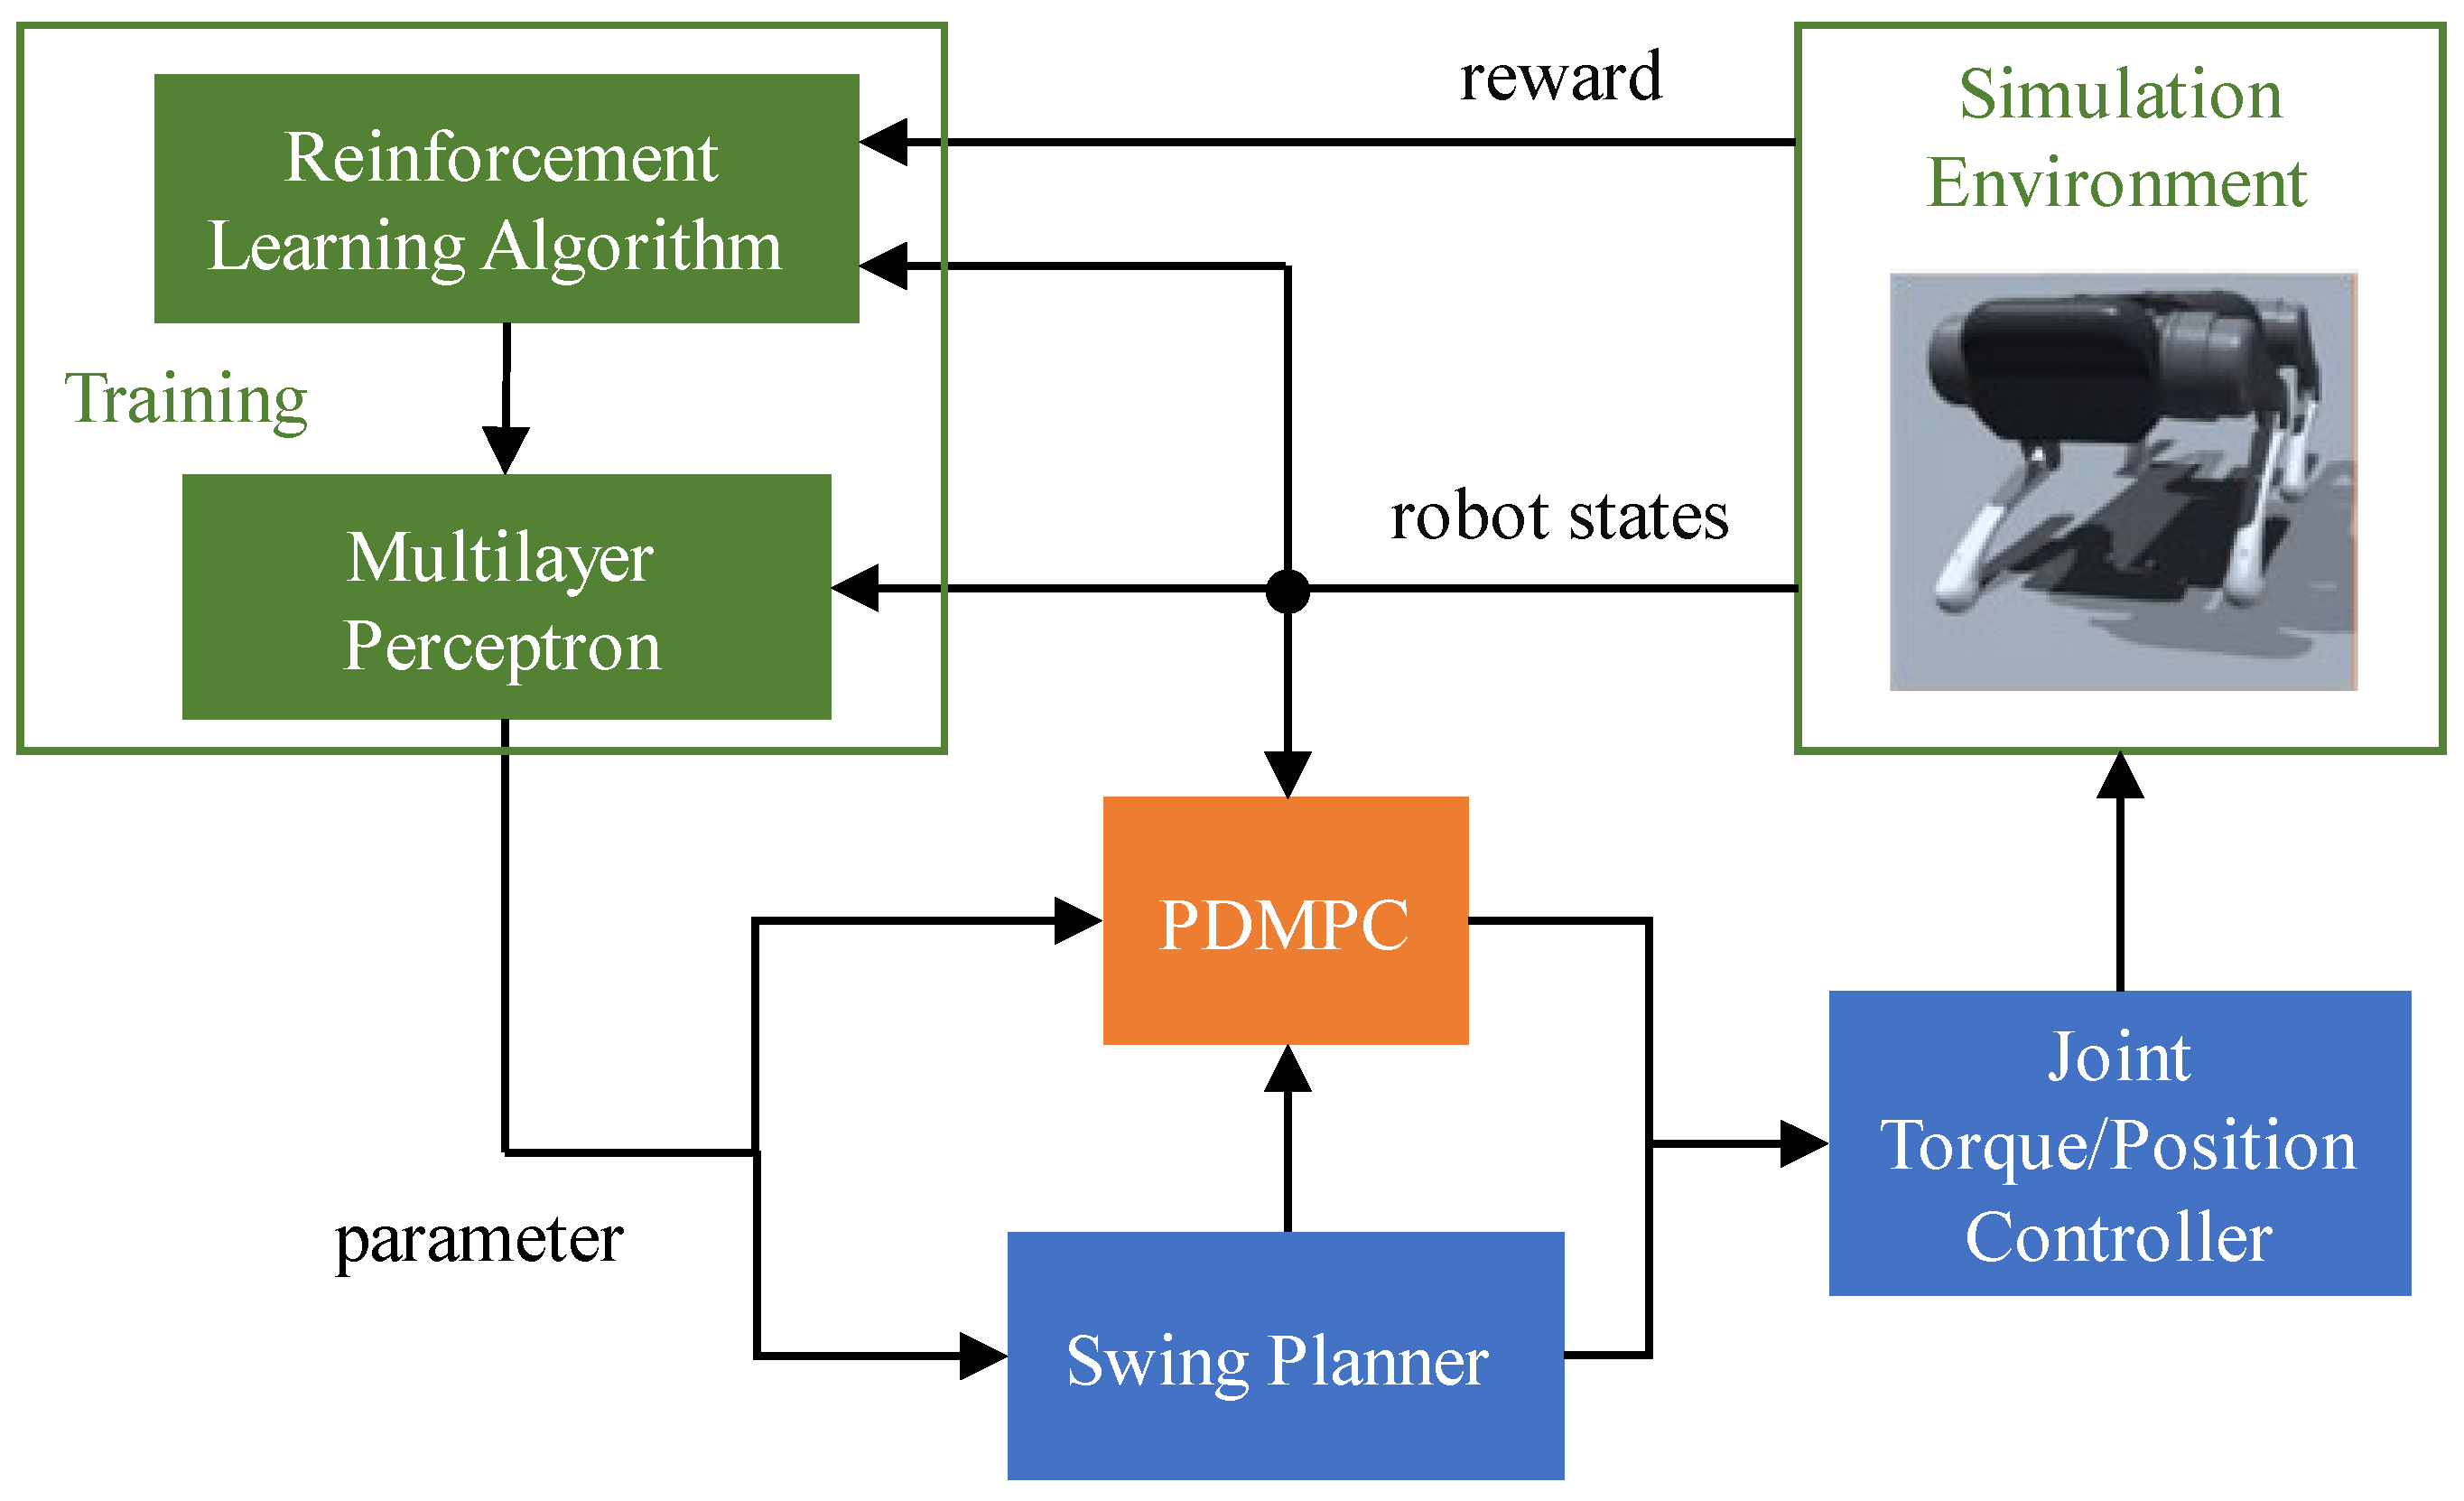
Model Predictive Control of Quadruped Robot Based on Reinforcement Learning

A Survey on Design, Actuation, Modeling, and Control of Continuum Robot ...
Advertisement Space (336x280)

Ask1: Development and Reinforcement Learning-Based Control of a Custom ...

Design and Control of Two-Wheeled Self-Balancing Robot Using Arduino ...
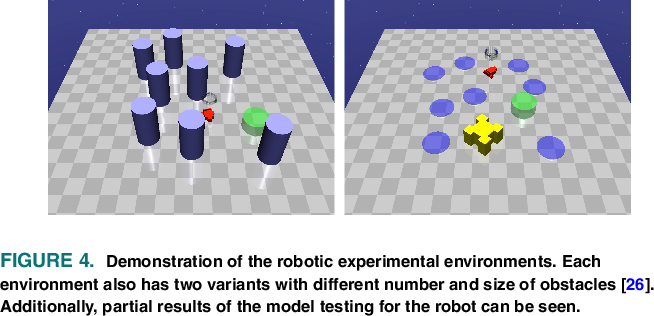
Figure 1 from Learning-Based Safe Control for Robot and Autonomous ...

Design and Implementation of a Self-Balancing Two-Wheeled Robot Driven ...
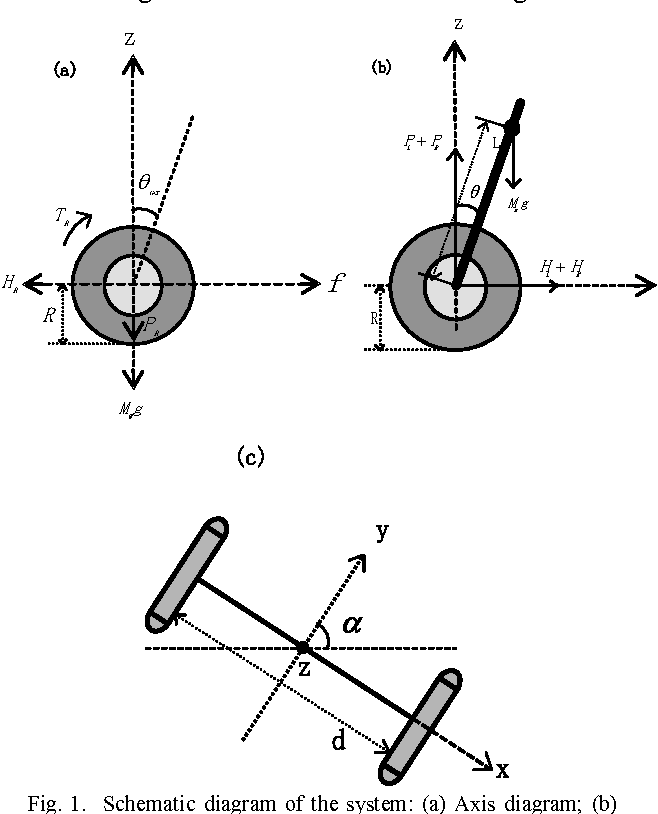
Figure 1 from Control system design for two-wheel self-balanced robot ...

(PDF) A Two-Link Robot Manipulator: Simulation and Control Design