
Figure 2 From Localization Of Auvs Using Depth Information Of
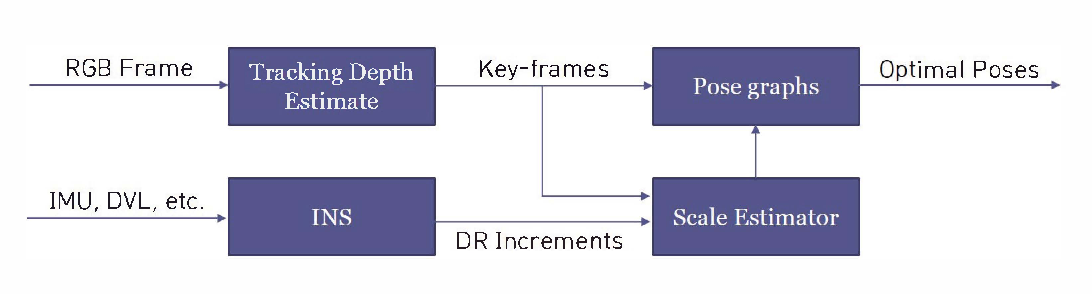
Figure 2 from Localization of AUVs using depth information of ...
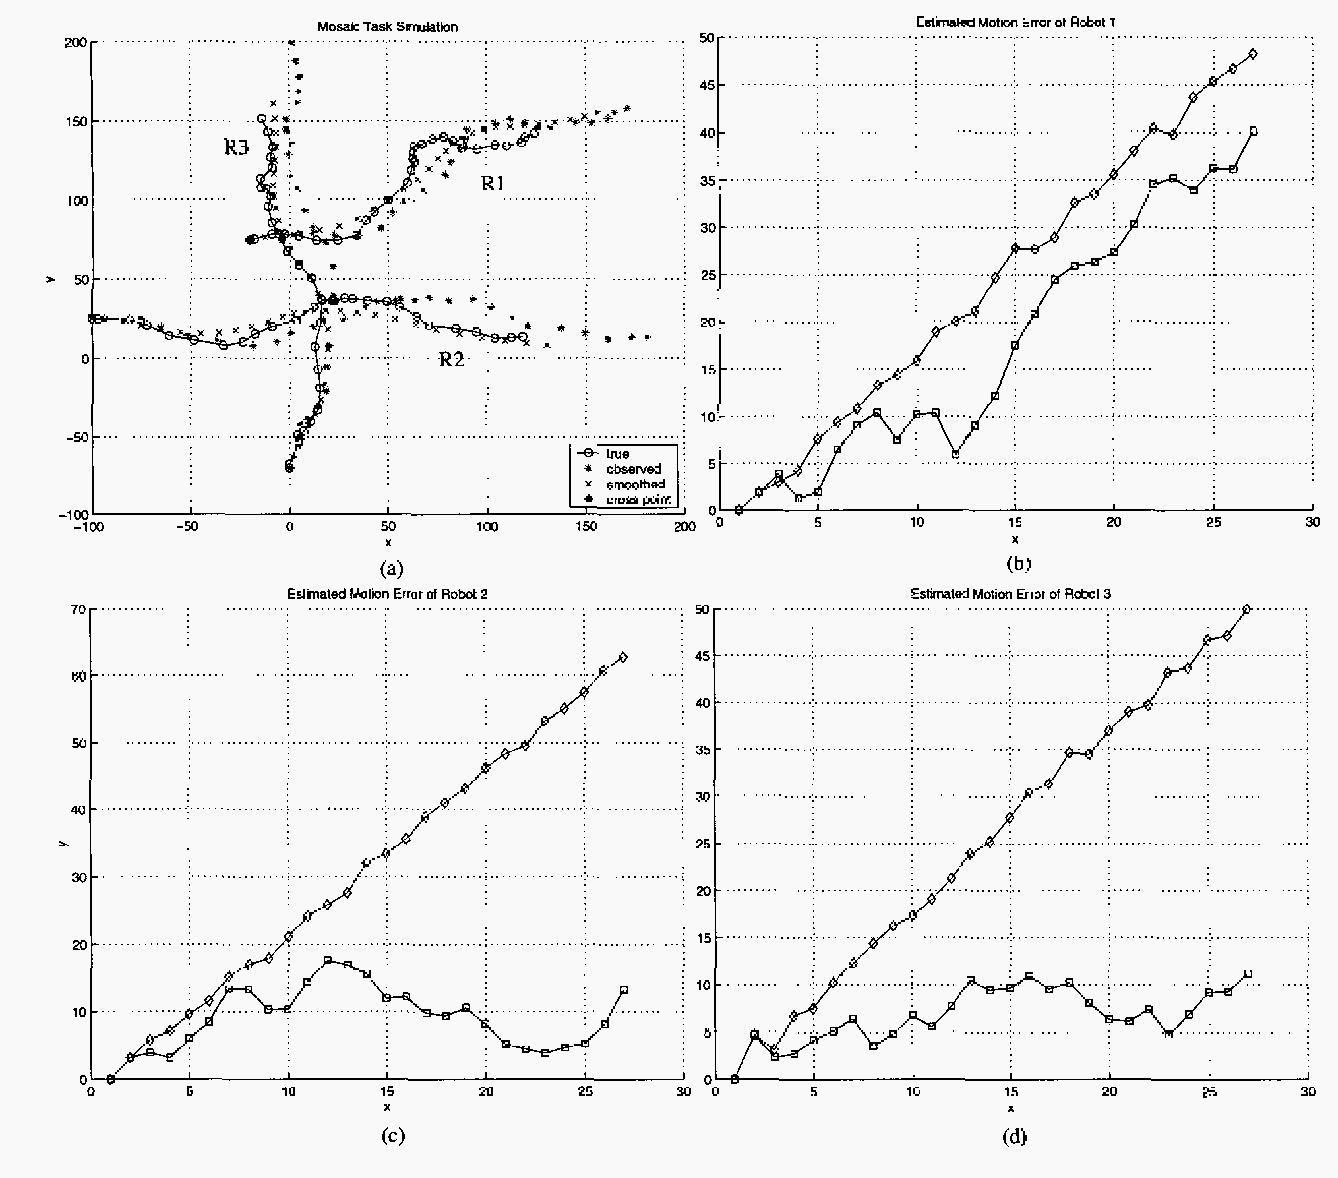
Figure 2 from Localization of a fleet of AUVs using visual maps ...
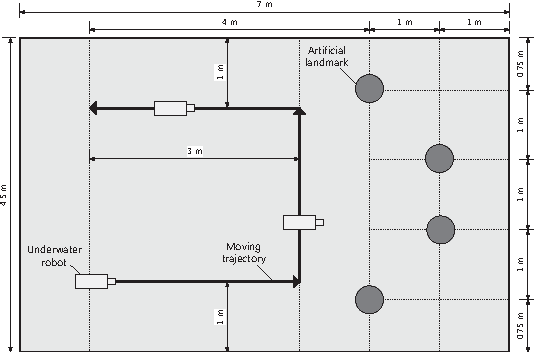
Figure 2 from Experiments on localization of an AUV using graph-based ...

Figure 2 from Underwater Navigation of AUVs Using Uncorrelated ...
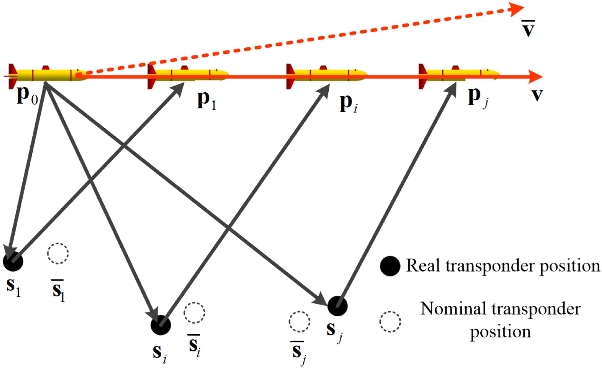
Figure 1 from Underwater Localization of AUVs in Motion Using Two-Way ...

Figure 5 from Localization of AUV Using Visual Shape Information of ...
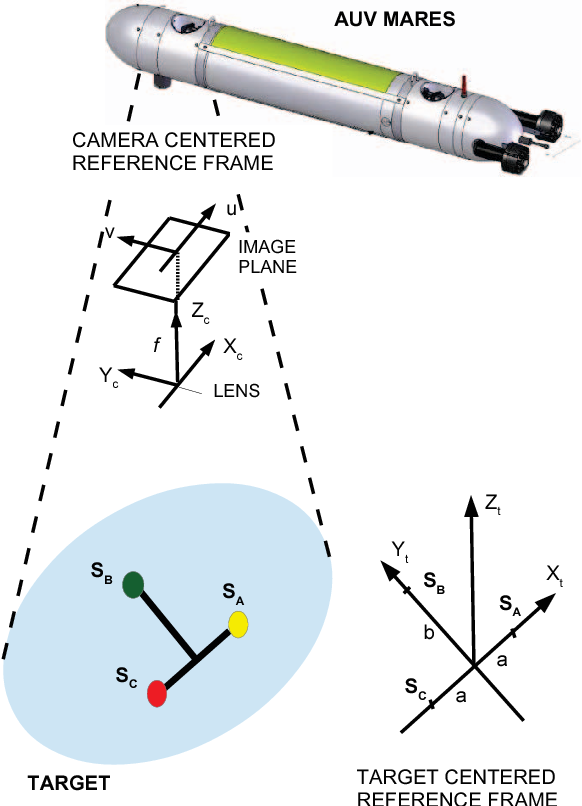
Figure 2 from Vision-based localization and positioning of an AUV ...
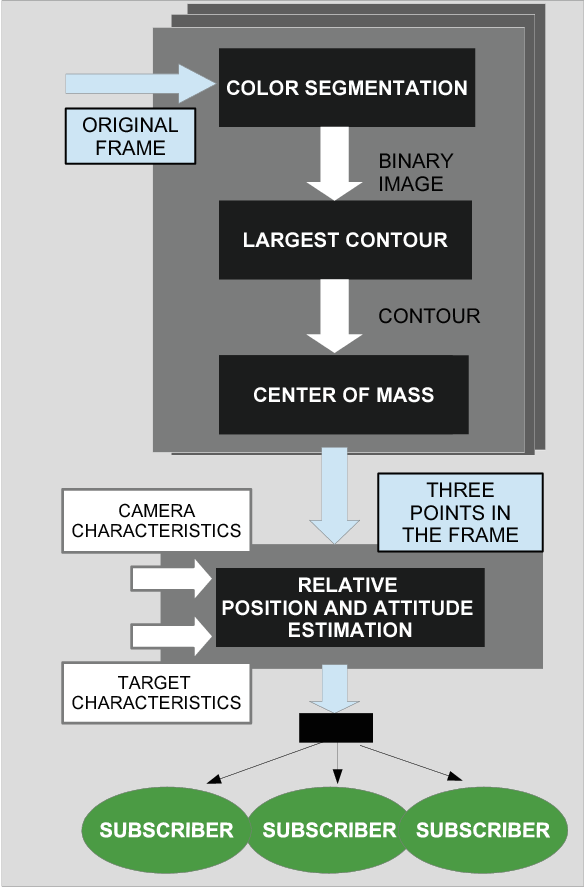
Figure 2 from Vision-based localization and positioning of an AUV ...

Figure 2 from Development and Validation of Buoyancy Based Depth ...
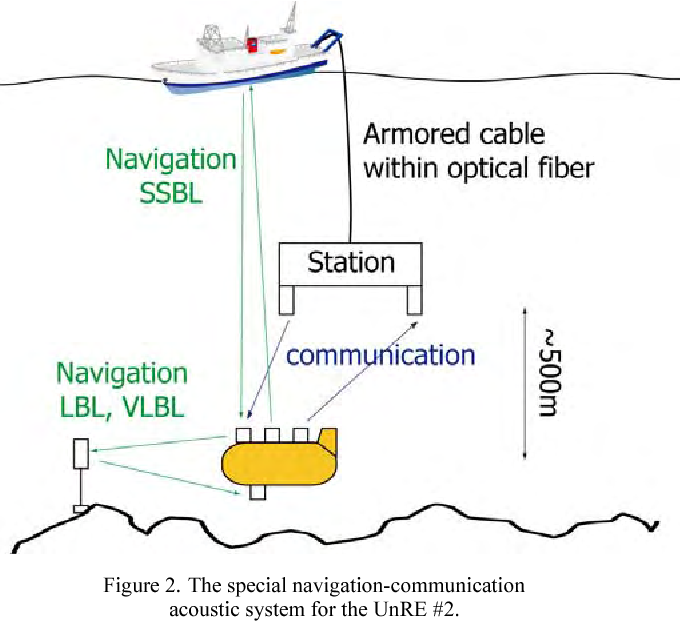
Figure 2 from Development of two-type AUVs for deep-sea carbon dioxide ...
Advertisement Space (300x250)

Localization of AUVs using visual information of underwater structures ...

Figure 2 from A Review on Optimal Placement of Sensors for Cooperative ...
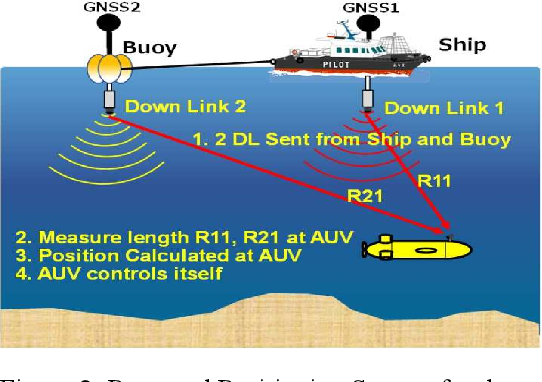
Figure 2 from Ocean experiment result of Two Reference points ...

Figure 2 from Global path planning for multiple AUVs using GWO ...

Figure 2 from Noncooperative Mobile Target Tracking Using Multiple AUVs ...
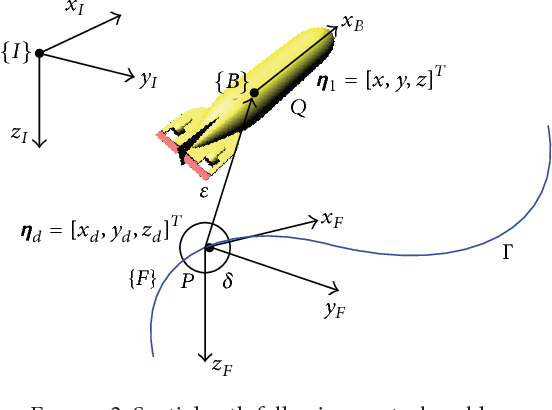
Figure 2 from Spatial Path Following for AUVs Using Adaptive Neural ...

Depth data from a single AUV run. Figure (a) shows the path of the AUV ...
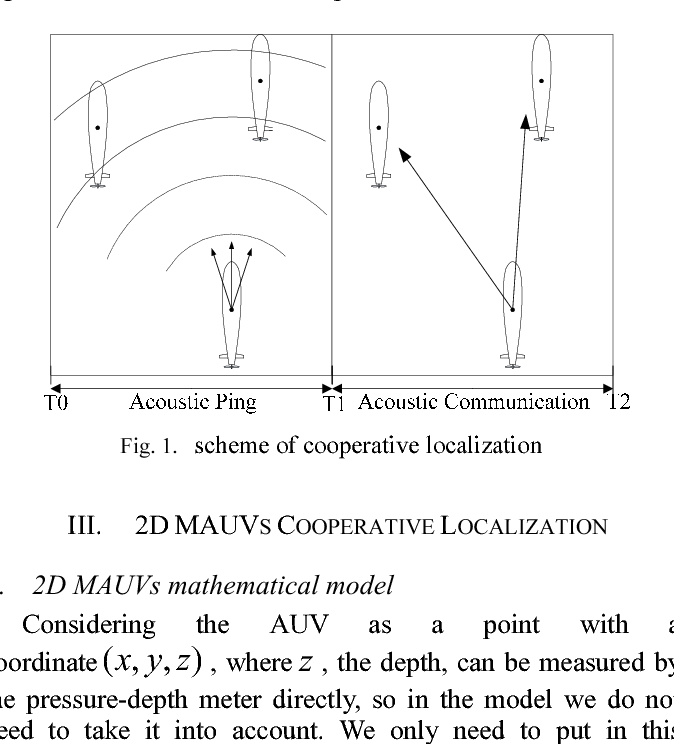
Figure 1 from Optimal formation of multiple AUVs cooperative ...

Figure 2 from Simultaneous Localization And Mapping with depth ...

Optimal Sensor Formation for 3D Cooperative Localization of AUVs Using ...
Advertisement Space (336x280)
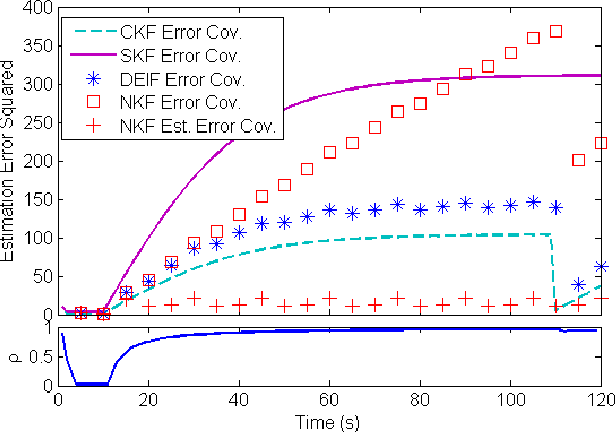
Figure 2 from Cooperative multi-AUV localization using distributed ...
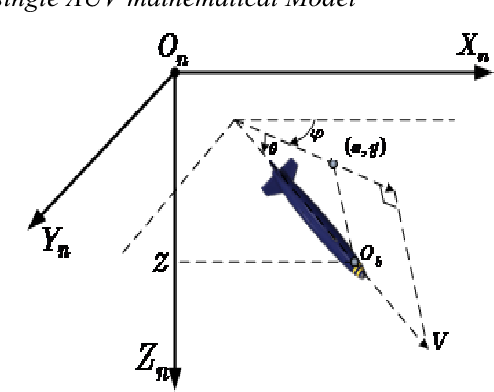
Figure 3 from Optimal formation of multiple AUVs cooperative ...

Optimal Sensor Formation for 3D Cooperative Localization of AUVs Using ...

Figure 2 from Terrain Based Localization Method for Wreck Observation ...

Figure 1 from Hybrid TOA-AOA Cooperative Localization for Multiple AUVs ...
Architecture of multiple AUVs cooperative localization based on two ...
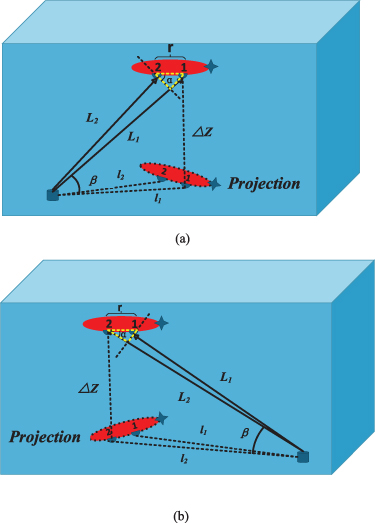
A method for real-time localization of AUV using acoustic ray ...
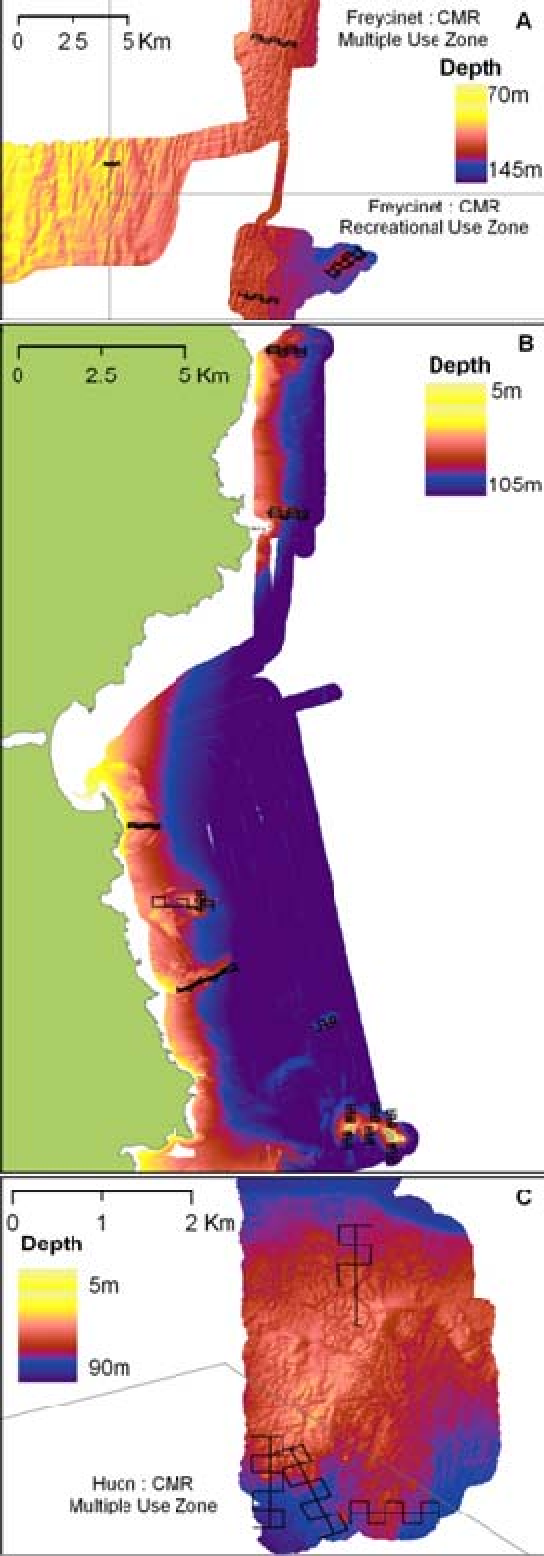
Figure 2 from Autonomous Underwater Vehicle (AUV) for mapping marine ...
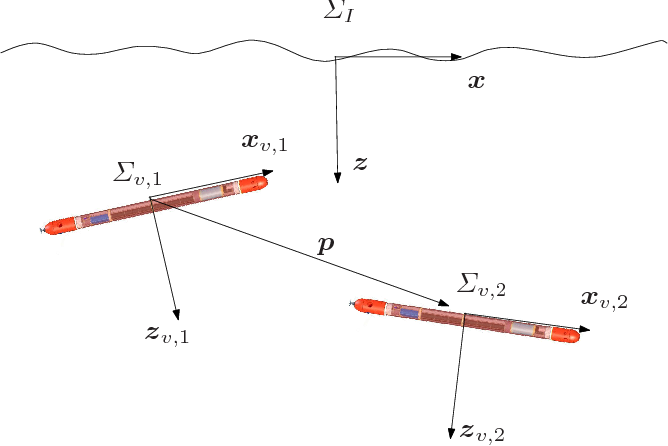
Figure 2 from Designing behaviors to improve observability for relative ...

Review of Localization and Clustering in USV and AUV for Underwater ...
Advertisement Space (336x280)

Figure 1 from Reinforcement Learning Based AUV Localization in ...

Examples of two faults mapped using the AUV Sentry, location given in ...

(a)-(d). Depth profiles of the AUV transects: (a) PR-03, (b) PR-04, (c ...

Figure 1 from A Novel Multi-AUV Cooperative Navigation Method Using ...

A Review of Underwater Localization Techniques, Algorithms, and ...

(a) Map view of seawater depth distribution measured by AUV in 2008 and ...