
Figure 2 From Modeling And Control Of An Antagonistic Shape Memory
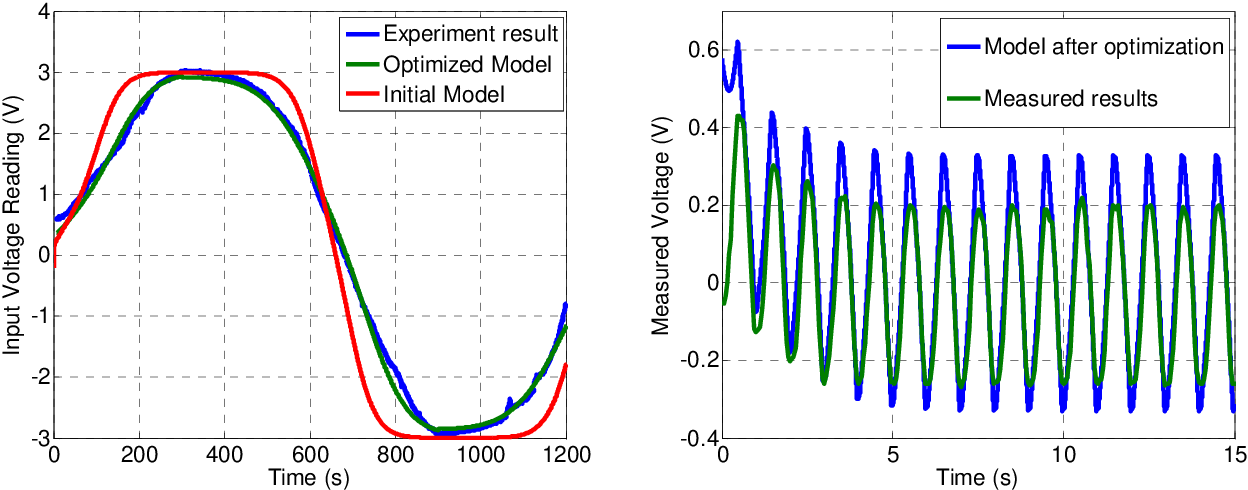
Figure 2 from Modeling and Control of an Antagonistic Shape Memory ...
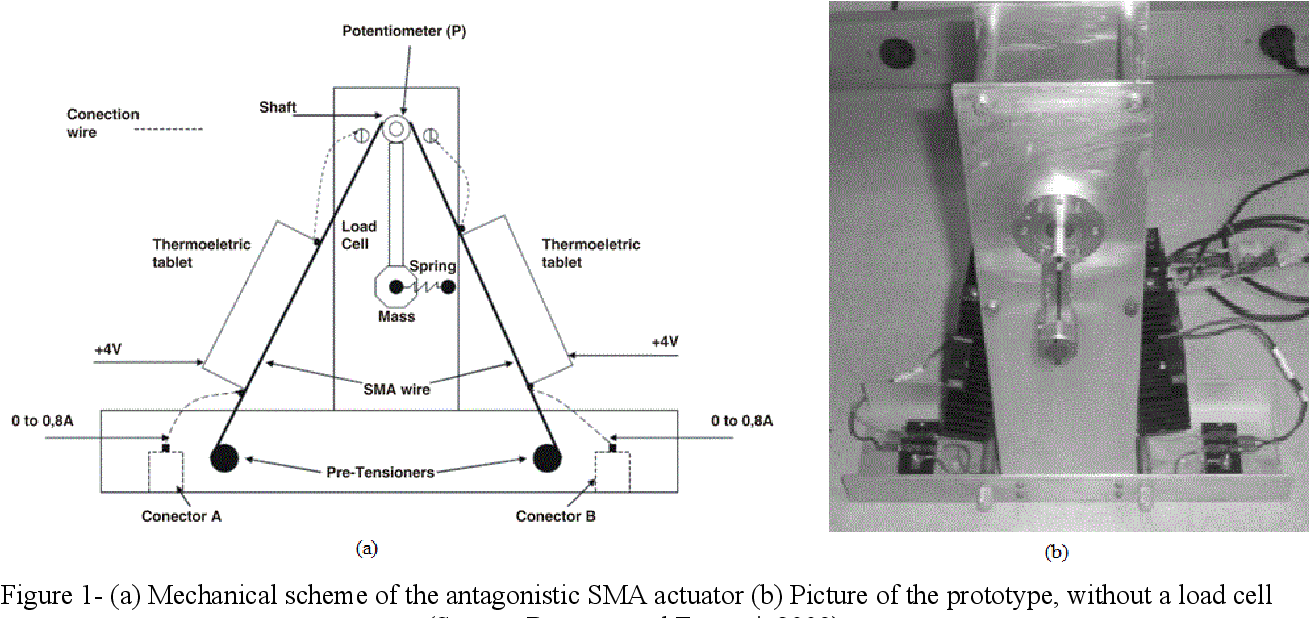
Figure 1 from Modeling and Control of an Antagonistic Shape Memory ...
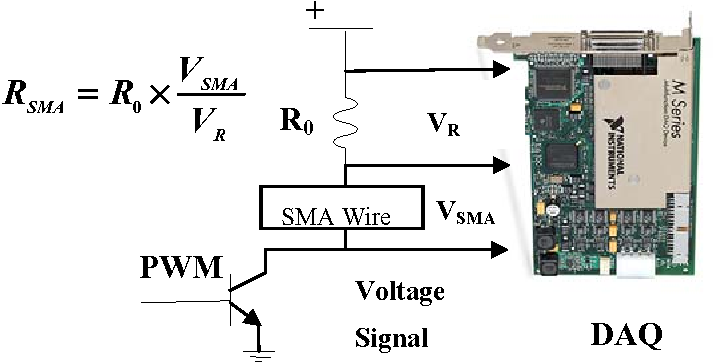
Figure 2 from An Accurately Controlled Antagonistic Shape Memory Alloy ...
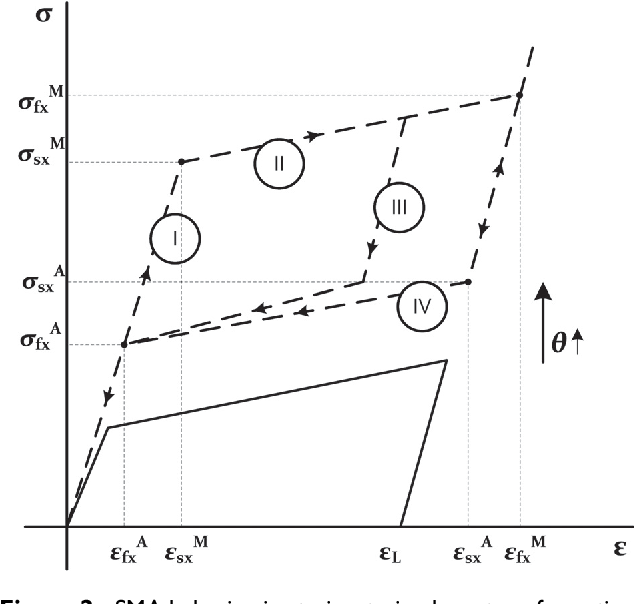
Figure 2 from Model based design of antagonistic shape memory alloy ...
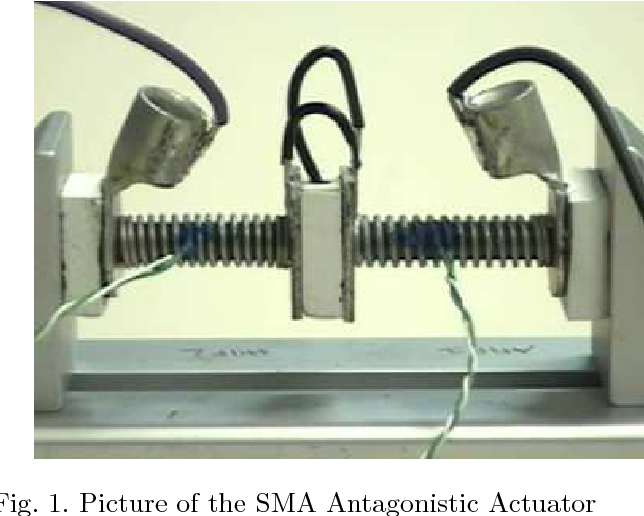
Figure 1 from Model-Free Control of Shape Memory Alloys Antagonistic ...
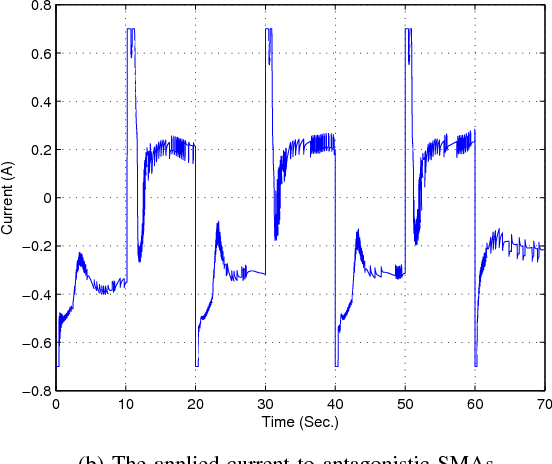
Figure 4 from Nonlinear Position Control of Antagonistic Shape Memory ...
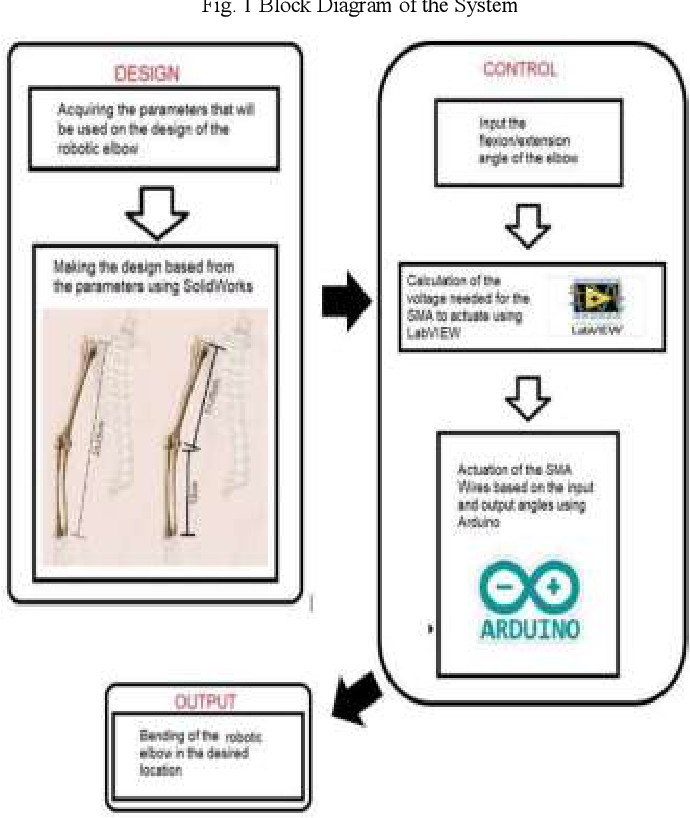
Figure 1 from Design and Control of Robotic Elbow Using Shape Memory ...

Figure 2 from Design and Control of Turtle Locomotion-Inspired Robots ...
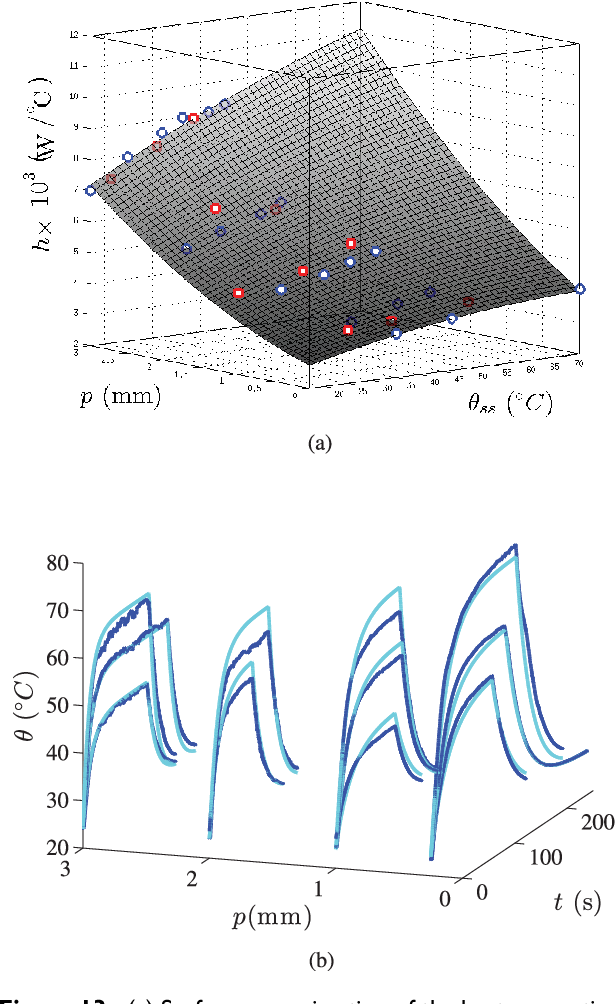
Figure 1 from Model based design of antagonistic shape memory alloy ...
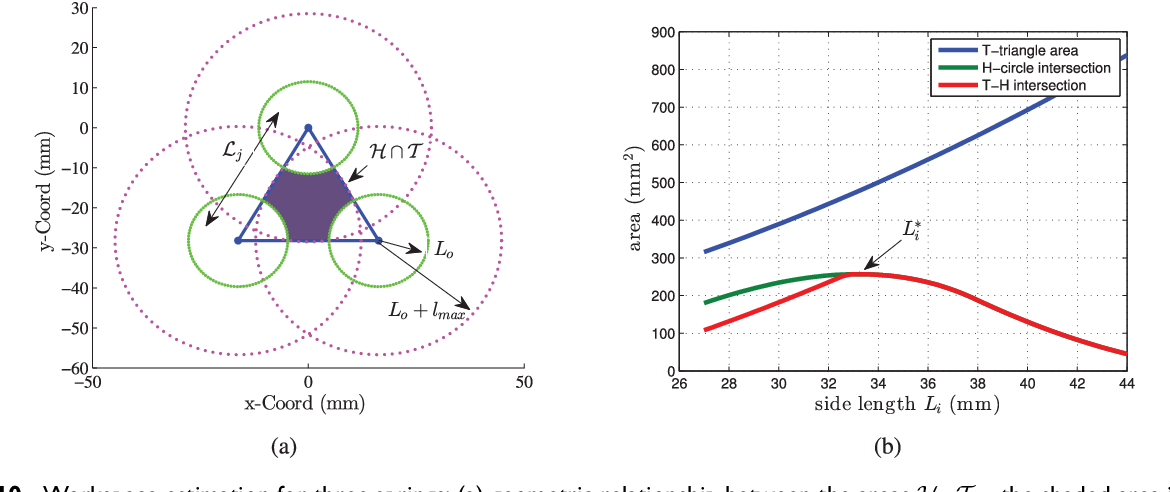
Figure 1 from Model based design of antagonistic shape memory alloy ...
Advertisement Space (300x250)
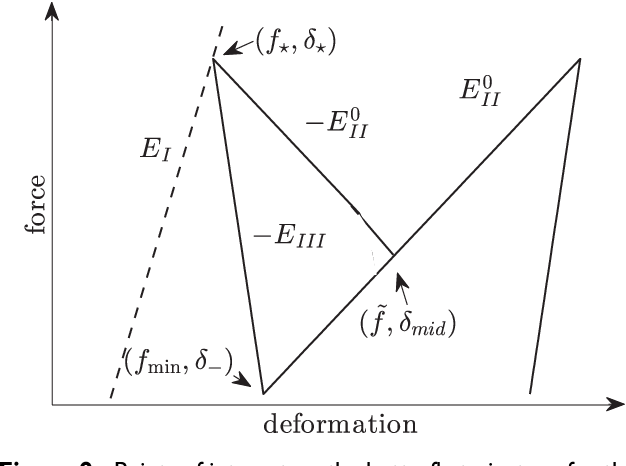
Figure 1 from Model based design of antagonistic shape memory alloy ...

Figure 1 from Model based design of antagonistic shape memory alloy ...

Figure 1 from Model based design of antagonistic shape memory alloy ...
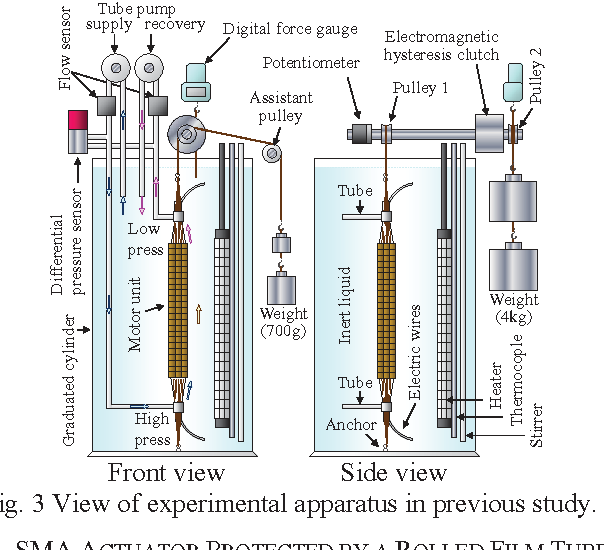
Figure 3 from Portability and antagonistic stiffness control for an ...
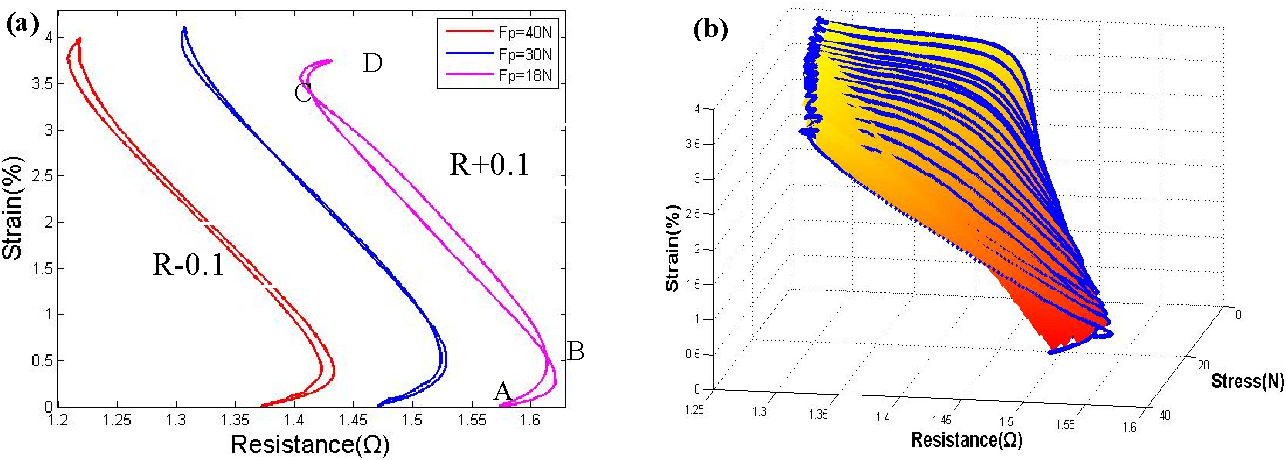
Figure 4 from An Accurately Controlled Antagonistic Shape Memory Alloy ...
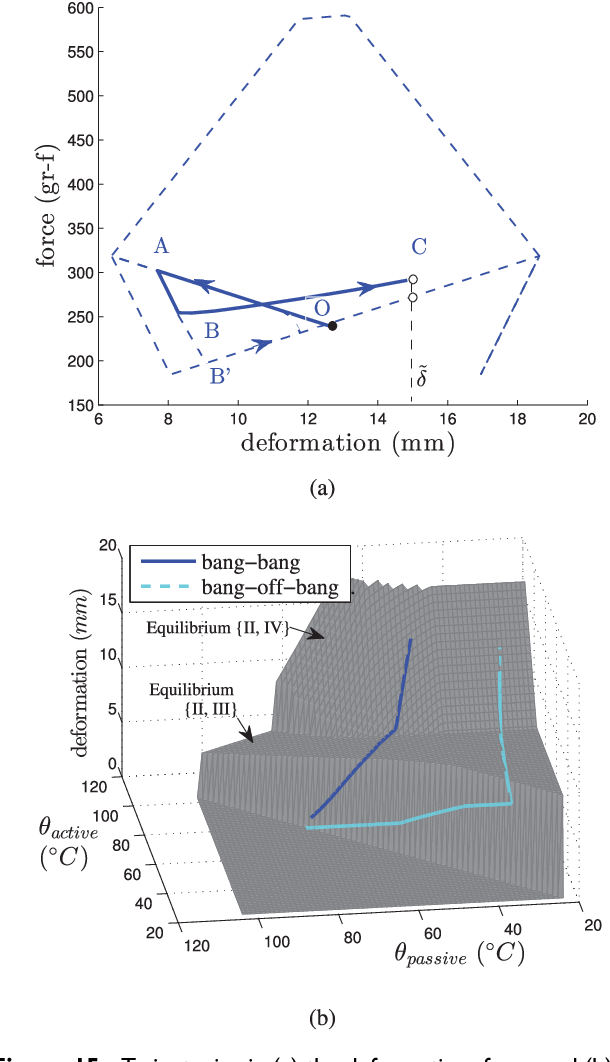
Figure 1 from Model based design of antagonistic shape memory alloy ...
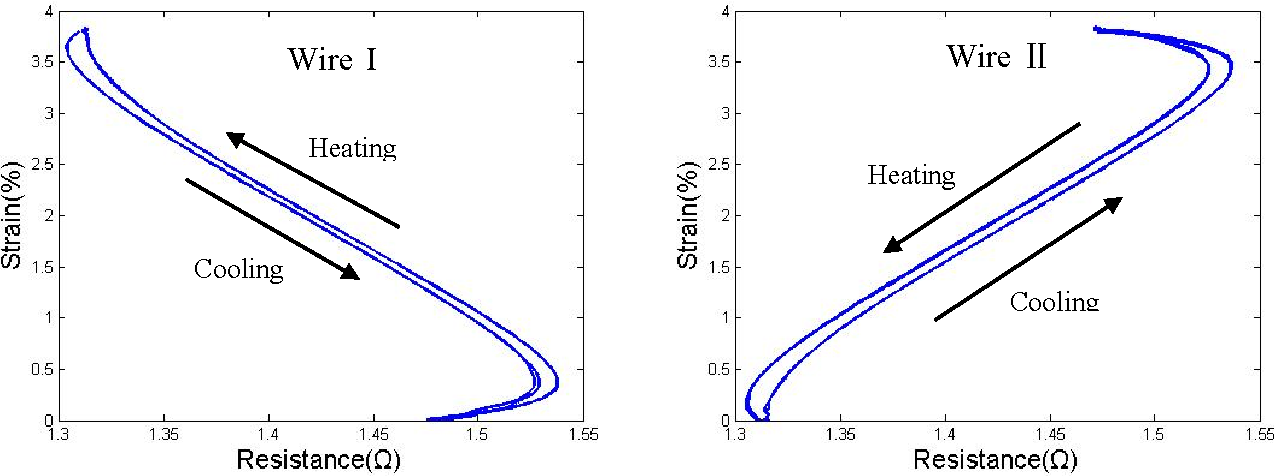
Figure 5 from An Accurately Controlled Antagonistic Shape Memory Alloy ...
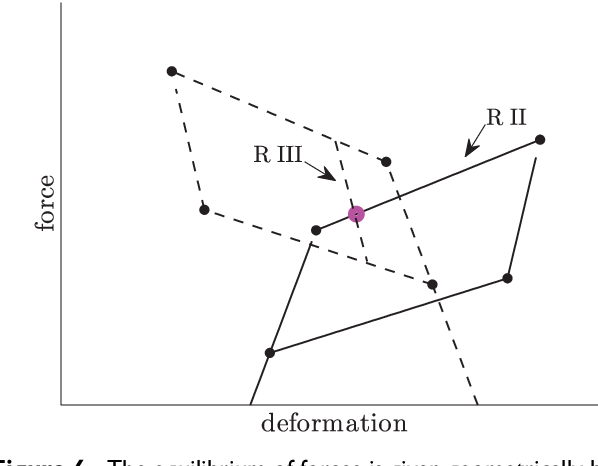
Figure 1 from Model based design of antagonistic shape memory alloy ...
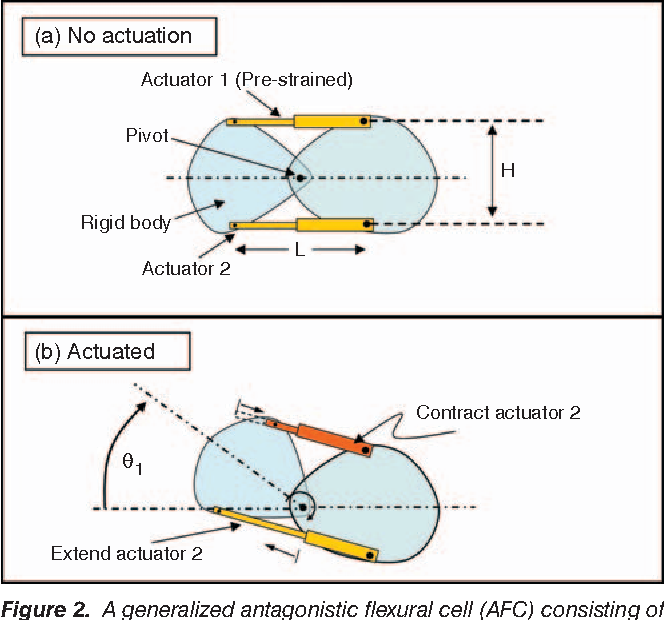
Figure 2 from Two-way Antagonistic Shape Actuation Based on the One-way ...

Figure 1 from Indirect Intelligent Sliding Mode Control of Antagonistic ...
Advertisement Space (336x280)

(PDF) Model-Free Control of Shape Memory Alloys Antagonistic Actuators
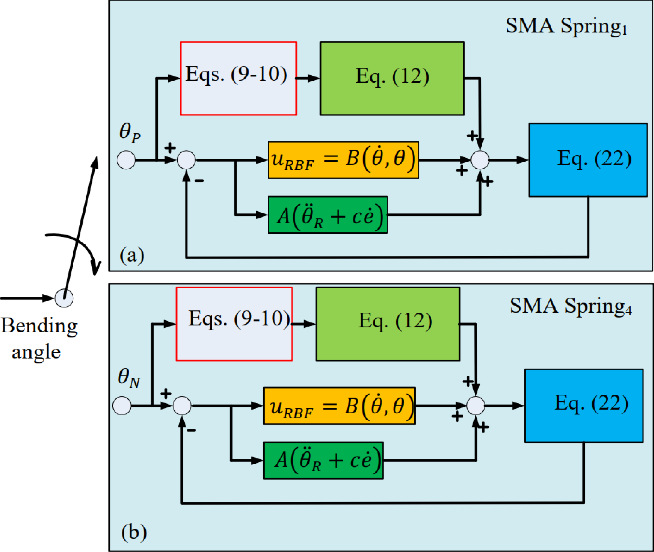
Figure 11 from Design and Control of Turtle Locomotion-Inspired Robots ...
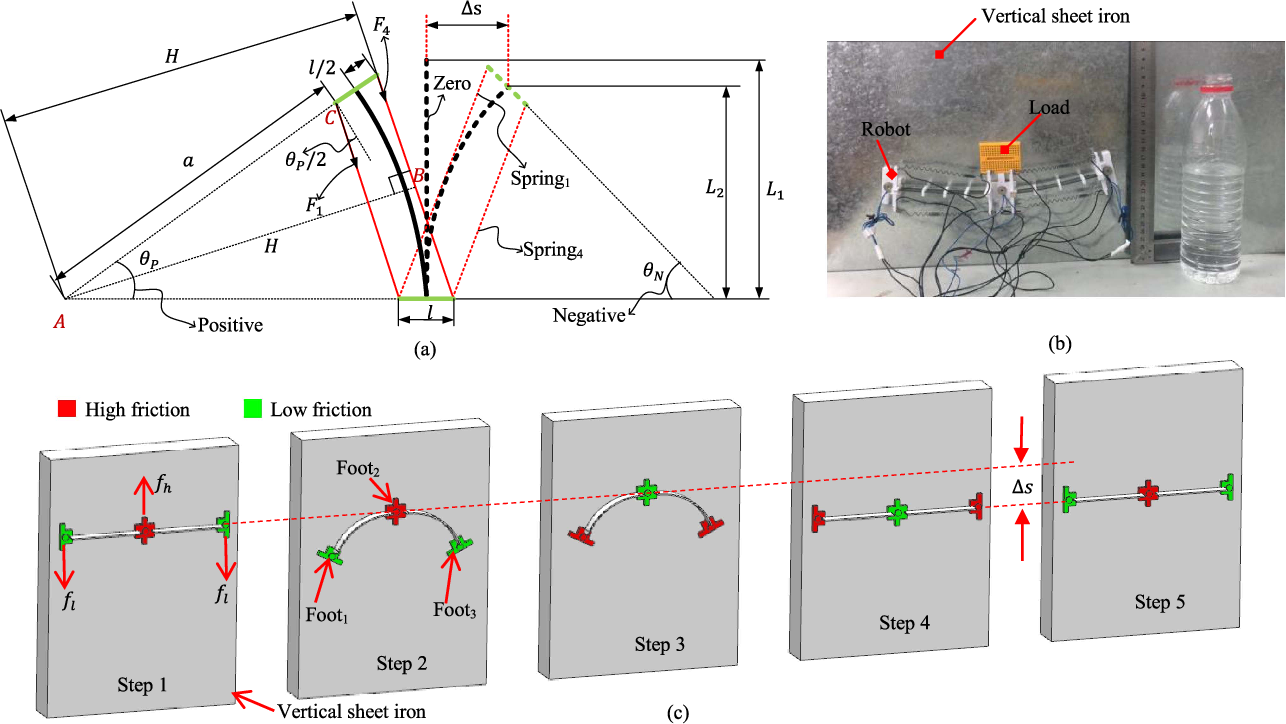
Figure 3 from Design and Control of Turtle Locomotion-Inspired Robots ...

Modeling and Position Control Simulation Research on Shape Memory Alloy ...
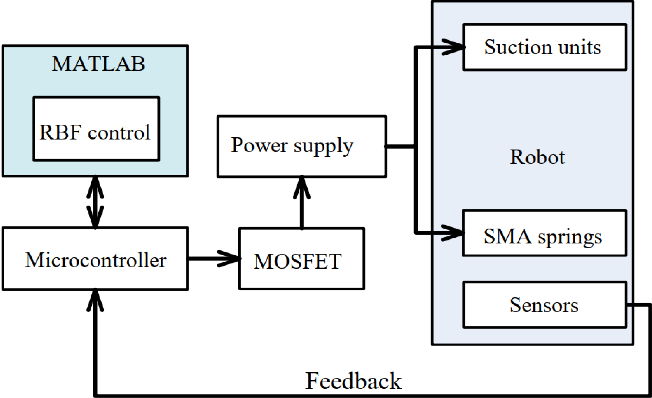
Figure 12 from Design and Control of Turtle Locomotion-Inspired Robots ...
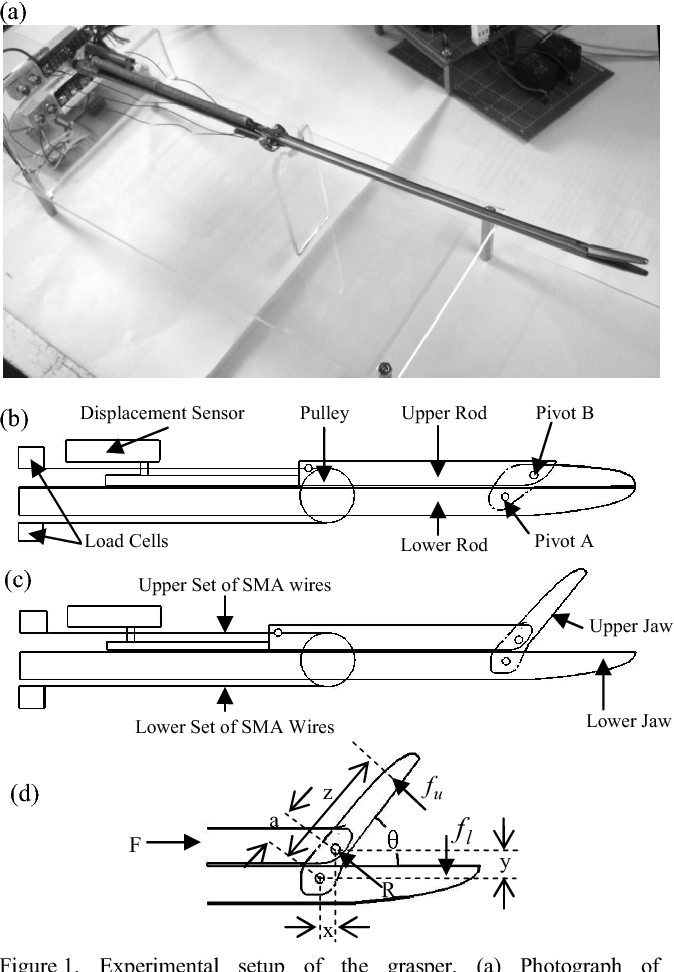
Figure 1 from Force control of laparoscopy grasper using antagonistic ...
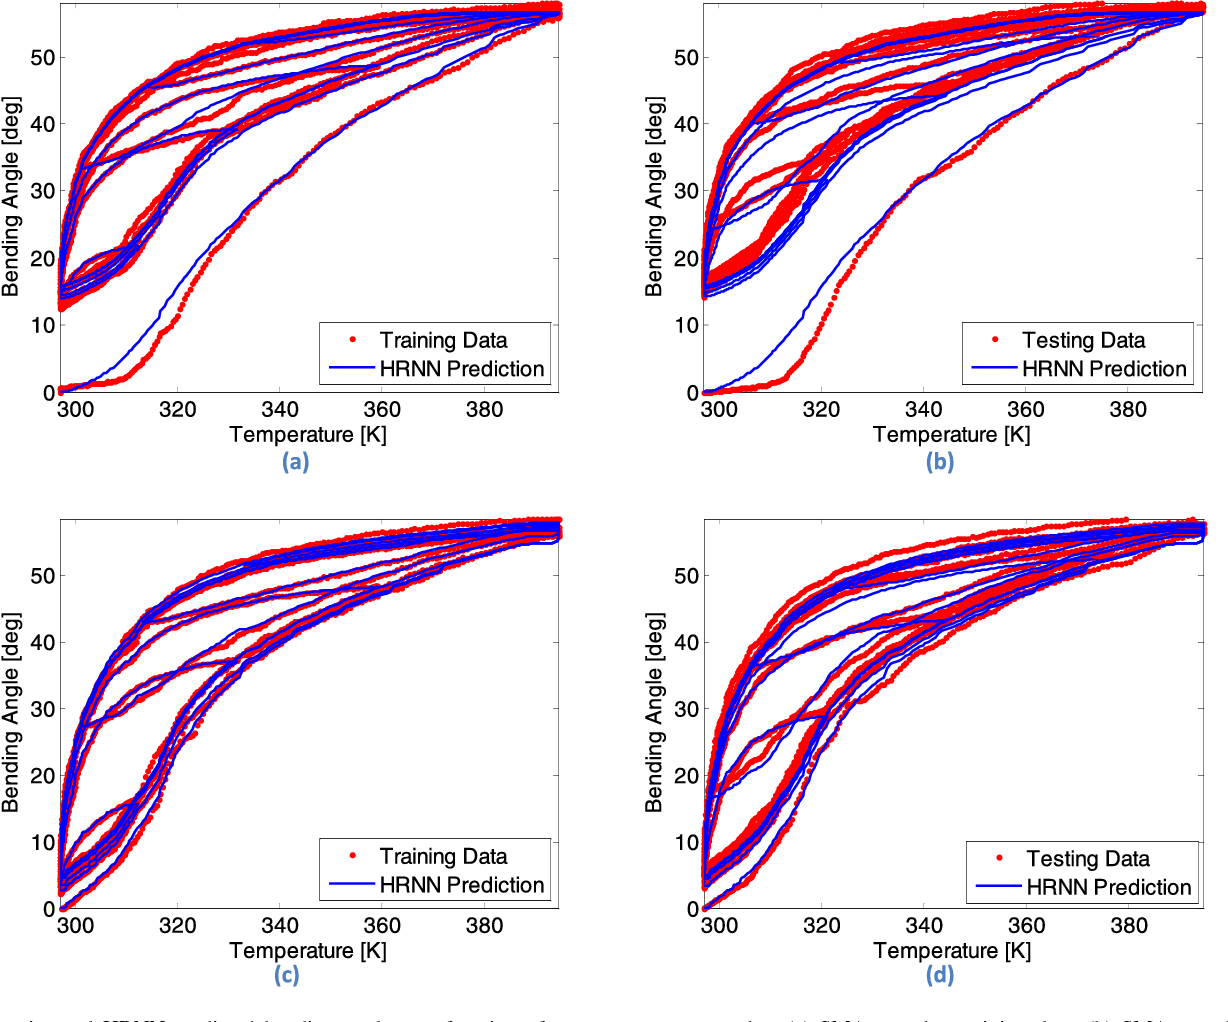
Figure 7 from Indirect Intelligent Sliding Mode Control of Antagonistic ...
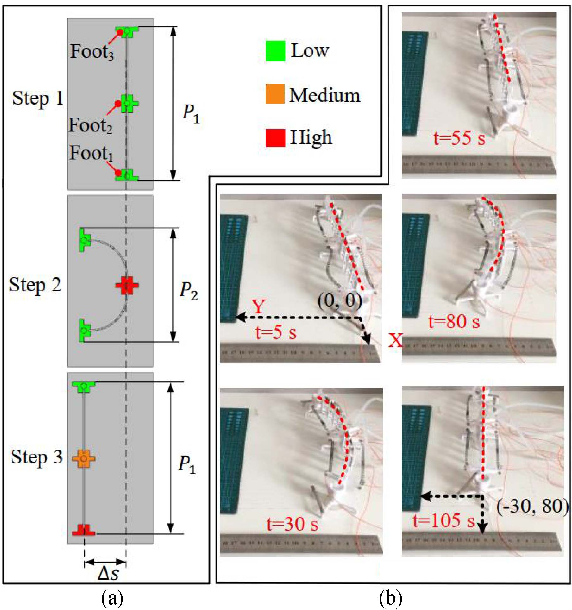
Figure 16 from Design and Control of Turtle Locomotion-Inspired Robots ...

(PDF) Finite‐Element Analysis of an Antagonistic Bistable Shape Memory ...
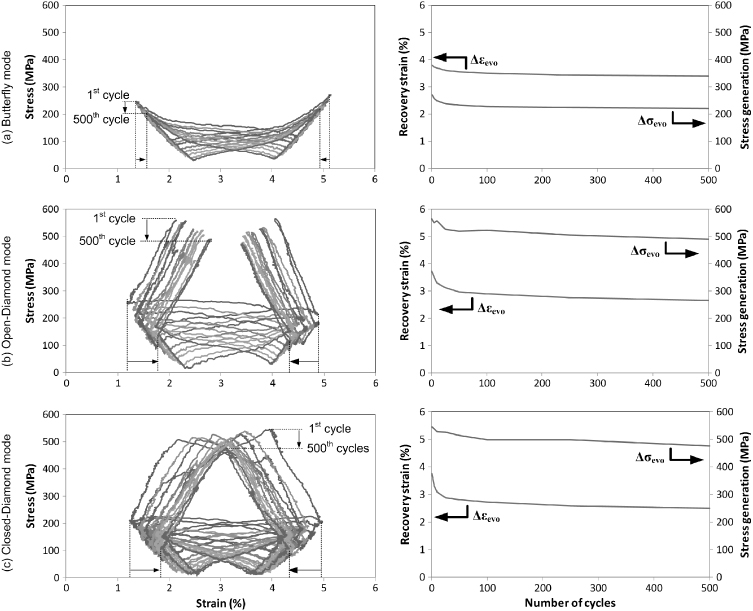
Characterization and design of antagonistic shape memory alloy ...
Advertisement Space (336x280)

Figure 2 from Comparison of position control algorithms of embedded ...
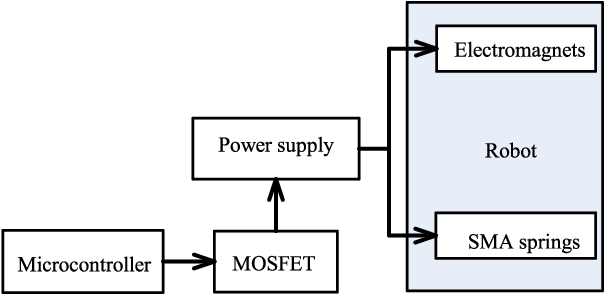
Figure 4 from Design and Control of Turtle Locomotion-Inspired Robots ...
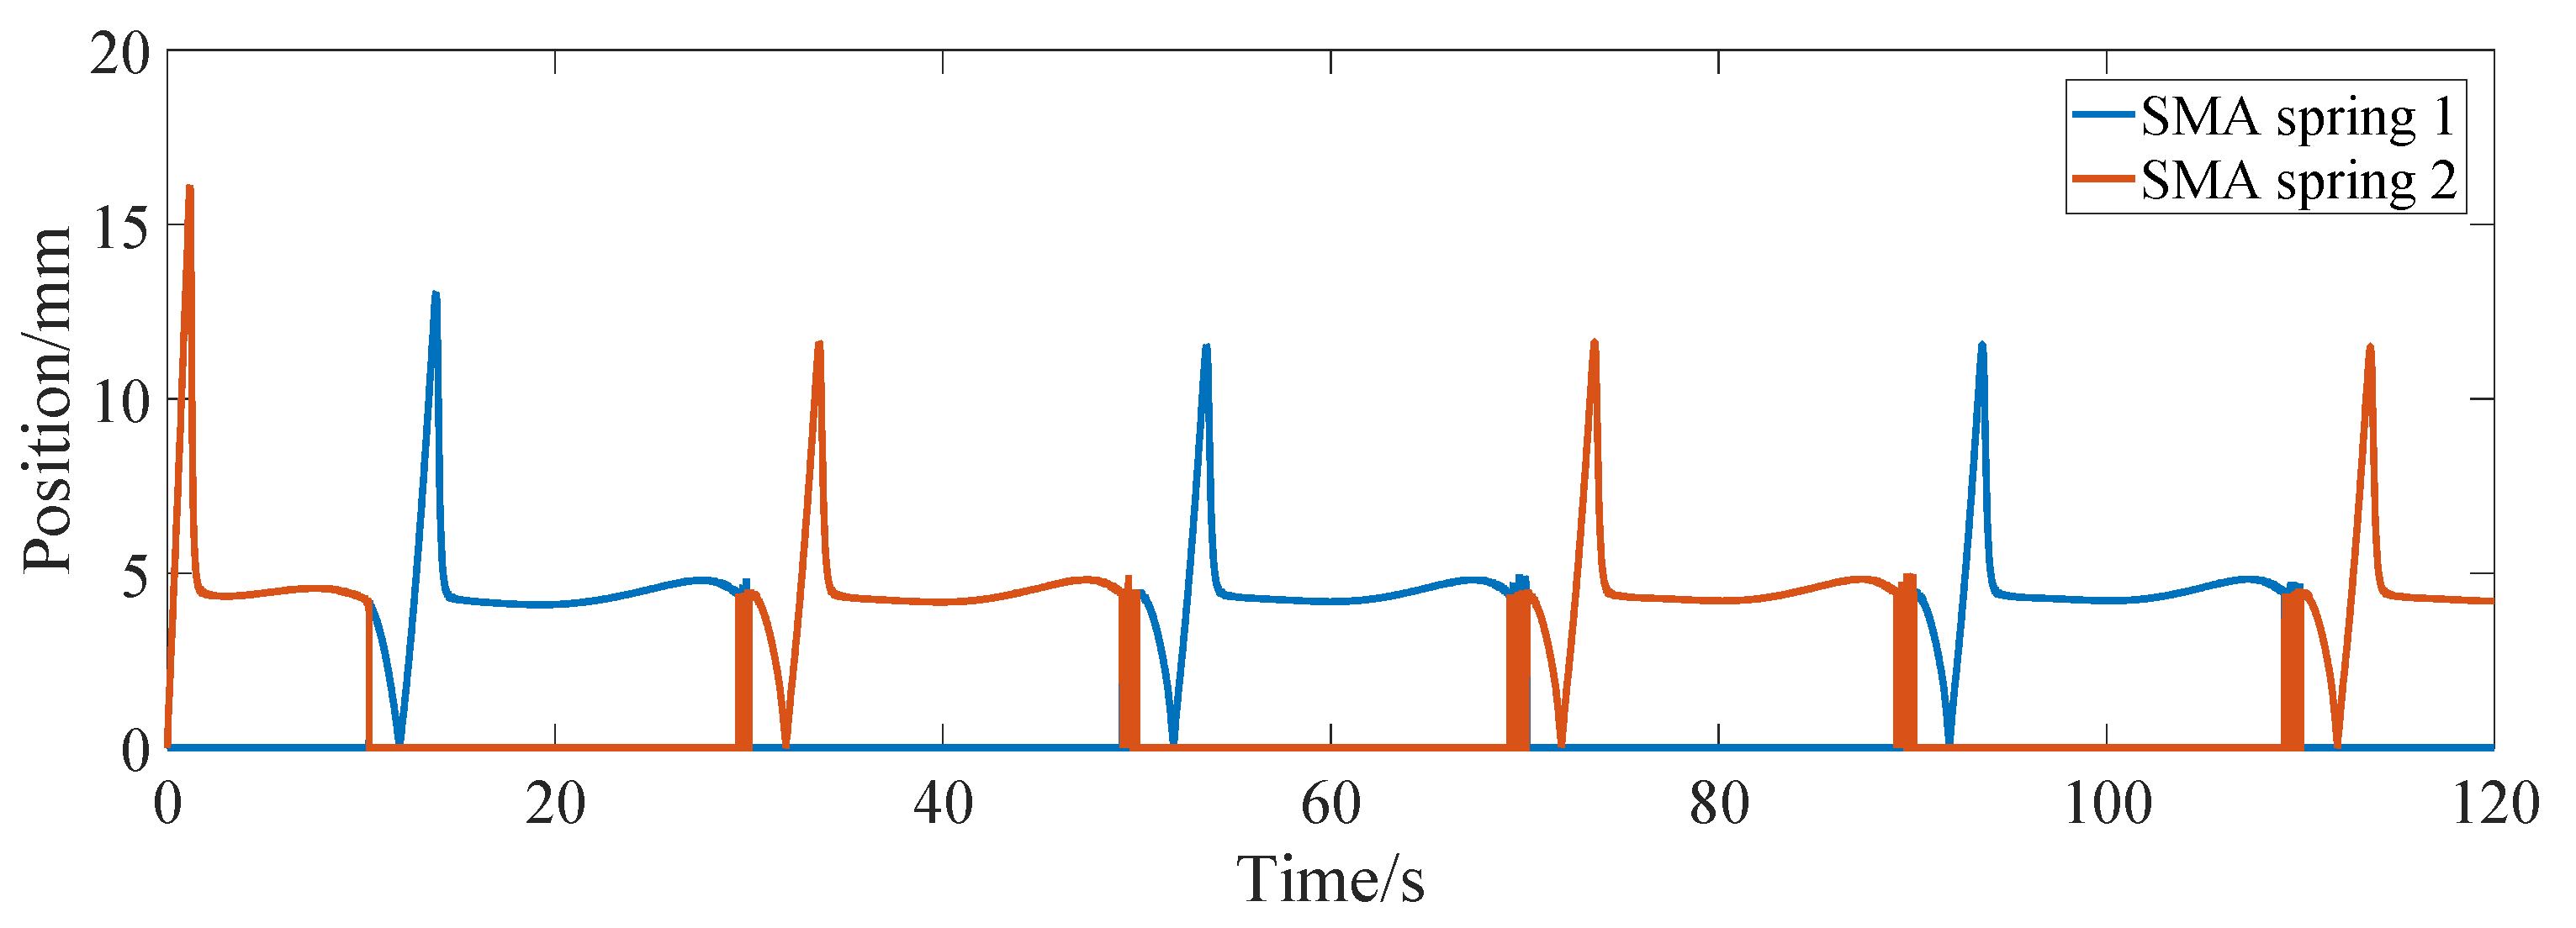
Modeling and Position Control Simulation Research on Shape Memory Alloy ...
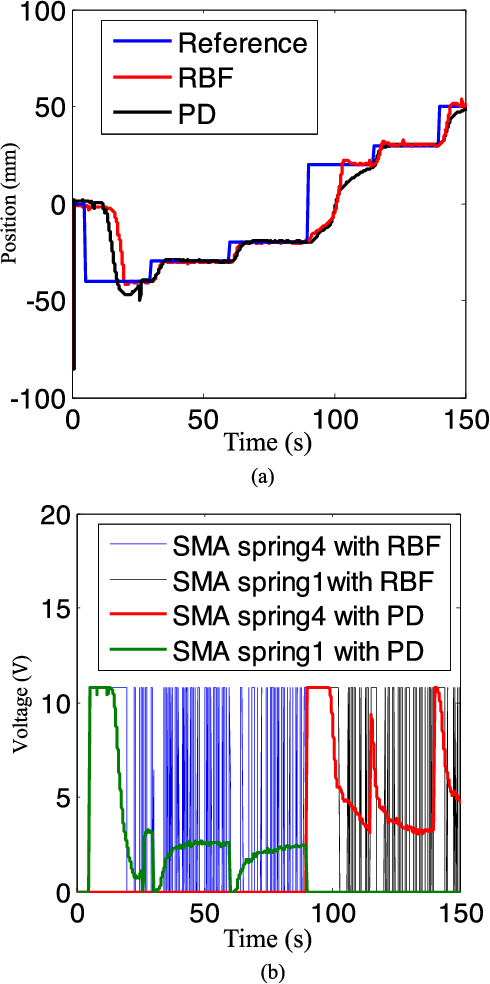
Figure 13 from Design and Control of Turtle Locomotion-Inspired Robots ...
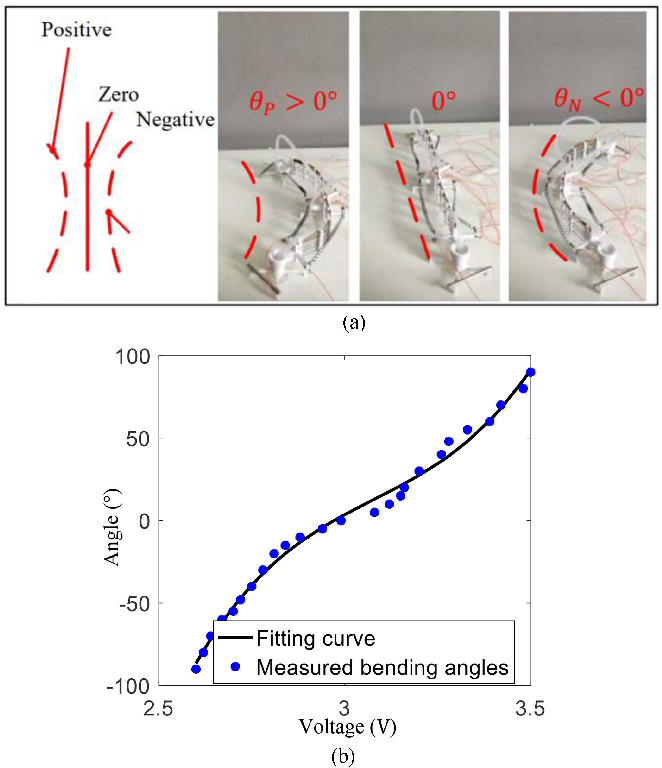
Figure 10 from Design and Control of Turtle Locomotion-Inspired Robots ...

Modeling and Position Control Simulation Research on Shape Memory Alloy ...