
Figure 2 From Two Time Scale Control And Observer Design For Trajectory

Figure 2 from Two-Time Scale Control and Observer Design for Trajectory ...
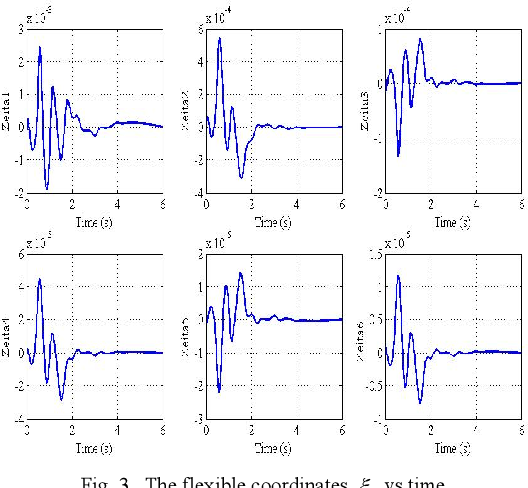
Figure 3 from Two-Time Scale Control and Observer Design for Trajectory ...
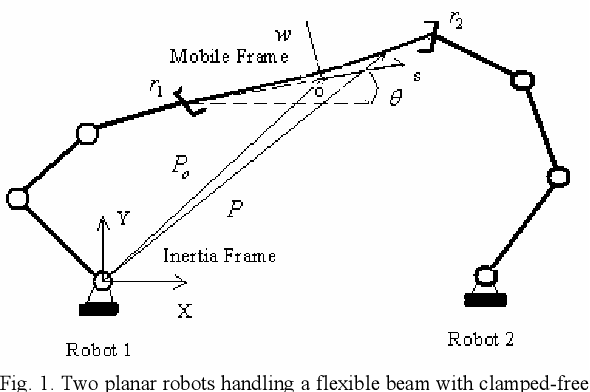
Figure 1 from Two-Time Scale Control and Observer Design for Trajectory ...
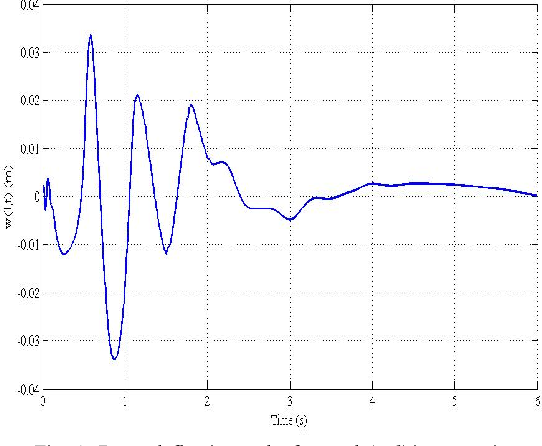
Figure 4 from Two-Time Scale Control and Observer Design for Trajectory ...

Figure 2 from Two-Time Scale Fuzzy Logic Controller and Observer Design ...

(PDF) Two-time scale control and observer design for trajectory ...

(PDF) Two-Time Scale Control and Observer Design for Trajectory ...

Figure 2 from A Two-Time Scale Design for Detection and Rectification ...

Figure 9 from Two-Time Scale Fuzzy Logic Controller and Observer Design ...

Figure 3 from Two-Time Scale Fuzzy Logic Controller and Observer Design ...
Advertisement Space (300x250)

Figure 1 from Boundary control and two-time scale method for vibration ...

Figure 4 from Two-Time Scale Fuzzy Logic Controller and Observer Design ...

Figure 2 from Missile Autopilot Design for Agile Turn Using Time Delay ...

Figure 2 from Optimal Two-Time Scale Controller for a Missile Autopilot ...

Figure 2 from Event-Triggered H∞ Control for Fuzzy Two-Time-Scale ...
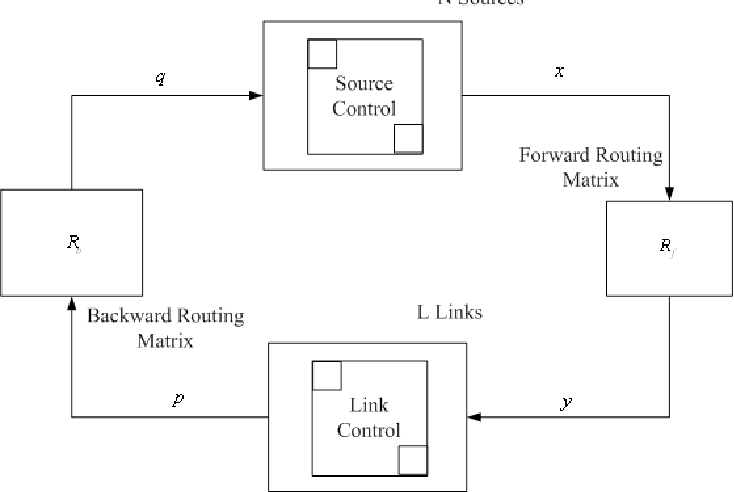
Figure 1 from A Two-Time-Scale Design for Edge-Based Detection and ...
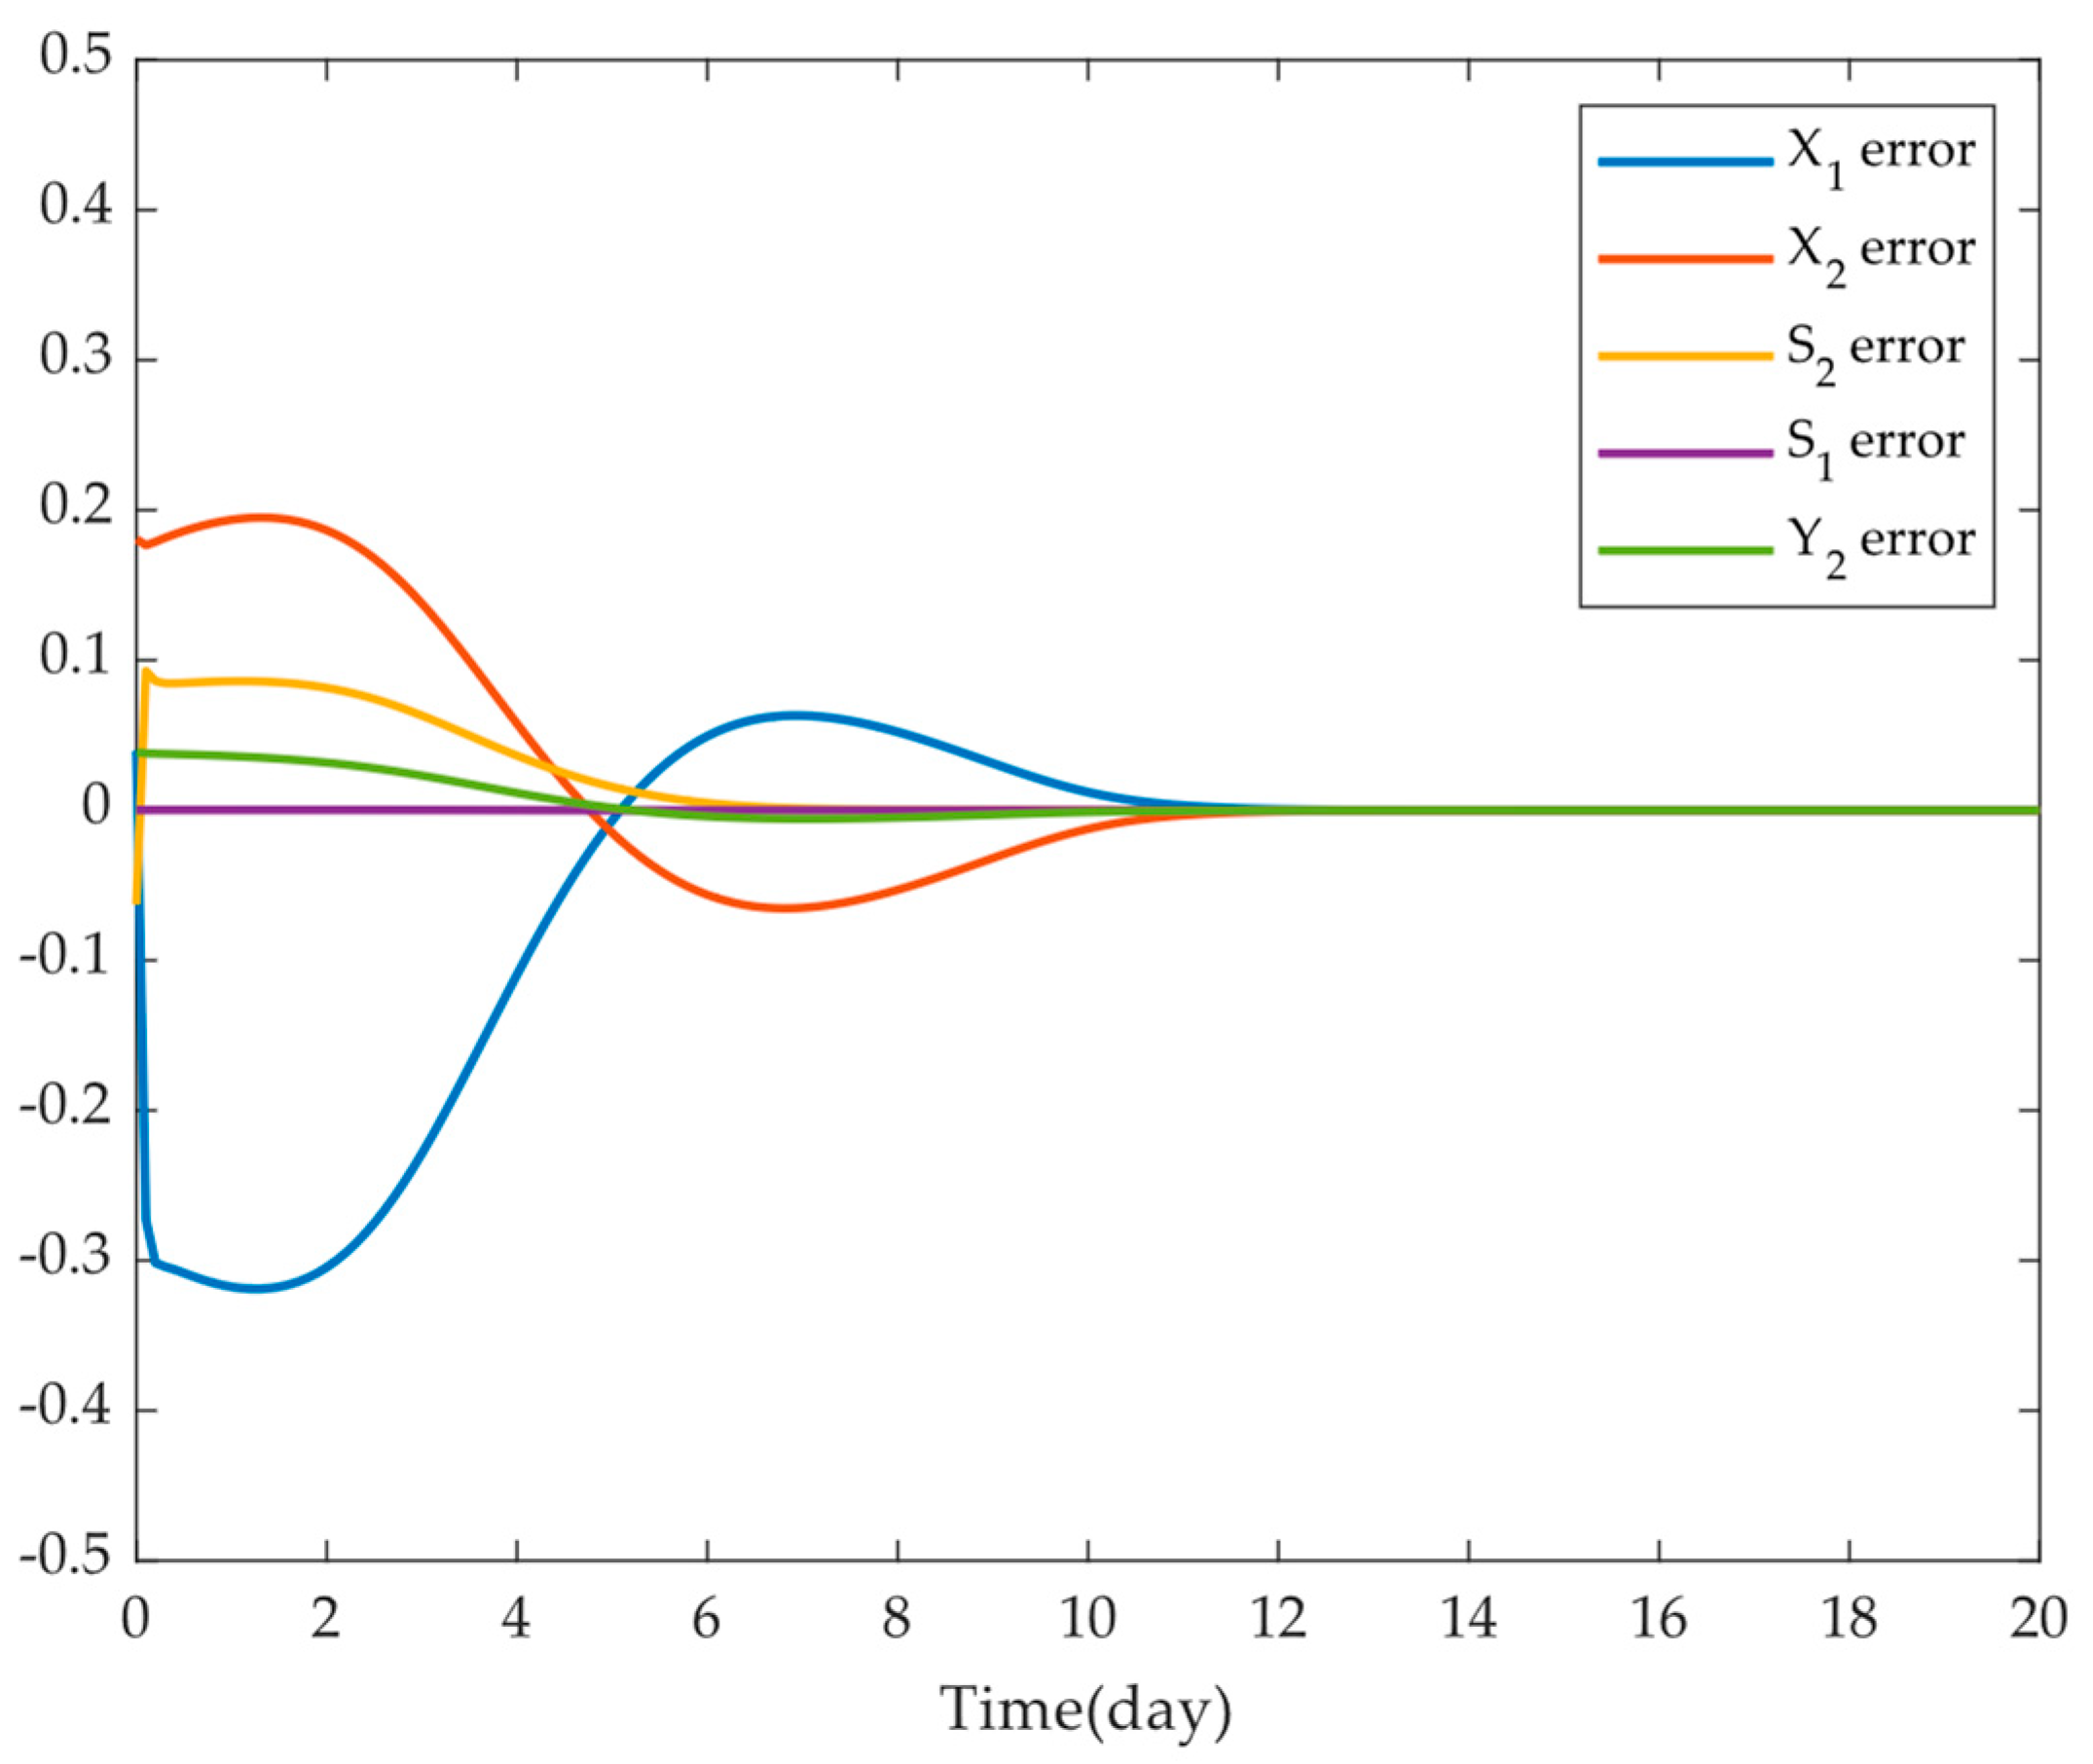
Observer Design for State and Parameter Estimation for Two-Time-Scale ...

Observer Design for State and Parameter Estimation for Two-Time-Scale ...

Observer Design for State and Parameter Estimation for Two-Time-Scale ...

Observer Design for State and Parameter Estimation for Two-Time-Scale ...
Advertisement Space (336x280)
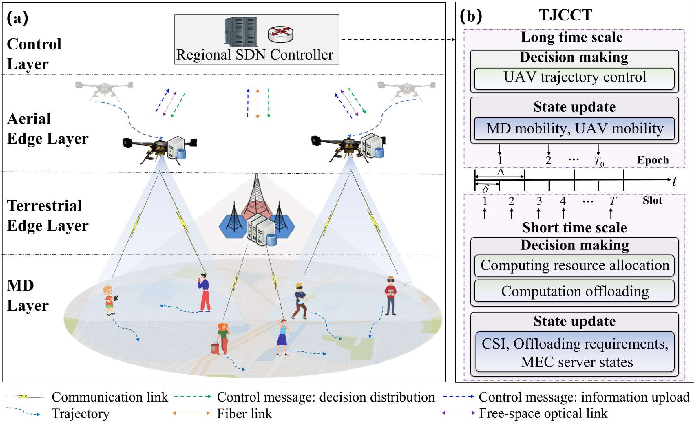
Figure 1 from A Two Time-Scale Joint Optimization Approach for UAV ...

Observer Design for State and Parameter Estimation for Two-Time-Scale ...

Figure 2 from Finite-Time Control of Dynamic Positioning Vessel Based ...
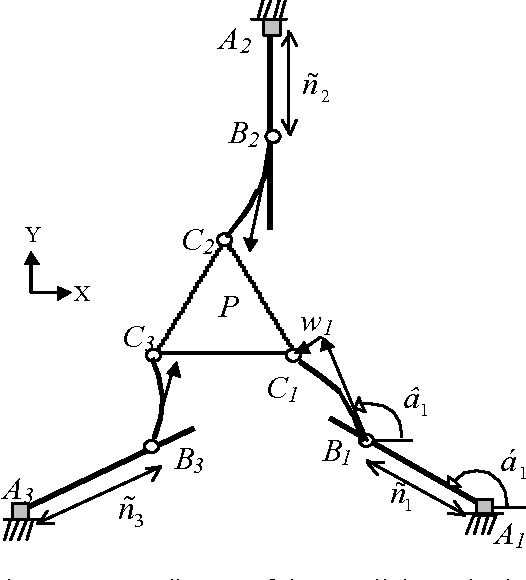
Figure 1 from Two-Time Scale Control of a High Speed Planar Parallel ...

Figure 1 from Yaw rate and sideslip angle control of active 4WS using a ...
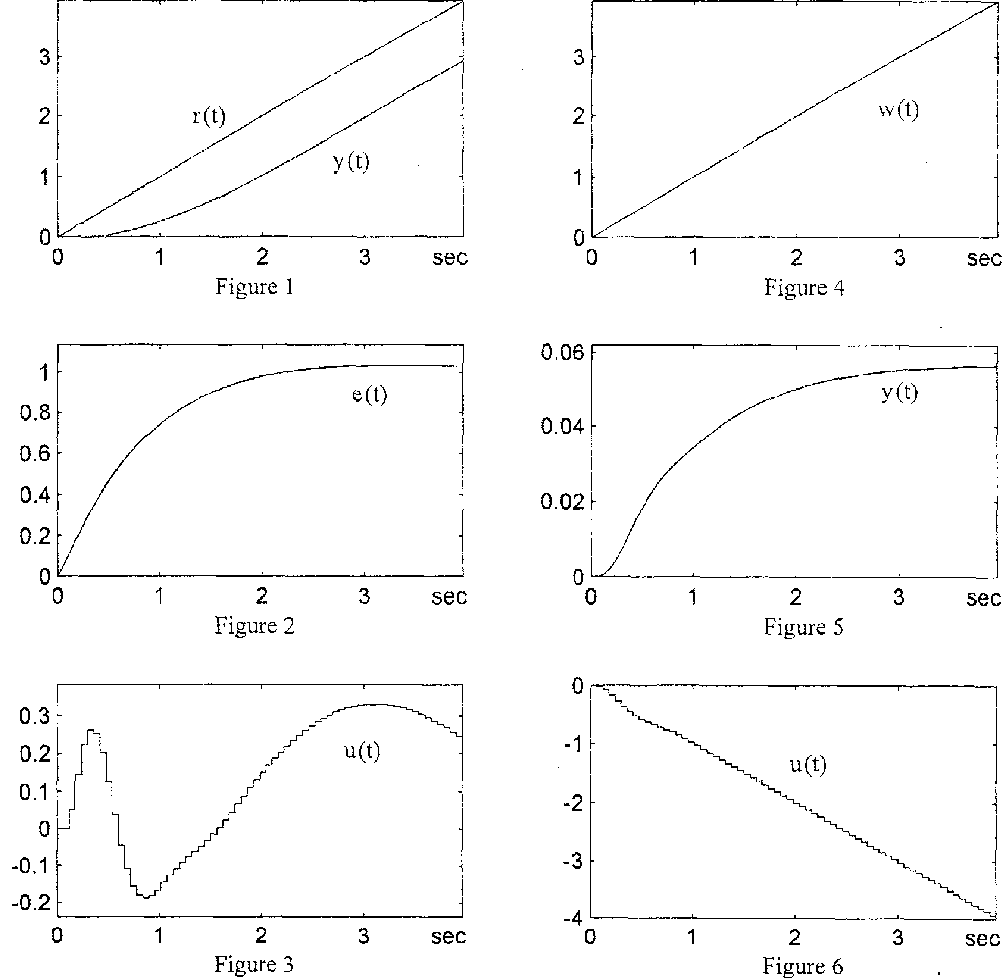
Figure 3 from Design of digital control systems with two-time-scale ...
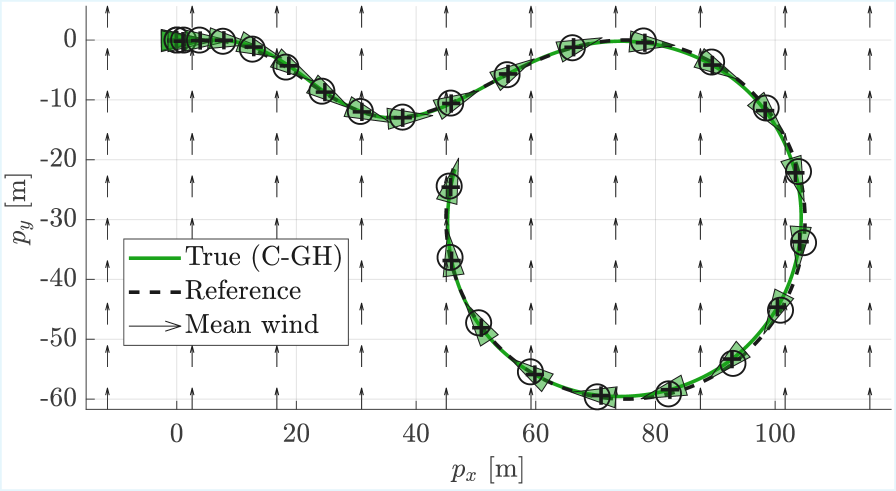
Trajectory Tracking Control Design for Autonomous Helicopters with ...
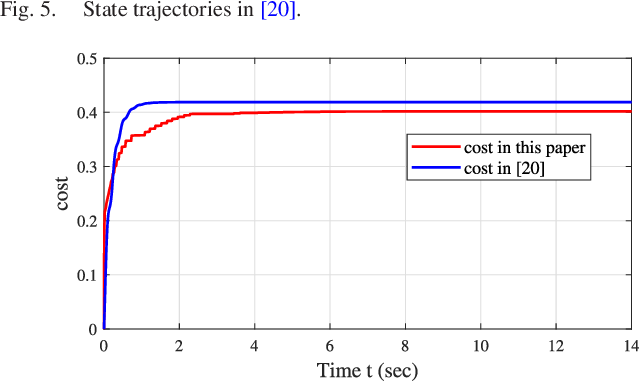
Figure 6 from Event-Triggered H∞ Control for Fuzzy Two-Time-Scale ...
(PDF) Robust two-time scale control system design for reactive Ion ...

Trajectory Tracking Design for Unmanned Surface Vessels: Robust Control ...
Advertisement Space (336x280)
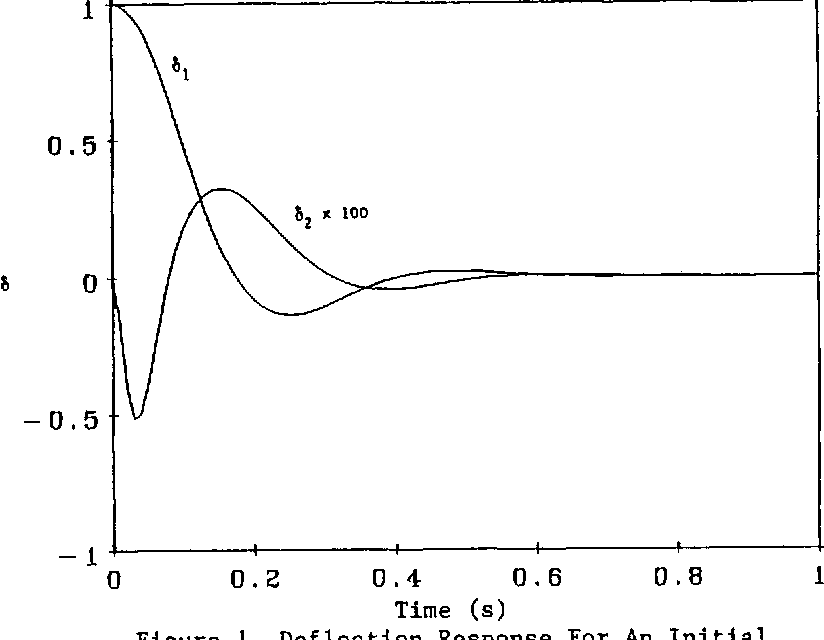
Figure 1 from Optimal output fast feedback in two-time scale control of ...

The block diagram of two time scales SMC observer | Download Scientific ...
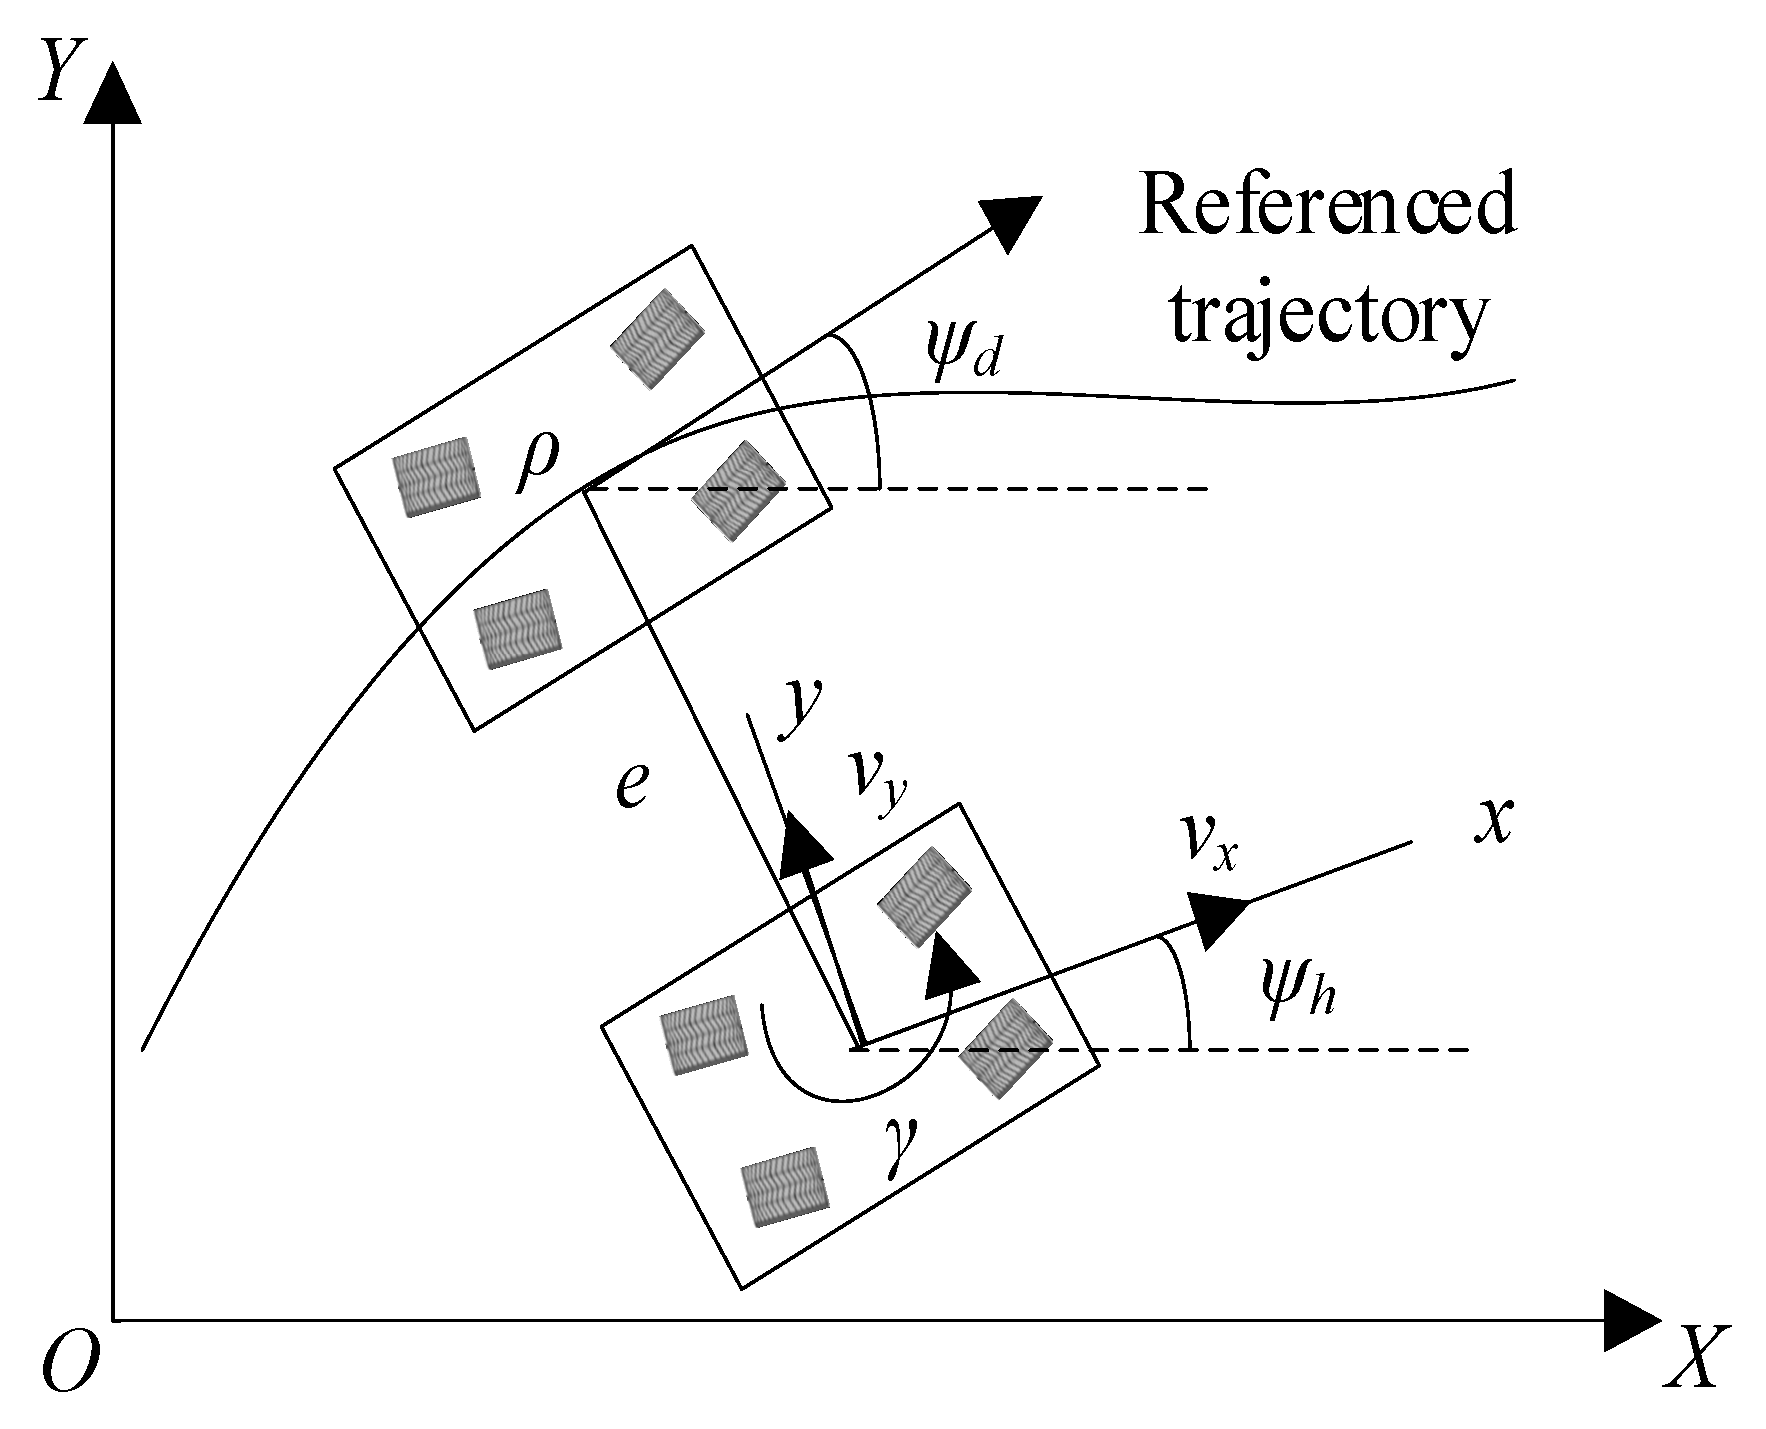
Observer-Based Coordinated Control of Trajectory Tracking and Lateral ...

Observer‐Based Robust Finite‐Time Trajectory Tracking Control for a ...

Trajectory tracking for the beam rigid motion, orientation, vs. time ...

Trajectory tracking for the beam rigid motion, orientation, vs. time ...