
Figure 2 From Unified Path And Gait Planning For Safe Bipedal Robot

Figure 2 from Unified Path and Gait Planning for Safe Bipedal Robot ...

Figure 9 from Unified Path and Gait Planning for Safe Bipedal Robot ...

Figure 10 from Unified Path and Gait Planning for Safe Bipedal Robot ...

Figure 11 from Unified Path and Gait Planning for Safe Bipedal Robot ...
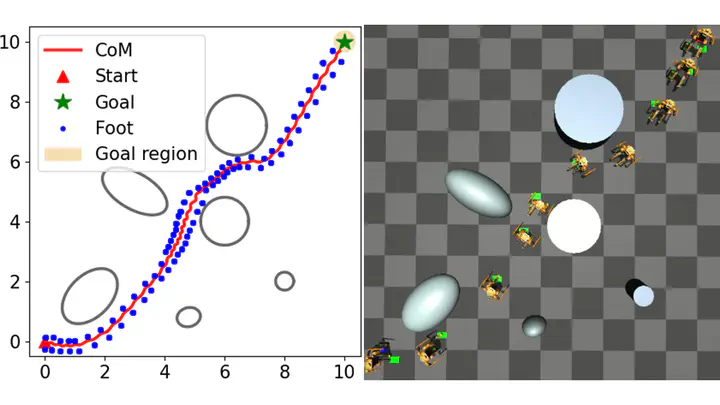
Unified Path and Gait Planning for Safe Bipedal Robot Navigation ...
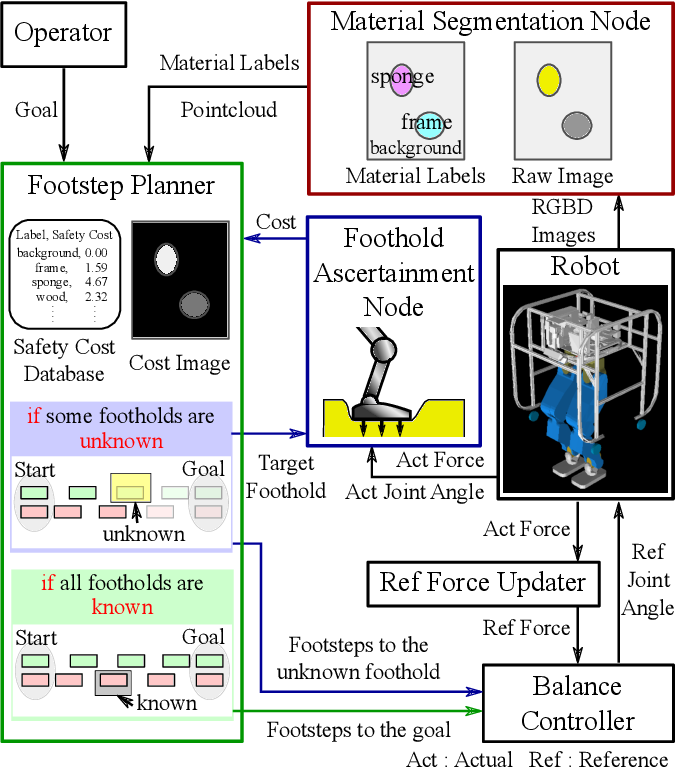
Figure 2 from Autonomous Safe Locomotion System for Bipedal Robot ...

Figure 3 from Gait Planning for Underactuated Bipedal Robot on ...
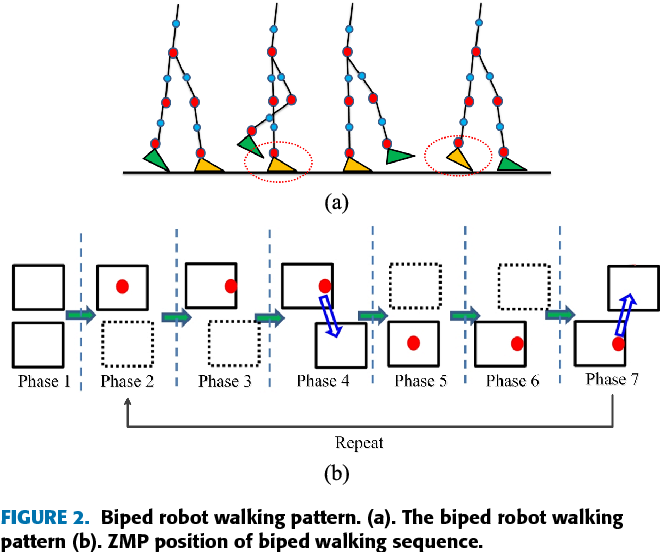
Figure 2 from Gait Balance and Acceleration of a Biped Robot Based on Q ...

Figure 2 from Gait Design of a Bipedal Walking Robot Based on the ...

Figure 4 from Gait Planning for Biped Robot Based on Variable Center-of ...
Advertisement Space (300x250)

Omni-directional Walking Gait and Path Planning for Biped Humanoid Robot

Figure 1 from Velocity-Based Gait Planning for Underactuated Bipedal ...

Figure 1 from A modified gait planning method for biped robot based on ...

Omni-directional Walking Gait and Path Planning for Biped Humanoid Robot

Figure 5 from Velocity-Based Gait Planning for Underactuated Bipedal ...
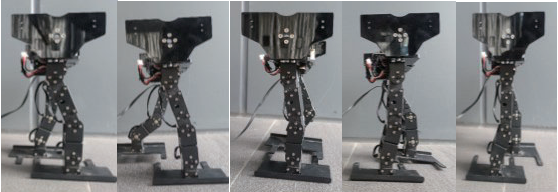
Figure 13 from Gait Planning for Biped Robot Based on Variable Center ...

Figure 1 from A Humanoid Robot Gait Planning and Its Stability ...

Omni-directional Walking Gait and Path Planning for Biped Humanoid Robot
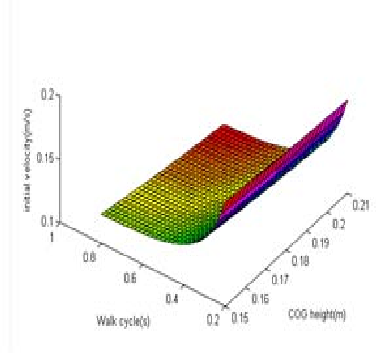
Figure 5 from Design and Implementation of Stable Gait for Bipedal ...
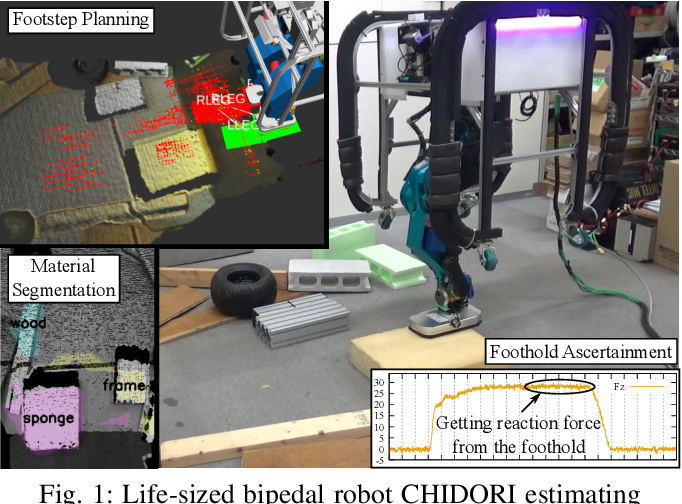
Figure 1 from Autonomous Safe Locomotion System for Bipedal Robot ...
Advertisement Space (336x280)

Figure 3 from Optimized stable gait planning of biped robot using multi ...
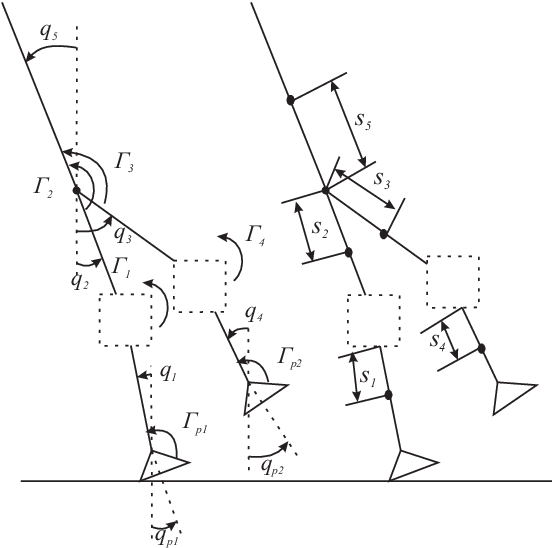
Figure 1 from Walking gait of a planar bipedal robot with four-bar ...

Figure 1 from Real-Time Path Planning in Unknown Environments for ...

Figure 1 from Bipedal Robot Gait Control Strategies Based on ...

Figure 2 from Recent Advances in Bipedal Walking Robots: Review of Gait ...
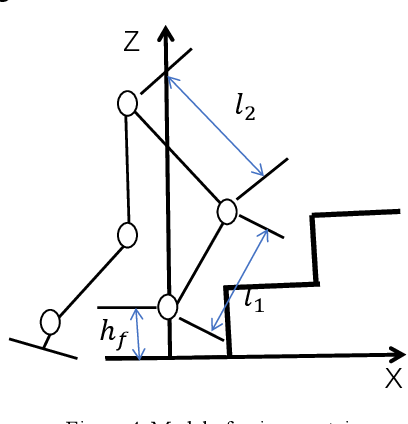
Figure 4 from Gait Design of a Bipedal Walking Robot Based on the ...
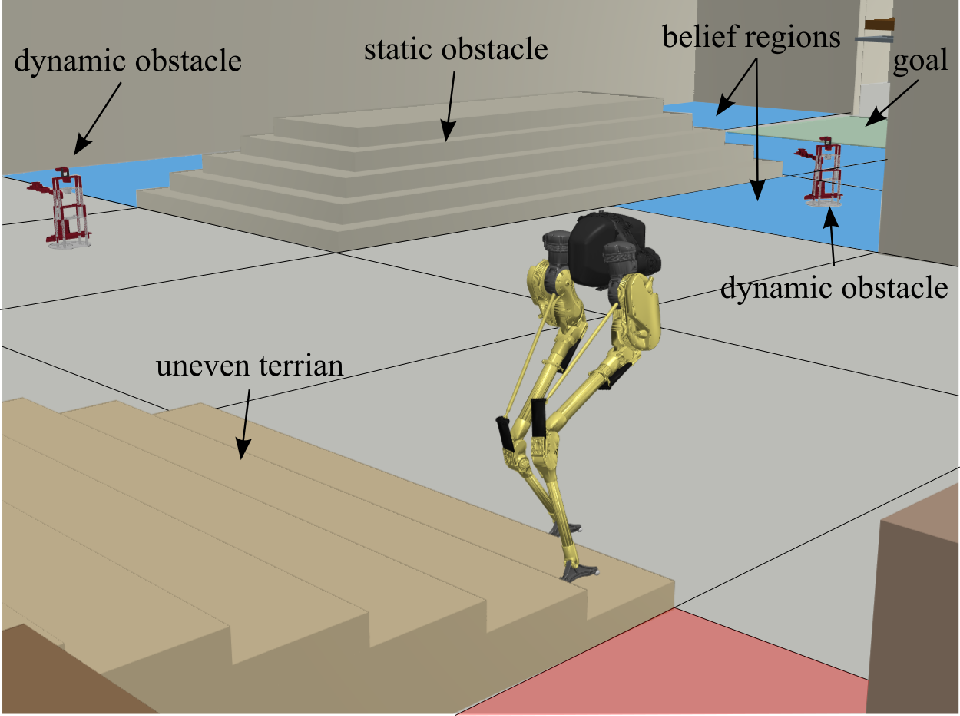
Figure 1.1 from SAFETY-GUARANTEED TASK PLANNING FOR BIPEDAL NAVIGATION ...
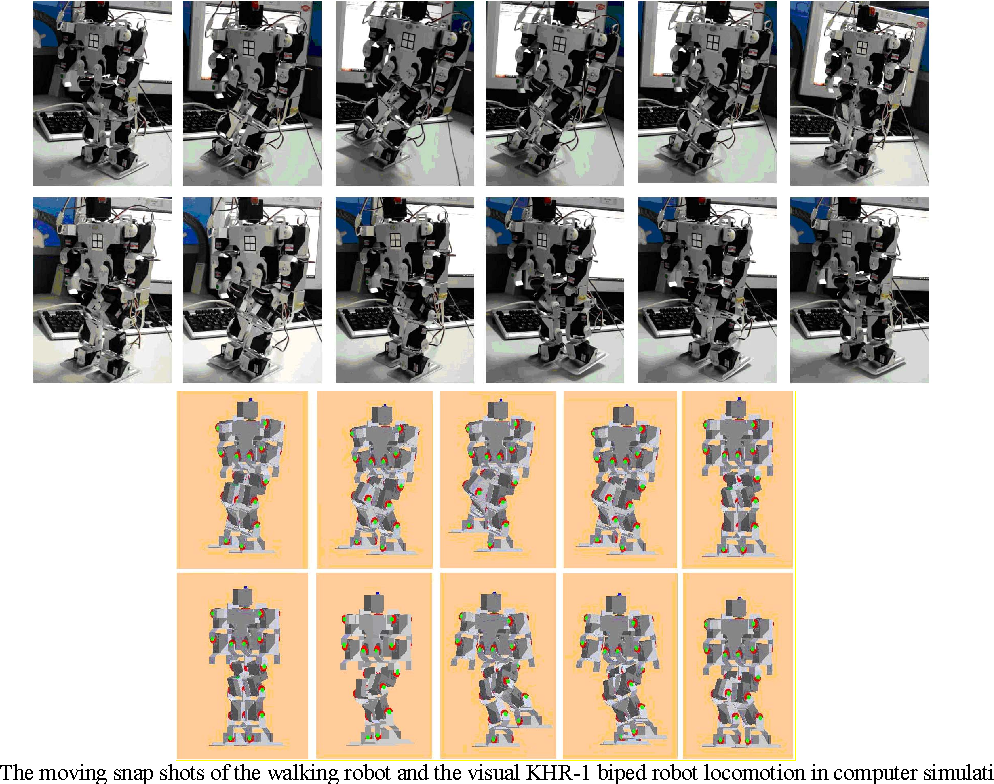
Figure 10 from Investigation on gait pattern planning and dynamic ...
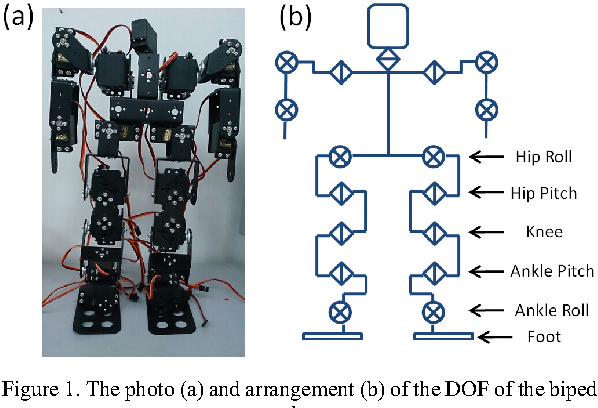
Figure 1 from Research on Gait Planning and Inverse Kinematics Solving ...

Figure 1 from Planning walking patterns for a biped robot | Semantic ...
Advertisement Space (336x280)
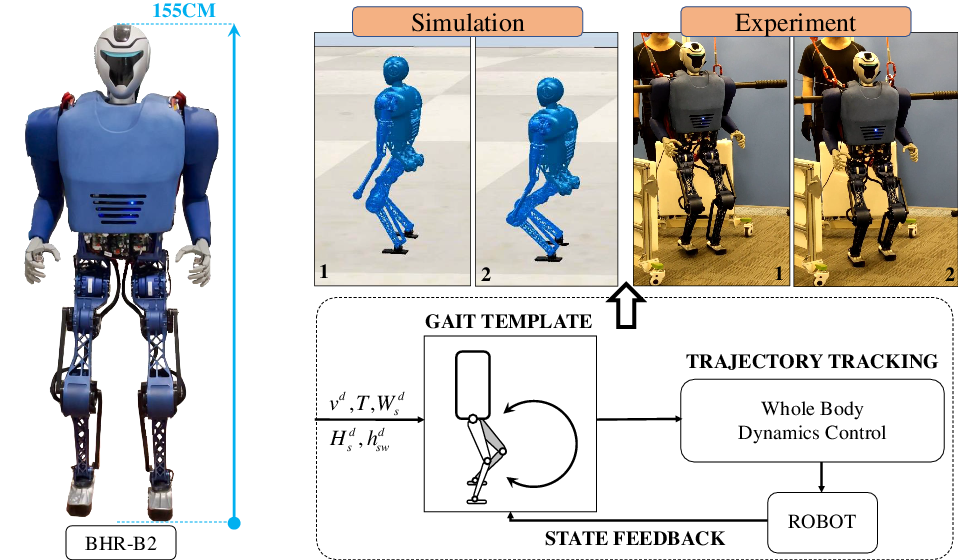
A heuristic gait template planning and dynamic motion control for biped ...

Figure 2 from Planar Bipedal Locomotion with Nonlinear Model Predictive ...

Human-Inspired Gait and Jumping Motion Generation for Bipedal Robots ...

Bipedal walking pattern generation and control for humanoid robot with ...

Human-Inspired Gait and Jumping Motion Generation for Bipedal Robots ...
Realization of a Human-like Gait for a Bipedal Robot Based on Gait Analysis