
Figure 3 From Multi Vehicle Avoidance Using Nonlinear Branch And Bound
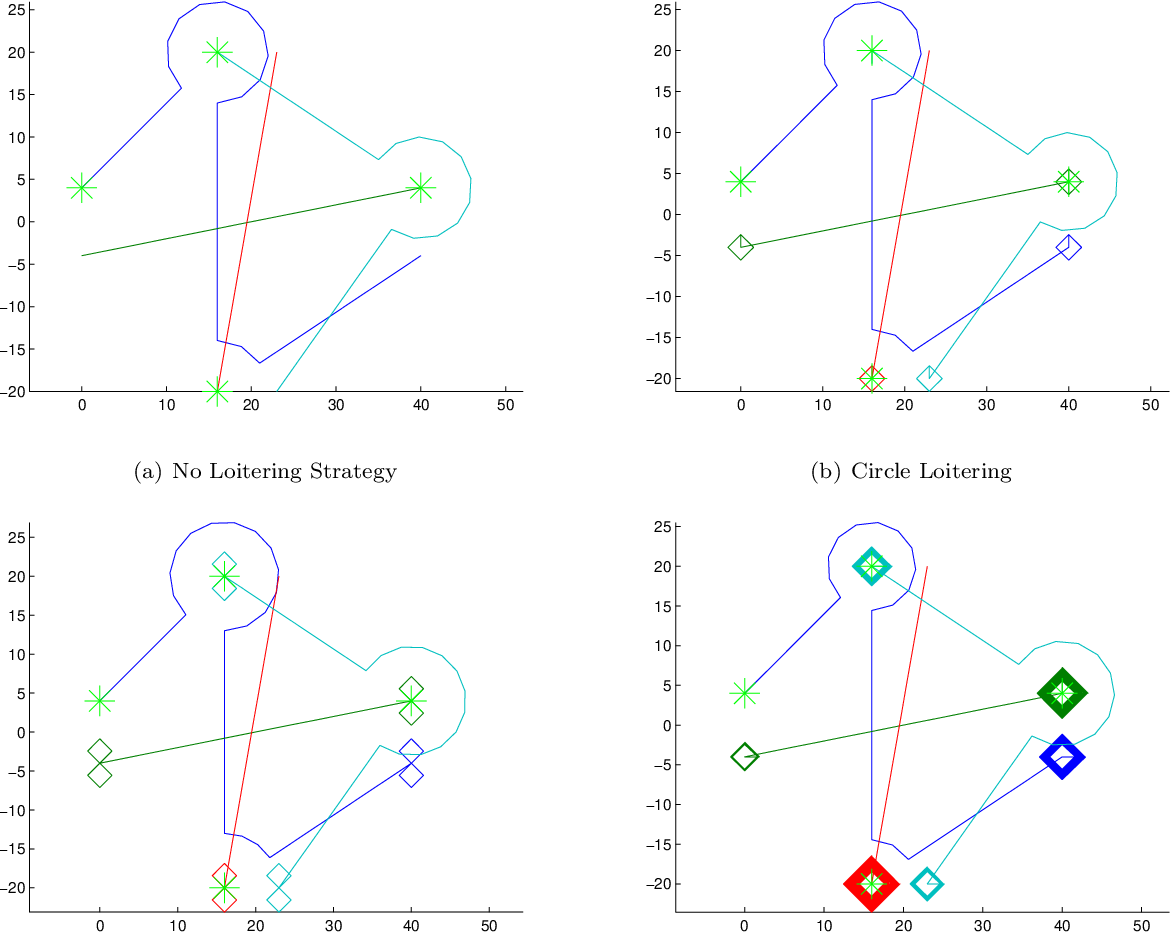
Figure 3 from Multi Vehicle Avoidance Using Nonlinear Branch and Bound ...
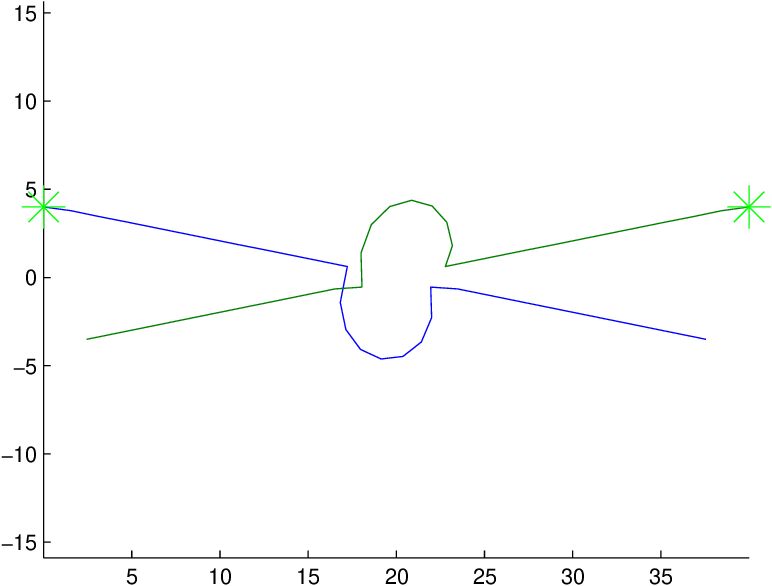
Figure 2 from Multi Vehicle Avoidance Using Nonlinear Branch and Bound ...

Figure 3 from Collision Avoidance using Iterative Dynamic and Nonlinear ...

Figure 3 from Dynamic Obstacles Avoidance Using Nonlinear Model ...

Figure 3 from Dynamic Obstacles Avoidance Using Nonlinear Model ...

Figure 3 from Collision Detection and Avoidance Using Intelligent ...
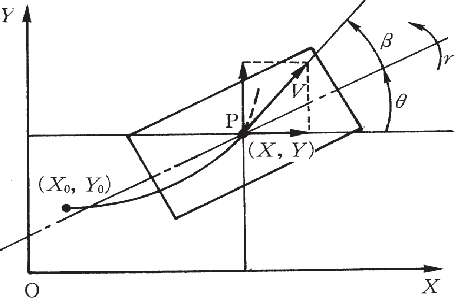
Figure 3 from Nonlinear model predictive control for vehicle collision ...

Figure 3 from Velocity Obstacle-Based Collision Avoidance and Motion ...

Figure 3 from Multiple-Target Surrounding and Collision Avoidance With ...
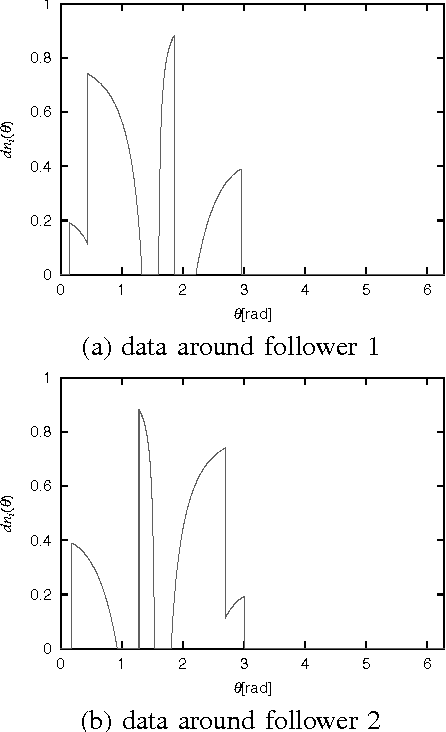
Figure 3 from Obstacle avoidance of a mobile robot group using a ...
Advertisement Space (300x250)

Figure 1 from Efficient Real-Time Obstacle Avoidance Using Multi ...

Figure 3 from A Detailed Study on Obstacle Detection and Avoidance ...
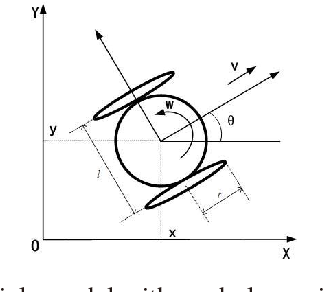
Figure 1 from Formation control and obstacle avoidance for multi ...

Figure 3 from Dynamic Collision Avoidance Using Velocity Obstacle-Based ...

Figure 3 from Nonlinear Model Predictive Control for Multi-Micro Aerial ...

Figure 3 from Interaction-Aware Vehicle Motion Planning with Collision ...
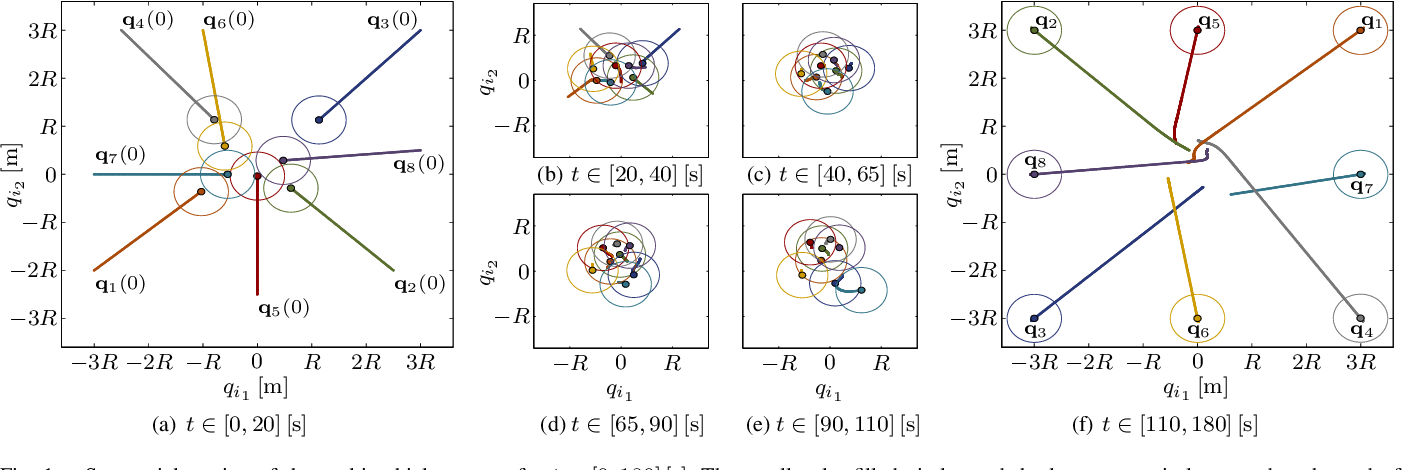
Figure 1 from Self-triggered collision avoidance control for multi ...

Figure 3 from An Obstacle Avoidance Algorithm for Unmanned Surface ...
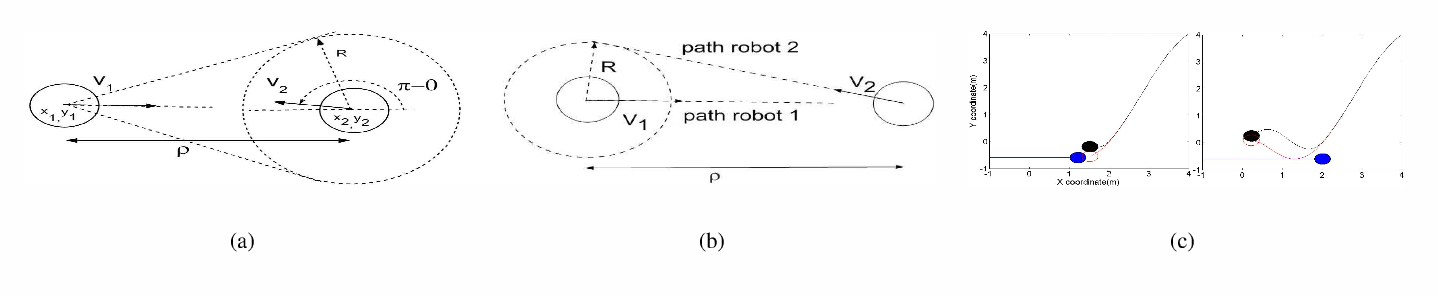
Figure 3 from Reactive collision avoidance for multiple robots by non ...
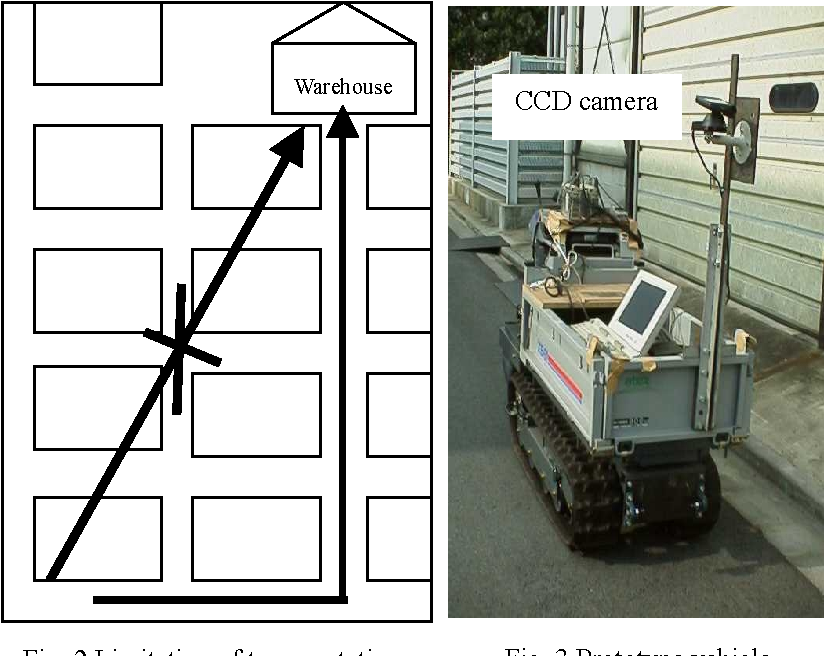
Figure 3 from Obstacle Avoidance System for Autonomous Transportation ...
Advertisement Space (336x280)

Figure 2 from Intelligent vehicle obstacle avoidance path-tracking ...
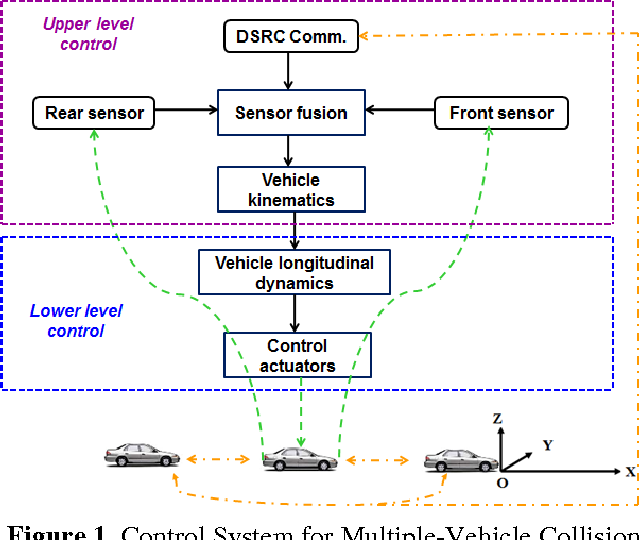
Figure 1 from Multiple-vehicle longitudinal collision avoidance and ...

Figure 3 from Obstacle Avoidance Path Design for Autonomous Vehicles ...

Figure 3 from A Multi-Vehicle Longitudinal Trajectory Collision ...

Multiple vehicle cooperation and collision avoidance in automated ...
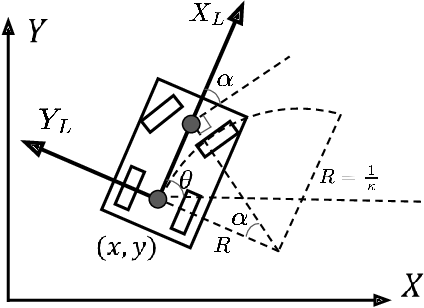
Figure 2 from Optimal Vehicle Trajectory Planning for Static Obstacle ...
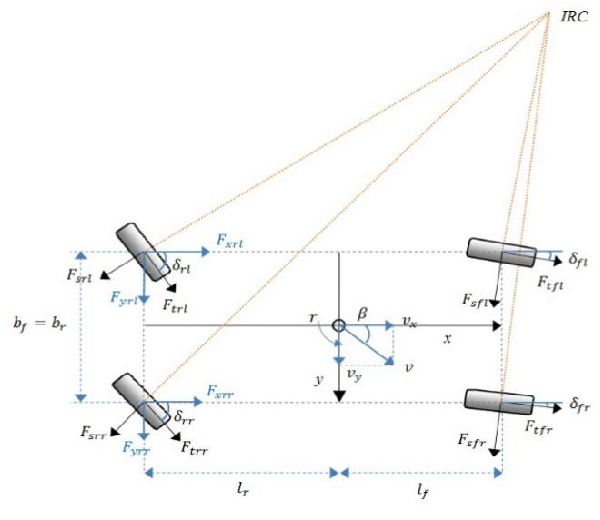
Figure 1 from Integrated trajectory planning and control for obstacle ...

Figure 3 from Experimental testing of a semi-autonomous multi-vehicle ...

Figure 3 from Learning Behaviours for Decentralised Multi-Robot ...
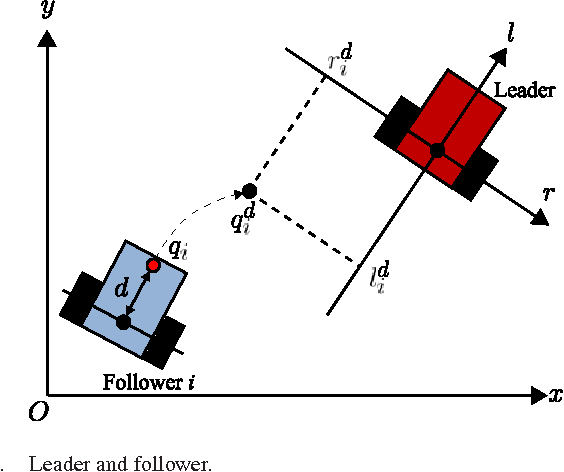
Figure 1 from Model Predictive Formation Control Using Branch-and-Bound ...
Advertisement Space (336x280)
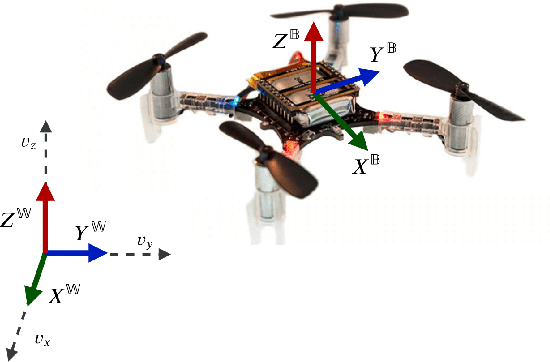
Figure 1 from Collision Avoidance for Multiple Micro Aerial Vehicles ...

Figure 1 from Extended Kalman Filtering-Based Nonlinear Model ...

Comparison of nonlinear MPC Controller with and without DRO for vehicle ...
Linear constraint modelling of obstacle avoidance and vehicle ...

Multiple vehicle cooperation and collision avoidance in automated ...
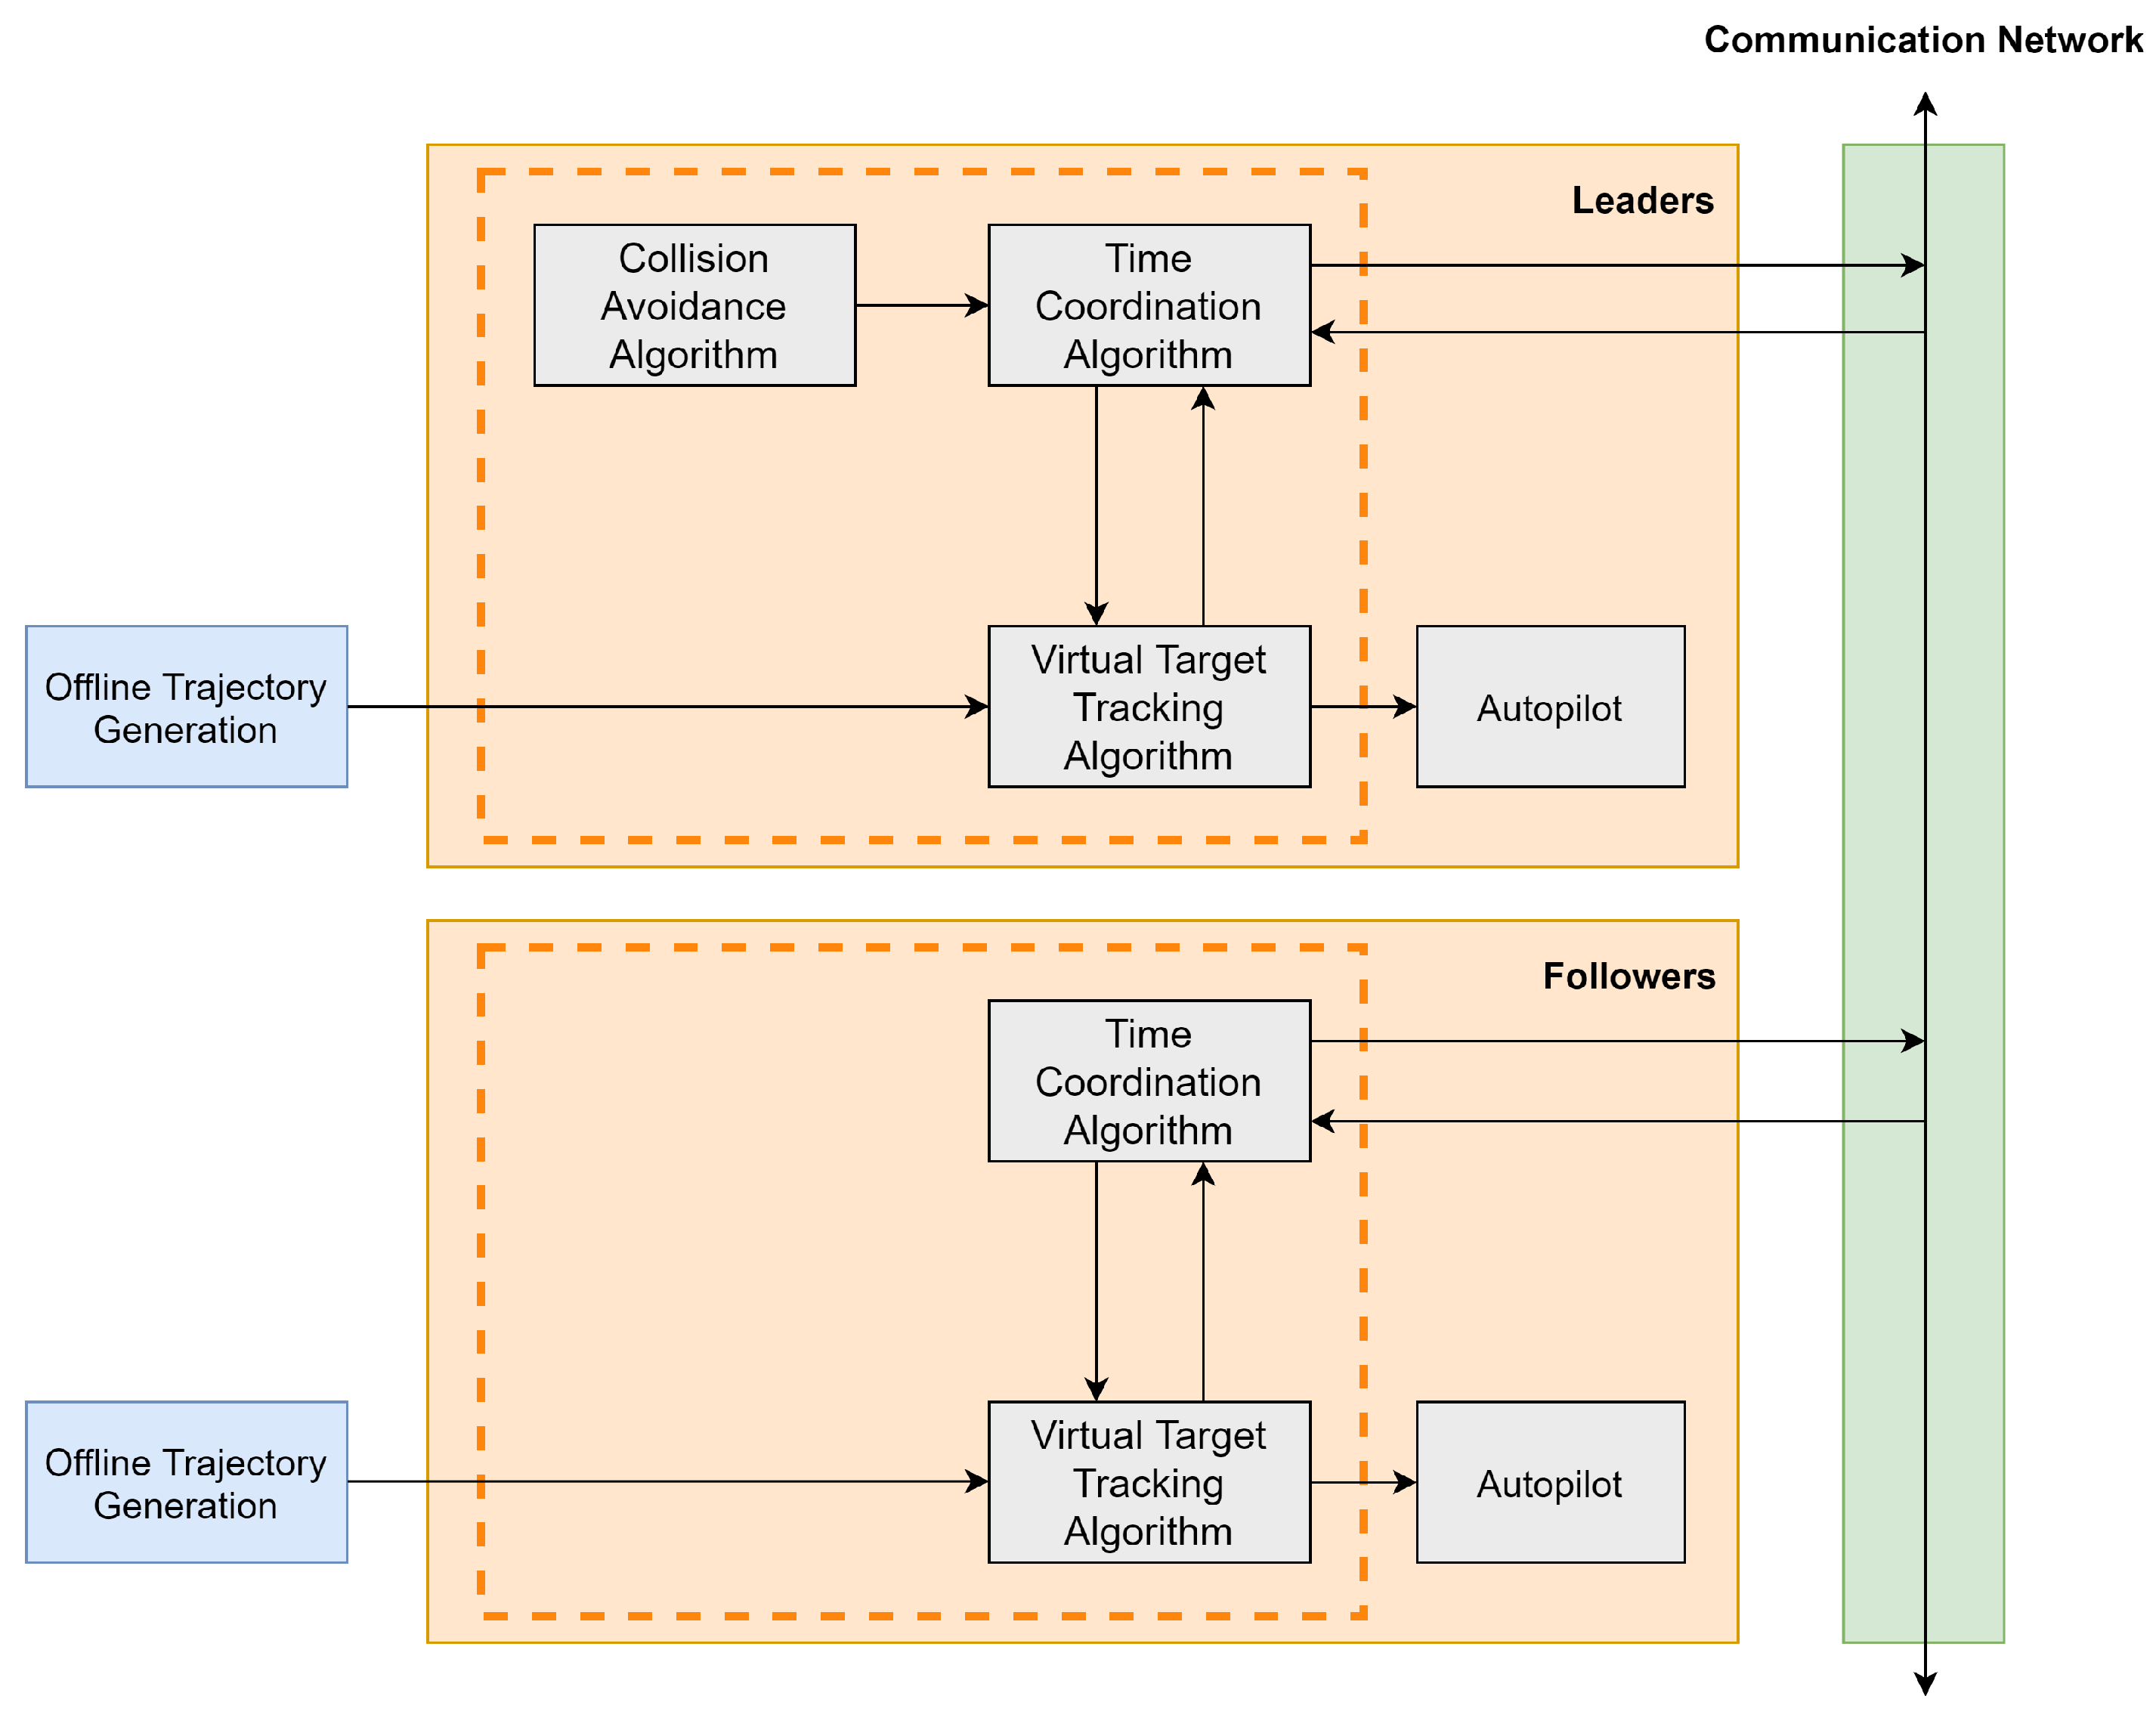
Time Coordination and Collision Avoidance Using Leader-Follower ...