
Figure 4 From Counting Objects In A Robotic Hand Semantic Scholar
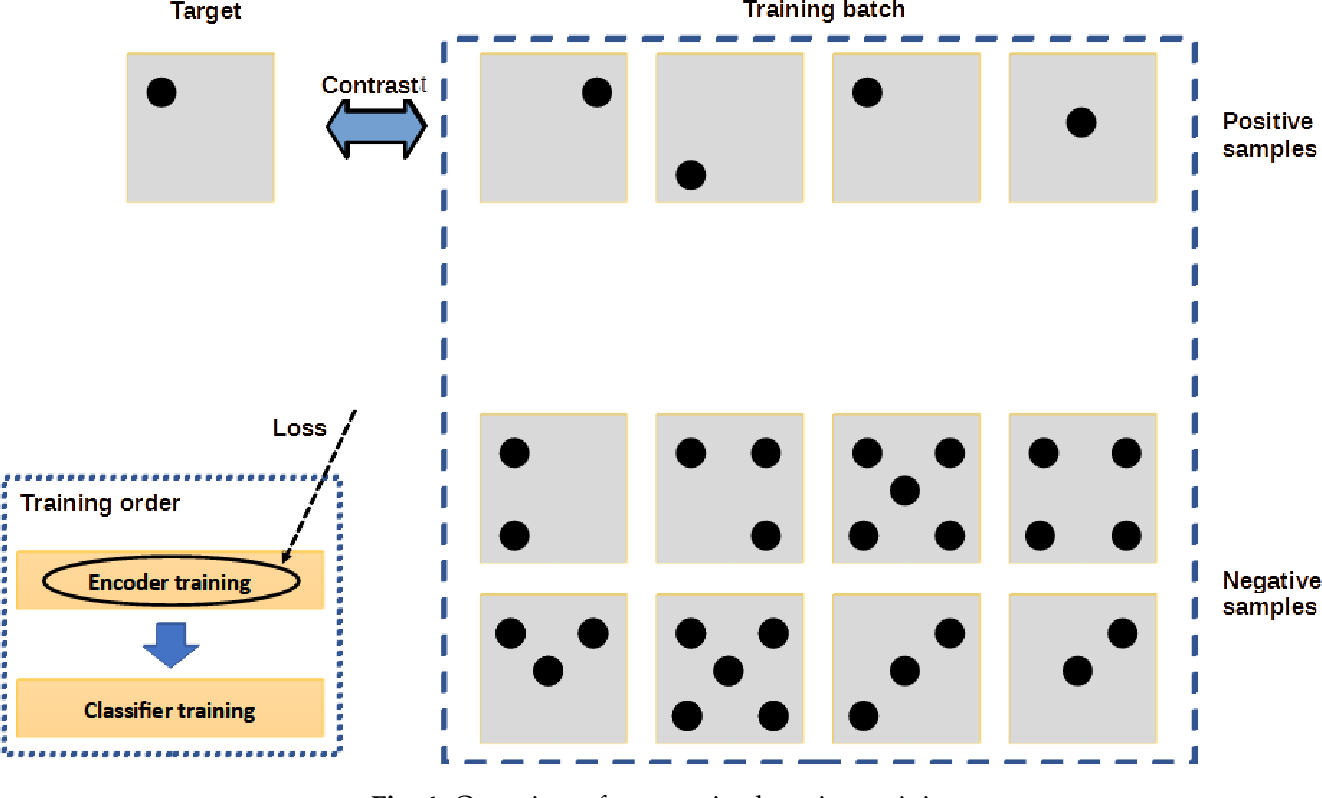
Figure 4 from Counting Objects in a Robotic Hand | Semantic Scholar

Figure 5 from Counting Objects in a Robotic Hand | Semantic Scholar

Figure 3 from Counting Objects in a Robotic Hand | Semantic Scholar

Figure 2 from Counting Objects in a Robotic Hand | Semantic Scholar
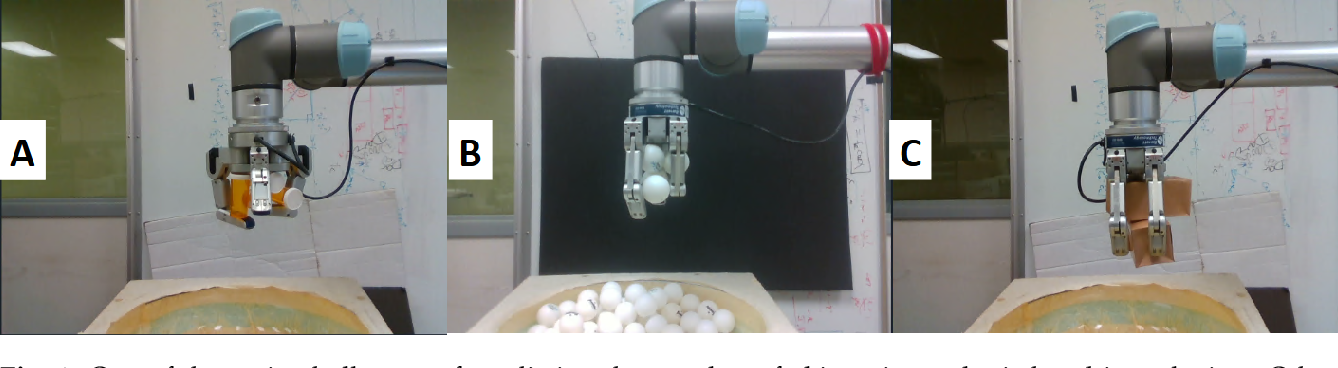
Figure 1 from Counting Objects in a Robotic Hand | Semantic Scholar

Table 4 from Counting Objects in a Robotic Hand | Semantic Scholar

Figure 6 from Counting Objects in a Robotic Hand | Semantic Scholar

Table 2 from Counting Objects in a Robotic Hand | Semantic Scholar
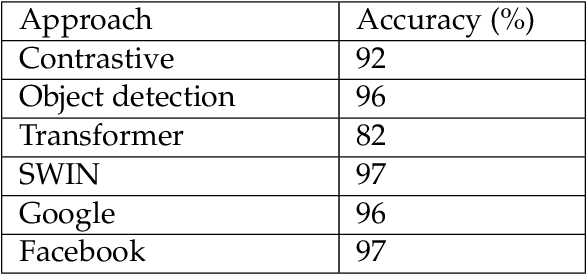
Table 3 from Counting Objects in a Robotic Hand | Semantic Scholar
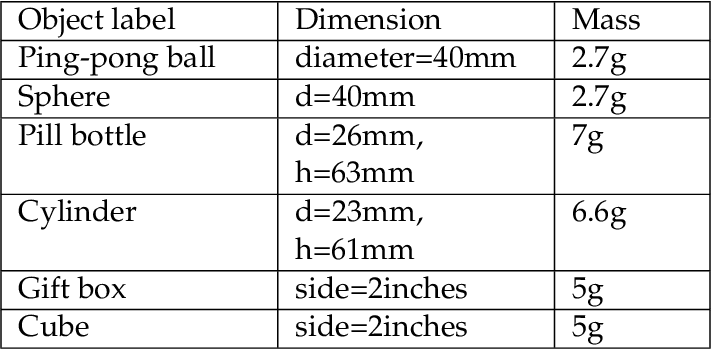
Table 1 from Counting Objects in a Robotic Hand | Semantic Scholar
Advertisement Space (300x250)
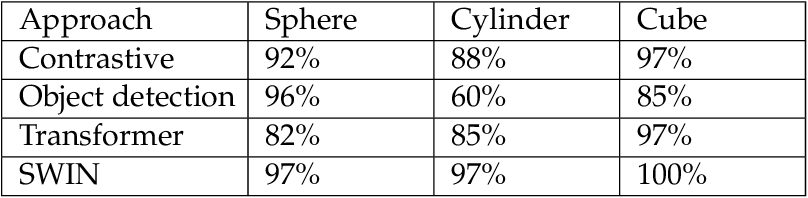
Table 5 from Counting Objects in a Robotic Hand | Semantic Scholar
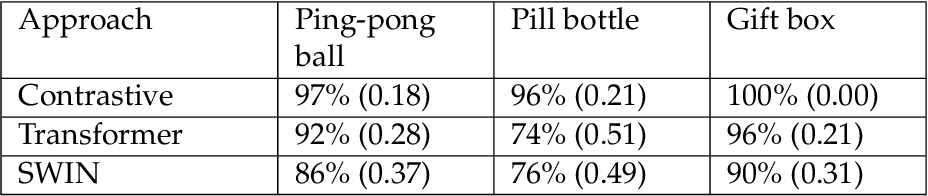
Table 7 from Counting Objects in a Robotic Hand | Semantic Scholar

Figure 4 from A Dual-Mode Actuator for Soft Robotic Hand | Semantic Scholar

Figure 4 from Grasp Multiple Objects With One Hand | Semantic Scholar
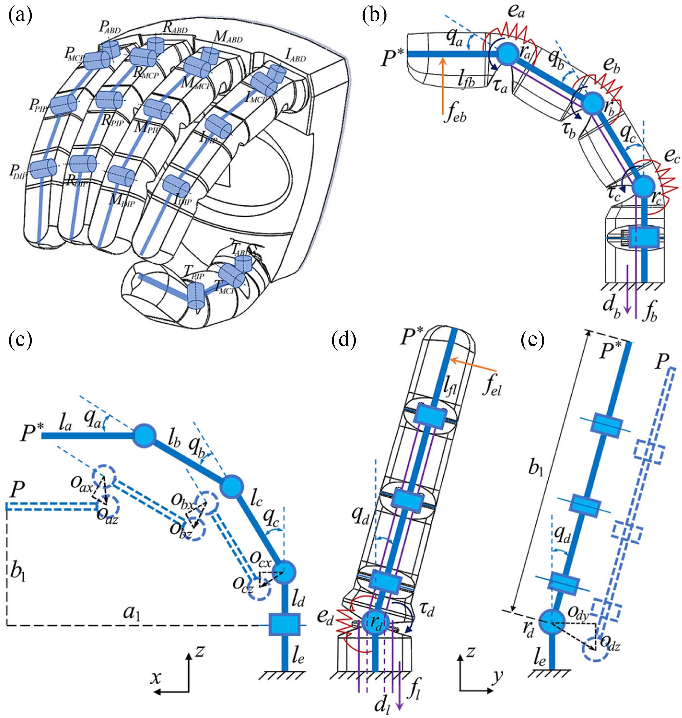
Figure 4 from A Cable-Driven Soft Robotic Hand With an In-Hand RGB-D ...
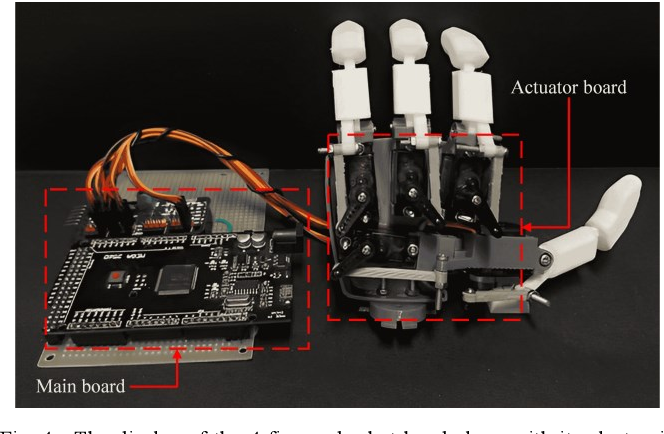
Figure 4 from Design and Experiment of a Four-Fingered Robotic Hand for ...

Figure 4 from A drawing robotic hand based on inverse kinematics ...

Figure 4 from Hand Gesture Recognition using OpenCV | Semantic Scholar
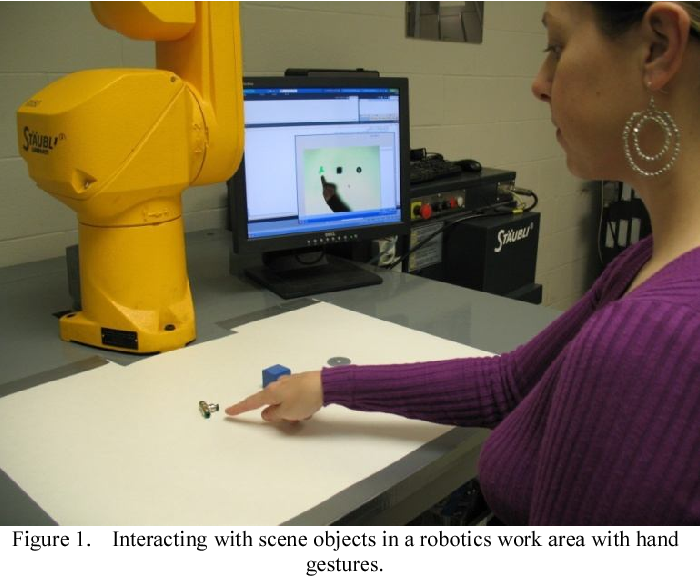
Figure 1 from Visual detection of objects in a robotic work area using ...

Figure 4 from Robotic pick-and-place of novel objects in clutter with ...
Advertisement Space (336x280)
Figure 4 from Hands in the Real World | Semantic Scholar
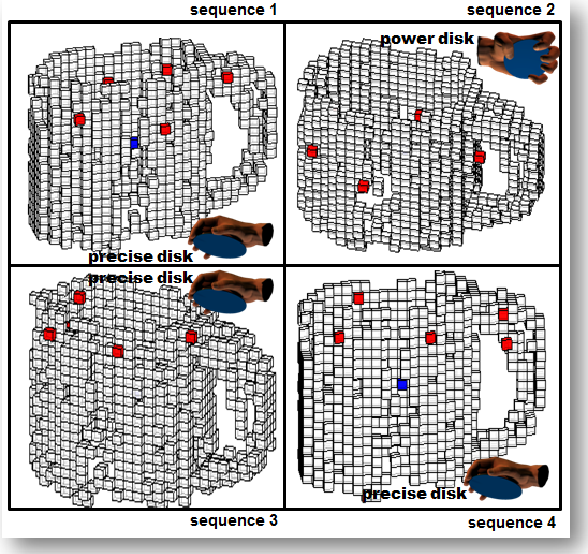
Figure 4 from Identifying objects from hand configurations during in ...
Figure 1 from 3D Printed Robotic Arm using Hand Gestures | Semantic Scholar

Figure 4 from Implementation of a Wireless Human Hand Gesture ...
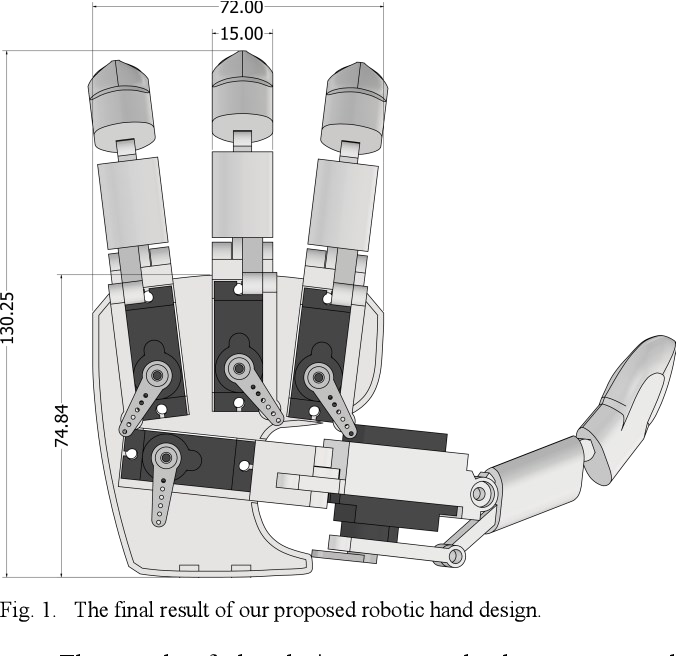
Figure 1 from Design and Experiment of a Four-Fingered Robotic Hand for ...

Figure 1 from A Modular Bio-inspired Robotic Hand with High Sensitivity ...

Figure 16 from Design and Building of a Multi-finger Robotic Hand ...

Figure 4 from DESIGN AND ANALYSIS OF MULTI-FINGER ROBOTIC HAND ...

Figure 3 from The KIT Robotic Hands – A Scalable Humanoid Hand Platform ...
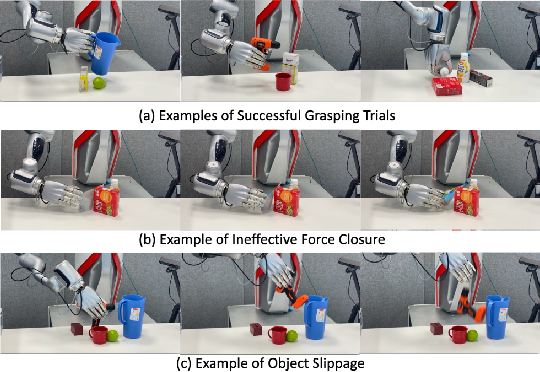
Figure 10 from ContactDexNet: Multi-fingered Robotic Hand Grasping in ...
Advertisement Space (336x280)

Figure 1 from A Wearable Robotic Hand for Hand-over-Hand Imitation ...

Figure 11 from RoboRay hand: A highly backdrivable robotic hand with ...
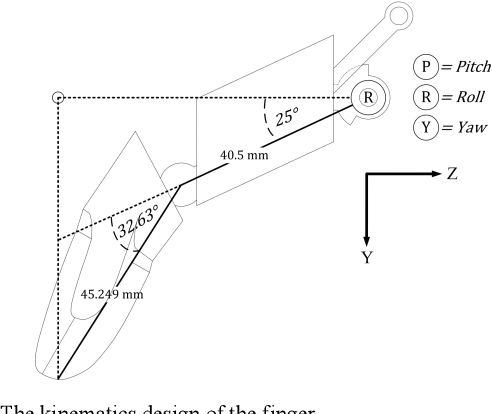
Figure 5 from Design and Experiment of a Four-Fingered Robotic Hand for ...
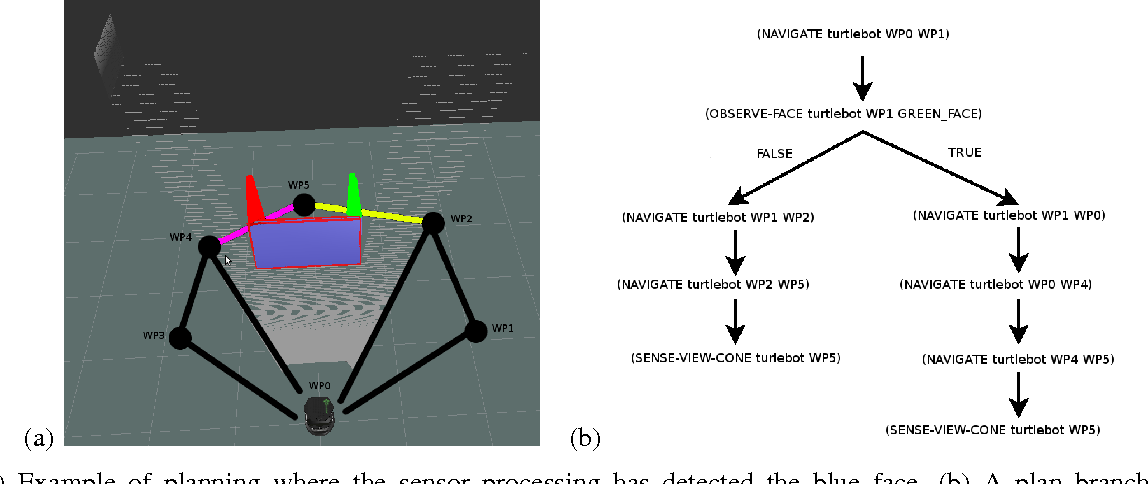
Figure 4 from Efficient Search for Known Objects in Unknown Environments ...

Figure 5 from Four Gesture Recognization of a Robotic Hand using EMG ...

Figure 1 from Modelling and simulation of a multi-fingered robotic hand ...