
Figure 4 From Posture Adaptive Control Of Multi Wheel Legged Robot In

Figure 4 from Posture Adaptive Control of Multi-Wheel-Legged Robot in ...

Figure 1 from Posture Adaptive Control of Multi-Wheel-Legged Robot in ...
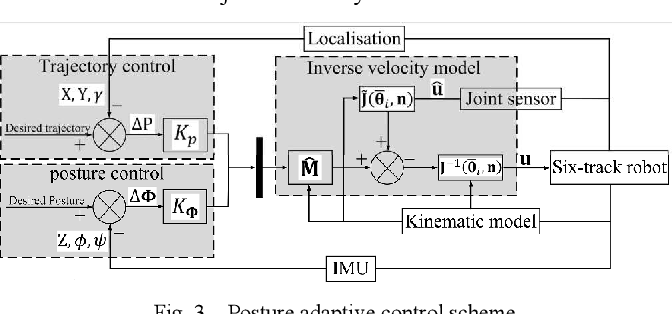
Figure 3 from Posture Adaptive Control of Multi-Wheel-Legged Robot in ...

Figure 1 from Posture Adaptive Control of Multi-Wheel-Legged Robot in ...
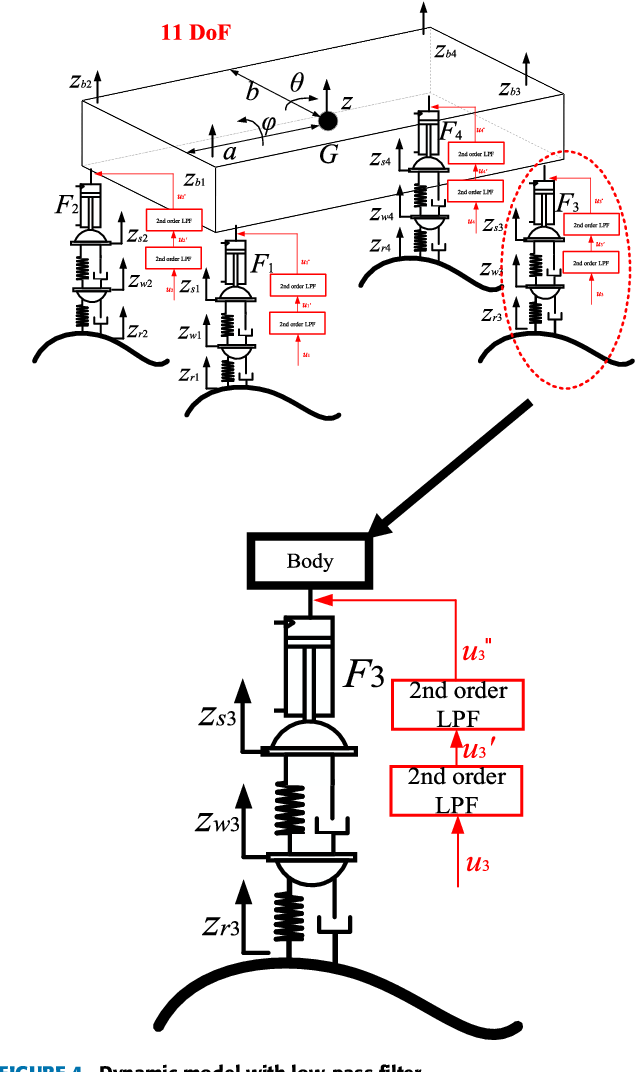
Figure 4 from Posture Control of a Four-Wheel-Legged Robot With a ...
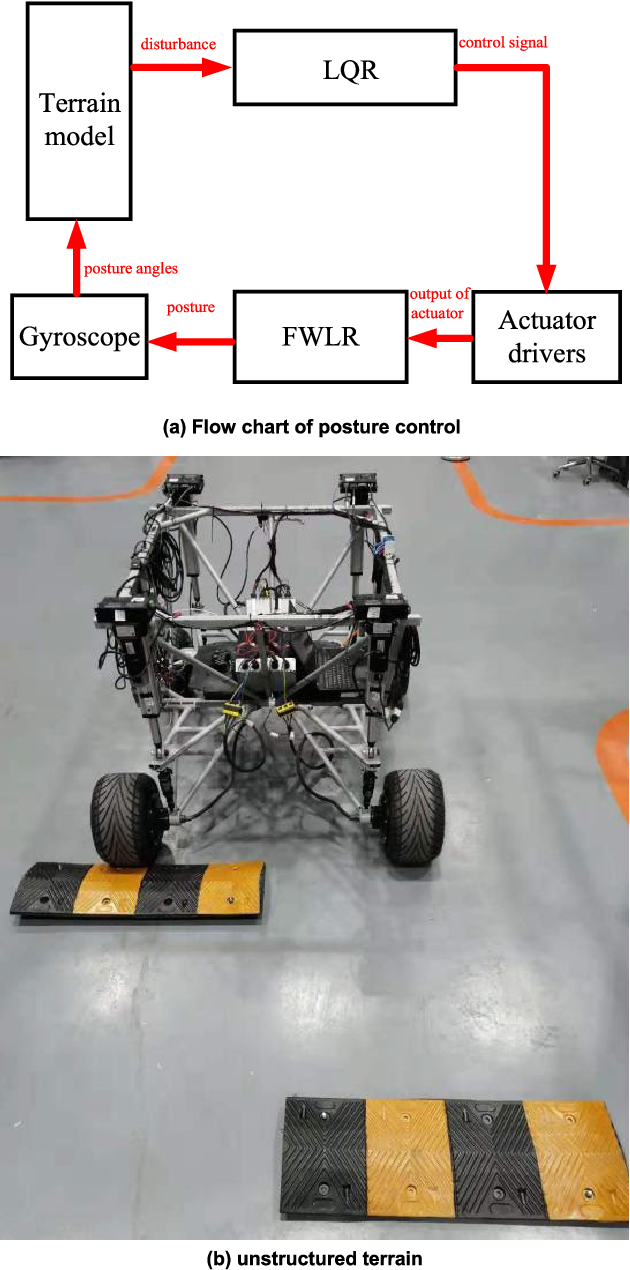
Figure 10 from Posture Control of a Four-Wheel-Legged Robot With a ...
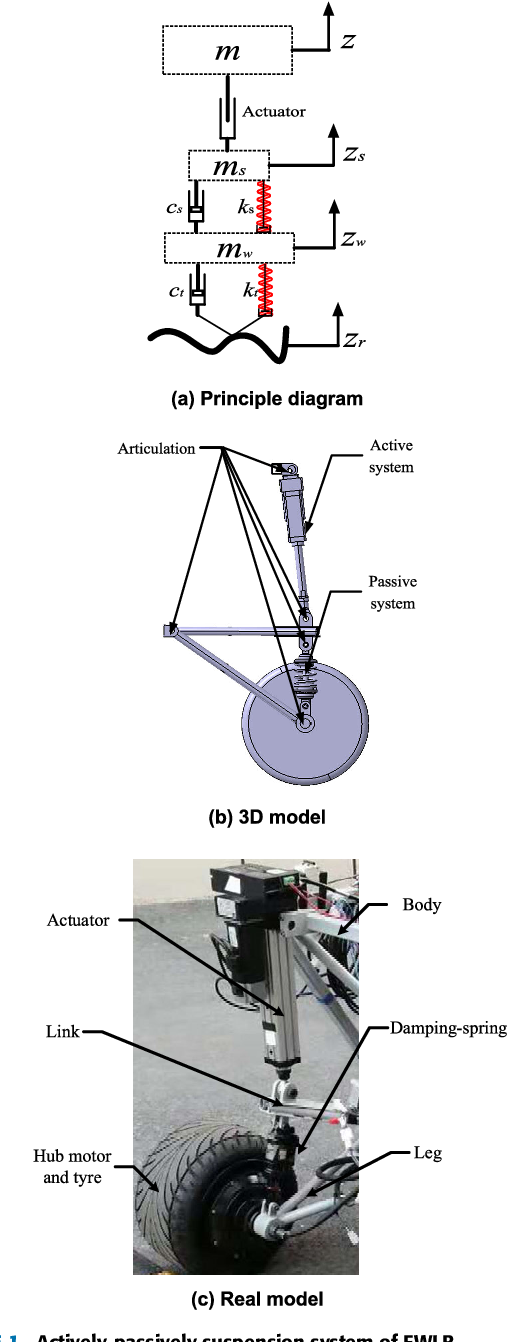
Figure 1 from Posture Control of a Four-Wheel-Legged Robot With a ...
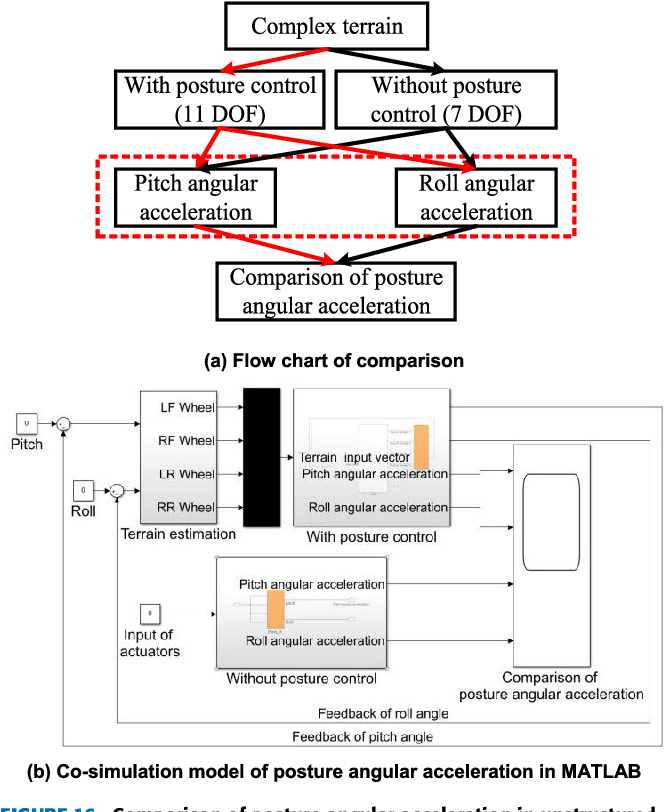
Figure 16 from Posture Control of a Four-Wheel-Legged Robot With a ...
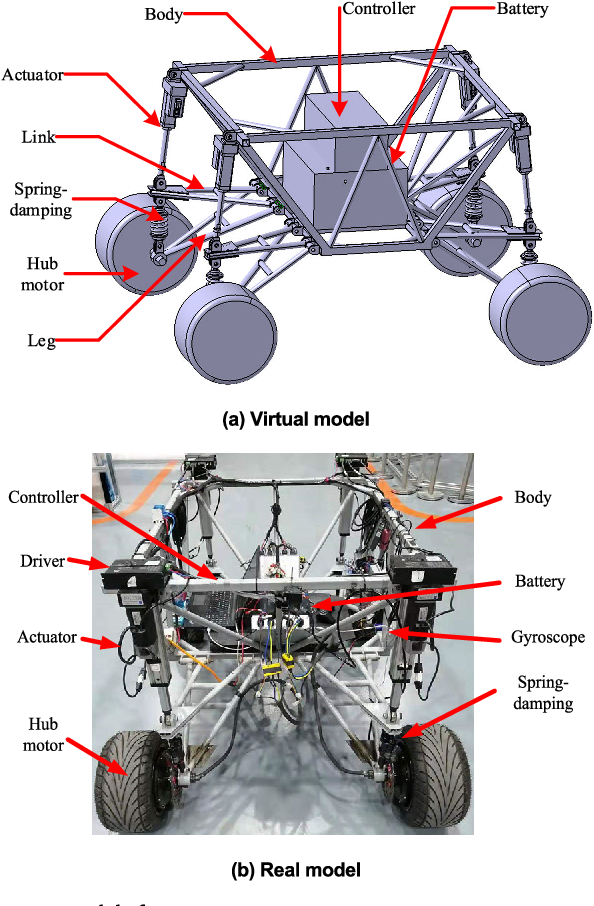
Figure 2 from Posture Control of a Four-Wheel-Legged Robot With a ...
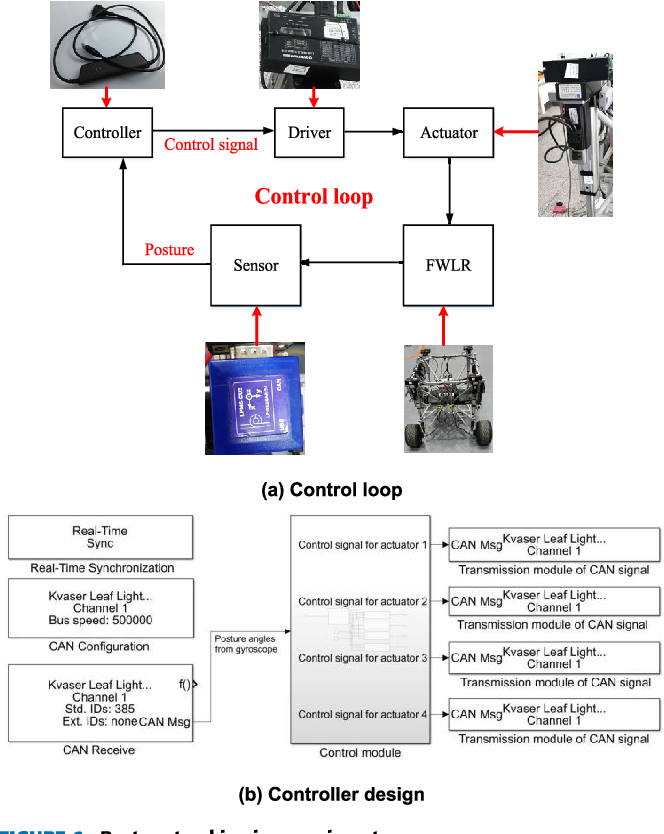
Figure 6 from Posture Control of a Four-Wheel-Legged Robot With a ...
Advertisement Space (300x250)
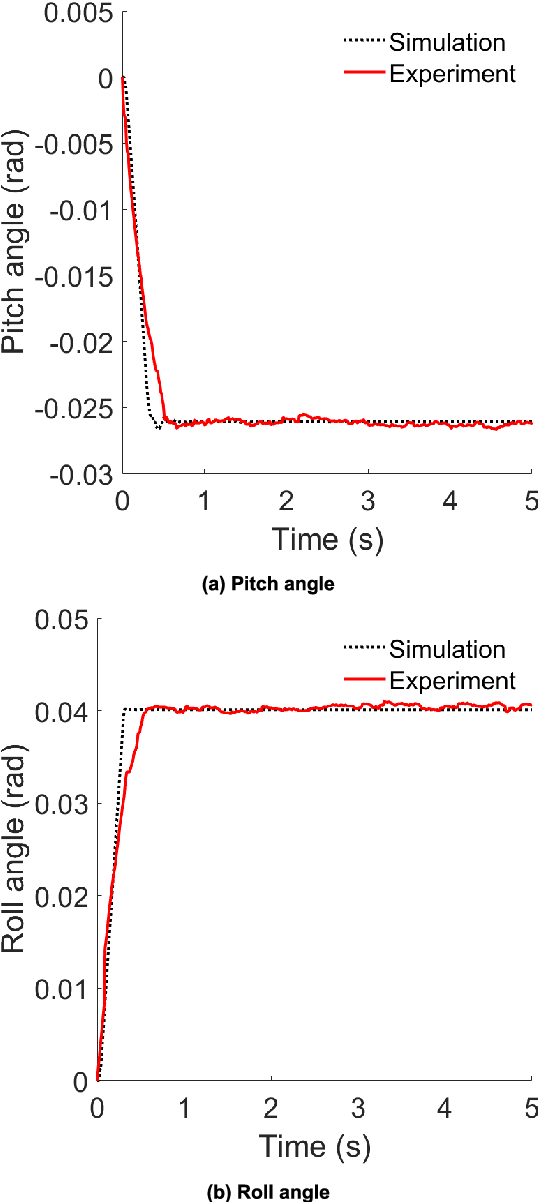
Figure 7 from Posture Control of a Four-Wheel-Legged Robot With a ...

Figure 4 from Learning Complex Motor Skills for Legged Robot Fall ...

Figure 1 from Idea of wheel-legged robot and its control system design ...
Figure 1 from An Adaptive Approach to Whole-Body Balance Control of ...
Figure 3 from Design and Control of Multi-mode Wheeled-Bipedal Robot ...

Figure 5 from Adaptive Motion Control of a Terrain-Adaptive Self ...

Figure 4 from Design of an Impact-resistant Elbow Mechanism for Wheel ...

Figure 4 from A Bipedal Wheel-Legged Robot with Improved Balancing and ...

Research on Motion Control Method of Wheel-Legged Robot in Unstructured ...

Figure 2 from Adaptive optimal output regulation for wheel-legged robot ...
Advertisement Space (336x280)
Figure 1 from Learning Adaptive Escape Behavior for Wheel-Legged Robot ...

Figure 7 from Design of an Impact-resistant Elbow Mechanism for Wheel ...

Figure 6 from Study on multi-legged walking robot in Huazhong ...

(PDF) Posture Control of a Four-Wheel-Legged Robot With a Suspension System

Figure 1 from Balance Control of a Novel Wheel-legged Robot: Design and ...

Figure 1 from A New Augmented L1 Adaptive Control for Wheel-Legged ...

(PDF) Posture Control of a Four-Wheel-Legged Robot With a Suspension System

Figure 1 from Development of terrain adaptive sole for multi-legged ...
Figure 4 from Modelling and Experimental Analysis for a two legged ...
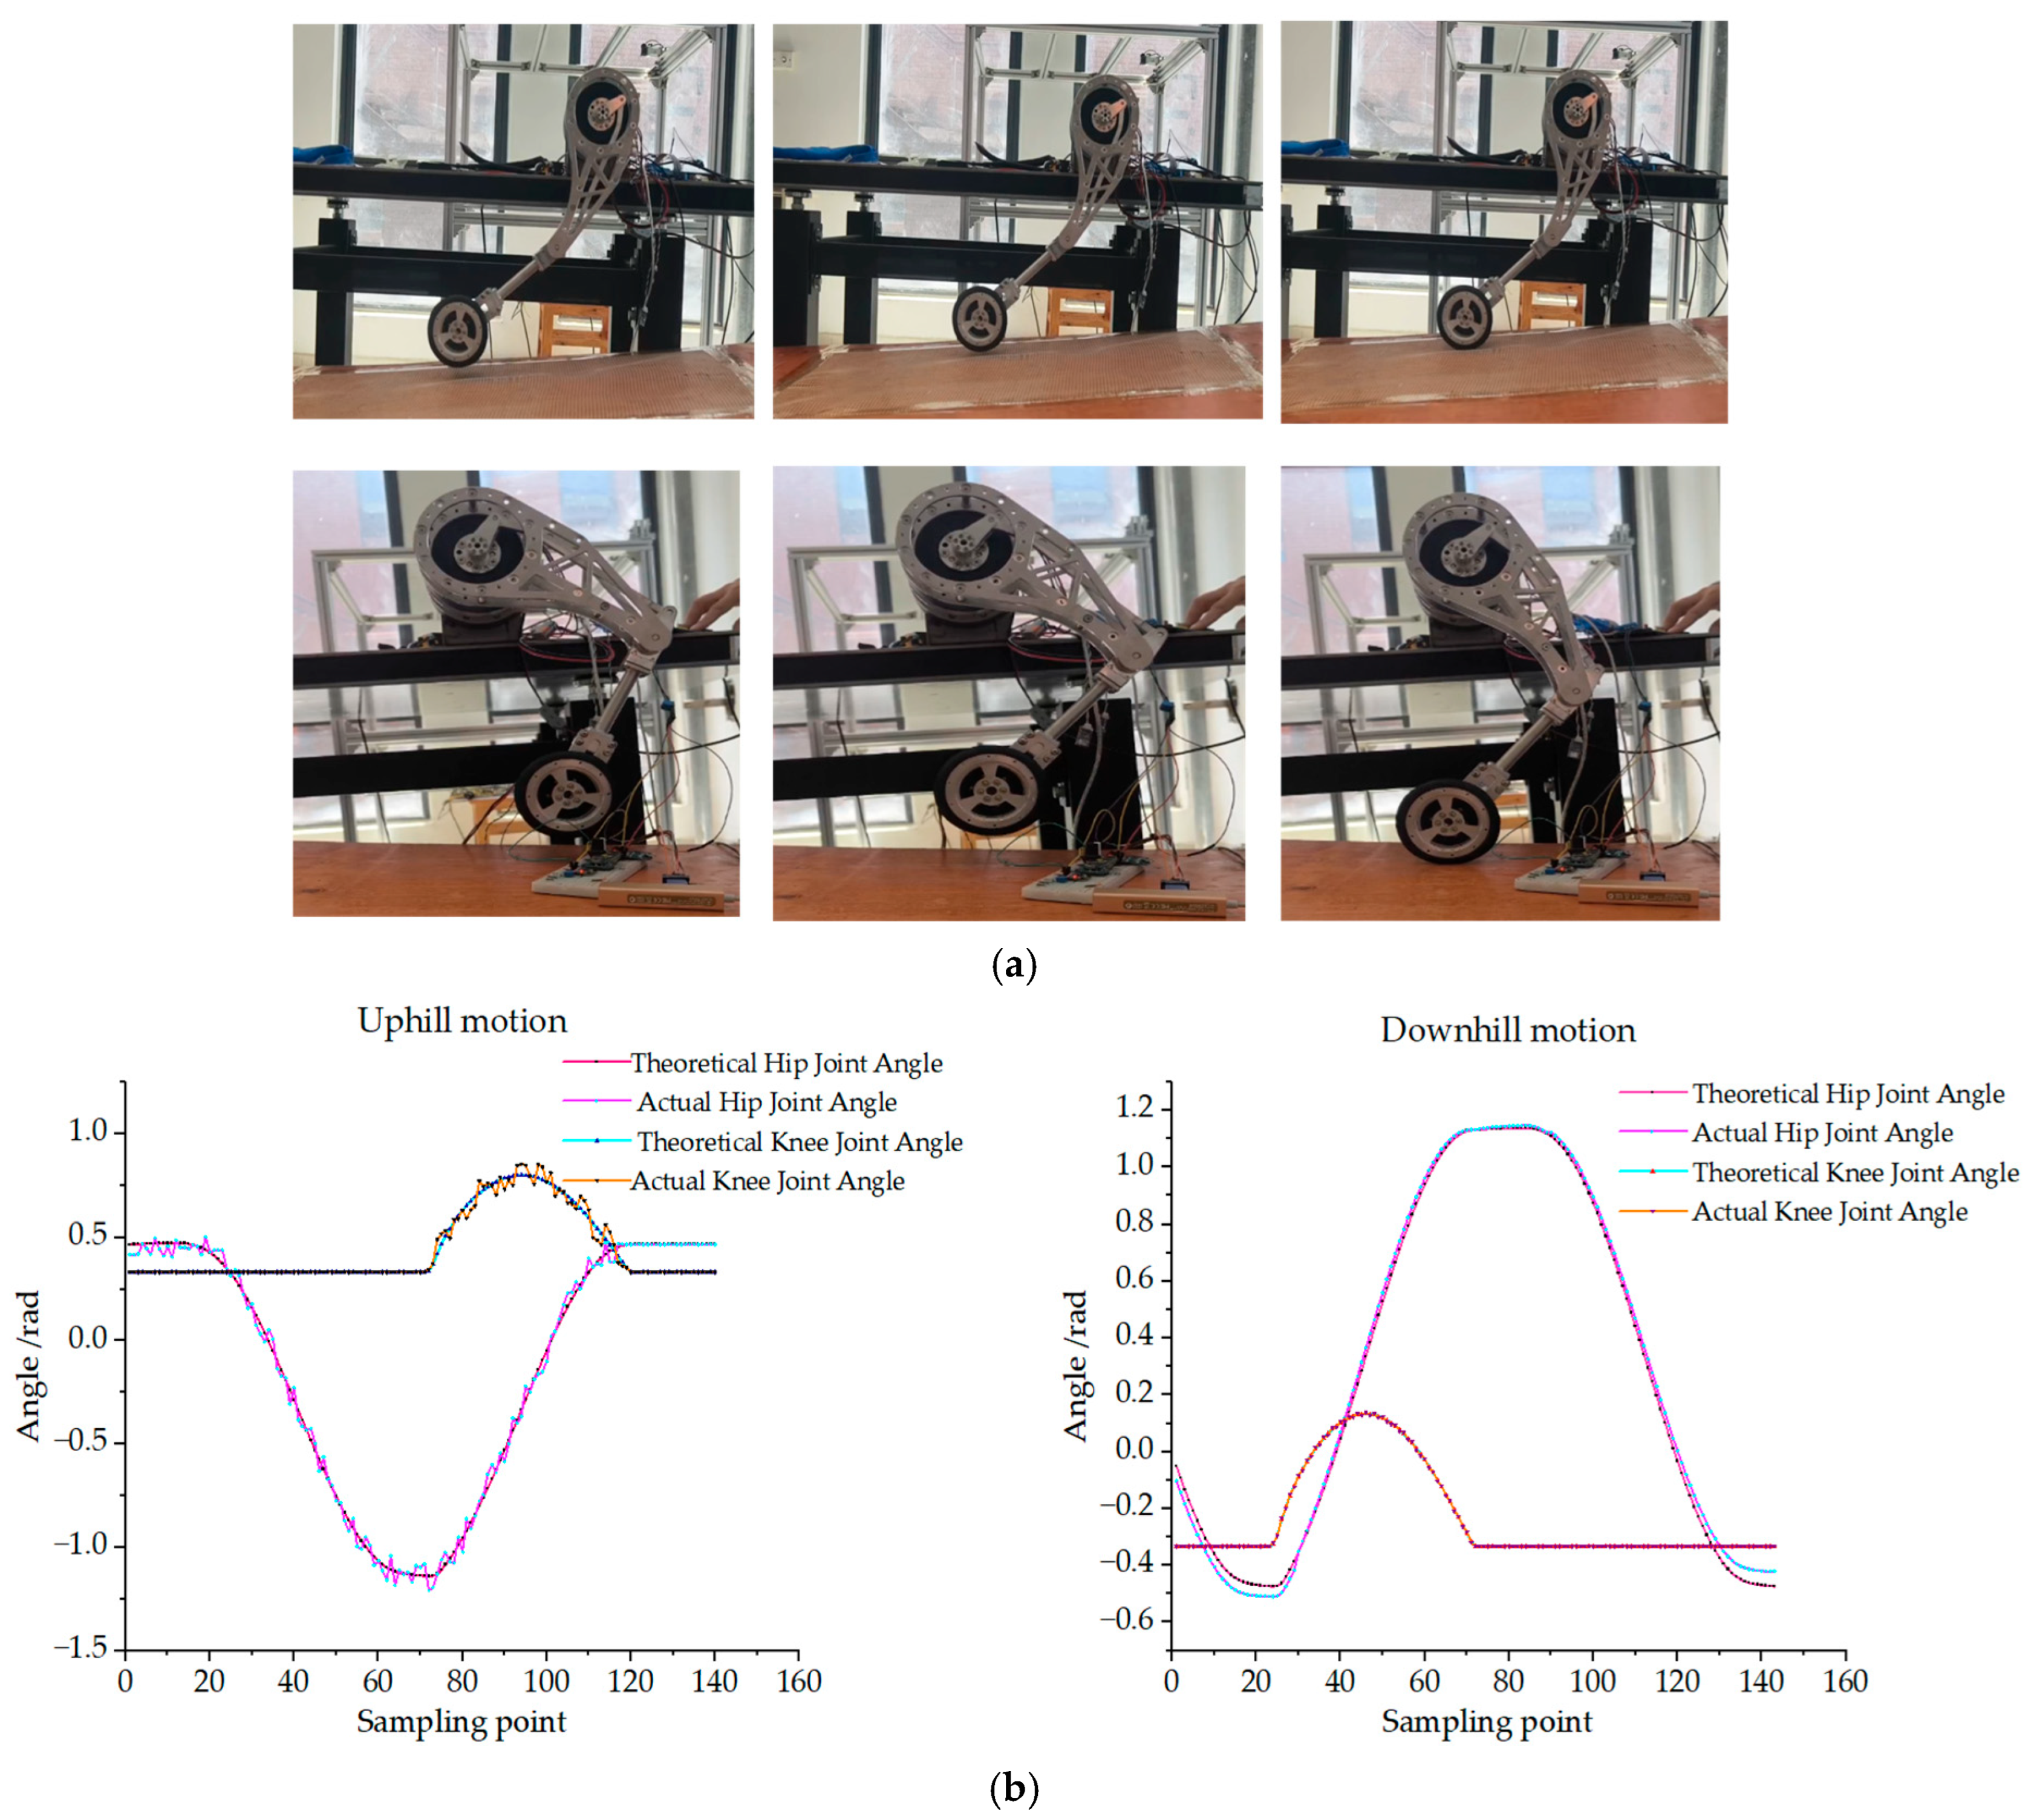
Research on Motion Control Method of Wheel-Legged Robot in Unstructured ...
Advertisement Space (336x280)

Figure 2 from Modeling and Simulation of a Wheel-Leg Robot | Semantic ...

Figure 1 from The Wheel-legged Robot for Guanular Terrain: Guardian ...

Frontiers | Adaptive Control Strategies for Interlimb Coordination in ...

Posture Control in Four-Wheel-Legged Robots | PDF | Simulation | Computers

Design and Control of a High-Dynamic Modular Reconfigurable Legged ...
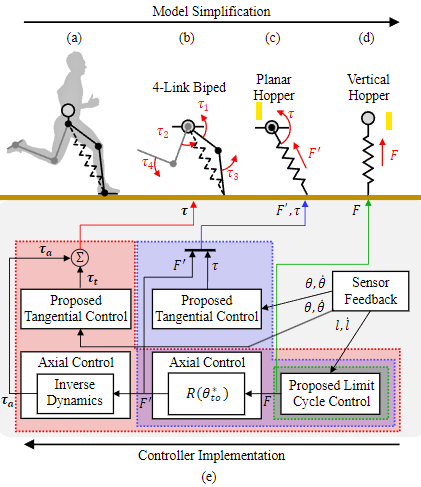
Legged Robot Control – BMT Lab, MAE, CUHK