
Figure 5 From Design And Gait Control Of A Quadruped Robot With Low
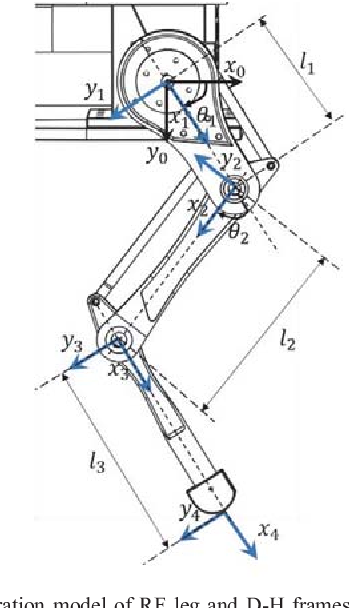
Figure 5 from Design and Gait Control of a Quadruped Robot with Low ...

Figure 2 from Design and Gait Control of a Quadruped Robot with Low ...
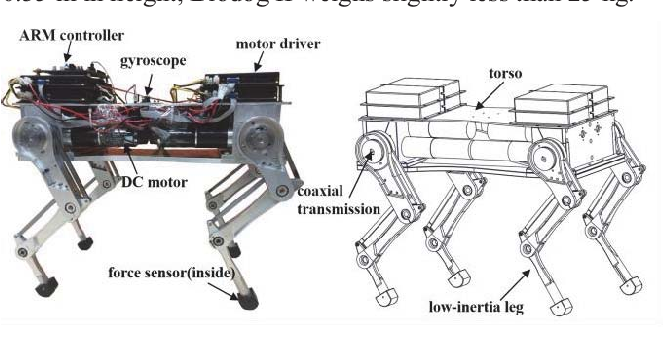
Figure 1 from Design and Gait Control of a Quadruped Robot with Low ...
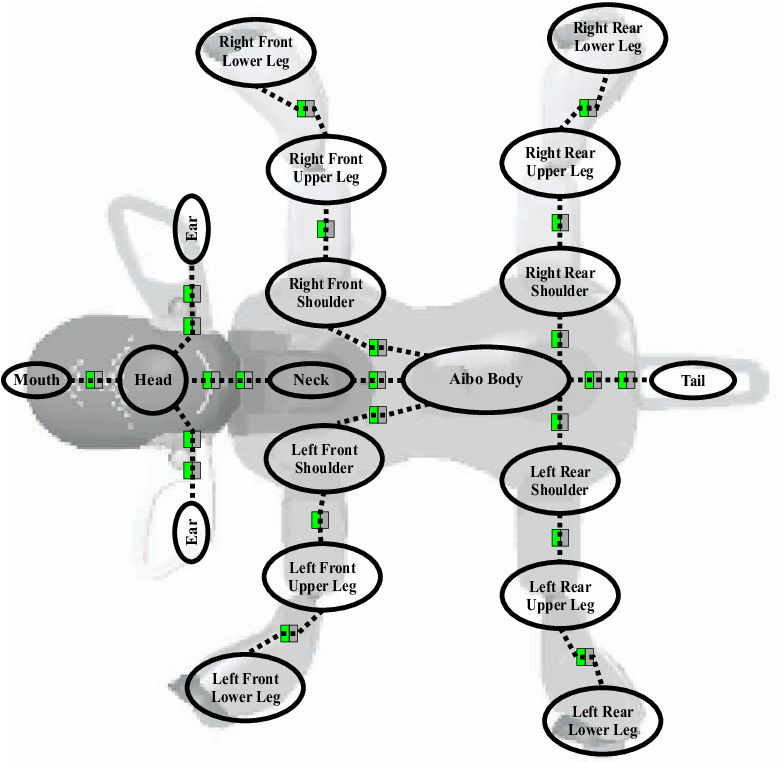
Figure 2.1 from Modeling and gait control of a quadruped robot ...

Figure 2 from Gait design and comparison study of a quadruped robot ...
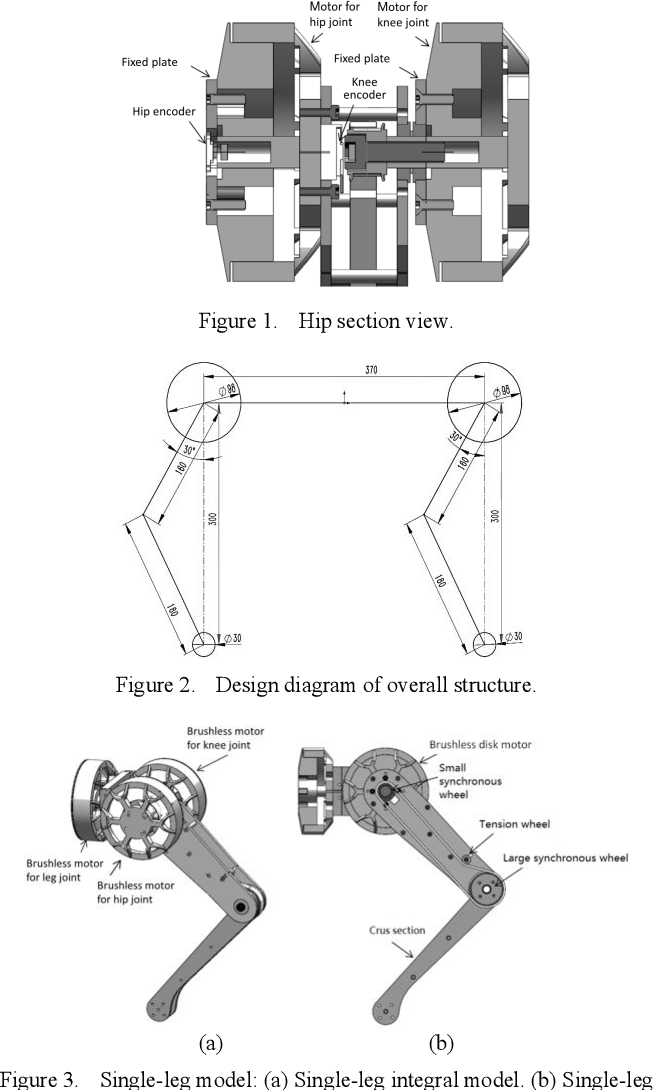
Figure 4 from Design and Gait Optimization of Quadruped Robot Based on ...

Figure 1 from Trajectory design and control of quadruped robot for ...

Figure 4 from Design and Gait Optimization of Quadruped Robot Based on ...
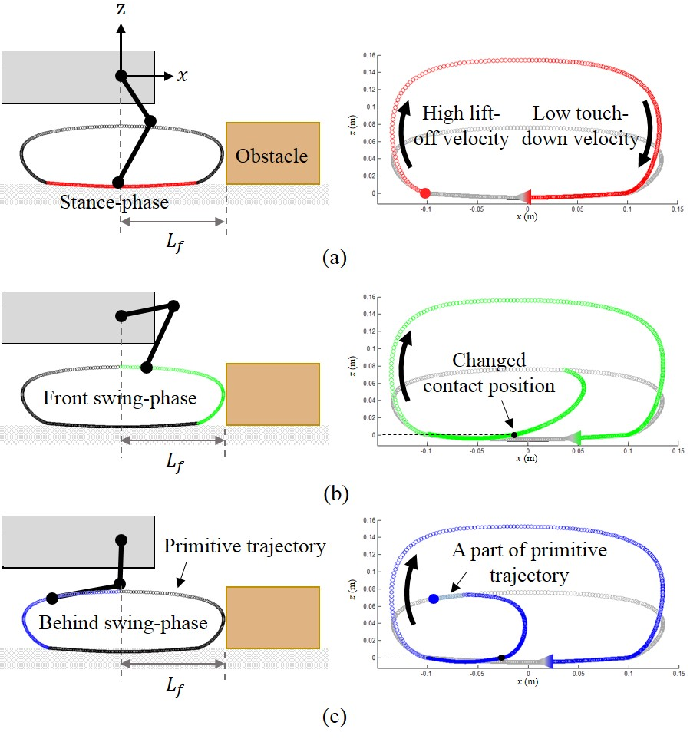
Figure 1 from Trajectory design and control of quadruped robot for ...
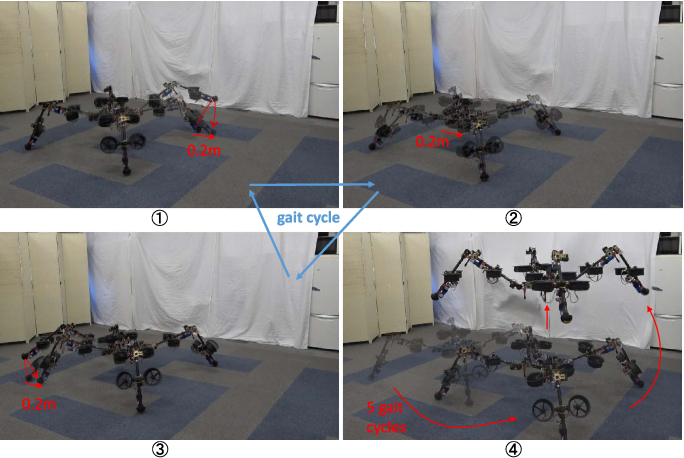
Figure 10 from Design, Modeling, and Control of a Quadruped Robot ...
Advertisement Space (300x250)

Figure 1 from Gait Design and Numerical Simulation for a Quadruped ...

Figure 2 from Design and walking planning of bionic quadruped robot ...

Figure 3 from Structural design and gait research of a new bionic ...
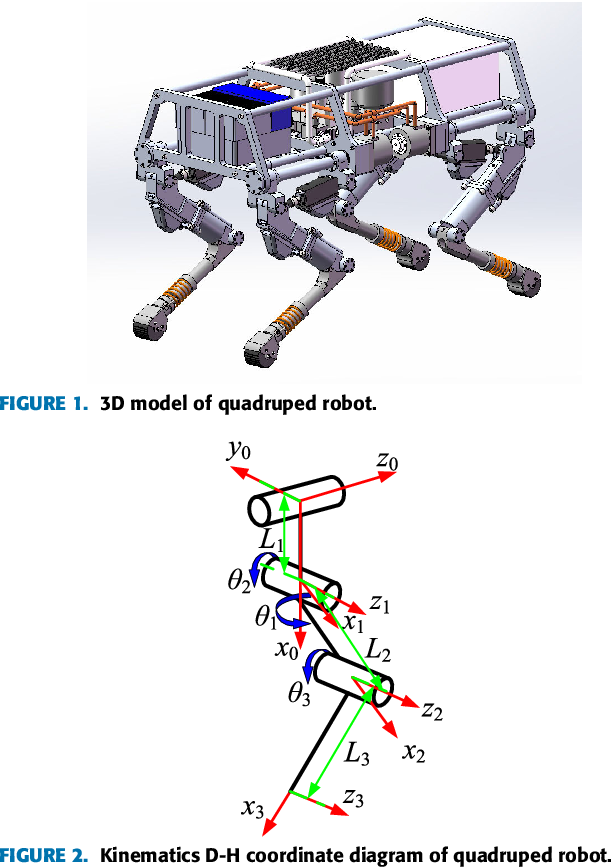
Figure 1 from Research on Gait Switching Control of Quadruped Robot ...
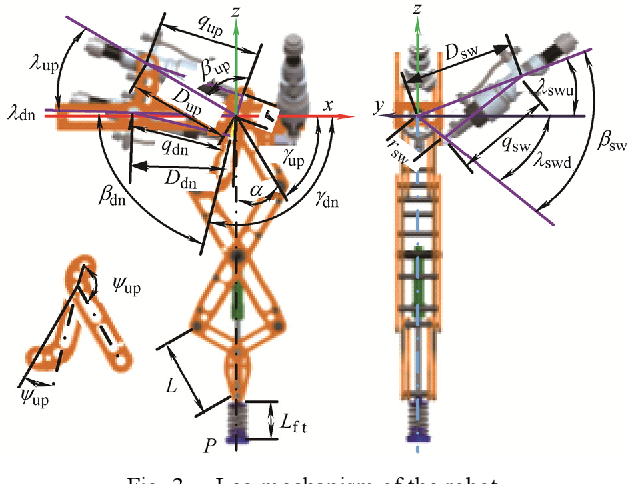
Figure 3 from Gait planning for a quadruped robot with one faulty ...
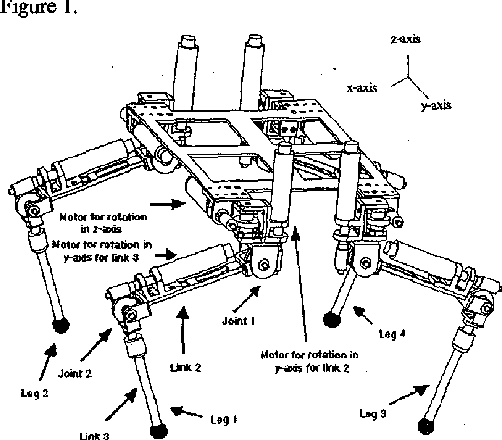
Figure 1 from Mechatronics design and gait implementation of a ...
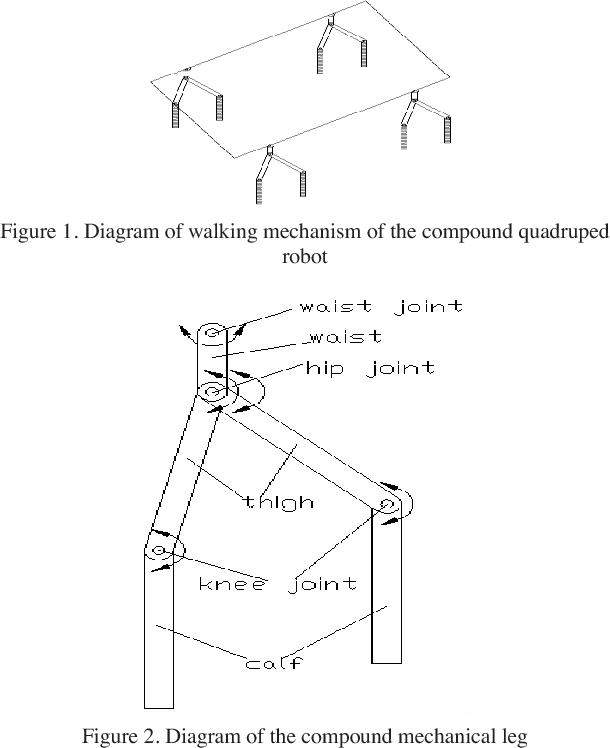
Figure 1 from Walking Mechanism and Gait Design of a Novel Compound ...

Figure 5 from Learning Impulse-Reduced Gait for Quadruped Robot using ...

(PDF) Design of a Large-scale Electrically-actuated Quadruped Robot and ...

Trot Gait Stability Control of Small Quadruped Robot Based on MPC and ...
Advertisement Space (336x280)

Design and Control of a Open-Source, Low Cost, 3D Printed Dynamic ...

Table I from Design of an Unconventional Bionic Quadruped Robot with ...

Design and Control of a Open-Source, Low Cost, 3D Printed Dynamic ...

Design and Control of a Open-Source, Low Cost, 3D Printed Dynamic ...
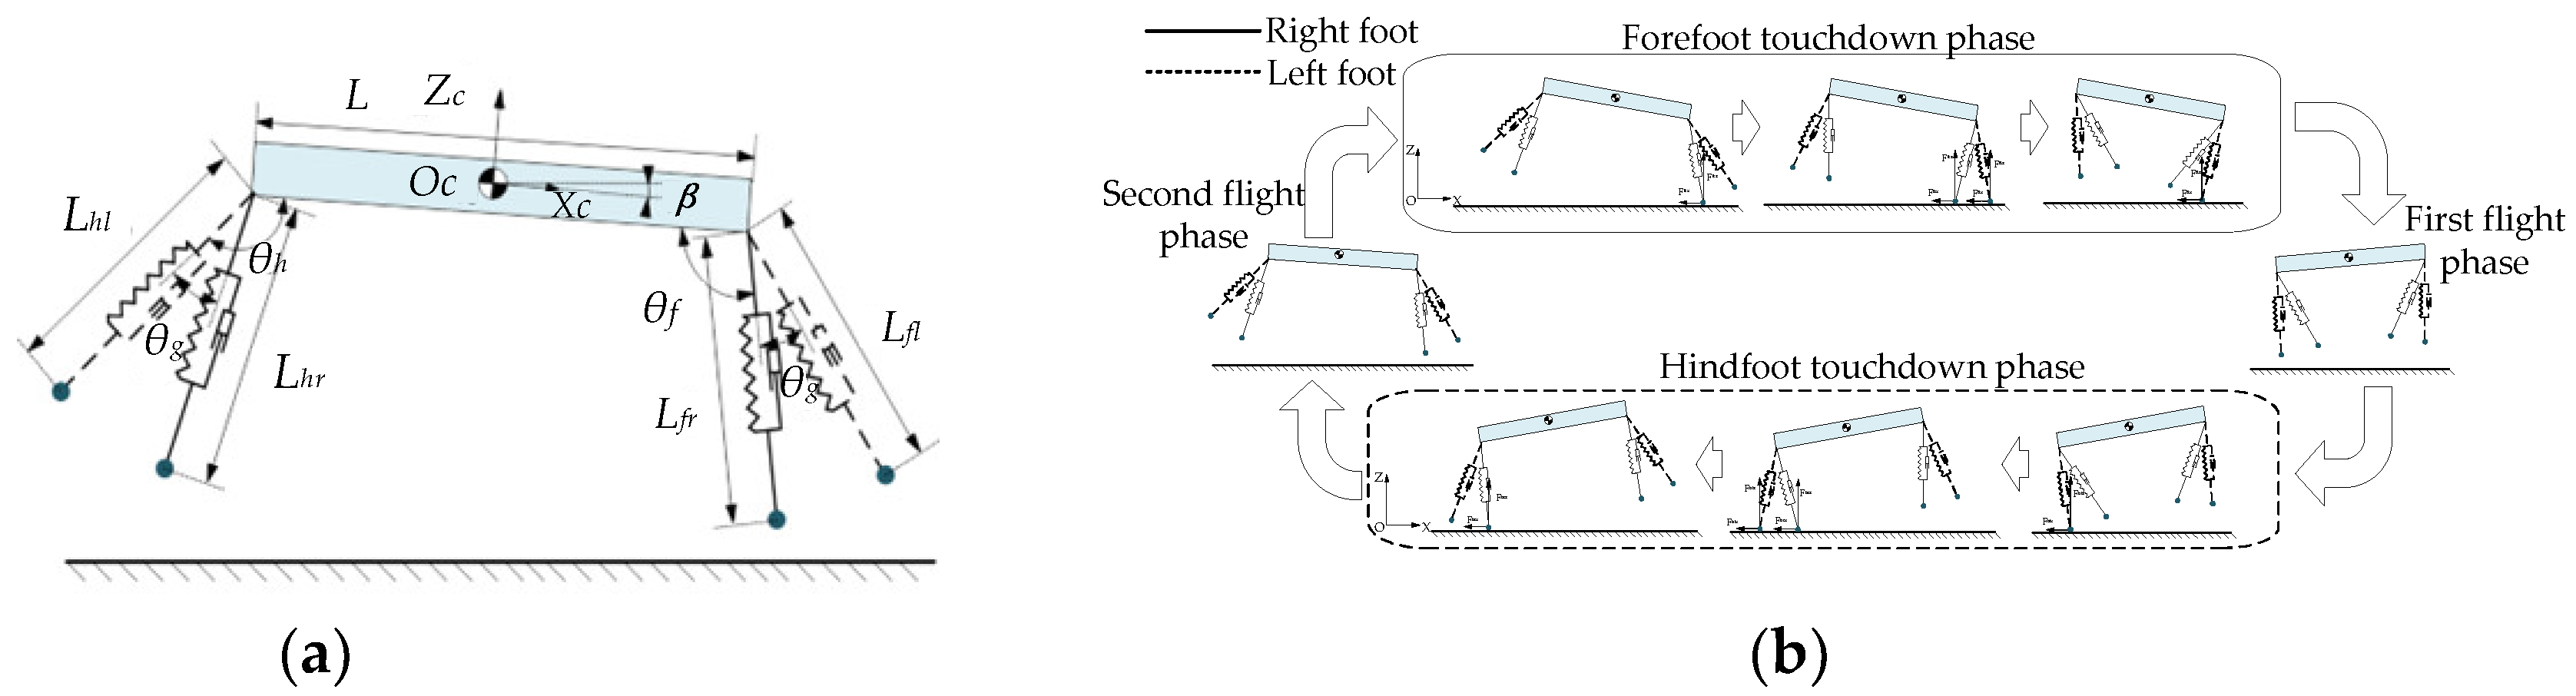
Running Gait and Control of Quadruped Robot Based on SLIP Model

Running Gait and Control of Quadruped Robot Based on SLIP Model

Running Gait and Control of Quadruped Robot Based on SLIP Model

Running Gait and Control of Quadruped Robot Based on SLIP Model

Running Gait and Control of Quadruped Robot Based on SLIP Model

Trot Gait Stability Control of Small Quadruped Robot Based on MPC and ...
Advertisement Space (336x280)

Running Gait and Control of Quadruped Robot Based on SLIP Model

Design, Modeling and Control of a Quadruped Robot SPIDAR: Spherically ...

Running Gait and Control of Quadruped Robot Based on SLIP Model

Planning and Control Framework for a Quadruped Robot With Changeable ...

Trot Gait Stability Control of Small Quadruped Robot Based on MPC and ...

(PDF) Dynamics and stable gait planning of a quadruped robot