
Figure 8 From Memory Efficient Boundary Map For Large Scale Occupancy
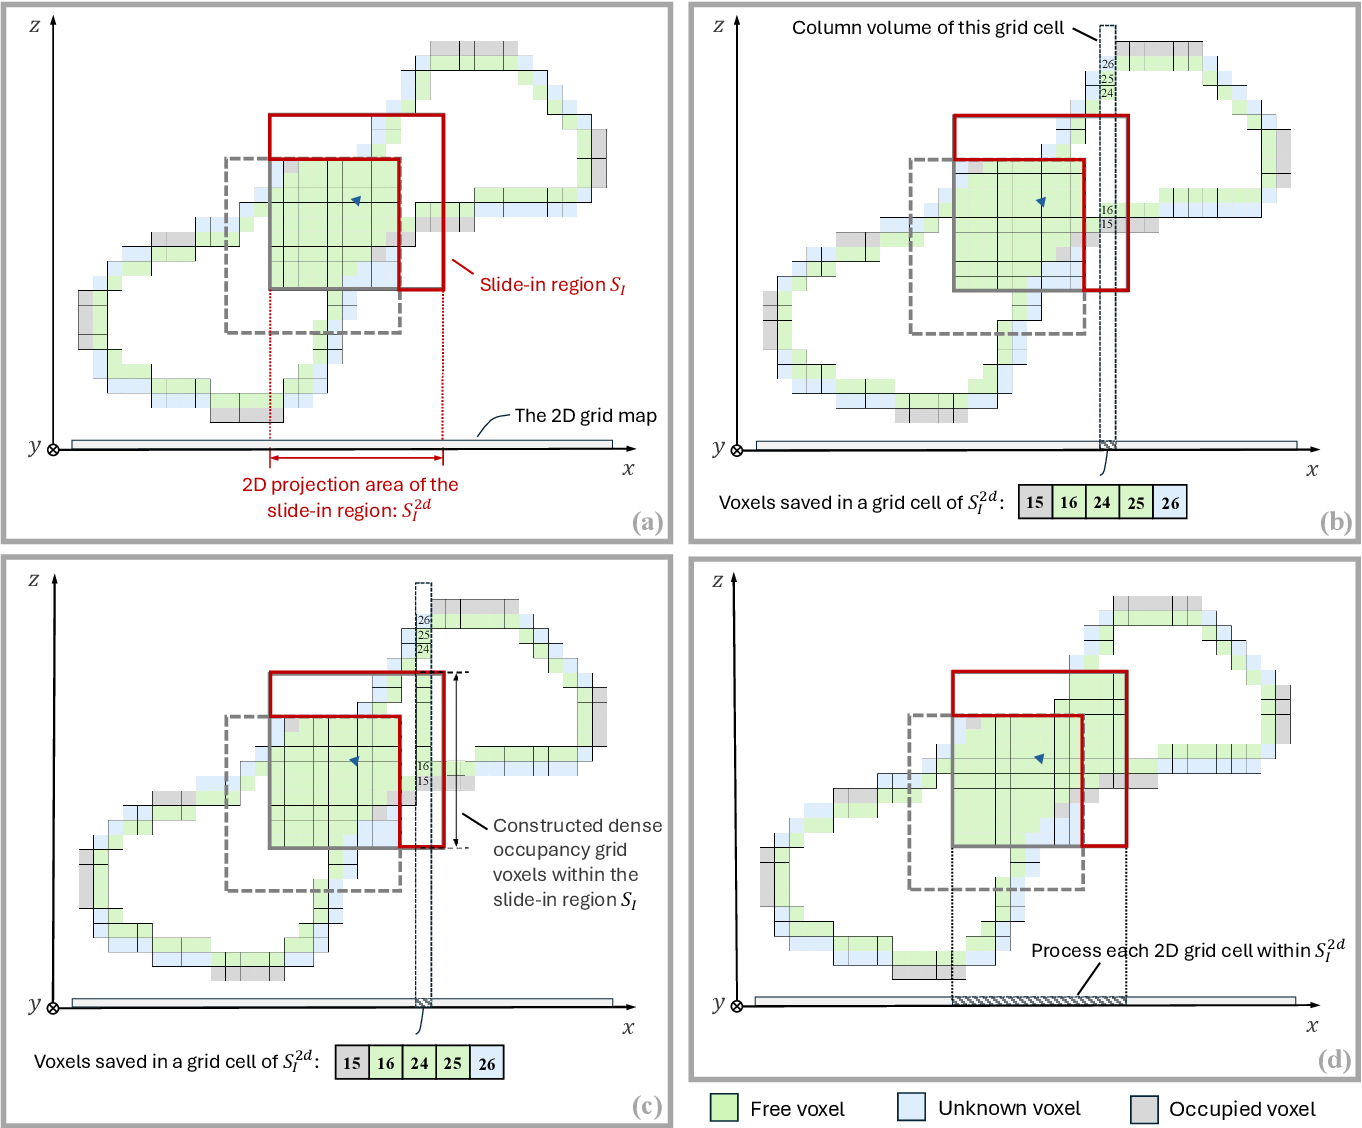
Figure 8 from Memory-efficient boundary map for large-scale occupancy ...

Figure 1 from Memory-efficient boundary map for large-scale occupancy ...

Figure 1 from Memory-efficient boundary map for large-scale occupancy ...

Figure 1 from Memory-efficient boundary map for large-scale occupancy ...

Figure 1 from Memory-efficient boundary map for large-scale occupancy ...

Figure 1 from Memory-efficient boundary map for large-scale occupancy ...

Figure 1 from Memory-efficient boundary map for large-scale occupancy ...

Figure 1 from Memory-efficient boundary map for large-scale occupancy ...

Figure 1 from Memory-efficient boundary map for large-scale occupancy ...
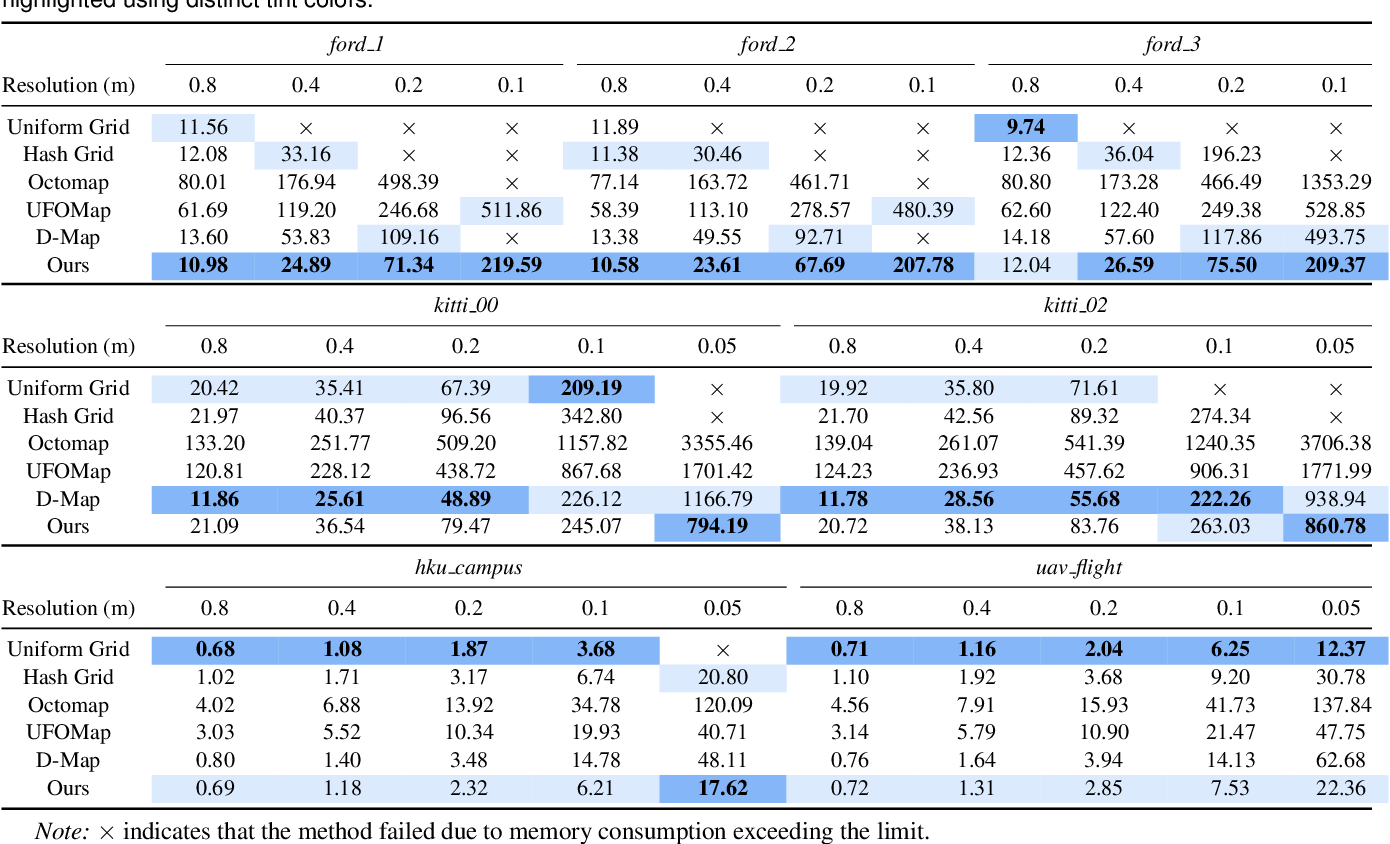
Table 2 from Memory-efficient boundary map for large-scale occupancy ...
Advertisement Space (300x250)
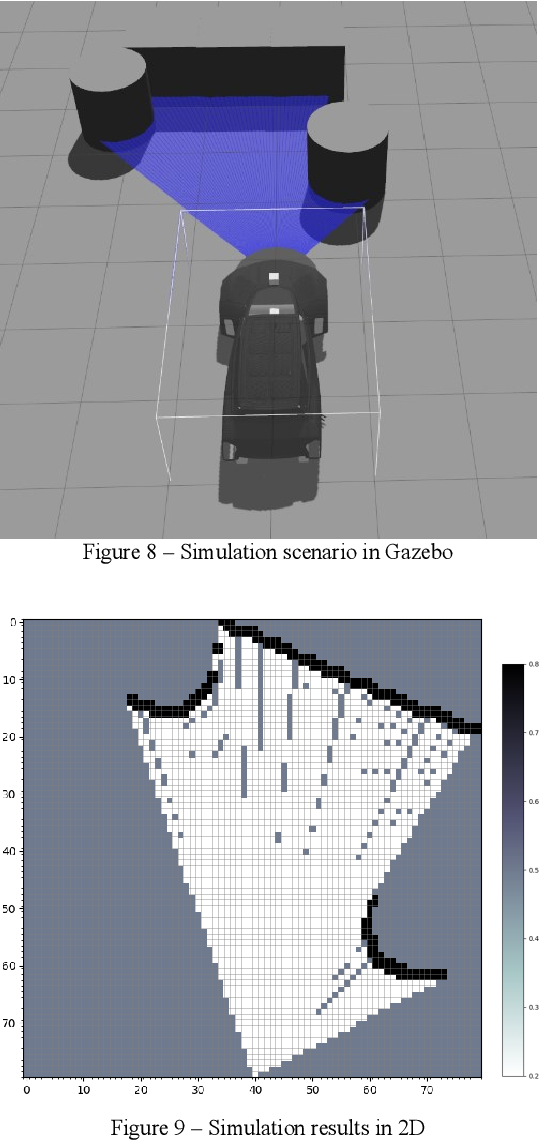
Figure 8 from A Mobile Robot and Vehicle Occupancy Map Construction ...

Memory-Efficient Boundary Map for Large-Scale Occupancy Grid Mapping ...
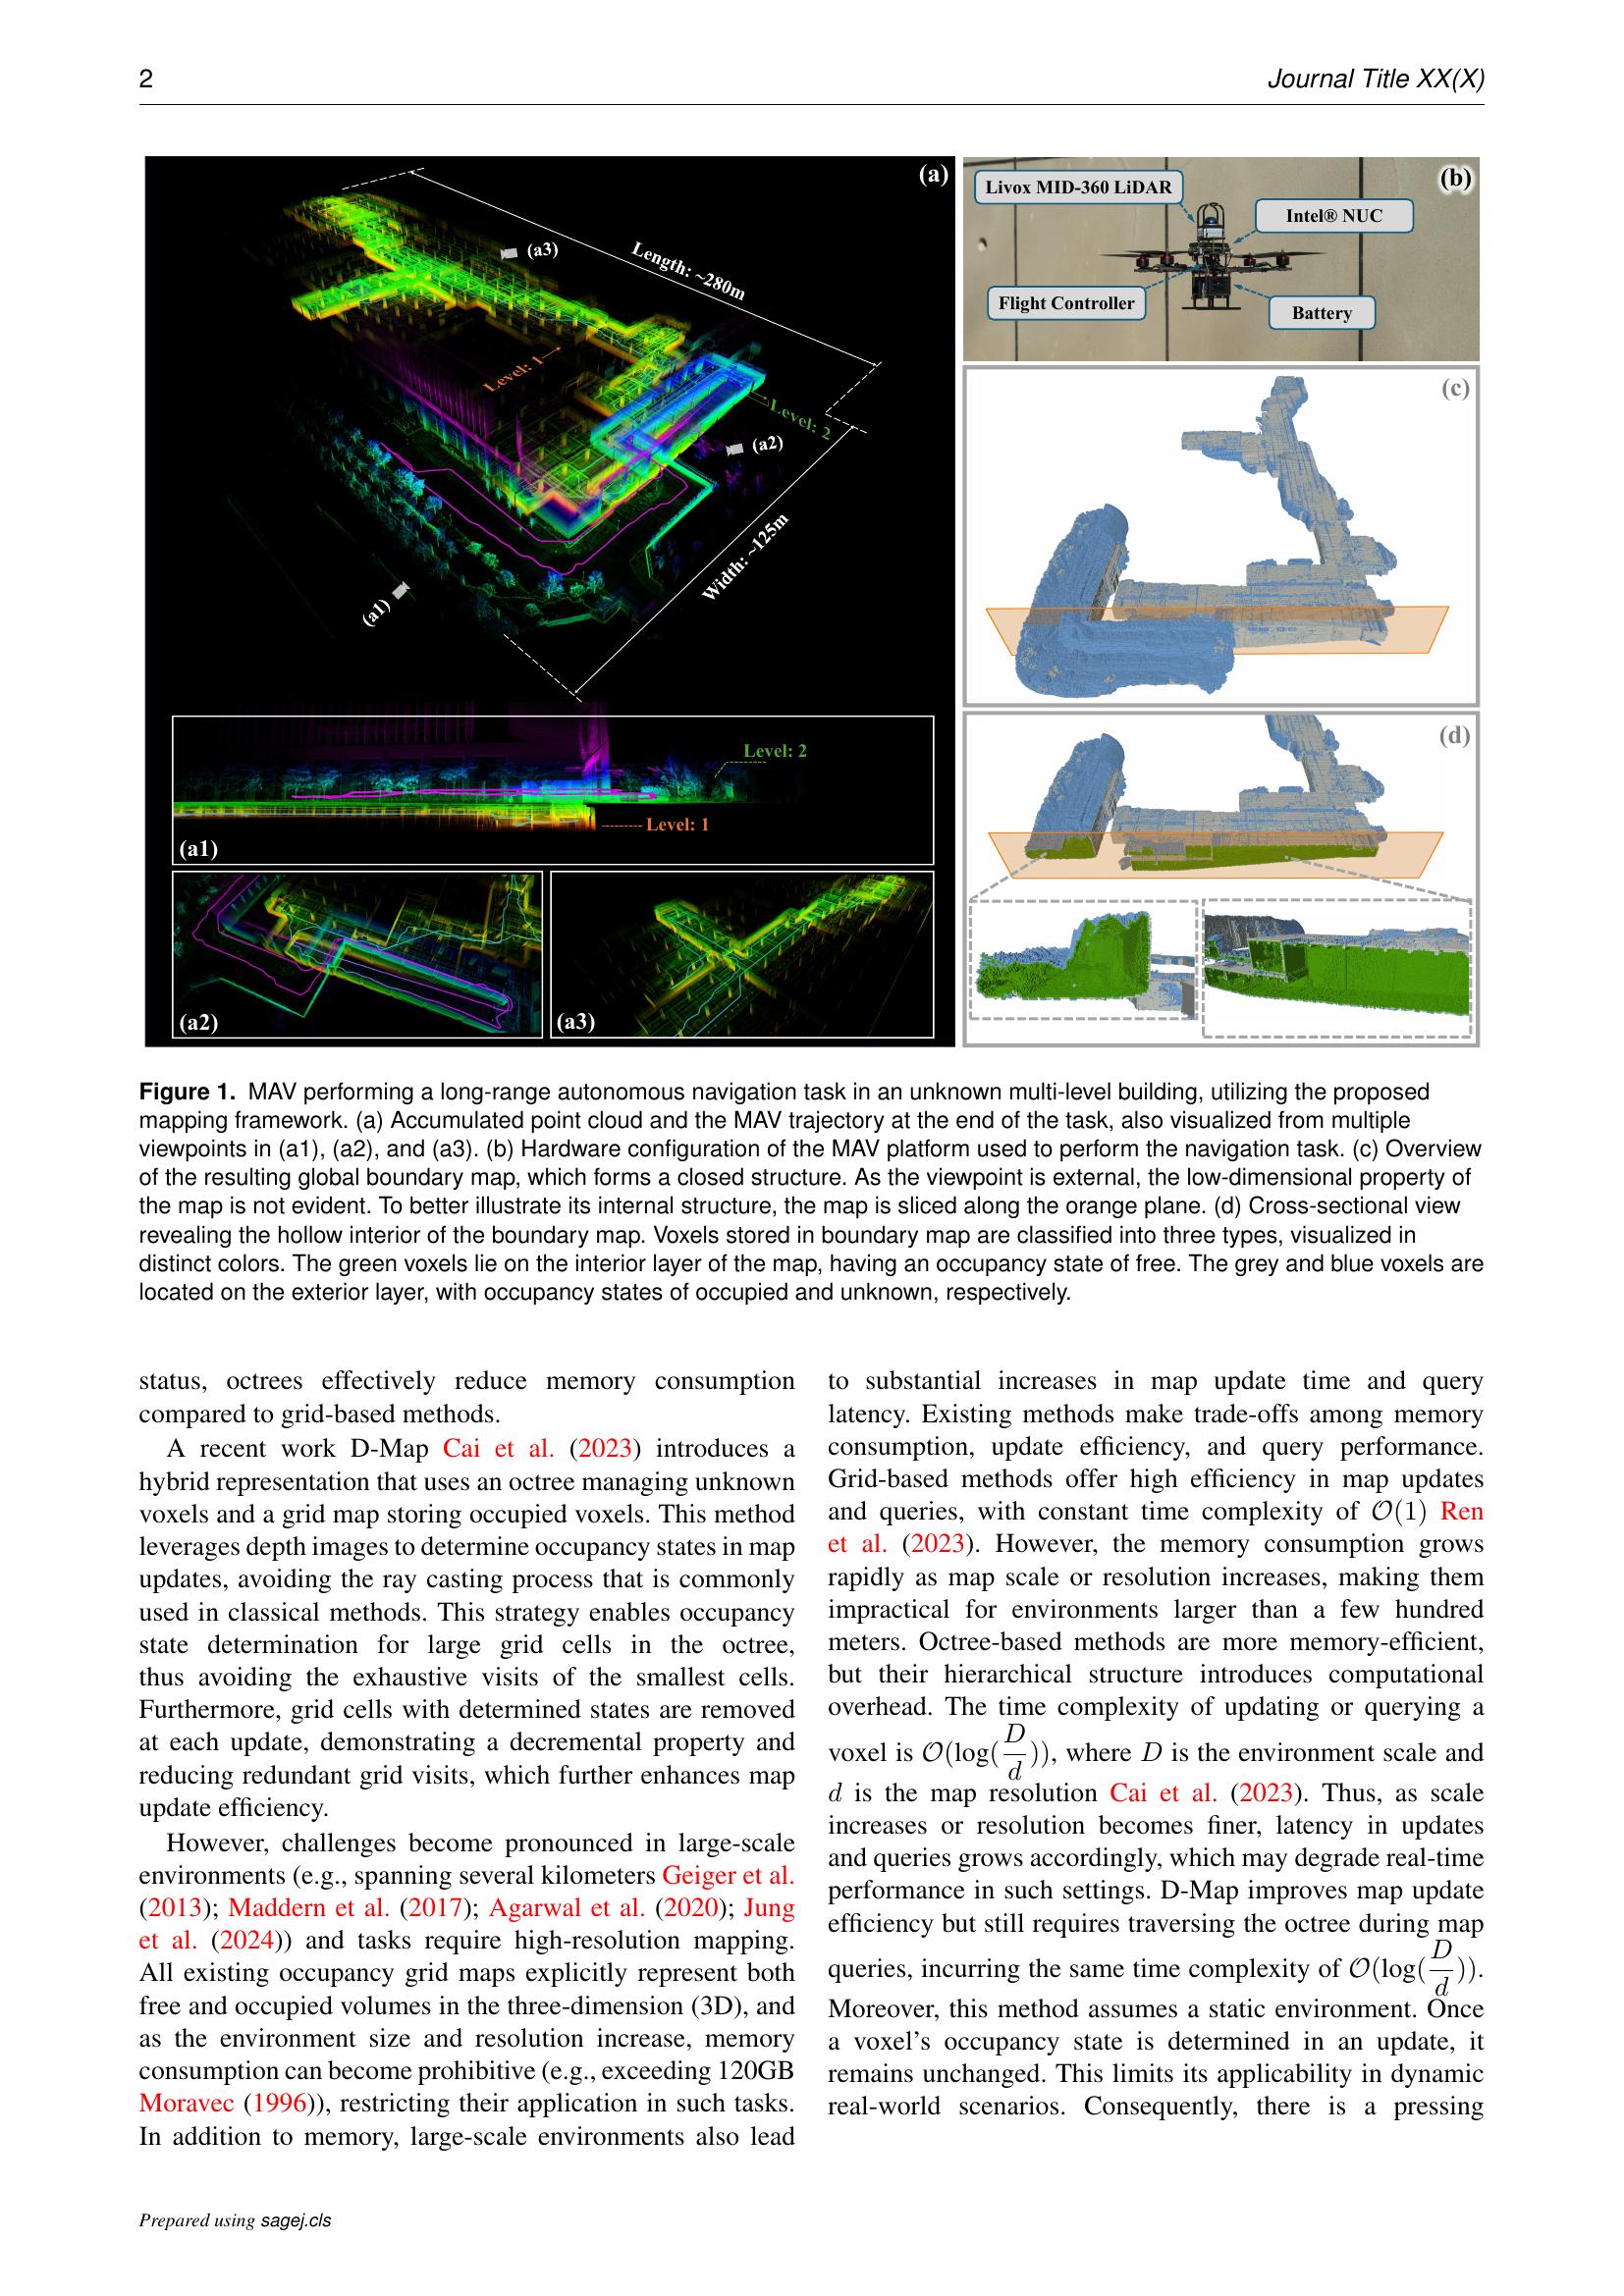
Memory-Efficient Boundary Map for Large-Scale Occupancy Grid Mapping ...
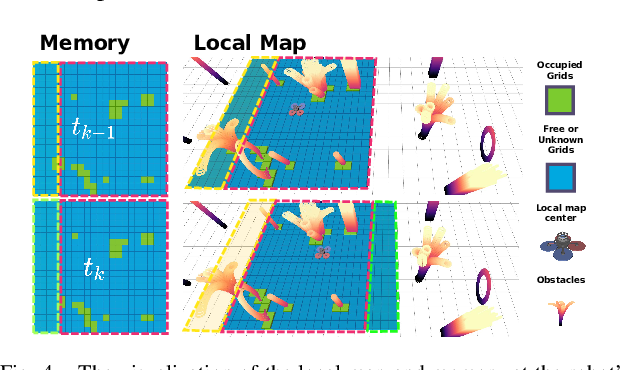
ROG-Map: An Efficient Robocentric Occupancy Grid Map for Large-scene ...
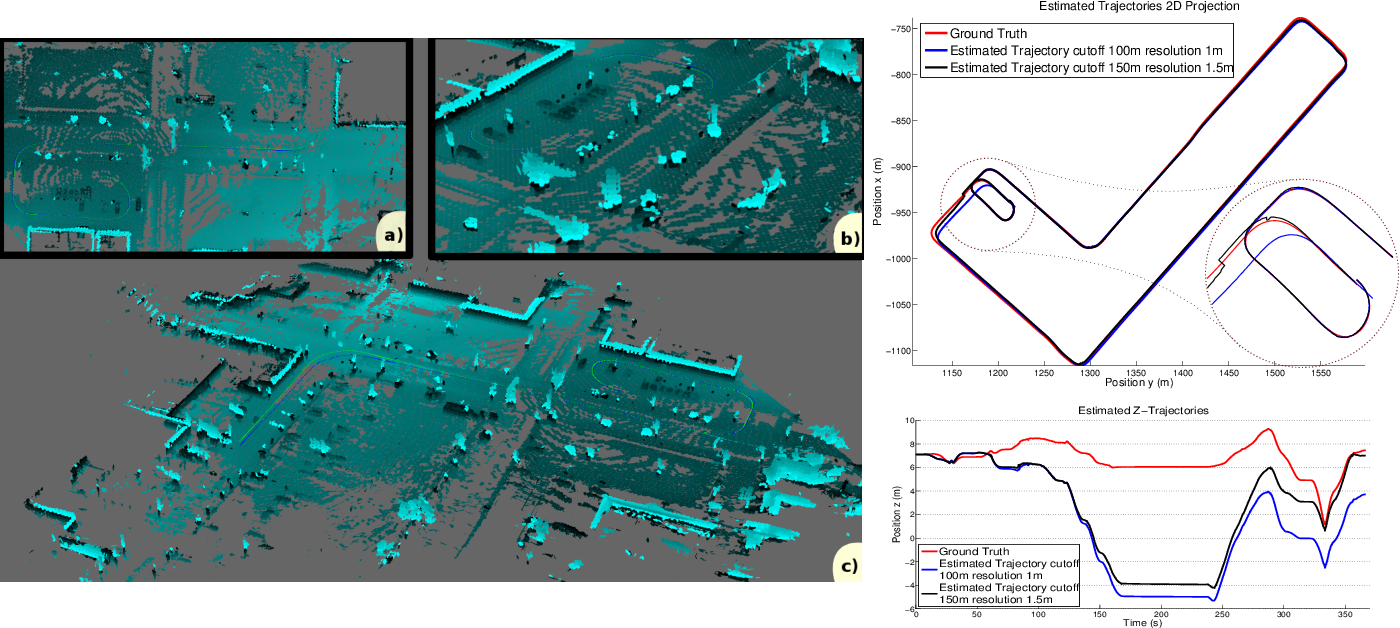
Figure 3 from Normal Distributions Transform Occupancy Map fusion ...

Figure 1 from Online and Consistent Occupancy Grid Mapping for Planning ...
ROG-Map: An Efficient Robocentric Occupancy Grid Map for Large-scene ...
GMMap Memory Efficient Continuous Occupancy Map Using Gaussian Mixture ...

Figure 1 from Evidential Occupancy Grid Map Augmentation using Deep ...
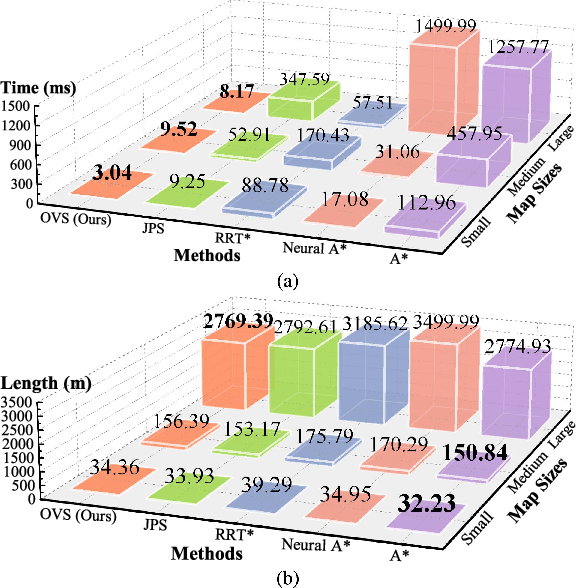
Figure 3 from Efficient Multi-Robot Task and Path Planning in Large ...
Advertisement Space (336x280)

ROG-Map: An Efficient Robocentric Occupancy Grid Map for Large-scene ...

Figure 4 from Efficient occupancy grid computation on the GPU with ...
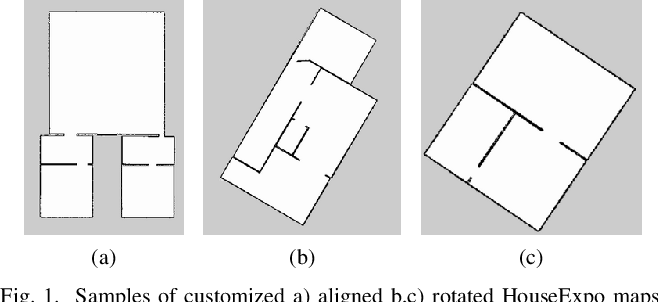
Figure 1 from Occupancy Grid Map Completion Based on Geometric Features ...
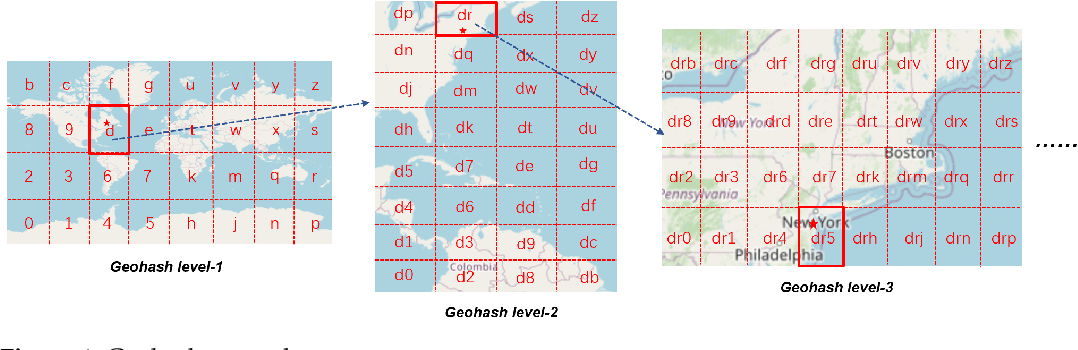
Figure 1 from Memory efficient location recommendation through ...
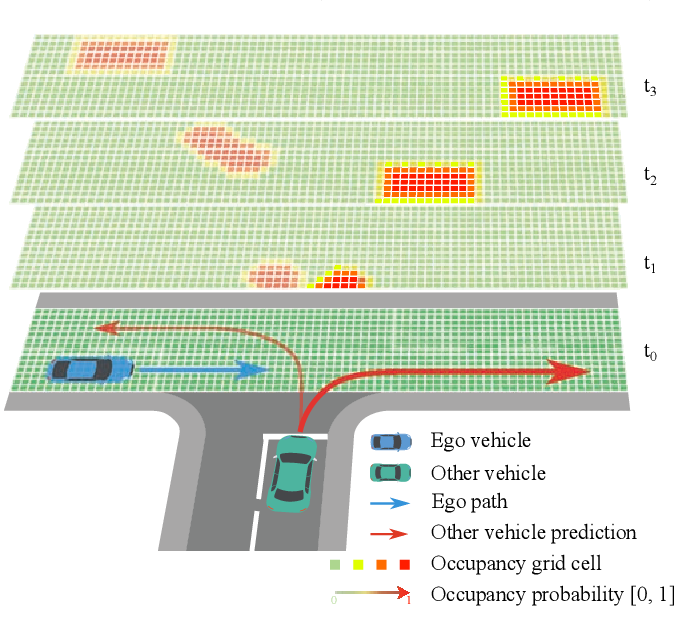
Figure 1 from Efficient POMDP Behavior Planning for Autonomous Driving ...
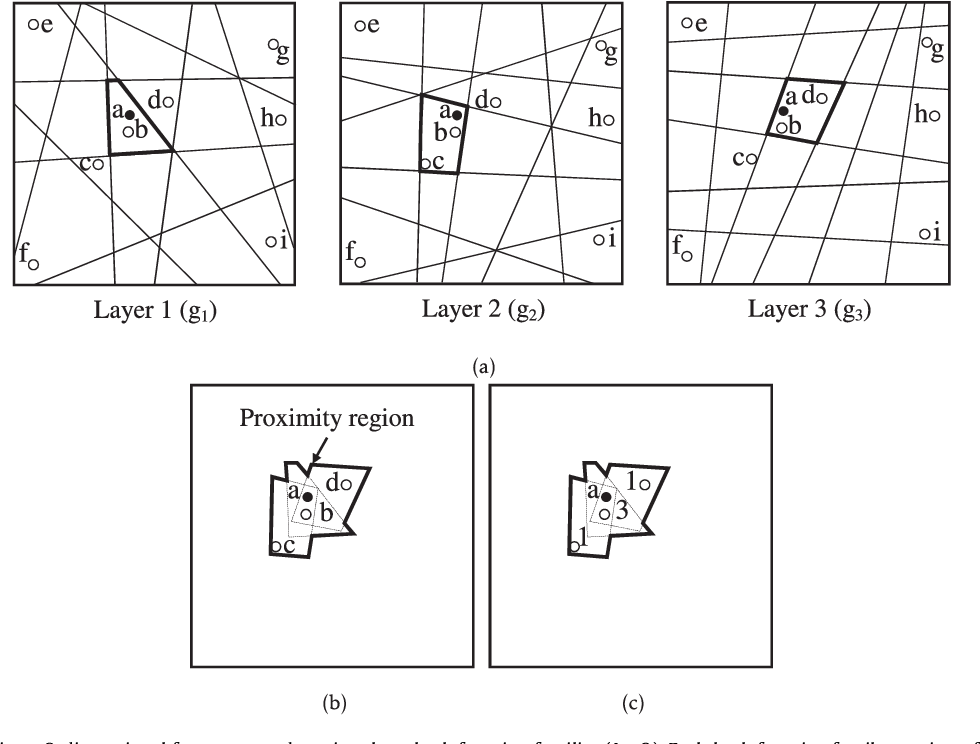
Figure 1 from Efficient and decision boundary aware instance selection ...
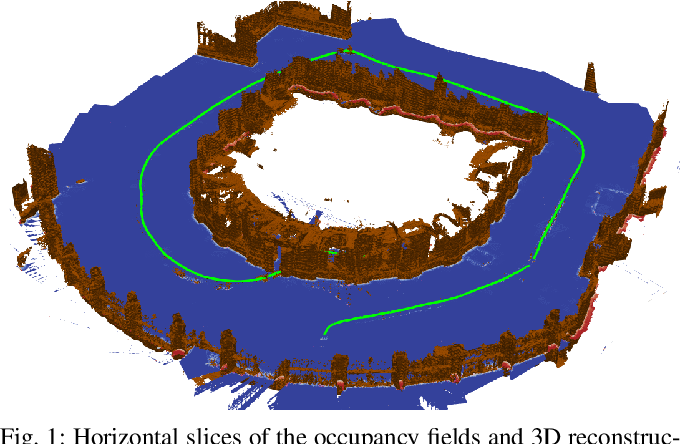
Figure 1 from Tightly-Coupled LiDAR-Visual-Inertial SLAM and Large ...

The test map used for evaluation. (far left) An occupancy map ...

Occupancy Map Construction for Indoor Robot Navigation | IntechOpen

Figure 1 from Efficient Map/Reduce-Based DBSCAN Algorithm with ...
Advertisement Space (336x280)
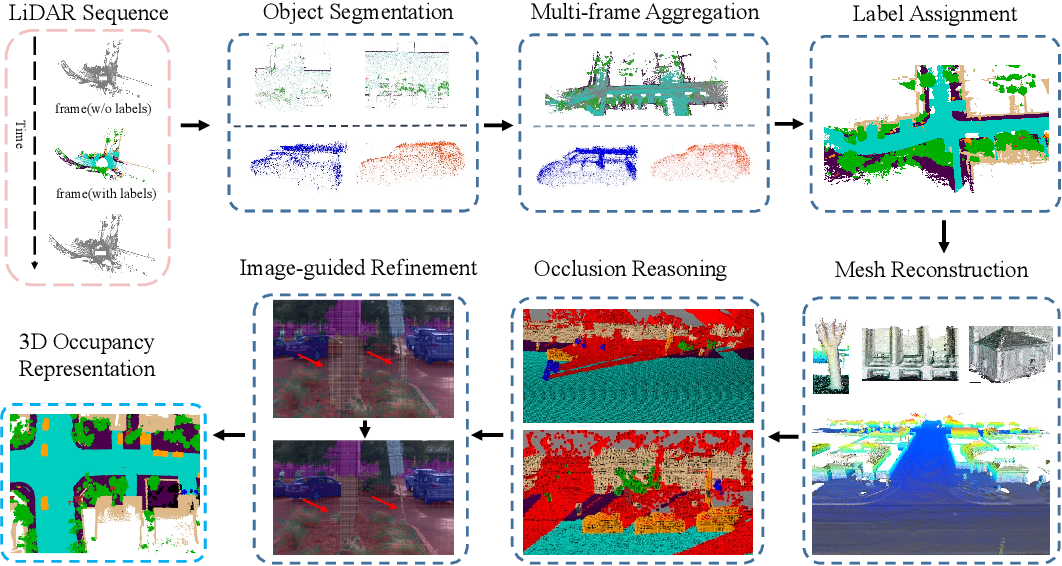
Figure 2 from Occ3D: A Large-Scale 3D Occupancy Prediction Benchmark ...

Figure 2 from Tightly-Coupled LiDAR-Visual-Inertial SLAM and Large ...
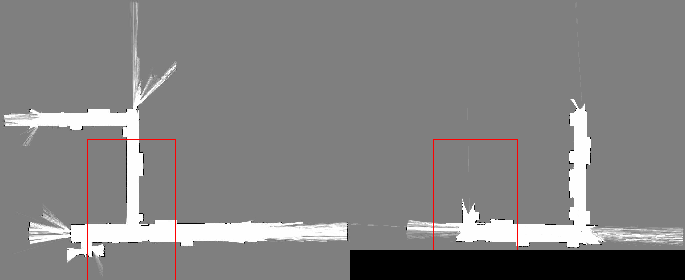
Figure 2 from A Method of Fast and Accurate Occupancy Grid Maps Merging ...
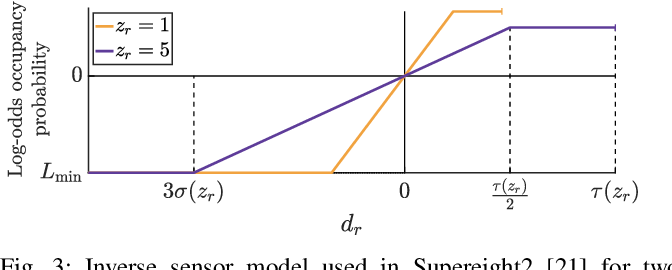
Figure 3 from Tightly-Coupled LiDAR-Visual-Inertial SLAM and Large ...

The test map used for evaluation. (far left) An occupancy map ...
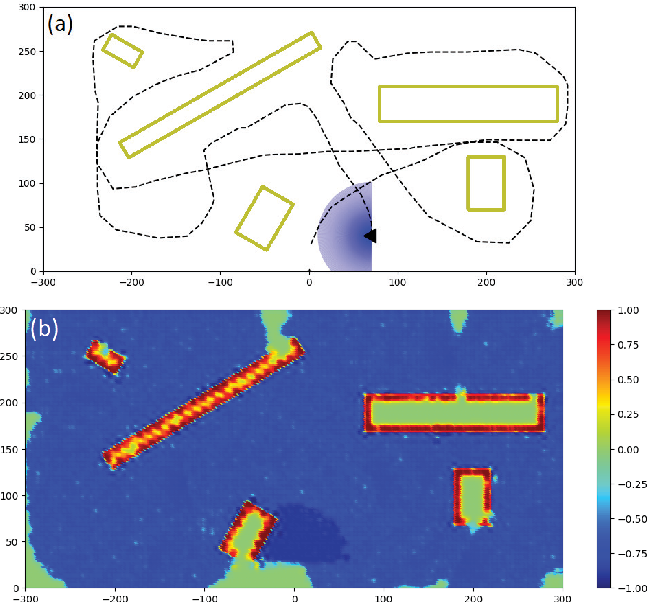
Figure 1 from Building Continuous Occupancy Maps With Moving Robots ...