
Graphslam Documentation Graphslam 0017 Documentation

graphslam Documentation — graphslam 0.0.17 documentation

graphslam Documentation — graphslam 0.0.17 documentation

graphslam Documentation — graphslam 0.0.17 documentation

PPT - Understanding the GraphSLAM Algorithm for Robot Mapping and Path ...
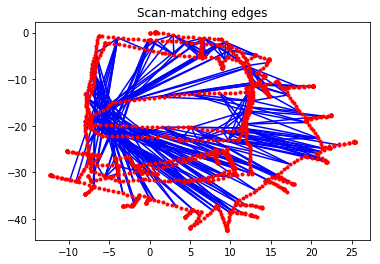
Graph based SLAM — PythonRobotics documentation
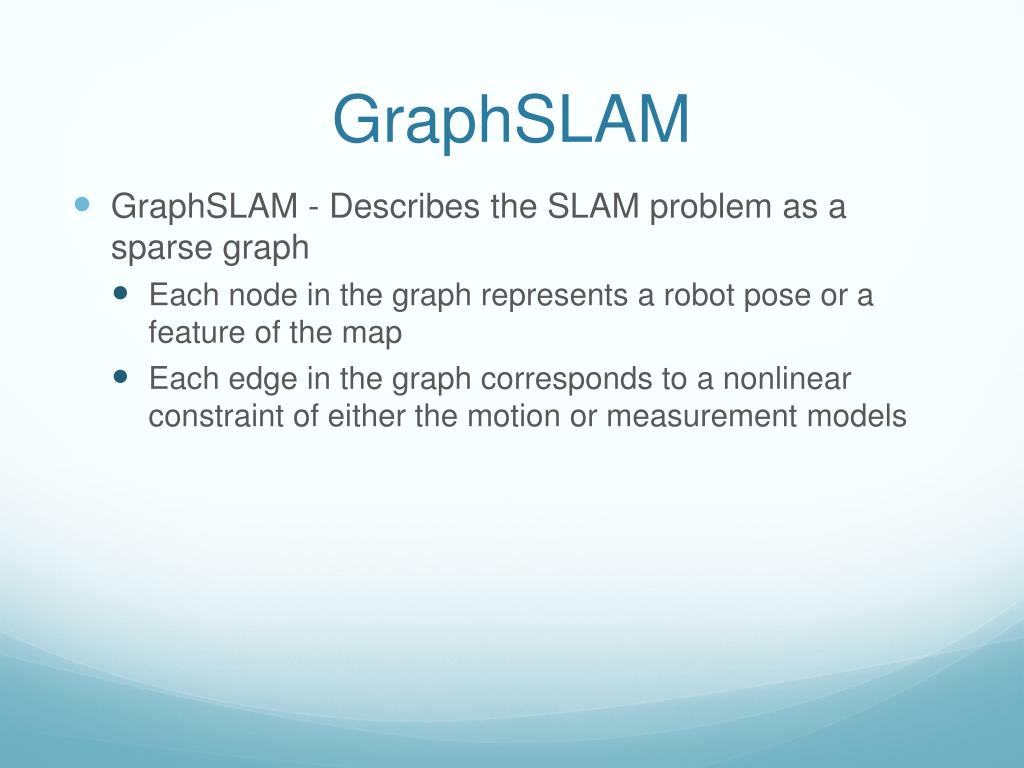
PPT - Understanding the GraphSLAM Algorithm for Robot Mapping and Path ...

Example: graphslam_example — MRPT 2.15.13 documentation
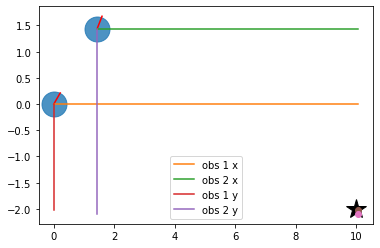
Graph based SLAM — PythonRobotics documentation
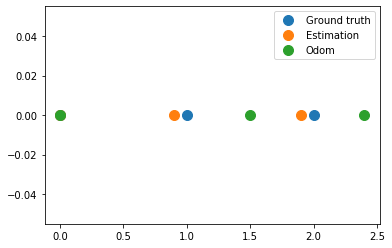
Graph based SLAM — PythonRobotics documentation
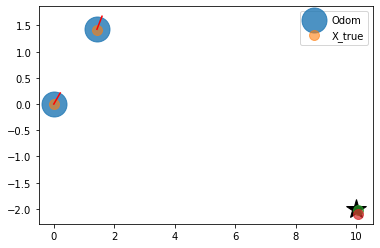
Graph based SLAM — PythonRobotics documentation
Advertisement Space (300x250)
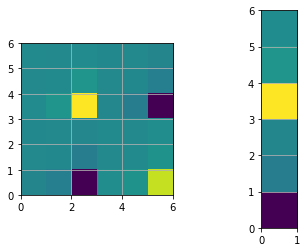
Graph based SLAM — PythonRobotics documentation
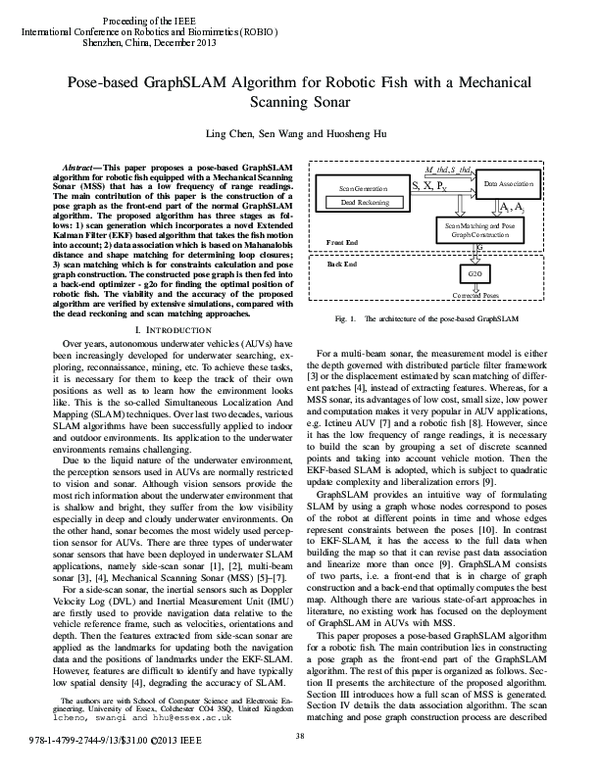
(PDF) Pose-based GraphSLAM algorithm for robotic fish with a mechanical ...

GraphSLAM | Yuvanshu_Agarwal
PPT - Understanding the GraphSLAM Algorithm for Robot Mapping and Path ...
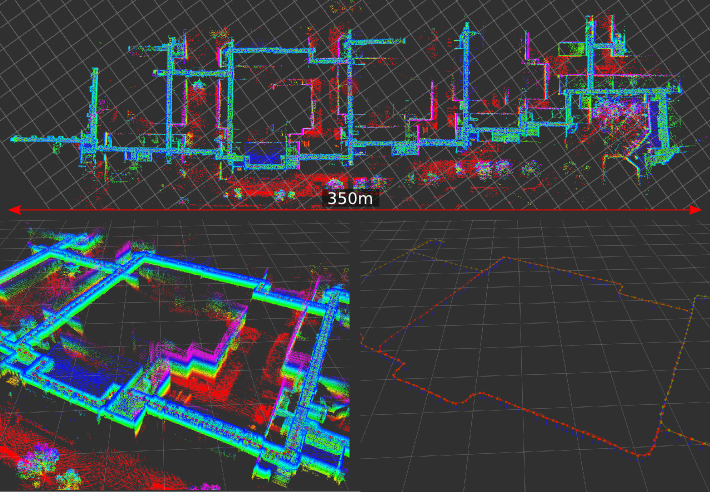
hdl_graph_slam - Autoware Documentation

Understanding SLAM: FastSLAM & GraphSLAM | PDF | Applied Mathematics ...
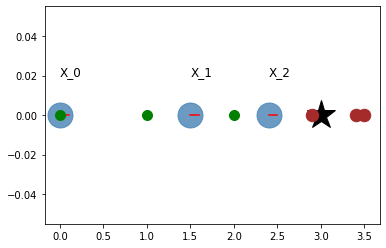
Graph based SLAM — PythonRobotics documentation
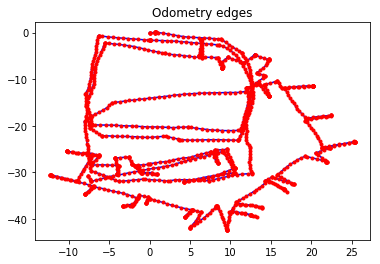
Graph based SLAM — PythonRobotics documentation
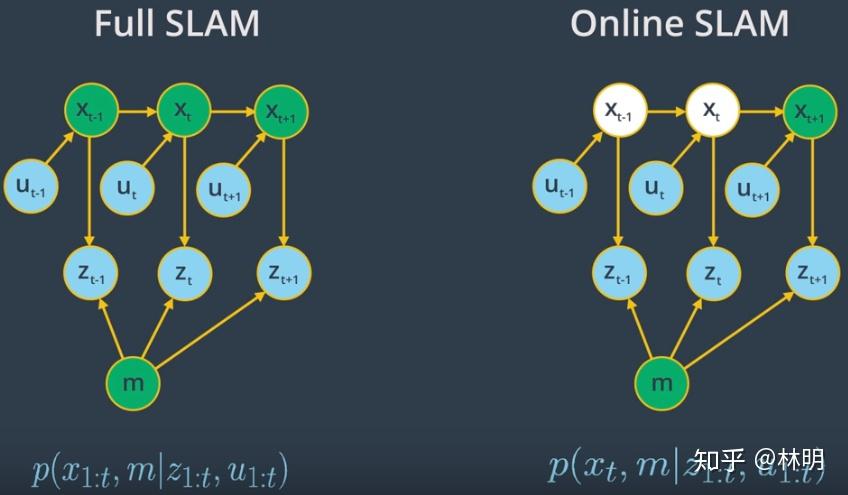
GraphSLAM 学习笔记 - 知乎
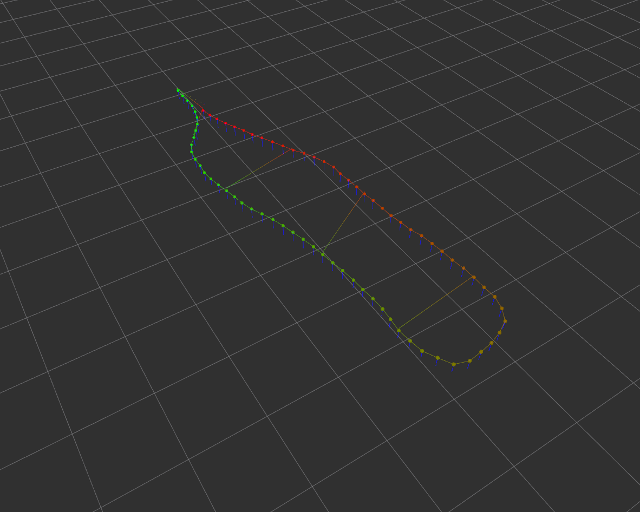
hdl_graph_slam - Autoware Documentation
Advertisement Space (336x280)
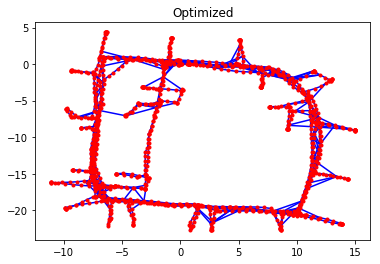
Graph based SLAM — PythonRobotics documentation

Illustration of GraphSLAM concepts. Map edges spatially constrain the ...

hdl_graph_slam - Autoware Documentation
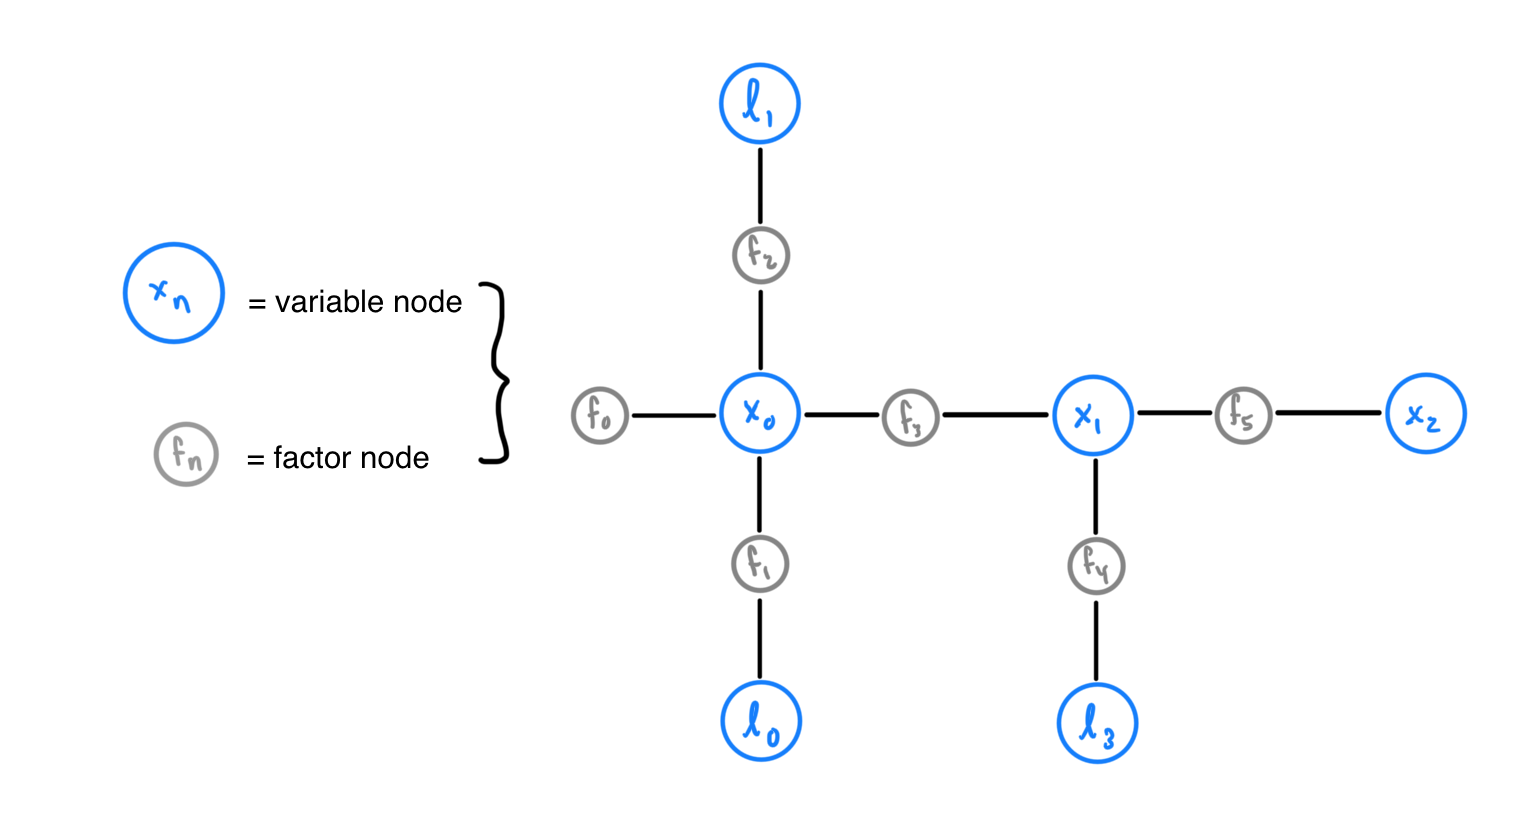
What is Factor Graph SLAM? — CMR Driverless Path Planning 1.0 documentation

graphslam-engine - execute graphSLAM in MRPT - YouTube
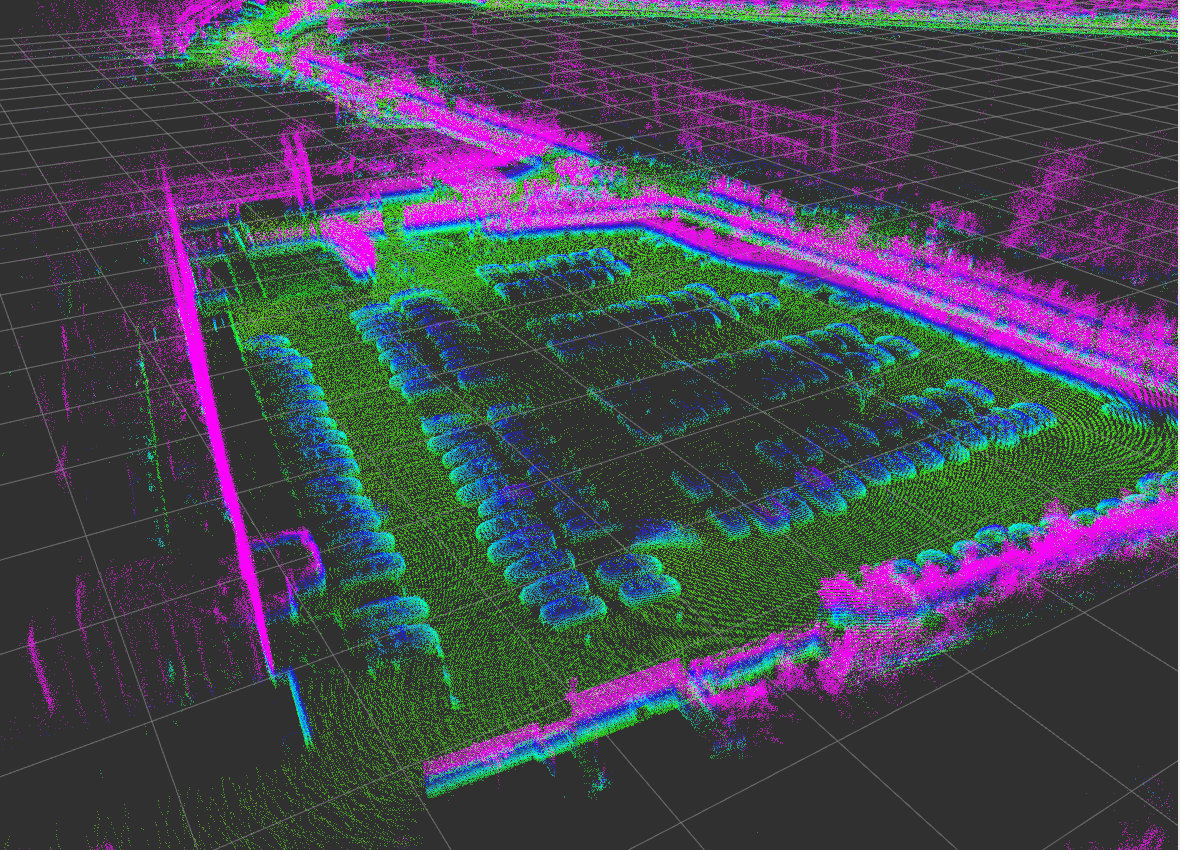
hdl_graph_slam - Autoware Documentation

GraphSLAM | Yuvanshu_Agarwal

algorithms - GraphSlam Doubt - Computer Science Stack Exchange

Graph SLAMの導出 — SLAM documentation
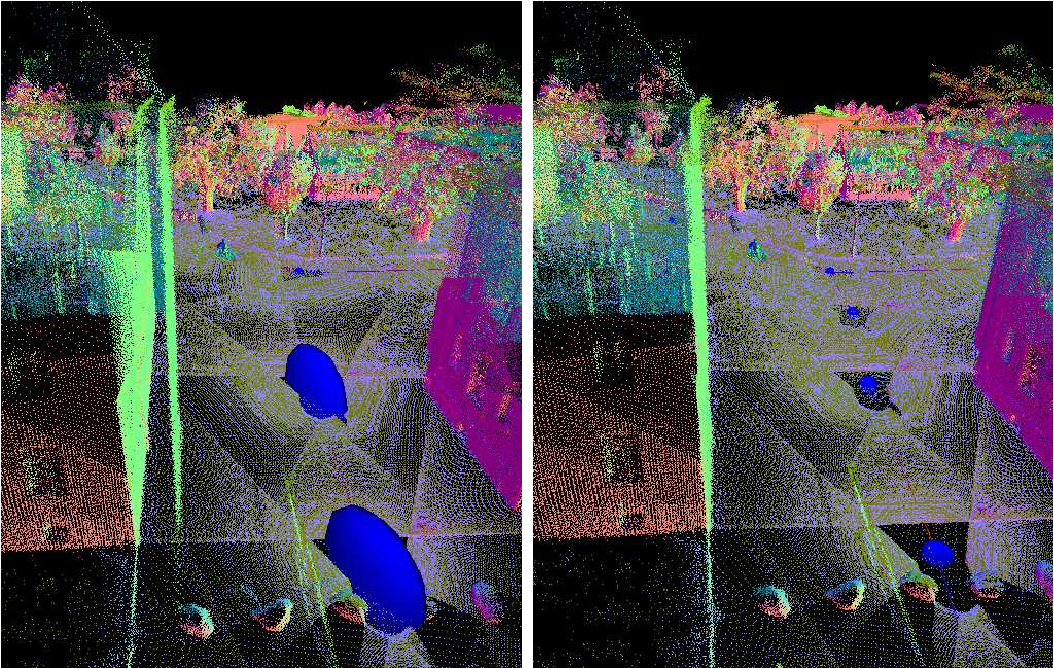
Figure 5.12 from A Full 2D/3D GraphSLAM System for Globally Consistent ...
Advertisement Space (336x280)

Multi-Lane Perception Using Feature Fusion Based on GraphSLAM
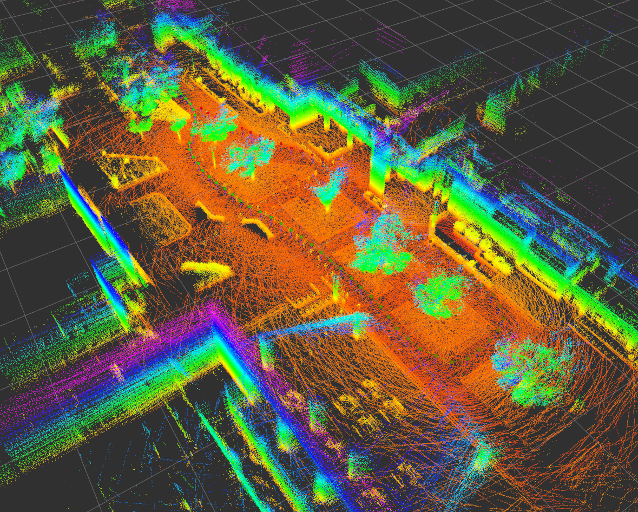
hdl_graph_slam - Autoware Documentation
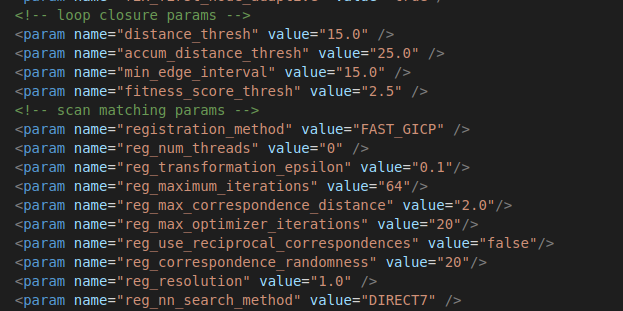
hdl_graph_slam - Autoware Documentation

31. ROS2-SLAM Mapping Course — PuppyPi v2.0 documentation
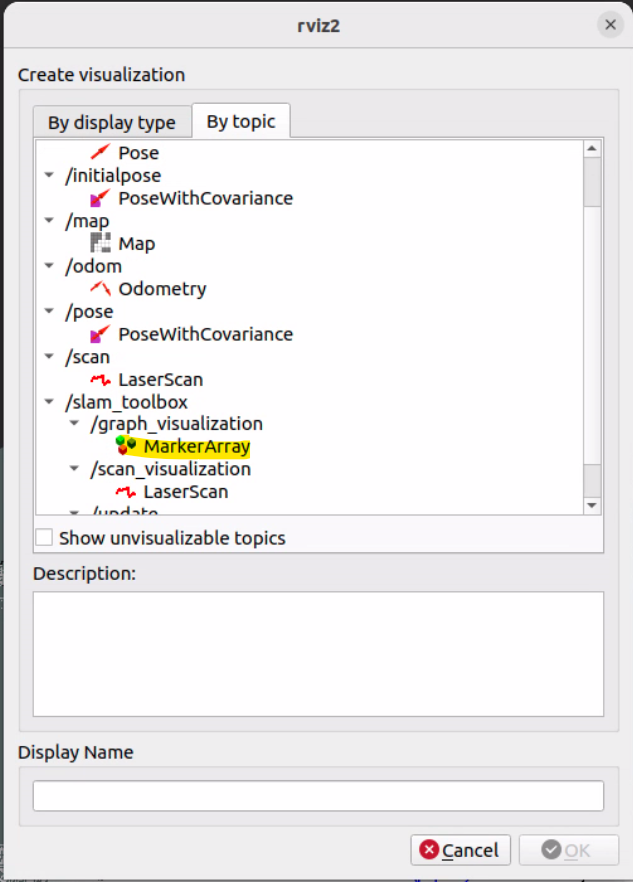
SLAM Toolbox — RoboRacer - Learn latest documentation

Multi-Lane Perception Using Feature Fusion Based on GraphSLAM