
Ide Settings Backup And Sync Rustrover Documentation
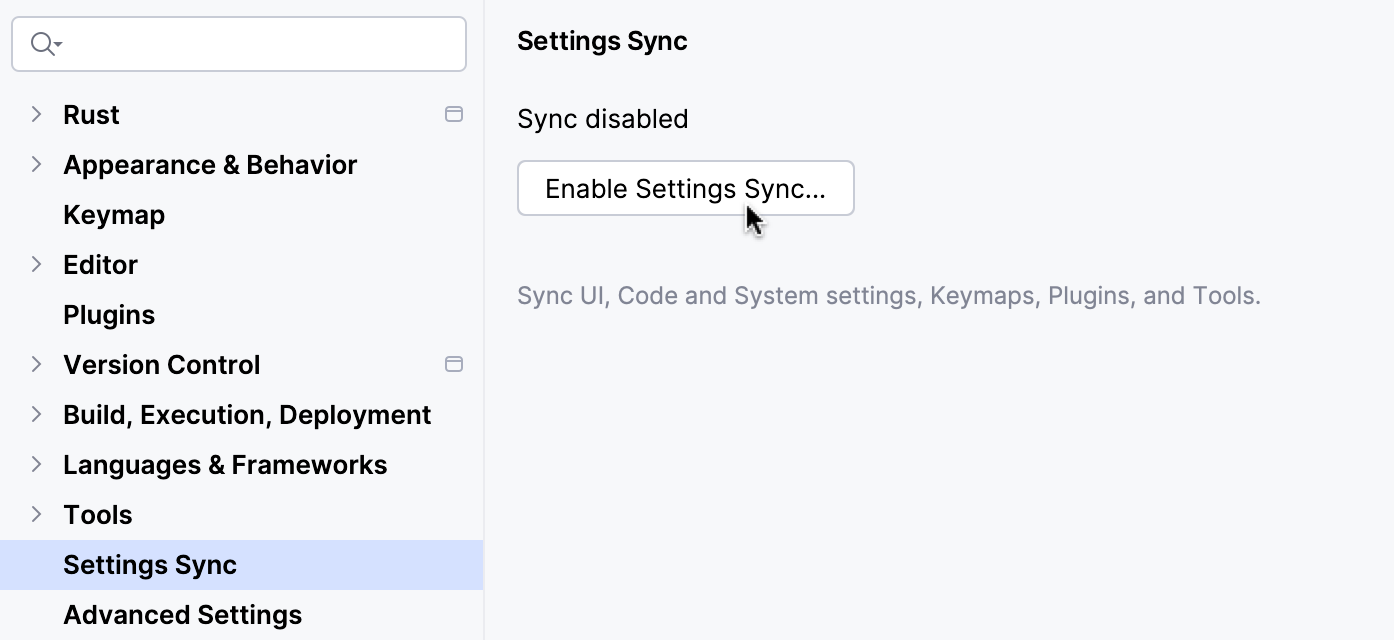
IDE settings backup and sync | RustRover Documentation
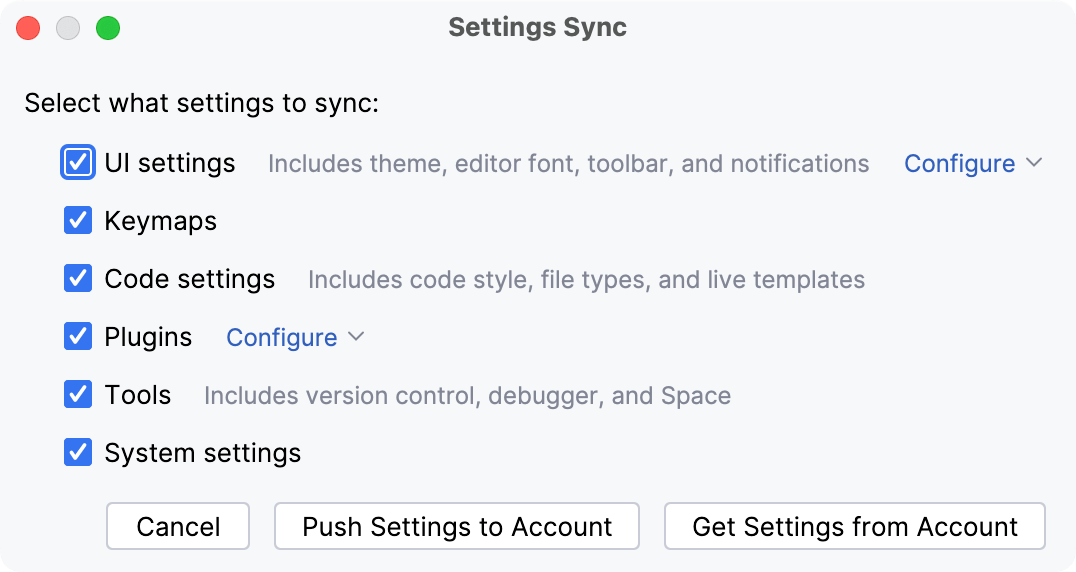
IDE settings backup and sync | RustRover Documentation
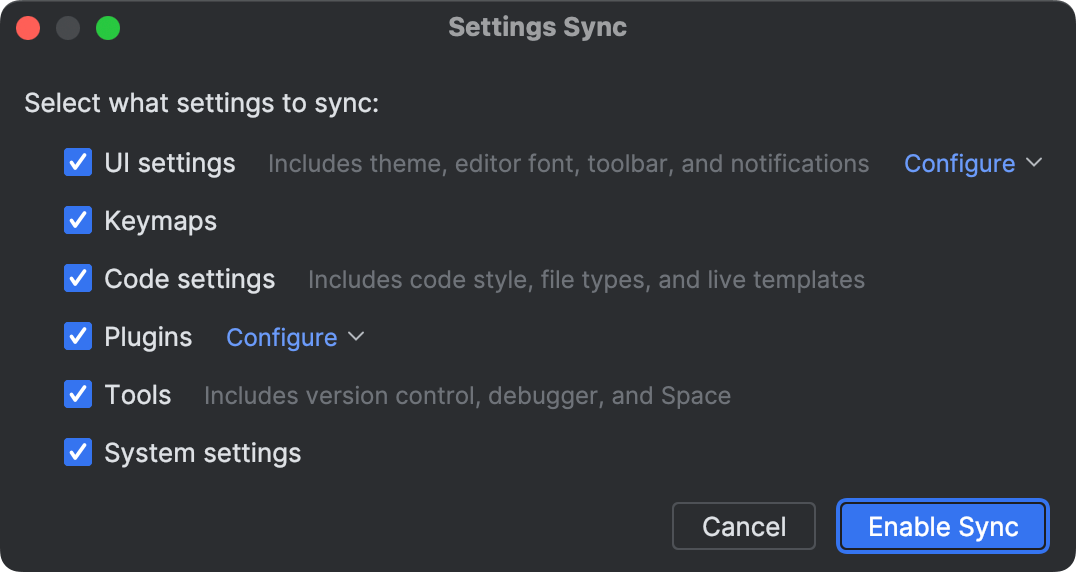
IDE settings backup and sync | RustRover Documentation
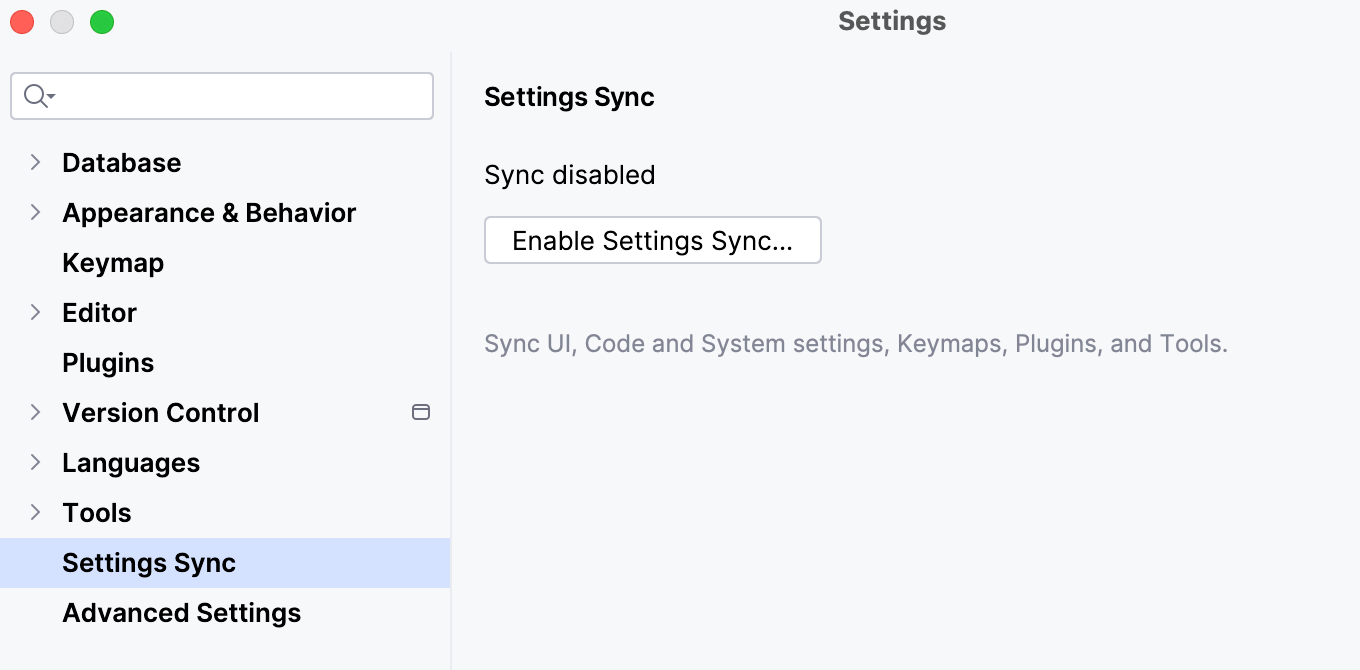
IDE settings backup and sync | DataGrip Documentation
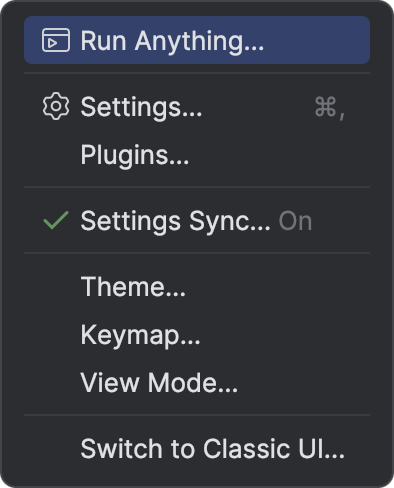
IDE settings backup and sync | DataGrip Documentation
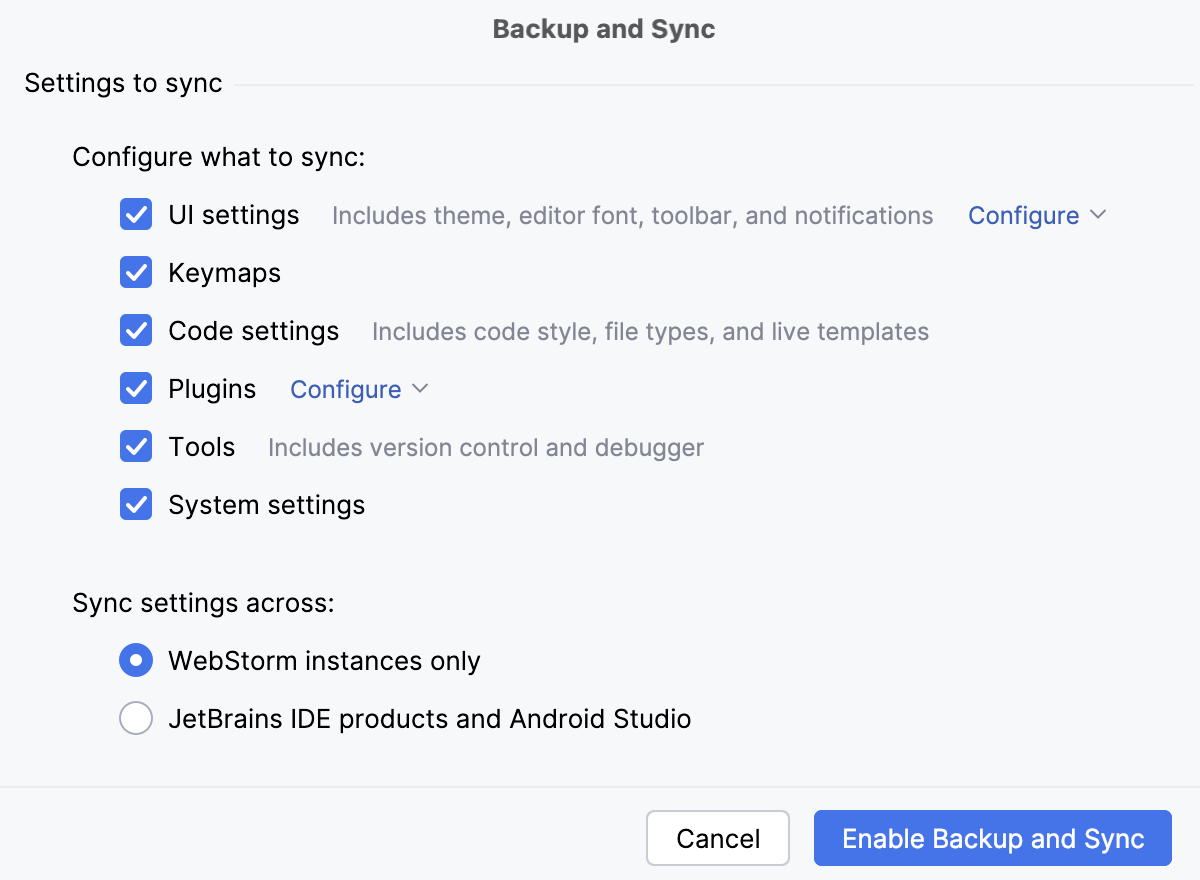
IDE settings backup and sync | WebStorm Documentation
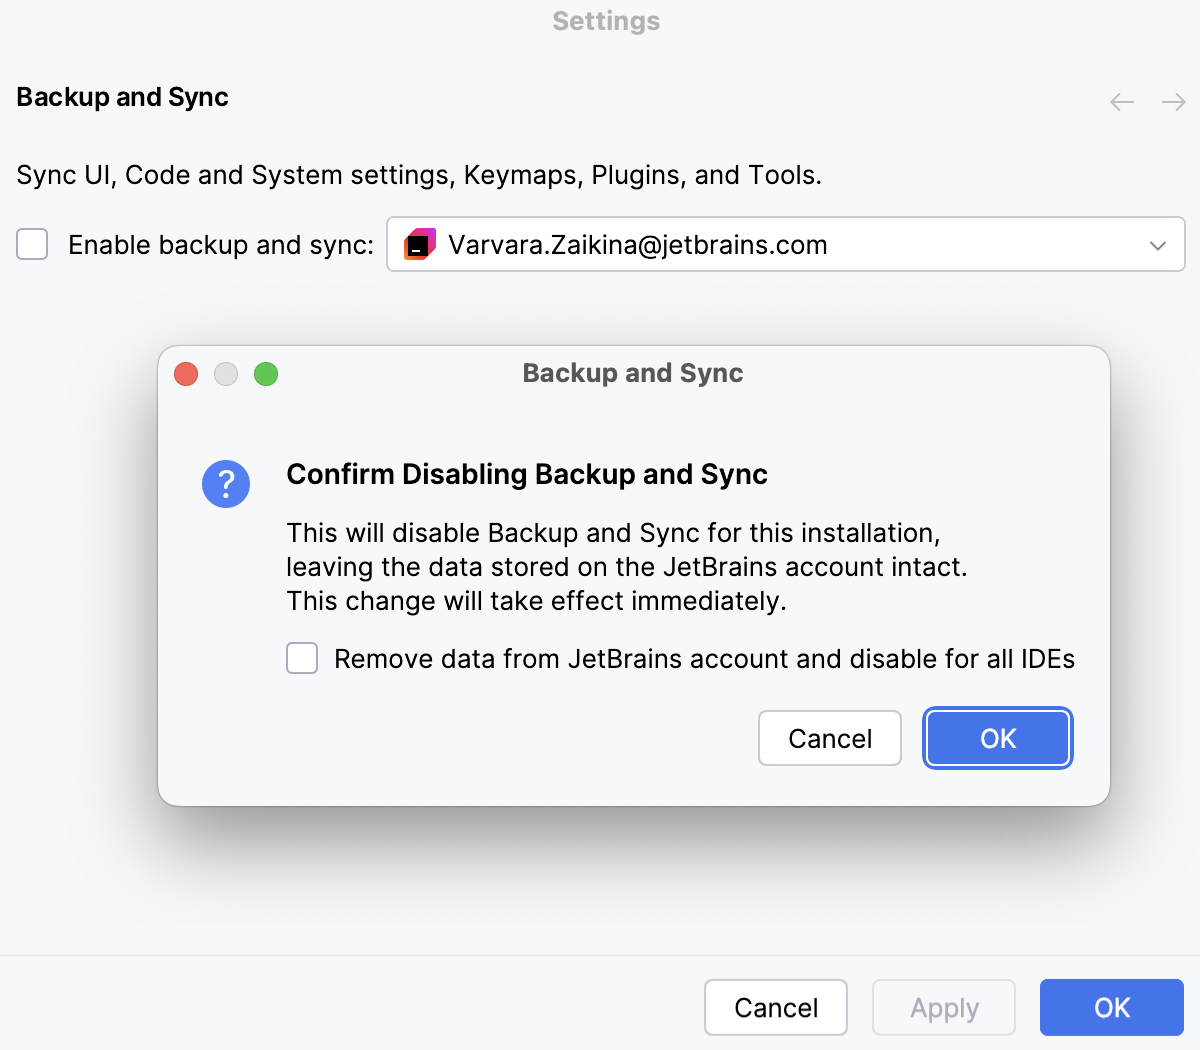
IDE settings backup and sync | WebStorm Documentation
IDE settings backup and sync | DataGrip Documentation
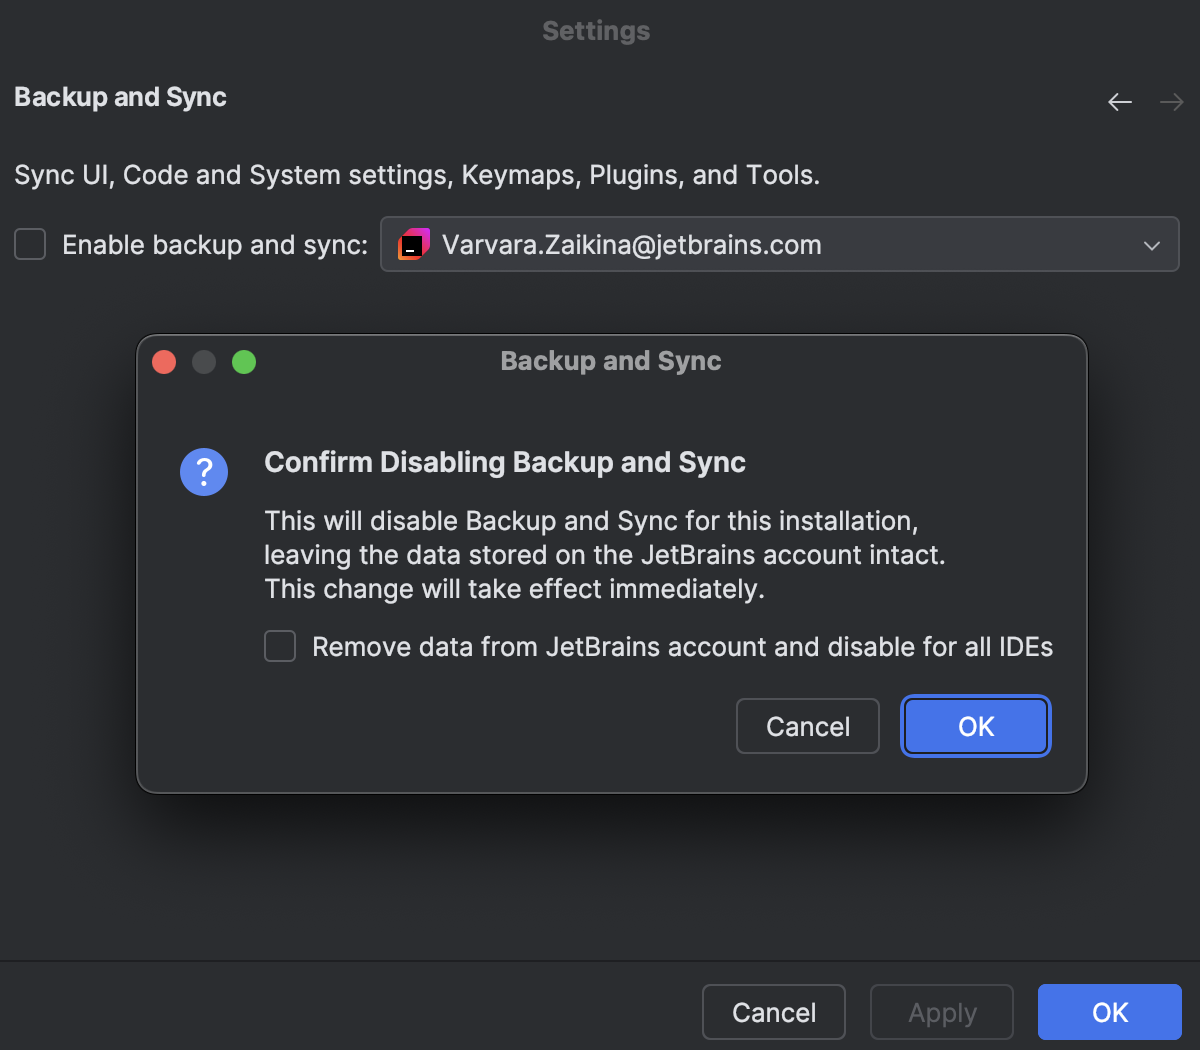
IDE settings backup and sync | WebStorm Documentation
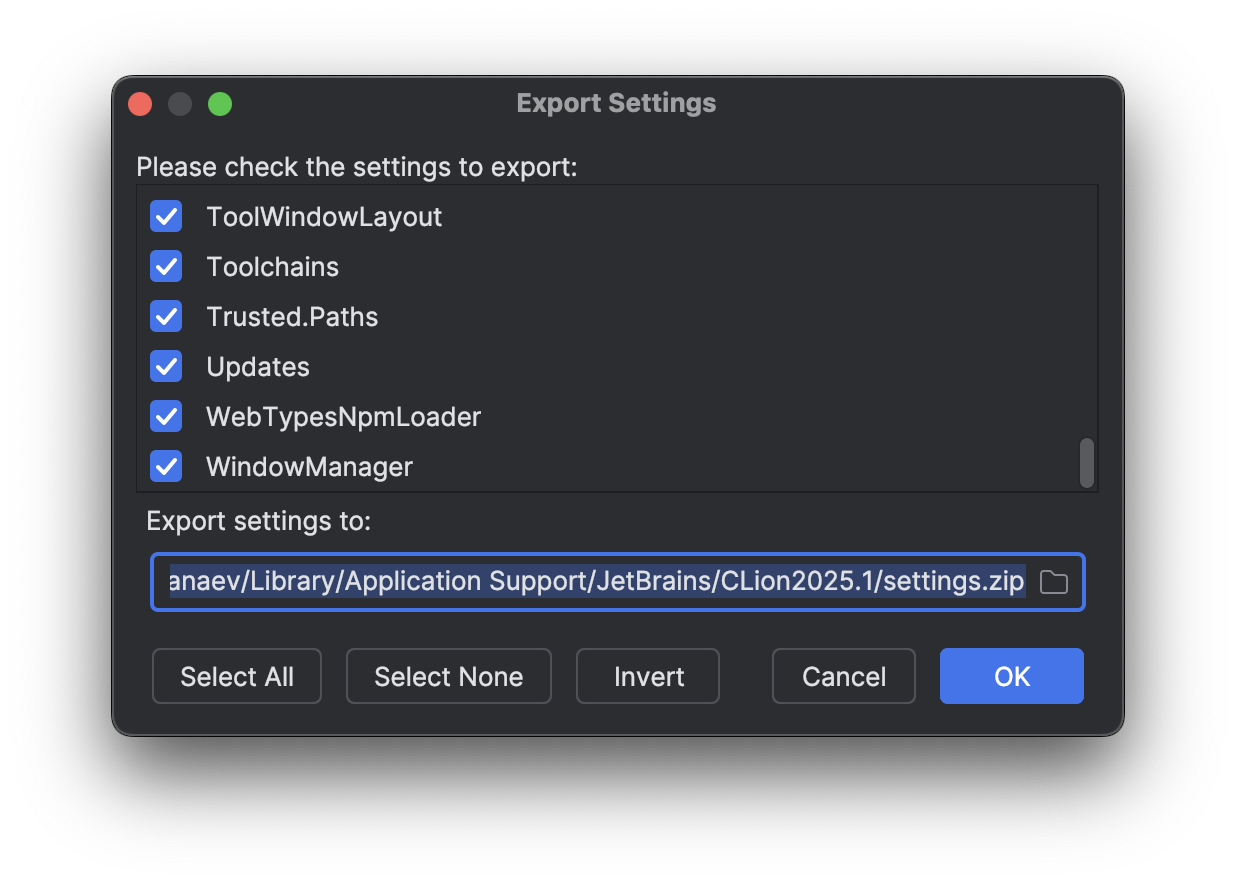
IDE settings backup and sync | CLion Documentation
Advertisement Space (300x250)
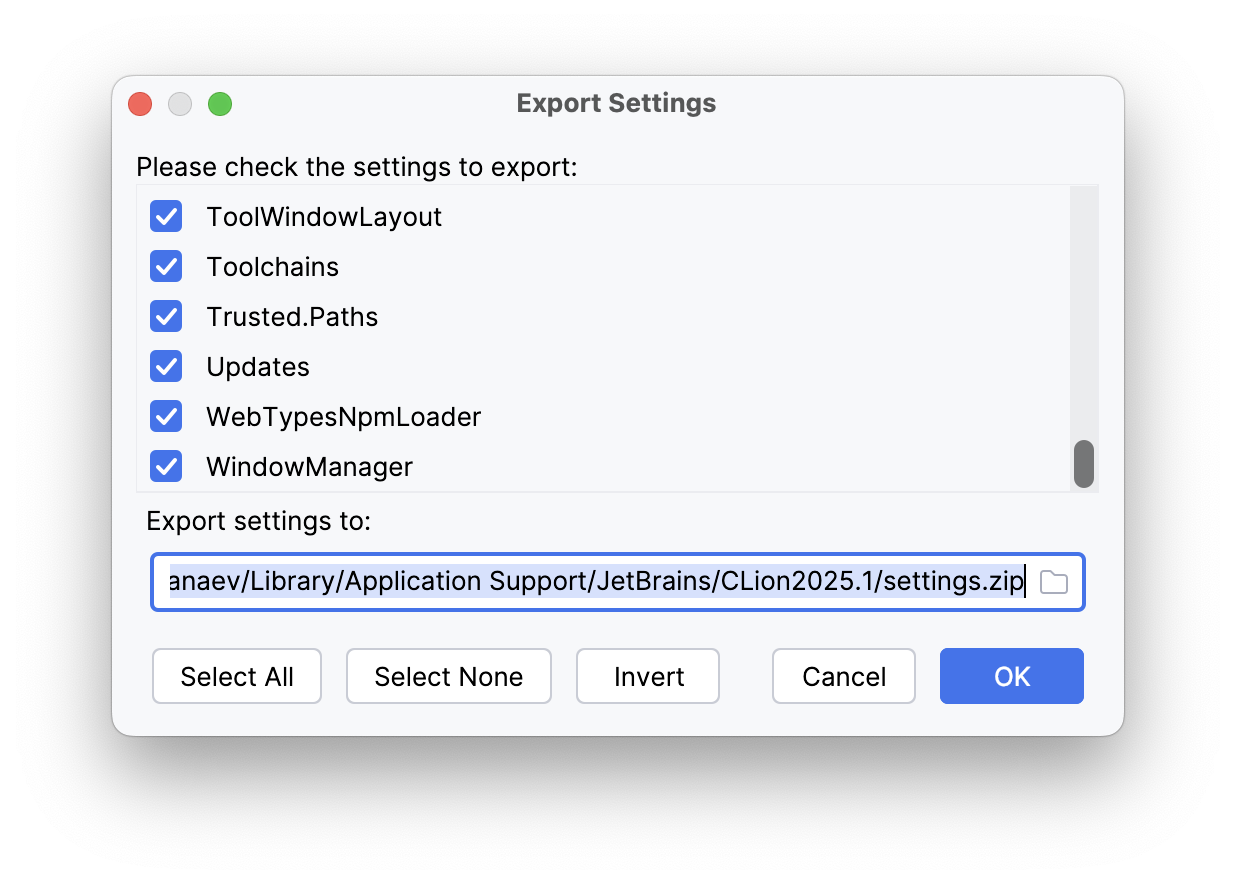
IDE settings backup and sync | CLion Documentation
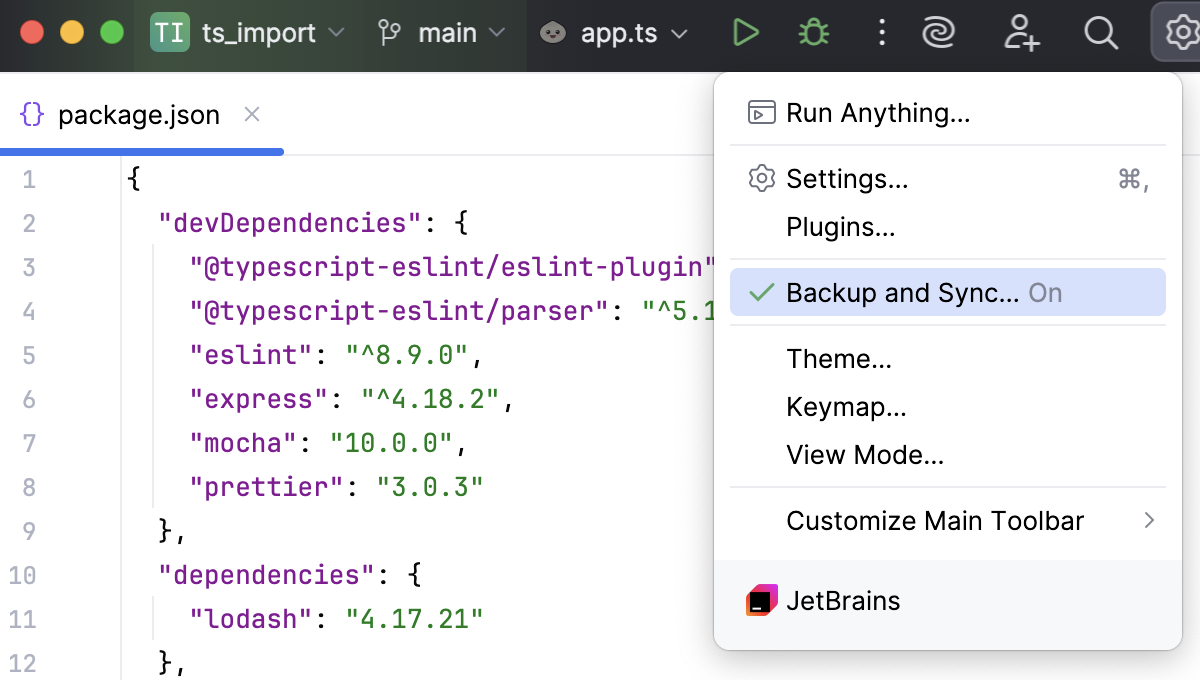
IDE settings backup and sync | WebStorm Documentation
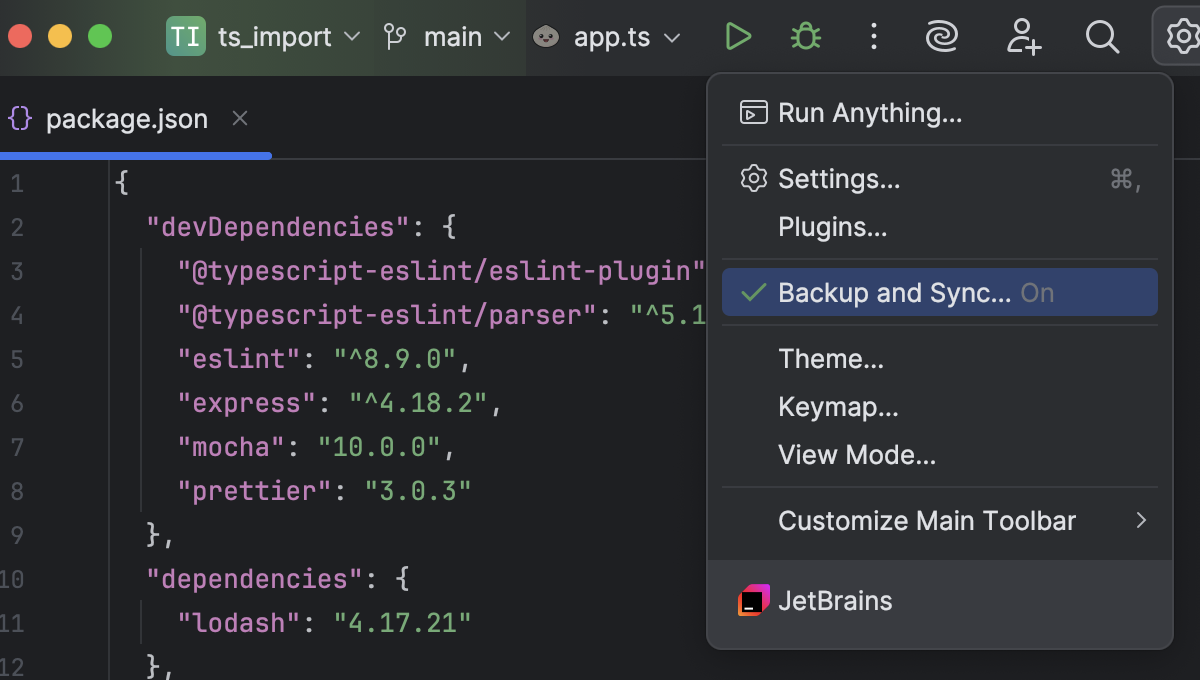
IDE settings backup and sync | WebStorm Documentation
IDE settings backup and sync | IntelliJ IDEA Documentation
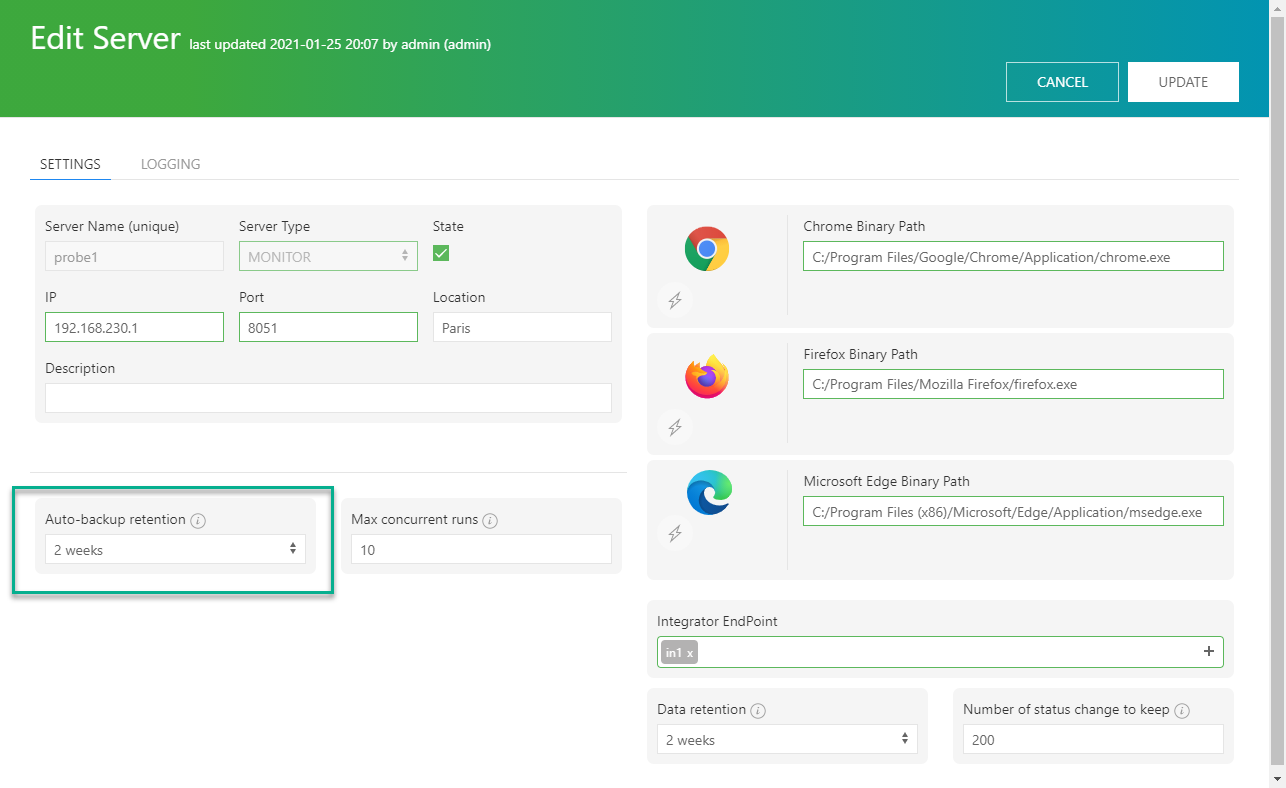
Backup and Restore | Mugnsoft IDE documentation

Share IDE settings | IntelliJ IDEA Documentation

Share IDE settings | WebStorm Documentation

Share IDE settings | IntelliJ IDEA Documentation
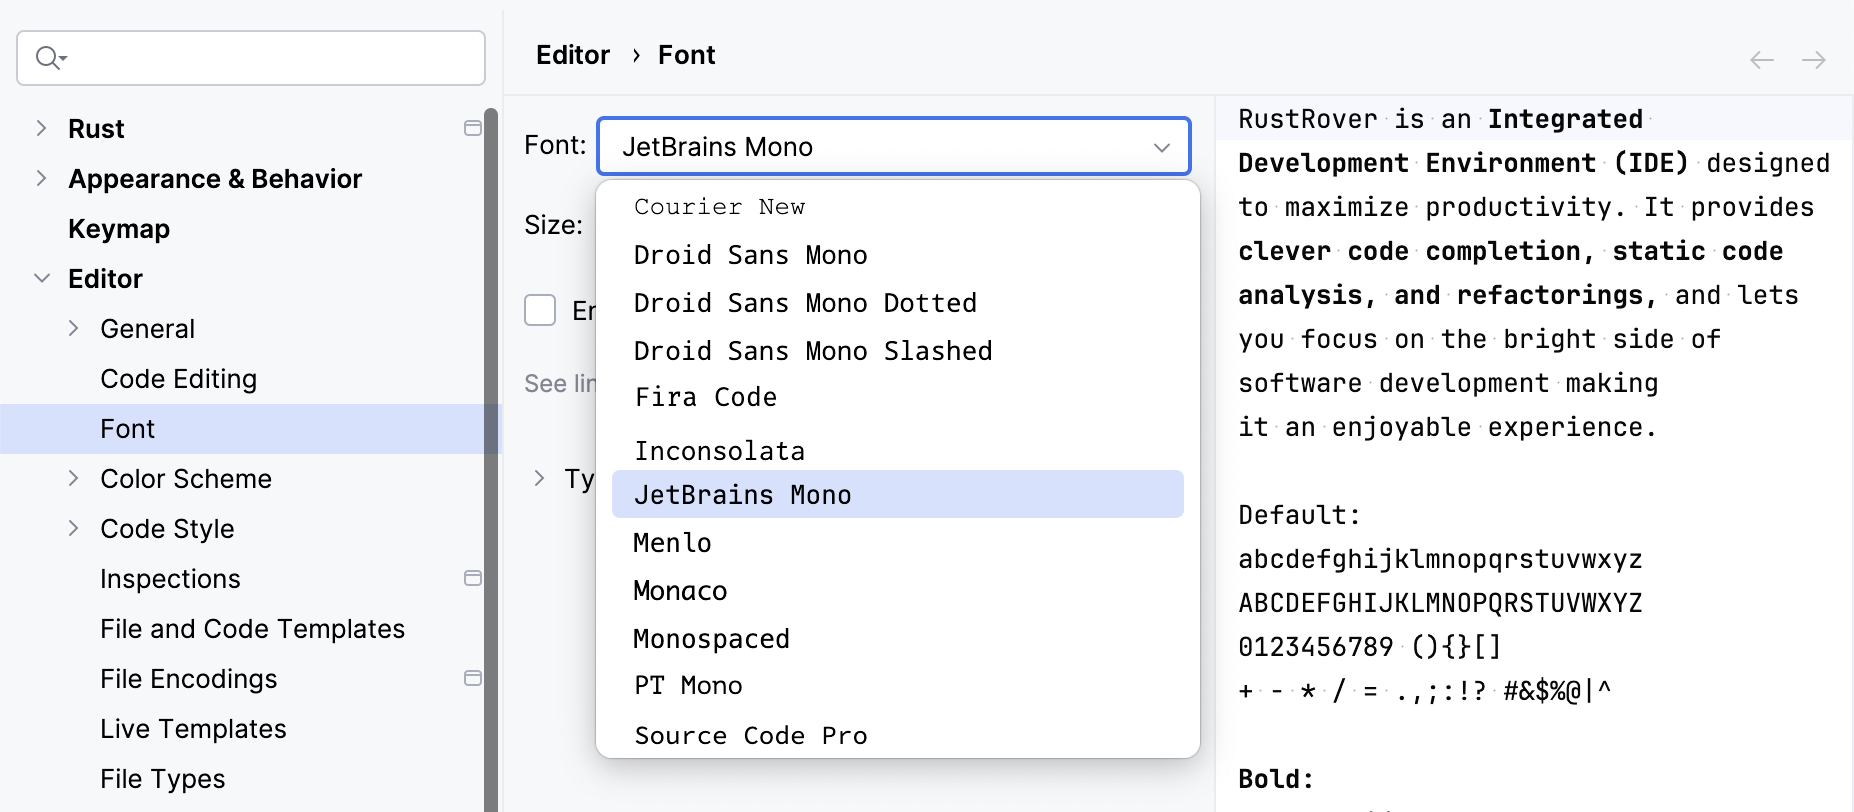
Colors and fonts | RustRover Documentation
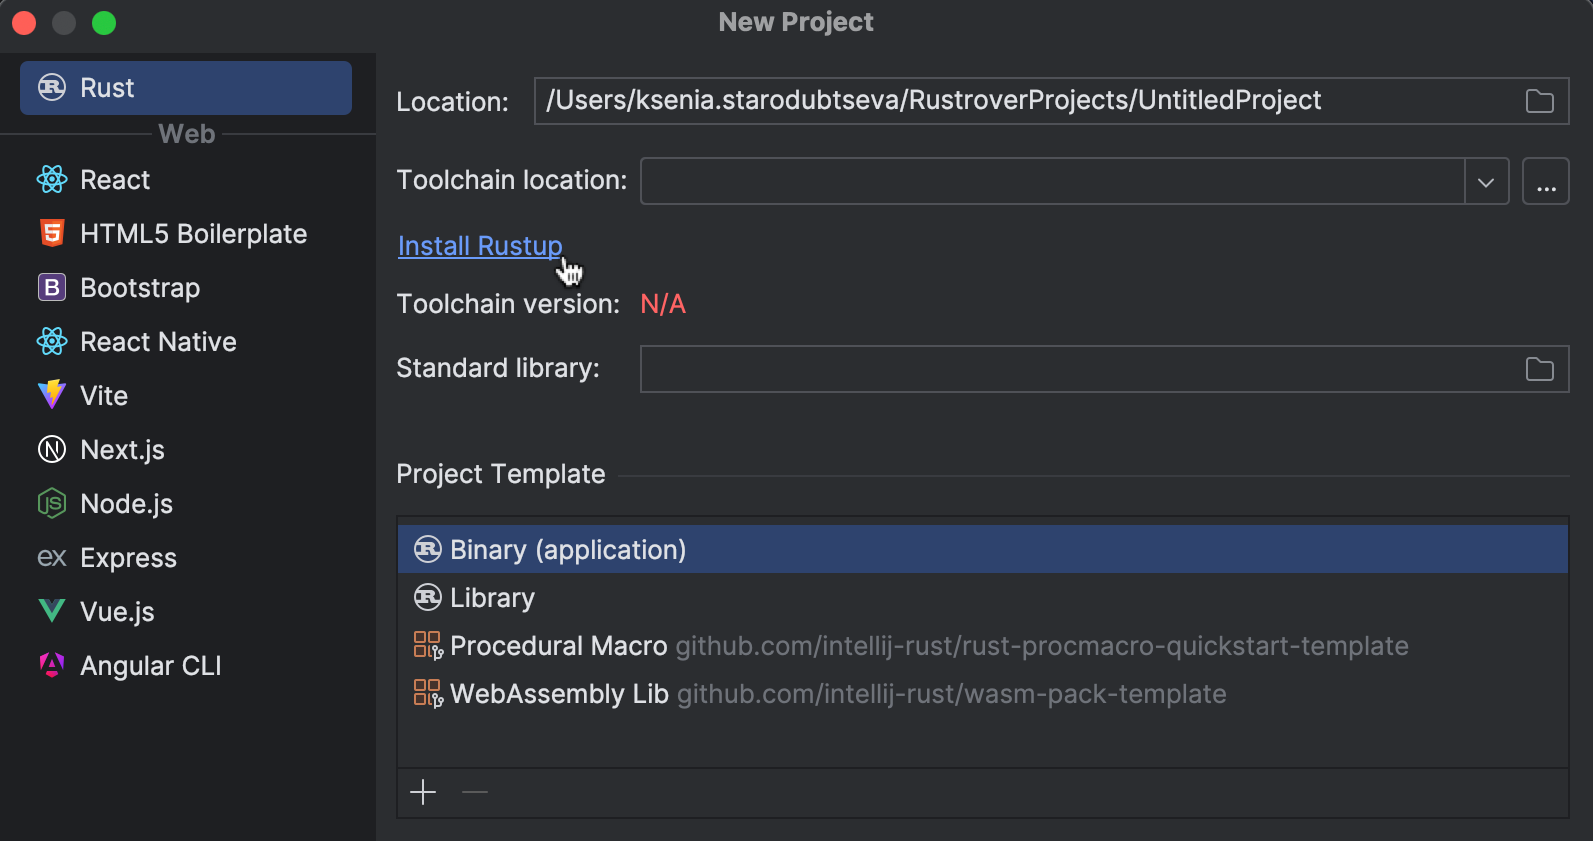
Rust toolchain and standard library | RustRover Documentation
Advertisement Space (336x280)
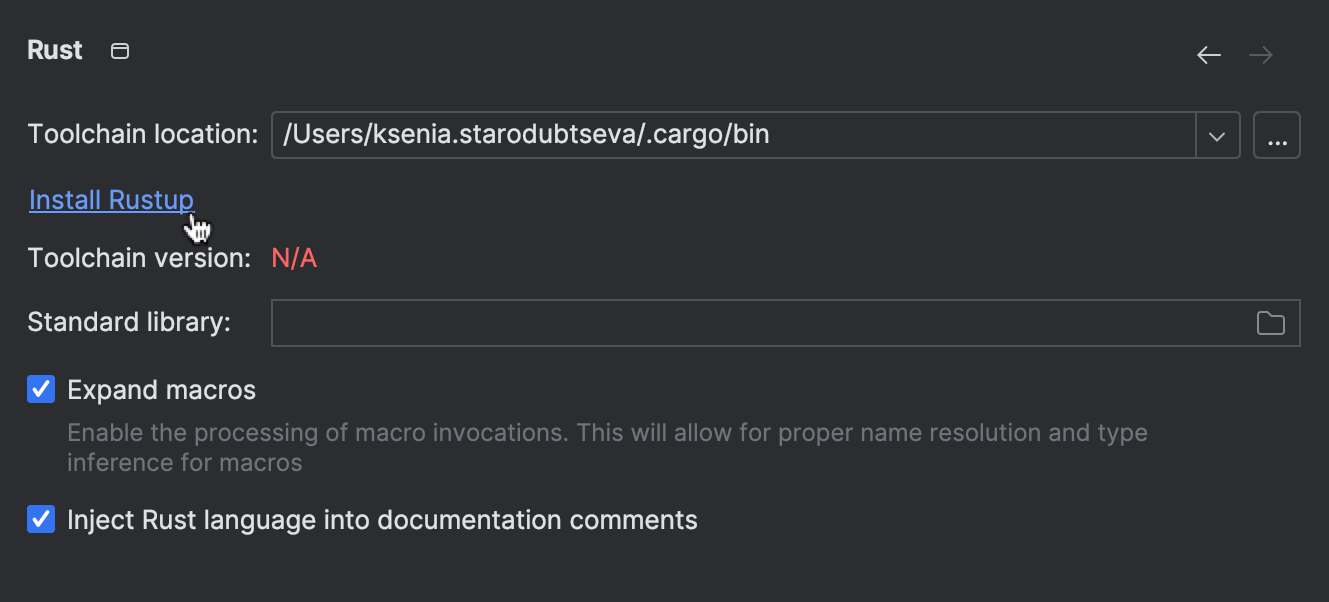
Rust toolchain and standard library | RustRover Documentation
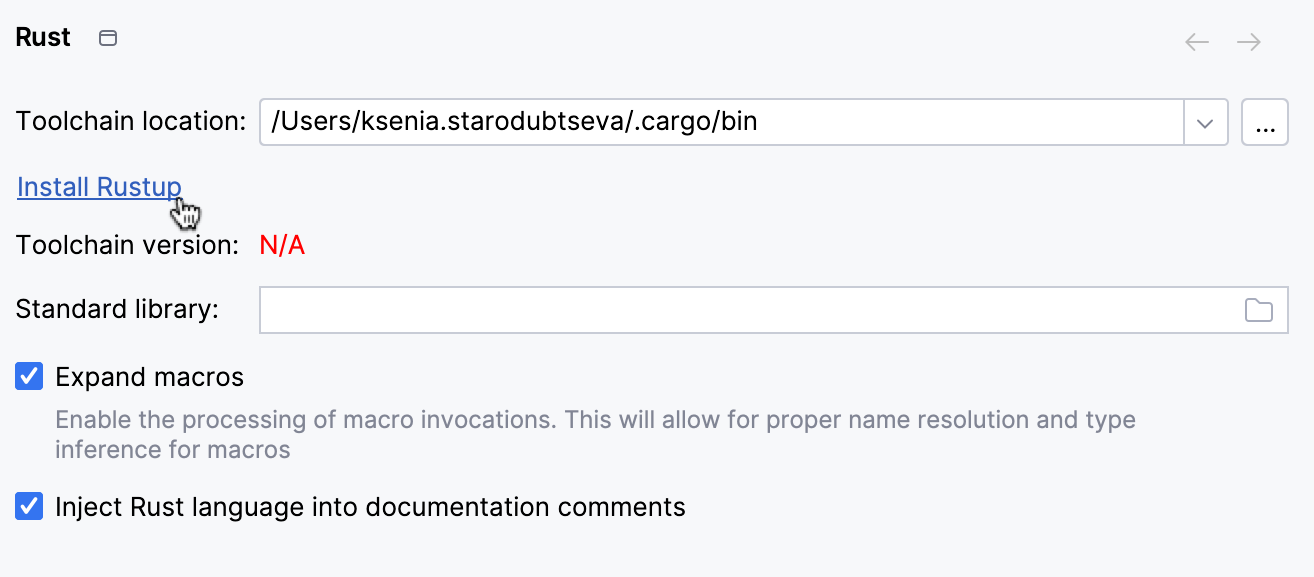
Rust toolchain and standard library | RustRover Documentation

Rust toolchain and standard library | RustRover Documentation
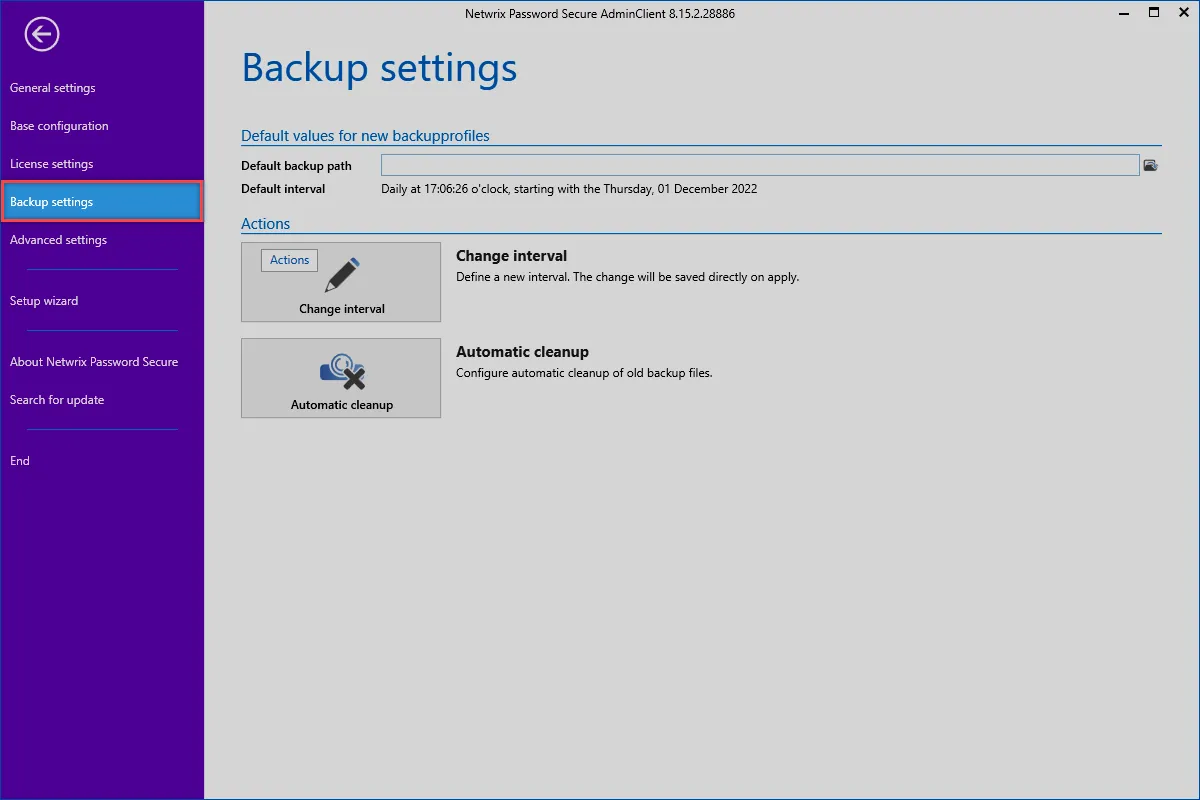
Backup settings | Netwrix Product Documentation

Switching debuggers and renderers | RustRover Documentation

Rust toolchain and standard library | RustRover Documentation
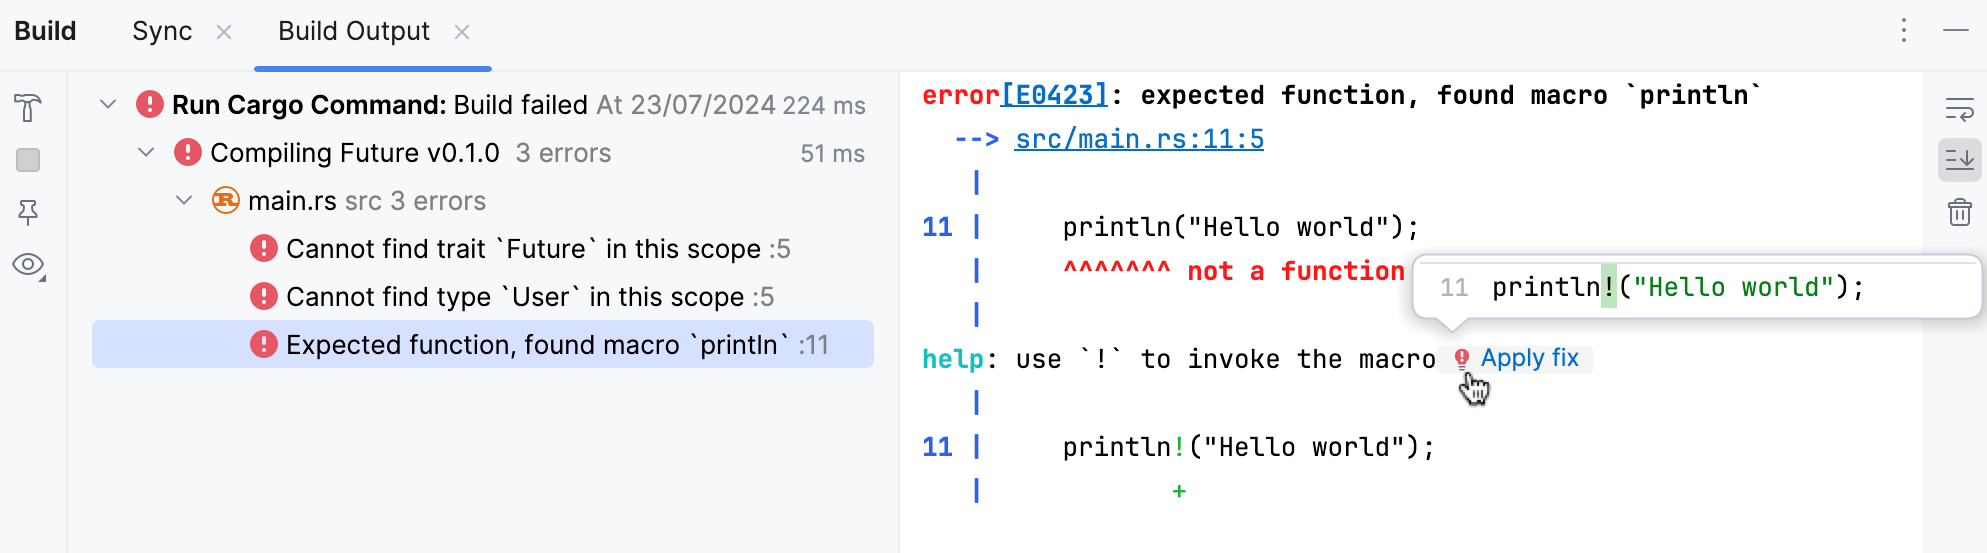
Building and running | RustRover Documentation

Rust toolchain and standard library | RustRover Documentation
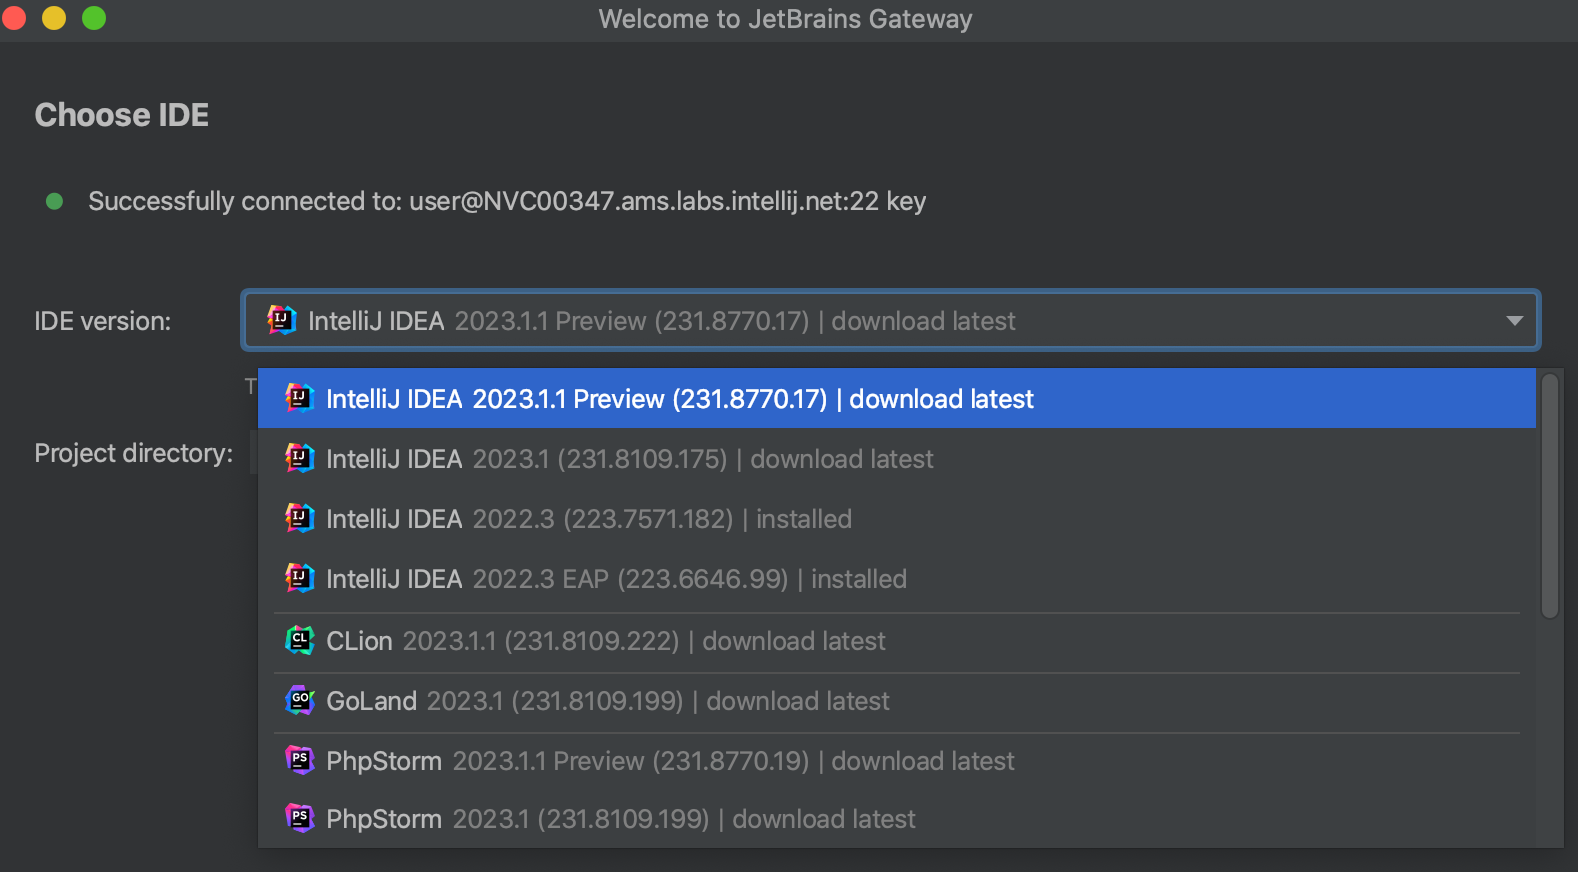
Connect and work with JetBrains Gateway | RustRover Documentation

Rust toolchain and standard library | RustRover Documentation
Advertisement Space (336x280)
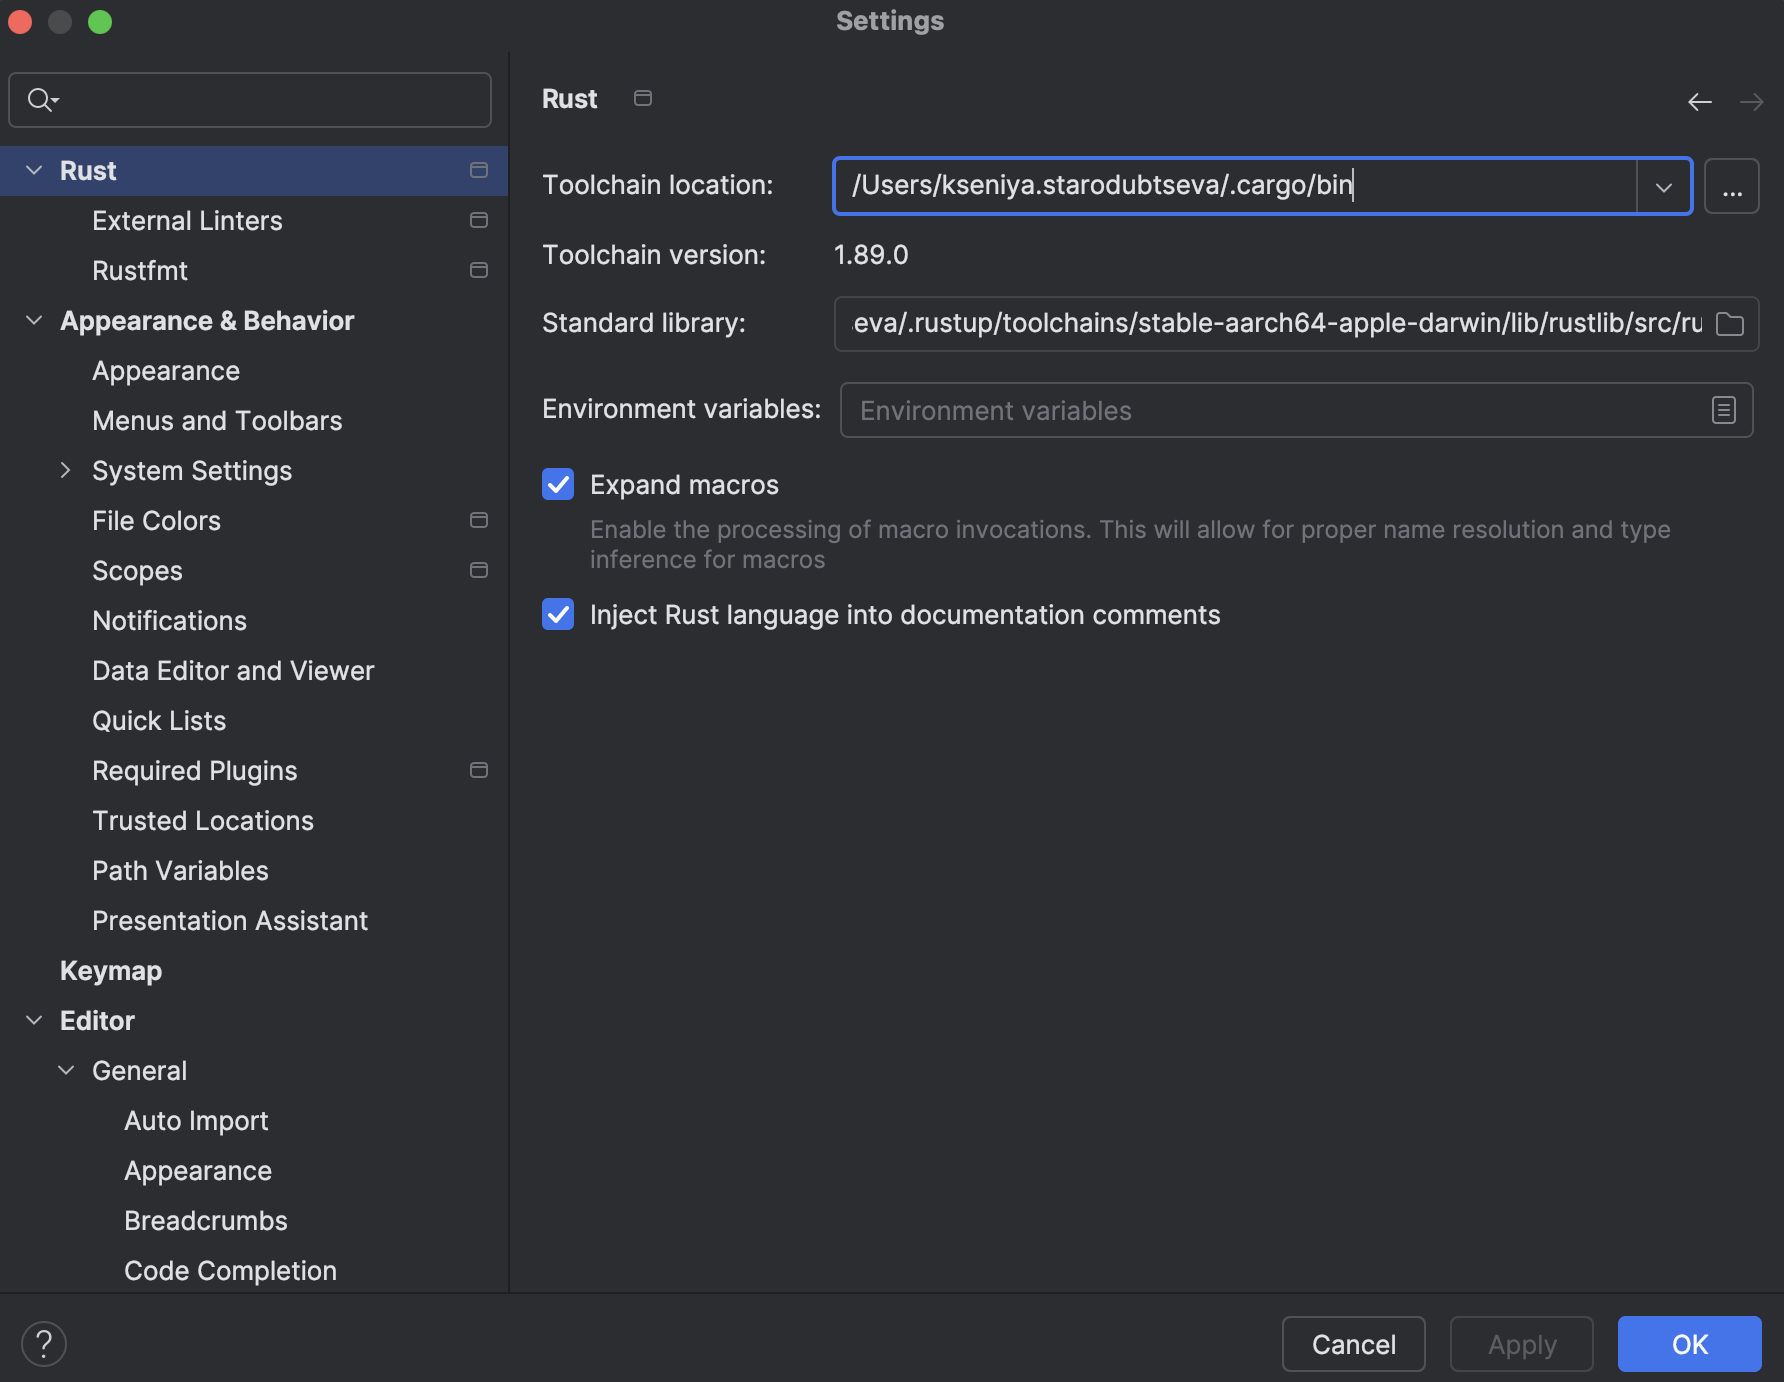
配置 IDE | RustRover 文档

User interface | RustRover Documentation

How to migrate to RustRover from another JetBrains IDE | RustRover ...

IDE configuration | DataGrip Documentation

How to migrate to RustRover from another JetBrains IDE | RustRover ...
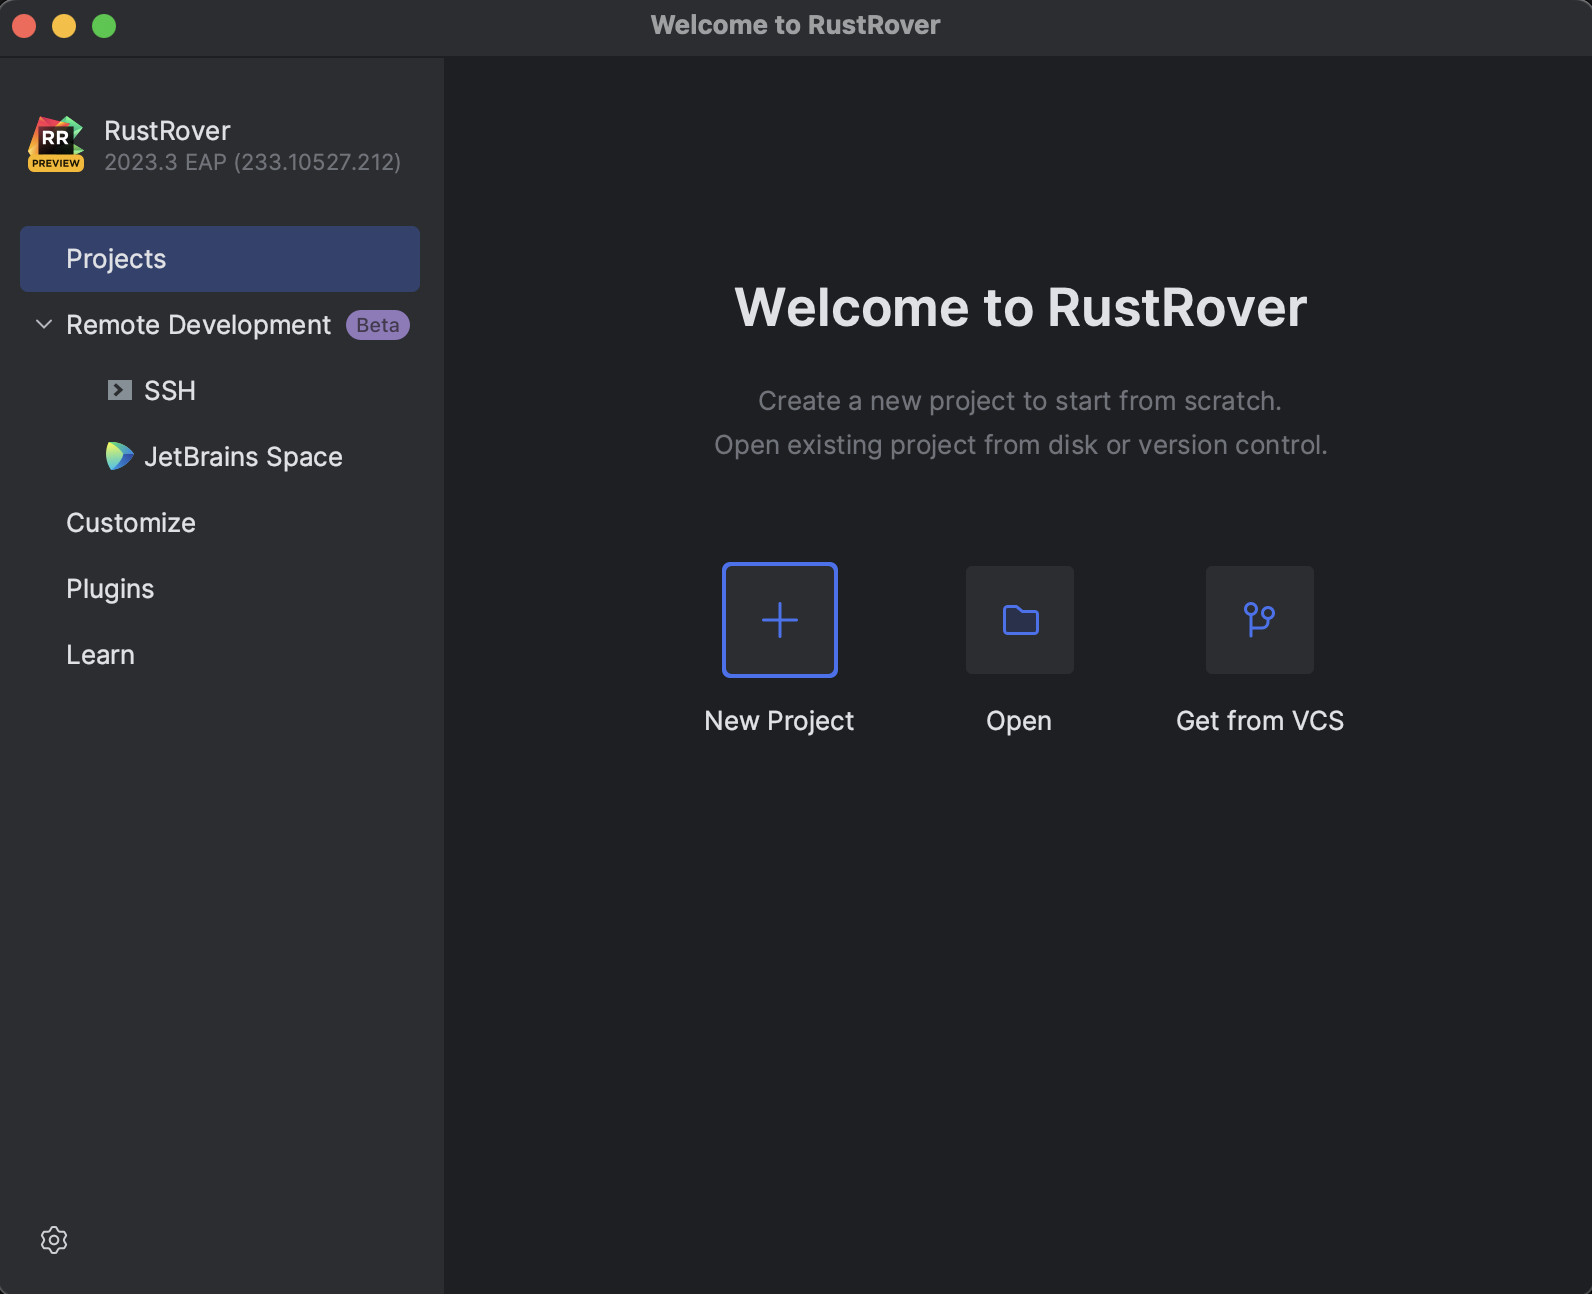
Run RustRover for the first time | RustRover Documentation