
In A B Two Obstacles Are Represented In The Ws 2d And In C Space

In (a)-(b) two obstacles are represented in the WS (2D) and in C-Space ...

In (a)-(b) two obstacles are represented in the WS (2D) and in C-Space ...
A 2D grid (of size 8x8). Two obstacles, in black, are restricting the ...

The left subfigure shows the likelihood, L obs in a 2D space with two ...

A simple 2D example; obstacles are shown in bright red; distance to the ...
Individual obstacles are detected in the voxel space (red voxels), and ...
A set of obstacles in the Workspace is transformed to the C-Space and ...
The obstacles A and B are considered for shielding. Obstacle C is not ...

Three obstacles are randomly placed in the 2D space. The solid curves ...

(b),(c) and (d) are affected in space. In the following two exercises, ch..
Advertisement Space (300x250)

A 2D environment consisting of obstacles in the workspace | Download ...

The obstacles A and B are considered for shielding. Obstacle C is not ...

(a) Top view of a scenario with two obstacles in the environment. The ...

(a) The surface of the topographic map; (b) obstacles represented in ...

(a) The surface of the topographic map; (b) obstacles represented in ...

(a) The surface of the topographic map; (b) obstacles represented in ...

(a) The surface of the topographic map; (b) obstacles represented in ...

A Lower Bounding Framework for Motion Planning amid Dynamic Obstacles in 2D

Consider the workspace shown in the following figure. Obstacles are ...

Obstacles in a given configuration. represented in a polar plane. This ...
Advertisement Space (336x280)

A Lower Bounding Framework for Motion Planning amid Dynamic Obstacles in 2D

14.1.3 Obstacles in the Phase Space

Example of obstacles (blue) above the public sidewalk (brown) in a ...

Scenario used for the simulations presented in Table I. Obstacles are ...

The C-space obstacles may contain wells that trap planners in local ...
Obstacle positions in beams attack (a-b) and orbs attack (c-d) in two ...

Avoiding Dense and Dynamic Obstacles in Enclosed Spaces: Application to ...

First simulation: a single static obstacles in a two-dimensional ...

(PDF) Epistemological Obstacles in Solving 2D Geometry Problems Using ...

Left: δ-obstacles obtained by virtually expanding the obstacles as in ...
Advertisement Space (336x280)
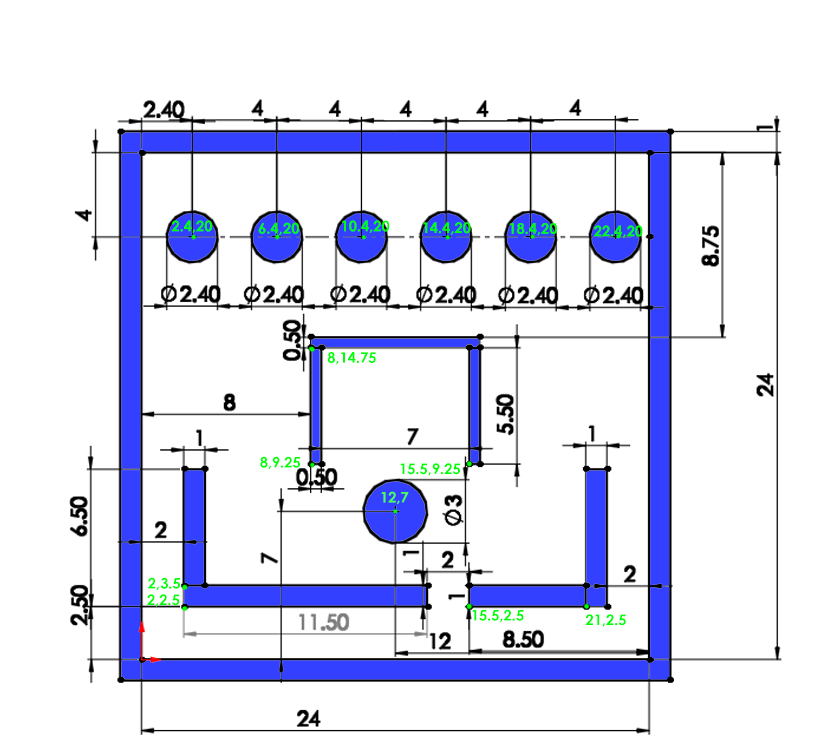
Path Finding in a 2D Environment for a Robot | Ben’s Portfolio

SOLVED: QUESTION: Between the two images A and B representing a CAD ...
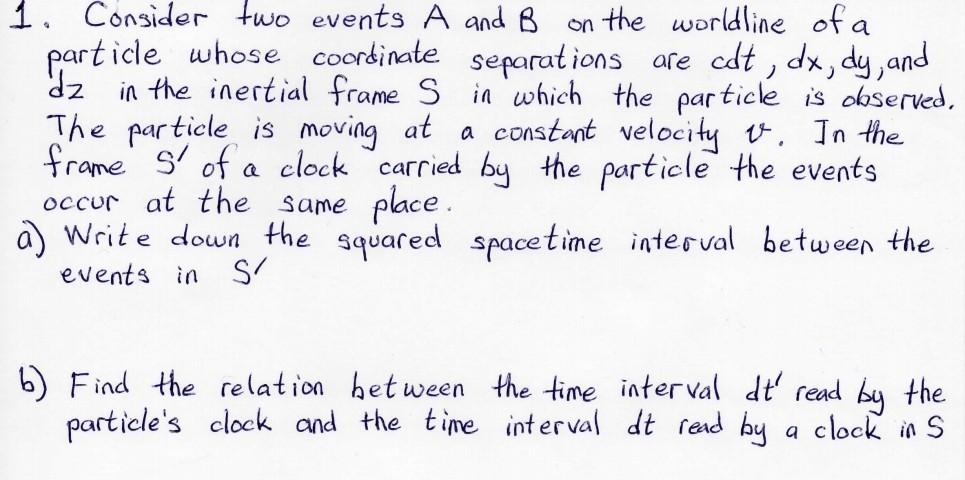
Solved 1. Consider two events A and B on the worldline of a | Chegg.com

In the surrounding with analytical obstacle descriptions (brown), a ...

a) Workspace: two obstacles and a moving object. b) Cspace obstacles ...
a A one-obstacle environment. b Augmented obstacles due to the cables ...