
Interactive Force Control Based On Multimodal Robot Skin For Physical

Interactive Force Control Based on Multimodal Robot Skin for Physical ...

Interactive Force Control Based on Multimodal Robot Skin for Physical ...

Interactive Force Control Based on Multimodal Robot Skin for Physical ...

Interactive Force Control Based on Multimodal Robot Skin for Physical ...

Interactive Force Control Based on Multimodal Robot Skin for Physical ...

Interactive Force Control Based on Multimodal Robot Skin for Physical ...

Interactive Force Control Based on Multimodal Robot Skin for Physical ...

Interactive Force Control Based on Multimodal Robot Skin for Physical ...

(PDF) Interactive Force Control Based on Multimodal Robot Skin for ...

Interactive Force control based on Multi-Modal Robot Skin for physical ...
Advertisement Space (300x250)

An MPC-DCM Control Method for a Forward-Bending Biped Robot Based on ...

Research on Multimodal Control Method for Prosthetic Hands Based on ...
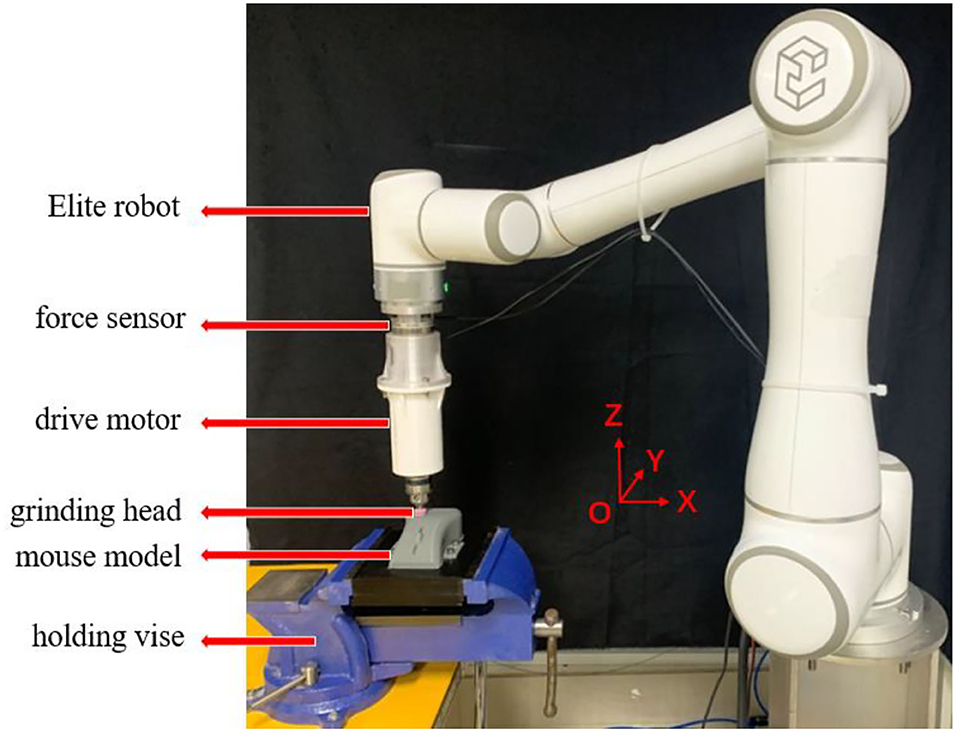
Frontiers | A Compliant Force Control Scheme for Industrial Robot ...

Physical human-robot interface based on force sensors | Download ...
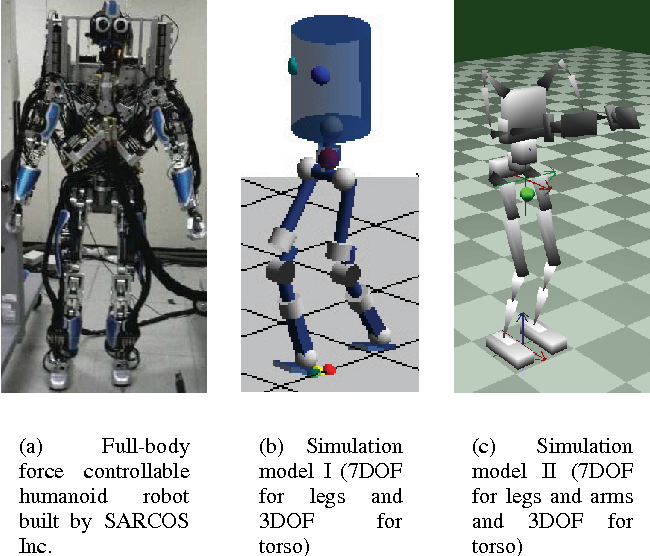
Figure 1 from Passivity-Based Full-Body Force Control for Humanoids and ...

Soft robot skin with stretchable structure for on-body tactile ...

Real‐Time Control of a Humanoid Robot for Whole‐Body Tactile ...
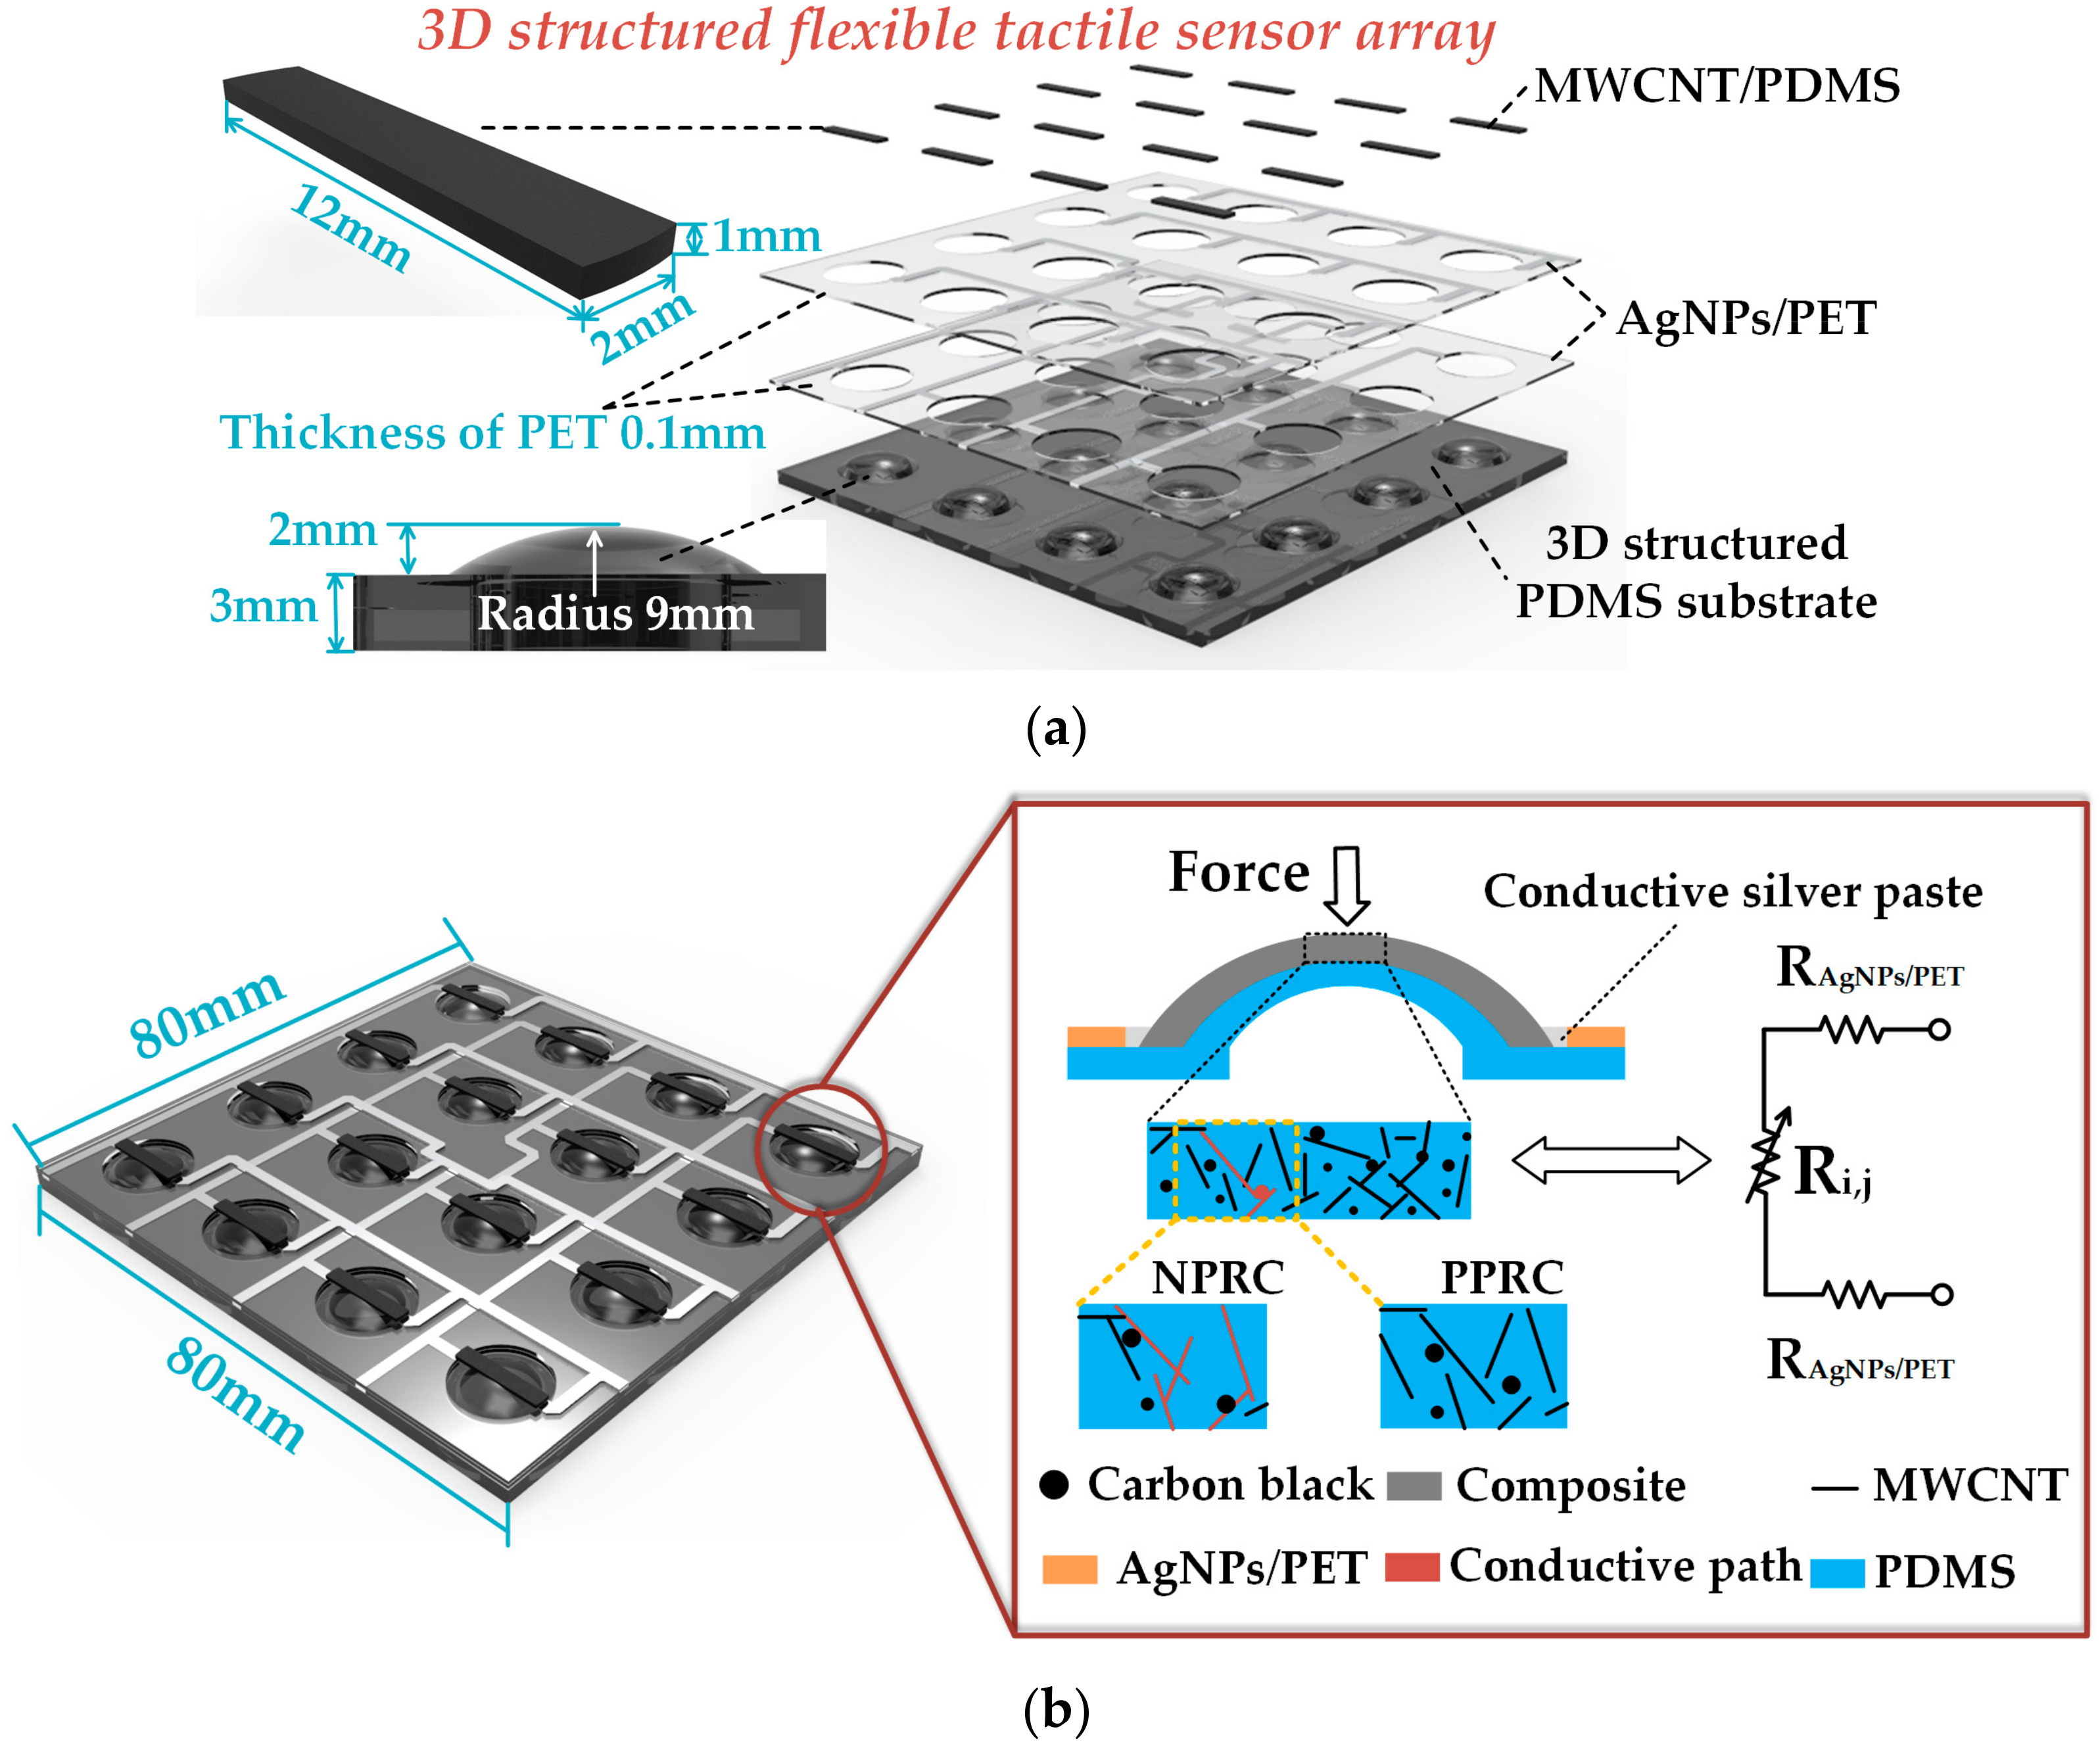
Development of Flexible Robot Skin for Safe and Natural Human–Robot ...
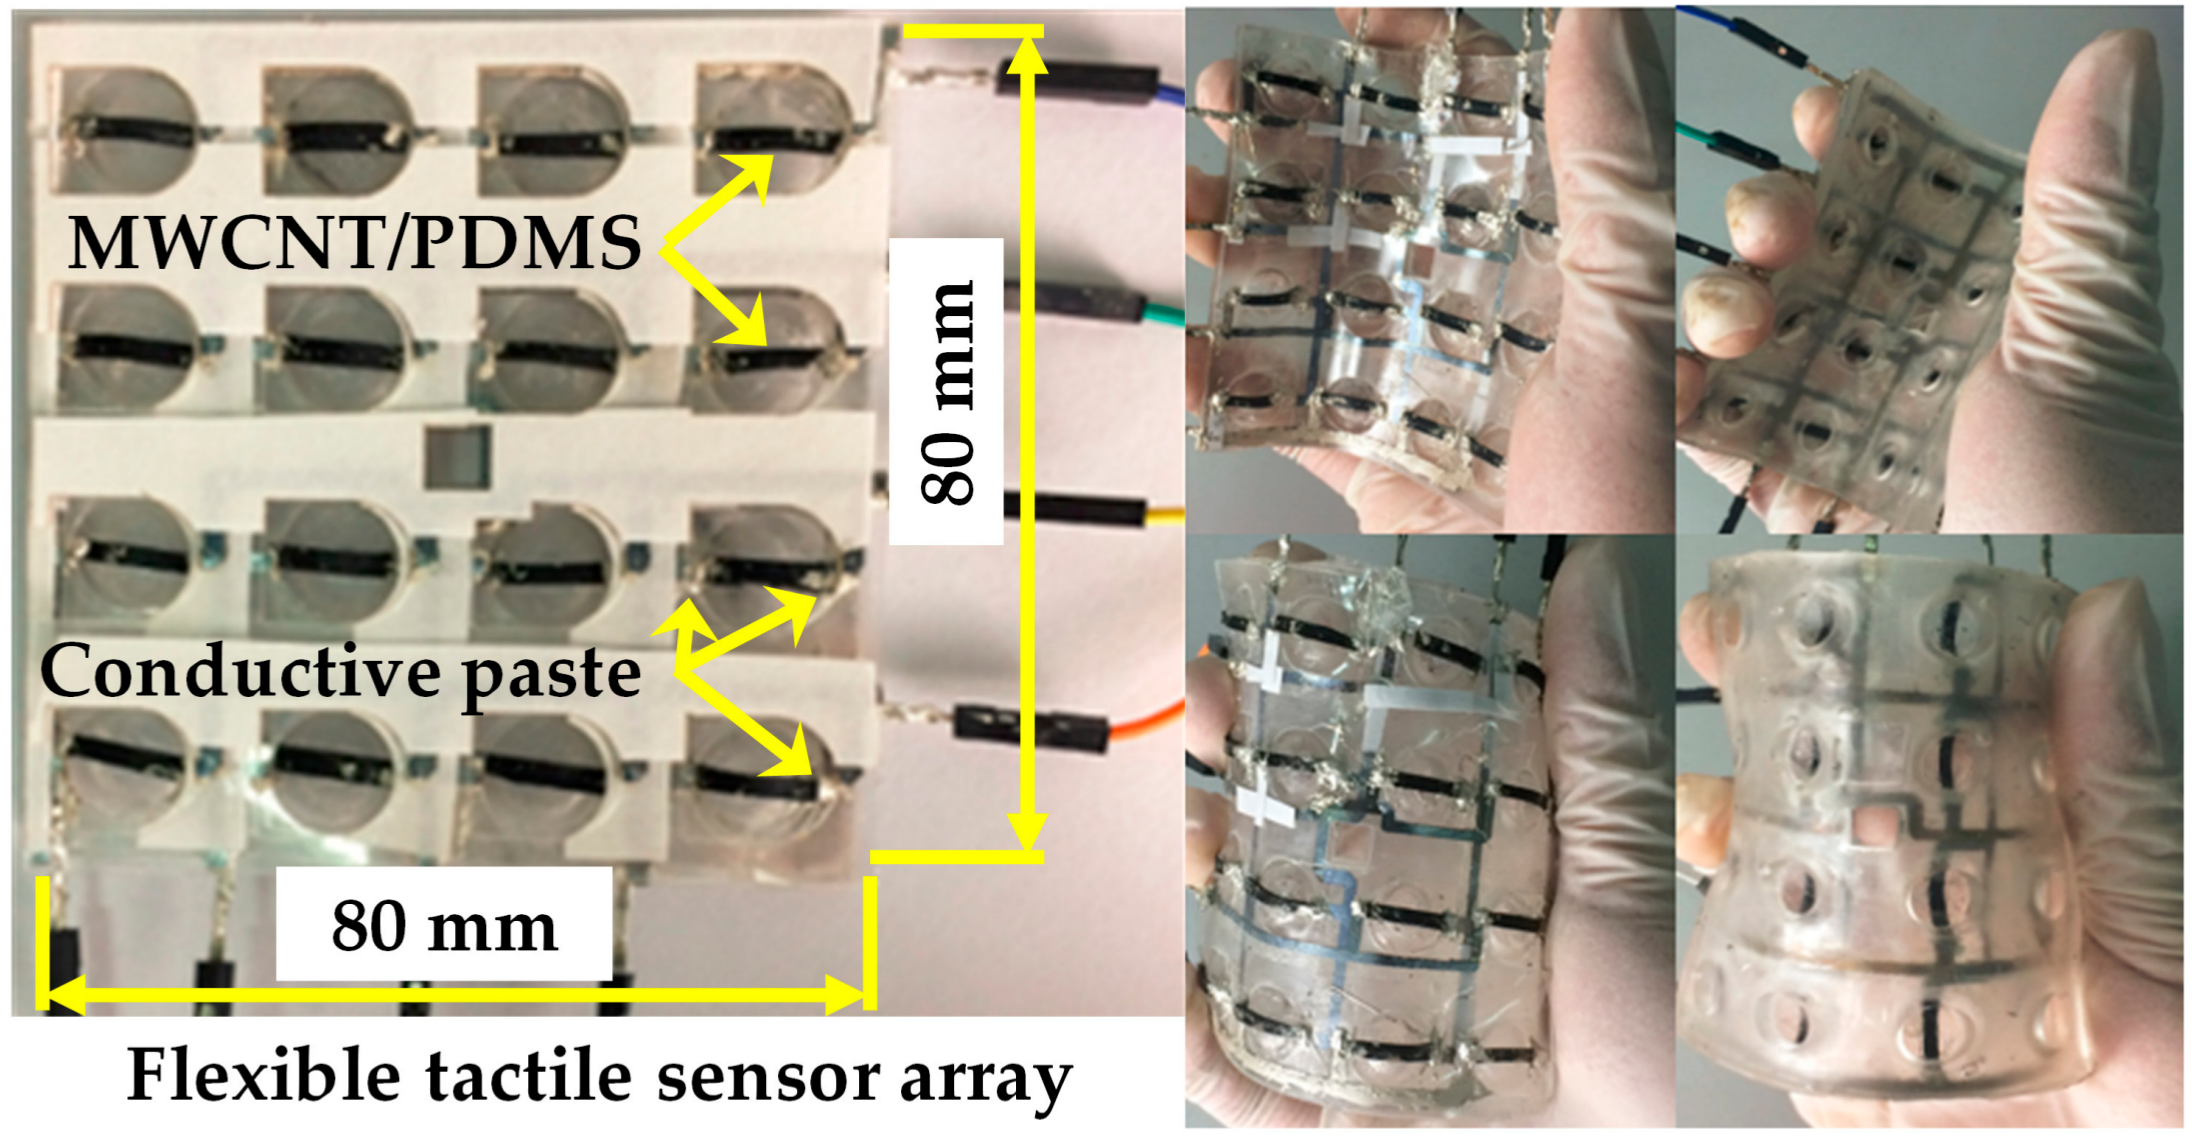
Development of Flexible Robot Skin for Safe and Natural Human–Robot ...

Human-robot collaborative interaction force and interactive control ...
Advertisement Space (336x280)

Soft Conductive Hydrogel-Based Electronic Skin for Robot Finger ...
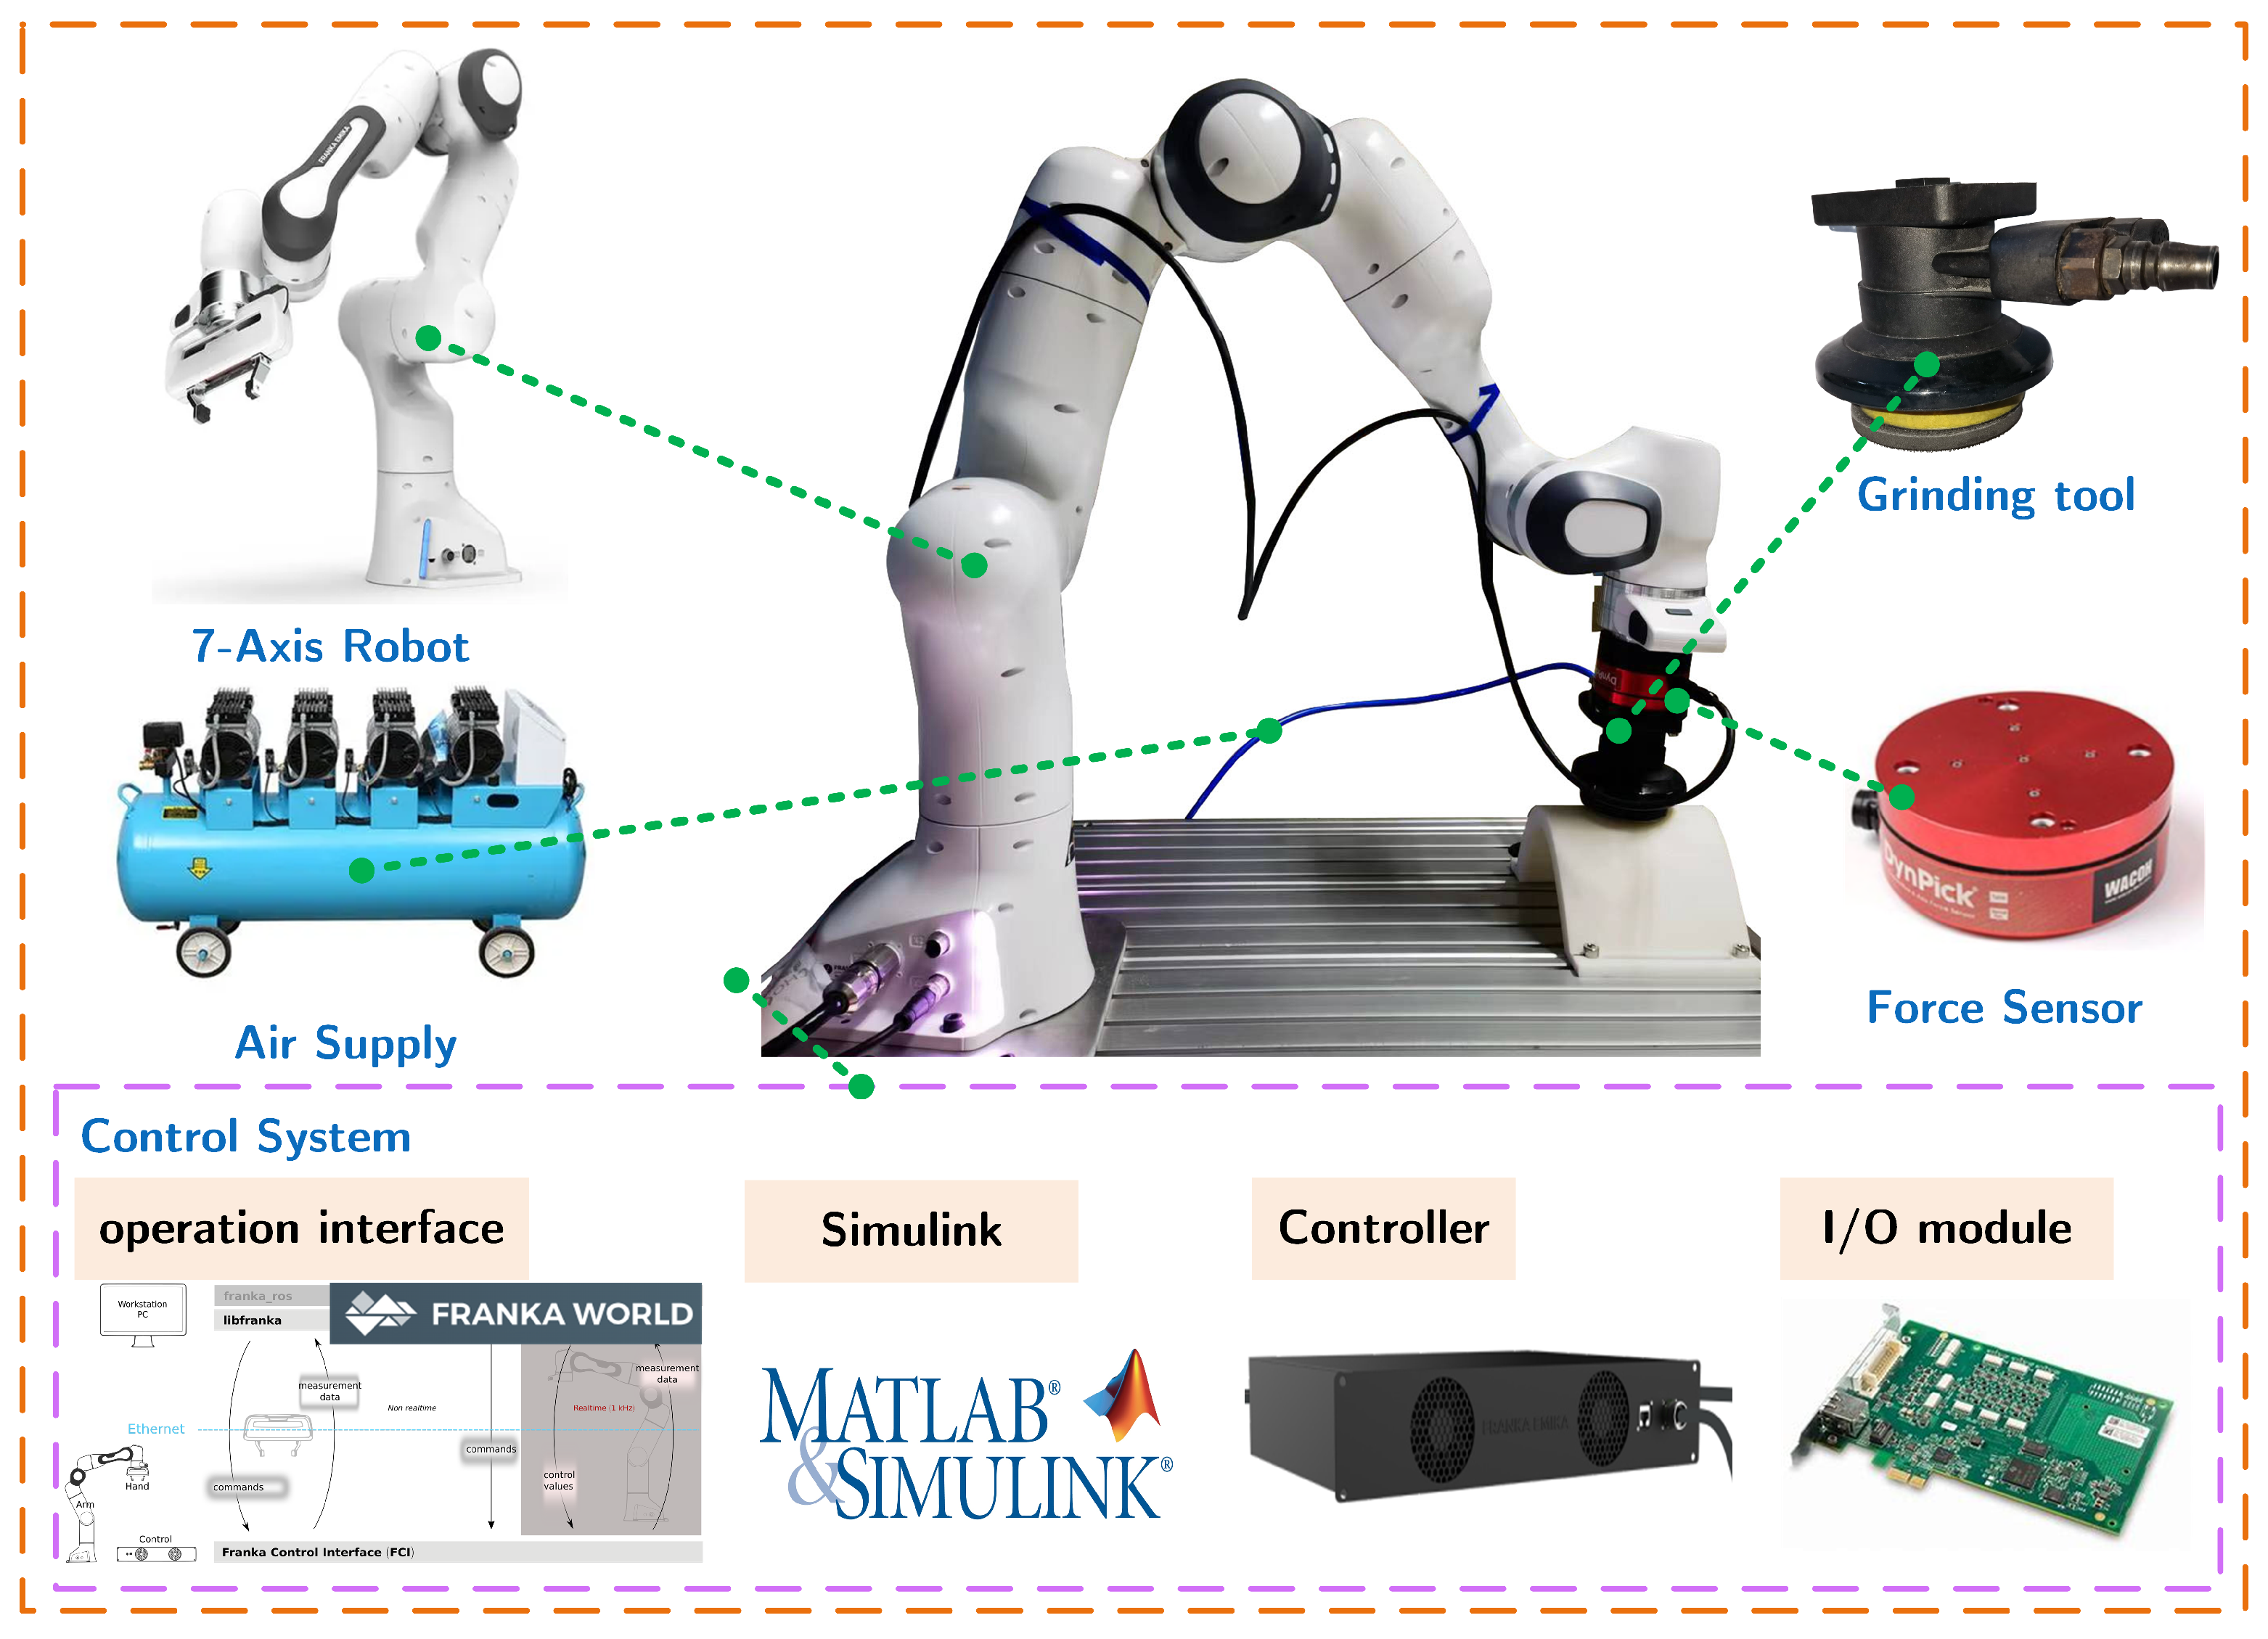
Dual PID Adaptive Variable Impedance Constant Force Control for ...
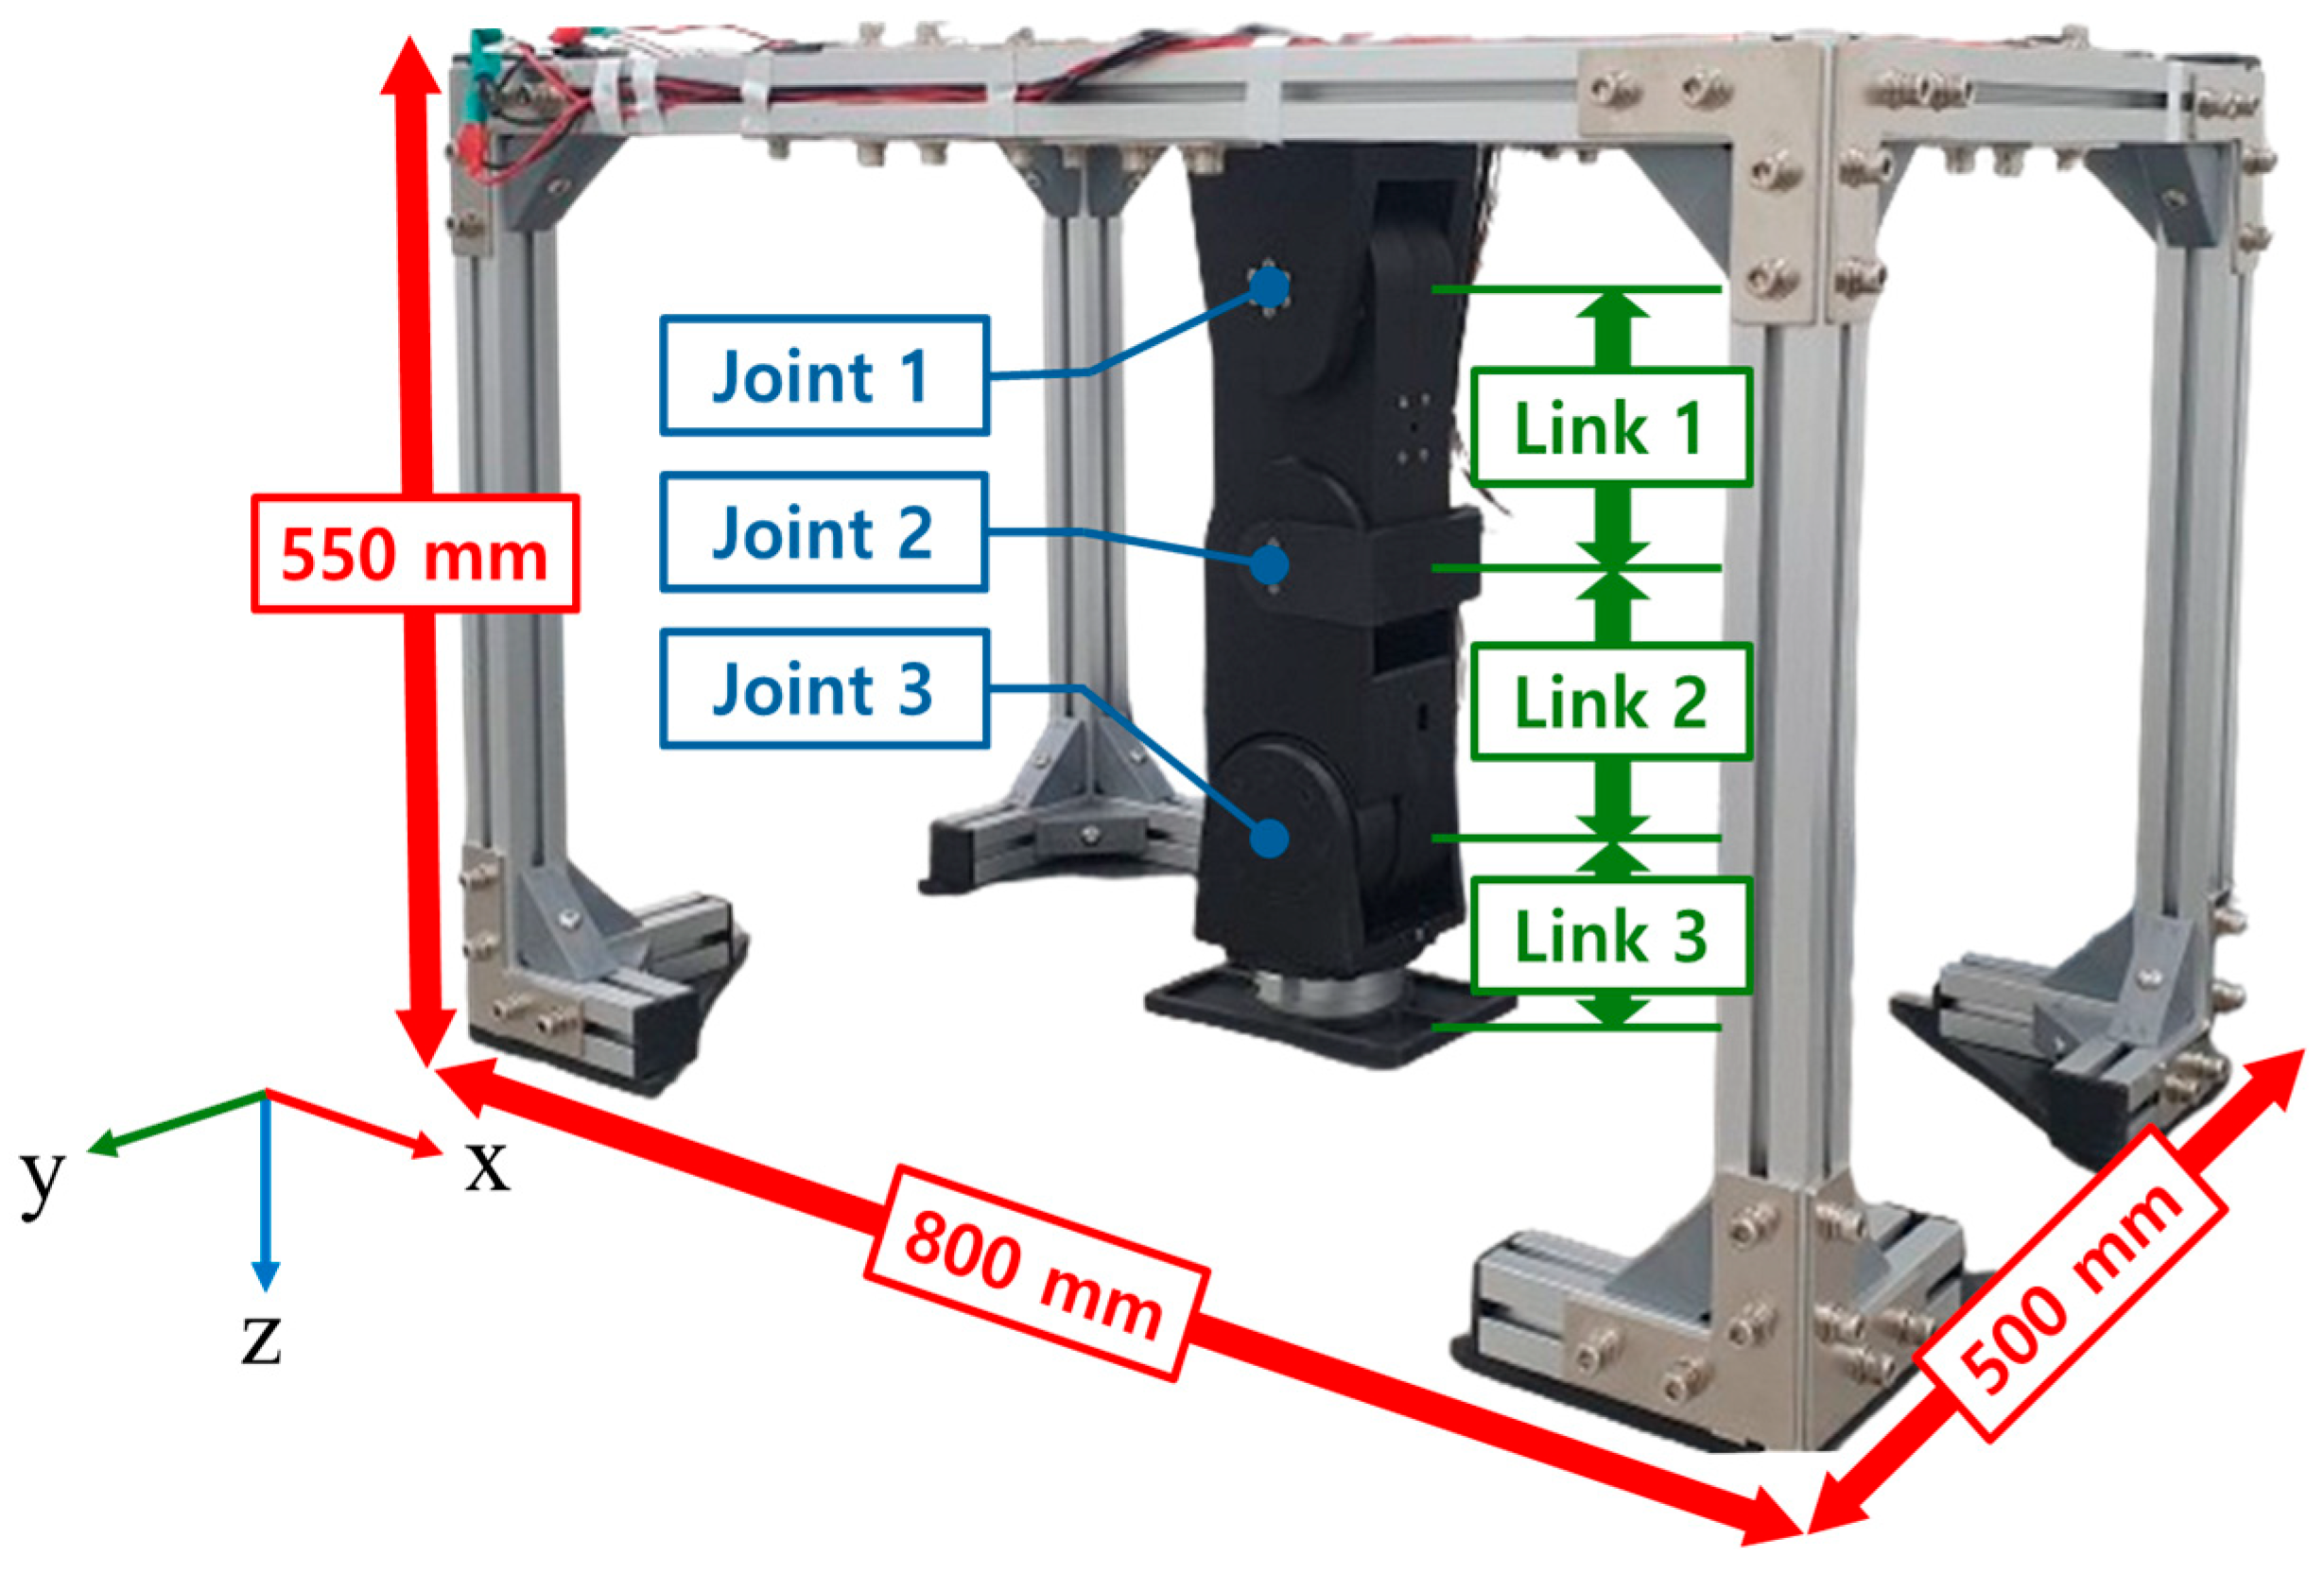
Deep Learning-Based Contact Force Control for a Robotic Leg

A Flexible Multimodal Sole Sensor for Legged Robot Sensing Complex ...
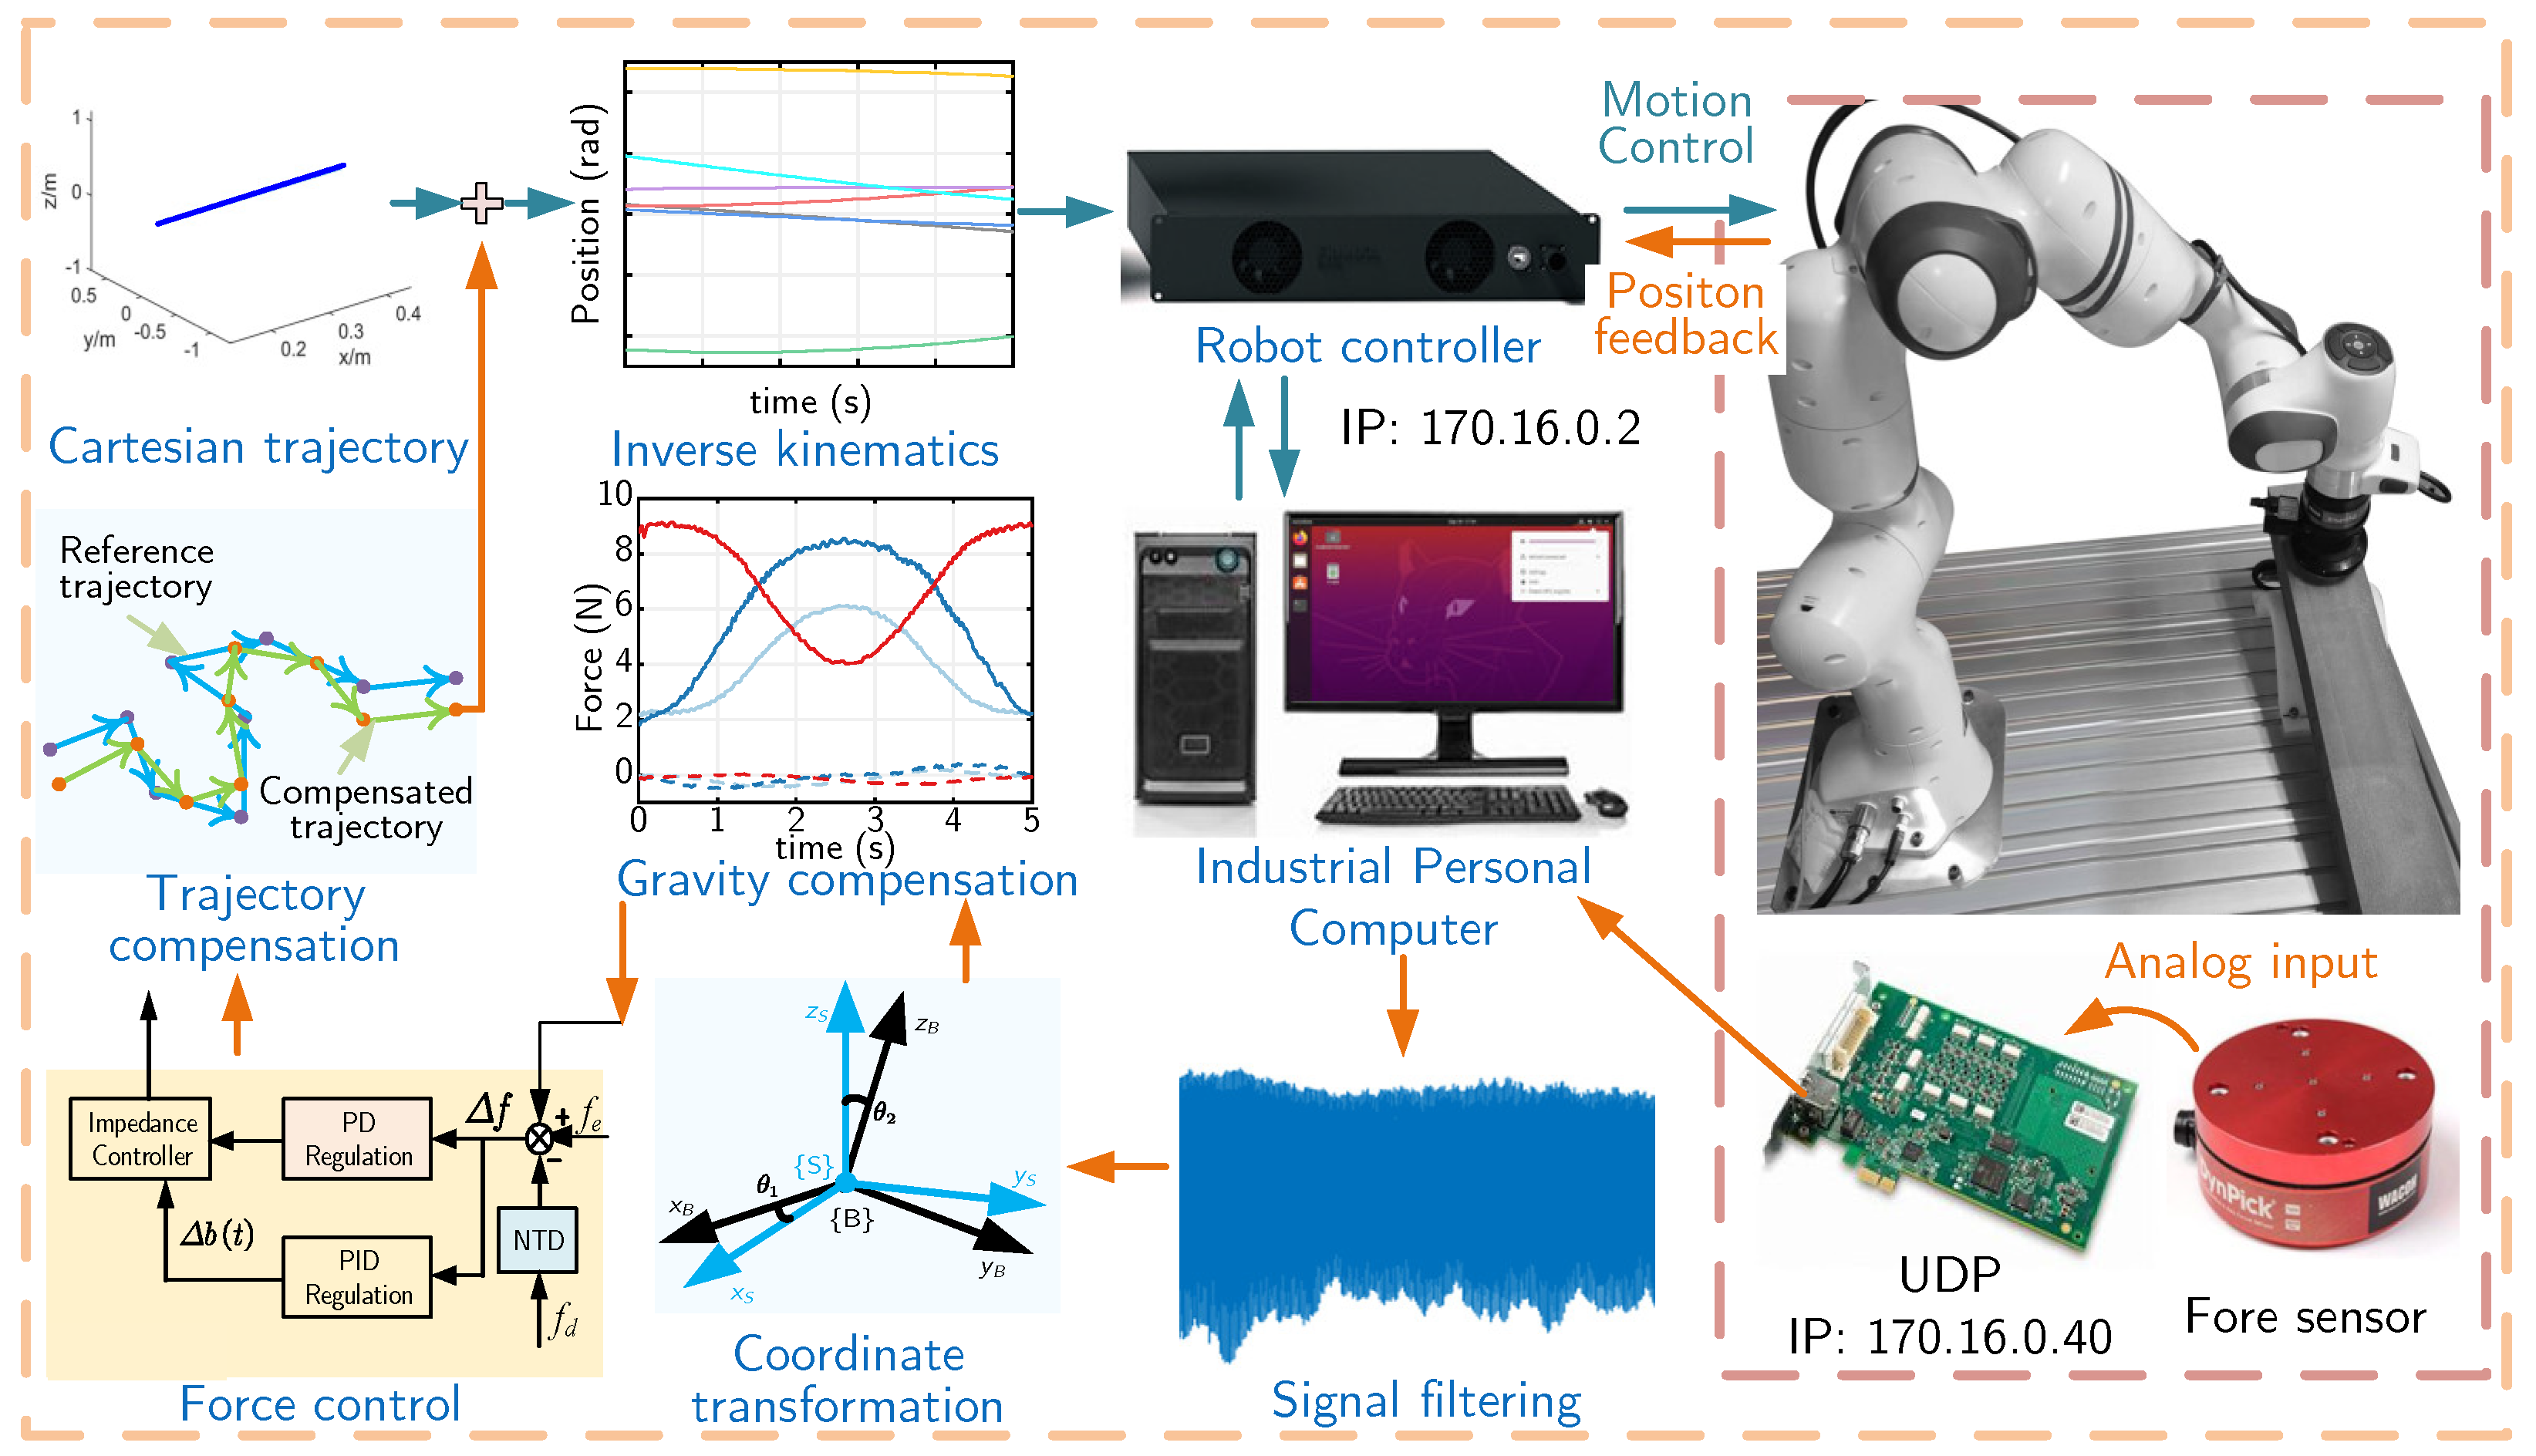
Dual PID Adaptive Variable Impedance Constant Force Control for ...

Figure 2 from A Conformable Force/Tactile Skin for Physical Human–Robot ...

A Force Control Method Integrating Human Skills for Complex Surface ...

Development of Flexible Robot Skin for Safe and Natural Human–Robot ...

[论文评述] Robot Tactile Gesture Recognition Based on Full-body Modular E-skin

Soft robot skin with stretchable structure for on-body tactile ...
Advertisement Space (336x280)

Survey of Visual and Force/Tactile Control of Robots for Physical ...

(PDF) A Conformable Force/Tactile Skin for Physical Human-Robot Interaction
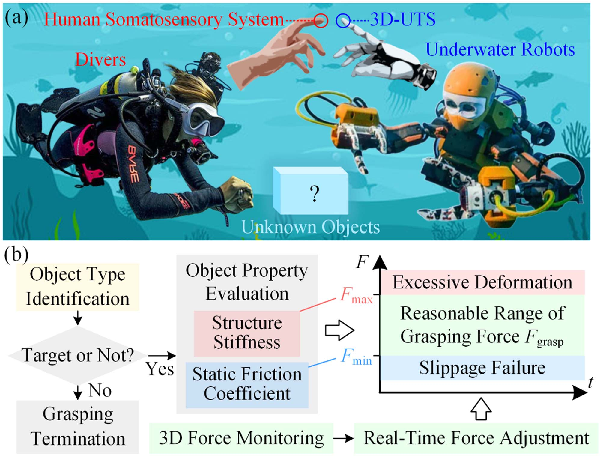
Figure 1 from 3D Force Sensor-Based Multimodal Tactile Sensing for ...
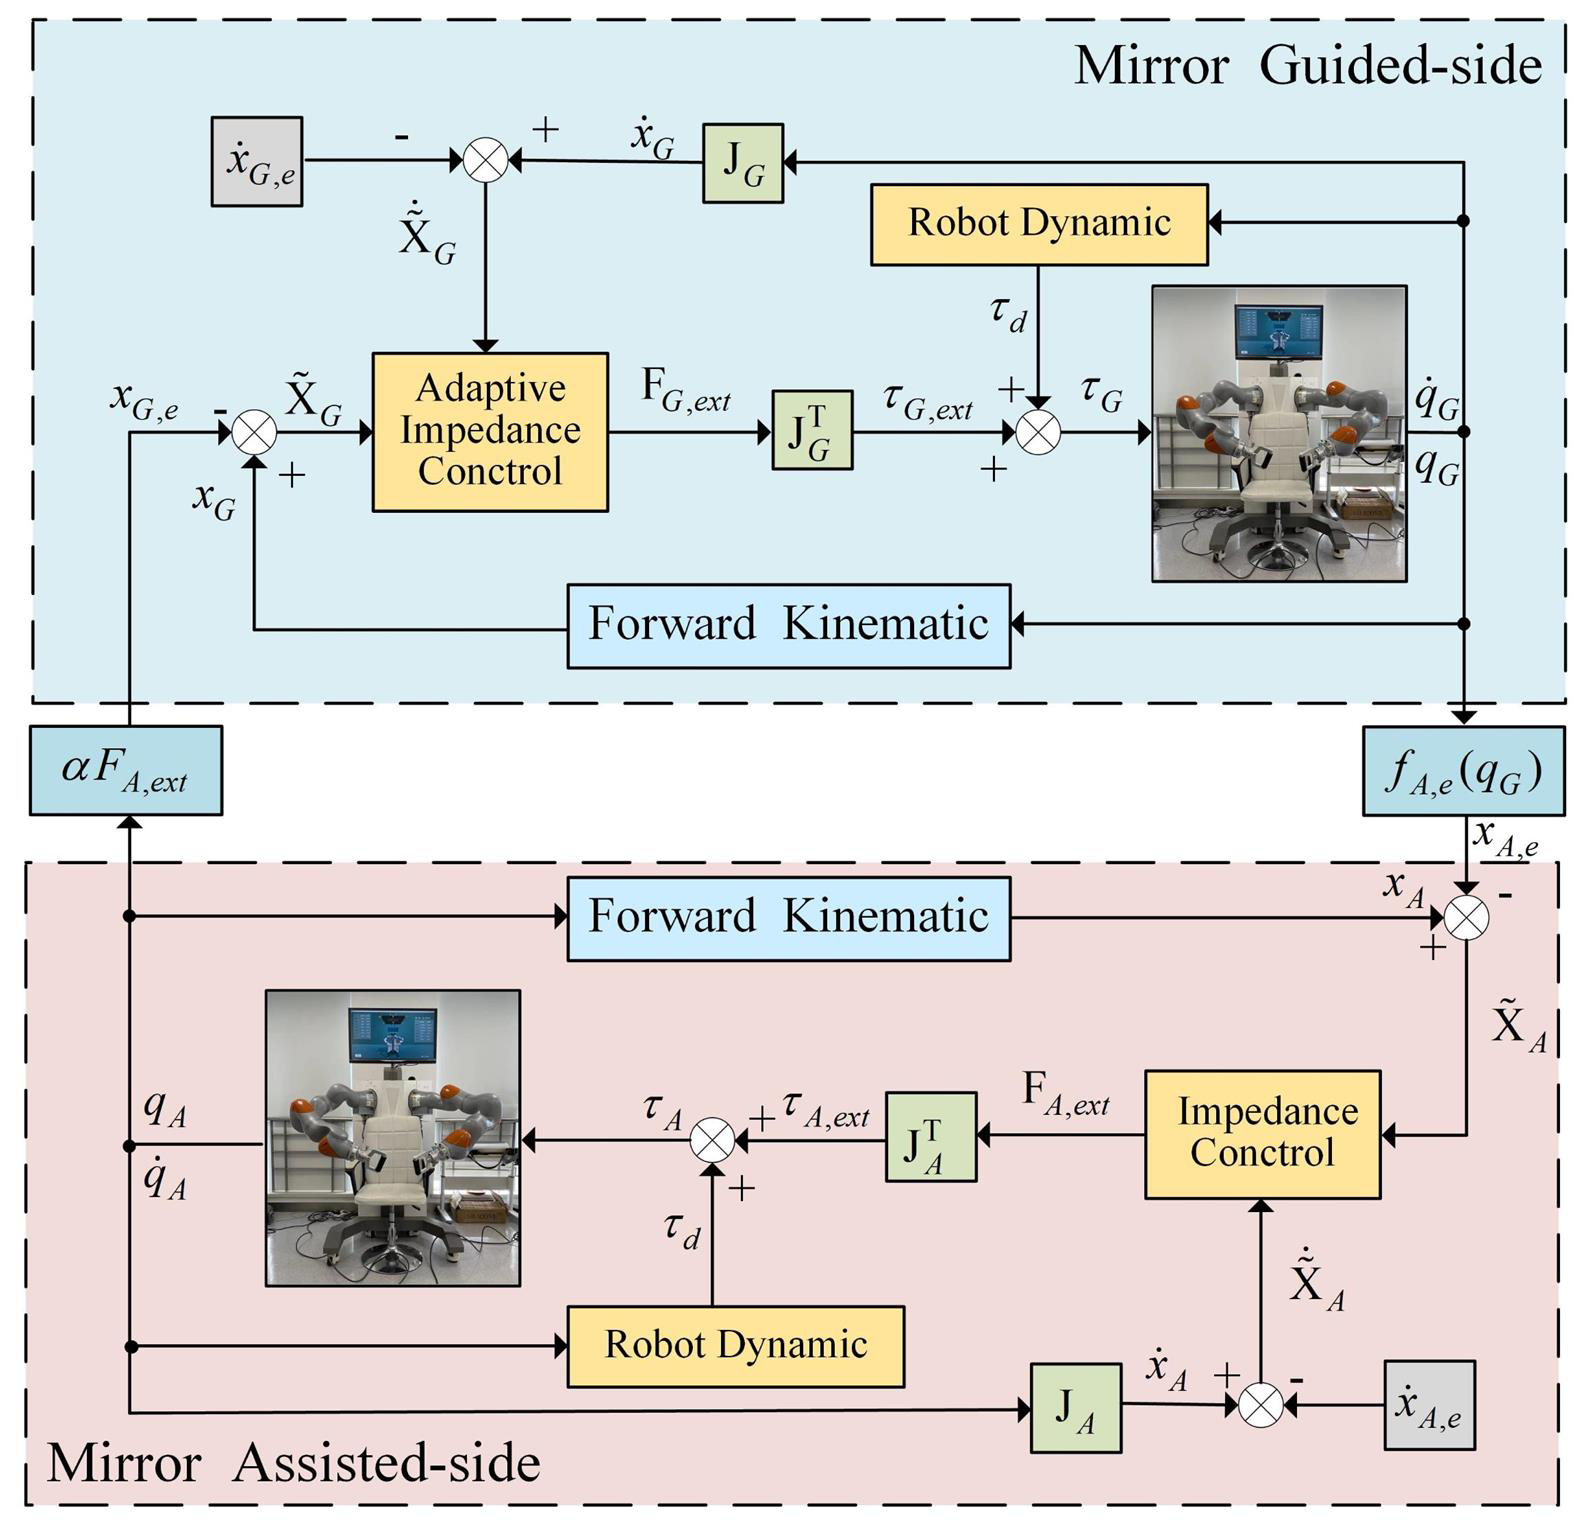
MS - Analysis of force feedback mirror-assisted strategy based on ...
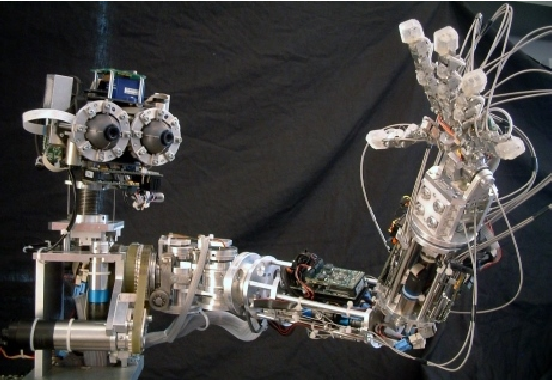
Figure 1 from Control of physical interaction through tactile and force ...
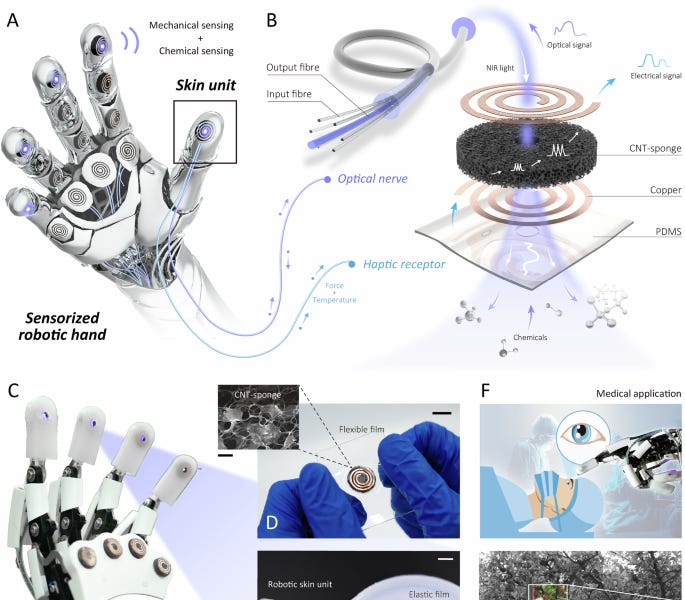
Dual-Mode Artificial Skin for Advanced Robotic Sensing and Gentle ...