
Norm Of Trc Errors For Proposed And Integral Controllers When Random

Norm of TRC errors for proposed and integral controllers when random ...

Norm of TRC errors for proposed and integral controllers when random ...

Steady-state TRC error for the proposed and the integral controllers ...
Steady-state TRC error for the proposed and the integral controllers ...

Steady-state TRC error for the proposed and the integral controllers ...

Steady-state TRC error for the proposed and the integral controllers ...

Norm of the tracking errors for the standard and proposed robust ...

(a)Tracking results and (b) tracking errors of the proposed controllers ...

The norm of tracking errors obtained from the proposed control method ...

Norms of tracking errors and control signals of proposed controller ...
Advertisement Space (300x250)

The norm of tracking errors obtained from the proposed control method ...

The norm of tracking errors obtained from the proposed control method ...

Profiles of control input and tracking errors using the proposed ...

Integral Absolute Error and Control Energy of Controllers | Download ...

Estimation errors of TDE technique for the proposed controller (blue ...

The tracking errors and control inputs of the proposed controller ...

Performance tracking error of the proposed and comparative controllers ...

Comparison on tracking errors of the proposed controller (5) and the ...

Comparison between the norm of interaction errors using the proposed ...

Profiles of control input and tracking errors using the proposed ...
Advertisement Space (336x280)

Norms of tracking errors and control signals of proposed controller ...

(a) Comparative tracking errors of the compared five controllers for ...

Position error and its integral for L 1 and MSM controllers in the case ...

Comparison on tracking errors of the proposed controller (5) and the ...

Euclidean norm of task errors e e for controller (25), (46)-(48) versus ...

Position error and its integral for L 1 and MSM controllers in the case ...
Control errors of the proposed controller on the time axis and the ...

Root mean square error of different controllers with random ...

Tracking errors without actuator dynamics and no integral control ...

Model Predictive Control for Formation Placement and Recovery of ...
Advertisement Space (336x280)

Tracking errors of four controllers during the last 10 min. | Download ...
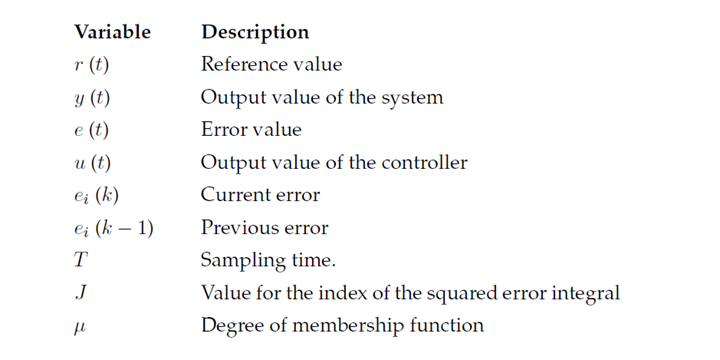
Methodology Based on the Squared Error Integral for the Design of Fuzzy ...

(a) Norm feature errors in left and right images. (b) Robot joint value ...

Square norm of the trajectory errors generated by each control strategy ...
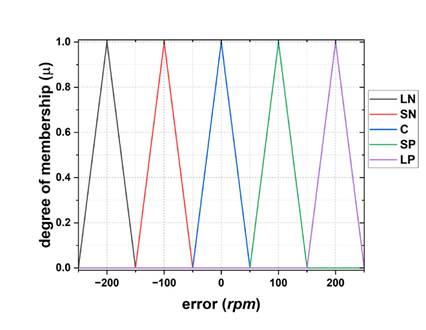
Methodology Based on the Squared Error Integral for the Design of Fuzzy ...

Square norm of the trajectory errors generated by each control strategy ...