
Optimal Trunk Trajectory Computed From The First Simulation A 1 And

Optimal trunk trajectory computed from the first simulation (a = 1 and ...

Optimal trunk trajectory computed from the first simulation (a = 1 and ...
Optimal trajectory computed solving the MICP (24) for N = 60 and ...

Optimal trajectory computed solving the MICP (24) for N = 60 and ...
Optimal trajectory computed solving the MICQ for N = 30 and N b = 10 ...

Six snapshots of the optimal trajectory (blue line) simulation for a ...

Simulated trajectory from the linear control problem and optimal ...

The transformation from a simulation trajectory generated by the ...

Optimal trunk trajectory determined using the different models: (A ...

Optimal trunk trajectory determined using the different models: (A ...
Advertisement Space (300x250)
Comparison of the computed trajectories with FMT* and the optimal ...

Optimal trunk trajectory determined using the different models: (A ...

Illustration of the optimal trajectory computed at each time instant by ...

Example of a numerically computed optimal controlled trajectory (shown ...

Optimal position and orientation trajectory of the drag-mode AWE ...

Illustration of the optimal trajectory computed at each time instant by ...

(A) A simulation trajectory showing a transition event from F2 to F1 ...
Comparison of the computed trajectories with FMT* and the optimal ...

Projection of optimal trajectory 1 on the horizontal plane. | Download ...
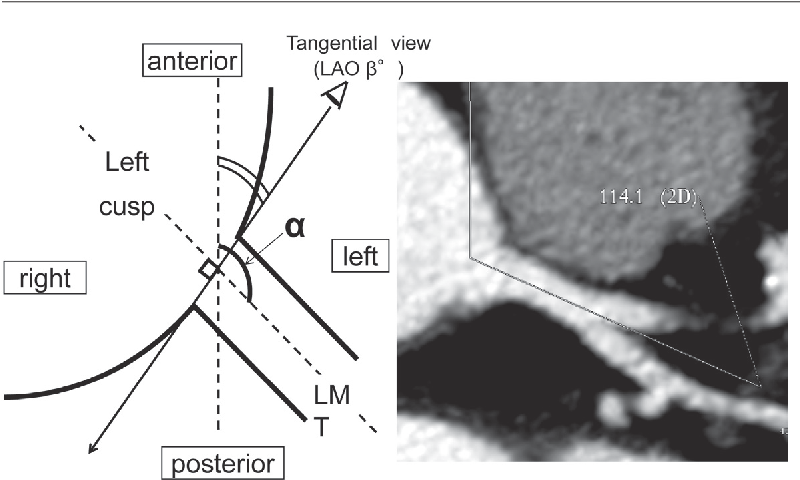
Figure 1 from [Validation of optimal coronary angiography angle for the ...
Advertisement Space (336x280)

Comparison of the computed trajectories with FMT* and the optimal ...

Initial orbits and optimal transfer trajectory in the long path ...
2-D energy optimal trajectory as computed by the ToC method | Download ...

A schematic of the experimental design. a The 11 trunk movements and ...

Optimal trunk trajectory determined using the different models: (A ...

Optimal trajectory x 1 (t) (black) and optimal control x * 1 (t) (red ...

Trajectory tracking of the first simulation. The position (x, y, and z ...

Optimal Trajectory Planning and Linear Velocity Feedback Control of a ...

(a) Computed optimal control and (b) corresponding state trajectory ...

Initial orbits and optimal transfer trajectory in the short path ...
Advertisement Space (336x280)
Optimal trajectory for OCP A (−), B (− −) and a circle with ...
Trunks of the tree and the simulation environment. ((left) The trunk of ...
Discrete optimal trajectory-tracking simulation for the UCAV ...

First simulation: Minimization of the trajectory length. The robot ...

A healthy subject ’ s (control no. 1) trunk path ( A ) and velocity ...

Optimal trajectory generated by the proposed method regarding maneuver ...