
Pr2ethercattutorialsrunning Ros Wiki

pr2_etherCAT/Tutorials/Running - ROS Wiki
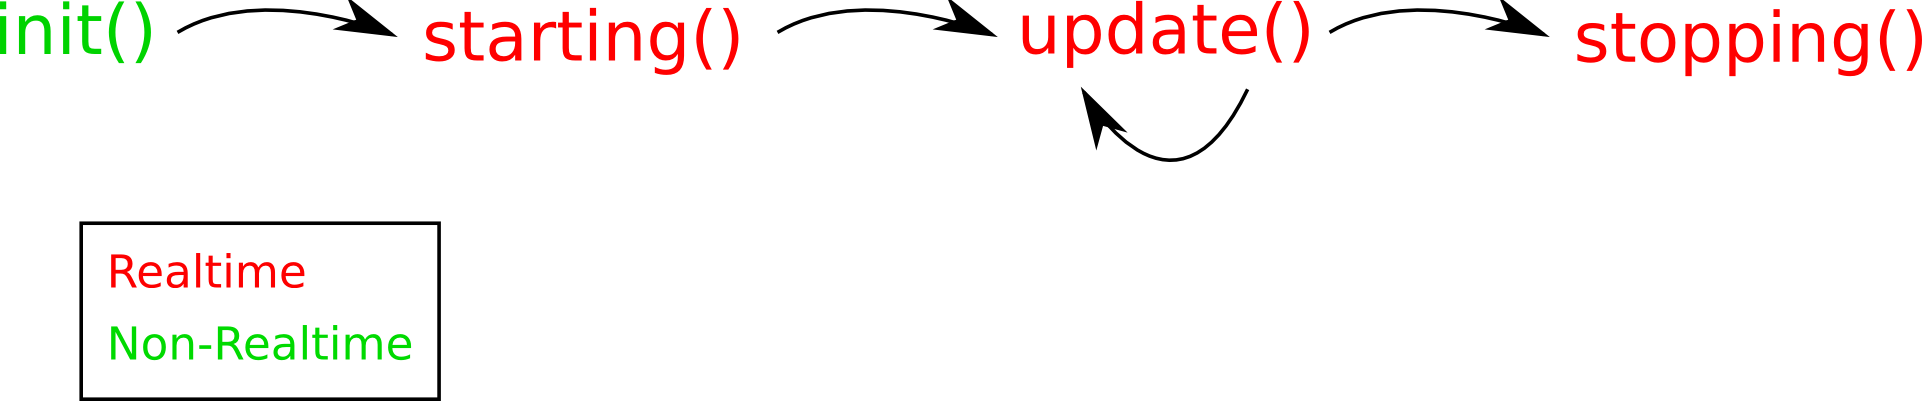
pr2_controller_interface - ROS Wiki

3 ROS Tutorials Navigating The Filesystem - ROS Wiki - Note: This ...
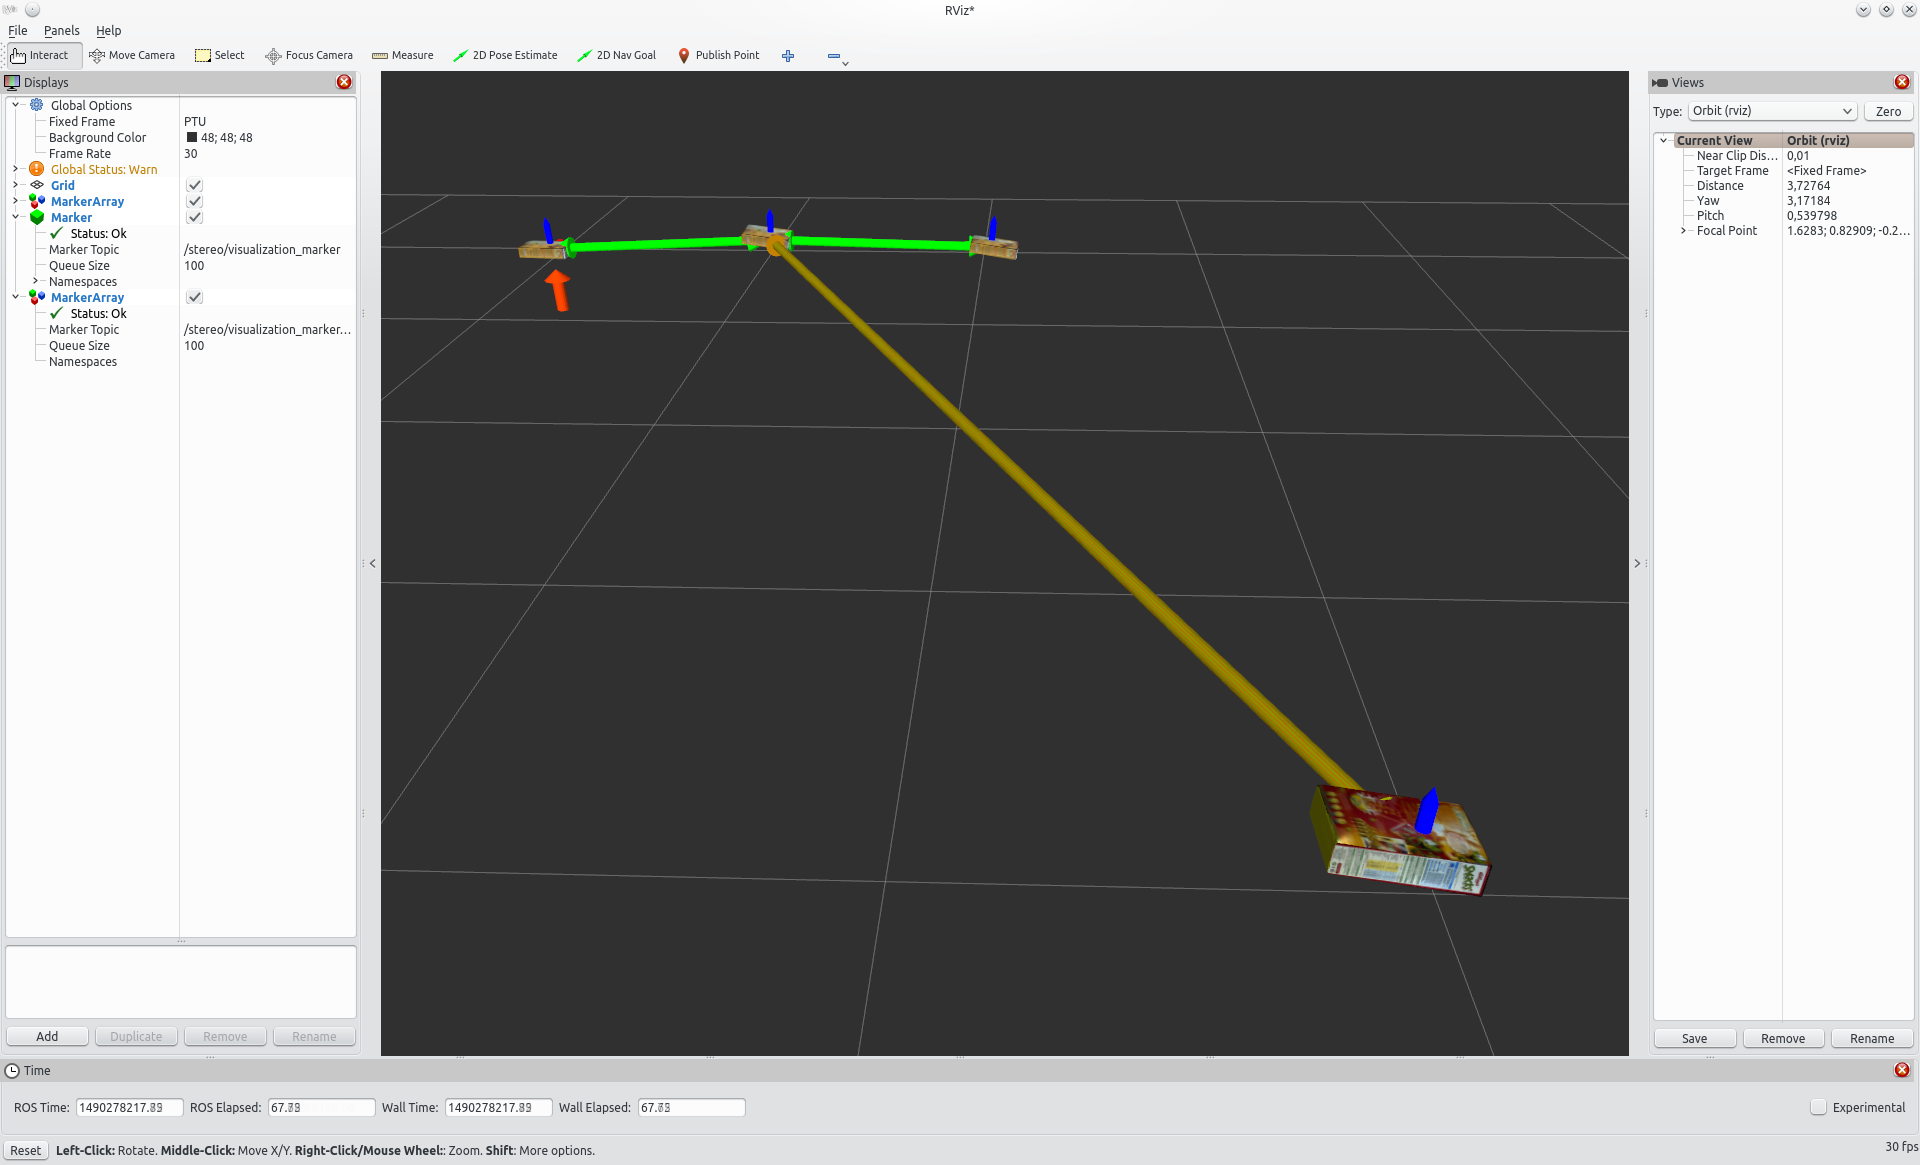
asr_psm/tutorial - ROS Wiki

roslaunch/Tutorials/Roslaunch Nodes in Valgrind or GDB - ROS Wiki ...

ROS - HowardWhile/2023_note GitHub Wiki

ROS - HowardWhile/2023_note GitHub Wiki

rosserial_arduino/Tutorials - ROS Wiki

ROS - Tutorials - UnderstandingNodes - ROS Wiki | PDF | Library ...

ROS - HowardWhile/2023_note GitHub Wiki
Advertisement Space (300x250)

How to Develop EtherCAT Motion Controller on ROS (2) - DEV Community
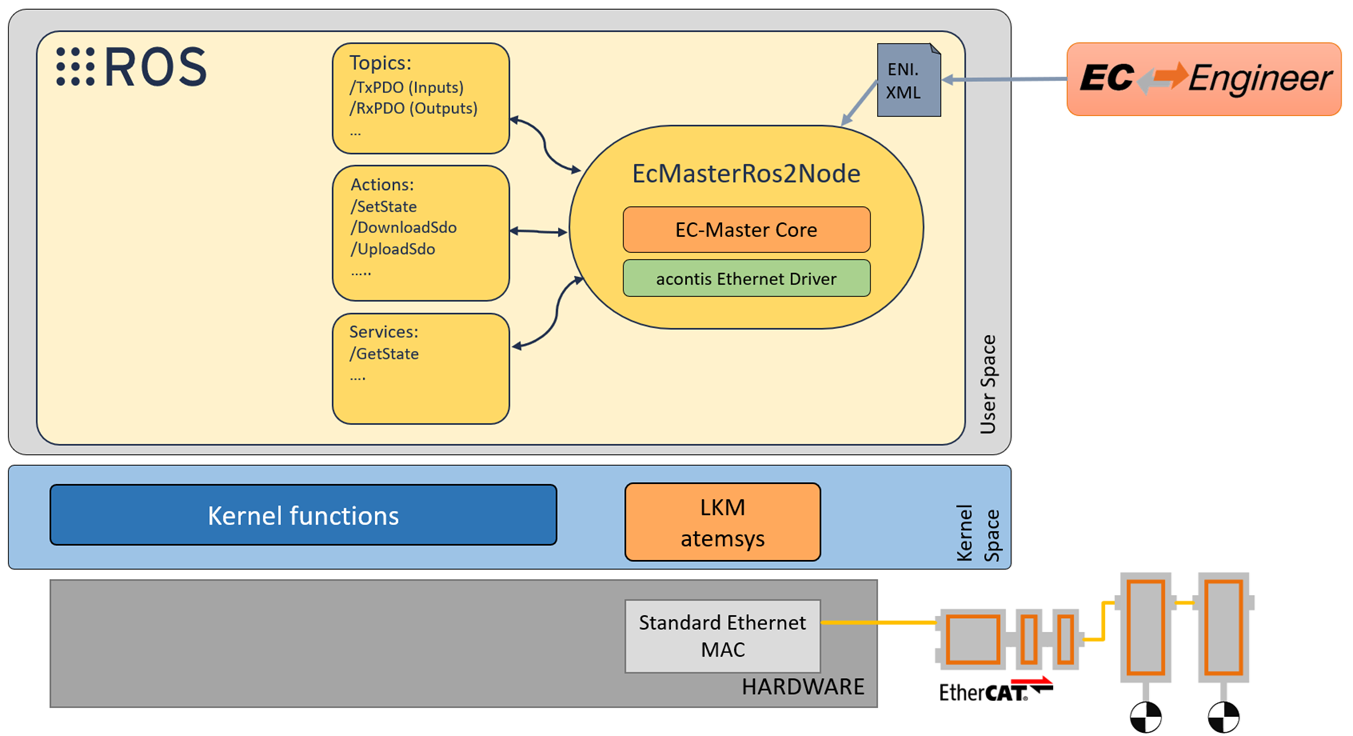
EtherCAT for ROS - acontis

EtherCAT for ROS - acontis
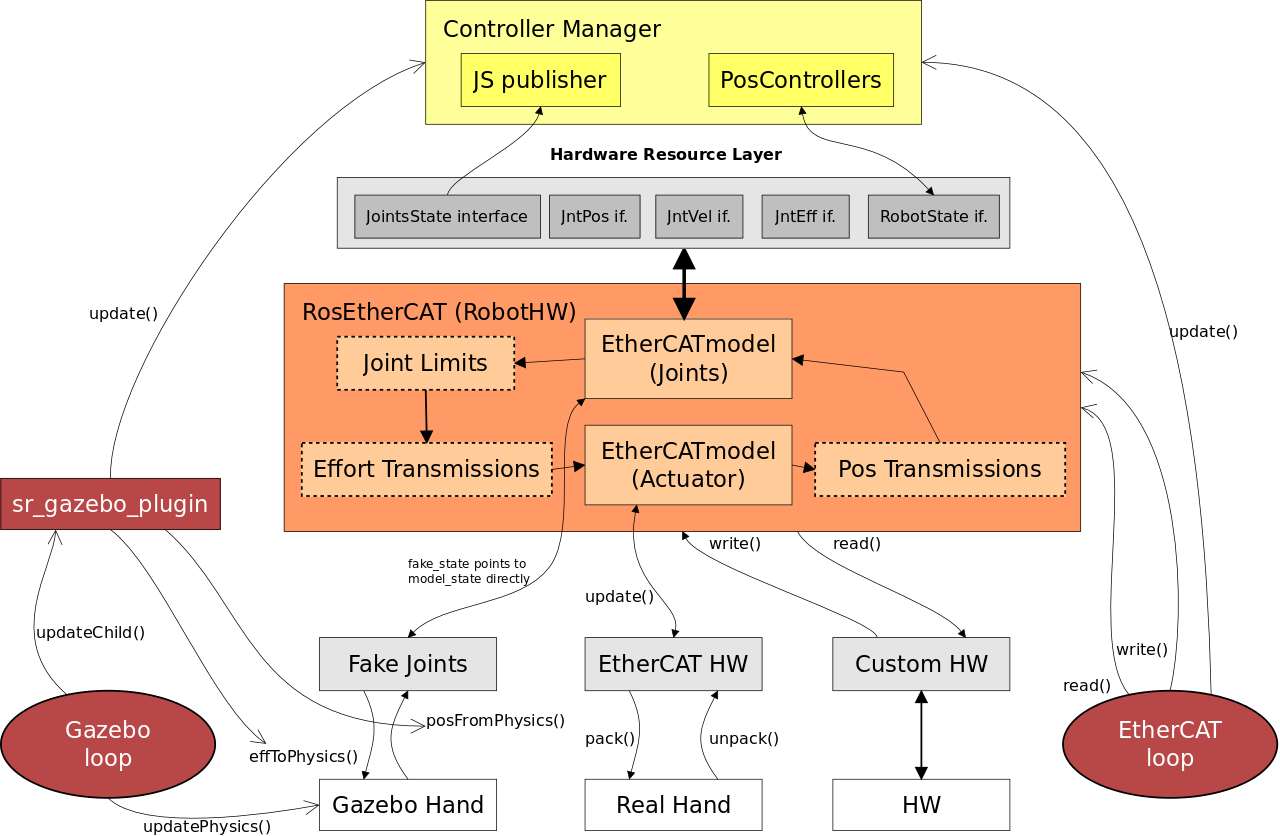
ros_ethercat - ROS Repository Overview

Software-defined EtherCAT combined with ROS 2 | Accelerate AMR ...

The diagram of ROS nodes | Download Scientific Diagram

Running ROS 2 on Multiple Machines | Husarion

How to Develop EtherCAT Motion Controller on ROS (1) - DEV Community
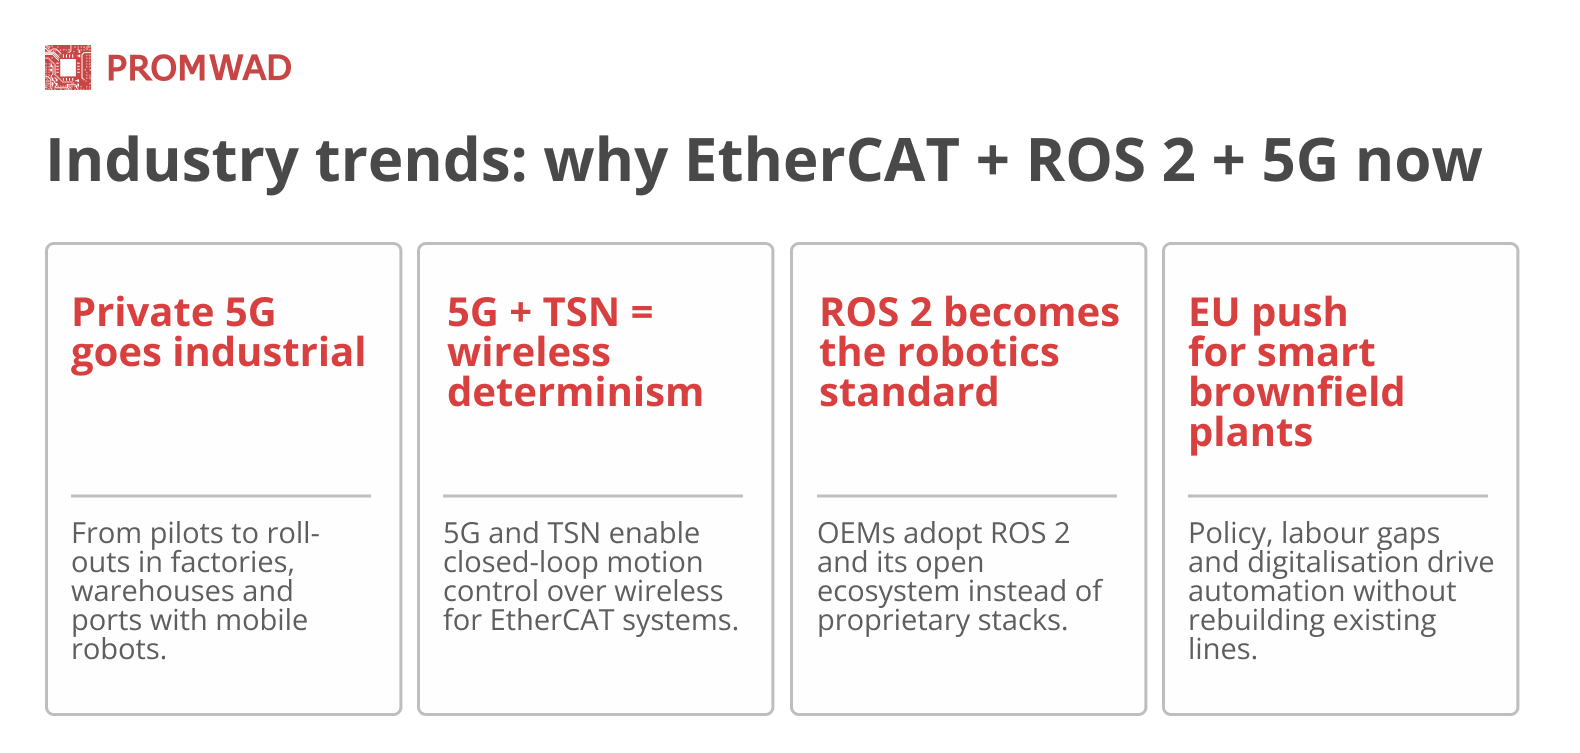
EtherCAT + ROS 2 + 5G | Reusable Robotics Software Platform

ROS Tutorial: Communication between two Computers - Machine Learning Site
Advertisement Space (336x280)
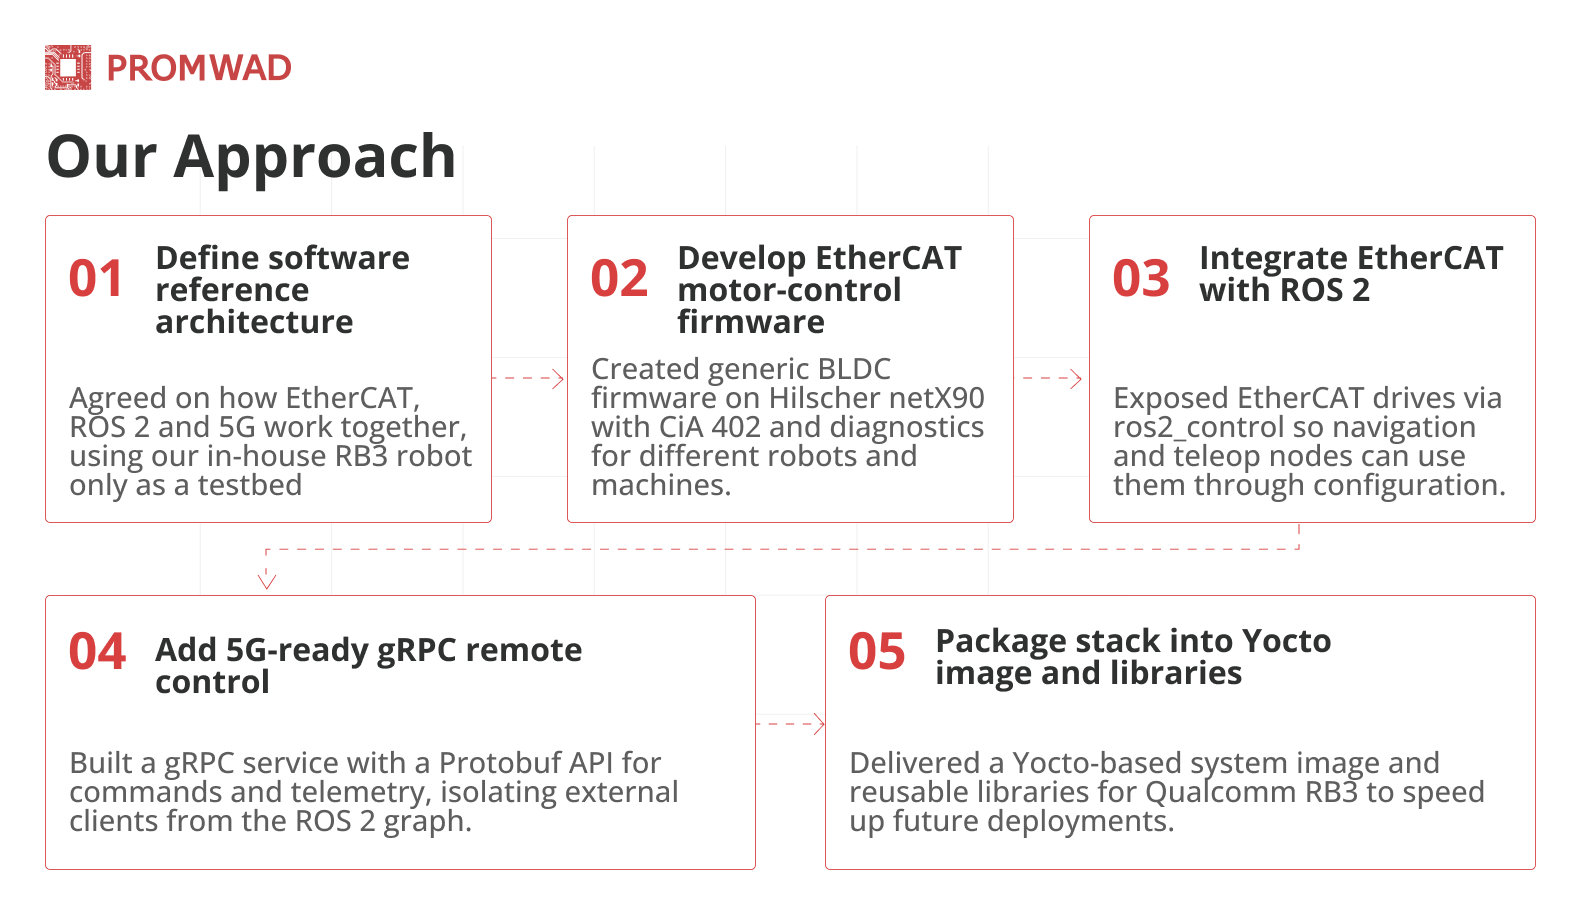
EtherCAT + ROS 2 + 5G | Reusable Robotics Software Platform

Beginner's Guide: ROS with Docker | PDF | Command Line Interface ...
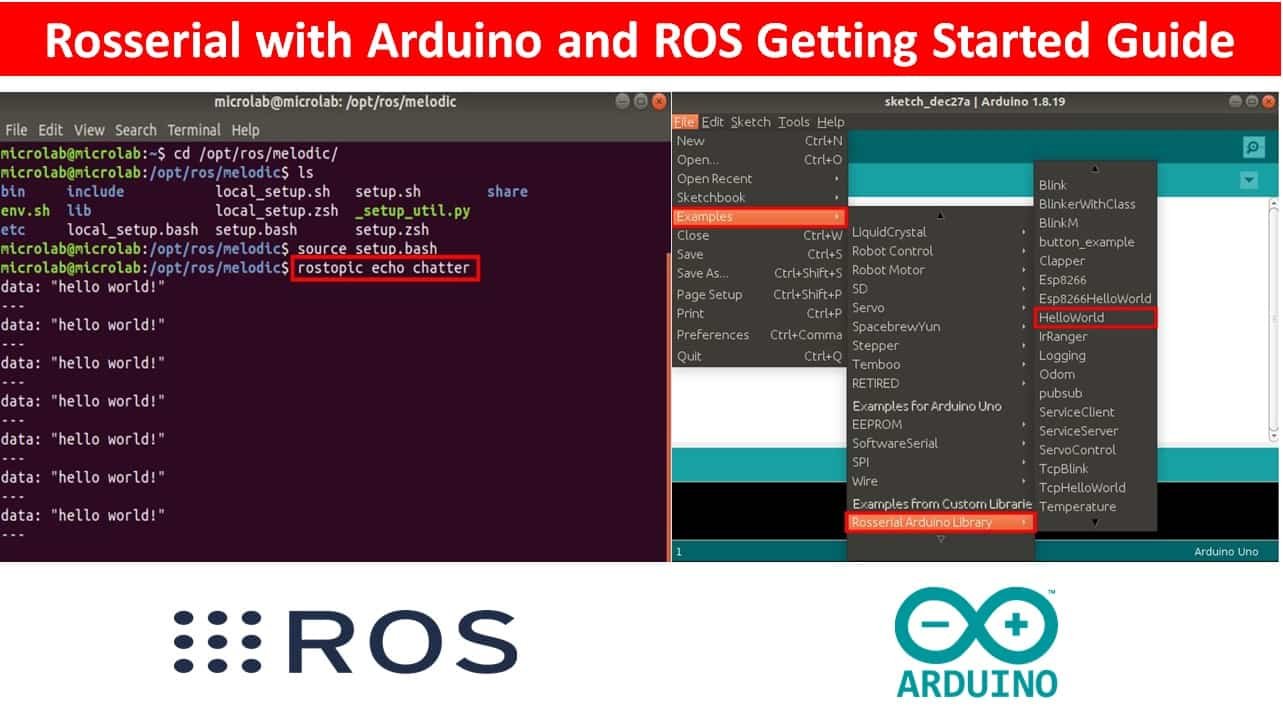
Rosserial with Arduino and Setup ROS Node on Arduino

ros - AddingSensorsToPR2 tutorial errors - Robotics Stack Exchange
Installing ROS 2 Using Docker (Linux & Mac) - ROS 2 Labs in The Diamond

How to Develop EtherCAT Motion Controller on ROS (1) - DEV Community
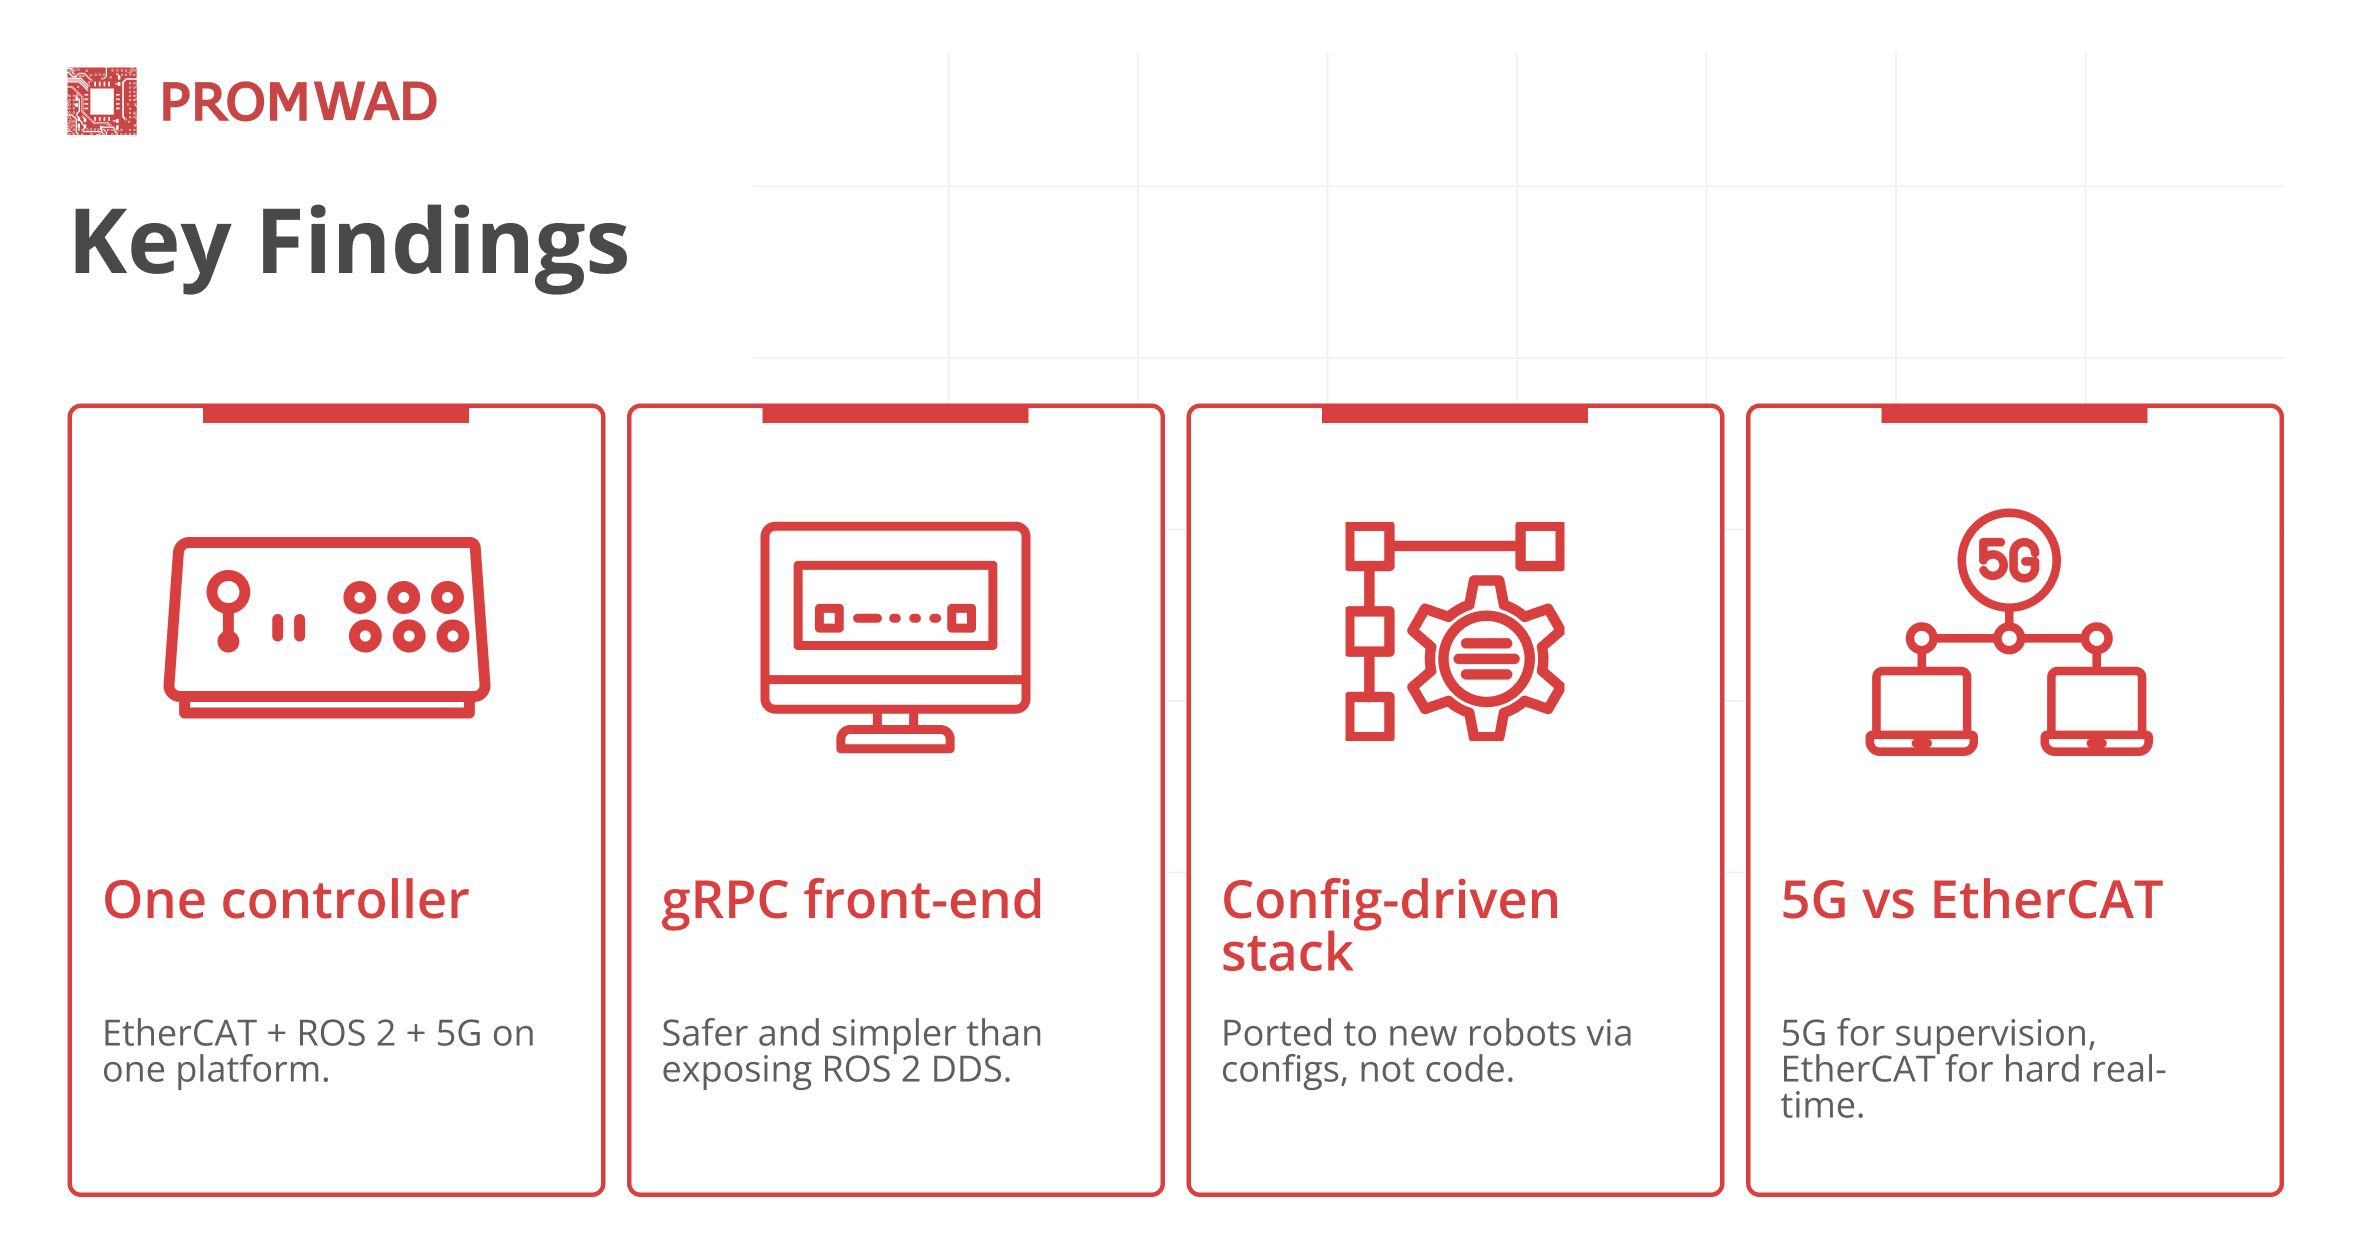
EtherCAT + ROS 2 + 5G | Reusable Robotics Software Platform

What Is A Ros Plugin at Brittany Wertz blog

Teleoperate robot using EASE with ROS - Hackster.io
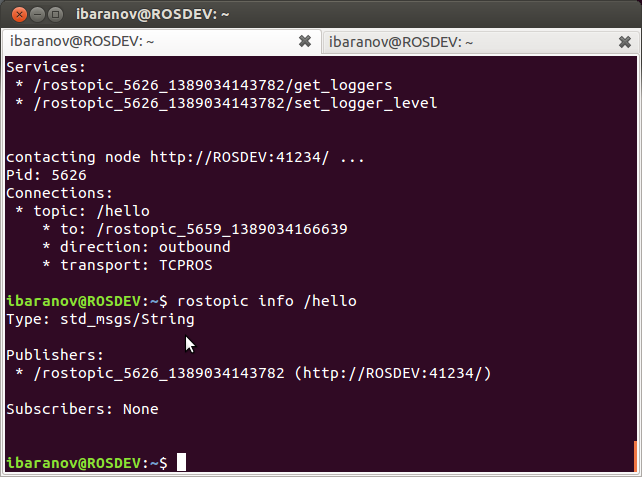
Practical Example — ROS Tutorials 0.6.0 documentation
Advertisement Space (336x280)

Ros Controller Manual : Welcome to the ros2 – KHAVXF
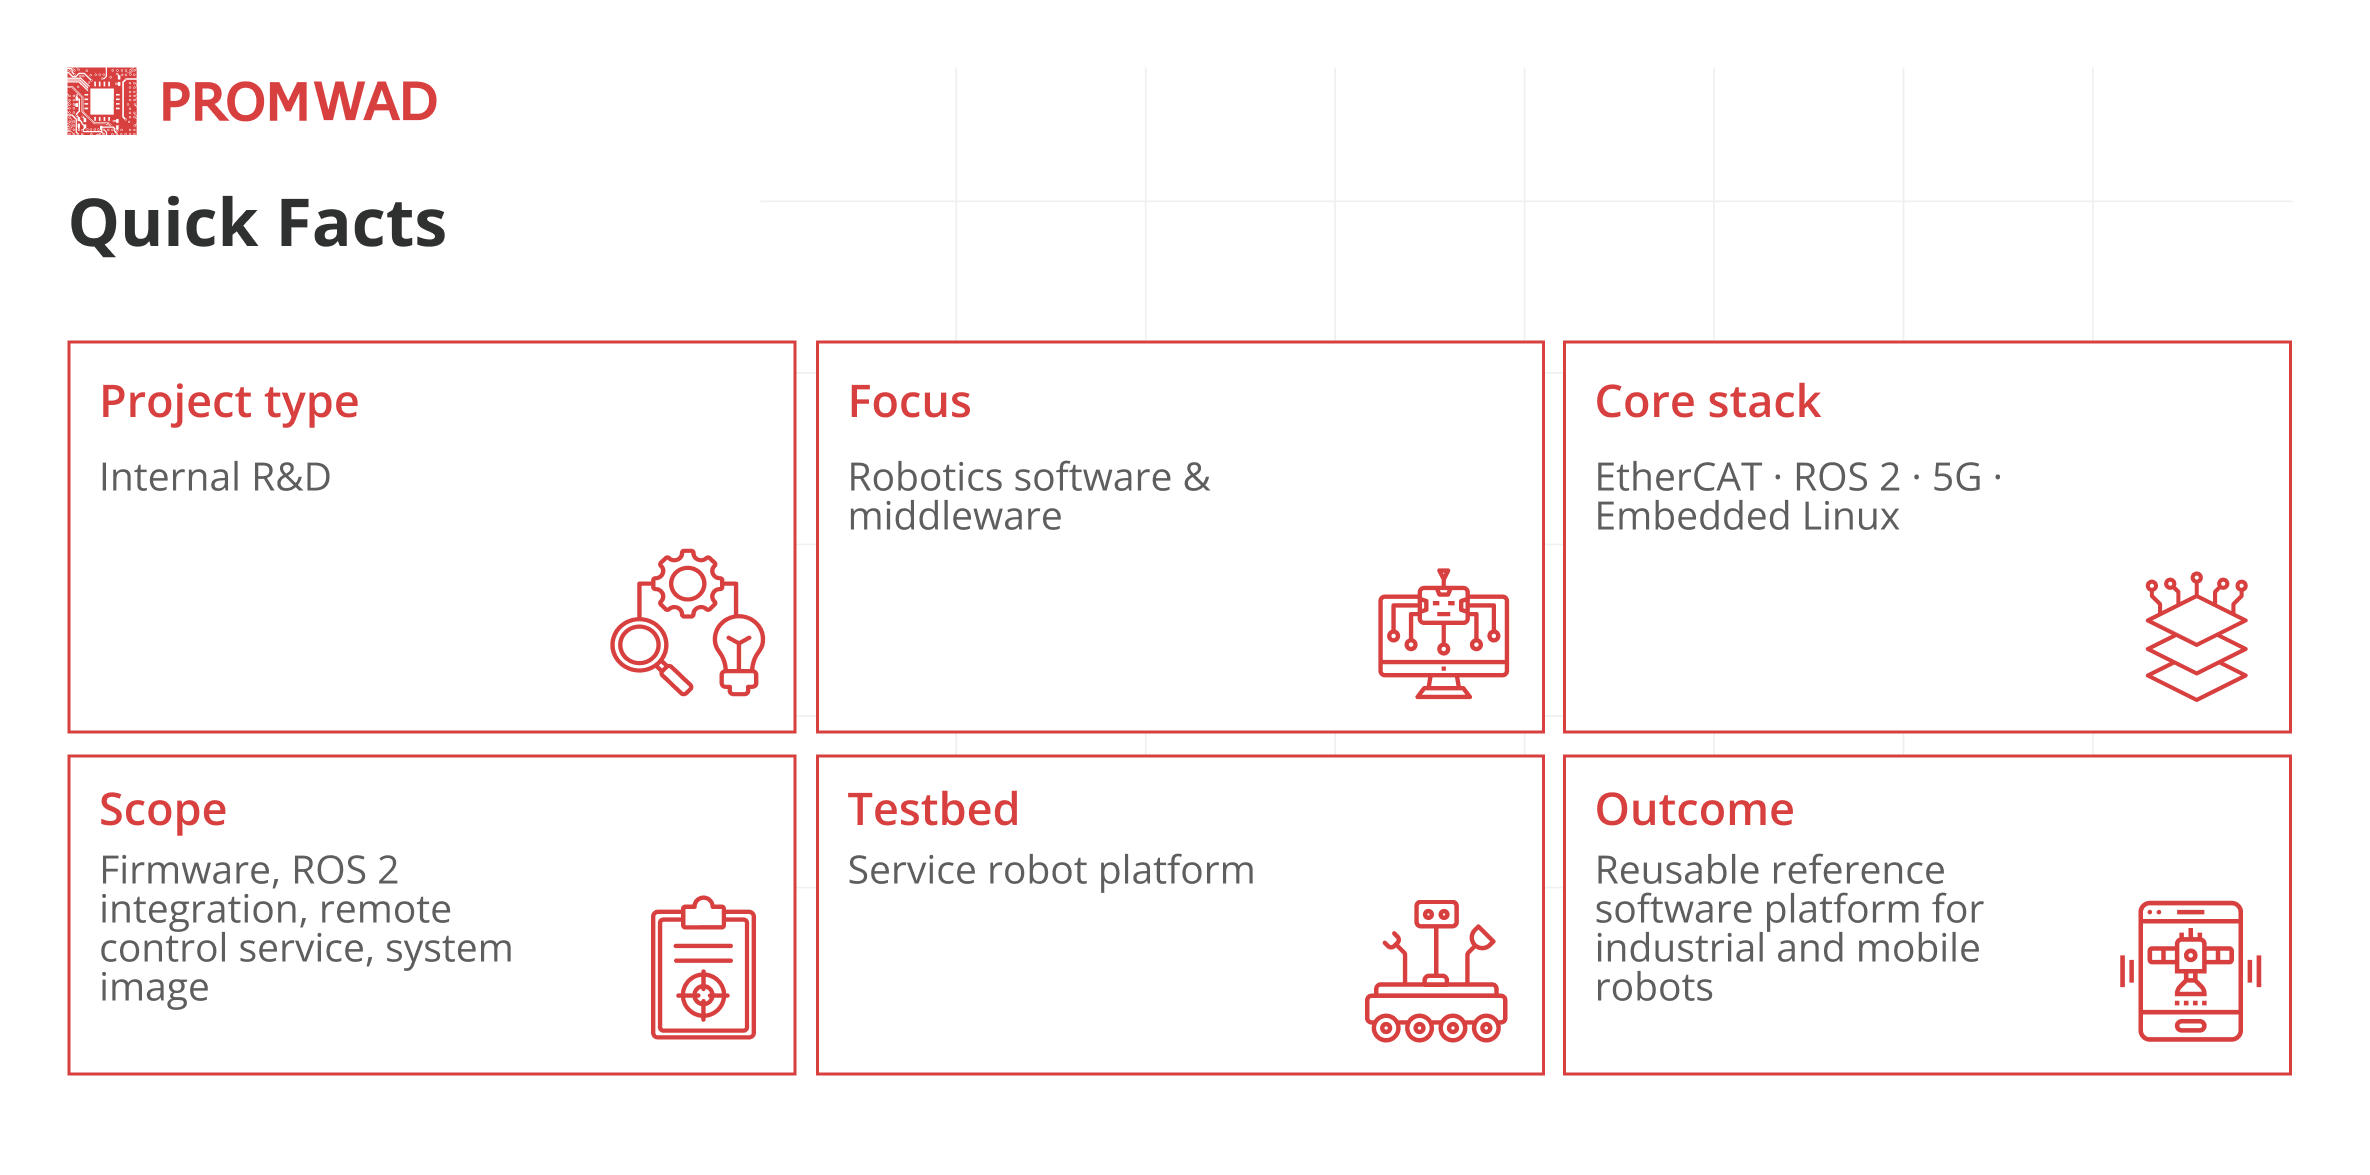
EtherCAT + ROS 2 + 5G | Reusable Robotics Software Platform

6. Writing ROS Controllers and Visualization Plugins | Mastering ROS ...
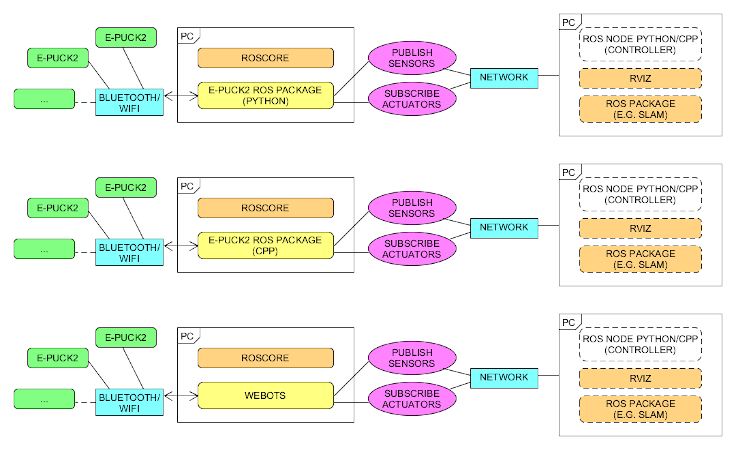
e-puck2 PC side development - GCtronic wiki

PPT - ROS - Lesson 1 PowerPoint Presentation, free download - ID:6084893

ROS 2 basics — ROS 2 course 0.1 documentation