
Robot Grasp Planning A Learning From Demonstration Based Approach

Robot Grasp Planning: A Learning from Demonstration-Based Approach

Robot Grasp Planning: A Learning from Demonstration-Based Approach

Robot Grasp Planning: A Learning from Demonstration-Based Approach
Robot Grasp Planning: A Learning from Demonstration-Based Approach
Robot Grasp Planning: A Learning from Demonstration-Based Approach

Robot Grasp Planning: A Learning from Demonstration-Based Approach

Robot Grasp Planning: A Learning from Demonstration-Based Approach
Robot Grasp Planning: A Learning from Demonstration-Based Approach

Robot Grasp Planning: A Learning from Demonstration-Based Approach

Robot Grasp Planning: A Learning from Demonstration-Based Approach
Advertisement Space (300x250)

Robot Grasp Planning: A Learning from Demonstration-Based Approach

Robot Grasp Planning: A Learning from Demonstration-Based Approach

Robot Grasp Planning: A Learning from Demonstration-Based Approach
Robot Grasp Planning: A Learning from Demonstration-Based Approach

Robot Grasp Planning: A Learning from Demonstration-Based Approach

Robot Learning from Demonstration: A Task-level Planning Approach ...

Figure 1 from Robot Learning from Demonstration based on Human-in-the ...

Overview of the robot grasping learning based on demonstration ...
A grasping approach based on sensors and learning networks [134 ...

(PDF) Robot Grasp Learning by Demonstration without Predefined Rules
Advertisement Space (336x280)

(PDF) A Fast Grasp Planning Algorithm for Humanoid Robot Hands

(PDF) Grasp Planning for a Multifingered Hand with a Humanoid Robot

Figure 1 from Robot Grasp with Multi-object Detection based on RGB-D ...

(PDF) An active learning approach for assessing robot grasp reliability

(PDF) Robotic Edge-Rolling Manipulation: A Grasp Planning Approach
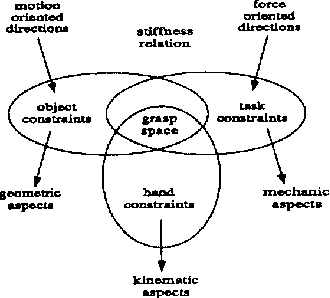
Figure 1 from A simulation-based grasp planning system for multifinger ...

Depth Image–Based Deep Learning of Grasp Planning for Textureless ...

Depth Image–Based Deep Learning of Grasp Planning for Textureless ...
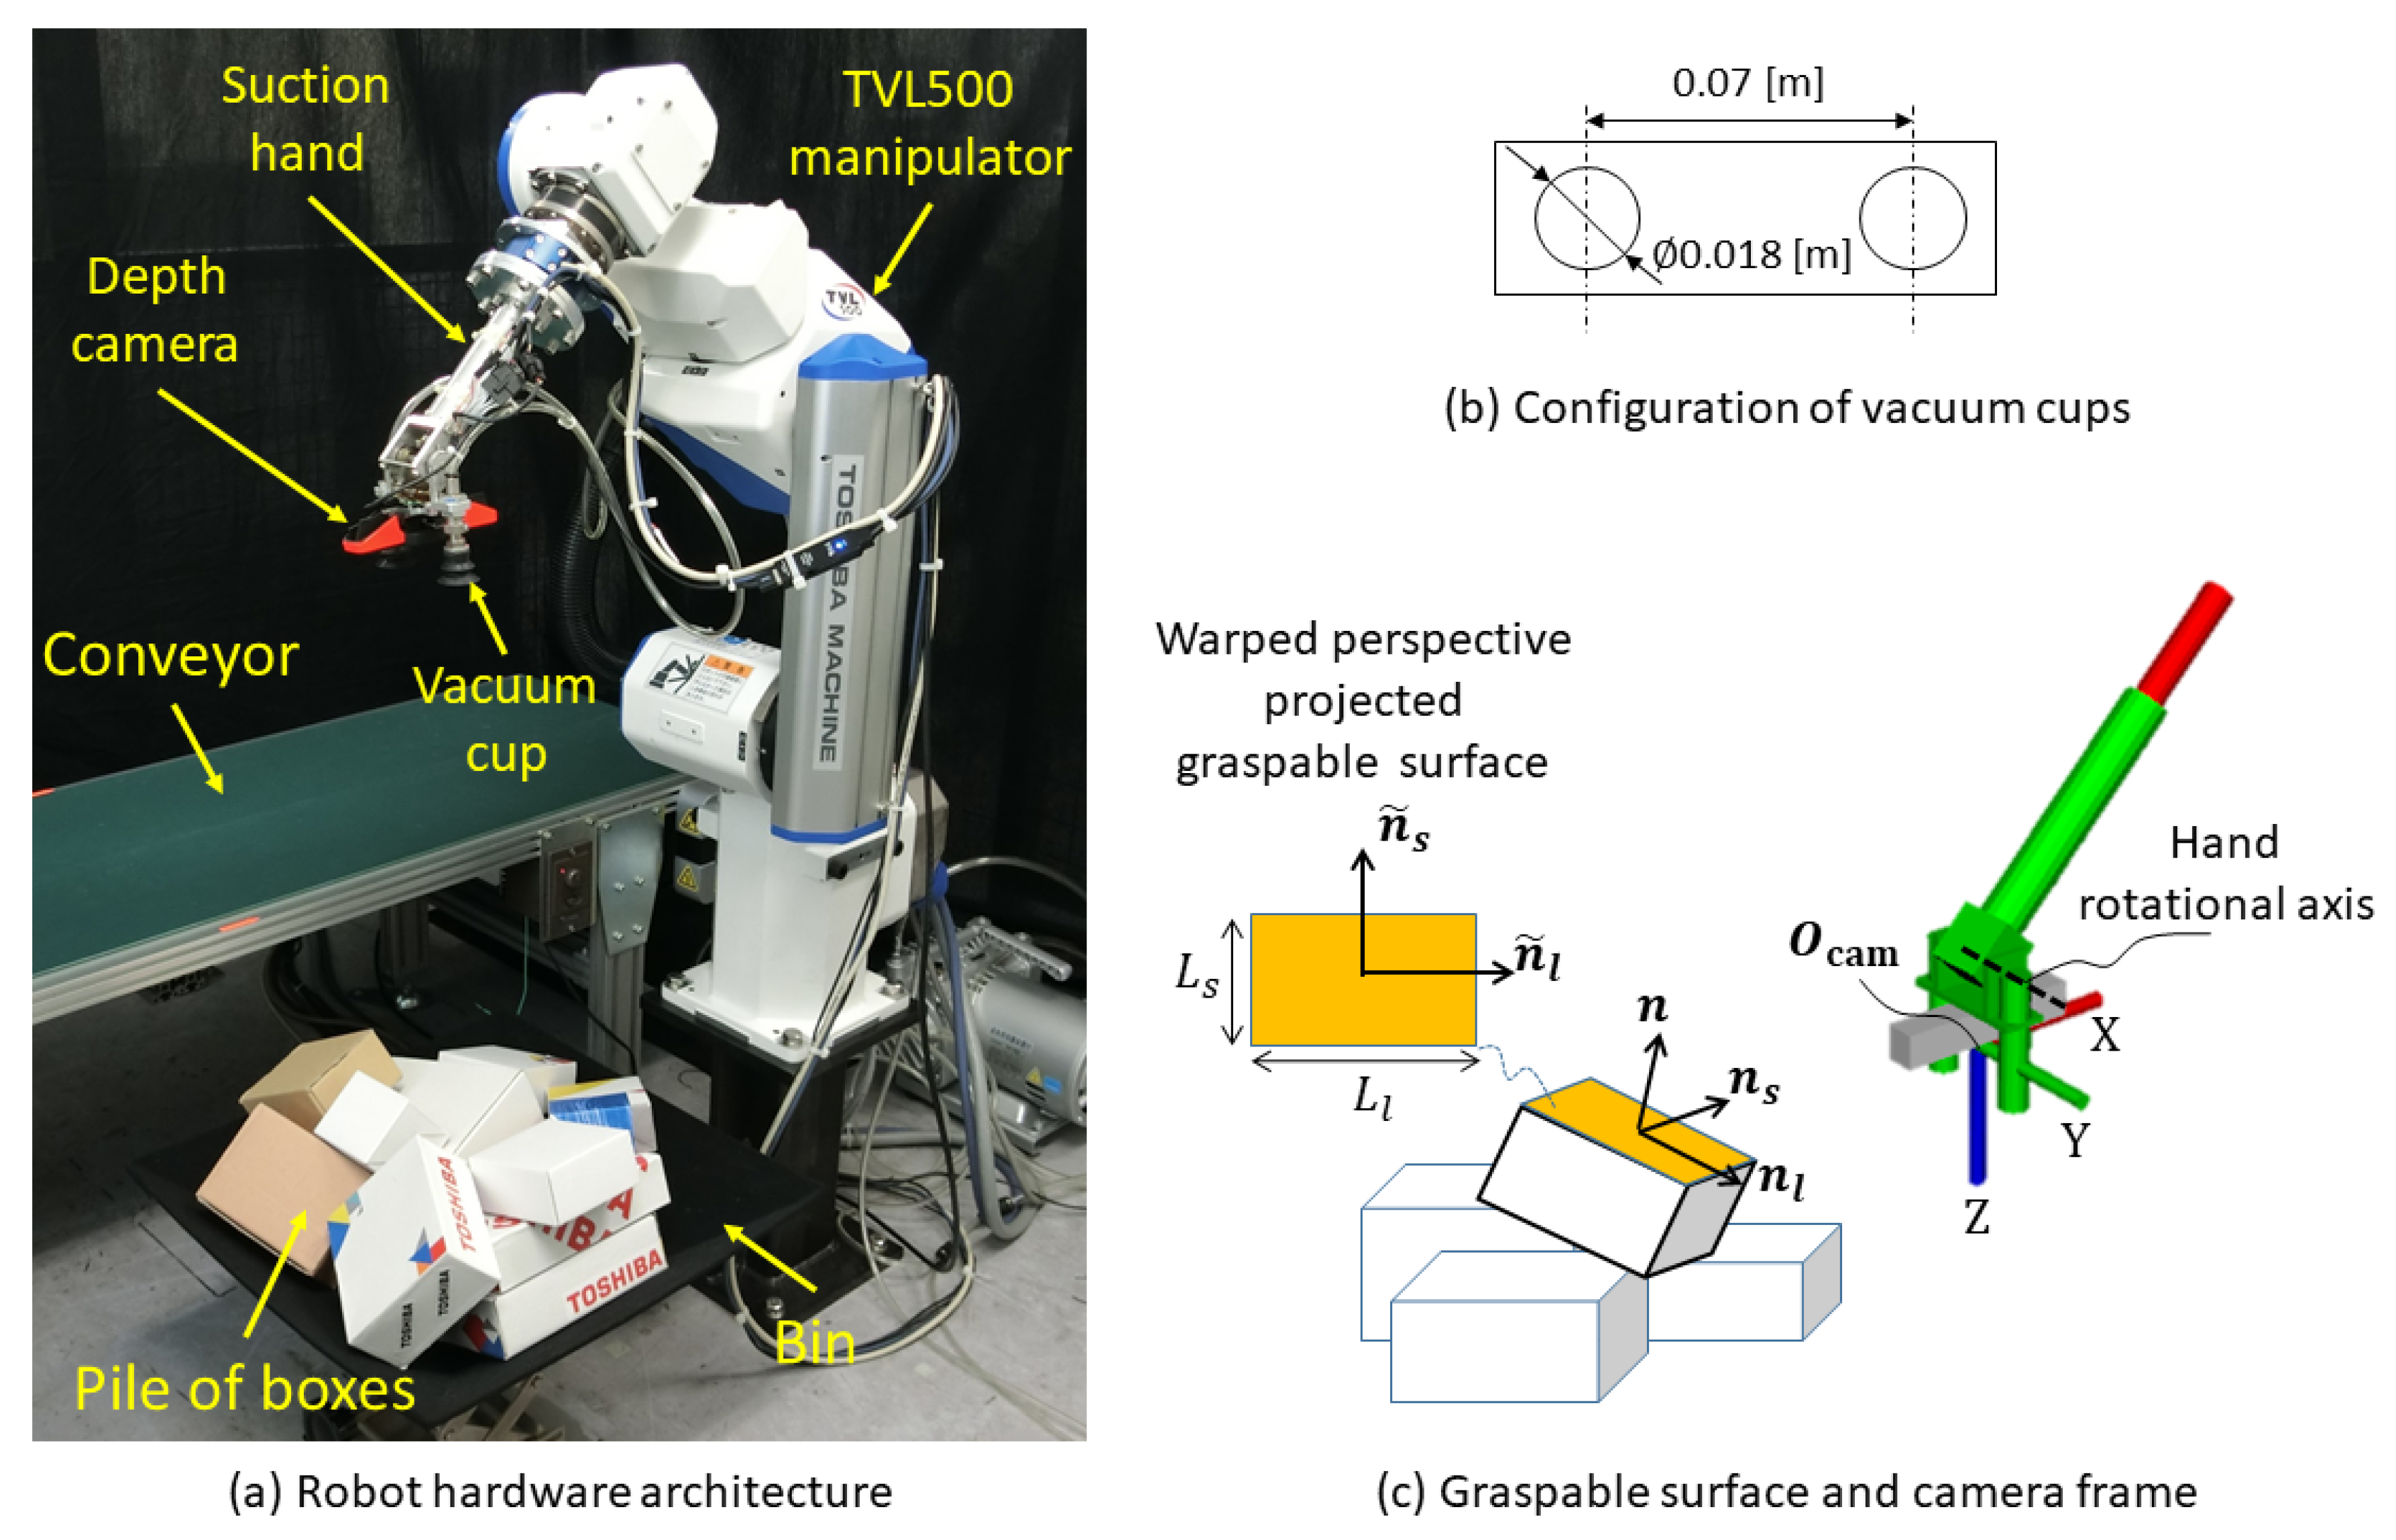
Depth Image–Based Deep Learning of Grasp Planning for Textureless ...
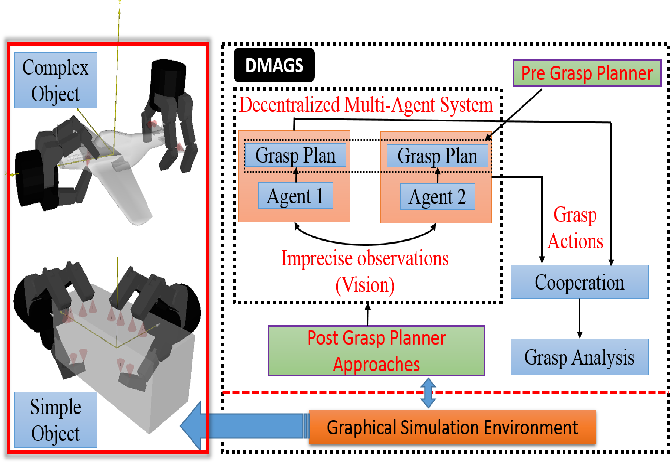
Figure 2 from Task specific cooperative grasp planning for ...
Advertisement Space (336x280)
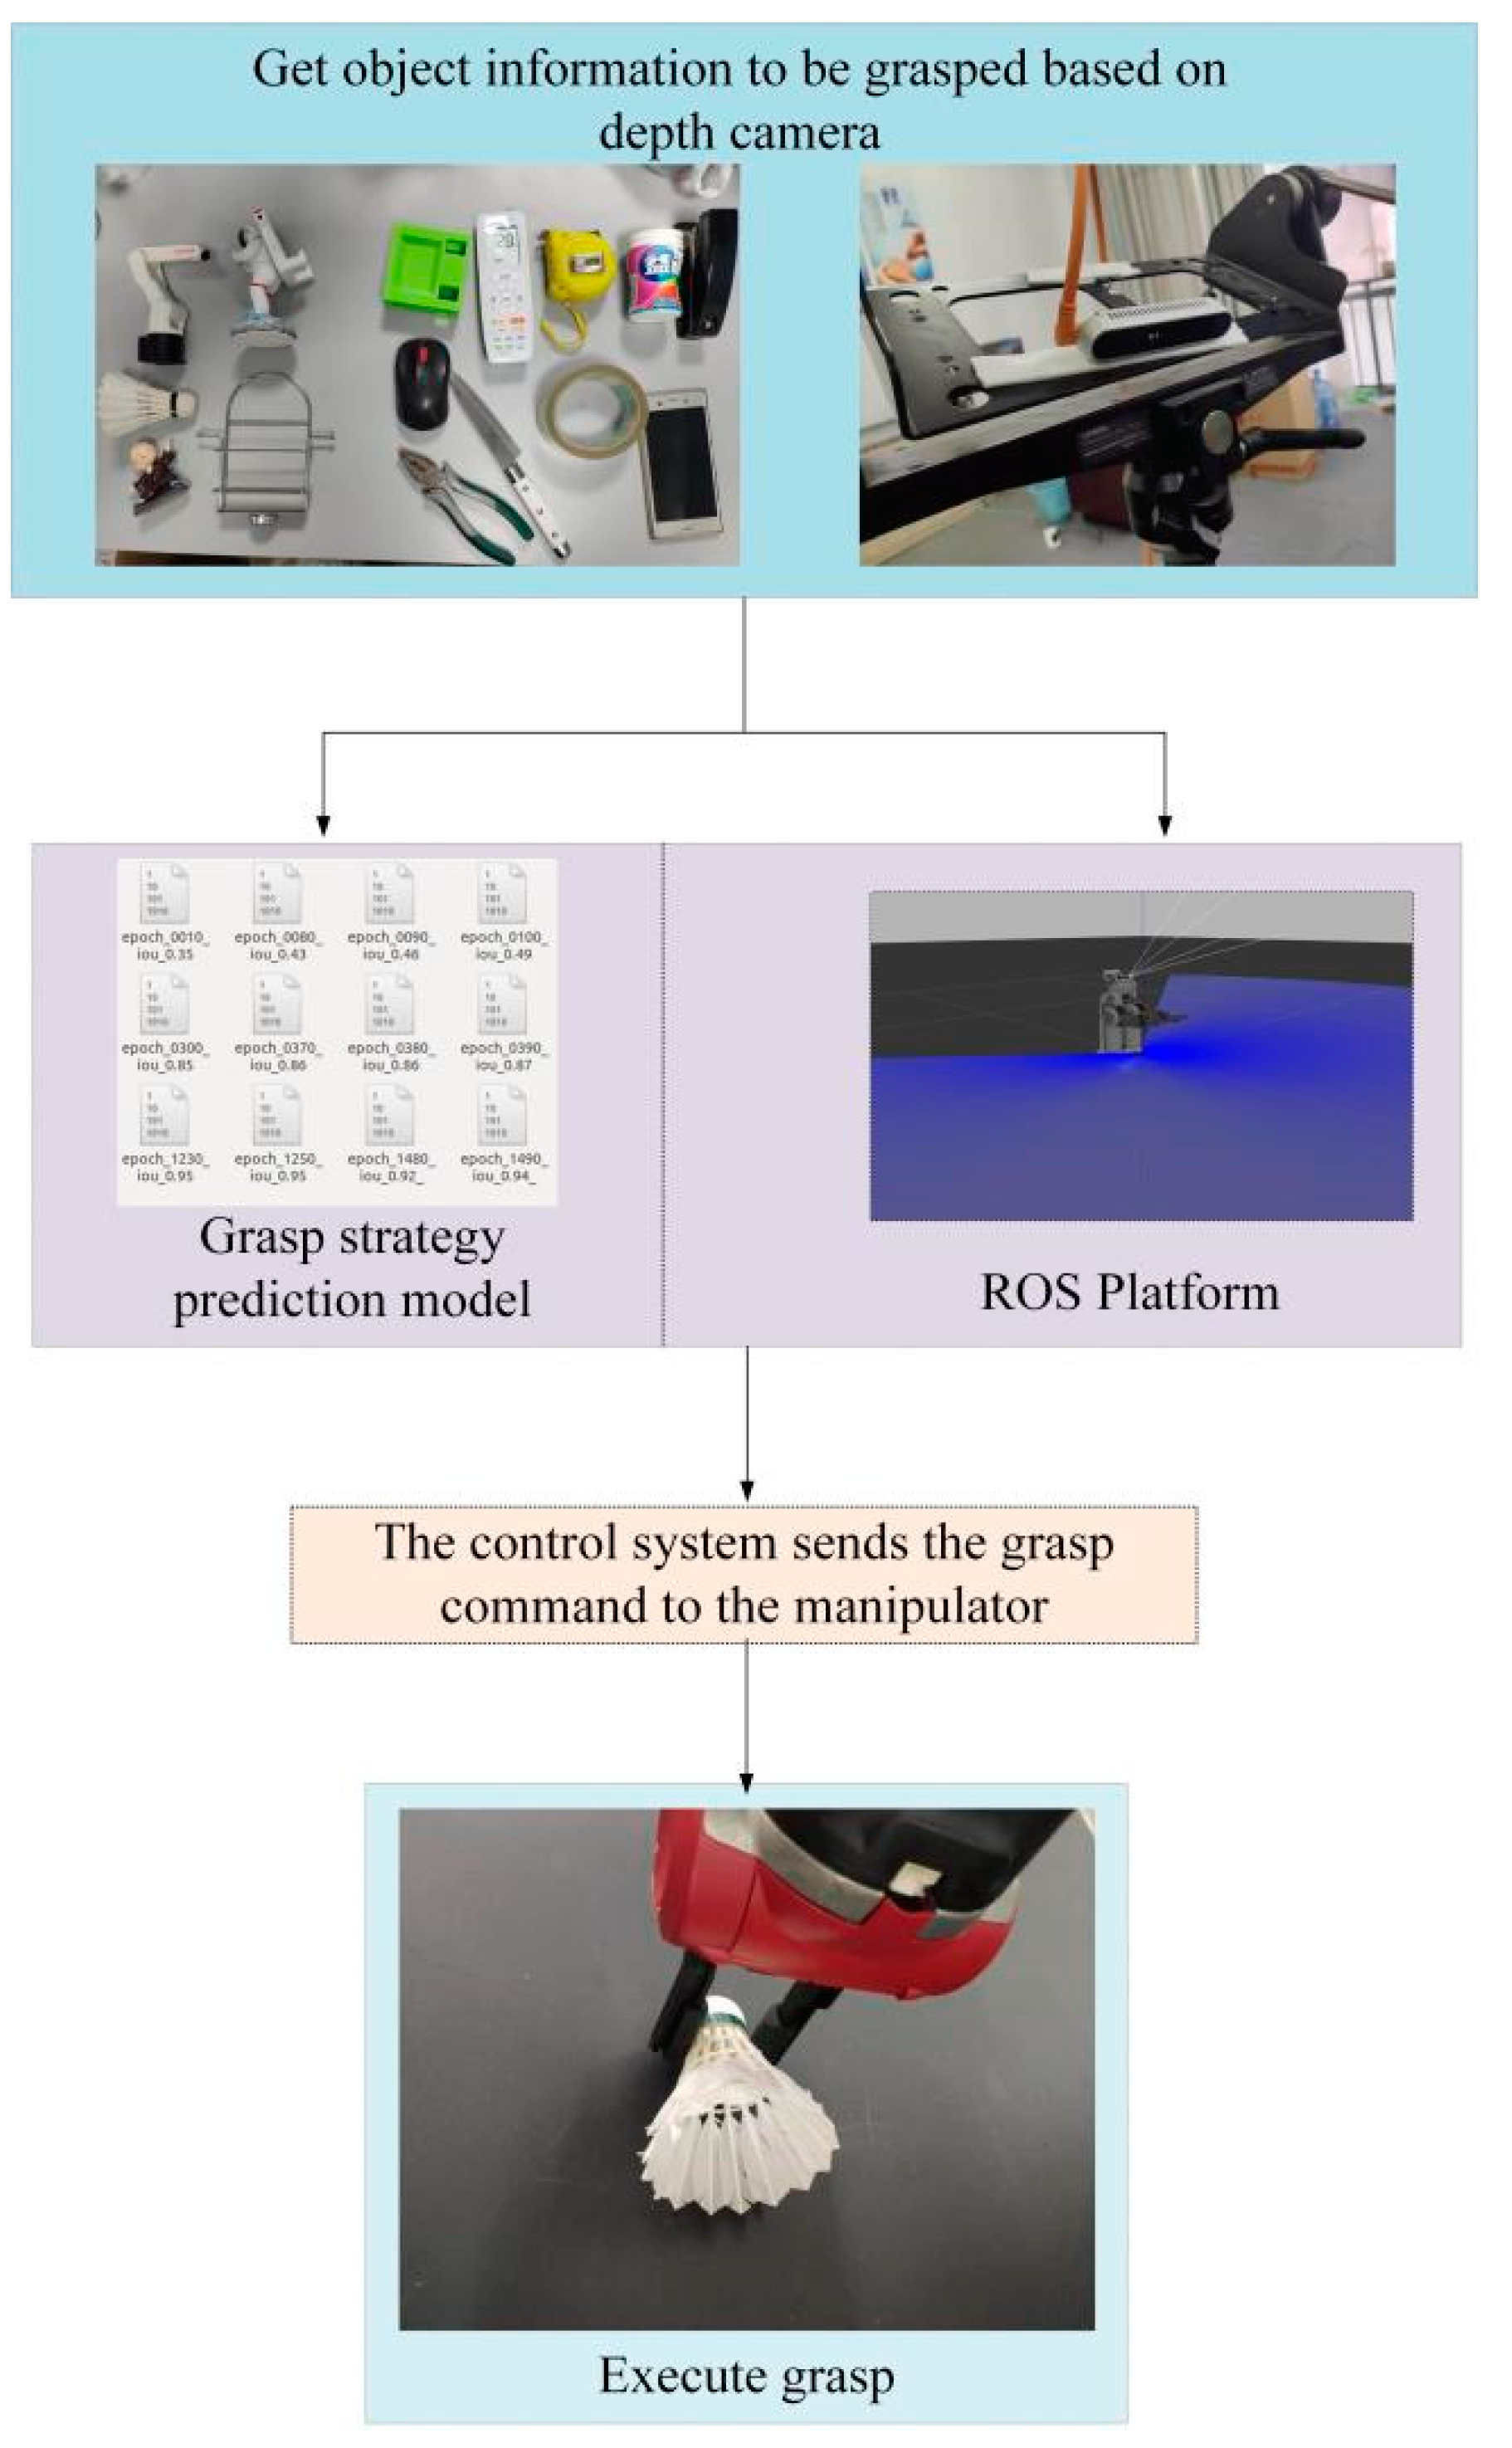
Research on Robot Grasping Based on Deep Learning for Real-Life Scenarios
Planning for one grasp pose by OpenRave. First (a), the robot model ...

Figure 5 from A Simulation-Based Grasp Planner for Enabling Robotic ...

Development of a Multifunctional Mobile Manipulation Robot Based on ...

The computation of the best grasp and its execution on a real robot ...

Figure 1 from Vision-based grasp planning of 3D objects by extending 2D ...