
Ros Indigo Beginnertutorials 10 Ros Hello World Python

ROS Indigo beginner_Tutorials-10 编写 ROS 话题版的 Hello World 程序(Python版 ...

The Ultimate Guide to Printing Hello World in ROS using Python - YouTube

Hello World project in ROS on Windows 10

Hello World project in ROS on Windows 10
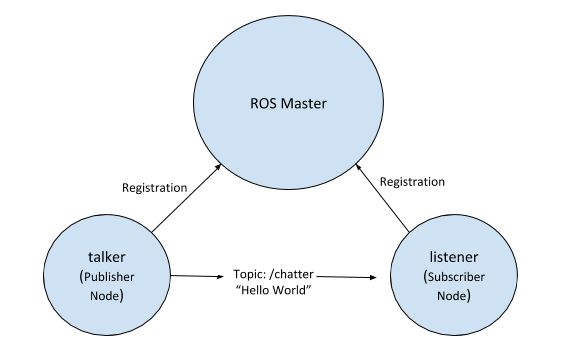
Create a Hello World Project in ROS
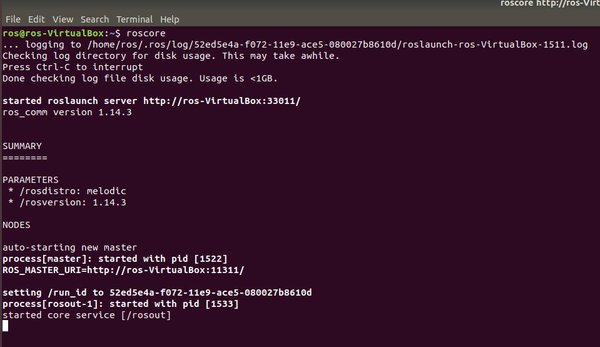
Create a Hello World Project in ROS

ros hello world 实现_ros helloworld 发布订阅-CSDN博客
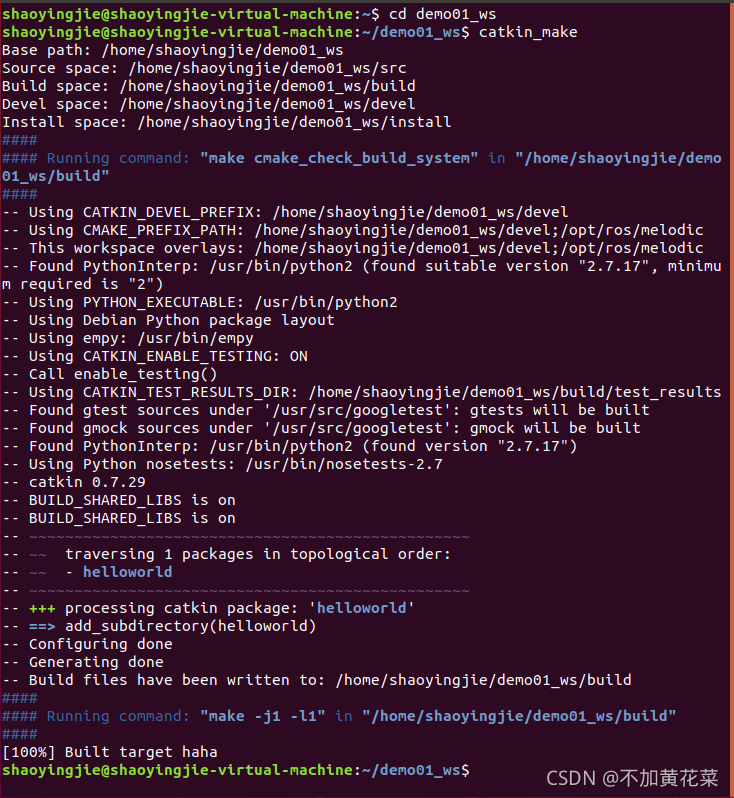
Ros学习笔记(一)Ros中HelloWorld实现(C++/Python)_vsode ros python hello实现-CSDN博客
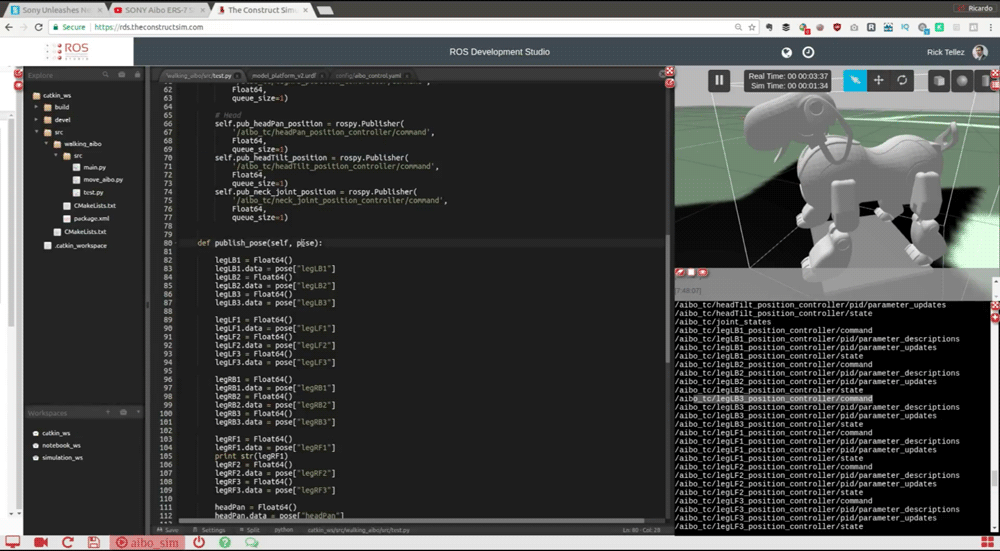
Learn ROS with Python or with C++? Pros & Cons | The Construct

How to create a ROS Service | Python | ROS Tutorial for Beginners - YouTube
Advertisement Space (300x250)

ROS Indigo Cheatsheet

Write Python ROS (Robot Operating System) Publisher/Subscriber Nodes ...
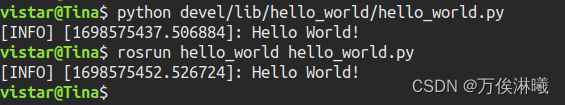
[ROS 系列学习教程] ROS Hello World-CSDN博客

ROS Tutorial #3.2: Python Services - YouTube
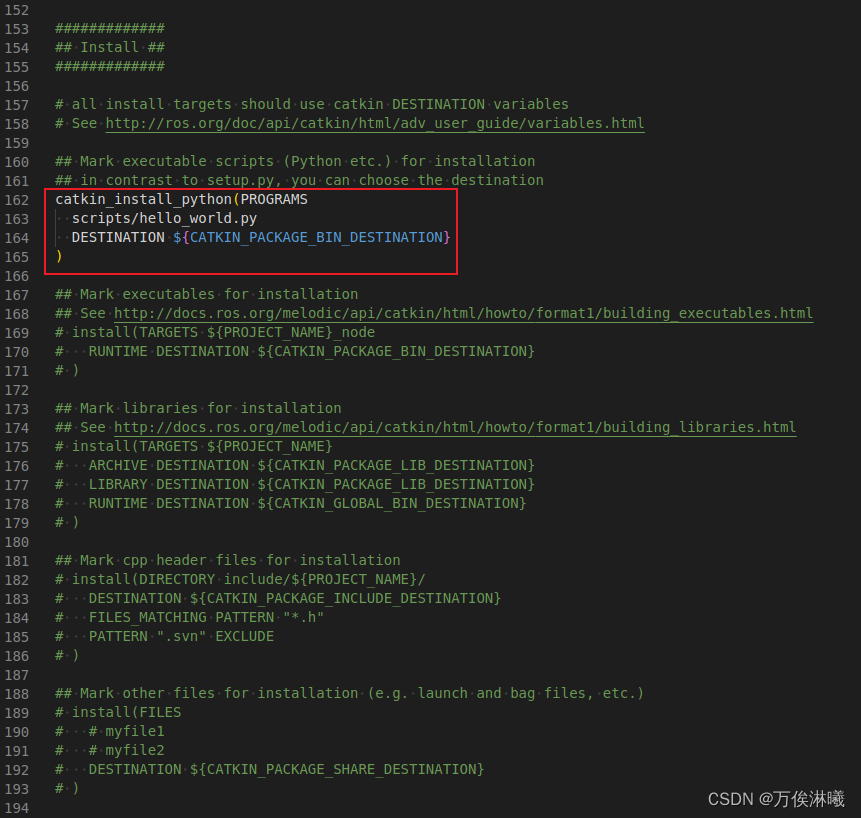
[ROS 系列学习教程] ROS Hello World-CSDN博客

ROS Tutorials Python - Beginner - YouTube

Ros Topic Python – Ros Editor Python – XRNXW

[ROS in 5 mins] 055 - Four different ways of testing your ROS python ...
Ros Python Tutorial | Python Ros Robot – QPZO

[ROS Q&A] 010 - How to import python modules from different ROS ...
Advertisement Space (336x280)

ROSTHAI สร้างหุ่นยนต์ด้วย ROS: สร้าง Packages ของ ROS ด้วยภาษา Python
Learn ROS with Python or with C++? Pros & Cons | The Construct

ROSTHAI สร้างหุ่นยนต์ด้วย ROS: สร้าง Packages ของ ROS ด้วยภาษา Python

ROS tutorial #2.2: Python walkthrough of publisher/subscriber lab - YouTube

Python ROS2: Mastering Callbacks Tutorial | ROS Developers Open Class ...
[ROS Tutorial] 3. ROS Indigo 개발 환경 구축 (세미나 영상) - YouTube
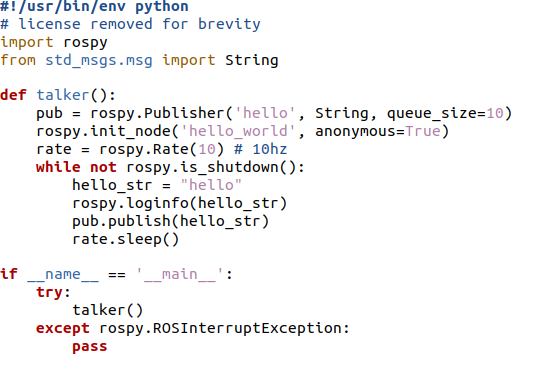
Tutorial: Build and run a new ROS package - PAL SDK 23.1 documentation
ROS Tutorial for Beginners (python) | The Construct

【ROS教程】 Python 版:ROS运行 Hello Word_python ros-CSDN博客
ROS for Beginners: How to Learn ROS - The Construct
Advertisement Space (336x280)

Learn Robot Operating System - ROS Cheat Sheet

Tutorial: Build and run a new ROS package - PAL SDK 23.1 documentation
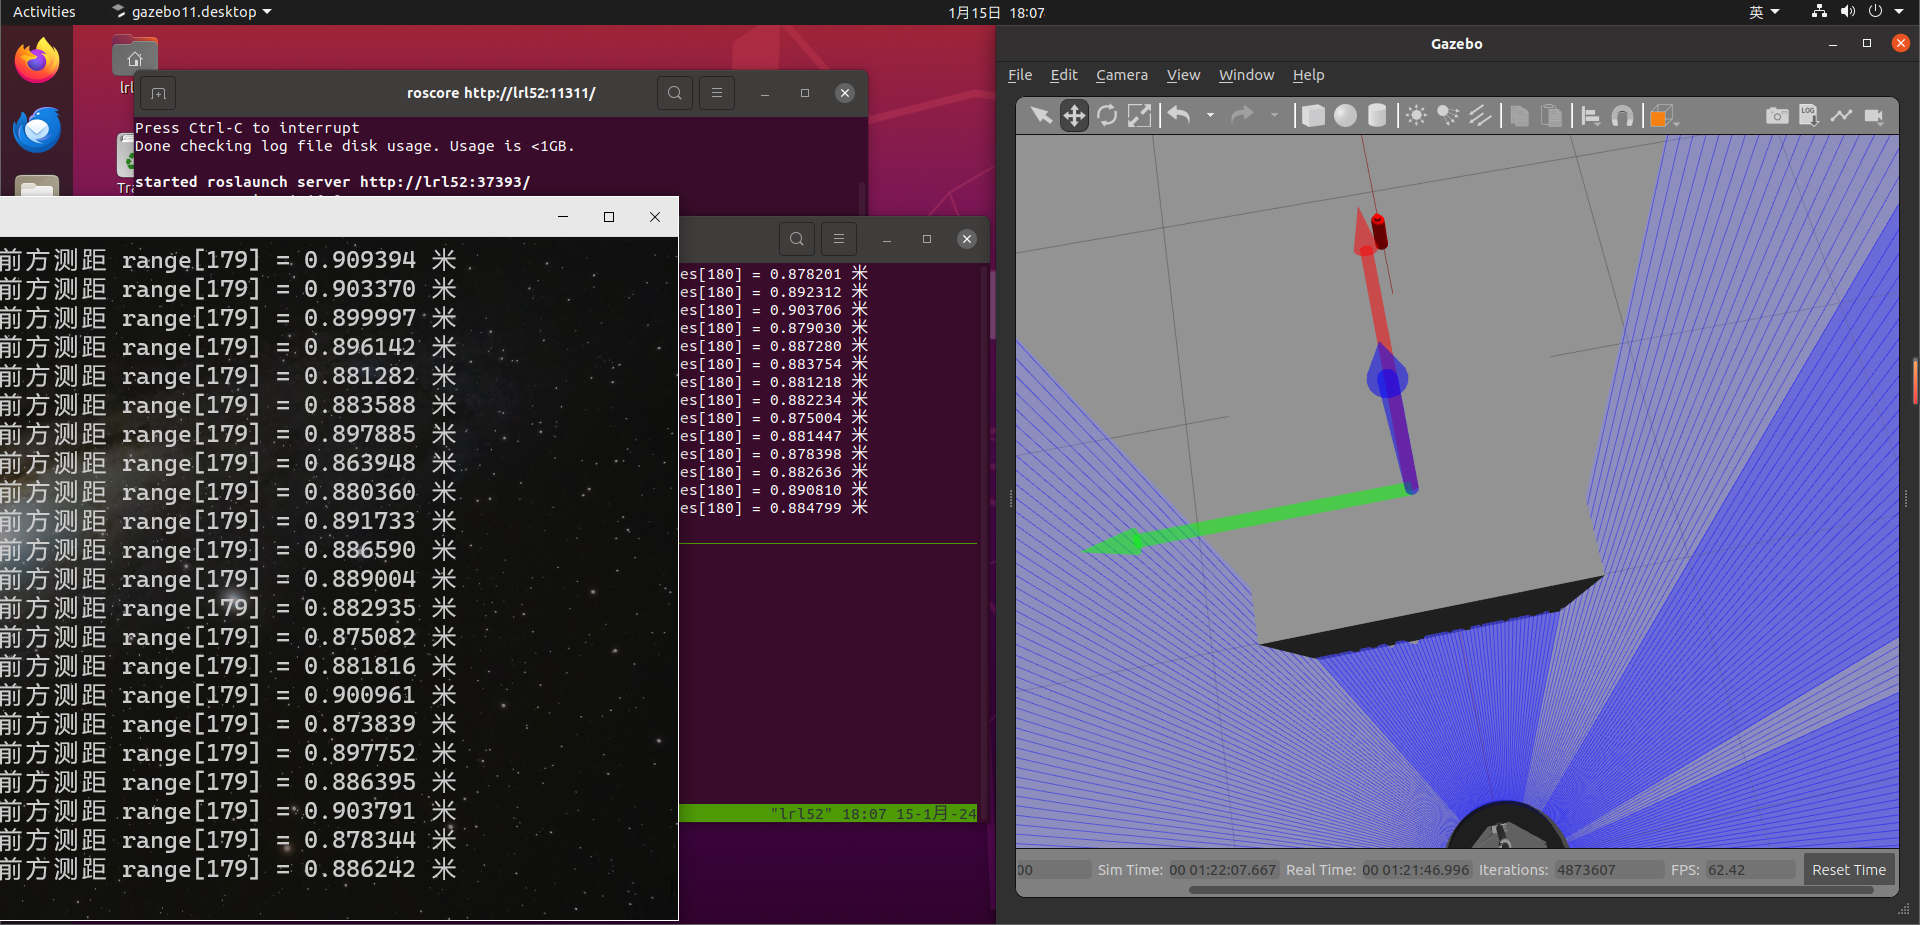
ROS 入门教程(含开发调试配置) – LRL52 的博客

10. ROS (1).pptx
ROS indigo, OSX 10.10.5 - 理科系の勉強日記

Deploying ROS 2 packages on your robot - PAL OS 25.01 documentation