
Ros2control Rolling Hardwareinterfaceresourcemanager Class Reference
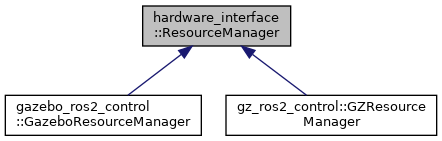
ros2_control - rolling: hardware_interface::ResourceManager Class Reference
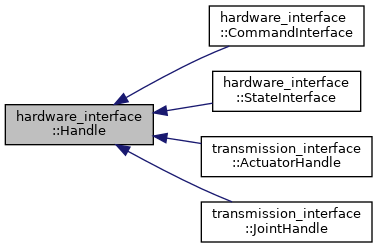
ros2_control - rolling: hardware_interface::Handle Class Reference
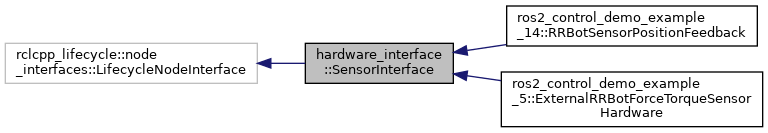
ros2_control - rolling: hardware_interface::SensorInterface Class Reference
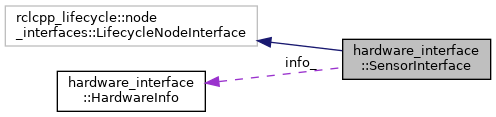
ros2_control - rolling: hardware_interface::SensorInterface Class Reference
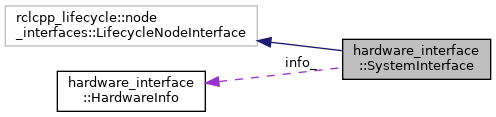
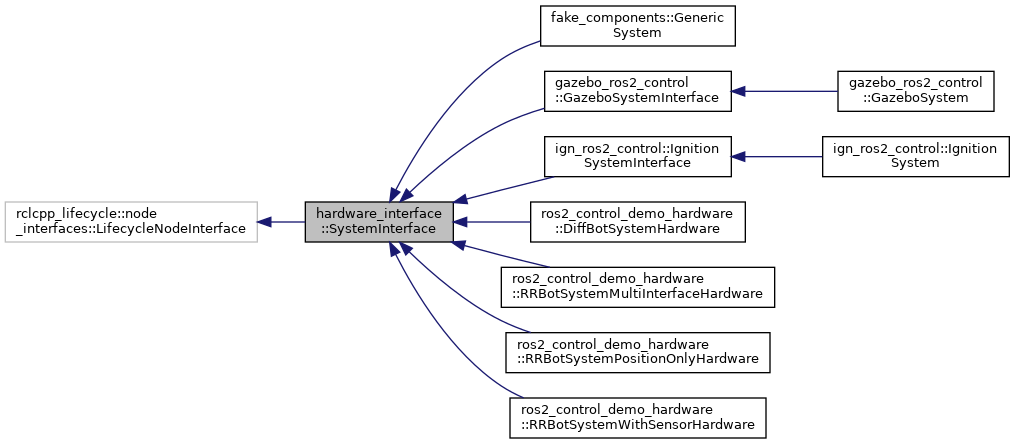
ros2_control - rolling: hardware_interface::SystemInterface Class Reference

ros2_control - rolling: hardware_interface::StateInterface Class Reference
Ros2 Control: Hardware_Interface::Stateinterface Class Reference – GHCLZB
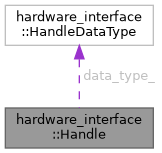
ros2_control - rolling: hardware_interface::Handle Class Reference

ros2_control - rolling: hardware_interface::SensorInterface Class Reference
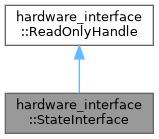
ros2_control - foxy: hardware_interface::StateInterface Class Reference
Advertisement Space (300x250)
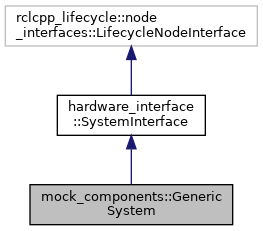
ros2_control - rolling: mock_components::GenericSystem Class Reference
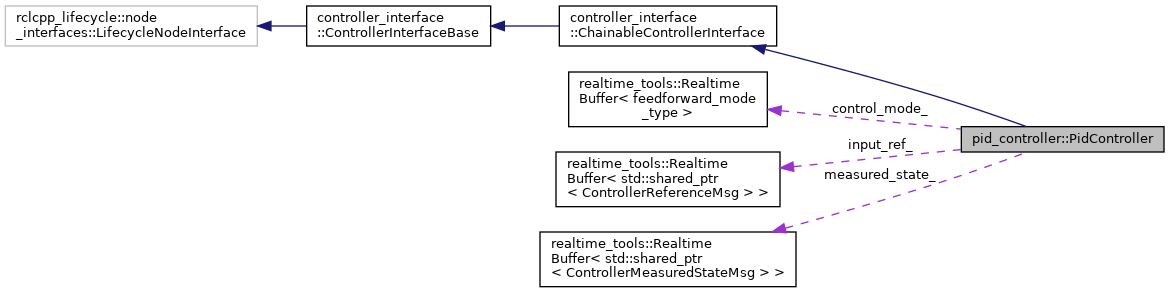
ros2_control - rolling: pid_controller::PidController Class Reference
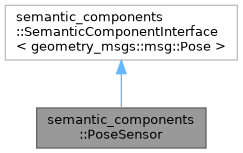
ros2_control - rolling: semantic_components::PoseSensor Class Reference
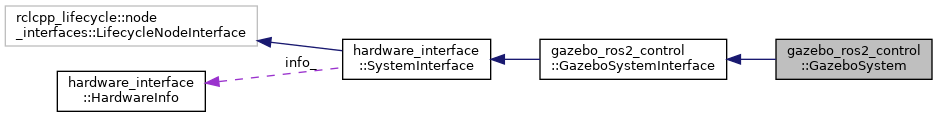
ros2_control - rolling: gazebo_ros2_control::GazeboSystem Class Reference
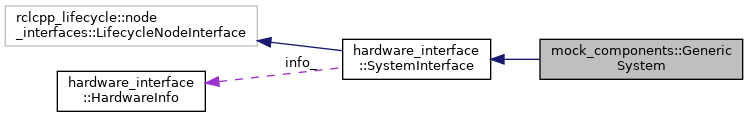
ros2_control - rolling: mock_components::GenericSystem Class Reference
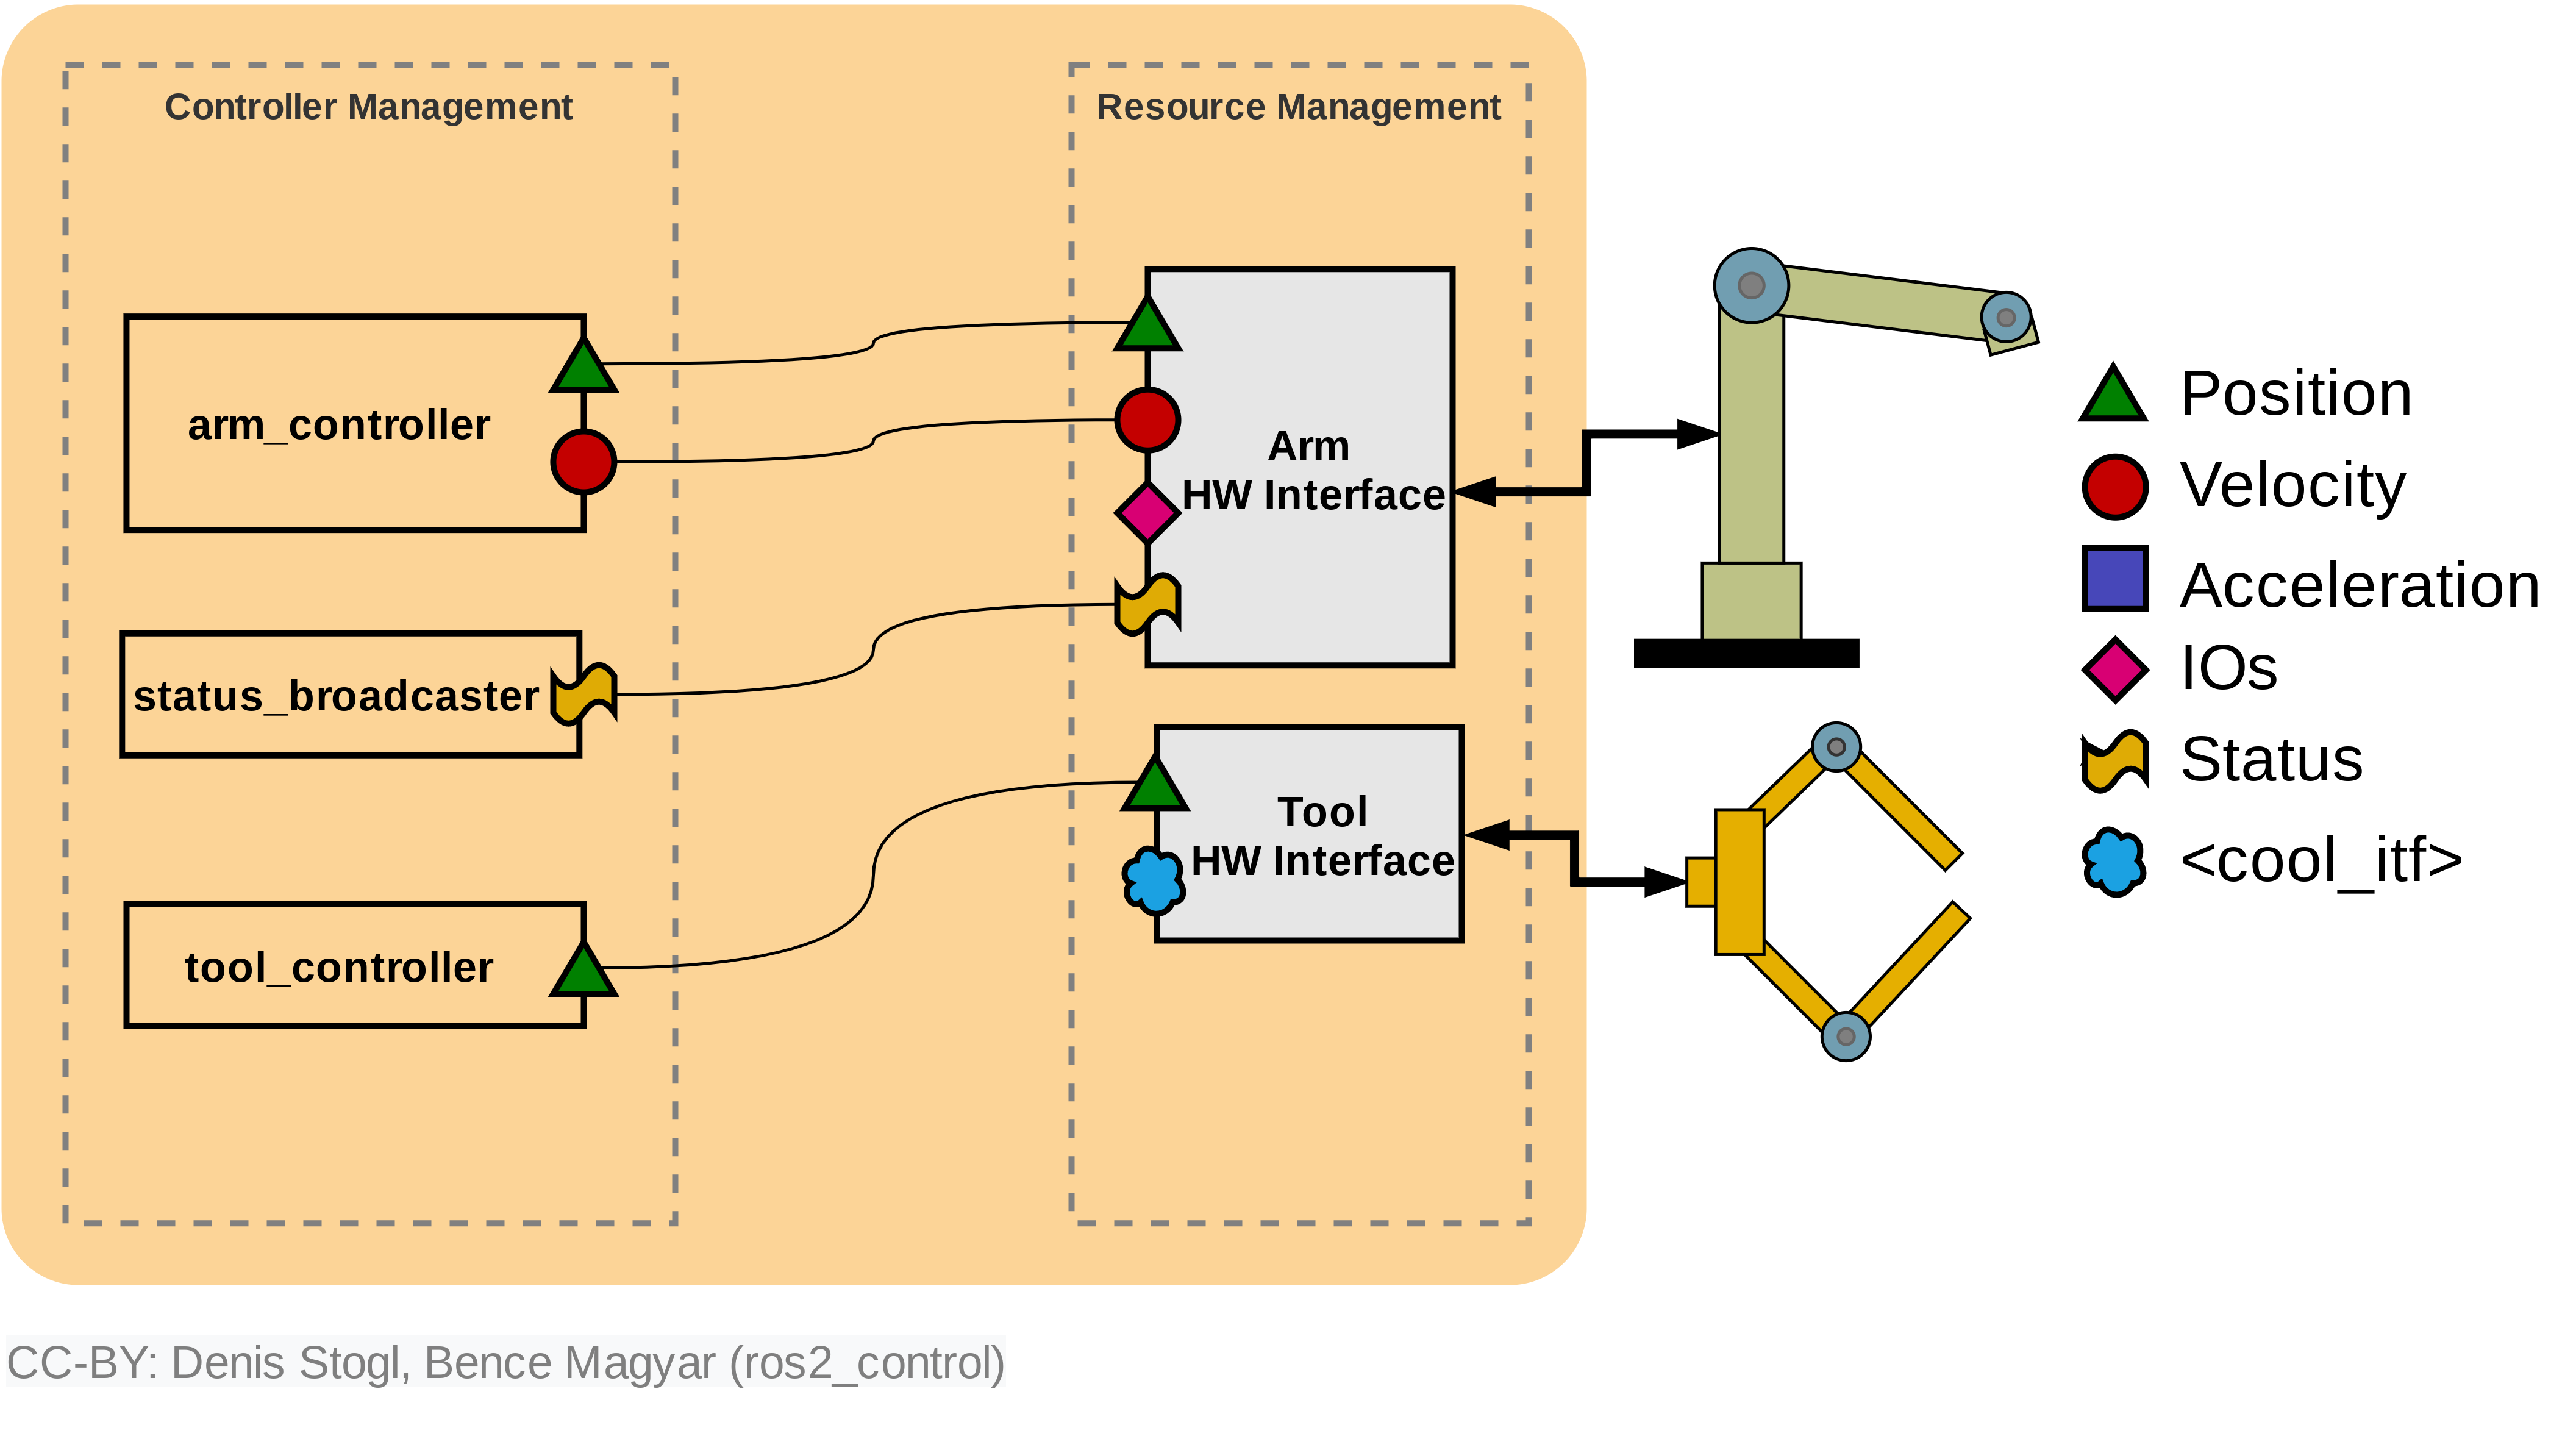
Resources — ROS2_Control: Rolling Apr 2026 documentation
Resources — ROS2_Control: Rolling Apr 2026 documentation

ros2_control - rolling: hardware_interface::CommandInterface Class ...
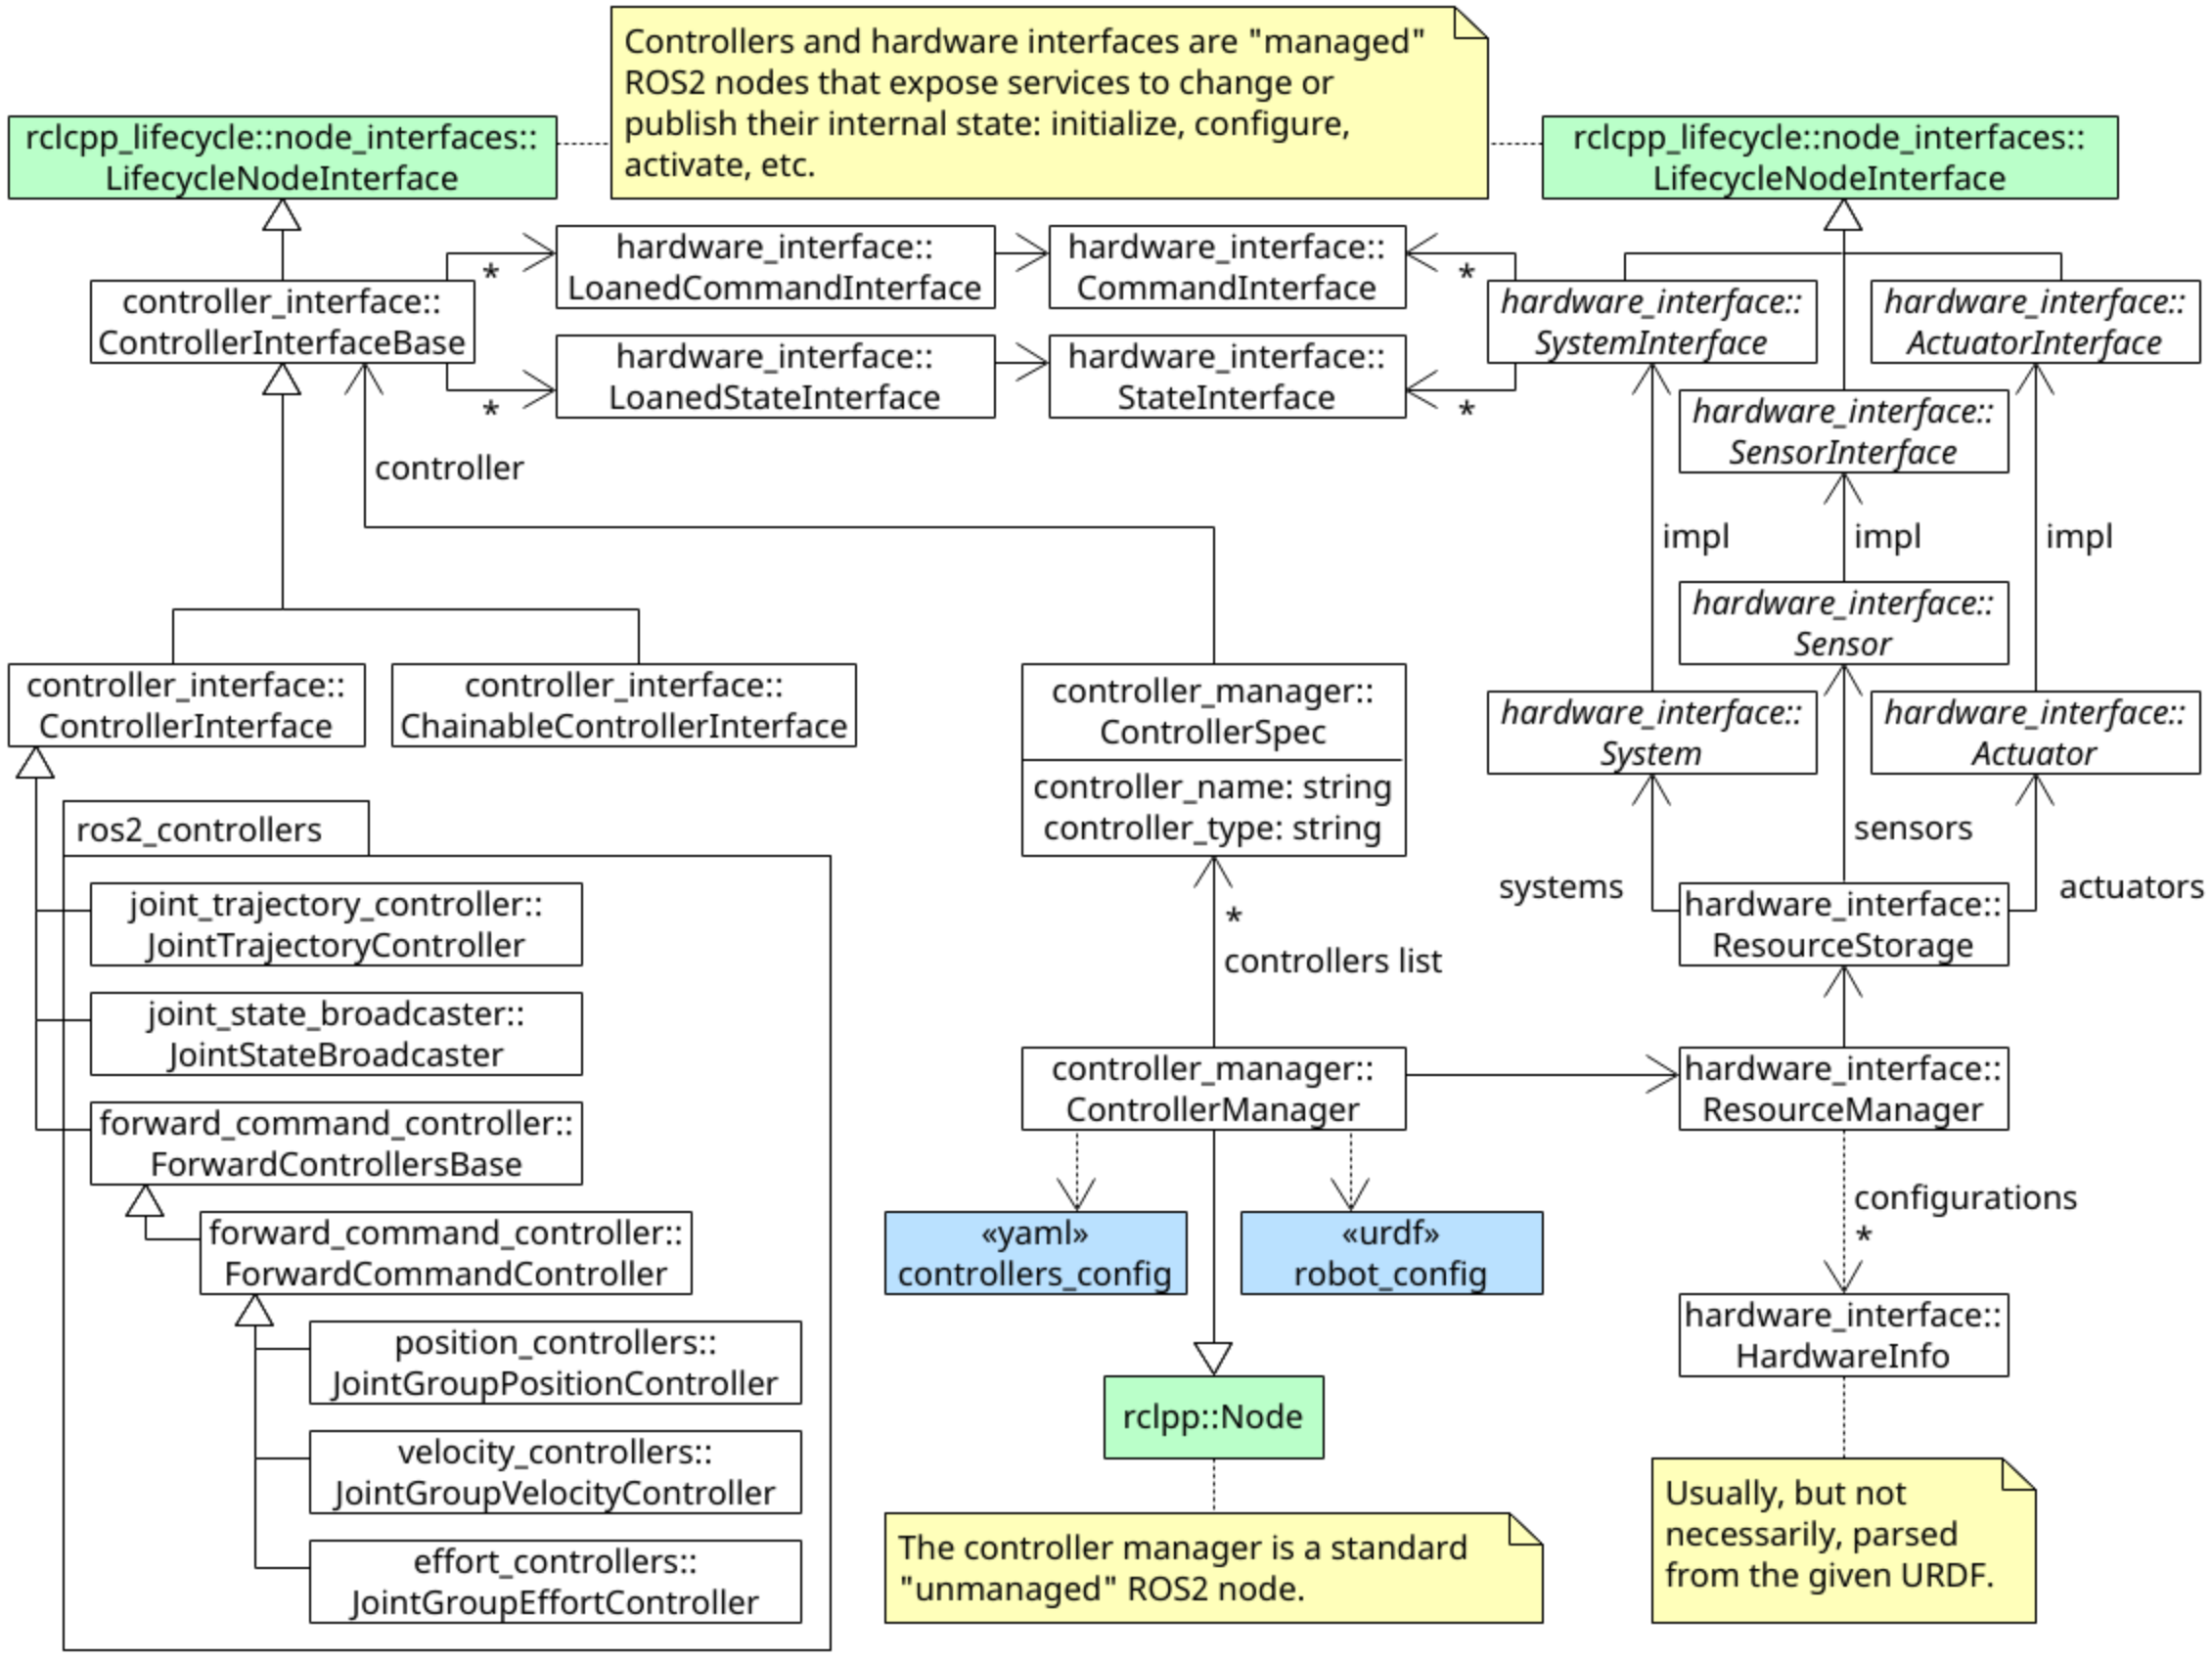
Getting Started — ROS2_Control: Rolling Oct 2025 documentation
Resources — ROS2_Control: Rolling Apr 2026 documentation
Advertisement Space (336x280)
Resources — ROS2_Control: Rolling Apr 2026 documentation
Resources — ROS2_Control: Rolling Apr 2026 documentation
Resources — ROS2_Control: Rolling Apr 2026 documentation
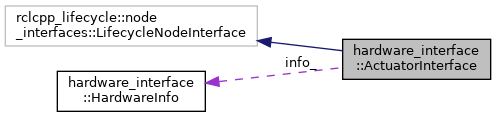
ros2_control - rolling: hardware_interface::ActuatorInterface Class ...
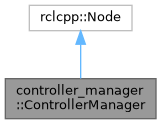
ros2_control - rolling: controller_manager::ControllerManager Class ...
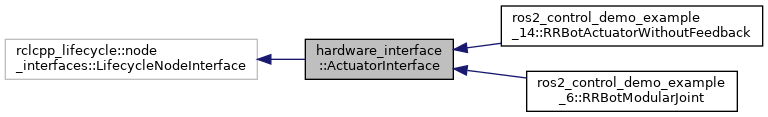
ros2_control - rolling: hardware_interface::ActuatorInterface Class ...
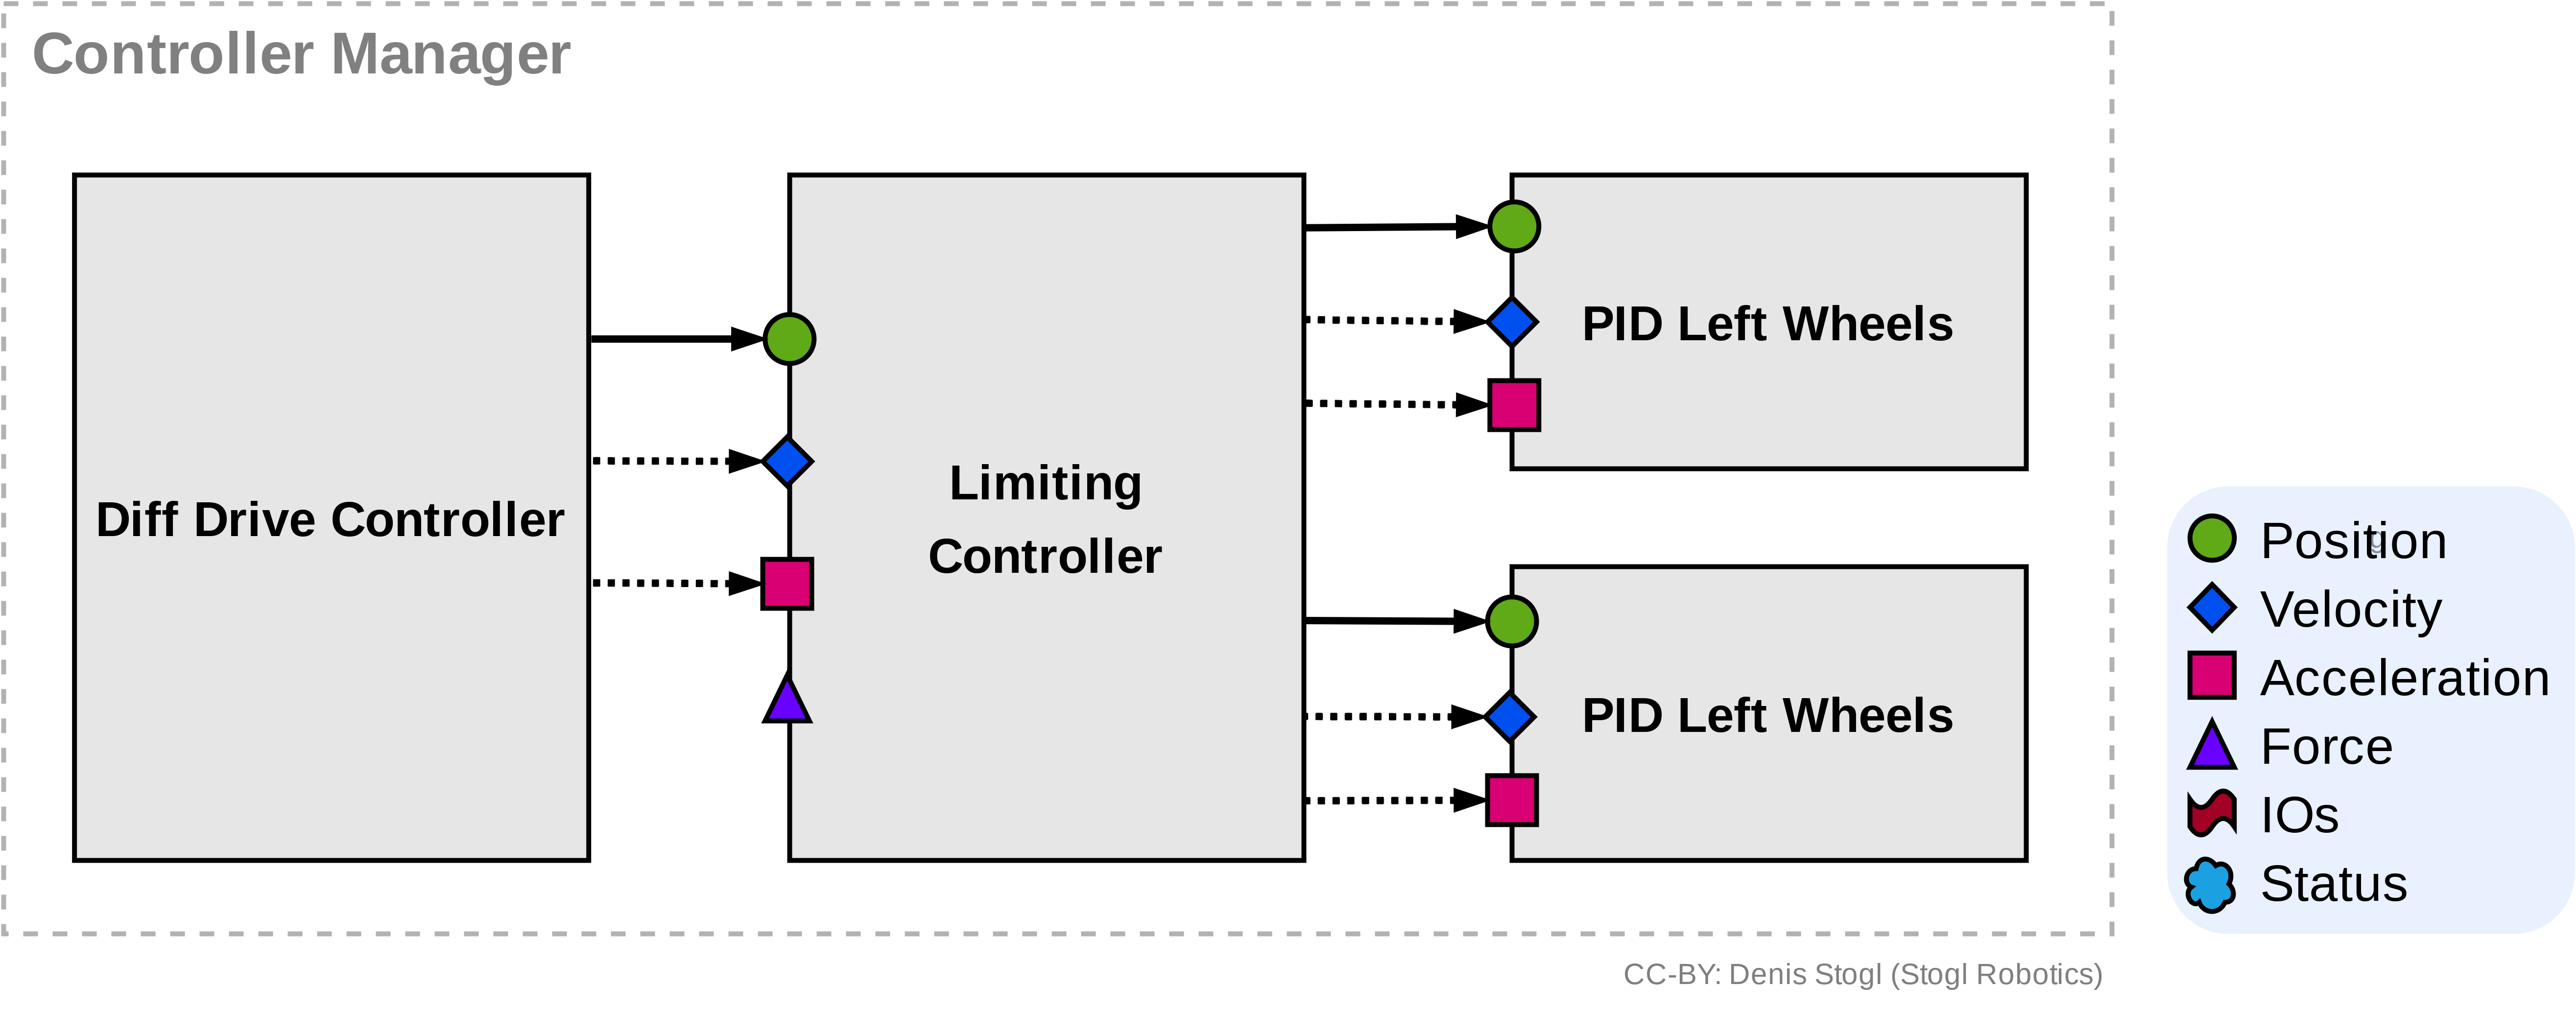
Resources — ROS2_Control: Rolling Apr 2026 documentation
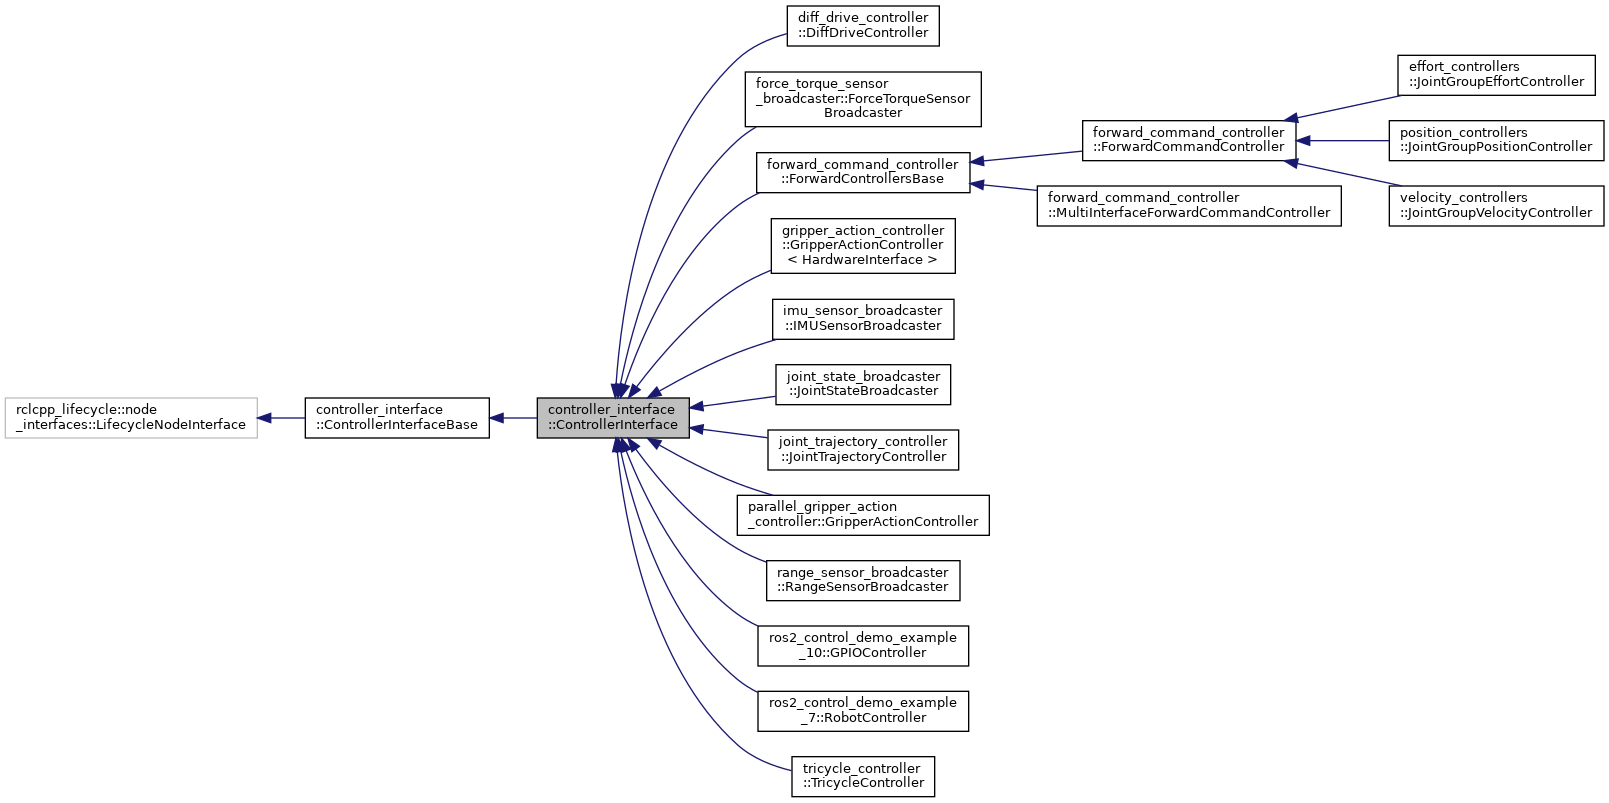
ros2_control - rolling: controller_interface::ControllerInterface Class ...
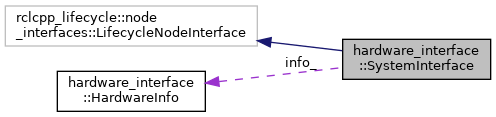
ros2_control - galactic: hardware_interface::SystemInterface Class ...
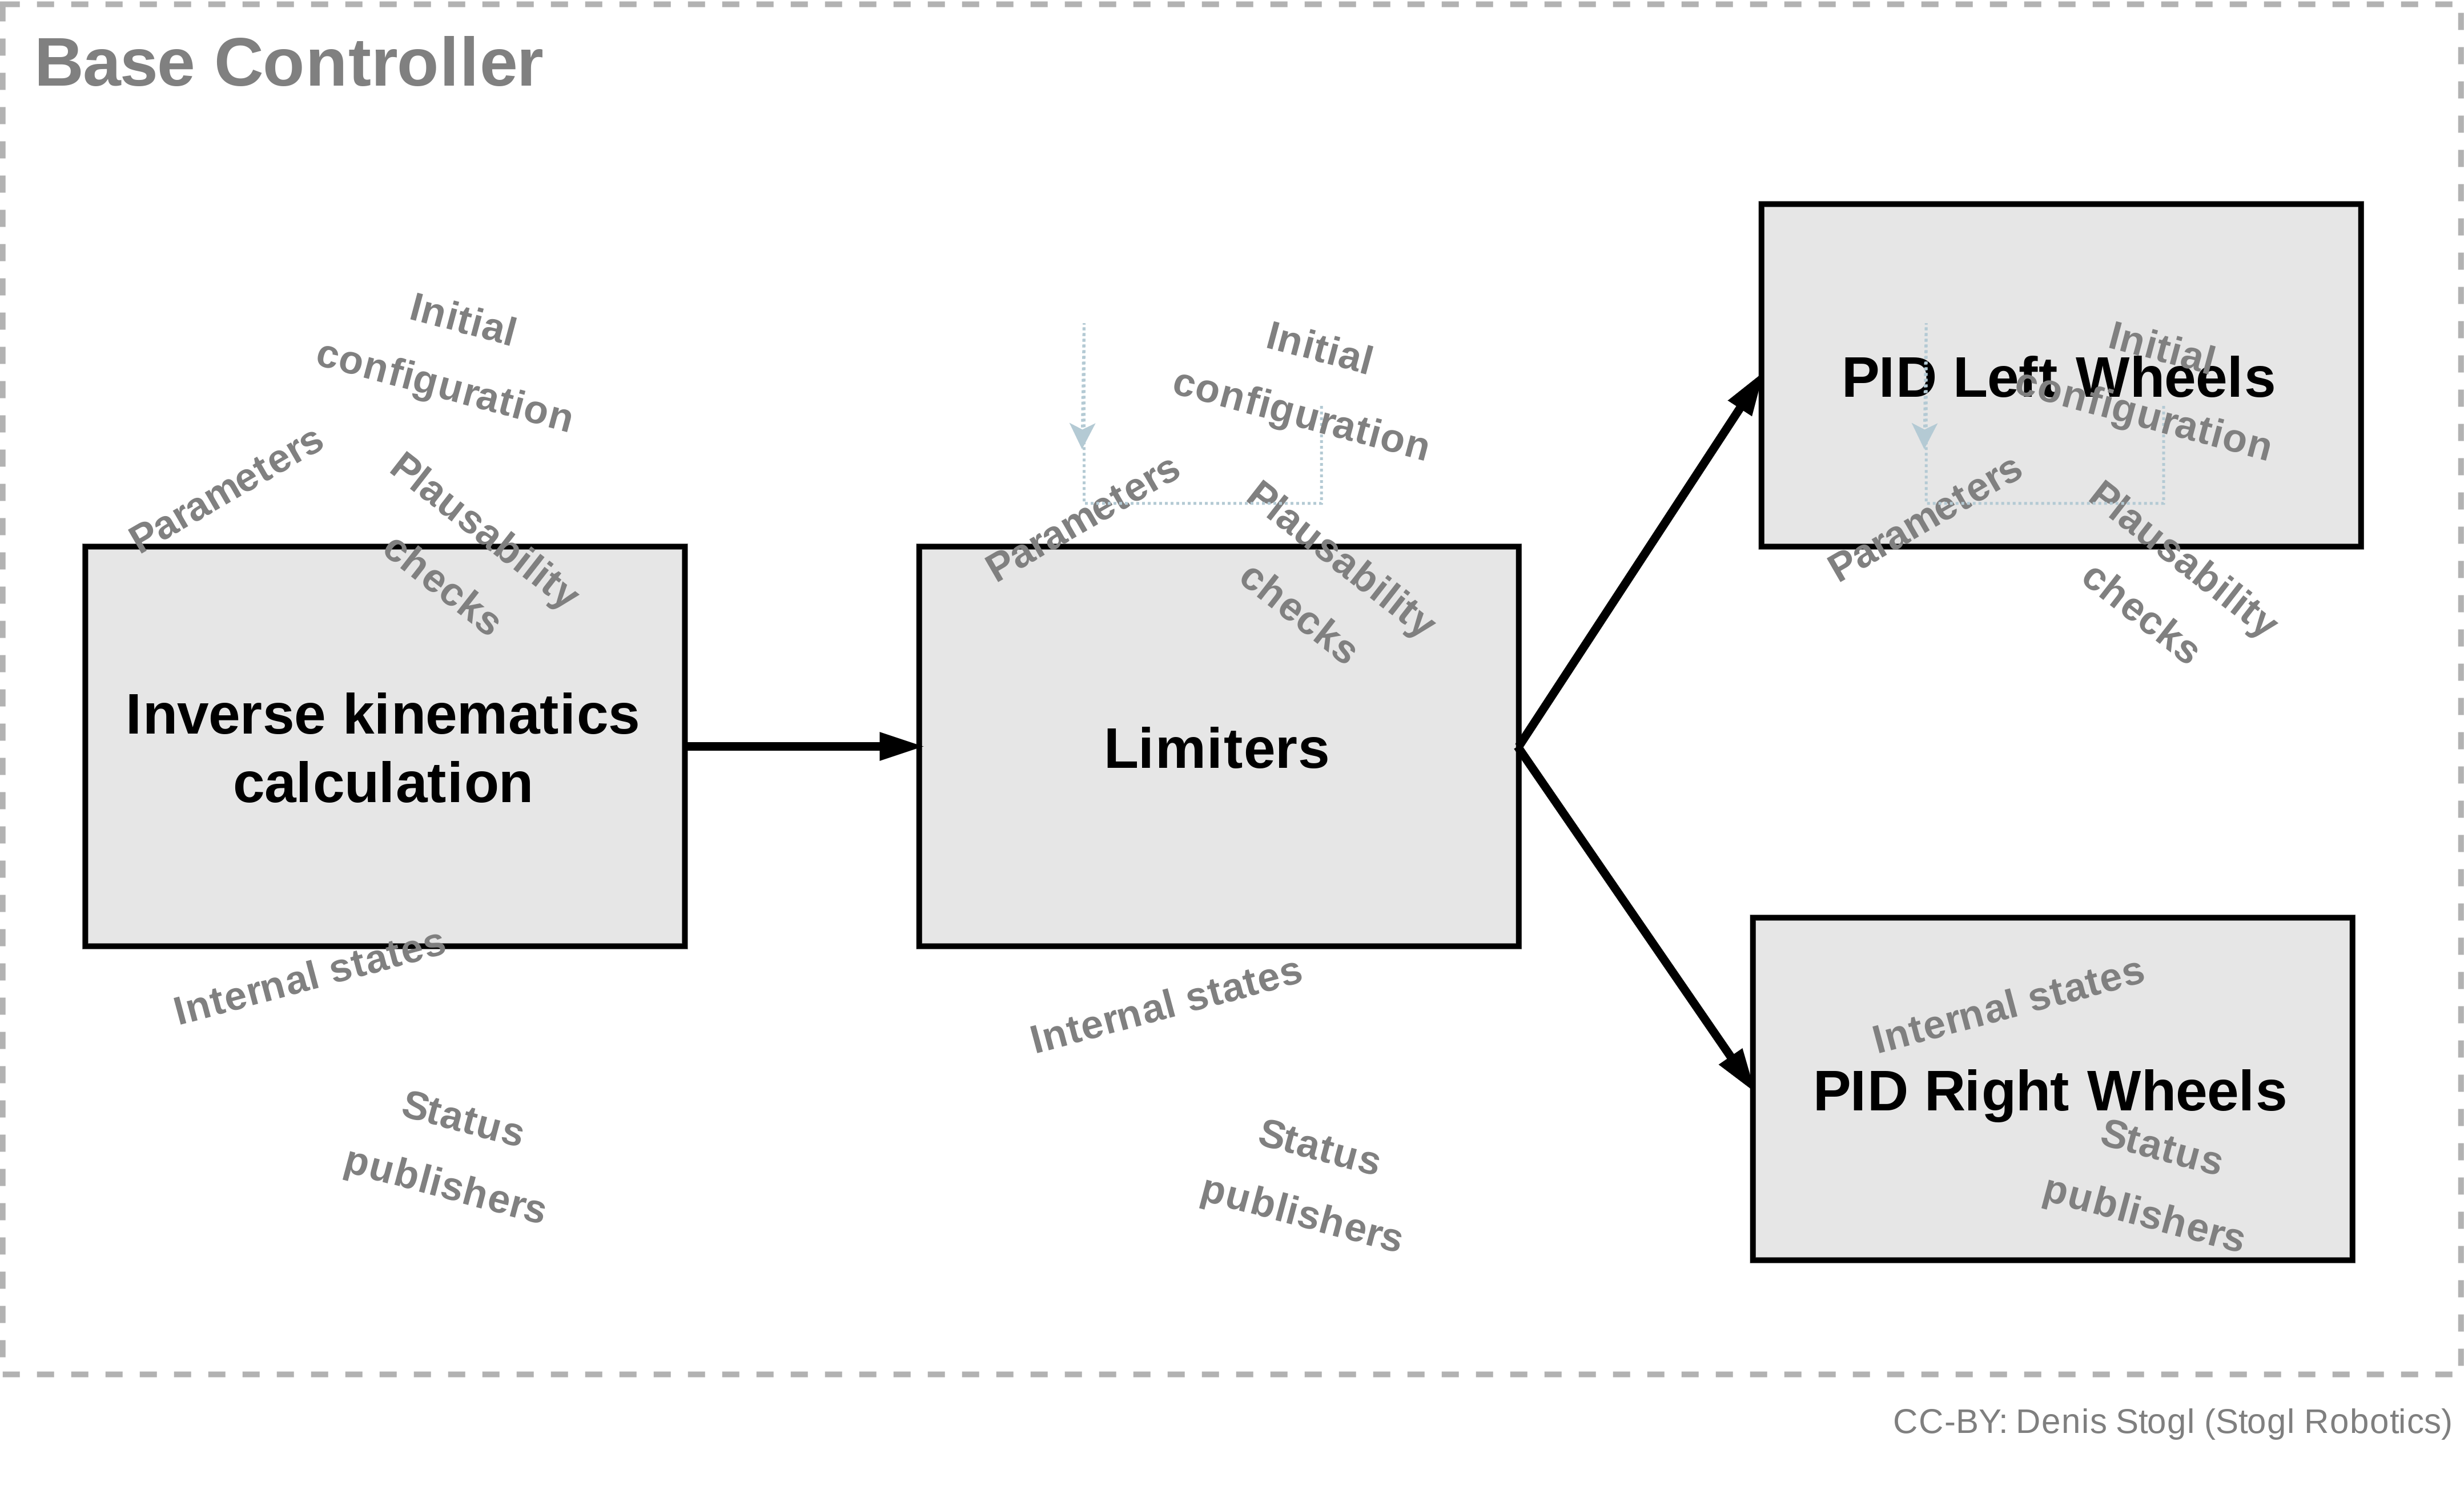
Resources — ROS2_Control: Rolling Apr 2026 documentation
Advertisement Space (336x280)

ros2_control - rolling: hardware_interface::ActuatorInterface Class ...
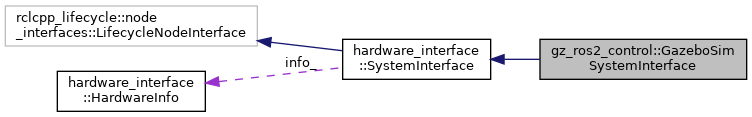
ros2_control - rolling: gz_ros2_control::GazeboSimSystemInterface Class ...
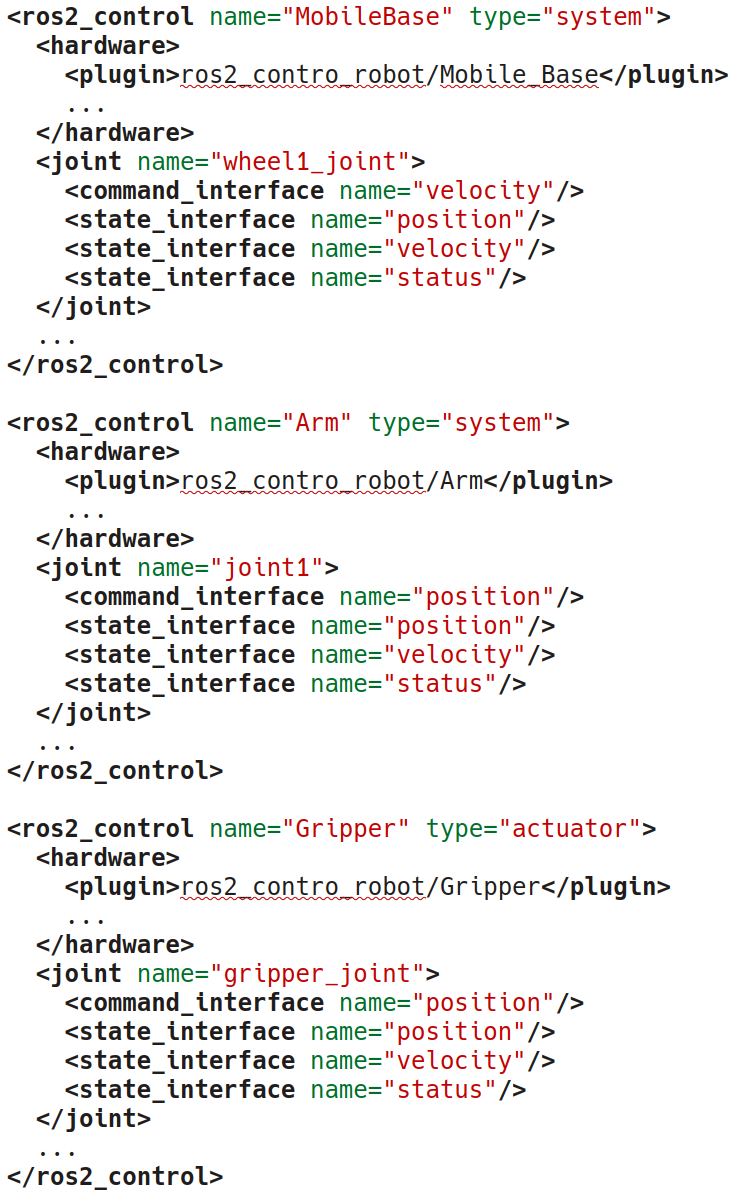
Resources — ROS2_Control: Rolling Apr 2026 documentation
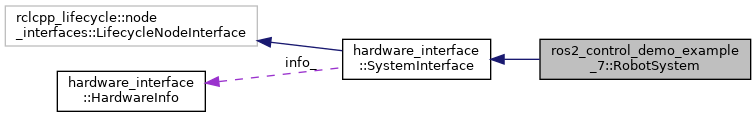
ros2_control - rolling: ros2_control_demo_example_7::RobotSystem Class ...
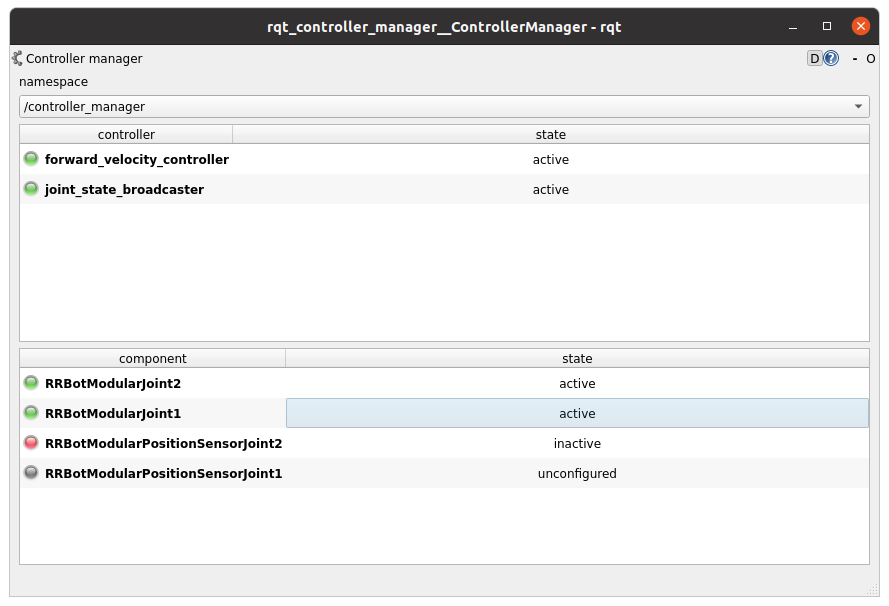
Controller Manager — ROS2_Control: Rolling Jul 2026 documentation
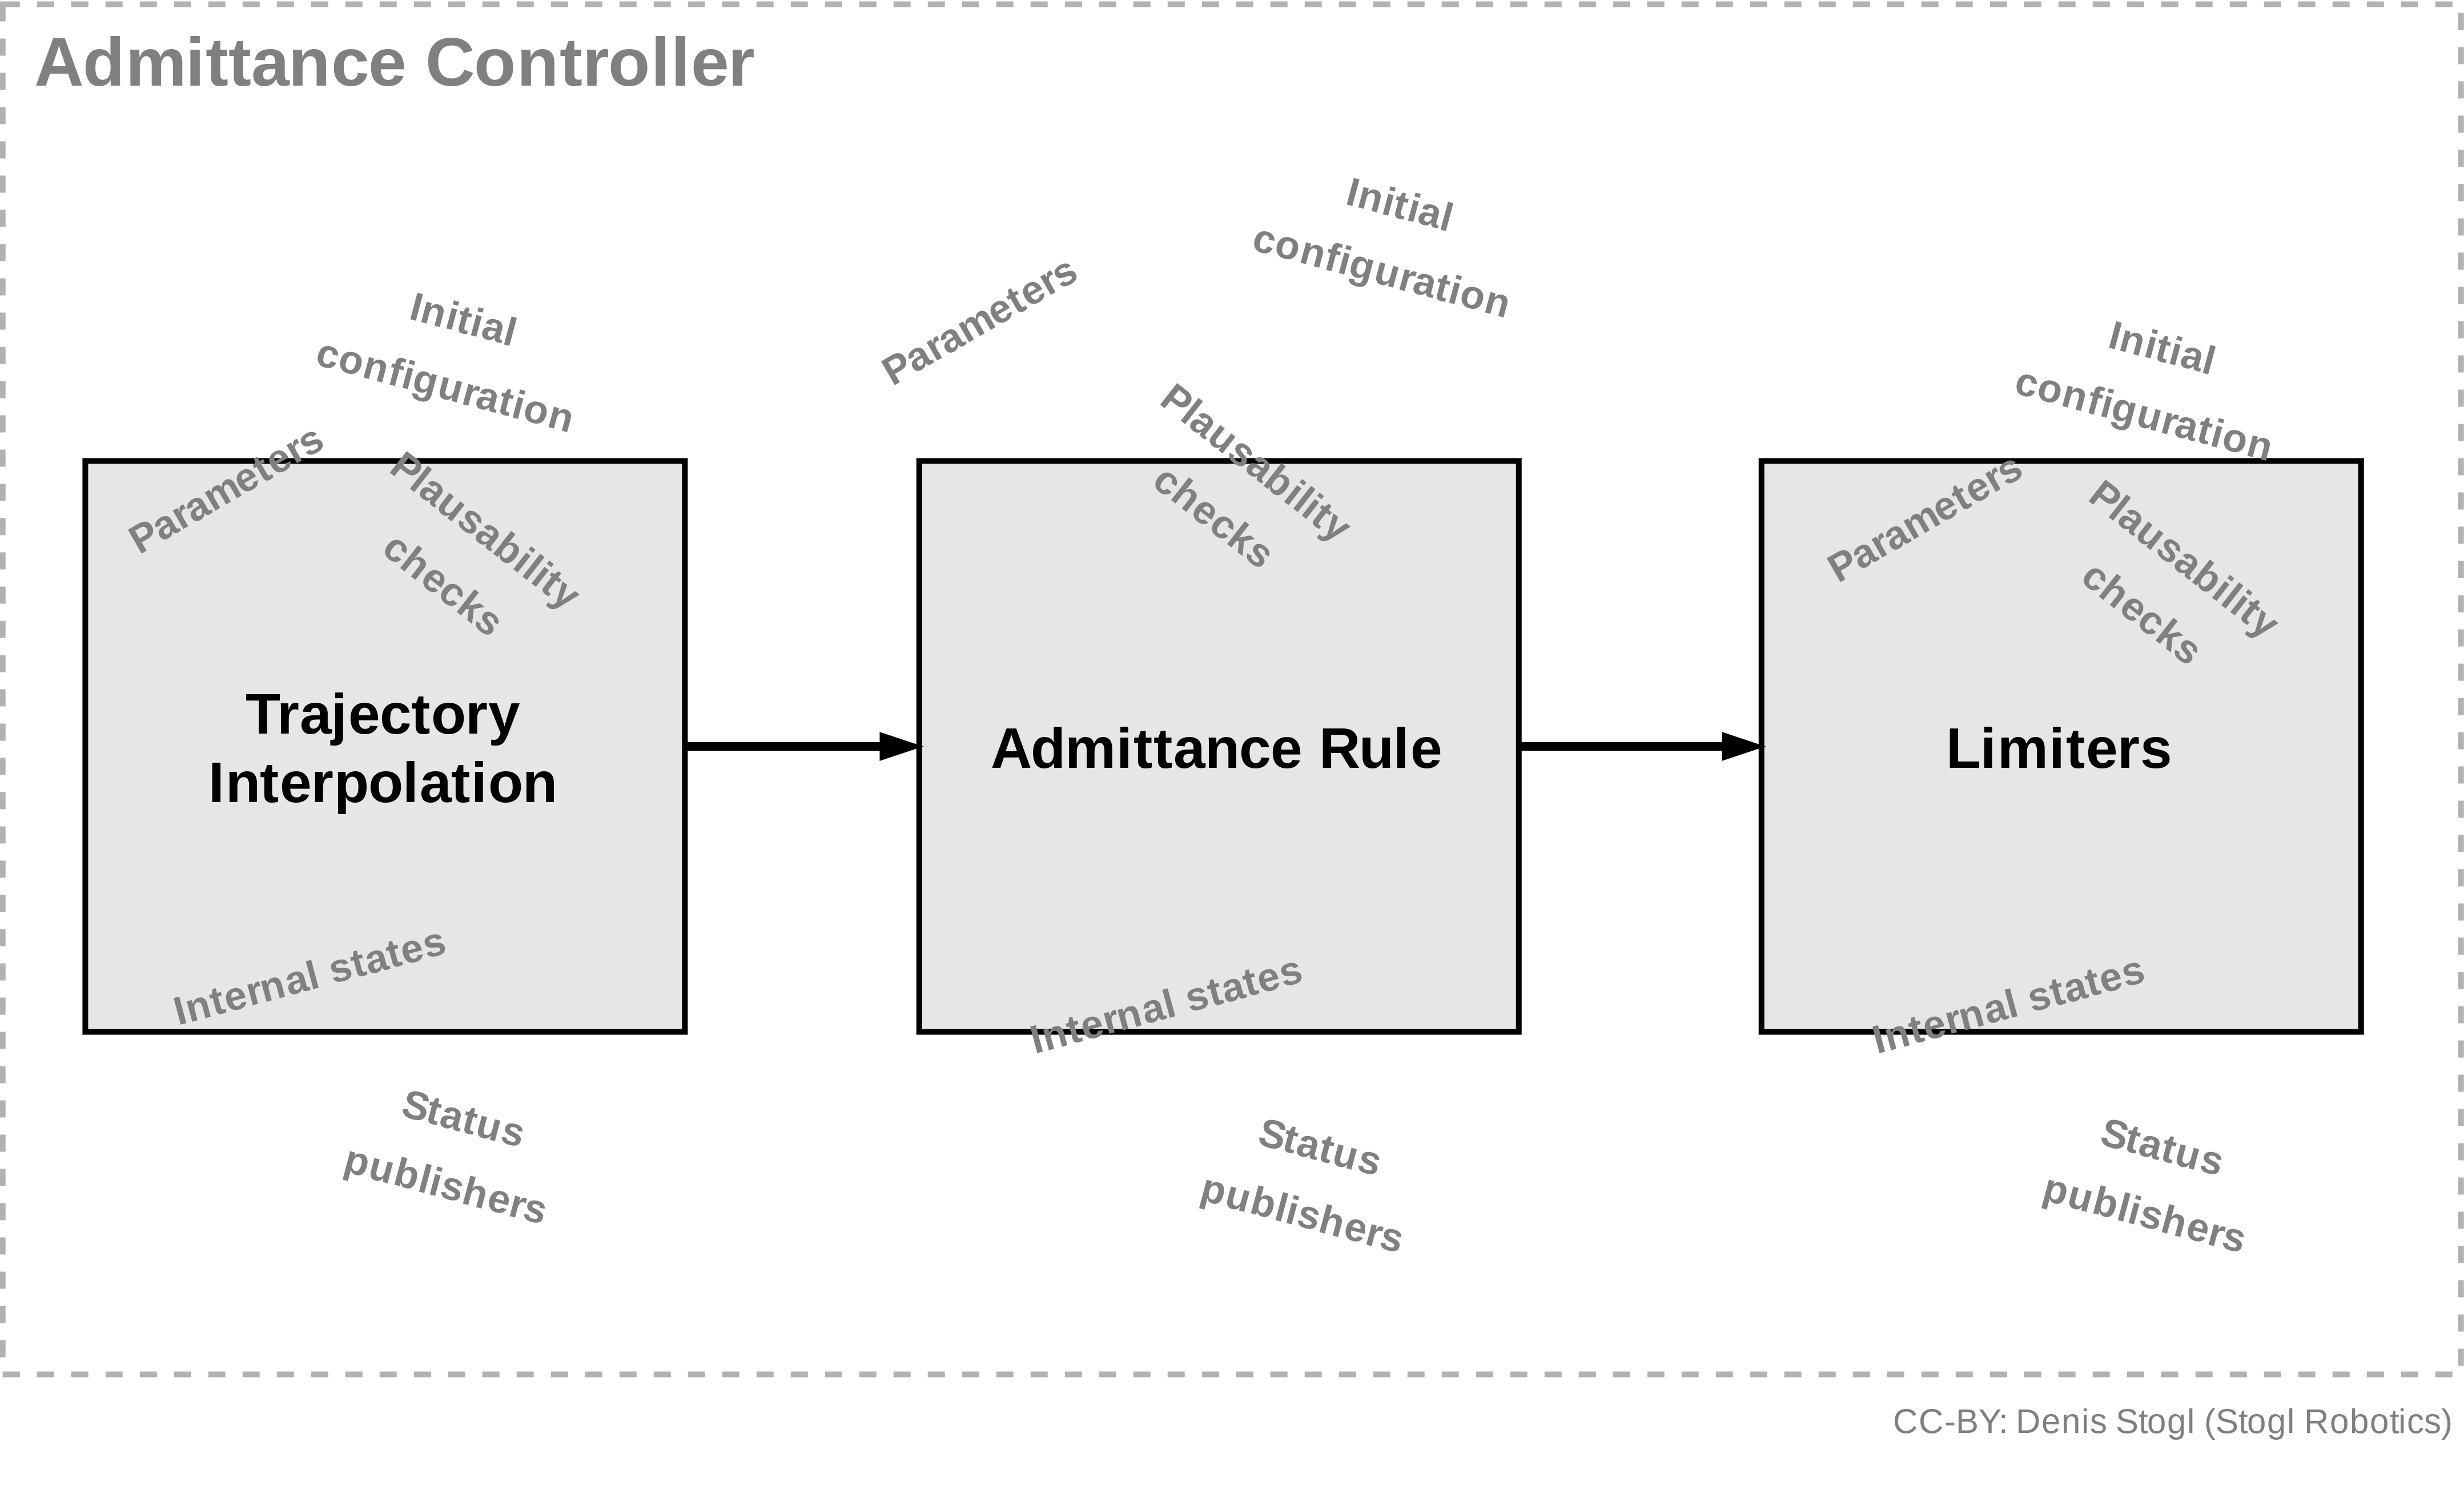
Resources — ROS2_Control: Rolling Apr 2026 documentation